2 layers
Robot MGR
rayvburn/diff_drive_mapping_robot
ROS driver for the Raspberry Pi based differential drive robot
95 parts27

 jalmx/base_esp322
Base for esp32 to connect IO
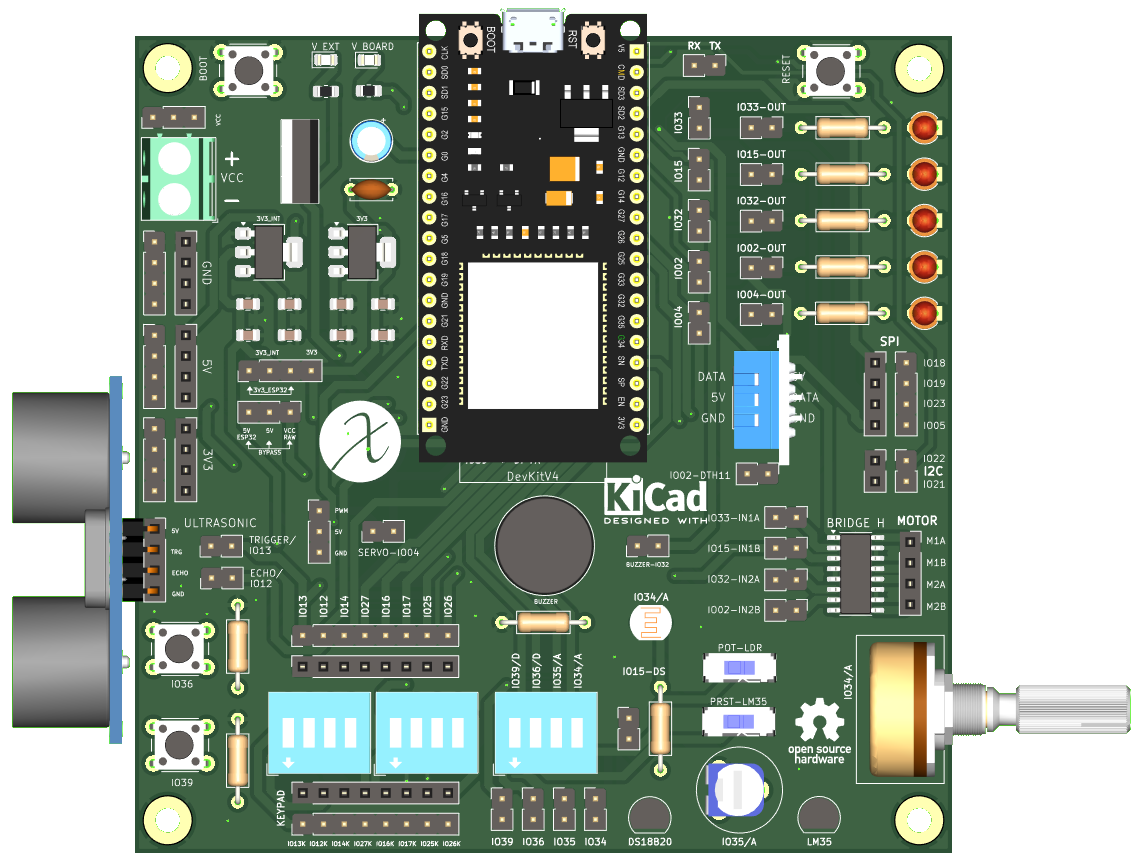
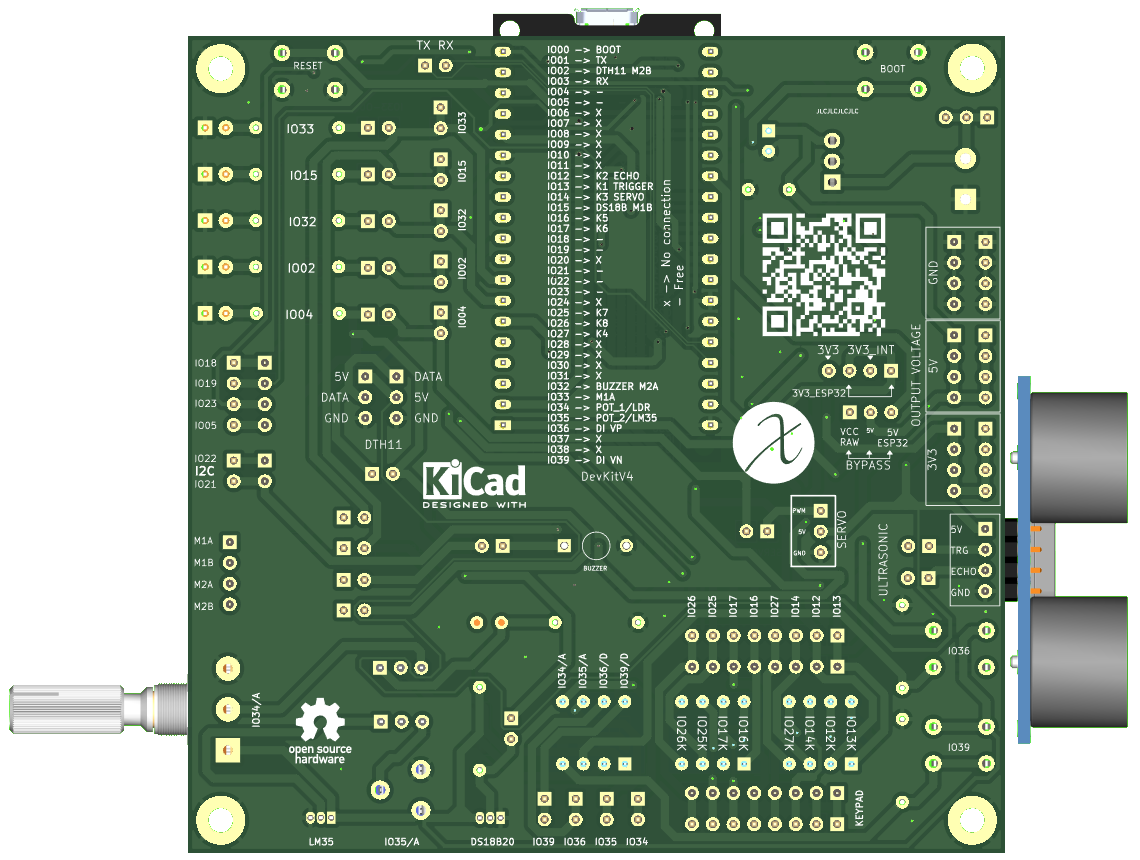
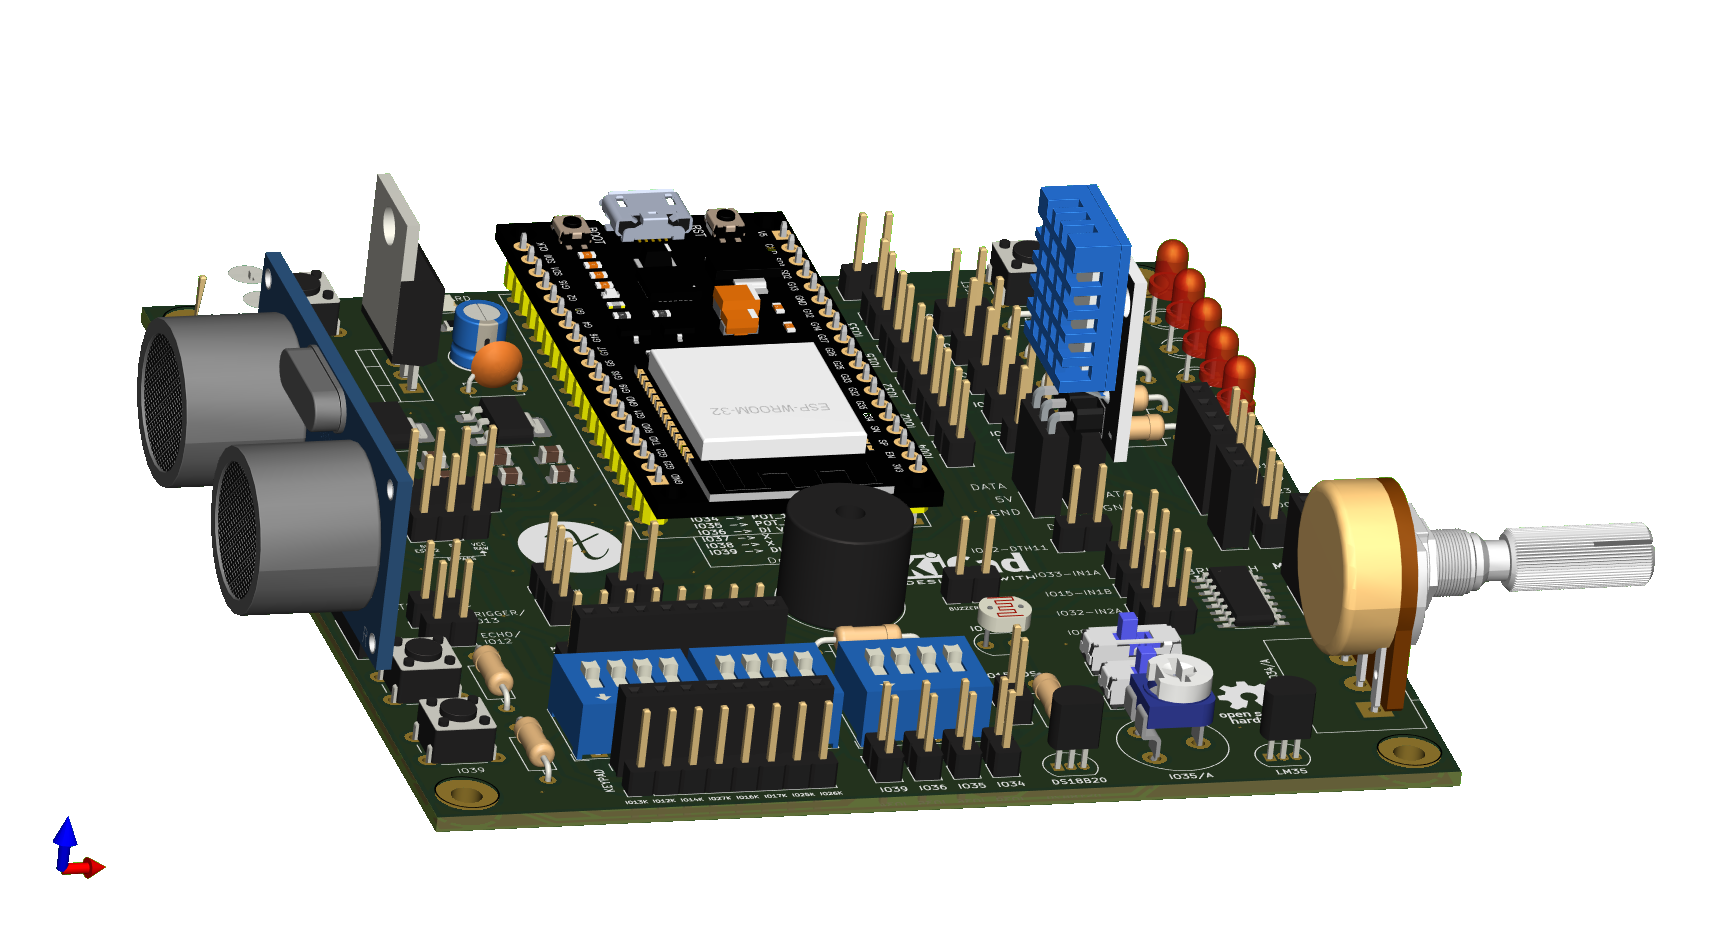
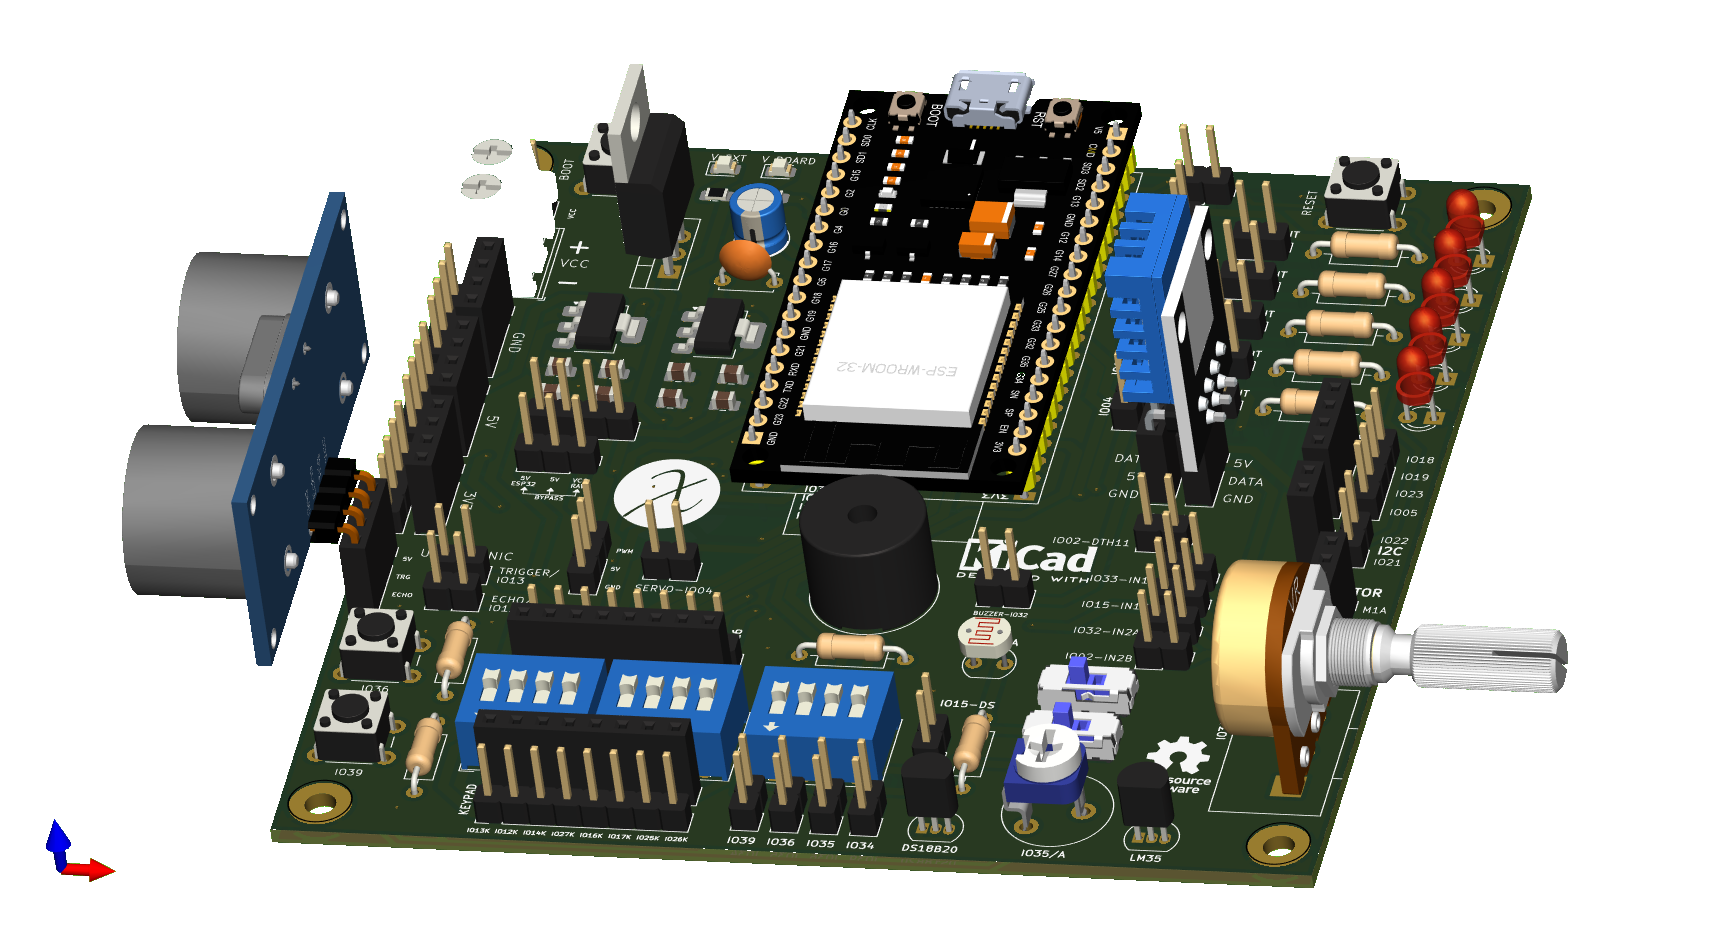
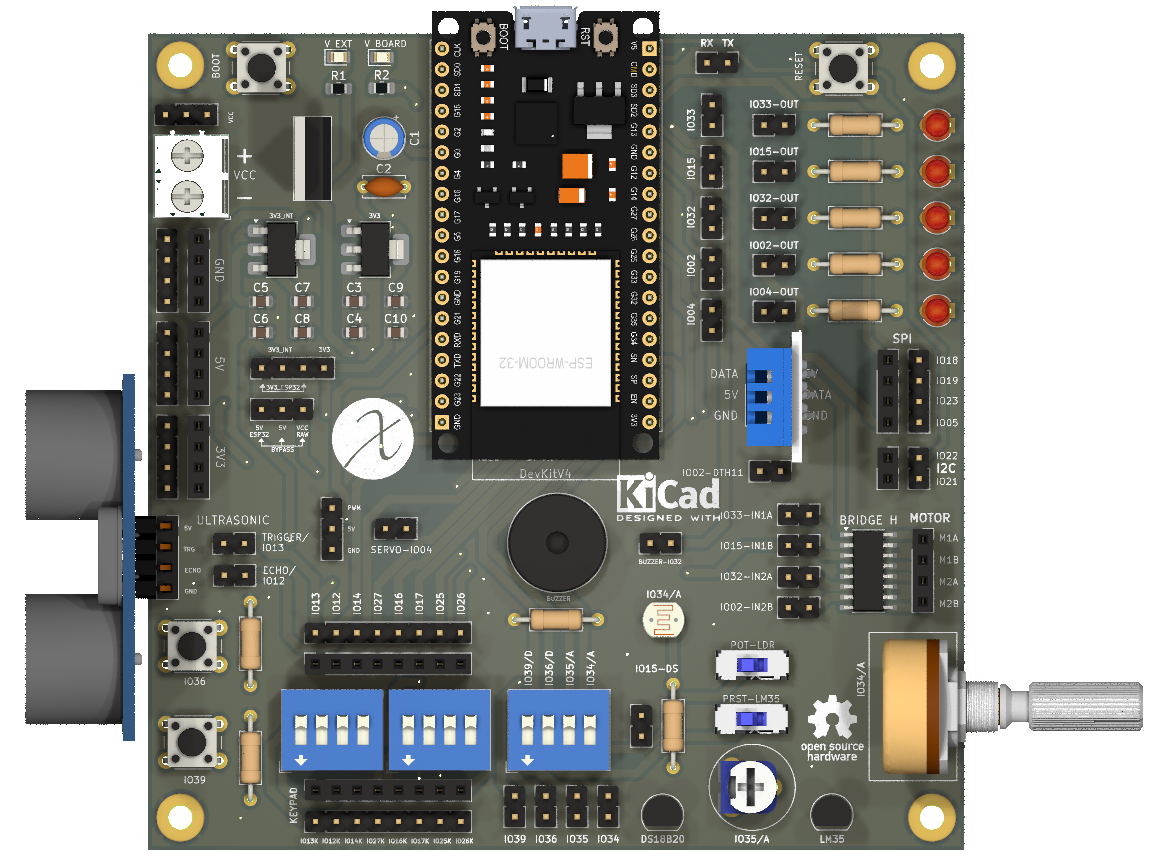
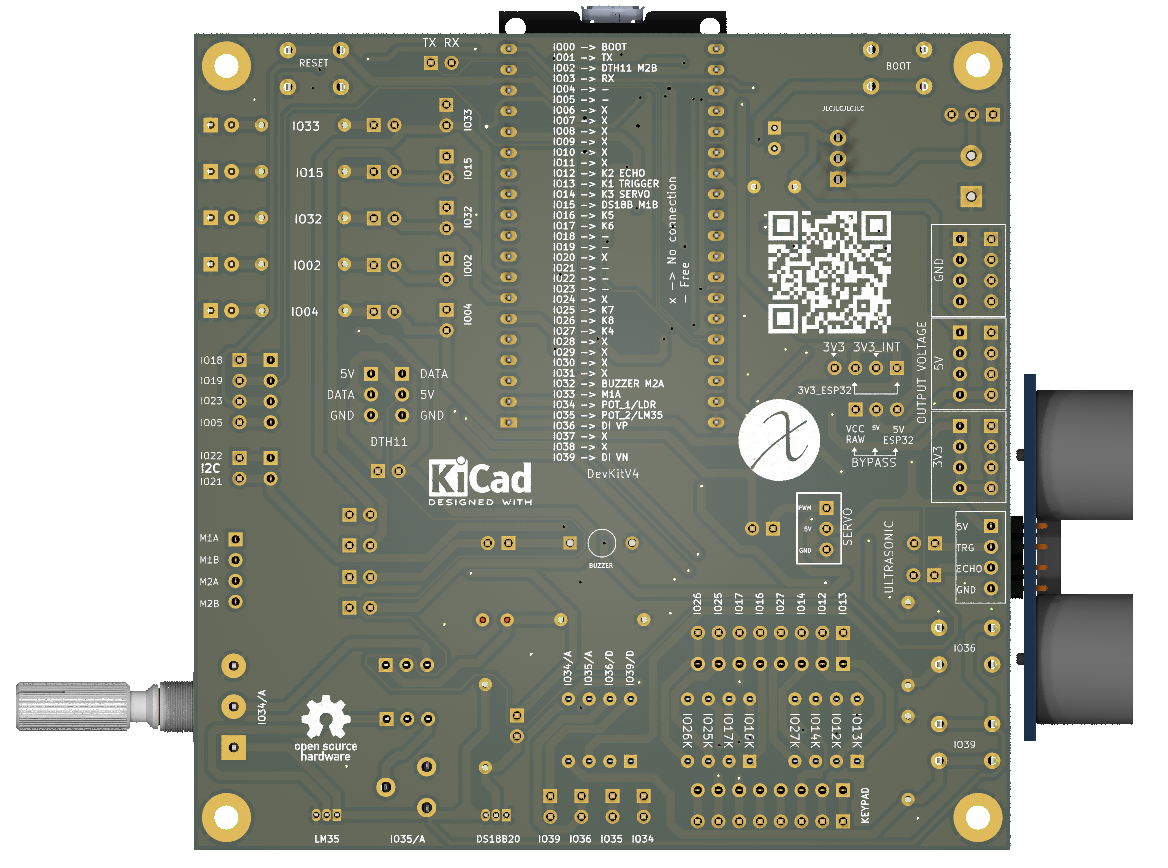
Base esp32 is an open-source printed circuit board by jalmx, from the jalmx/base_esp32 repository on GitHub, published under the MIT licence. It is a 2-layer board of 100 × 100 mm with 107 parts on 82 nets, routed with 984 tracks and 86 vias.
It is built around the ESP32-DEVKITC-VE, DS18B20 and HDS18B20, with the AMS1117 and MX1508 among its other parts. Its parts include 45 connectors, 12 resistors, 10 capacitors, 9 switches and 7 ICs. It belongs with the ESP32 boards of this library.


This board is a base to connect different components to test. Make easy life

| Qty | Value | Footprint | References |
|---|---|---|---|
| 6 | 100nF | Capacitor_SMD:C_0805_2012Metric | C3, C4, C6, C7, C8, C10 |
| 5 | 470 | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R6, R7, R9, R11, R12 |
| 5 | LED | LED_THT:LED_D3.0mm | D3, D4, D5, D6, D7 |
| 4 | MountingHole_Pad | MountingHole:MountingHole_3mm_Pad_TopBottom | H1, H2, H3, H4 |
| 2 | 1k | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R3, R4 |
| 2 | 1k | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R1, R2 |
| 2 | AMS1117 | Package_TO_SOT_SMD:SOT-223-3_TabPin2 | U2, U4 |
| 2 | LOGO | my_symbols:logo_x | G***, G*** |
| 1 | 0.1uF | Capacitor_THT:C_Disc_D5.0mm_W2.5mm_P5.00mm | C2 |
| 1 | 10k | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R10 |
| 1 | 10nF | Capacitor_SMD:C_0805_2012Metric | C5 |
| 1 | 10uF | Capacitor_SMD:C_0805_2012Metric | C9 |
| 1 | 1uF | Capacitor_THT:CP_Radial_D5.0mm_P2.50mm | C1 |
| 1 | 4k7 | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R5 |
| 1 | BOOT | Button_Switch_THT:SW_PUSH_6mm | SW4 |
| 1 | BYPASS SRC 3V3 | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J14 |
| 1 | BYPASS SRC 5V | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J13 |
| 1 | Buzzer | Buzzer_Beeper:MagneticBuzzer_ProSignal_ABI-010-RC | BZ1 |
| 1 | DS18B20 | Package_TO_SOT_THT:TO-92_Inline | U6 |
| 1 | DTH11_V1 | Connector_PinSocket_2.54mm:PinSocket_1x03_P2.54mm_Vertical | J28 |
| 1 | DTH11_V2 | Connector_PinSocket_2.54mm:PinSocket_1x03_P2.54mm_Vertical | J29 |
| 1 | ENABLE | Button_Switch_THT:SW_PUSH_6mm | SW3 |
| 1 | ESP32-DevKitC | PCM_Espressif:ESP32-DevKitC | U3 |
| 1 | H_3V3_2 | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J4 |
| 1 | H_5V | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J2 |
| 1 | H_BUZZER | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J17 |
| 1 | H_DS18B | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J31 |
| 1 | H_DTH11 | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J30 |
| 1 | H_ECHO | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J41 |
| 1 | H_GND | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J6 |
| 1 | H_I2C | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J20 |
| 1 | H_INA1 | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J16 |
| 1 | H_INA2 | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J23 |
| 1 | H_INB1 | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J18 |
| 1 | H_INB2 | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J24 |
| 1 | H_IO | Connector_PinHeader_2.54mm:PinHeader_1x08_P2.54mm_Vertical | J9 |
| 1 | H_IO02 | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J44 |
| 1 | H_IO02_OUT | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J45 |
| 1 | H_IO04 | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J46 |
| 1 | H_IO04_OUT | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J47 |
| 1 | H_IO15 | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J39 |
| 1 | H_IO15_OUT | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J40 |
| 1 | H_IO32 | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J42 |
| 1 | H_IO32_OUT | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J43 |
| 1 | H_IO33 | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J37 |
| 1 | H_IO33_OUT | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J36 |
| 1 | H_IO34 | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J19 |
| 1 | H_IO35 | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J22 |
| 1 | H_IO36 | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J25 |
| 1 | H_IO39 | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J32 |
| 1 | H_KEYPAD | Connector_PinHeader_2.54mm:PinHeader_1x08_P2.54mm_Vertical | J11 |
| 1 | H_SERVO | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J15 |
| 1 | H_SPI | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J26 |
| 1 | H_Src_raw | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J1 |
| 1 | H_TRIGGER | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J35 |
| 1 | INPUT_D1 | Button_Switch_THT:SW_PUSH_6mm | SW5 |
| 1 | INPUT_D2 | Button_Switch_THT:SW_PUSH_6mm | SW7 |
| 1 | Input Source | TerminalBlock_Phoenix:TerminalBlock_Phoenix_PT-1,5-2-5.0-H_1x02_P5.00mm_Horizontal | J8 |
| 1 | LDR_1 | OptoDevice:R_LDR_5.0x4.1mm_P3mm_Vertical | R8 |
| 1 | LED BOARD | LED_SMD:LED_0805_2012Metric | D2 |
| 1 | LED EXT | LED_SMD:LED_0805_2012Metric | D1 |
| 1 | LM35-LP | Package_TO_SOT_THT:TO-92_Inline | U7 |
| 1 | LM7805_TO220 | Package_TO_SOT_THT:TO-220-3_Vertical | U1 |
| 1 | LOGO | my_symbols:qr | G*** |
| 1 | MOTOR | Connector_PinSocket_2.54mm:PinSocket_1x04_P2.54mm_Vertical | J34 |
| 1 | MX1508 | Package_SO:SOP-16_3.9x9.9mm_P1.27mm | U5 |
| 1 | POT_1 | Potentiometer_THT:Potentiometer_Alps_RK163_Single_Horizontal | RV1 |
| 1 | POT_2 | Potentiometer_THT:Potentiometer_Piher_PT-10-V05_Vertical | RV2 |
| 1 | SW_DIP_INPUTS | Button_Switch_THT:SW_DIP_SPSTx04_Slide_9.78x12.34mm_W7.62mm_P2.54mm | SW6 |
| 1 | SW_DIP_KEYPAD_1 | Button_Switch_THT:SW_DIP_SPSTx04_Slide_9.78x12.34mm_W7.62mm_P2.54mm | SW1 |
| 1 | SW_DIP_KEYPAD_2 | Button_Switch_THT:SW_DIP_SPSTx04_Slide_9.78x12.34mm_W7.62mm_P2.54mm | SW2 |
| 1 | S_3V3_2 | Connector_PinSocket_2.54mm:PinSocket_1x04_P2.54mm_Vertical | J5 |
| 1 | S_5V | Connector_PinSocket_2.54mm:PinSocket_1x04_P2.54mm_Vertical | J3 |
| 1 | S_GND | Connector_PinSocket_2.54mm:PinSocket_1x04_P2.54mm_Vertical | J7 |
| 1 | S_I2C | Connector_PinSocket_2.54mm:PinSocket_1x02_P2.54mm_Vertical | J21 |
| 1 | S_IO | Connector_PinSocket_2.54mm:PinSocket_1x08_P2.54mm_Vertical | J10 |
| 1 | S_KEYPAD | Connector_PinSocket_2.54mm:PinSocket_1x08_P2.54mm_Vertical | J12 |
| 1 | S_SPI | Connector_PinSocket_2.54mm:PinSocket_1x04_P2.54mm_Vertical | J27 |
| 1 | Selector Input 1 | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | SW8 |
| 1 | Selector Input 2 | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | SW9 |
The 100 most common of 107 parts.
It measures 100 × 100 mm and has 2 copper layers, 1.6 mm thick.
107 parts, built around the ESP32-DEVKITC-VE, DS18B20, HDS18B20 and AMS1117. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the jalmx/base_esp32 repository on GitHub, at the commit this page was made from: the board is base_esp32.kicad_pcb and its schematic base_esp32.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).
rayvburn/diff_drive_mapping_robot
ROS driver for the Raspberry Pi based differential drive robot

Circuit-Digest/ESP32-Cam-Surveillance-Car
Watch full video on ESP32 surveillance car

shaise/OpenSky328
An atmel implementation of OpenSky FrSky-compatible RX

louismomo66/field-eyes_pcb
Open fieldeyesv2.kicadpro in KiCad 9. The whole circuit is one flat schematic (fieldeyesv2.kicadsch): all 168 parts are on a single page, in four framed sections.


vmfachini/Lumibot
Desenvolvimento de um Hardware Livre, com uso de energia limpa, baseado no micro:bit para criar robôs móveis acessíveis, promovendo ensino de robótica, pensamento computacional e sustentabilidade no Brasil.