L298N
akhil053/L298-Motor-Driver
This project focuses on the design of a DC motor driver PCB using the L298N motor driver IC. The schematic and PCB layout were developed in KiCad with proper component placement, routing, and net labeling.

PCB repo for the micromouse project
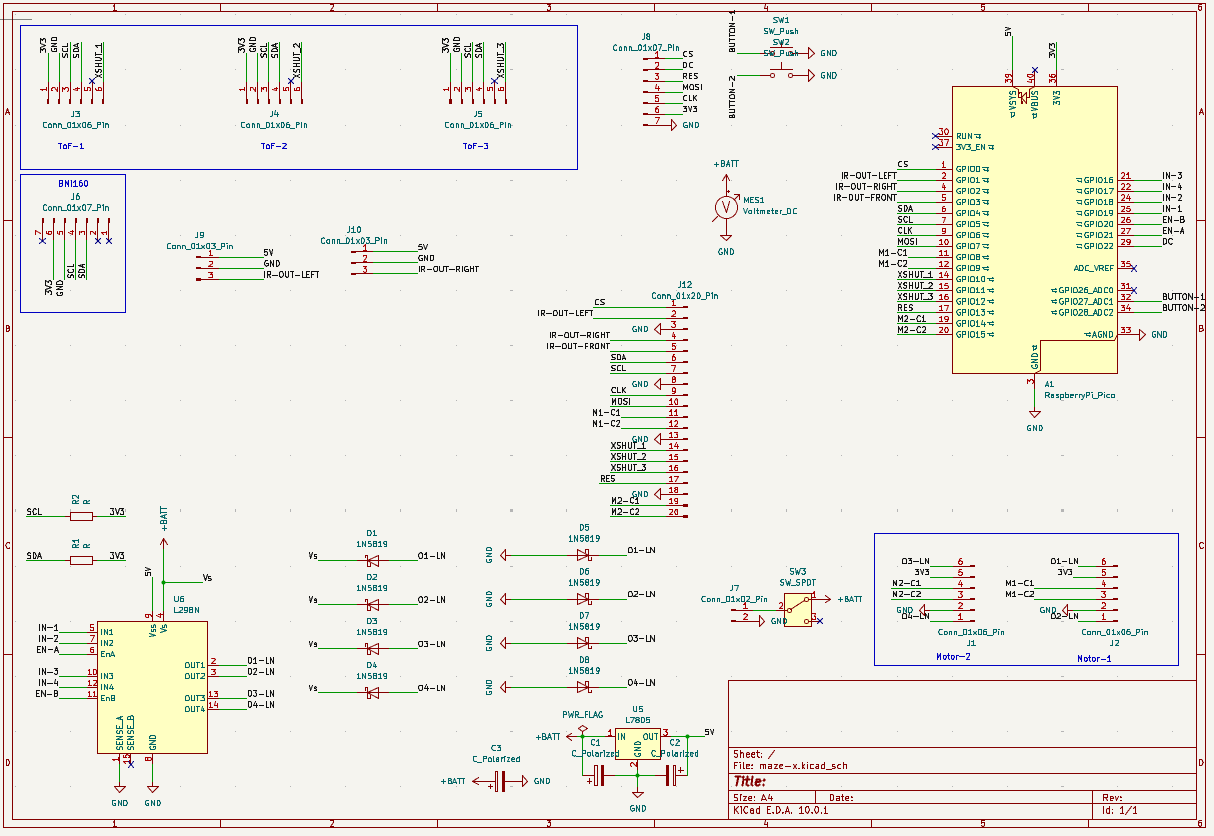
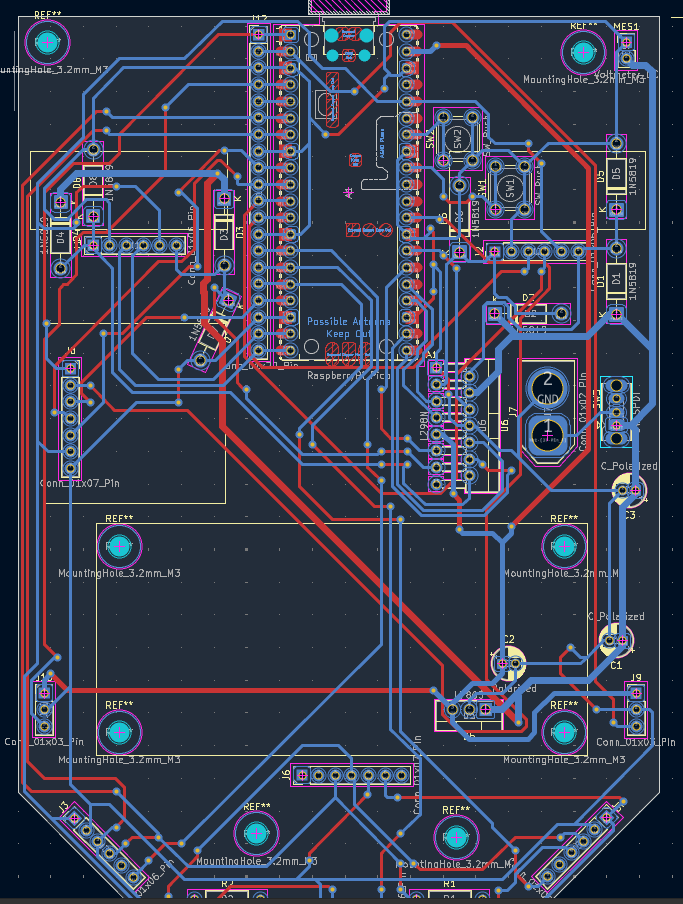
Maze x is an open-source printed circuit board by isrxth, from the isrxth/mircomice-pcb repository on GitHub. It is a 2-layer board of 98 × 140.2 mm with 39 parts on 52 nets, routed with 704 tracks and 86 vias.
It is built around the L298N and L7805. Its parts include 11 connectors, 8 diodes, 3 capacitors, 3 switches and 2 resistors. It belongs with the RP2040 boards of this library.
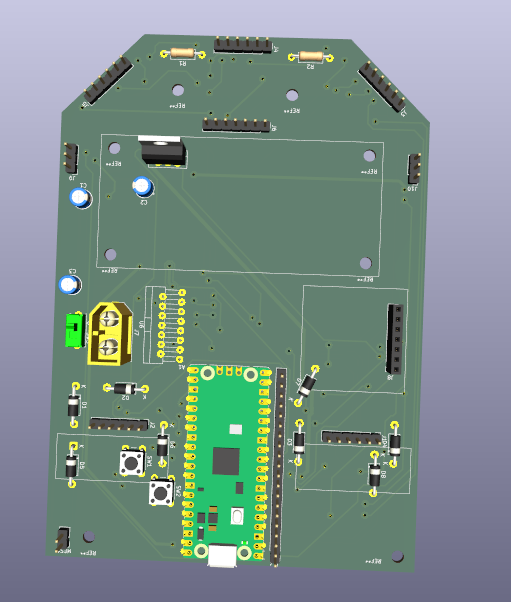
KiCad design files for a Raspberry Pi Pico-based maze robot controller. The board brings together motor control, sensor headers, power input, user controls, and expansion connectors on a single PCB.
| File | Description |
|---|---|
maze-x.kicad_sch | Schematic |
maze-x.kicad_pcb | PCB layout |
maze-x.kicad_pro | KiCad project configuration |
images/ | Schematic and board screenshots |
maze-x-backups/ | KiCad backup files |


maze-x.kicad_pro in KiCad.The main challenge was fitting the complete design onto a single-layer PCB while working to a strict deadline. This constraint influenced the routing, component placement, and board footprint, and is one reason a multilayer revision is planned for future development.
This repository contains the current design files and visual previews. Review the schematic, run electrical-rule checks, and verify the board with your intended components and fabrication requirements before ordering.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 8 | 1N5819 | Diode_THT:D_DO-41_SOD81_P10.16mm_Horizontal | D1, D2, D3, D4, D5, D6, D7, D8 |
| 5 | Conn_01x06_Pin | Connector_PinHeader_2.54mm:PinHeader_1x06_P2.54mm_Vertical | J1, J2, J3, J4, J5 |
| 3 | C_Polarized | Capacitor_THT:CP_Radial_D5.0mm_P2.00mm | C1, C2, C3 |
| 2 | Conn_01x03_Pin | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J9, J10 |
| 2 | R | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R1, R2 |
| 2 | SW_Push | Button_Switch_THT:SW_PUSH_6mm_H4.3mm | SW1, SW2 |
| 1 | Conn_01x02_Pin | Connector_AMASS:AMASS_XT60-M_1x02_P7.20mm_Vertical | J7 |
| 1 | Conn_01x07_Pin | Connector_PinHeader_2.54mm:PinHeader_1x07_P2.54mm_Vertical | J6 |
| 1 | Conn_01x07_Pin | Connector_PinSocket_2.54mm:PinSocket_1x07_P2.54mm_Vertical | J8 |
| 1 | Conn_01x20_Pin | Connector_PinHeader_2.54mm:PinHeader_1x20_P2.54mm_Vertical | J12 |
| 1 | L298N | Package_TO_SOT_THT:TO-220-15_P2.54x5.08mm_StaggerOdd_Lead4.58mm_Vertical | U6 |
| 1 | L7805 | Package_TO_SOT_THT:TO-220-3_Vertical | U5 |
| 1 | RaspberryPi_Pico | Module:RaspberryPi_Pico_Common_Unspecified | A1 |
| 1 | SW_SPDT | Button_Switch_THT:SW_Slide_SPDT_Straight_CK_OS102011MS2Q | SW3 |
| 1 | Voltmeter_DC | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | MES1 |
The 31 most common of 39 parts.
It measures 98 × 140.2 mm and has 2 copper layers, 1.6 mm thick.
39 parts, built around the L298N and L7805. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the isrxth/mircomice-pcb repository on GitHub, at the commit this page was made from: the board is maze-x.kicad_pcb and its schematic maze-x.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask isrxth before reusing the design.

akhil053/L298-Motor-Driver
This project focuses on the design of a DC motor driver PCB using the L298N motor driver IC. The schematic and PCB layout were developed in KiCad with proper component placement, routing, and net labeling.


hurryharii/kicad-pcb-learning-project
A work-in-progress PCB designed using KiCad, featuring a 7805 voltage regulator, 1N4007 diodes, capacitors, motor connectors, and test points.


Mahfuz-Sarker136/L298N-Motor-driver-PCB-layout-with-Kicad
A custom, dual-layer L298N Motor Driver PCB module optimized for Robotics,Arduino or ESP-32 project


Omar-Hany00/ESP32-Robotic-Arm-Car
Custom ESP32-based RC robotic arm car with integrated PCB, motor control, and servo actuation.