Buck boost
introlab/t-top
T-Top is a tabletop robot designed with advanced audio and vision sensors, deep learning perceptual processing and telecommunication capabilities to provide richer interaction modalities and develop higher cognitive…

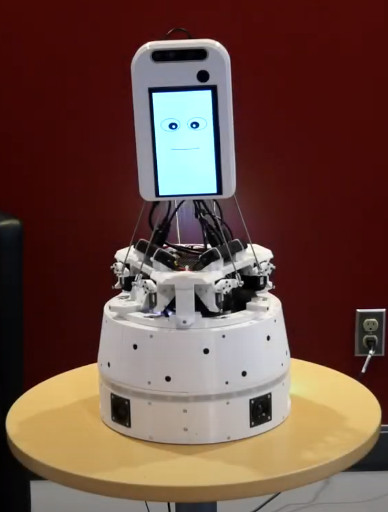
T-Top is a tabletop robot designed with advanced audio and vision sensors, deep learning perceptual processing and telecommunication capabilities to provide richer interaction modalities and develop higher cognitive abilities from interacting with people.
Psu control is an open-source printed circuit board by introlab, from the introlab/t-top repository on GitHub. It is a 4-layer board of 100 × 70 mm with 122 parts on 81 nets, routed with 896 tracks and 110 vias.
It is built around the 74LVC2G34GW, SN65C3221EPW and SN74LV1T34DBV, with the 74HC14, DSS16U and CEM-1206S among its other parts. Its parts include 43 resistors, 31 capacitors, 12 connectors, 7 ICs and 7 diodes. It belongs with the robots and motor control and audio and music boards and the NXP (LPC, Kinetis, i.MX RT) boards of this library.
T-Top is a tabletop robot designed with advanced audio and vision sensors, deep learning perceptual processing and telecommunication capabilities to provide richer interaction modalities and develop higher cognitive abilities from interacting with people.

| Category | Type | Description |
|---|---|---|
| Power | Power Adapter | 19 V |
| Battery | 1x RRC2054-2 | |
| Battery Charger | 1x RRC-PMM240 | |
| Sensors | Microphone Array | 16x xSoundsMicrophones, 1x 16SoundsUSB |
| RGB-D Camera | 1x Intel RealSense D435i | |
| Wide Angle Camera | 1x Arducam AR0230 | |
| Touchscreen | 1x 7 inch 1024x600 capacitive touchscreen | |
| Current/Voltage | INA220 | |
| Light Sensors | 4x Adafruit ALS-PT19 | |
| Buttons | 4x buttons | |
| Actuators | Stewart Platform | Displacement range: ±3 cm (x, y and z), ±20° (x and y), ±30° (z). Motor: Dynamixel XL430-W250 |
| Rotating Base | Displacement range: illimited. Motor: Dynamixel XL430-W250 | |
| Speakers | 4x Dayton Audio DMA45-8, 2x MAX9744 | |
| Cooling | 2x Noctua NF-A4x20 5V | |
| Touchscreen | 1x 7 inch 1024x600 capacitive touchscreen | |
| LED | Battery status, volume level, led strip | |
| Network | WiFi | Intel Dual Band Wireless-AC 8265 NGW |
| Ethernet | 100 Mbps | |
| Processing | Computer | NVIDIA Jetson AGX Xavier Developer Kit or NVIDIA Jetson AGX Xavier Orin Developer Kit |
| Motor MCU | Teensy 4.0 | |
| Battery MCU | Teensy LC | |
| Perceptions | SLAM, object detection, person pose estimation, face recognition, sound classification, speaker identification, robot name detection, speech to text, person identification, music beat detection, source source localization, ego noise reduction, vad | |
| Behaviors | Telepresence, emotions, talking, greeting, face following, dancing, exploring, sound following |
See 01_COMPUTER_CONFIGURATION.md

IntRoLab - Intelligent / Interactive / Integrated / Interdisciplinary Robot Lab
| Qty | Value | Footprint | References |
|---|---|---|---|
| 21 | 0.1µF/25V | Capacitor_SMD:C_0805_2012Metric | C1, C11, C12, C13, C14, C15, C16, C17, C18, C19, C20, C21, C22, C25, C26, C27 +5 |
| 15 | 10k | Resistor_SMD:R_0805_2012Metric | R15, R18, R25, R26, R27, R28, R29, R30, R31, R32, R33, R34, R35, R36, TH2 |
| 5 | 100k | Resistor_SMD:R_0805_2012Metric | R5, R6, R13, R23, R24 |
| 5 | BUTTON | Connector_JST:JST_PH_B2B-PH-K_1x02_P2.00mm_Vertical | SW2, SW3, SW4, SW5, SW6 |
| 4 | 0 | Resistor_SMD:R_0805_2012Metric | R7, R8, R9, R10 |
| 4 | 2.2k | Resistor_SMD:R_0805_2012Metric | R3, R4, R40, R41 |
| 4 | NI | Resistor_SMD:R_0805_2012Metric | R16, R17, R19, R20 |
| 3 | 100µF/35V | Capacitor_THT:CP_Radial_D6.3mm_P2.50mm | C5, C9, C23 |
| 3 | 698 | Resistor_SMD:R_0805_2012Metric | R21, R22, R39 |
| 3 | DSS16U | Diode_SMD:D_SOD-123F | D1, D2, D3 |
| 2 | 0 | Resistor_SMD:R_1206_3216Metric | R43, R44 |
| 2 | 10 | Resistor_SMD:R_0805_2012Metric | R11, R12 |
| 2 | 10µF/25V | Capacitor_SMD:C_0805_2012Metric | C10, C24 |
| 2 | 22µH (NS12575T220MN) | t-top:NS12575T220MN | L1, L2 |
| 2 | 22μF/10V | Capacitor_SMD:C_0805_2012Metric | C4, C31 |
| 2 | 63.4 | Resistor_SMD:R_0805_2012Metric | R37, R38 |
| 2 | Fan | Connector_JST:JST_PH_B2B-PH-K_1x02_P2.00mm_Vertical | M1, M2 |
| 2 | Vout (10-24V) | t-top:OSTTA020161 | J2, J4 |
| 2 | White | Connector_JST:JST_PH_B2B-PH-K_1x02_P2.00mm_Vertical | D4, D5 |
| 1 | 0.004 | Resistor_SMD:R_1206_3216Metric | R14 |
| 1 | 10A Slow Blow | t-top:M205_FUSE | F1 |
| 1 | 10k | Connector_JST:JST_PH_B2B-PH-K_1x02_P2.00mm_Vertical | TH1 |
| 1 | 1µF/10V | Capacitor_SMD:C_0805_2012Metric | C3 |
| 1 | 22µF/25V | Capacitor_SMD:C_0805_2012Metric | C2 |
| 1 | 47 | Resistor_SMD:R_0805_2012Metric | R42 |
| 1 | 680µF/35V | Capacitor_THT:CP_Radial_D10.0mm_P5.00mm | C6 |
| 1 | 74HC14 | Package_SO:TSSOP-14_4.4x5mm_P0.65mm | U5 |
| 1 | 74LVC2G34 | Package_SO:TSOP-6_1.65x3.05mm_P0.95mm | U8 |
| 1 | Amplifier 1 I2C | Connector_JST:JST_PH_B3B-PH-K_1x03_P2.00mm_Vertical | J8 |
| 1 | Amplifier 2 I2C | Connector_JST:JST_PH_B3B-PH-K_1x03_P2.00mm_Vertical | J7 |
| 1 | CEM-1206S | t-top:WT-1205 | LS1 |
| 1 | DMG9926USD | Package_SO:SOIC-8_3.9x4.9mm_P1.27mm | Q4 |
| 1 | INA220 | Package_SO:VSSOP-10_3x3mm_P0.5mm | U3 |
| 1 | K7805-3AR3 | t-top:K7805-3AR3 | U4 |
| 1 | LED Strip | Connector_JST:JST_XH_B3B-XH-A_1x03_P2.50mm_Vertical | J6 |
| 1 | Light Sensor Back | Connector_JST:JST_PH_B3B-PH-K_1x03_P2.00mm_Vertical | J13 |
| 1 | Light Sensor Front | Connector_JST:JST_PH_B3B-PH-K_1x03_P2.00mm_Vertical | J11 |
| 1 | Light Sensor Left | Connector_JST:JST_PH_B3B-PH-K_1x03_P2.00mm_Vertical | J12 |
| 1 | Light Sensor Right | Connector_JST:JST_PH_B3B-PH-K_1x03_P2.00mm_Vertical | J14 |
| 1 | Non-Momentary DPST | Connector_JST:JST_PH_B4B-PH-K_1x04_P2.00mm_Vertical | SW1 |
| 1 | RRC-PMM240 | Connector_JST:JST_PH_B5B-PH-K_1x05_P2.00mm_Vertical | J15 |
| 1 | RS232 | Connector_JST:JST_PH_B3B-PH-K_1x03_P2.00mm_Vertical | J16 |
| 1 | SMAJ9.0A-13-F | Diode_SMD:D_SMA | D6 |
| 1 | SN65C3221E | Package_SO:TSSOP-16_4.4x5mm_P0.65mm | U7 |
| 1 | SN74LV1T34 | Package_TO_SOT_SMD:SOT-23-5 | U6 |
| 1 | SUD50P04-09L-E3 | Package_TO_SOT_SMD:TO-252-2 | Q2 |
| 1 | SZ1SMA24AT3G | Diode_SMD:D_SMA | D7 |
| 1 | T2N7002AK | Package_TO_SOT_SMD:SOT-23 | Q3 |
| 1 | Teensy_LC | t-top:Teensy_LC | U2 |
| 1 | Vin (10-24V) | t-top:OSTTA020161 | J1 |
The 116 most common of 122 parts.

introlab/t-top
T-Top is a tabletop robot designed with advanced audio and vision sensors, deep learning perceptual processing and telecommunication capabilities to provide richer interaction modalities and develop higher cognitive…

introlab/t-top
T-Top is a tabletop robot designed with advanced audio and vision sensors, deep learning perceptual processing and telecommunication capabilities to provide richer interaction modalities and develop higher cognitive…

jackw01/pi-pico-printer-board
Tinkerer-friendly Klipper compatible 3D printer control board using Raspberry Pi Pico

dev-campusfab/FabRice
Documentation et code source de FabRice, le robot Autonome.

custom-ds/ptFlex
ptFlex tracker board starting with version 2.0 of the hardware, which is based on the improvements found in the ptSolar tracker.

ratmuds/revo
a "cheap" 6 DoF robot arm intentionally pushing the limits of low quality hobby servos


efabless/foss-asic-tools
FOSS-ASIC-TOOLS is all in one container for SKY130 based design both Analog and Digital. Below is a list of the current tools already installed and ready to use.

damienmaguire/MG-EV-Inverter
Reverse engineering of the drive motor and inverter used in MG Electric Vehicles

Duet3D/Duet3-Mini5plus
This repository also contains information in the Mini 2+ : a two driver expansion board for the Duet 3 mini 5+
It measures 100 × 70 mm and has 4 copper layers, 1.6 mm thick.
122 parts, built around the 74LVC2G34GW, SN65C3221EPW, SN74LV1T34DBV and 74HC14. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the introlab/t-top repository on GitHub, at the commit this page was made from: the board is PCB/psu_control/psu_control.kicad_pcb and its schematic PCB/buck_boost/buck_boost.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask introlab before reusing the design.