MTR Tiny MD
MoreThanRobotsFR/MTR_Tiny_MD
This Arduino project utilizes SimpleFOC library for sensor-based brushless motor control with a DRV8316 driver. It also incorporates an Adafruit NeoPixel for visual feedback.

The 3d model can be found at this public onshape project.
Handy is an open-source printed circuit board by ImNotDavid, from the ImNotDavid/handy repository on GitHub, published under the MIT licence. It is a 2-layer board of 69.1 × 8.6 mm with 22 parts on 34 nets, routed with 183 tracks and 21 vias.
It is built around the AS5600L-ASOM and TCA9548ARGER. Its parts include 8 resistors, 4 ICs, 3 capacitors and 3 connectors.

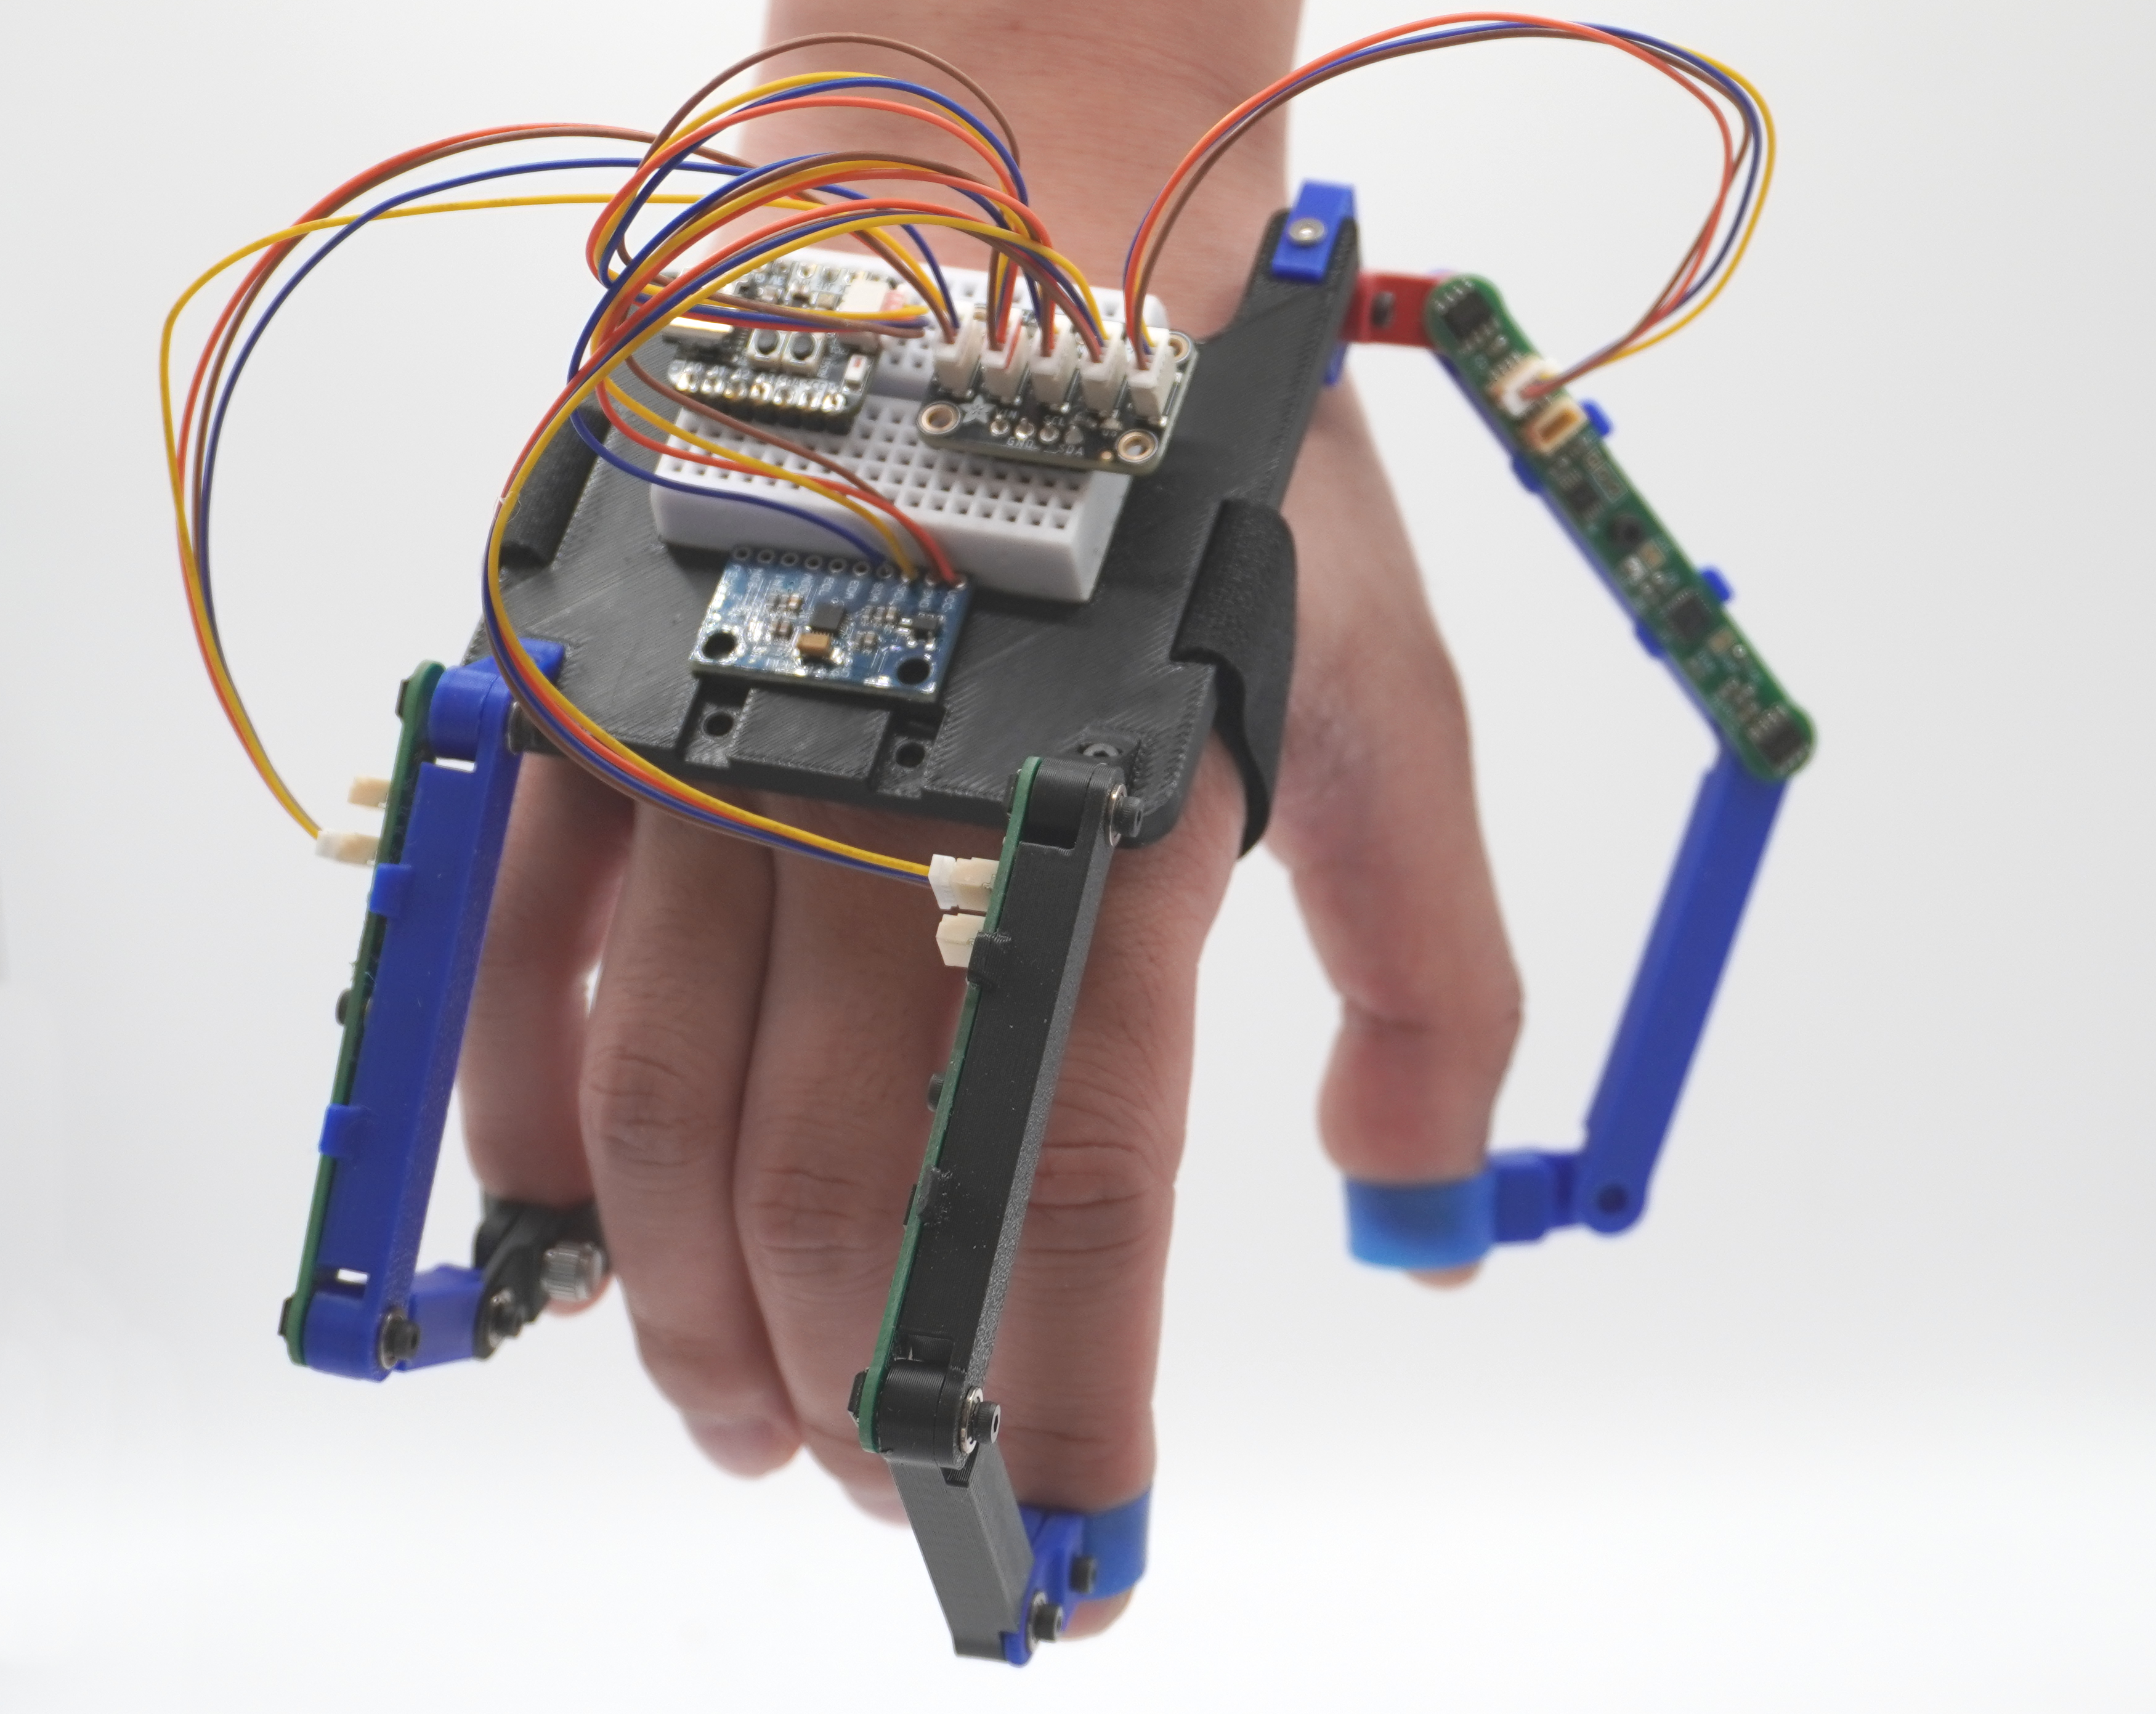
The Haptically-enabled and Afforable framework to control of Non-anthropomorphic robot manipulators for Data gatheringY (HANDY) is a very affordable data glove and ROS software stack to allow anyone to capture dexterous manipulation data.
The 3d model can be found at this public onshape project.
The lenghts of the linkages can be changed by editing variables in the Passive Link file or configuration values in Main Assembly. The size of the finger mounts can be edited similarly in Finger Trap Net. It is highly recommended to use onshape-to-robot to convert the assembly into a URDF. The assembly, URDF has already been set up for this purpose and the config file here has been configured to point to the correct file. You will need to change this to your own URL if you are making modifications.
All parts can be printed in PLA at 0.16mm layer height. The following off the shelf components are required to assemble the Handy (5 fingered configuration):
All the gerber files for the PCB are found here and can be ordered from a manufacturer like JLCPCB for a low price. The component list is included in the KiCad project.
The firmware exists as a platformio project in the firmware folder. This can be modified to work on any ESP-32 based microcontroller by selecting the appropriate chip in platformio.ini.
The ROS nodes are written for ROS2 Humble. To install, simply clone this repo into your ros_ws/src/ folder and colcon build in your workspace. Note that rosdeps are not properly setup so some work may need to done manually installing required python packages.
After sourcing the workspace, running ros2 launch handy handy.launch.py should deploy the software stack including the kinematic mapping to 2 fingered manipulator. This can be visualised in rviz.
Here are some examples of Handy being used for manipulation tasks:
https://github.com/user-attachments/assets/99e4fd3a-1bce-4f82-9469-66eb39cce375
https://github.com/user-attachments/assets/1d073916-30b5-41df-a31d-748b461f2f68
If you have any problems (I suspect you will), feel free to reach out to me through email or discord.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 4 | 100k | Resistor_SMD:R_0603_1608Metric | R7, R8, R9, R10 |
| 4 | 4.7k | Resistor_SMD:R_0603_1608Metric | R1, R2, R3, R4 |
| 3 | ~ | Jumper:SolderJumper-2_P1.3mm_Open_TrianglePad1.0x1.5mm | JP1, JP2, JP3 |
| 2 | 100nF | Capacitor_SMD:C_0603_1608Metric | C1, C2 |
| 2 | AS5600L-ASOM | footprints:AS5600L-ASOM_AMS | U2, U3 |
| 2 | JST-SH 1x4 | Connector_JST:JST_SH_BM04B-SRSS-TB_1x04-1MP_P1.00mm_Vertical | J1, J2 |
| 1 | 100uF | Capacitor_SMD:C_0603_1608Metric | C3 |
| 1 | Conn_01x03_Pin | Connector_PinSocket_2.00mm:PinSocket_1x03_P2.00mm_Vertical | J3 |
| 1 | DRV8830DGQR | DRV8830:DGQ10_2P18X1P72 | U4 |
| 1 | MountingHole | MountingHole:MountingHole_2.2mm_M2_ISO14580_Pad | H1 |
| 1 | TCA9548ARGER | Package_DFN_QFN:Texas_RGE0024C_VQFN-24-1EP_4x4mm_P0.5mm_EP2.1x2.1mm | U1 |
It measures 69.1 × 8.6 mm and has 2 copper layers, 1.6 mm thick.
22 parts, built around the AS5600L-ASOM and TCA9548ARGER. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the ImNotDavid/handy repository on GitHub, at the commit this page was made from: the board is pcb/handy.kicad_pcb and its schematic pcb/handy.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).

MoreThanRobotsFR/MTR_Tiny_MD
This Arduino project utilizes SimpleFOC library for sensor-based brushless motor control with a DRV8316 driver. It also incorporates an Adafruit NeoPixel for visual feedback.

Valar-Systems/VAL3100
The VAL3100 is now part of the Valar Motion mono-repo, alongside the VAL3000 and VAL3101 controllers:


Shubham-Khandelwal1/Universal-Robotic-Arm-Driver
The architecture follows a per-joint control philosophy, where each PCB operates as an independent node responsible for motor control and feedback acquisition, while communicating with a central compute unit (Jetson).

wayri/SPIKE
PCB-focused multiphysics simulation, from board to complete assembly: PI, SI, circuits, thermal, EM/RF and mechanical workflows, with MCAD collaboration and a roadmap toward large-scale coupled assemblies.

AdvikChitre/MSL_Imperial_2023
Repository for Imperial College London Robocup MSL team 2023


ayuusweetfish/Malletwand
A pendulum as a hands-on musical interface for all · NIME 2024 Short Paper