2 layers170.2 × 78.7 mm
ROsiM
hkzlab/ROsiM
ROsiM is a ROM simulator/emulator, supporting up to 512k/16bit ROMs
93 parts11GPL-3.0

 hkzlab/ROsiM11
ROsiM is a ROM simulator/emulator, supporting up to 512k/16bit ROMs
Socket 29C040 is an open-source printed circuit board by hkzlab, from the hkzlab/ROsiM repository on GitHub, published under the GPL-3.0 licence. It is a 2-layer board of 17.8 × 40.6 mm with 2 parts on 31 nets, routed with 33 tracks and 0 vias.
Its parts include 1 IC and 1 connector. It belongs with the retro computing and games boards of this library.
The ROsiM is a ROM simulation / emulation board: it uses two 512k/8bit SRAM chips to simulate an 8 or 16 bit ROM (up to 512k bytes or 512k words in size).
The board is based around an ATMega328P chip @20Mhz, controlled via serial connection.
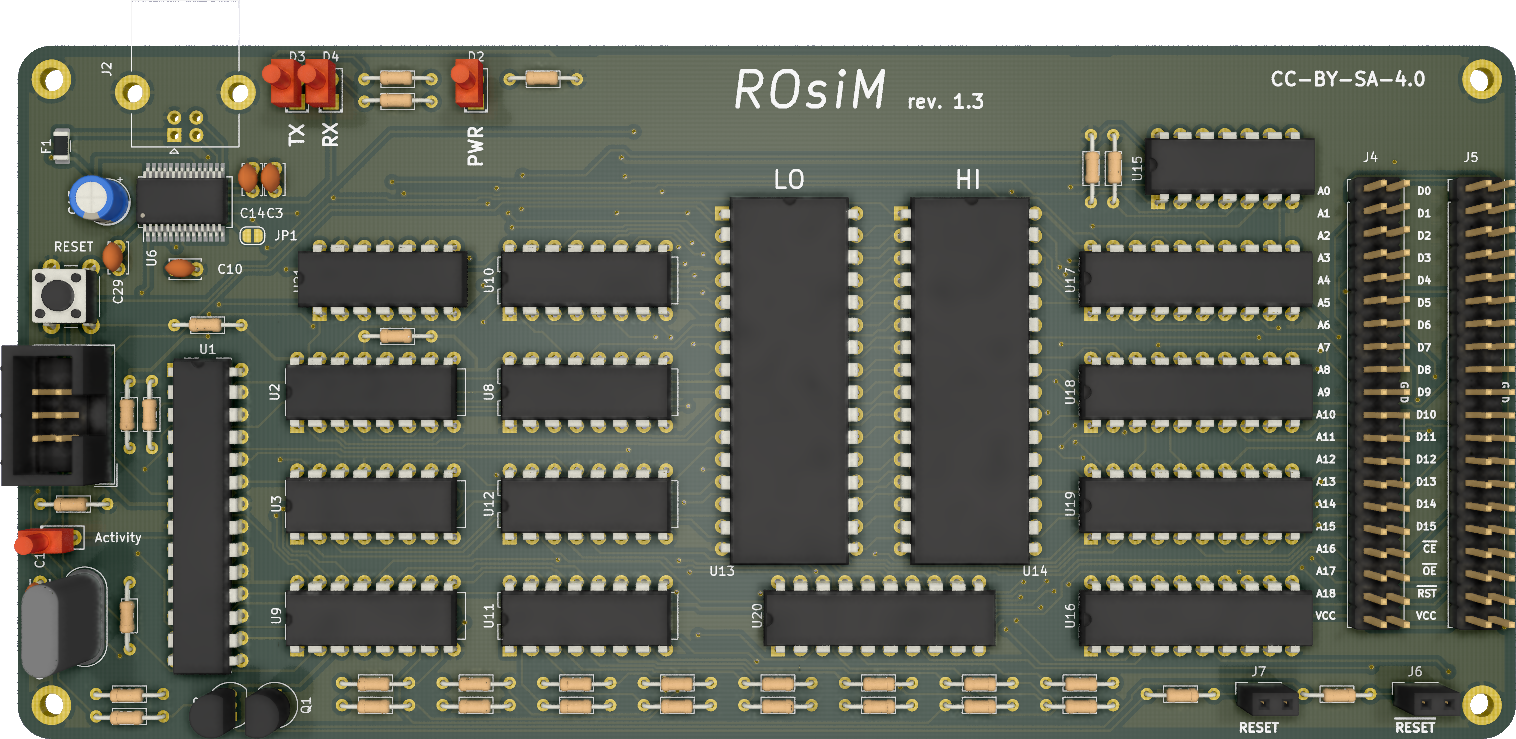
I made this out of my personal need of a simple way to quickly test ROM images on boards I repair/hack/build. Often, these boards use big 16bit EPROMs and the projects I found around did not cater to my needs.
The idea is to use this bare board and then "pods" that attach to the two 40pin header and adapt it to simulate various types of ROMs.
WARNING: While I might help you with quick questions, there is NOT going to be hand-holding for this one.
I have currently built and tested revision 1.3 of this board. The following fixes must be implemented to make it usable:
The following mod is optional but encouraged for safety, and have been implemented for revision 1.4:
This board is designed around relatively cheap through hole (with a few exceptions) components, and should be buildable by anyone with basic soldering skills.
You'll need a way to program your 328P MCU with the bootloader (you can then load the firmware via serial port).
I recommend optiboot. Remember to set the AVR frequency to 20Mhz and baudrate to 115200bps. I might provide prebuilt binaries of this in the future.
TODO
This is used for in-circuit programming of the MCU. You won't really use after burning the bootloader to the chip. You can leave this out if you pre-program the ATMega.
Connect your USB cable here. It will appear as an FTDI serial port to the host.
The Interface runs at 230400bps 8-n-1. The protocol is mainly ASCII based, but meant to be used with an external software.
Connect your DC power supply here, center tip positive. Anything between 7 to 9V will be good, 12V will work, but the regulator might get hotter. 500mA should be enough.
A 40 pin header:
A 40 pin header:
An active-low OC signal will be present on this header. You can use to pilot the /RESET of your target board.
Solder an arc of rigid wire on this one, so you can attach a small crocodile clip to it.
An active-high signal (either high or disconnected) will be present on this header.
Solder an arc of rigid wire on this one, so you can attach a small crocodile clip to it.
While this board can be controlled directly via a simple serial terminal, it is advised to use a client software that supports the following protocol, like the ROsiM Loader.
The Remote Control protocol is pretty simple and ASCII based. It supports 12 commands, each with its own syntax and response.
String CMD_ERR will be sent in case the command is not recognized, string CMD_INV will be sent in case the command cannot be executed at this time.
>K<Forces the reset by watchdog of the ROsiM.
>M<[M xx]Returns the current model of the board in hex.
>A 00xxxxxx<[A 00xxxxxx]Specifies the start address for the next read/write commands. The address must be specified in hex, and a mask of 0x7FFFF will be applied to it.
>W xxxx<[W xxxx]The SRAM must be in WRITE mode and the board switched to INTERNAL, otherwise the response CMD_INV will be sent.
xxxx is the data to write on SRAM at the current address in hex format.
Once the write completes, the address will automatically increment by 1.
>R<[R xxxx]The SRAM must be in READ mode and the board switched to INTERNAL, otherwise the response CMD_INV will be sent.
xxxx is the data written at the current address in hex format. Once the read completes, the address will automatically increment by 1.
>E y< where y can be 0 or 1[E y]Enables (1) or disables (0) the external RESET signal to the target board.
>S y< where y can be 0 or 1[S y]To execute this command, the SRAM must be in READ mode, otherwise the response CMD_INV will be sent.
Sets the board to INTERNAL (1) or EXTERNAL (0) mode. EXTERNAL mode will enable the drivers that communicate through the external address/data/control lines.
>X y< where y can be 0 or 1[X y]To execute this command, the board must be in INTERNAL mode, otherwise the response CMD_INV will be sent.
Sets the SRAM to READ (1) or WRITE (0) mode.
>V<[V 00xxxxxx yy]This command will print out the current address in hex format (00xxxxxx) and a mask (yy) in hex format that contains:
>D<[D]Will revert the board state to the following state:
The selection of the EXTERNAL RESET logic will NOT be restored by this command and will remain set to the current state.
>T<[T xx]Resets the board to defaults then executes a test on the SRAMs by writing patterns of data in them and reading them back.
The output can be:
00 test was completed successfully01 test failed while writing the first pattern (0xAA55)02 test failed while writing the first pattern (0x55AA)03 the test failed while writing the incremental pattern>O x<[O yy]Starts an XMODEM transfer of a binary file into the SRAM.
x can be:
0 The file will be considered an 8-bit dump, the highest 8 bits of the SRAM will be set to 0x00, only the lower 8 bits will be set.1 The file will be considered a 16-bit dump, and the data will be loaded into the SRAM in words. ODD bytes in the dump will end up in the high byte of the SRAM, EVEN bytes will end up in the low byte of the SRAM.2 The file will be considered a byte swapped 16-bit dump, and the data will be loaded into the SRAM in words. EVEN bytes in the dump will end up in the high byte of the SRAM, ODD bytes will end up in the low byte of the SRAM.yy will be:
00 for a failed transfer.01 for a successful transfer.| Qty | Value | Footprint | References |
|---|---|---|---|
| 1 | 29C040 | Package_DIP:DIP-32_W15.24mm | U1 |
| 1 | Adapter | Connector_PinHeader_2.54mm:PinHeader_2x16_P2.54mm_Vertical | J1 |
hkzlab/ROsiM
ROsiM is a ROM simulator/emulator, supporting up to 512k/16bit ROMs

hkzlab/ROsiM
ROsiM is a ROM simulator/emulator, supporting up to 512k/16bit ROMs

hkzlab/ROsiM
ROsiM is a ROM simulator/emulator, supporting up to 512k/16bit ROMs

hkzlab/ROsiM
ROsiM is a ROM simulator/emulator, supporting up to 512k/16bit ROMs

hkzlab/ROsiM
ROsiM is a ROM simulator/emulator, supporting up to 512k/16bit ROMs

hkzlab/ROsiM
ROsiM is a ROM simulator/emulator, supporting up to 512k/16bit ROMs

hkzlab/ROsiM
ROsiM is a ROM simulator/emulator, supporting up to 512k/16bit ROMs

hkzlab/ROsiM
ROsiM is a ROM simulator/emulator, supporting up to 512k/16bit ROMs

hkzlab/ROsiM
ROsiM is a ROM simulator/emulator, supporting up to 512k/16bit ROMs

hkzlab/ROsiM
ROsiM is a ROM simulator/emulator, supporting up to 512k/16bit ROMs

hkzlab/ROsiM
ROsiM is a ROM simulator/emulator, supporting up to 512k/16bit ROMs

hkzlab/ROsiM
ROsiM is a ROM simulator/emulator, supporting up to 512k/16bit ROMs

hzeller/rpi-rgb-led-matrix
Controlling up to three chains of 64x64, 32x32, 16x32 or similar RGB LED displays using Raspberry Pi GPIO


adamws/kicad-kbplacer
KiCad plugin for automatic keyboard's key placement and routing

Luos-io/luos_engine
Open-source and real-time orchestrator for cyber-physical-systems, to easily design, test and deploy embedded applications and digital twins.

NVNTLabs/switch2-SDEX2M2
Micro SD Express to M.2 NVME Adapter for Nintendo Switch 2

BlueSCSI/BlueSCSI-v2
BlueSCSI v2/Ultra - an open source, open hardware, SCSI emulator using the Pi Pico PR2040 and Pico 2 RP2350

ohmtech-rdi/eurorack-blocks
Software to Hardware Prototyping for Eurorack using C++, Max/Gen~ or Faust

It measures 17.8 × 40.6 mm and has 2 copper layers, 1.6 mm thick.
2 parts. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the hkzlab/ROsiM repository on GitHub, at the commit this page was made from: the board is board/socket_29C040/socket_29C040.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the GPL-3.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).