4 layers85.3 × 131.6 mm
Battery Monitor 1.2
team-mountaineers-urc-2023/electronics
Block diagrams, schematics, and PCB files related to the electronics subteam
167 parts2BSD-3-Clause

 gamer927/rav4
rav4
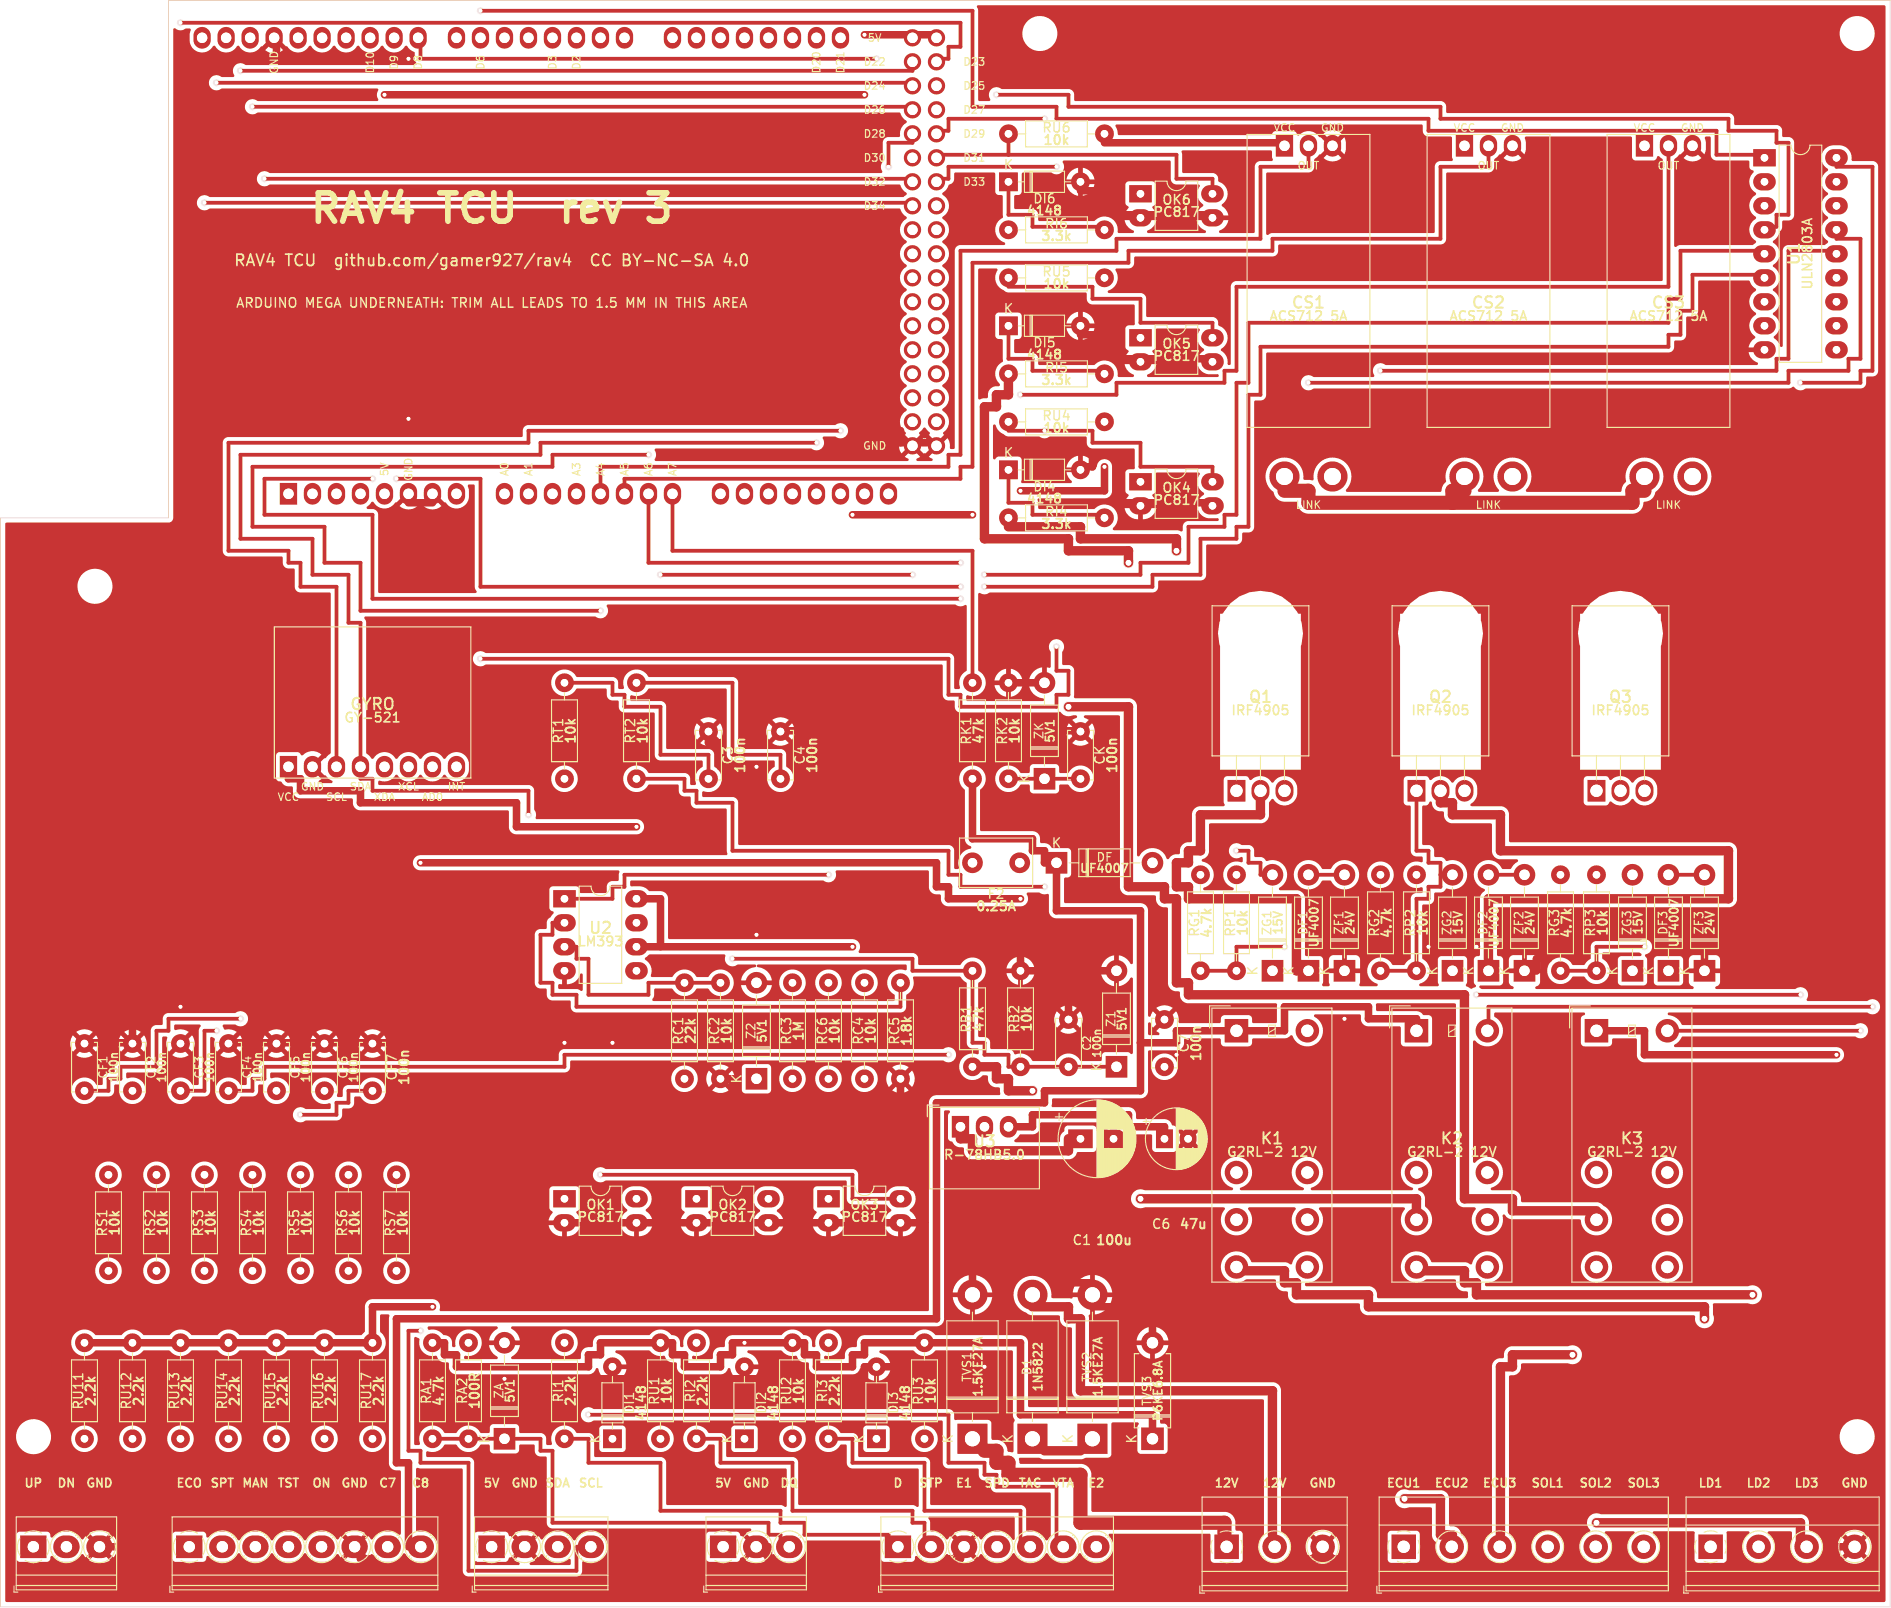
Rav4-tcu is an open-source printed circuit board by gamer927, from the gamer927/rav4 repository on GitHub. It is a 2-layer board of 200 × 170 mm with 118 parts on 84 nets, routed with 1,732 tracks and 87 vias.
It is built around the R-78HB5.0-0.5, LM393 and ULN2803A, with the UF4007, IRF4905 and 1.5KE27A among its other parts. Its parts include 14 capacitors, 4 connectors, 4 crystals, 3 ICs and 3 transistors.


One 2-layer board, 200 × 170 mm, that plugs straight onto the Arduino Mega and carries the whole TCU circuit. You order it bare and solder the parts in yourself (build book, parts 4–6): every connection between the parts is already a copper track, so there's no wiring on the bench.
Upload rav4-tcu-gerbers.zip as it is (don't unzip it) to a board
maker such as JLCPCB, PCBWay, OSH Park or Aisler. Their website reads the size and the number
of layers from the zip. Pick these options:
| Option | Choose |
|---|---|
| Layers | 2 |
| Size | 200 × 170 mm (read from the zip) |
| Thickness | 1.6 mm |
| Copper weight | 1 oz |
| Surface finish | HASL lead-free (or ENIG) |
| Solder mask colour | Any. Green is usually the cheapest and fastest |
| Quantity | 5 (the usual minimum) |
| Everything else | Leave at the default. You do not want assembly or a stencil |
It costs about $20–40 for five boards, shipping included, and arrives in 1–2 weeks. Boards over 100 × 100 mm cost a bit more at some makers. That's normal. Before you pay, look at the maker's preview of the board: it should match the picture above, with a notch in the back-left corner and 5 mounting holes.
| File | What it is |
|---|---|
rav4-tcu-gerbers.zip | The file to upload: copper, solder mask, labels, outline and drill files |
gerbers/ | The same files unzipped, to look at in a Gerber viewer |
rav4-tcu.kicad_pcb, .kicad_pro | The board in KiCad 7 or later, if you want to look closer or change it |
rav4tcu.pretty/ | The board's own footprints: the Mega's pins, the current-sensor module, the gyro module |
bom.csv | Every part on the board with its reference, value and footprint |
drc.txt | KiCad's design-rule check report: 0 errors and 0 unconnected pads |
part_fit.md | Will the real parts fit? Every part checked at the largest size it's sold in: legs vs holes, bodies vs neighbours, heights. 0 problems |
placement.png, routed.png | Pictures of where every part goes, and of every track |
The shopping list has every part with where to buy it. The build book's six soldering steps say which parts go in at each step.
tools/pcb.py builds the board from the tested
circuit in tools/boards.py: it places every part, routes every
track with tools/pcb_router.py, fills both sides with ground,
and refuses to write anything if KiCad's design-rule check finds an error or an unconnected
pad. It needs KiCad 7's Python module (python3 tools/pcb.py). Don't edit the board by hand:
change the script and run it again. make check then checks that every pad is on the net the
circuit says.Nothing has been made from these files yet. The first board you build is the first test of the layout: check it carefully, step by step, with the build book's meter checks, and see the system review §8.
RAV4 TCU by gamer927 · CC BY-NC-SA 4.0: free to build, not to sell. That includes the board: you may have boards made for your own build, but not sell them.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 23 | 10k | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | RB2, RC2, RC4, RC6, RK2, RP1, RP2, RP3, RS1, RS2, RS3, RS4, RS5, RS6, RS7, RT1 +7 |
| 12 | 100n | C_Disc_D5.0mm_W2.5mm_P5.00mm | C2, C3, C4, C7, CF1, CF2, CF3, CF4, CF5, CF6, CF7, CK |
| 10 | 2.2k | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | RI1, RI2, RI3, RU11, RU12, RU13, RU14, RU15, RU16, RU17 |
| 6 | 4148 | D_DO-35_SOD27_P7.62mm_Horizontal | DI1, DI2, DI3, DI4, DI5, DI6 |
| 6 | PC817 | DIP-4_W7.62mm_LongPads | OK1, OK2, OK3, OK4, OK5, OK6 |
| 5 | MountingHole_3.2mm_M3 | MountingHole_3.2mm_M3 | H1, H2, H3, H4, H5 |
| 4 | 4.7k | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | RA1, RG1, RG2, RG3 |
| 4 | 5V1 | D_DO-41_SOD81_P10.16mm_Horizontal | Z1, Z2, ZA, ZK |
| 4 | UF4007 | D_DO-41_SOD81_P10.16mm_Horizontal | DF, DF1, DF2, DF3 |
| 3 | 15V | D_DO-41_SOD81_P10.16mm_Horizontal | ZG1, ZG2, ZG3 |
| 3 | 24V | D_DO-41_SOD81_P10.16mm_Horizontal | ZF1, ZF2, ZF3 |
| 3 | 3.3k | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | RI4, RI5, RI6 |
| 3 | ACS712 5A | ACS712_Module | CS1, CS2, CS3 |
| 3 | G2RL-2 12V | Relay_DPDT_Omron_G2RL-2 | K1, K2, K3 |
| 3 | IRF4905 | TO-220-3_Horizontal_TabDown | Q1, Q2, Q3 |
| 2 | 1.5KE27A | D_DO-201AD_P15.24mm_Horizontal | TVS1, TVS2 |
| 2 | 47k | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | RB1, RK1 |
| 1 | 0.25A | C_Disc_D7.5mm_W5.0mm_P5.00mm | F2 |
| 1 | 1.8k | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | RC5 |
| 1 | 100R | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | RA2 |
| 1 | 100u | CP_Radial_D8.0mm_P3.50mm | C1 |
| 1 | 1M | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | RC3 |
| 1 | 1N5822 | D_DO-201AD_P15.24mm_Horizontal | D1 |
| 1 | 22k | R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | RC1 |
| 1 | 47u | CP_Radial_D6.3mm_P2.50mm | C6 |
| 1 | ATF | TerminalBlock_Phoenix_PT-1,5-3-3.5-H_1x03_P3.50mm_Horizontal | X6 |
| 1 | Arduino Mega | Arduino_Mega2560_Shield | A1 |
| 1 | DASH | TerminalBlock_Phoenix_PT-1,5-8-3.5-H_1x08_P3.50mm_Horizontal | X4 |
| 1 | GY-521 | GY-521_Module | GYRO |
| 1 | LM393 | DIP-8_W7.62mm_LongPads | U2 |
| 1 | LOAD | TerminalBlock_Phoenix_MKDS-1,5-4-5.08_1x04_P5.08mm_Horizontal | J4 |
| 1 | P6KE6.8A | D_DO-15_P10.16mm_Horizontal | TVS3 |
| 1 | PWR | TerminalBlock_Phoenix_MKDS-1,5-3-5.08_1x03_P5.08mm_Horizontal | J1 |
| 1 | R-78HB5.0 | Converter_DCDC_RECOM_R-78HB-0.5_THT | U3 |
| 1 | SCREEN | TerminalBlock_Phoenix_PT-1,5-4-3.5-H_1x04_P3.50mm_Horizontal | X5 |
| 1 | SHIFT | TerminalBlock_Phoenix_PT-1,5-3-3.5-H_1x03_P3.50mm_Horizontal | X7 |
| 1 | SIG | TerminalBlock_Phoenix_PT-1,5-7-3.5-H_1x07_P3.50mm_Horizontal | J3 |
| 1 | SOL | TerminalBlock_Phoenix_MKDS-1,5-6-5.08_1x06_P5.08mm_Horizontal | J2 |
| 1 | ULN2803A | DIP-18_W7.62mm_LongPads | U1 |
It measures 200 × 170 mm and has 2 copper layers, 1.6 mm thick.
118 parts, built around the R-78HB5.0-0.5, LM393, ULN2803A and UF4007. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the gamer927/rav4 repository on GitHub, at the commit this page was made from: the board is hardware/pcb/rav4-tcu.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask gamer927 before reusing the design.
team-mountaineers-urc-2023/electronics
Block diagrams, schematics, and PCB files related to the electronics subteam

ElTinmar/IR_LED
This is an open-source infra-red illumnination solution (LED panel and driver) for machine vision. An arduino nano every sits at the core of the driver board, and allows remote control from a PC through serial…


yupipi93/arduino-lemon-piano
Hold a ground clip in one hand and touch a lemon with the other: your body closes the circuit, the pin drops three or four ADC counts, and a note sounds. Seven lemons make a keyboard.


Operationorange01/Flyback-Driver
driver for high voltage flyback transformer

pasachan/ESP-32-RELAY-CONTROLLER
An 8-channel relay controller with Wi-Fi, an RS-485 field bus, and a 12 V power rail for downstream nodes. Designed as the master board for a small home-automation network: this board switches loads directly, talks to…