2 layers40 × 70 mm
KinetiCoreDC
axpaul/KinetiCoreDC
Compact STM32G0-based DC motor controller board featuring TI DRV8874 H-bridge drivers, RS485 communication, optoisolated I/O, and hardware power protection.
183 parts1CERN-OHL-S-2.0
 fcladera/EvMAPPER5
Source code for EvMAPPER
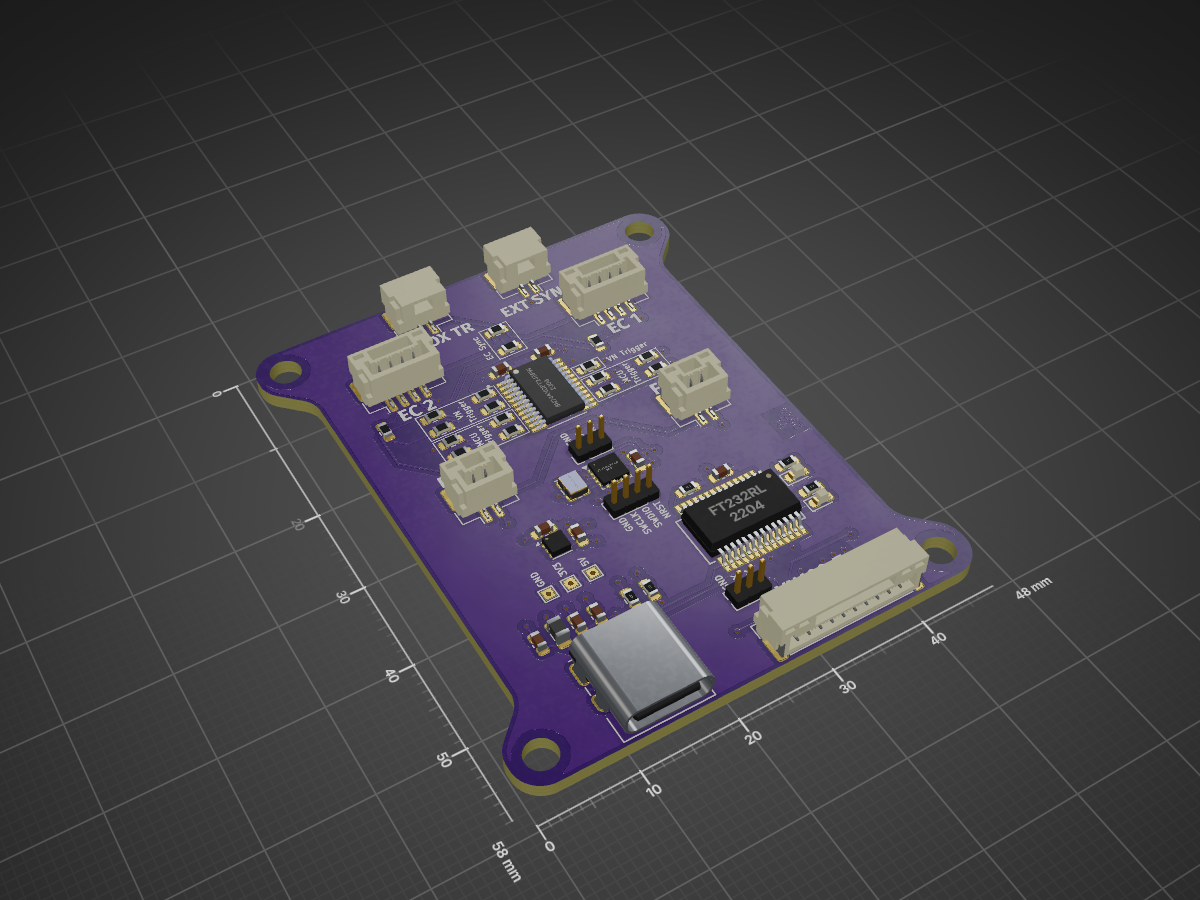
High Altitude Sync Board is an open-source printed circuit board by fcladera, from the fcladera/EvMAPPER repository on GitHub. It is a 4-layer board of 48 × 58 mm with 53 parts on 79 nets, routed with 428 tracks and 57 vias.
It is built around the FT232RL, LP5912-3.3DRVR and BM02B-GHS-TBT, with the BM04B-GHS-TBT, SM02B-GHS-TB and MI0805K400R-10 among its other parts. Its parts include 22 resistors, 11 connectors, 9 capacitors, 4 ICs and 2 diodes. It belongs with the STM32 boards of this library.


This is the source code repository for EvMAPPER, a high altitude orthomapping framework.
CAD: CAD models to attach the sensor stack (EV + RGB + VN100 + range sensor) to the Falcon 4 UAV.PCB: PCB for time synchronization.ha_python_utils: Python utilities for high altitude data processing.Notebooks: Jupyter notebooks for data processing and visualization.You can access our preprint on arXiv, and our video presentation.
@article{cladera2024evmapper,
  title={EvMAPPER: High Altitude Orthomapping with Event Cameras},
  author={Cladera, Fernando and Chaney, Kenneth and Hsieh, M Ani and Taylor, Camillo J and Kumar, Vijay},
  journal={arXiv preprint arXiv:2409.18120},
  year={2024}
}| Qty | Value | Footprint | References |
|---|---|---|---|
| 17 | 0R | Resistor_SMD:R_0603_1608Metric | R3, R4, R5, R6, R7, R8, R11, R12, R13, R14, R15, R16, R19, R20, R21, R22 +1 |
| 5 | 100nF | Capacitor_SMD:C_0603_1608Metric | C1, C2, C3, C5, C7 |
| 3 | 4.7uF | Capacitor_SMD:C_0603_1608Metric | C6, C9, C10 |
| 2 | 1k1 | Resistor_SMD:R_0603_1608Metric | R10, R17 |
| 2 | 5.1k | Resistor_SMD:R_0603_1608Metric | R1, R2 |
| 2 | BM02B-GHS-TBT | Connector_JST:JST_GH_BM02B-GHS-TBT_1x02-1MP_P1.25mm_Vertical | J18, J19 |
| 2 | BM04B-GHS-TBT | Connector_JST:JST_GH_BM04B-GHS-TBT_1x04-1MP_P1.25mm_Vertical | J23, J25 |
| 2 | LED | LED_SMD:LED_0603_1608Metric | D1, D2 |
| 2 | SM02B-GHS-TB | Connector_JST:JST_GH_SM02B-GHS-TB_1x02-1MP_P1.25mm_Horizontal | J2, J20 |
| 1 | 10k | Resistor_SMD:R_0603_1608Metric | R18 |
| 1 | 10nF_X7R | Capacitor_SMD:C_0603_1608Metric | C4 |
| 1 | 3V3 TP | TestPoint:TestPoint_THTPad_1.0x1.0mm_Drill0.5mm | TP3 |
| 1 | 5V TP | TestPoint:TestPoint_THTPad_1.0x1.0mm_Drill0.5mm | TP1 |
| 1 | ECS-2520MV | Oscillator:Oscillator_SMD_ECS_2520MV-xxx-xx-4Pin_2.5x2.0mm | X1 |
| 1 | FT232RL | Package_SO:SSOP-28_5.3x10.2mm_P0.65mm | U2 |
| 1 | GND TP | TestPoint:TestPoint_THTPad_1.0x1.0mm_Drill0.5mm | TP2 |
| 1 | LP5912-3.3DRV | Package_SON:WSON-6-1EP_2x2mm_P0.65mm_EP1x1.6mm_ThermalVias | U3 |
| 1 | MI0805K400R-10 | Inductor_SMD:L_0805_2012Metric | L1 |
| 1 | SN74AXC8T245PWR | Footprints:SOP65P640X120-24N | U1 |
| 1 | STM32L011F3Ux | Package_DFN_QFN:ST_UFQFPN-20_3x3mm_P0.5mm | U4 |
| 1 | SWD | Connector_PinHeader_1.27mm:PinHeader_1x04_P1.27mm_Vertical | J24 |
| 1 | UART | Connector_PinHeader_1.27mm:PinHeader_1x03_P1.27mm_Vertical | J26 |
| 1 | USB_C_Receptacle_USB2.0_14P | Connector_USB:USB_C_Receptacle_GCT_USB4085 | J1 |
| 1 | VN100T-UPDATE | Connector_PinHeader_1.27mm:PinHeader_1x03_P1.27mm_Vertical | J17 |
| 1 | VN100_T_CONN | Connector_JST:JST_GH_SM10B-GHS-TB_1x10-1MP_P1.25mm_Horizontal | J7 |
It measures 48 × 58 mm and has 4 copper layers, 1.57 mm thick.
53 parts, built around the FT232RL, LP5912-3.3DRVR, BM02B-GHS-TBT and BM04B-GHS-TBT. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the fcladera/EvMAPPER repository on GitHub, at the commit this page was made from: the board is PCB/High-Altitude-Sync-Board/High-Altitude-Sync-Board.kicad_pcb and its schematic PCB/High-Altitude-Sync-Board/High-Altitude-Sync-Board.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask fcladera before reusing the design.
axpaul/KinetiCoreDC
Compact STM32G0-based DC motor controller board featuring TI DRV8874 H-bridge drivers, RS485 communication, optoisolated I/O, and hardware power protection.

ekatynski/Test-Stand-Power-Monitor
A small board for cheaply and easily monitoring a motor test stand for a host of data types.

purduerov/X17-Pi-Shield
Custom PCB for Purdue IEEE ROV X17. Board powers the and connects sensors to the Pi


