
2 layers40.9 × 85 mm
Studio mic
Spirit532/studio_mic
A simple, easy to build preamplifier for any true condenser capsule, to make a condenser microphone
63 parts150MIT

 erinjense/raspberrypi-stepper-motor-pcb2
Quad Stepper Motor PCB module for the Raspberry Pi single board computer.
Raspi quad stepper motor module is an open-source printed circuit board by erinjense, from the erinjense/raspberrypi-stepper-motor-pcb repository on GitHub. It is a 2-layer board of 65 × 56 mm with 61 parts on 87 nets, routed with 733 tracks and 84 vias.
It is built around the DRV8821DCAR and M2.5. Its parts include 23 capacitors, 20 resistors, 6 connectors, 3 ICs and 2 switches. It belongs with the robots and motor control and computers and single-board computers boards of this library.
This repository, "raspberrypi-stepper-motor-pcb", includes Open Source Hardware "DESGIN FILES AND GUIDES".
THE "DESIGN FILES AND GUIDES" ARE PROVIDED “AS IS”, WITHOUT WARRANTY OF ANY KIND, EXPRESS OR IMPLIED, INCLUDING BUT NOT LIMITED TO THE WARRANTIES OF MERCHANTABILITY, FITNESS FOR A PARTICULAR PURPOSE AND NONINFRINGEMENT. IN NO EVENT SHALL THE AUTHORS OR COPYRIGHT HOLDERS BE LIABLE FOR ANY CLAIM, DAMAGES OR OTHER LIABILITY, WHETHER IN AN ACTION OF CONTRACT, TORT OR OTHERWISE, ARISING FROM, OUT OF OR IN CONNECTION WITH THE "DESIGN FILES AND GUIDES" OR THE USE OR OTHER DEALINGS IN THE "DESIGN FILES AND GUIDES".
See LICENSE for further details.
NOTE: This is not a Raspberry Pi "HAT" (Hardware Attached Top). A Raspberry Pi "HAT" is a specification by the Raspberry Pi Foundation set out to ensure various modules designed to interface with the Raspberry Pi do not conflict with each other. It is up to the User to ensure that the GPIO pins within this PCB module does not conflict with other modules, "HAT"s or desired use-cases.
See more within: Raspberry Pi HAT Details
This device is under test and not guaranteed to operate within electrical specifications or desired functionality.
✔️ Interfaces to Raspberry Pi, single-board computer, 40W GPIO Connector.
✔️ Drives up to 4 Stepper Motors.
✔️ Step Mode Control Switches.
✔️ Motor Drive Current Limiting Potentiometers.
✔️ Mixed Decay Mode.
✔️ Minimal Raspberry Pi GPIO Pin Usage
✔️ DC Barrel Jack for commonly available power supplies.
✔️ VM Motor Power Supply (DC barrel jack): 8 ~ 32V
✔️ Continuous Motor Output Current: 0 ~ 1.5 A / Motor Set
✔️ Working Temperature: TBD
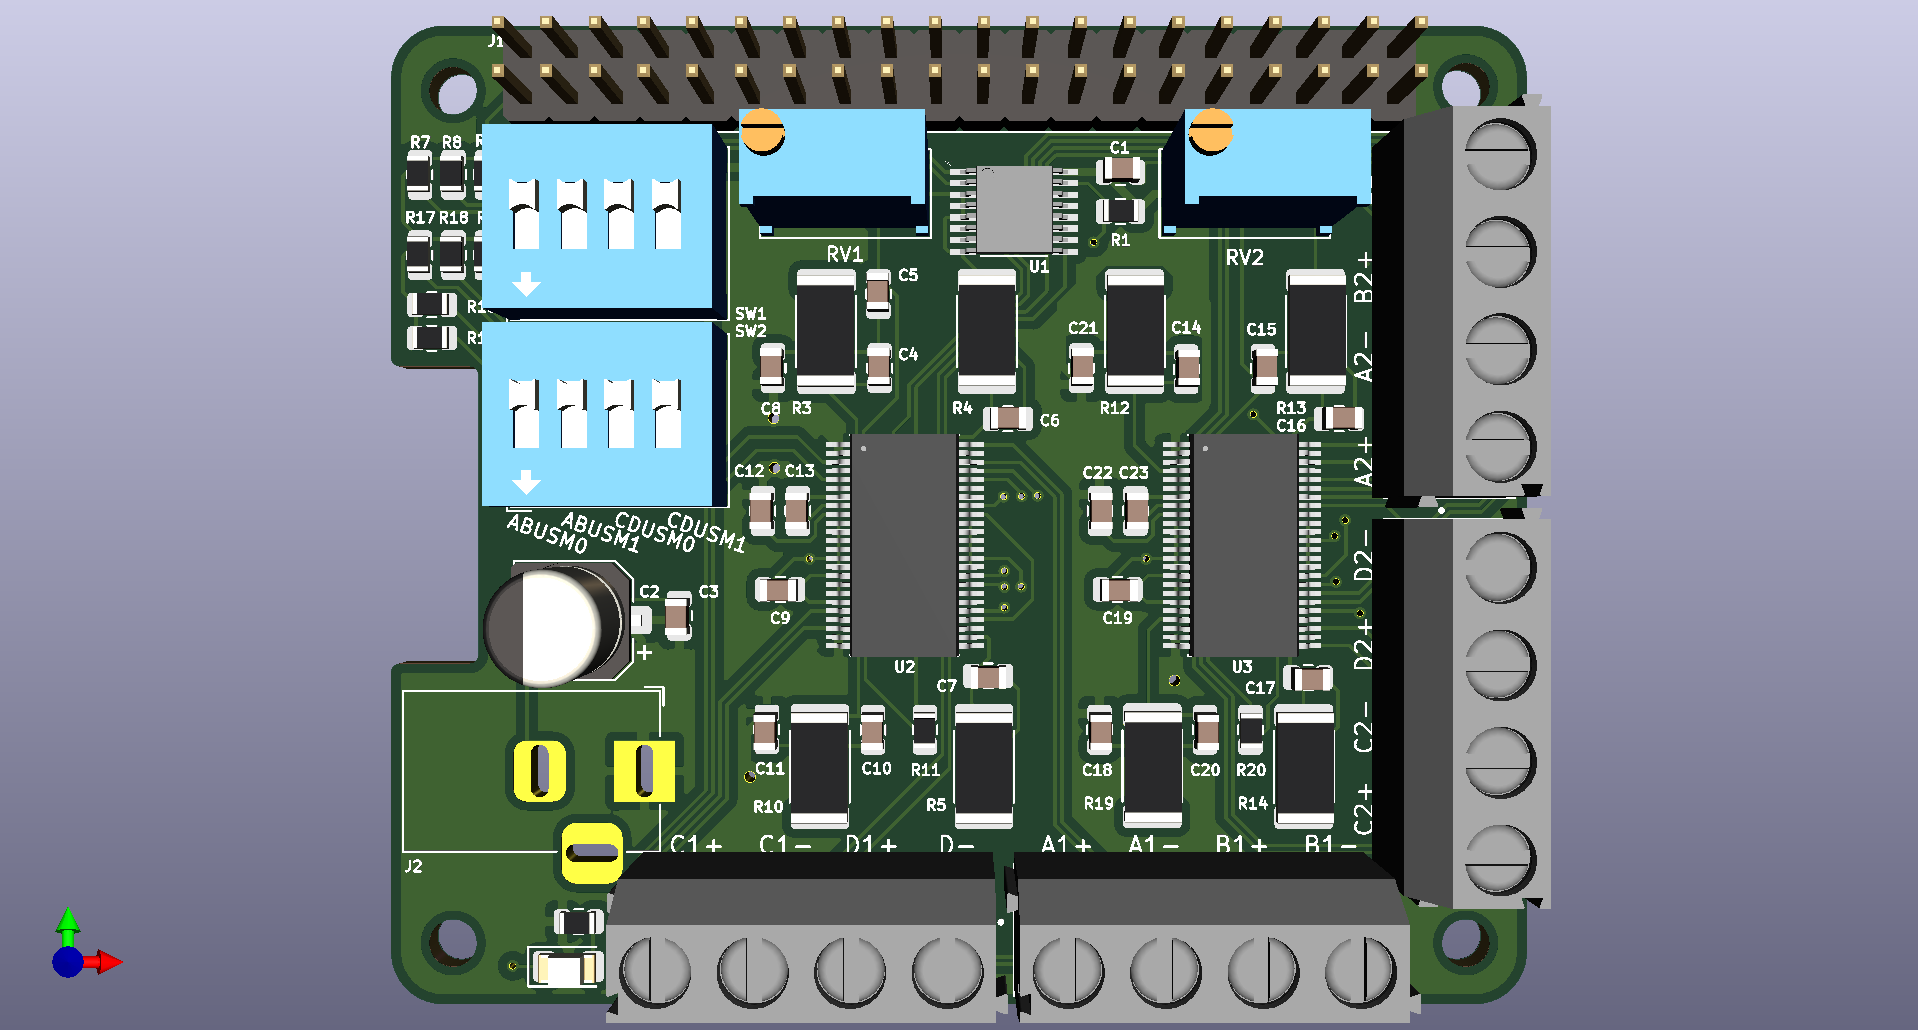
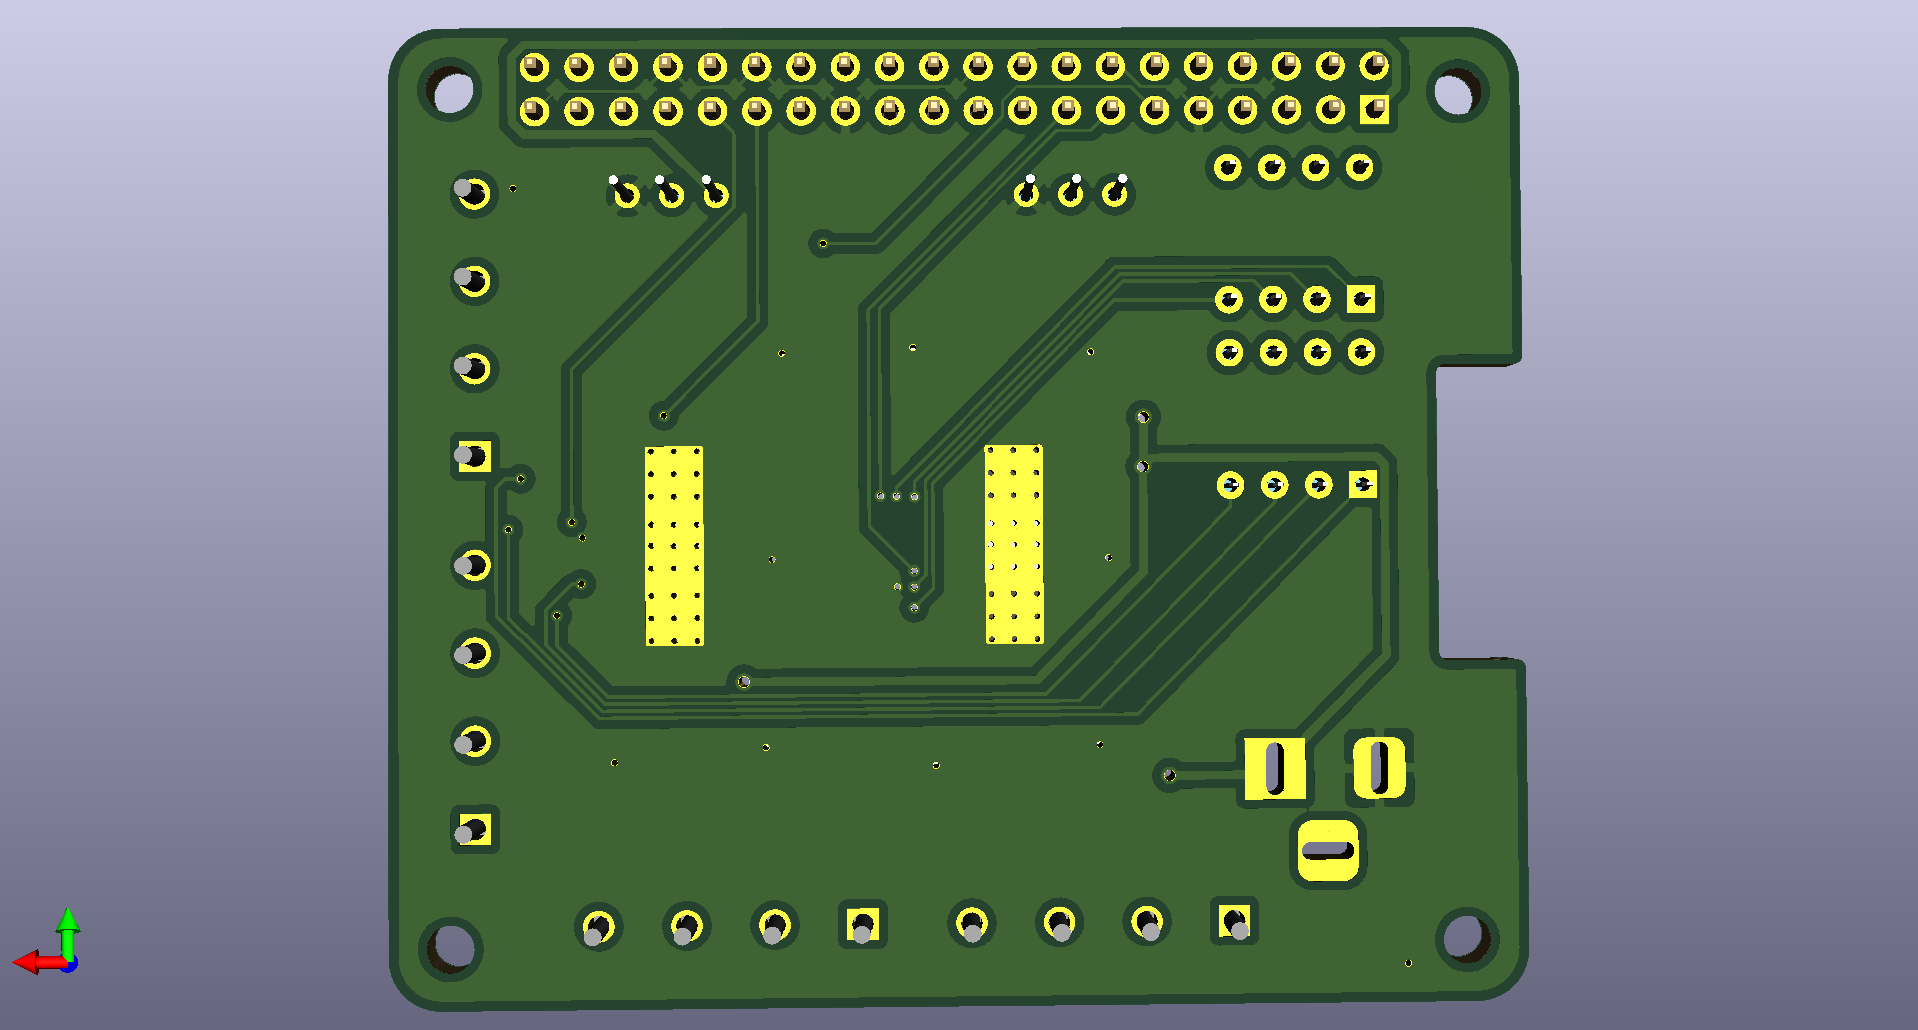
Coming soon...
Coming soon...
This order guide covers the following:
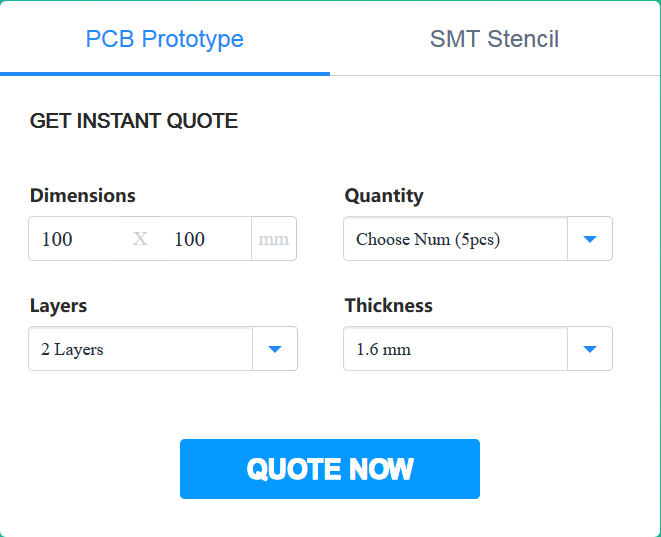
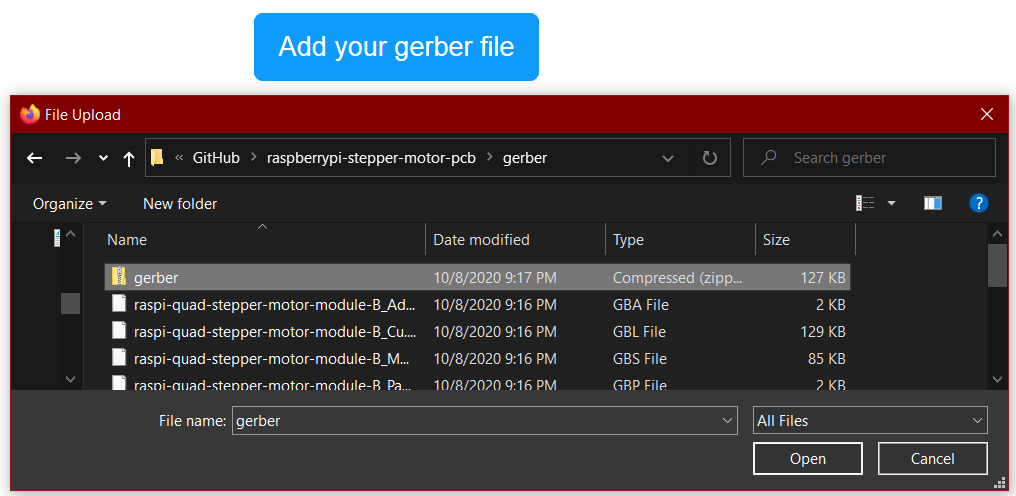
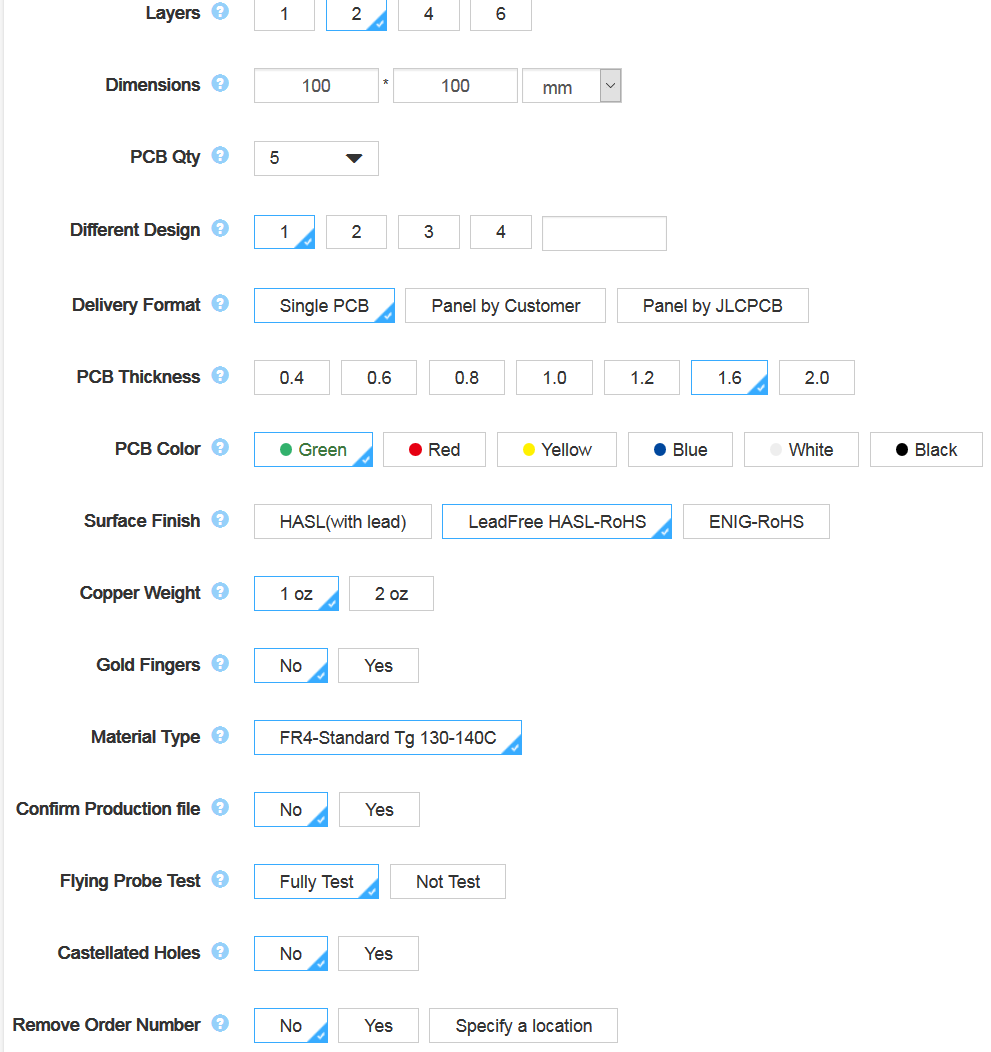
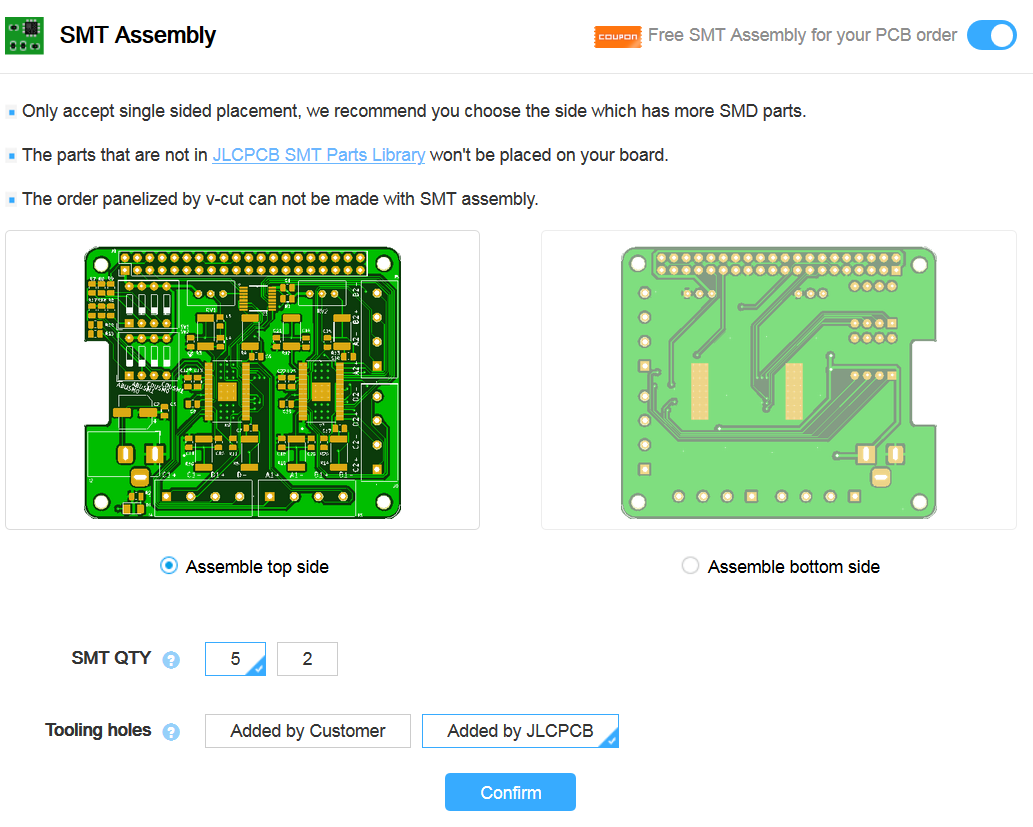
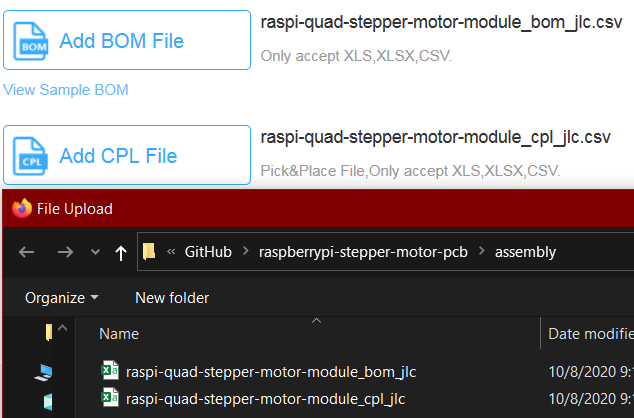
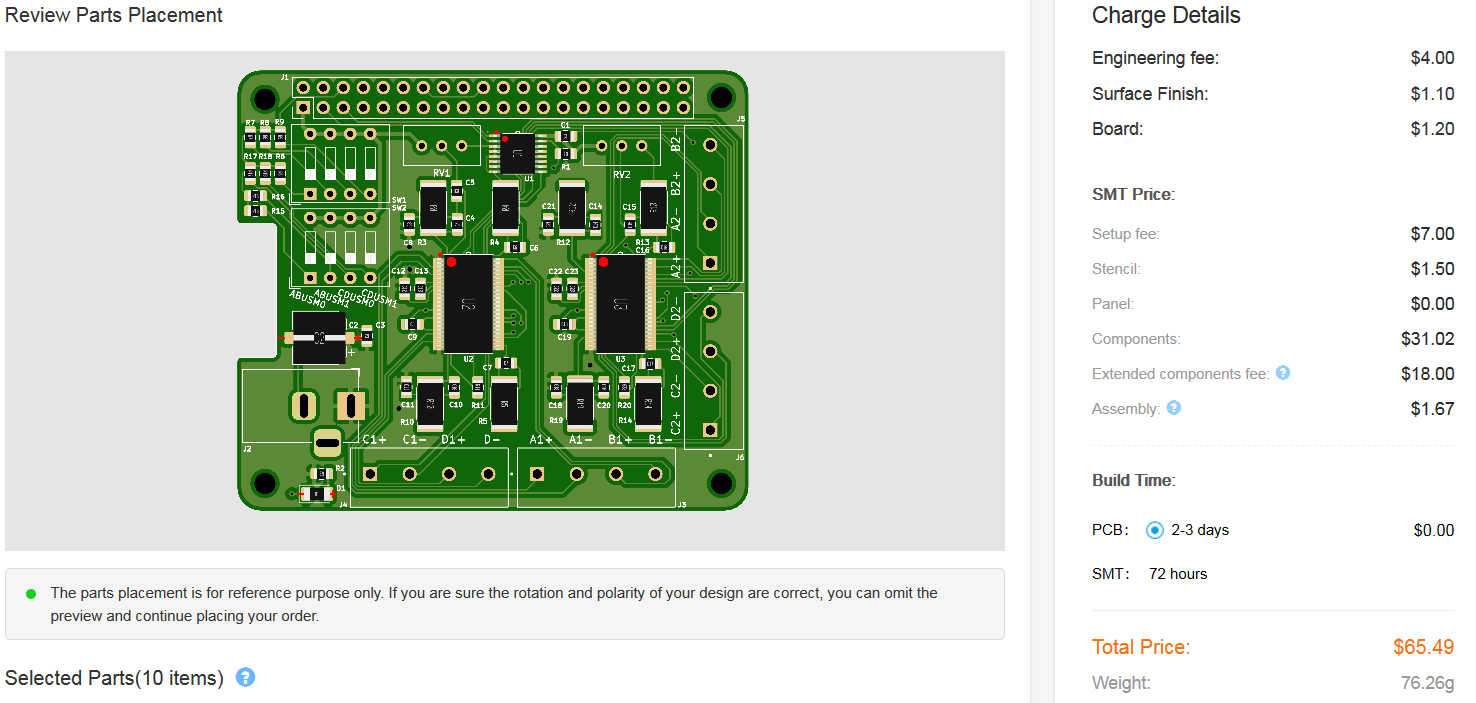
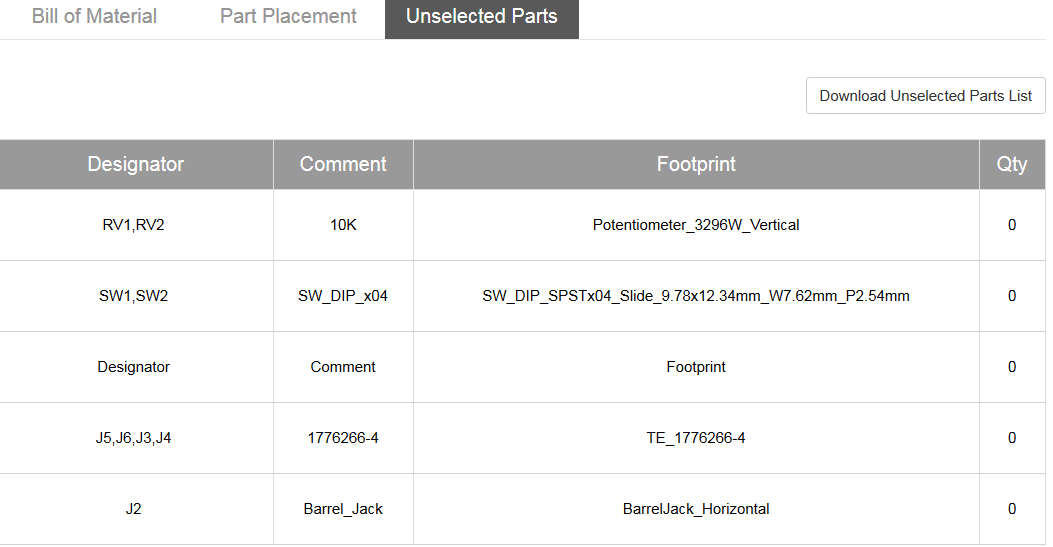
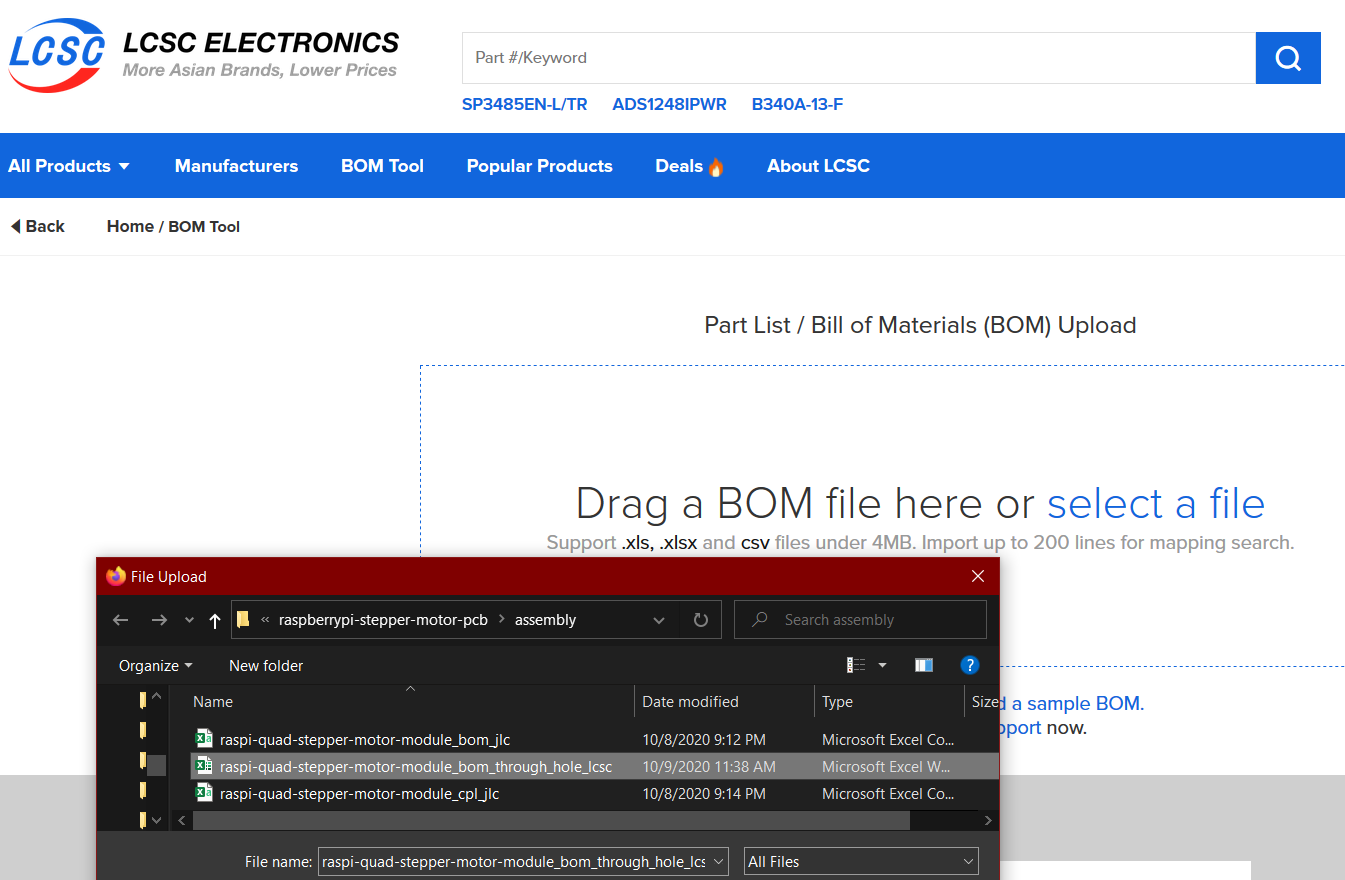
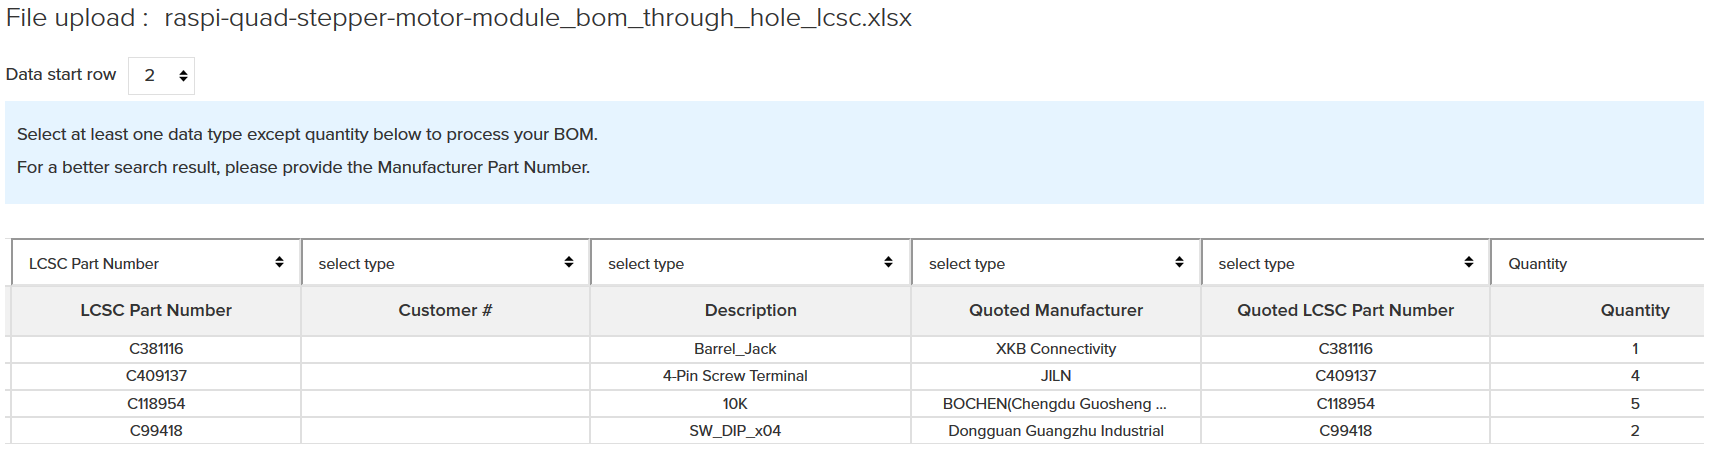
NOTE: If you did not choose SMT assembly on JLCPCB, you will have to order all the components, not just the through-hole parts, by uploading the "raspi-quad-stepper-motor-module_bom_jlc.csv" instead of "raspi-quad-stepper-motor-module_bom_through_hole_lcsc.xlsx".
| Qty | Value | Footprint | References |
|---|---|---|---|
| 17 | 100nF | Capacitor_SMD:C_0805_2012Metric | C1, C4, C5, C6, C7, C10, C11, C12, C14, C15, C16, C17, C18, C20, C21, C22 +1 |
| 11 | 10K | raspi-quad-stepper-motor-module:R_0805_2012Metric | R1, R6, R7, R8, R9, R11, R15, R16, R17, R18, R20 |
| 8 | 0.2 | Resistor_SMD:R_2512_6332Metric | R3, R4, R5, R10, R12, R13, R14, R19 |
| 4 | 1776266-4 | raspi-quad-stepper-motor-module:TE_1776266-4 | J3, J4, J5, J6 |
| 4 | M2.5 | MountingHole:MountingHole_2.7mm_M2.5 | MK1, MK2, MK3, MK4 |
| 2 | 10K | raspi-quad-stepper-motor-module:Potentiometer_3296W_Vertical | RV1, RV2 |
| 2 | 10nF | raspi-quad-stepper-motor-module:C_0805_2012Metric | C13, C23 |
| 2 | 470nF | raspi-quad-stepper-motor-module:C_0805_2012Metric | C9, C19 |
| 2 | DRV8821DCAR | raspi-quad-stepper-motor-module:SOP50P810X120-49N | U2, U3 |
| 2 | SW_DIP_x04 | raspi-quad-stepper-motor-module:SW_DIP_SPSTx04_Slide_9.78x12.34mm_W7.62mm_P2.54mm | SW1, SW2 |
| 1 | 100nF | raspi-quad-stepper-motor-module:C_0805_2012Metric | C3 |
| 1 | 100uF | raspi-quad-stepper-motor-module:CP_Elec_6.3x7.7 | C2 |
| 1 | Barrel_Jack | raspi-quad-stepper-motor-module:BarrelJack_Horizontal | J2 |
| 1 | LED | raspi-quad-stepper-motor-module:LED_1206_3216Metric | D1 |
| 1 | PCA9557PW,118 | raspi-quad-stepper-motor-module:SOP65P640X110-16N | U1 |
| 1 | R_2.2K | raspi-quad-stepper-motor-module:R_0805_2012Metric | R2 |
| 1 | Raspberry_Pi_Header | raspi-quad-stepper-motor-module:PinHeader_2x20_P2.54mm_Vertical | J1 |
Spirit532/studio_mic
A simple, easy to build preamplifier for any true condenser capsule, to make a condenser microphone


gmcn42/clumsyMIDI
A THT-only Raspberry Pi expansion board containing a MIDI interface, DAC, and OLED display

DvidMakesThings/HW_PDNode-600-Pro
The PDNode-600 is a professional-grade, 600W USB Power Delivery Unit designed specifically for compact 10-inch rack systems, targeting embedded developers, homelab enthusiasts, test benches, and smart infrastructure.


Zebra-Rodeo/marelleo
Une boîte qui raconte une histoire quand on pose une figurine dessus. Boîtier, carte, micrologiciel et doc pour la refaire.

dsanchezseco/punk75
Ortholinear keyboard with 75 keys and all components through hole
It measures 65 × 56 mm and has 2 copper layers, 1.6 mm thick.
61 parts, built around the DRV8821DCAR and M2.5. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the erinjense/raspberrypi-stepper-motor-pcb repository on GitHub, at the commit this page was made from: the board is raspi-quad-stepper-motor-module.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask erinjense before reusing the design.