
2 layers100 × 99.8 mm

 eli3162/diw_printer3
Direct ink Writing(DIW) is a technology that enables 3d printers to print many gels, solvents, and other liquids instead of normal plastic filaments. Many printers that have this function can cost from $2,000 up to $20,000, so the goal of this project is to make a low-cost, DIY DIW printer.
Compact stepper controller is an open-source printed circuit board by eli3162, from the eli3162/diw_printer repository on GitHub, published under the GPL-3.0 licence. It is a 4-layer board of 108.4 × 94 mm with 44 parts on 80 nets, routed with 634 tracks and 3 vias.
It is built around the DRV8825PWP. Its parts include 17 connectors, 8 capacitors and 8 switches. It belongs with the robots and motor control boards and the RP2040 boards of this library.
Direct ink Writing(DIW) is a technology that enables 3d printers to print many gels, solvents, and other liquids instead of normal plastic filaments. Many printers that have this function can cost from $2,000 up to $20,000, so the goal of this project is to make a low-cost, DIY DIW printer.
For more information about the software, go here
For more information about the circuit board, go here
For a digital view of the circuit board, go here
| Qty | Value | Footprint | References |
|---|---|---|---|
| 8 | 100µf | Capacitor_THT:CP_Radial_D6.3mm_P2.50mm | C1, C2, C3, C4, C5, C6, C7, C8 |
| 6 | 1x4 Pin | Connector_JST:JST_EH_B4B-EH-A_1x04_P2.50mm_Vertical | J2, J3, J4, J5, J9, J11 |
| 6 | DRV8825 | Module:Pololu_Breakout-16_15.2x20.3mm | A2, A3, A4, A5, A6, A7 |
| 6 | Screw Terminal | TerminalBlock_MetzConnect:TerminalBlock_MetzConnect_Type101_RT01602HBWC_1x02_P5.08mm_Horizontal | J1, J12, J13, J14, J16, J17 |
| 4 | 1x2 Pin | Connector_JST:JST_EH_B2B-EH-A_1x02_P2.50mm_Vertical | J6, J7, J8, J10 |
| 4 | Switch | TerminalBlock_MetzConnect:TerminalBlock_MetzConnect_Type073_RT02603HBLU_1x03_P5.08mm_Horizontal | SW1, SW2, SW3, SW4 |
| 4 | Switch | Button_Switch_THT:SW_CK_JS202011AQN_DPDT_Angled | SW5, SW6, SW7, SW8 |
| 1 | Conn_01x06_Pin | Connector_Molex:Molex_KK-254_AE-6410-06A_1x06_P2.54mm_Vertical | J15 |
| 1 | Raspberry Pi Pico 2 W | Module:RaspberryPi_Pico_Common_THT | Raspberry Pi Pico |
The 40 most common of 44 parts.
It measures 108.4 × 94 mm and has 4 copper layers, 1.6 mm thick.
44 parts, built around the DRV8825PWP. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the eli3162/diw_printer repository on GitHub, at the commit this page was made from: the board is pcb/compact_stepper_controller/compact_stepper_controller.kicad_pcb and its schematic pcb/compact_stepper_controller/compact_stepper_controller.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the GPL-3.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).

mathias31415/diy_robotics
Gripper, PCBs and ROS2 software for Six-Axis Robot Arm WE-R2.4 from LoboCNC

o7-machinehum/Hydroponic
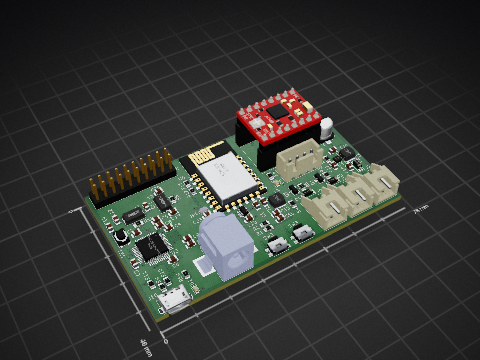
Please find the electronics files in the ee folder, all pcb design is done with the open source software KiCad. Is uses an STM32 as the main controller, and an ST L6470 moter driver for the stepper motor.


