4 layers160.4 × 76.9 mm
Smartswitch board
Arhamee/hardware-portfolio
Multi-layer PCB designs in KiCad 10 schematic capture to fabrication-ready Gerbers. High-speed routing, BGA escape, power electronics.
116 partsMIT

 aryan-asit/flight-controller
This is a flight controller for model rocket.
Flight1 is an open-source printed circuit board by aryan-asit, from the aryan-asit/flight-controller repository on GitHub. It is a 2-layer board of 63 × 64.5 mm with 61 parts on 71 nets, routed with 701 tracks and 103 vias.
It is built around the ESP32-WROOM-32E, LM2596S-5.0 and BMP388, with the AOD4184A, SS8050 and AMS1117 among its other parts. Its parts include 20 resistors, 14 capacitors, 5 connectors, 4 diodes and 4 transistors. It belongs with the robots and motor control boards and the ESP32 boards of this library.


# Model Rocket Flight Controller
A compact 2-layer flight controller PCB designed for model rocket applications.
## PCB Preview
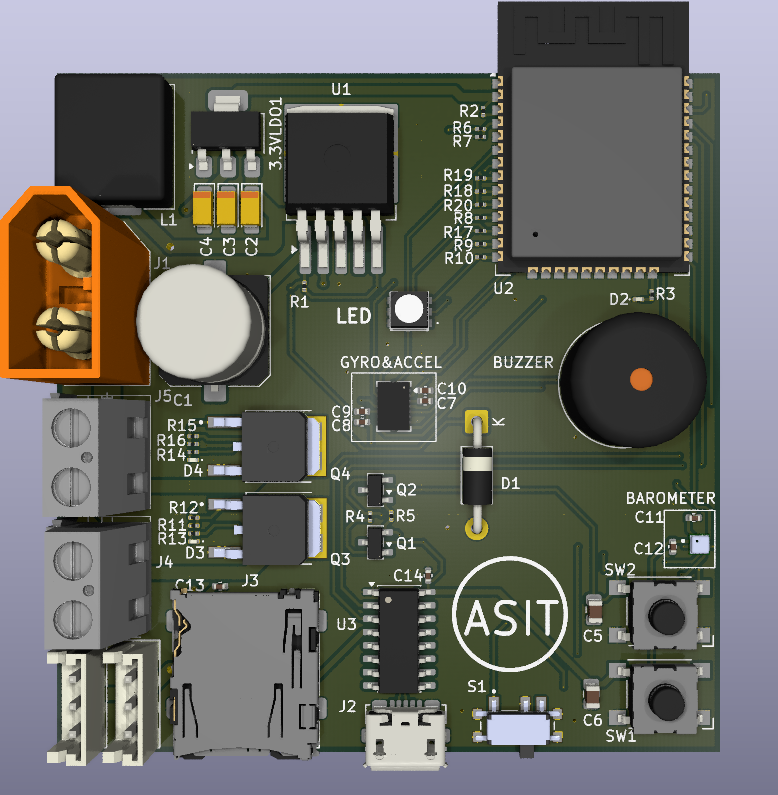
## Overview
This project is a small form-factor flight controller designed for model rockets.
The main goal was to fit the required sensors, microcontroller, power and control
interfaces onto a compact 2-layer PCB.
The board is approximately **6 × 6 cm**, making it suitable for applications where
PCB space is limited.
## Main Components
- **ESP32-WROOM-32E** – Main microcontroller
- **BMI088** – 6-axis IMU with gyroscope and accelerometer
- **Bosch BMP388** – Barometric pressure sensor for altitude measurement
- **USB interface** – Dedicated USB connection for programming and controlling the ESP32
- **Buzzer** – Audible indication
- **Status LED** – Board status indication
- **Push buttons** – User input and control
- **Power and peripheral connectors**
## PCB Specifications
| Parameter | Details |
|---|---|
| PCB Type | 2-Layer |
| Board Size | ~60 × 60 mm |
| Microcontroller | ESP32-WROOM-32E |
| IMU | BMI088 |
| Barometer | Bosch BMP388 |
| USB | Dedicated USB interface |
| PCB Design Tool | KiCad |
## Design
The ESP32 is used as the main controller of the board. The BMI088 provides
acceleration and gyroscope data, while the BMP388 is used for pressure and
altitude-related measurements.
A dedicated USB interface is included for programming and direct communication
with the ESP32.
The PCB was designed with a focus on keeping the board compact while still
providing the required sensors, connectors and control interfaces.
## Repository Contents
flight-controller/

│

├── flight1/

│   ├── flight1.kicad\_pro

│   ├── flight1.kicad\_sch

│   └── flight1.kicad\_pcb

│

├── schematic file/

├── symbols and footprints/

├── images/

│   └── Screenshot 2026-09-24 230031.png

│
| Qty | Value | Footprint | References |
|---|---|---|---|
| 8 | 10K | Resistor_SMD:R_0201_0603Metric | R1, R2, R4, R5, R17, R18, R19, R20 |
| 5 | 100NF | Capacitor_SMD:C_0402_1005Metric | C7, C8, C11, C12, C13 |
| 4 | 220 OHM | Resistor_SMD:R_0201_0603Metric | R12, R13, R14, R15 |
| 3 | LED | LED_SMD:LED_0201_0603Metric | D2, D3, D4 |
| 2 | 100UF | Capacitor_SMD:C_0805_2012Metric | C5, C6 |
| 2 | 10UF | Capacitor_SMD:C_0402_1005Metric | C9, C10 |
| 2 | 2.2k OHM | Resistor_SMD:R_0201_0603Metric | R11, R16 |
| 2 | 33 OHM | Resistor_SMD:R_0201_0603Metric | R9, R10 |
| 2 | AOD4184A | AOD4184A:DPAK228P994X240-4N | Q3, Q4 |
| 2 | Conn_01x03 | Connector_JST:JST_EH_B3B-EH-A_1x03_P2.50mm_Vertical | TVC-Y1, TVC-Z1 |
| 2 | SS8050 | Package_TO_SOT_SMD:SOT-23 | Q1, Q2 |
| 2 | SW_Omron_B3FS | Button_Switch_SMD:SW_SPST_Omron_B3FS-101xP | SW1, SW2 |
| 2 | Screw_Terminal_01x02 | TerminalBlock:TerminalBlock_MaiXu_MX126-5.0-02P_1x02_P5.00mm | J4, J5 |
| 1 | 100UF | Capacitor_SMD:C_0402_1005Metric | C14 |
| 1 | 10UF | Capacitor_Tantalum_SMD:CP_EIA-3216-12_Kemet-S_HandSolder | C3 |
| 1 | 120 OHM | Resistor_SMD:R_0201_0603Metric | R8 |
| 1 | 150353M153300 | KiCad1:150353M153300 | LED |
| 1 | 1N5818 | Diode_THT:D_DO-41_SOD81_P10.16mm_Horizontal | D1 |
| 1 | 20K | Resistor_SMD:R_0201_0603Metric | R6 |
| 1 | 220 | Resistor_SMD:R_0201_0603Metric | R3 |
| 1 | 220UF | Capacitor_Tantalum_SMD:CP_EIA-3216-12_Kemet-S_HandSolder | C2 |
| 1 | 22UF | Capacitor_Tantalum_SMD:CP_EIA-3216-12_Kemet-S_HandSolder | C4 |
| 1 | 3.3K | Resistor_SMD:R_0201_0603Metric | R7 |
| 1 | 33UH | Inductor_SMD:L_Chilisin_BMRF00101040 | L1 |
| 1 | 680UF | Capacitor_SMD:C_Elec_10x10.2 | C1 |
| 1 | AMS1117 | Package_TO_SOT_SMD:SOT-223-3_TabPin2 | 3.3VLDO1 |
| 1 | BMI088 | Package_LGA:Bosch_LGA-16_4.5x3mm_P0.5mm_LayoutBorder7x1y_ClockwisePinNumbering | GYRO&ACCEL |
| 1 | BMP388 | BMP388:XDCR_BMP388 | BAROMETER |
| 1 | Buzzer | Buzzer_Beeper:Buzzer_12x9.5RM7.6 | BUZZER |
| 1 | ESP32-WROOM-32E | RF_Module:ESP32-WROOM-32E | U2 |
| 1 | LM2596S-5 | Package_TO_SOT_SMD:TO-263-5_TabPin3 | U1 |
| 1 | MSK12C02 | MSK12C02:SW_MSK12C02 | S1 |
| 1 | Micro_SD_Card | Connector_Card:microSD_HC_Molex_47219-2001 | J3 |
| 1 | USB PORT | Connector_USB:USB_Micro-B_Molex_47346-0001 | J2 |
| 1 | USB-UART CH340C | Package_SO:SOIC-16_3.9x9.9mm_P1.27mm | U3 |
| 1 | XT60-M | XT60-M:AMASS_XT60-M | J1 |
It measures 63 × 64.5 mm and has 2 copper layers, 1.6 mm thick.
61 parts, built around the ESP32-WROOM-32E, LM2596S-5.0, BMP388 and AOD4184A. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the aryan-asit/flight-controller repository on GitHub, at the commit this page was made from: the board is flight1/flight1.kicad_pcb and its schematic flight1/Microproc_esp32.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask aryan-asit before reusing the design.
Arhamee/hardware-portfolio
Multi-layer PCB designs in KiCad 10 schematic capture to fabrication-ready Gerbers. High-speed routing, BGA escape, power electronics.

zaidh-mech/PROJECTS
Engineering, robotics, embedded systems, CAD, and PCB projects


ChladpavPy/Super3DMaker
So first I want to explain, why I started this project. I had an old Profi3DMaker 3D printer at home, which was not used for a long time, mainly because of the hardware, which was just outdated.

pms67/HadesFCS
Complete flight control system designed from scratch. Hardware designed with KiCad.

felixznr/ALBERT
Albert I was a rhesus macaque monkey and the first mammal launched on a rocket (V-2 Rocket "Blossom No. 3") on June 18, 1948.

