
4 layers40 × 20 mm
Grove - Vision AI Module V2
aram-ap/daredevil
Computer Vision-Based Tactile Feedback for the Visually Impaired
114 parts3MIT

 aram-ap/daredevil3
Computer Vision-Based Tactile Feedback for the Visually Impaired
Wrist module is an open-source printed circuit board by aram-ap, from the aram-ap/daredevil repository on GitHub, published under the MIT licence. It is a 2-layer board of 59 × 48 mm with 30 parts on 27 nets, routed with 183 tracks and 8 vias.
It is built around the ULN2003A. Its parts include 6 diodes, 6 connectors, 5 resistors, 3 capacitors and 2 ICs. It belongs with the ESP32 and RISC-V boards of this library.
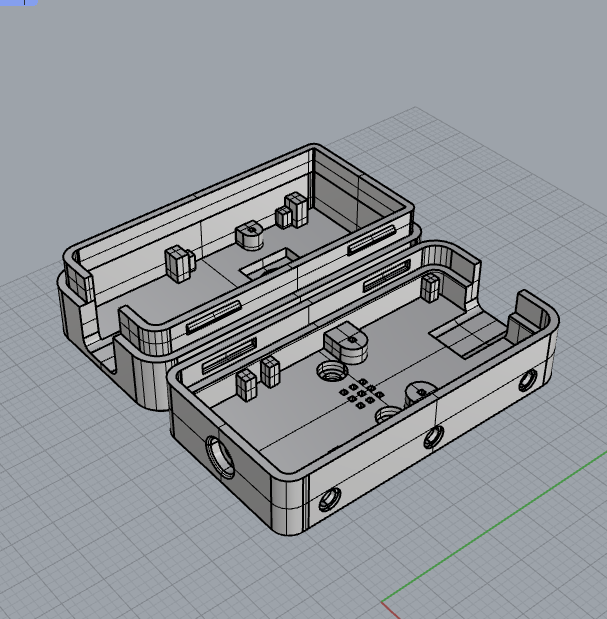
This is the library for Grove Vision AI V2 and its case.

You can find the case here as well.
You can refer to this link to download the KiCad software.
You can download the "OPL_KiCad_Library" or use command to clone:
git clone https://github.com/Seeed-Studio/OPL_Kicad_Library.git
File -> Open Project.


Perferences -> Manage Footprint Libraries


Now you have added the "XIAO footprint library"


File -> Open Project.

Perferences -> Manage Symbol Libraries


Now you have added the "OPL_Sensor-Transducer library"


Seeed Studio Fusion serves as the comprehensive service platform for Seeed Studio, a global one-stop online platform offering PCB manufacturing, PCB assembly and hardware customization with global sourcing capability. Whether you need prototyping, mass production, custom solutions for open-source products, or the transformation of your creative ideas into profitable products, Seeed Studio Fusion can meet your requirements.
Leverage our Co-Create Program to transform your advanced prototype into a commercially successful product! This program is designed to optimize your product's journey from prototype to market by handling marketing, packaging, and distribution, allowing you to concentrate on refining your product. Upon acceptance of your prototype by Seeed, it will be showcased on the Seeed Studio marketplace. You'll receive a portion of the profits for each unit sold.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 5 | 1N5819 | Diode_THT:D_DO-41_SOD81_P10.16mm_Horizontal | D1, D3, D4, D5, D6 |
| 4 | MountingHole | MountingHole:MountingHole_2.2mm_M2_ISO7380 | H1, H2, H3, H4 |
| 2 | 0.1uF | Capacitor_THT:C_Disc_D3.8mm_W2.6mm_P2.50mm | C2, C3 |
| 2 | 100k | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R6, R7 |
| 2 | 10k | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R5, R8 |
| 1 | 100uF | Capacitor_THT:CP_Radial_D8.0mm_P2.50mm | C1 |
| 1 | 180 | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R1 |
| 1 | BATT CONN | Connector_JST:JST_PH_B2B-PH-K_1x02_P2.00mm_Vertical | J1 |
| 1 | MOT 1 | Connector_JST:JST_PH_B2B-PH-K_1x02_P2.00mm_Vertical | J3 |
| 1 | MOT 2 | Connector_JST:JST_PH_B2B-PH-K_1x02_P2.00mm_Vertical | J4 |
| 1 | MOT 3 | Connector_JST:JST_PH_B2B-PH-K_1x02_P2.00mm_Vertical | J5 |
| 1 | MOT 4 | Connector_JST:JST_PH_B2B-PH-K_1x02_P2.00mm_Vertical | J6 |
| 1 | MOT 5 | Connector_JST:JST_PH_B2B-PH-K_1x02_P2.00mm_Vertical | J7 |
| 1 | PWR LED | LED_THT:LED_D5.0mm | D2 |
| 1 | PWR SW | Connector_JST:JST_PH_B3B-PH-K_1x03_P2.00mm_Vertical | SW2 |
| 1 | TOGG BTN | Button_Switch_THT:SW_PUSH_6mm | SW1 |
| 1 | TestPoint_THTPad_1.5x1.5mm_Drill0.7mm | TestPoint:TestPoint_THTPad_1.5x1.5mm_Drill0.7mm | T1 |
| 1 | TestPoint_THTPad_D1.5mm_Drill0.7mm | TestPoint:TestPoint_THTPad_D1.5mm_Drill0.7mm | T2 |
| 1 | ULN2003A | Package_DIP:DIP-16_W7.62mm_LongPads | U2 |
| 1 | XIAO ESP32C3 | XIAO Library:XIAO-ESP32-C3-DIP-SMD | U1 |
aram-ap/daredevil
Computer Vision-Based Tactile Feedback for the Visually Impaired

aram-ap/daredevil
Computer Vision-Based Tactile Feedback for the Visually Impaired

aram-ap/daredevil
Computer Vision-Based Tactile Feedback for the Visually Impaired

aram-ap/daredevil
Computer Vision-Based Tactile Feedback for the Visually Impaired


aram-ap/daredevil
Computer Vision-Based Tactile Feedback for the Visually Impaired


dbalsom/arduinoX86
An interface between an Arduino Due or Arduino GIGA and 8088, 8086, V20, V30, 186 or 286 CPUs

fehlfarbe/arduino-motorfocus
Arduino motorfocus with moonlite protocol for telescopes

Scottapotamas/zaphod-bot
A DIY high performance delta-bot for fun, and lightpainting...

AllYarnsAreBeautiful/ayab-hardware
Contains the schematics and layouts for the AYAB Arduino shield


codingcatgirl/split-flap-fae-pcb
Alternative drop-in replacement PCB for David Kingsman's split-flap display

palazzol/CyberamicControlCenter
Repo for docs and info about the Cyberamic Control Center
It measures 59 × 48 mm and has 2 copper layers, 1.6 mm thick.
30 parts, built around the ULN2003A. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the aram-ap/daredevil repository on GitHub, at the commit this page was made from: the board is hardware/wrist_module/wrist_module.kicad_pcb and its schematic hardware/wrist_module/Library/OPL_Kicad_Library-master/Grove Vision AI V2 Library/Grove - Vision AI Module V2.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).