4 layers29 × 50.3 mm
Lg hvac esp32
JanM321/esphome-lg-controller
Wired controller for LG HVAC units using ESPHome and ESP32
15 parts2920BSD

 aggeazagge/cppIHardlyKnowHer
A school project building autonomous vehicles that drive themselves along a walled track about 1 m wide. The firmware is written in MicroPython for an ESP32-family board.
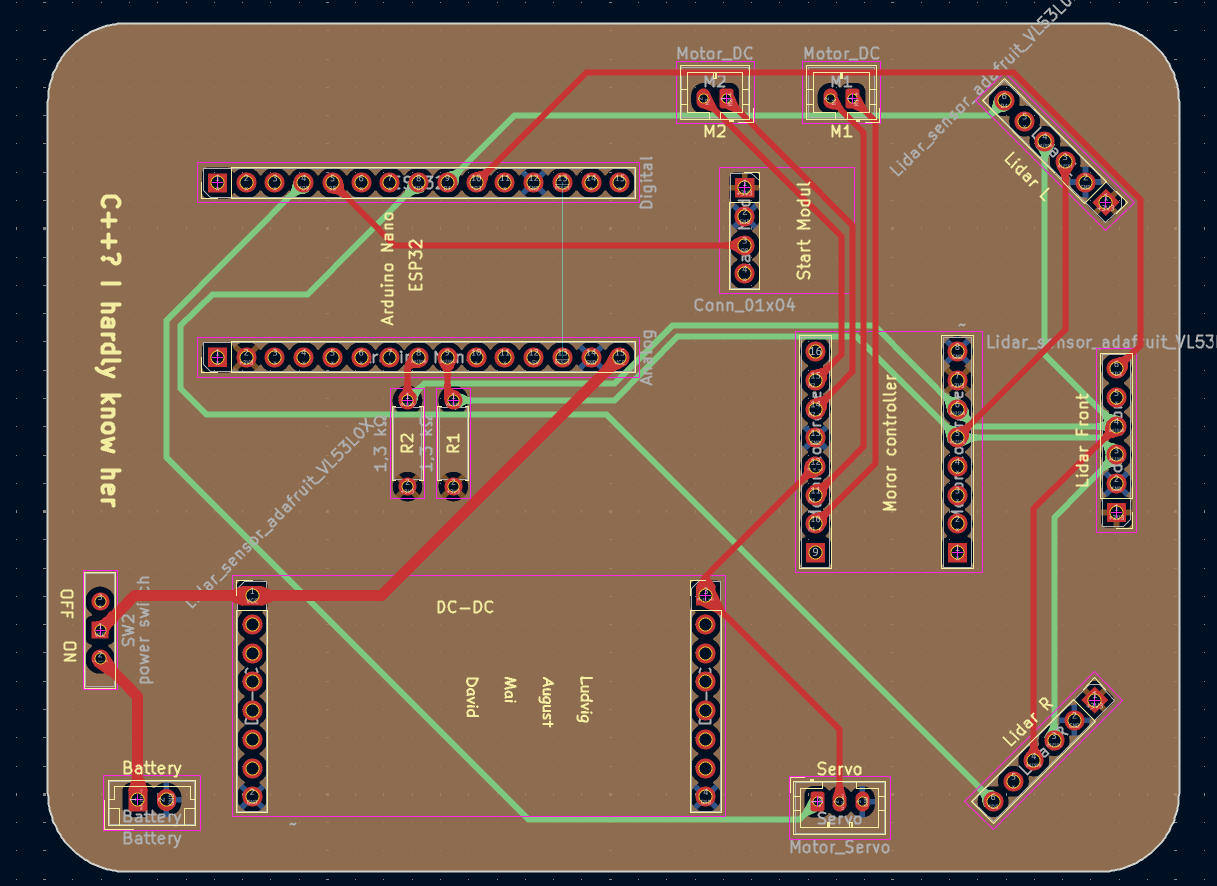
Self driving car is an open-source printed circuit board by aggeazagge, from the aggeazagge/cppIHardlyKnowHer repository on GitHub, published under the MIT licence. It is a 4-layer board of 100 × 75 mm with 15 parts on 43 nets, routed with 74 tracks and 0 vias.
Its parts include 2 resistors and 1 switch.
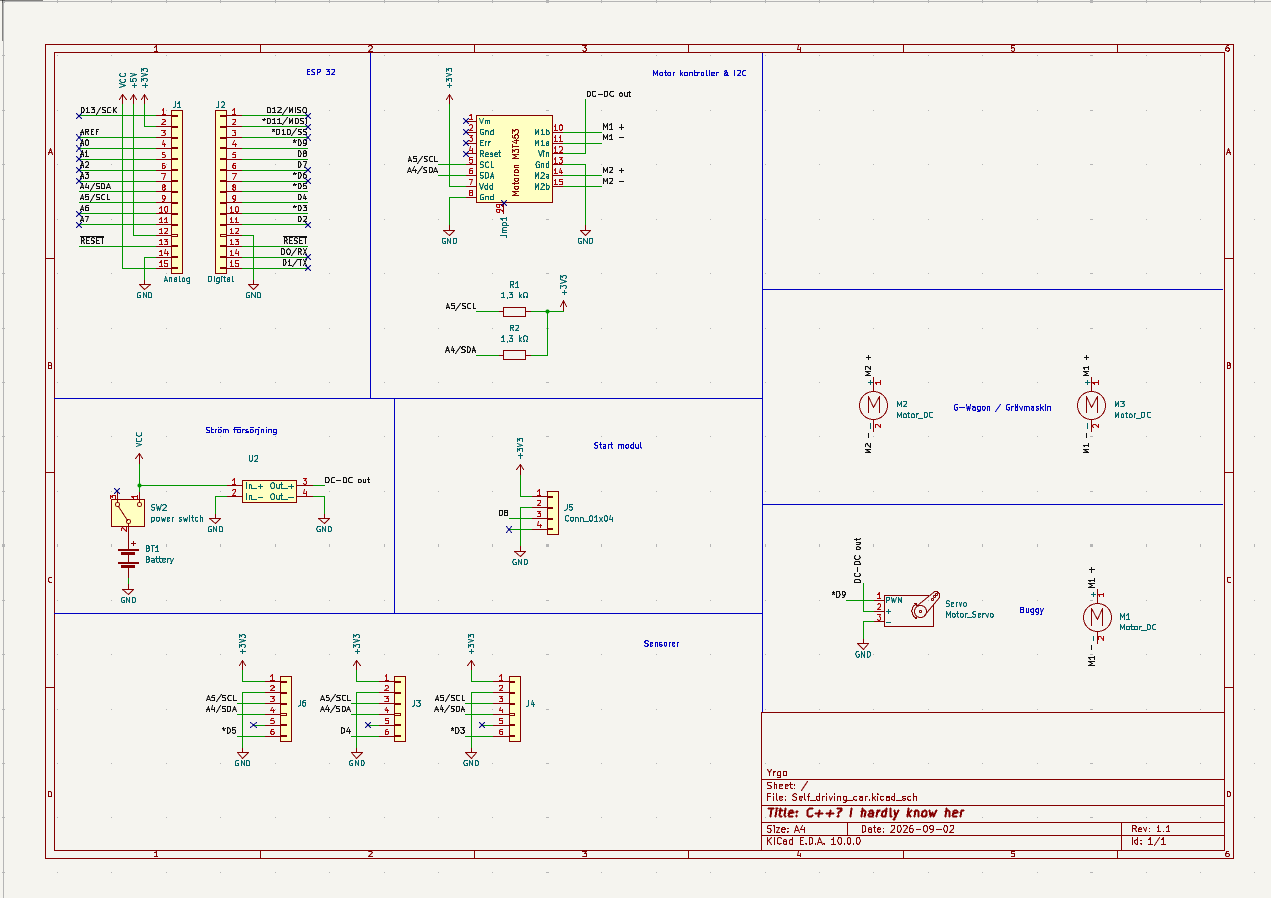
A school project building autonomous vehicles that drive themselves along a walled track about 1 m wide. The firmware is written in MicroPython for an ESP32-family board. Each vehicle uses three time-of-flight distance sensors to stay centered between the walls, a Pololu Motoron motor controller, and a start module that tells it when to go.
| Folder | Vehicle | Description |
|---|---|---|
| snok_1.2 | RC car | Ackermann steering with a servo and one drive motor. Detects when it is stuck and reverses out |
| huggorm_1.0 | Tracked chassis | Excavator with two tracks, steers by the speed difference between them |
Each folder is a complete firmware. To run one, copy its config.py, main.py
and lib/ to the board, for example with Thonny. All tunable values are in config.py.
Kicad/Bil v 1,0 contains the KiCad project for the
car's circuit board: the schematic, the PCB layout, and the custom symbol
libraries (Auto_car_library, motron_i2c_3motor).
See LICENSE.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 3 | Lidar_sensor_adafruit_VL53L0X | Connector_PinHeader_2.54mm:PinHeader_1x06_P2.54mm_Vertical | Lidar Front, Lidar L, Lidar R |
| 2 | 1,3 kΩ | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R1, R2 |
| 2 | Motor_DC | Connector_JST:JST_PH_B2B-PH-K_1x02_P2.00mm_Vertical | M1, M2 |
| 1 | Analog | Connector_PinHeader_2.54mm:PinHeader_1x15_P2.54mm_Vertical | Arduino Nano |
| 1 | Battery | Connector_JST:JST_EH_B2B-EH-A_1x02_P2.50mm_Vertical | Battery |
| 1 | Conn_01x04 | Connector_PinSocket_2.54mm:PinSocket_1x04_P2.54mm_Vertical | Start Modul |
| 1 | Digital | Connector_PinHeader_2.54mm:PinHeader_1x15_P2.54mm_Vertical | ESP32 |
| 1 | Motor_Servo | Connector_JST:JST_PH_B3B-PH-K_1x03_P2.00mm_Vertical | Servo |
| 1 | power switch | Button_Switch_THT:SW_Slide-03_Wuerth-WS-SLTV_10x2.5x6.4_P2.54mm | SW2 |
| 1 | ~ | Auto_car:DC_DC | DC-DC |
| 1 | ~ | Auto_car:Motron motorcontroller 2 motor | Moror controller |
It measures 100 × 75 mm and has 4 copper layers, 1.6 mm thick.
15 parts. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the aggeazagge/cppIHardlyKnowHer repository on GitHub, at the commit this page was made from: the board is Hardware/Self_driving_car_kicad/Self_driving_car.kicad_pcb and its schematic Hardware/Self_driving_car_kicad/Self_driving_car.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).
JanM321/esphome-lg-controller
Wired controller for LG HVAC units using ESPHome and ESP32


niklasekstrom/clockport_pi_interface
Amiga clock port to Raspberry Pi interface

RoboticsBrno/RB0005-UniversalStepDown
Universal step-down module

OpenDevicePartnership/pico-de-gallo
A tool for testing Embedded Rust drivers for discrete I2C/SPI components.
