2 layers
Tinyrobo even smaller
ab3nd/TinyRobo
Hardware and software for a tiny robot platform based on the ESP-8266 WiFi modules and hacked children's toys.
31 parts2
 ab3nd/TinyRobo2
Hardware and software for a tiny robot platform based on the ESP-8266 WiFi modules and hacked children's toys.
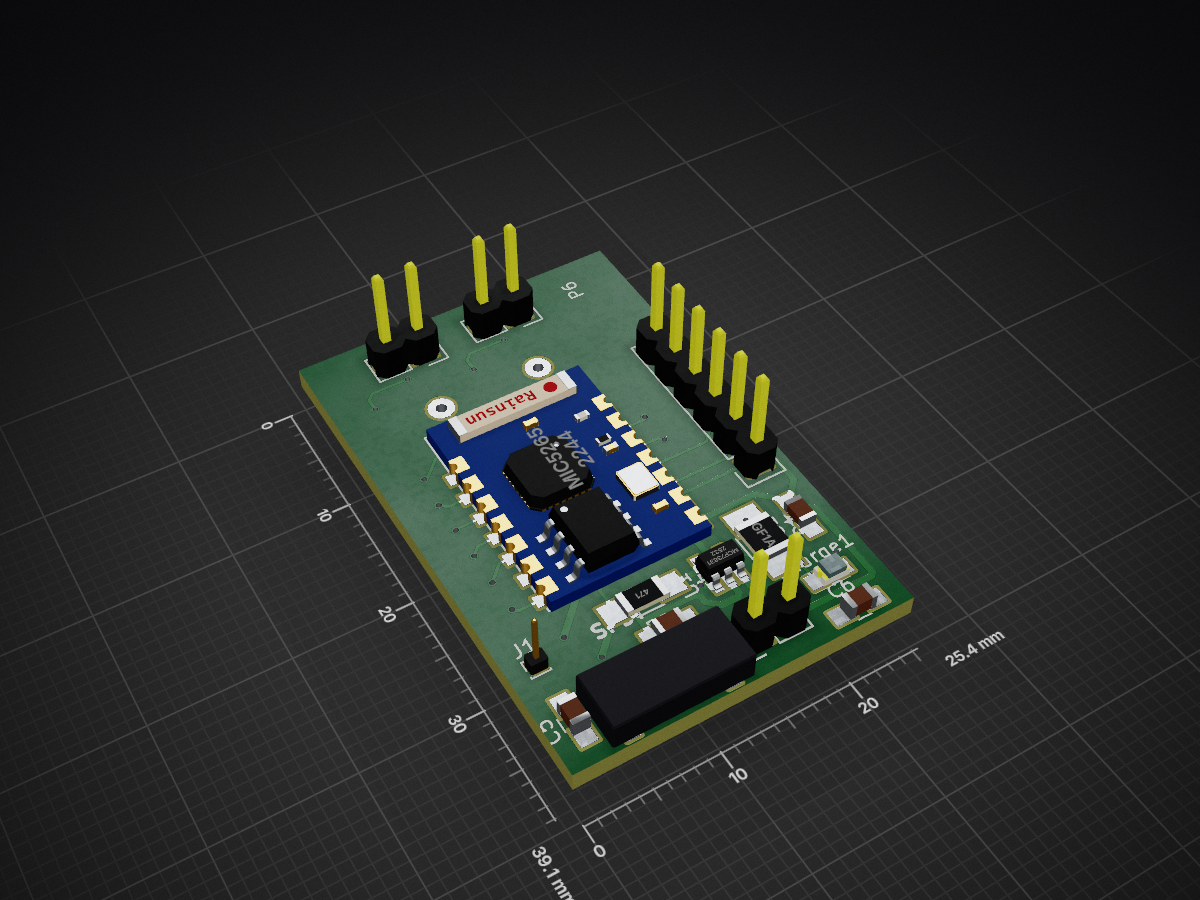
Tiny robo v2 is an open-source printed circuit board by ab3nd, from the ab3nd/TinyRobo repository on GitHub. It is a 2-layer board of 25.4 × 39.1 mm with 34 parts on 28 nets, routed with 239 tracks and 25 vias.
It is built around the DRV8830DRC, MCP73831 and GF1A. Its parts include 12 resistors, 7 connectors, 6 capacitors, 5 ICs and 1 diode. It belongs with the radio and wireless boards and the ESP8266 boards of this library.


Hardware and software for a tiny robot platform based on the ESP-8266 WiFi modules and hacked children's toys.
git clone https://github.com/ab3nd/TinyRobo
cd TinyRobo/software/catkin_ws/
sudo apt-get install libmagick++-dev
sudo ln -s /usr/include/ImageMagick-6/ /usr/include/ImageMagick
sudo apt-get install libmagickcore-dev
sudo apt-get install libmagickwand-6.q16-2
sudo apt-cache search libMagick++
sudo apt-get install libmagick++-6.q16-5v5
sudo apt-get install libmagick++-6.q16-dev libmagickcore-dev libmagick++-dev
sudo ln -s /usr/lib/x86_64-linux-gnu/libMagickCore-6.Q16.so /usr/lib/x86_64-linux-gnu/libMagickCore.so
sudo ln -s /usr/lib/x86_64-linux-gnu/libMagick++-6.Q16.so /usr/lib/x86_64-linux-gnu/libMagick++.so
I've recently switched to using http://wiki.ros.org/aruco_detect (although https://github.com/pal-robotics/aruco_ros can probably do a lot of the same things). When I remove my attempt at making a simulator and my modded version of APRIL tags, the dependencies of this section will change a lot.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 6 | 10k | Resistors_SMD:R_1206_HandSoldering | R1, R3, R5, R6, R9, R12 |
| 3 | 0.1uF | Capacitors_SMD:C_0805_HandSoldering | C3, C5, C6 |
| 2 | 0.22 | Resistors_SMD:R_1206_HandSoldering | R7, R8 |
| 2 | 1k | Resistors_SMD:R_1206_HandSoldering | R10, R11 |
| 2 | 4.7uF | Capacitors_SMD:C_0805_HandSoldering | C1, C2 |
| 2 | CONNECTOR | Pin_Headers:Pin_Header_Straight_1x02 | P2, P3 |
| 2 | DRV8830 | MSOP:MSOP10 | U4, U5 |
| 1 | 10uF | Capacitors_SMD:C_0805_HandSoldering | C4 |
| 1 | 2k | Resistors_SMD:R_1206_HandSoldering | R4 |
| 1 | 470 | Resistors_SMD:R_1206_HandSoldering | R2 |
| 1 | BATT | Wire_Pads:SolderWirePad_single_0-8mmDrill | P4 |
| 1 | CONN_01X02 | Pin_Headers:Pin_Header_Straight_1x02 | P6 |
| 1 | CONN_01X02 | Wire_Pads:SolderWirePad_single_0-8mmDrill | P5 |
| 1 | CONN_01X06 | Pin_Headers:Pin_Header_Straight_1x06 | P1 |
| 1 | Conn_01x01 | Pin_Headers:Pin_Header_Straight_1x01_Pitch1.00mm | J1 |
| 1 | ESP8266-ESP-03 | TO_SOT_Packages_SMD:SOT-23-5 | U2 |
| 1 | GF1A | Resistors_SMD:R_1210_HandSoldering | D1 |
| 1 | LED | LEDs:LED_0805 | Charge1 |
| 1 | MCP73831 | TO_SOT_Packages_SMD:SOT-23-5 | U1 |
| 1 | MIC5265 | esp-8266:ESP8266-ESP-03 | U3 |
| 1 | SPDT | switchSMD:spdt_pcm12stmr | SW1 |
| 1 | Thermal fuse | Resistors_SMD:R_1210_HandSoldering | 0ZCB0050FF2G1 |
ab3nd/TinyRobo
Hardware and software for a tiny robot platform based on the ESP-8266 WiFi modules and hacked children's toys.


AFS-pt/PROMETHEUS-1
Documentation lives here: https://afs-pt.github.io/PROMETHEUS-1


spacecraft-design-lab-2019/avionics-motherboard
Main flight computer board for the PyCubed-1 spacecraft
It measures 25.4 × 39.1 mm and has 2 copper layers, 1.6 mm thick.
34 parts, built around the DRV8830DRC, MCP73831 and GF1A. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the ab3nd/TinyRobo repository on GitHub, at the commit this page was made from: the board is hardware/kicad_files/tiny_robo_v2/tiny_robo_v2.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask ab3nd before reusing the design.