4 layers56 × 36 mm
Controller
Debanx3/Drishtikon
EdgeAI based human detection system for automated control of resistive and inductive loads at workspaces
44 partsMIT
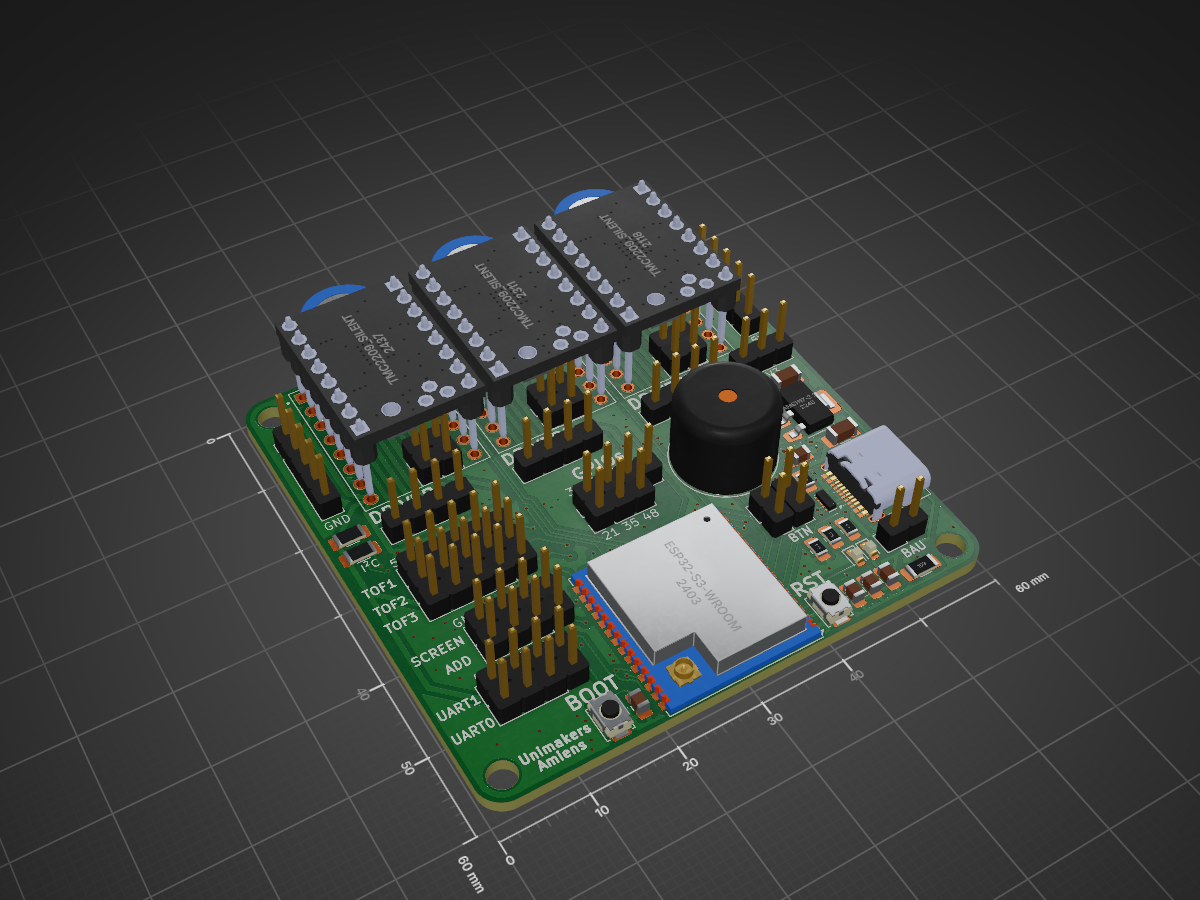
 UniDiggers/PCBete
Carte électronique ESP32-S3-WROOM-U1 permettant de controller : - Jusqu'à 3 NEMA 17 - 3 Capteurs TOF VL53L0X (i2c) - 1 écran OLED 0.96 12864 (i2c) - Buzzer - LiDAR
PCBete is an open-source printed circuit board by UniDiggers, from the UniDiggers/PCBete repository on GitHub. It is a 2-layer board of 60 × 60 mm with 57 parts on 76 nets, routed with 676 tracks and 156 vias.
It is built around the TMC2209SILENTSTEPSTICK, ESP32-S3-WROOM-1-N8 and D3V3XA4B10LP. Its parts include 12 connectors, 10 capacitors, 6 ICs, 5 resistors and 2 diodes. It belongs with the ESP32 boards of this library.


Création d'un PCB pour la robotique.
Carte électronique ESP32-S3-WROOM-U1 permettant de controller :
Alimentation via PowerBank 5Ah avec 5V/3A vers la carte en Type-C vers Type-C .
3000mA sont disponibles :
TOTAL THEORIQUE : 2635mA / 87% *Ce calcul ne prend pas en compte la consommation théorique des composants soudés à la carte.
*le LiDAR est un accessoire optionnel qui peut être ajouté si la consommation instantanée le permet. 1x LiDAR environ 150mA.
TOTAL THEORIQUE avec LiDAR : 2785mA / 92%
Energie Batterie = Capacité (Ah) x Tension sortie ( Volt). Energie Batterie = 5Ah x 5 = 25Wh.
Puissance carte = Intensité (A) x Tension (Volt). Puissance carte = 3A x 5V = 15W.
Temps d'utilisation (heure) = Energie Batterie (watt-heures) / Puissance carte (W). Temps d'utilisation (heure) = 25Wh / 15W = 1.67 heures.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 7 | Conn_01x04_Pin | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | ADD, J2, J3, J8, SCREEN, UART0, UART1 |
| 6 | Jumper_2_Open | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | JP1, JP2, JP3, JP4, JP5, JP6 |
| 5 | Conn_01x05_Pin | Connector_PinHeader_2.54mm:PinHeader_1x05_P2.54mm_Vertical | J10, J11, TOF1, TOF2, TOF3 |
| 4 | MountingHole | MountingHole:MountingHole_3.2mm_M3 | H1, H2, H3, H4 |
| 3 | 100uF | Capacitor_THT:CP_Radial_D10.0mm_P5.00mm | C3, C6, C8 |
| 3 | Conn_01x02_Pin | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J5, J6, J7 |
| 3 | TMC2209_SILENTSTEPSTICK | TMC2209:MODULE_TMC2209_SILENTSTEPSTICK | U1, U2, U5 |
| 2 | 0.1uF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C1, C2 |
| 2 | 10uF | Capacitor_SMD:C_1206_3216Metric_Pad1.33x1.80mm_HandSolder | C5, C7 |
| 2 | 10uF(25V/20%) | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C4, C9 |
| 2 | 120 | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R4, R5 |
| 2 | 5.1k | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R2, R3 |
| 2 | Jumper_2_Open | Resistor_SMD:R_1206_3216Metric_Pad1.30x1.75mm_HandSolder | JP7, JP8 |
| 2 | SW_Push | Button_Switch_SMD:SW_Push_SPST_NO_Alps_SKRK | SW1, SW2 |
| 2 | ~ | LED_SMD:LED_0603_1608Metric | D1, D2 |
| 1 | 0.1uF(50V/10%) | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C10 |
| 1 | 10k | Resistor_SMD:R_1206_3216Metric_Pad1.30x1.75mm_HandSolder | R1 |
| 1 | AMS1117-3.3 (UMW) | Package_TO_SOT_SMD:SOT-223-3_TabPin2 | U4 |
| 1 | Buzzer | Buzzer_Beeper:Buzzer_12x9.5RM7.6 | BZ1 |
| 1 | Conn_01x03_Pin | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J12 |
| 1 | Conn_01x07_Pin | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J4 |
| 1 | Conn_01x07_Pin | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J9 |
| 1 | D3V3XA4B10LP | Package_DFN_QFN:Diodes_UDFN-10_1.0x2.5mm_P0.5mm | U3 |
| 1 | ESP32-S3-WROOM-1 | RF_Module:ESP32-S3-WROOM-1U | U6 |
| 1 | USB_C_Receptacle_USB2.0_16P | Connector_USB:USB_C_Receptacle_HRO_TYPE-C-31-M-12 | J1 |
Debanx3/Drishtikon
EdgeAI based human detection system for automated control of resistive and inductive loads at workspaces

ficosta/Guardian-Sense
Guardian-Sense is a versatile hardware project based on the ESP32-S3, designed to monitor environmental conditions and provide real-time data to Zabbix.

sherwinchiu/get-a-grip-on-reality
fydp project 2025 for vr gloves. open source pcb

Tay0710/Design_S1_006
This project integrates hardware, firmware, and design elements to develop a fully functional autonomous 3D mapping drone system.


Angelo13C/3d-printer
Firmware, electronics, mechanics and control interface of a 3D printer

TiTooom/Global_ESP32S3_PCB
Carte électronique ESP32-S3-WROOM-U1 permettant de controller : - Jusqu'à 3 NEMA 17 - 3 Capteurs TOF VL53L0X (i2c) - 1 écran OLED 0.96 12864 (i2c) - Buzzer - LiDAR

It measures 60 × 60 mm and has 2 copper layers, 1.6 mm thick.
57 parts, built around the TMC2209SILENTSTEPSTICK, ESP32-S3-WROOM-1-N8 and D3V3XA4B10LP. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the UniDiggers/PCBete repository on GitHub, at the commit this page was made from: the board is PCB.kicad_pcb and its schematic PCB.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask UniDiggers before reusing the design.