2 layers38.4 × 63 mm
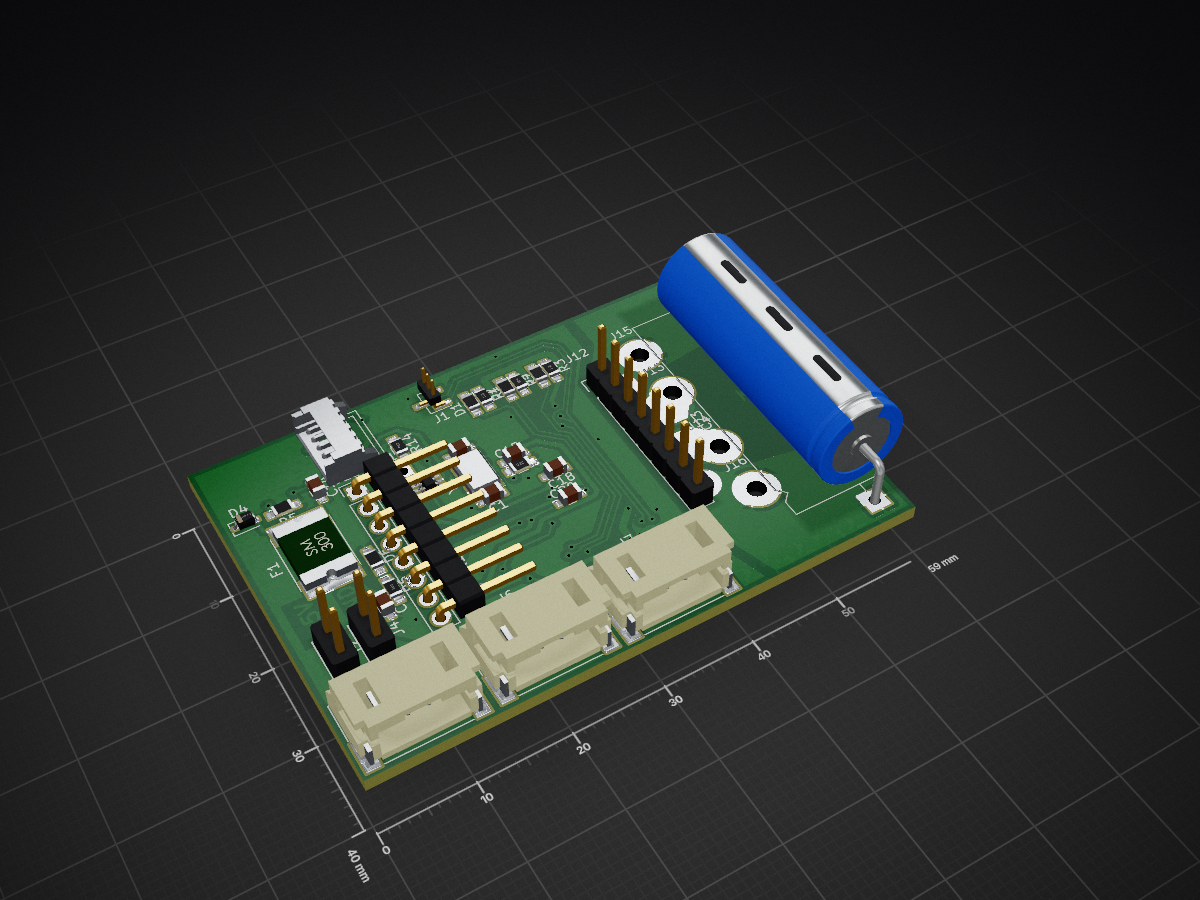
 UWRoverTeam/low_level
MotorDriver is an open-source printed circuit board by UWRoverTeam, from the UWRoverTeam/low_level repository on GitHub. It is a 2-layer board of 59 × 40 mm with 60 parts on 44 nets, routed with 851 tracks and 52 vias.
It is built around the SN65HVD231D, RCLAMP0504FA and LM1117-3.3. Its parts include 20 capacitors, 15 connectors, 10 resistors, 7 ICs and 6 diodes. It belongs with the robots and motor control boards and the STM32 boards of this library.


| Qty | Value | Footprint | References |
|---|---|---|---|
| 13 | 100n | Capacitors_SMD:C_0603_HandSoldering | C2, C4, C6, C7, C8, C9, C10, C11, C14, C15, C18, C20, C22 |
| 5 | LED | LEDs:LED_0603_HandSoldering | D1, D2, D3, D5, D6 |
| 4 | 100R | Resistors_SMD:R_0603_HandSoldering | R1, R2, R3, R6 |
| 4 | 4u7 | Capacitors_SMD:C_0603_HandSoldering | C5, C12, C13, C19 |
| 3 | 2k2 | Resistors_SMD:R_0603_HandSoldering | R4, R7, R13 |
| 3 | RCLAMP0504F | agg:SC-70-6 | IC1, IC3, IC4 |
| 2 | 18p | Capacitors_SMD:C_0603_HandSoldering | C1, C3 |
| 2 | SN65HVD231 | Housings_SOIC:SO-8_5.3x6.2mm_Pitch1.27mm | U1, U2 |
| 1 | 220R | Resistors_SMD:R_0603_HandSoldering | R5 |
| 1 | 39k | Resistors_SMD:R_0603_HandSoldering | R8 |
| 1 | 47k | Resistors_SMD:R_0603_HandSoldering | R14 |
| 1 | BATT_CONN | Wire_Pads:SolderWirePad_single_2mmDrill | J16 |
| 1 | CAN1_CONN1 | Connectors_JST:JST_PH_S4B-PH-SM4-TB_04x2.00mm_Angled | J5 |
| 1 | CAN1_CONN2 | Connectors_JST:JST_PH_S4B-PH-SM4-TB_04x2.00mm_Angled | J6 |
| 1 | CAN1_GND | Pin_Headers:Pin_Header_Straight_2x01_Pitch2.54mm | J4 |
| 1 | CAN1_POWER | Pin_Headers:Pin_Header_Straight_2x01_Pitch2.54mm | J3 |
| 1 | CAN2_CONN | Connectors_JST:JST_PH_S4B-PH-SM4-TB_04x2.00mm_Angled | J7 |
| 1 | CP | Capacitors_ThroughHole:CP_Axial_L30.0mm_D15.0mm_P35.00mm_Horizontal | C23 |
| 1 | Crystal_GND24 | Crystals:Crystal_SMD_5032-4pin_5.0x3.2mm | Y1 |
| 1 | DEBUG_SERIAL_CONN | Pin_Headers:Pin_Header_Straight_1x03_Pitch1.00mm_SMD_Pin1Left | J1 |
| 1 | D_Schottky | Diodes_SMD:D_SOD-323 | D4 |
| 1 | GNDPWR_CONN | Wire_Pads:SolderWirePad_single_2mmDrill | J15 |
| 1 | LM1117-3.3 | TO_SOT_Packages_SMD:SOT-223 | U4 |
| 1 | MOTOR_A_CONN | Wire_Pads:SolderWirePad_single_2mmDrill | J13 |
| 1 | MOTOR_B_CONN | Wire_Pads:SolderWirePad_single_2mmDrill | J14 |
| 1 | POLOLU_CTRL_CONN | Pin_Headers:Pin_Header_Straight_1x08_Pitch2.54mm | J10 |
| 1 | POLOLU_MOTOR_CONN | KP:Pin_Header_Pololu_OUT | J12 |
| 1 | POLOLU_VREF_CONN | Pin_Headers:Pin_Header_Straight_1x01_Pitch2.54mm | J11 |
| 1 | PROG_CONN | Connectors_Molex:Molex_PicoBlade_53047-0510_05x1.25mm_Straight | J2 |
| 1 | Polyfuse | Fuse_Holders_and_Fuses:Fuse_SMD2920 | F1 |
| 1 | STM32F105RBTx | Housings_QFP:LQFP-64_10x10mm_Pitch0.5mm | U3 |
| 1 | VESC_CONN | Connectors_JST:JST_PH_S4B-PH-SM4-TB_04x2.00mm_Angled | J9 |


ysoyjcgoxohxoh/Bird3
Drop-in replacement Bird Brain design for Bird 3 scooters.

bobbycar-graz/Telemetry-PCB
PCB with ESP32, CANbus, microSD, GPS and LoRa


vatsalbansal123/reaction-wheel-controller-pcb
Open-source FOC motor controller PCB for a reaction wheel — STM32G431 + DRV8311H driving a BLDC motor, with CAN bus interface. Designed in KiCad.
It measures 59 × 40 mm and has 2 copper layers, 1.6 mm thick.
60 parts, built around the SN65HVD231D, RCLAMP0504FA and LM1117-3.3. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the UWRoverTeam/low_level repository on GitHub, at the commit this page was made from: the board is motorDriver/pcb/motorDriver.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask UWRoverTeam before reusing the design.