
2 layers
Ardumower unroutet
Starsurfer78/Ardumower_PCBs
DIY Robot Lawn Mower Community: https://www.diy-robot-lawn-mower.com/
56 parts1GPL-3.0

 Starsurfer78/Ardumower_PCBs1
DIY Robot Lawn Mower Community: https://www.diy-robot-lawn-mower.com/
Ardumower is an open-source printed circuit board by Starsurfer78, from the Starsurfer78/Ardumower_PCBs repository on GitHub, published under the GPL-3.0 licence. It is a 2-layer board of 169.8 × 97 mm with 75 parts on 93 nets, routed with 1,126 tracks and 15 vias.
It is built around the MC33926PNB. Its parts include 40 connectors, 17 resistors, 4 diodes, 2 ICs and 1 capacitor.
DIY Robot Lawn Mower Community: https://www.diy-robot-lawn-mower.com/
If you want to buy a Board, you can send me an E-Mail: info@projekt-heimwerken.de
New Board Design. All Pins from Software are now on the PCB. Supports 4 Motor Driver for Mowing. Only a few Electronic Parts are needed.
Tested with MC33926 motor driver. Brushless Motordriver did not work at the Moment with Azuritber.
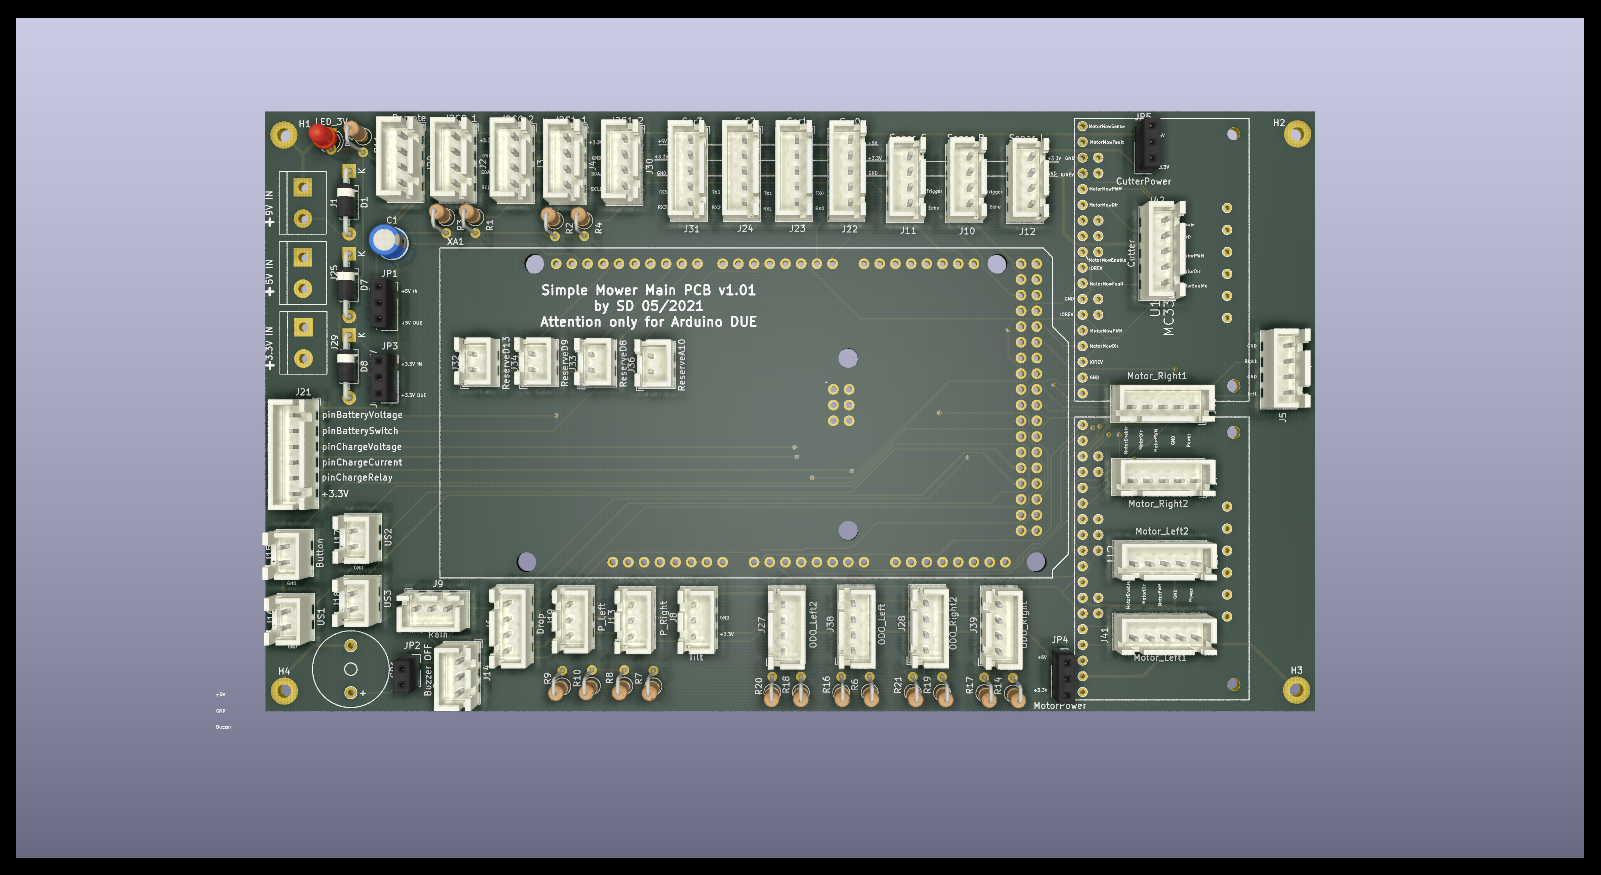
The charging board and the power supply for the motors are on a separate board.

Should also fit into small housings.
Use it at your own Risk.
Projekt: https://forum.ardumower.de/
Software Azuritber: https://github.com/Boilevin/AzuritBer
Ardumower Original Software: https://github.com/Ardumower
Facebook Gruppe DIY Robot Lawn Mower: https://www.facebook.com/groups/319588508137220
| Qty | Value | Footprint | References |
|---|---|---|---|
| 6 | 1KO | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P2.54mm_Vertical | R6, R7, R9, R14, R18, R19 |
| 4 | 1,5KO | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P2.54mm_Vertical | R16, R17, R20, R21 |
| 4 | MountingHole_Pad | MountingHole:MountingHole_2.2mm_M2_Pad_TopBottom | H1, H2, H3, H4 |
| 4 | XXX | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P2.54mm_Vertical | R1, R2, R3, R4 |
| 3 | 1N5819 | Diode_THT:D_DO-41_SOD81_P10.16mm_Horizontal | D1, D7, D8 |
| 2 | 1.5KO | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P2.54mm_Vertical | R8, R10 |
| 2 | MC33926 | Zimprich:MC_33926_31polig_mit_Bohrloch_neue_Masse | U1, U2 |
| 1 | 100 | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P2.54mm_Vertical | R11 |
| 1 | 100nF | Capacitor_THT:CP_Radial_D5.0mm_P2.50mm | C1 |
| 1 | 3.3V IN | TerminalBlock:TerminalBlock_bornier-2_P5.08mm | J29 |
| 1 | 5V IN | TerminalBlock:TerminalBlock_bornier-2_P5.08mm | J25 |
| 1 | 9V IN | TerminalBlock:TerminalBlock_bornier-2_P5.08mm | J1 |
| 1 | Arduino_Due_Shield | Arduino:Arduino_Due_Shield | XA1 |
| 1 | Bumper | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J5 |
| 1 | Button | Connector_JST:JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J15 |
| 1 | Buzzer | Connector_JST:JST_XH_B3B-XH-A_1x03_P2.50mm_Vertical | J14 |
| 1 | Buzzer OFF | Connector_PinSocket_2.54mm:PinSocket_1x02_P2.54mm_Vertical | JP2 |
| 1 | Cutter | Connector_JST:JST_XH_B5B-XH-A_1x05_P2.50mm_Vertical | J42 |
| 1 | CutterPower | Connector_PinSocket_2.54mm:PinSocket_1x03_P2.54mm_Vertical | JP5 |
| 1 | Drop | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J6 |
| 1 | I2C0_1 | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J2 |
| 1 | I2C0_2 | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J3 |
| 1 | I2C1_1 | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J4 |
| 1 | I2C1_2 | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J30 |
| 1 | Jumper_3.3V | Connector_PinSocket_2.54mm:PinSocket_1x03_P2.54mm_Vertical | JP3 |
| 1 | Jumper_5V | Connector_PinSocket_2.54mm:PinSocket_1x03_P2.54mm_Vertical | JP1 |
| 1 | LED_3V | LED_THT:LED_D3.0mm | D2 |
| 1 | MotorPower | Connector_PinSocket_2.54mm:PinSocket_1x03_P2.54mm_Vertical | JP4 |
| 1 | Motor_Left1 | Connector_JST:JST_XH_B5B-XH-A_1x05_P2.50mm_Vertical | J41 |
| 1 | Motor_Left2 | Connector_JST:JST_XH_B5B-XH-A_1x05_P2.50mm_Vertical | J26 |
| 1 | Motor_Right1 | Connector_JST:JST_XH_B5B-XH-A_1x05_P2.50mm_Vertical | J40 |
| 1 | Motor_Right2 | Connector_JST:JST_XH_B5B-XH-A_1x05_P2.50mm_Vertical | J7 |
| 1 | ODO_Left | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J39 |
| 1 | ODO_Left2 | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J28 |
| 1 | ODO_Right | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J38 |
| 1 | ODO_Right2 | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J27 |
| 1 | PCB_2 | Connector_JST:JST_XH_B6B-XH-A_1x06_P2.50mm_Vertical | J21 |
| 1 | P_Left | Connector_JST:JST_XH_B3B-XH-A_1x03_P2.50mm_Vertical | J19 |
| 1 | P_Right | Connector_JST:JST_XH_B3B-XH-A_1x03_P2.50mm_Vertical | J13 |
| 1 | Rain | Connector_JST:JST_XH_B3B-XH-A_1x03_P2.50mm_Vertical | J9 |
| 1 | Remote | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J20 |
| 1 | ReserveA10 | Connector_JST:JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J36 |
| 1 | ReserveD13 | Connector_JST:JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J32 |
| 1 | ReserveD8 | Connector_JST:JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J33 |
| 1 | ReserveD9 | Connector_JST:JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J34 |
| 1 | SPEAKER | Zimprich:Buzzer_12x9.5RM7.6 | SP1 |
| 1 | Ser0 | Connector_JST:JST_XH_B5B-XH-A_1x05_P2.50mm_Vertical | J22 |
| 1 | Ser1 | Connector_JST:JST_XH_B5B-XH-A_1x05_P2.50mm_Vertical | J23 |
| 1 | Ser2 | Connector_JST:JST_XH_B5B-XH-A_1x05_P2.50mm_Vertical | J24 |
| 1 | Ser3 | Connector_JST:JST_XH_B5B-XH-A_1x05_P2.50mm_Vertical | J31 |
| 1 | Sonar_C | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J11 |
| 1 | Sonar_L | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J12 |
| 1 | Sonar_R | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J10 |
| 1 | Tilt | Connector_JST:JST_XH_B3B-XH-A_1x03_P2.50mm_Vertical | J8 |
| 1 | US1 | Connector_JST:JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J16 |
| 1 | US2 | Connector_JST:JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J17 |
| 1 | US3 | Connector_JST:JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J18 |
Starsurfer78/Ardumower_PCBs
DIY Robot Lawn Mower Community: https://www.diy-robot-lawn-mower.com/

Starsurfer78/Ardumower_PCBs
DIY Robot Lawn Mower Community: https://www.diy-robot-lawn-mower.com/

Ardumower/ardumower
Develop an open source robotic lawn mower (HW+SW reference platform)


Luos-io/luos_engine
Open-source and real-time orchestrator for cyber-physical-systems, to easily design, test and deploy embedded applications and digital twins.
It measures 169.8 × 97 mm and has 2 copper layers, 1.6 mm thick.
75 parts, built around the MC33926PNB. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the Starsurfer78/Ardumower_PCBs repository on GitHub, at the commit this page was made from: the board is DUE_PCB_V1.01/Ardumower.kicad_pcb and its schematic Charging_PCB/charge_pcb.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the GPL-3.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).