
Open secure esc 6s 50a can485 faraday sameend faceted
Stab-Rabbit-coding/Open-Secure-ESC
Governed by AGENTS.md. Build spec: ../README.md. Plan: Serenity-UAV docs/plans/2026-09-17-001-feat-tilt-controller-open-secure-esc-build-plan.md (U4).

Governed by AGENTS.md. Build spec: ../README.md. Plan: Serenity-UAV docs/plans/2026-09-17-001-feat-tilt-controller-open-secure-esc-build-plan.md (U4).
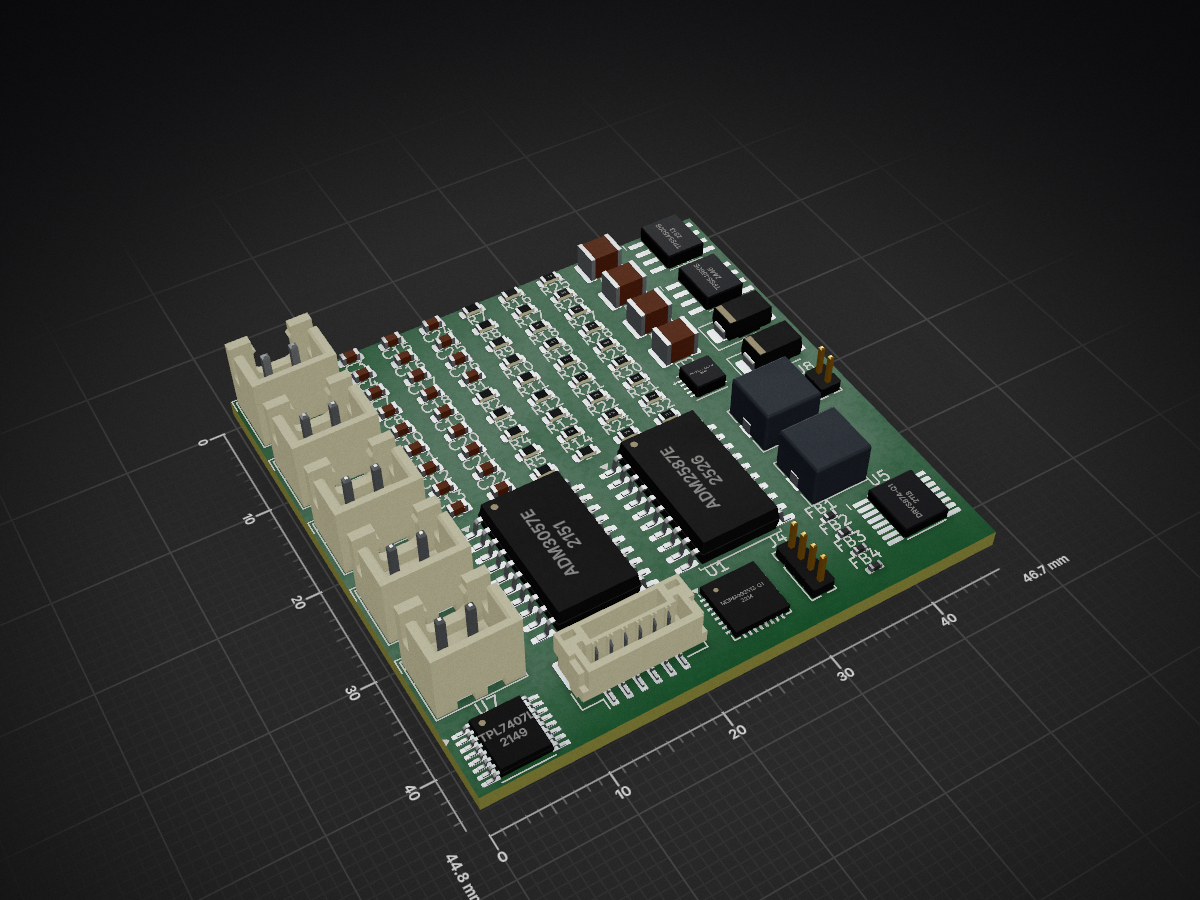
Open secure esc 6s 10a brushed can485 iso is an open-source printed circuit board by Stab-Rabbit-coding, from the Stab-Rabbit-coding/Open-Secure-ESC repository on GitHub, published under the CERN-OHL-P-2.0 licence. It is a 2-layer board with 82 parts on 90 nets.
It is built around the RS485, TPS54560BDDA and TPL7407LD. Its parts include 32 resistors, 26 capacitors, 8 ICs, 8 connectors and 2 diodes. It belongs with the robots and motor control boards of this library.
Governed by AGENTS.md. Build spec: ../README.md. Plan: Serenity-UAV
docs/plans/2026-09-17-001-feat-tilt-controller-open-secure-esc-build-plan.md (U4).
| Item | State (2026-09-17) |
|---|---|
| Schematic | Generated by tools/gen_schematic.py; ERC 0 errors / 0 warnings at --severity-all (kicad-cli 9.0.2, project context) |
| Netlist | 90 nets, 81 parts; every intended net present, no single-pin nets, PMODE → GND, IMODE strap, nFAULT pull-up, BRAKE_EN pull-down and VM-sense divider all confirmed from kicad-cli sch export netlist |
| PCB | Not started — no .kicad_pcb; see ../gerbers/README.md for the gate list |
| Envelope check | docs/tools/isolation_envelope.py --widest 7.0 --board-width 36.5 → minimum width 25.96 mm for the widest non-isolated part (a 7 mm inductor class) to sit between the two isolated rows; at 36.5 mm the check passes with 12.8 mm of margin, so control sits alongside comms with no creepage band in the stack |
The schematic is label-wired, not drawn: every pin that carries a net has
a global label placed on its connection point and every unused pin has a
no-connect flag there. There are no wires. This is deliberate — it removes
the hand-wiring Y-sign trap (docs/solutions/architecture-patterns/schematic-pin-y-sign-when-hand-wiring.md)
and makes the netlist the proof of connectivity. The consequence is that the
sheet is a netlist you can open in KiCad, not a diagram arranged for
reading; a human-arranged view is a follow-up (TODO.md 18.6).
tools/gen_schematic.py is the single source. It reads pin geometry from the
same symbols/*.kicad_sym files it embeds, so a regenerated symbol cannot
drift from the sheet. python3 tools/gen_schematic.py --check exits 0 only
when the committed sheet equals the generator output — run it before every
commit that touches either. Do not edit the .kicad_sch by hand; if
KiCad's GUI is used to rearrange it, port the change into the generator
or the next regeneration will drop it (the 6S/50A build's divergence trap).
| File | What it is |
|---|---|
open_secure_esc_6s_10a_brushed_can485_iso.kicad_sch | The schematic (KiCad 9 format 20250114), generated |
open_secure_esc_6s_10a_brushed_can485_iso.kicad_pro | Project file: net classes Default / Power (1.5 mm) / Motor (1.5 mm) / Isolated / Sense with the net assignments below |
open_secure_esc_6s_10a_brushed_can485_iso.kicad_dru | Custom rules: power/motor/sense conductor spacing, isolation-barrier no-via rule (7.5 mm, [9] Table 6) with its negative control |
sym-lib-table | Symbol bindings to symbols/, each descr carrying the REFERENCES tag and verification note |
fp-lib-table | Open_Secure_ESC.pretty (this repo's TI PWP0016J / DDA0008B / OPTIGA USON-10 footprints) |
tools/gen_schematic.py | Generator (kiutils-free) |
| Class | Nets | Why |
|---|---|---|
| Power | VBAT, GND, VMOT, 3V3, U6_SW, U8_SW | 3 A branch, 2.9 A motor stall; width sized in the layout follow-up (IPC-2152 [46] unread) |
| Motor | MOT_OUT1, MOT_OUT2, SOL_N | Bridge outputs and the solenoid sink |
| Isolated | CAN_H/L, CAN_VISOIN/OUT, CAN_ISO_GND, CAN_GNDISO, RS485_A/B, RS485_VISOIN/OUT, RS485_ISO_GND, RS485_GNDISO | Isolated side of both transceivers; the .kicad_dru via rule keys on this class |
| Sense | ADC_IPROPI, ADC_VM, ADC_VBUS, BRAKE_SENSE, U5_VREF, U5_IPROPI | Analog, 0.3 mm spacing |
| Nickname | Symbol | Pin-map status |
|---|---|---|
MSPM0G3518_Q1_RHB_TILT | U1 MCU, tilt-build role names, all 32 pins | VERIFIED — [44] Fig. 6-6 / Table 6-2 (symbols/specs/MSPM0G3518_Q1_RHB_TILT.json) |
OPTIGA_TRUST_M | U2 | VERIFIED — [45] p.17 Table 6 |
ADM3055E_ADM3057E | U3 (ADM3057E) | VERIFIED — [10]; part Candidate |
ADM2582E_ADM2587E | U4 (ADM2587E) | VERIFIED — [9]; part Candidate |
DRV8874_Q1 | U5 | VERIFIED — [63] §5, cross-checked [62] |
TPS54560B | U6, U8 | VERIFIED — [65] §5 |
TPL7407L | U7 | VERIFIED — [66] §5 |
BLM15HD182SN1D | FB1–FB4 | VERIFIED — [53] |
AEAT_8800_Q24 | (not placed; off-board sensor daughter) | VERIFIED — [64] |
Open_Secure_ESC_Generic | R, C, Conn_01x02/04, PWR_FLAG | Generic |
Device, Connector_Generic (KiCad stock) | L1/L2, D1/D2, J7 | Generic; parts UNVERIFIED — see ../README.md |
| Qty | Value | Footprint | References |
|---|---|---|---|
| 9 | 100nF | Capacitor_SMD:C_0603_1608Metric | C4, C8, C10, C16, C18, C20, C22, C24, C26 |
| 4 | 10uF | Capacitor_SMD:C_0603_1608Metric | C19, C21, C23, C25 |
| 4 | 33R | Resistor_SMD:R_0603_1608Metric | R28, R29, R30, R31 |
| 4 | BLM15HD182SN1D | Inductor_SMD:L_0402_1005Metric | FB1, FB2, FB3, FB4 |
| 3 | 100k | Resistor_SMD:R_0603_1608Metric | R19, R21, R32 |
| 3 | 10k | Resistor_SMD:R_0603_1608Metric | R13, R26, R27 |
| 3 | 47k | Resistor_SMD:R_0603_1608Metric | R20, R22, R25 |
| 2 | 100nF 50V | Capacitor_SMD:C_0603_1608Metric | C2, C11 |
| 2 | 10nF | Capacitor_SMD:C_0603_1608Metric | C14, C17 |
| 2 | 22uF 16V | Capacitor_SMD:C_1210_3225Metric | C5, C6 |
| 2 | C_COMP | Capacitor_SMD:C_0603_1608Metric | C3, C7 |
| 2 | D_CATCH_60V | Diode_SMD:D_SMA | D1, D2 |
| 2 | RT_500kHz | Resistor_SMD:R_0603_1608Metric | R3, R9 |
| 2 | R_COMP | Resistor_SMD:R_0603_1608Metric | R6, R12 |
| 2 | R_FB_HI | Resistor_SMD:R_0603_1608Metric | R4, R10 |
| 2 | R_FB_LO | Resistor_SMD:R_0603_1608Metric | R5, R11 |
| 2 | R_UVLO_HI | Resistor_SMD:R_0603_1608Metric | R1, R7 |
| 2 | R_UVLO_LO | Resistor_SMD:R_0603_1608Metric | R2, R8 |
| 2 | TPS54560B | Open_Secure_ESC:TI_DDA0008B_HSOIC-8_3.9x4.9mm_P1.27mm_EP2.71x3.4mm | U6, U8 |
| 1 | 100nF 16V | Capacitor_SMD:C_0603_1608Metric | C12 |
| 1 | 10uF 50V | Capacitor_SMD:C_1210_3225Metric | C1 |
| 1 | 180k | Resistor_SMD:R_0603_1608Metric | R23 |
| 1 | 1k | Resistor_SMD:R_0603_1608Metric | R17 |
| 1 | 20k | Resistor_SMD:R_0603_1608Metric | R24 |
| 1 | 22nF 50V | Capacitor_SMD:C_0603_1608Metric | C13 |
| 1 | 22uF 10V | Capacitor_SMD:C_1210_3225Metric | C9 |
| 1 | 470nF | Capacitor_SMD:C_0603_1608Metric | C15 |
| 1 | 62k | Resistor_SMD:R_0603_1608Metric | R18 |
| 1 | ADM2587E | Package_SO:SOIC-20W_7.5x12.8mm_P1.27mm | U4 |
| 1 | ADM3057E | Package_SO:SOIC-20W_7.5x12.8mm_P1.27mm | U3 |
| 1 | BRAKE_SOL | Connector_JST:JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J3 |
| 1 | CAN | Connector_JST:JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J5 |
| 1 | DRV8874-Q1 | Open_Secure_ESC:TI_PWP0016J_HTSSOP-16_4.4x5mm_P0.65mm_EP2.46x3.55mm | U5 |
| 1 | ENCODER | Connector_JST:JST_GH_BM06B-GHS-TBT_1x06-1MP_P1.25mm_Vertical | J7 |
| 1 | L_3V3 | Inductor_SMD:L_Wuerth_HCI-5040 | L2 |
| 1 | L_VMOT | Inductor_SMD:L_Wuerth_HCI-5040 | L1 |
| 1 | MOTOR | Connector_JST:JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J2 |
| 1 | MSPM0G3518-Q1 RHB | Package_DFN_QFN:Texas_RHB0032E_VQFN-32-1EP_5x5mm_P0.5mm_EP3.45x3.45mm | U1 |
| 1 | OPTIGA Trust M V3 | Open_Secure_ESC:Infineon_PG-USON-10-2-4_3x3mm_P0.5mm_EP1.7x2.5mm | U2 |
| 1 | RIPROPI | Resistor_SMD:R_0603_1608Metric | R16 |
| 1 | RS485 | Connector_JST:JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J6 |
| 1 | R_VREF_HI | Resistor_SMD:R_0603_1608Metric | R14 |
| 1 | R_VREF_LO | Resistor_SMD:R_0603_1608Metric | R15 |
| 1 | SWD | Connector_PinHeader_1.27mm:PinHeader_1x04_P1.27mm_Vertical | J4 |
| 1 | TPL7407L | Package_SO:TSSOP-16_4.4x5mm_P0.65mm | U7 |
| 1 | TRIP | Connector_PinHeader_1.27mm:PinHeader_1x02_P1.27mm_Vertical | J8 |
| 1 | VBAT_IN | Connector_JST:JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J1 |
Stab-Rabbit-coding/Open-Secure-ESC
Governed by AGENTS.md. Build spec: ../README.md. Plan: Serenity-UAV docs/plans/2026-09-17-001-feat-tilt-controller-open-secure-esc-build-plan.md (U4).


kieraneglin/hexagon-art
A passive breakout board: two lever-terminal inputs, three JST XH outputs, all six conductors (RX bus, two spares, +12V, GND, +5V) paralleled straight across. No active components, no regulation, nothing to configure.

Twistiee/rcm
A CAN-controlled relay driver for a car. 21 universal channels, each of which is simultaneously a low-side output and an input — so the same board builds as a relay controller or as a switch panel, decided in firmware…

drandyhaas/KiCadRoutingTools
A set of Python/Rust tools to aid routing in KiCad

phonght32/OpenDrone_HW_AIO_FC_F405
OpenDrone Project - AIO Brushless FC F405.

pollen-robotics/elec_grabette
Set of electronic boards for Grabette/Gripette

jaeyeon302/2021BEV
Graduation Project making Battery Electric Vehicle. Dept. of Electrical and Computer Engineering at SNU.

82 parts, built around the RS485, TPS54560BDDA and TPL7407LD. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the Stab-Rabbit-coding/Open-Secure-ESC repository on GitHub, at the commit this page was made from: the board is builds/6s/10A/BRUSHED_CAN_485_isolation/kicad/open_secure_esc_6s_10a_brushed_can485_iso.kicad_pcb and its schematic builds/6s/10A/BRUSHED_CAN_485_isolation/kicad/open_secure_esc_6s_10a_brushed_can485_iso.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the CERN-OHL-P-2.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).