2 layers88.9 × 50.8 mm

 SharKingStudios/Guardrail-FC
A Flight Assist PCB that helps you not crash.
Guardrail FC is an open-source printed circuit board by SharKingStudios, from the SharKingStudios/Guardrail-FC repository on GitHub, published under the MIT licence. It is a 2-layer board of 50 × 50 mm with 87 parts on 81 nets, routed with 808 tracks and 175 vias.
It is built around the RP2040, SPA06-003 and TMI3341, with the W25Q16JVUXIQ, ICM-42688P-HXY and SAM-M8Q-0 among its other parts. Its parts include 31 resistors, 25 capacitors, 10 connectors, 6 ICs and 4 diodes. It belongs with the RP2040 boards of this library.


visuals because everyone loves eye candy.
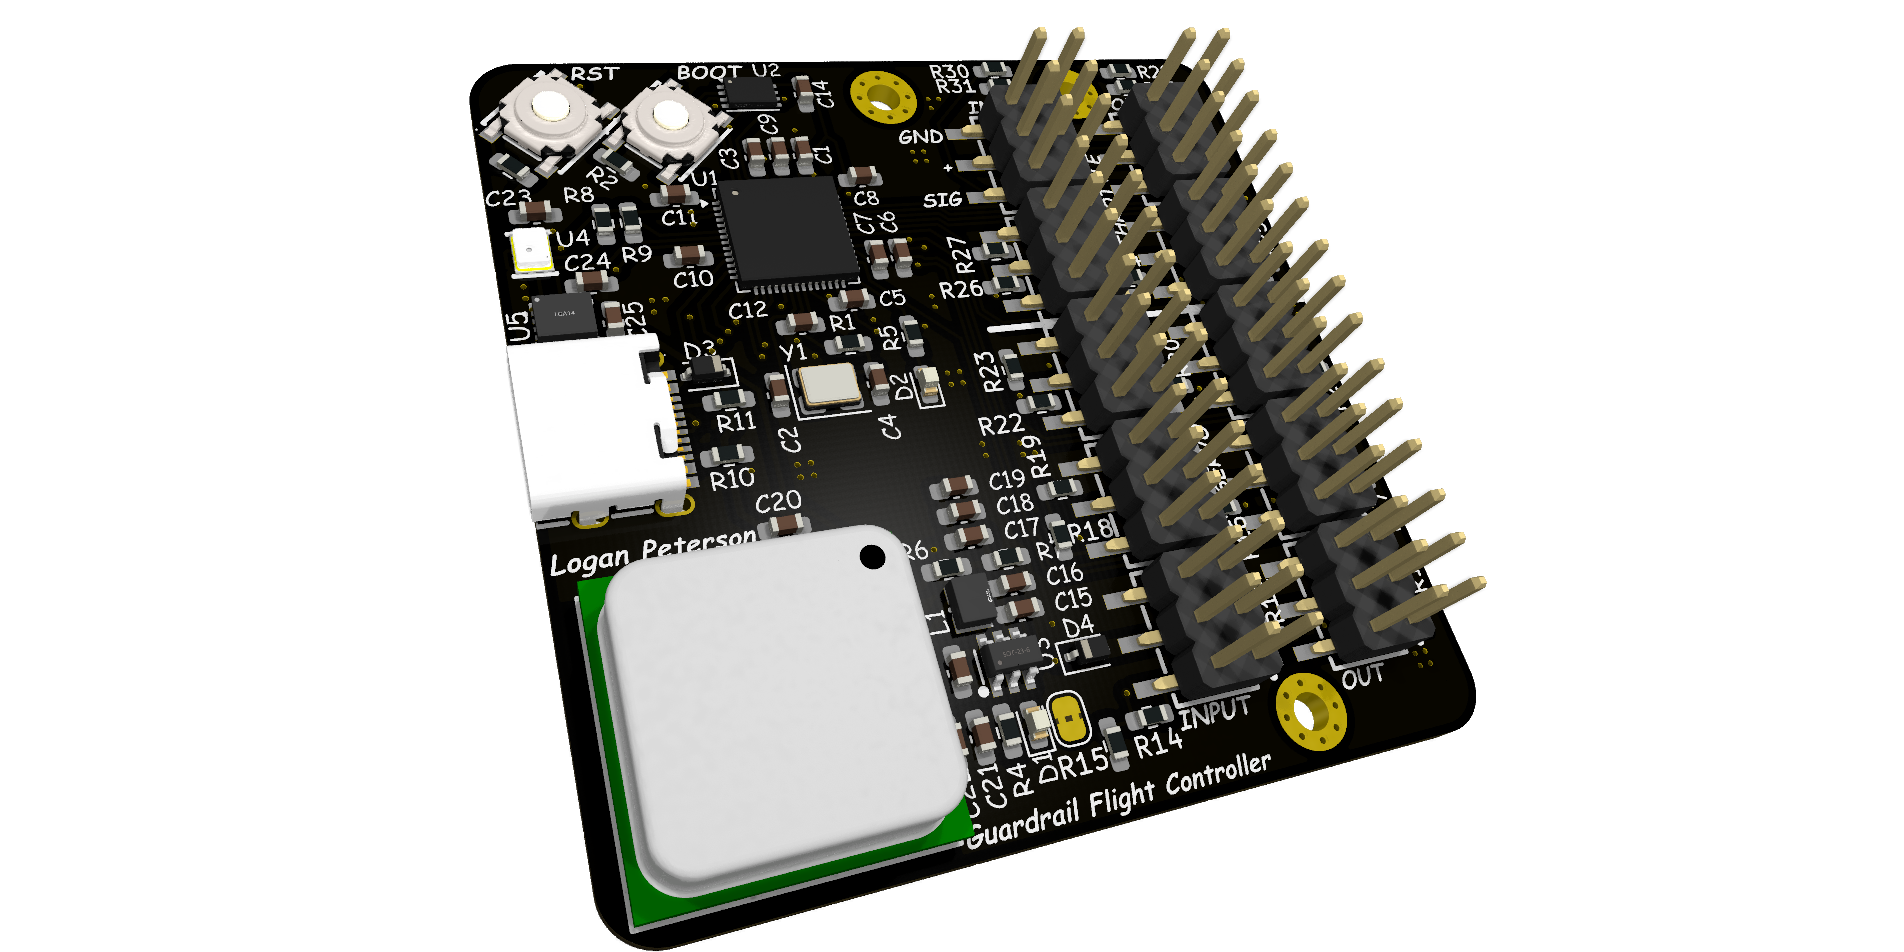
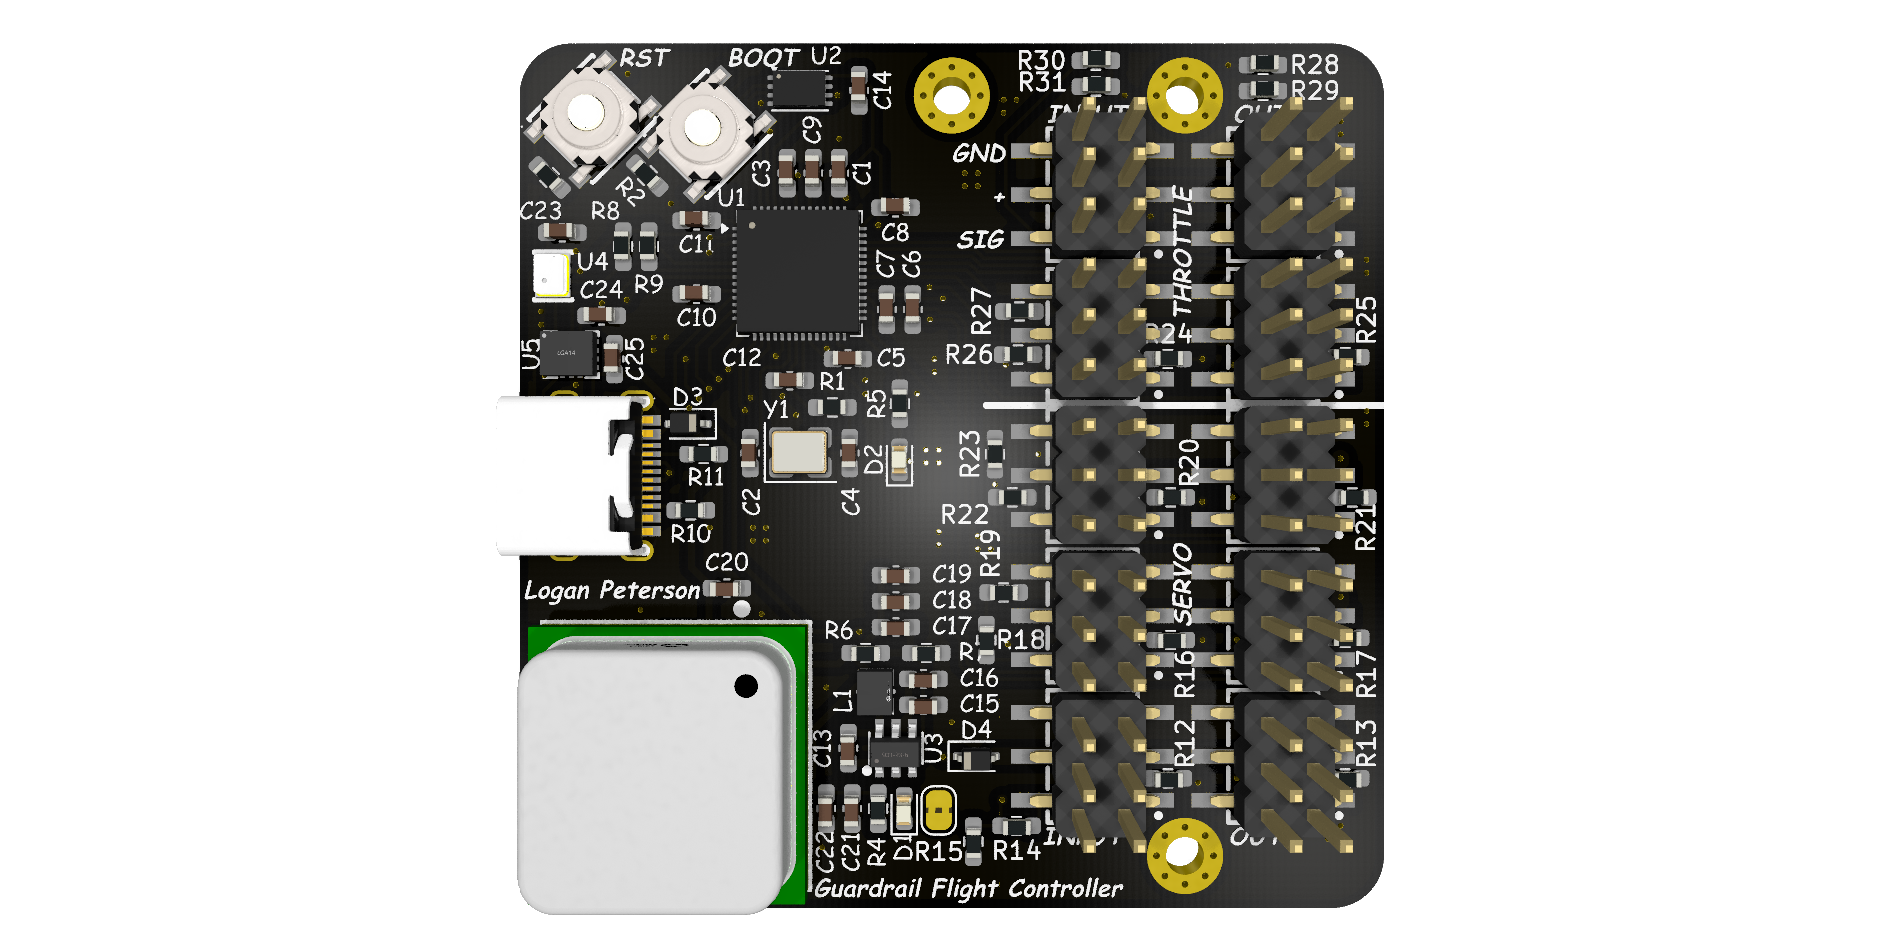
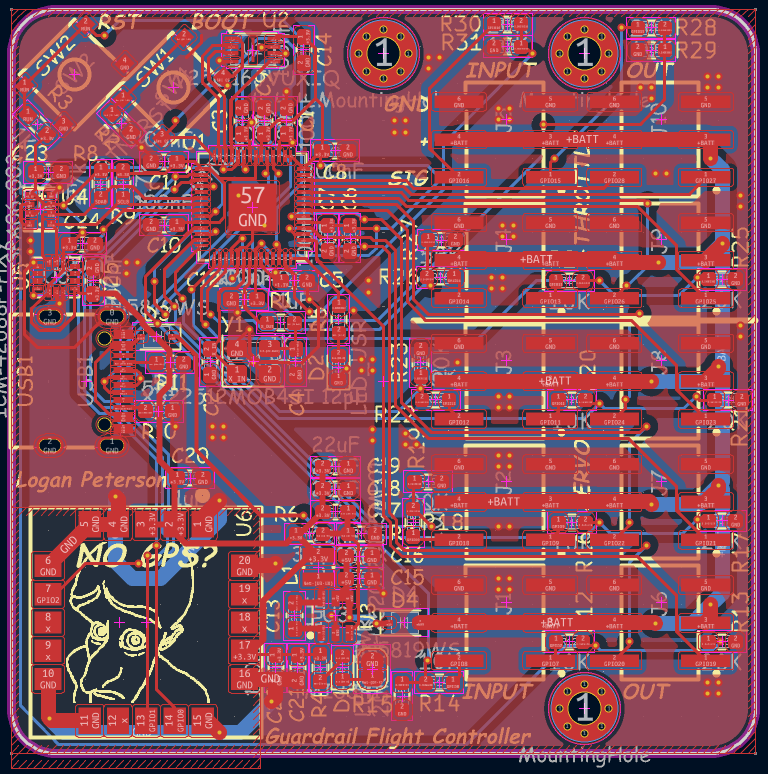
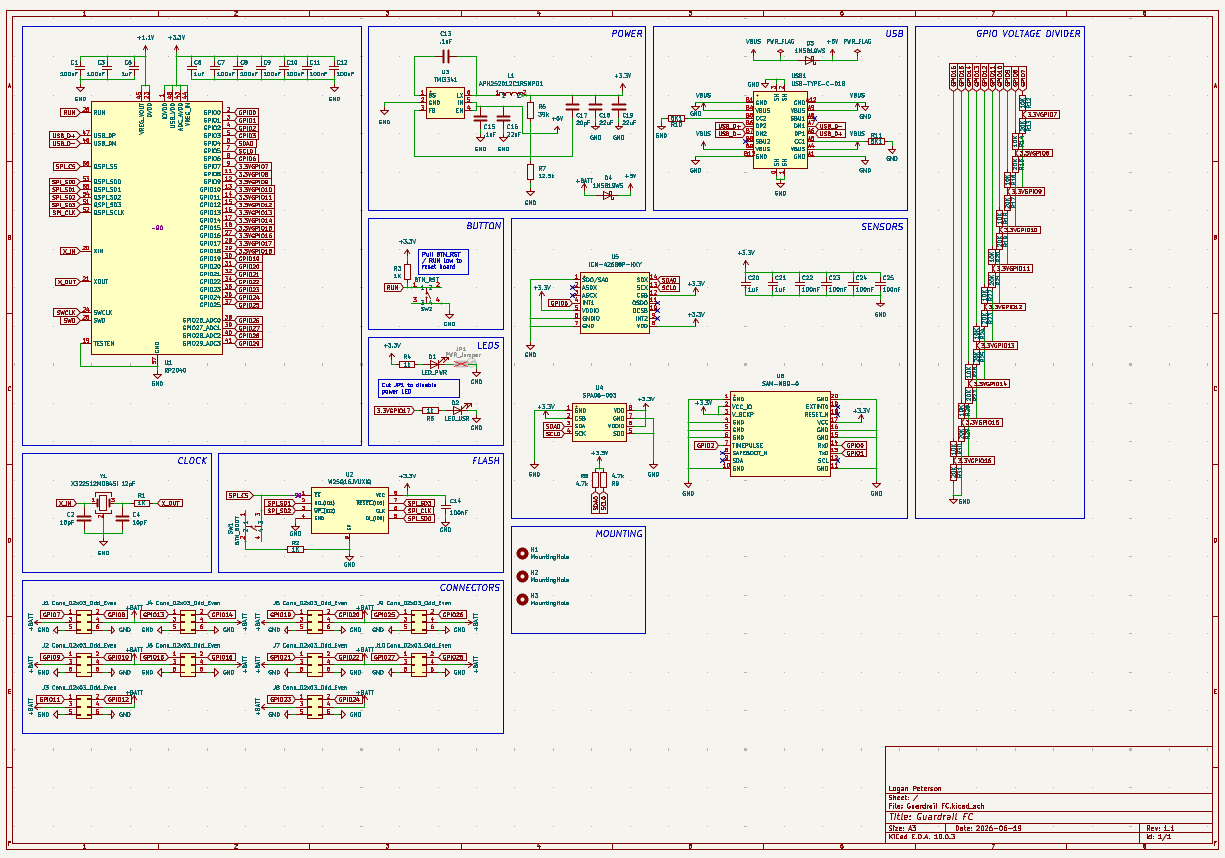
All the sensing and thinky bits live here.
Main characters:
(See BOM.csv for full part values, footprints, and sourcing.)
The Guardrail FC is a Flight Controller built around a RP2040 microcontroller and a handful of sensors, designed to help you not crash your RC planes and drones!
It does this by sitting in the middle of the data signals between the RC reciever and the plane's control surfaces / throttle. The board will use the pilot's input to steer the plane, but will lock the plane to certain bank angles in order to prevent the plane from flipping upside down and crashing. The board also logs all the sensor data and pilot inputs to its onboard flash, which can be retrieved after the flight to analyze flight characteristics afterwards.
On startup, the board will continuously read the IMU, GNSS, and pressure sensors to get an idea of the plane's orientation, position, and altitude. From these readings, the board calculates what angles the servos need to be at to get to a certain desired angle using a PID loop.
The board will then read the pilot's input from the RC receiver, and use that to control the desired angle for the plane.
At a high level:
The main feature of the Guardrail FC is its flight assist capabilities. By using the IMU data, the board can determine the plane's current orientation and adjust the control surfaces to keep the plane within a certain bank angle, preventing it from flipping upside down and crashing.
The board logs all sensor data and pilot inputs to its onboard flash memory. This allows you to analyze flight characteristics after the flight.
In addition to flight assist, the firmware includes a guarded automatic-throttle mode that uses pressure altitude, vertical speed, aircraft attitude, and optional GNSS ground speed. Waypoint navigation remains future work.
The firmware lives in Firmware/ and is written in Python using MicroPython. Interrupt-driven input capture keeps all ten receiver channels live while the controller reads sensors and logs the flight.
See the Firmware/README.md for more details on how to set up the firmware and tune the board for your specific plane.
Because crashing is bad, and this board helps you not crash! I've had an interest in RC planes and drones for a while, and by making this board, I can run whatever kind of firmware I want to create interesting flight characteristics. One of my friends recently created and crashed their custom built plane, and I wanted to make something that might have been able to save it!
This is a personal project, but if you have any ideas or suggestions, feel free to open an issue or submit a pull request! I'm always open to feedback and improvements.
This project is still in development, and I have yet to test it in flight. Remember to test in a safe environment before flying with hardware from a random internet person! I am not responsible for any crashes or damage caused by this board. Use at your own risk!
| Qty | Value | Footprint | References |
|---|---|---|---|
| 13 | 100nF | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C1, C3, C7, C8, C9, C10, C11, C12, C14, C22, C23, C24, C25 |
| 10 | 10K | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R12, R14, R16, R18, R20, R22, R24, R26, R28, R30 |
| 10 | 20K | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R13, R15, R17, R19, R21, R23, R25, R27, R29, R31 |
| 10 | Conn_02x03_Odd_Even | imported_components:HDR-SMD_6P-P2.54-V | J1, J2, J3, J4, J5, J6, J7, J8, J9, J10 |
| 4 | 1uF | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C5, C6, C20, C21 |
| 3 | 1K | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R1, R2, R3 |
| 3 | 22uF | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C16, C18, C19 |
| 3 | MountingHole | MountingHole:MountingHole_2.2mm_M2_Pad_Via | H1, H2, H3 |
| 2 | .1uF | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C13, C15 |
| 2 | 15pF | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C2, C4 |
| 2 | 1N5819WS | Diode_SMD:D_SOD-323 | D3, D4 |
| 2 | 1k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R4, R5 |
| 2 | 4.7k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R8, R9 |
| 2 | 5K1 | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R10, R11 |
| 2 | LOGO | LOGO | G***, NO GPS? |
| 1 | 12.5k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R7 |
| 1 | 20pF | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C17 |
| 1 | 39k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R6 |
| 1 | APH252012C1R5MP01 | easyeda2kicad:IND-SMD_APH252012C3R3MP01 | L1 |
| 1 | BTN_BOOT | imported_lcsc:SW-SMD_4P-L5.2-W5.2-P5.80-LS6.4 | SW1 |
| 1 | BTN_RST | imported_lcsc:SW-SMD_4P-L5.2-W5.2-P5.80-LS6.4 | SW2 |
| 1 | ICM-42688P-HXY | imported_lcsc:LGA-14_L3.0-W2.5-P0.50-TL | U5 |
| 1 | LED_PWR | LED_SMD:LED_0603_1608Metric | D1 |
| 1 | LED_USR | LED_SMD:LED_0603_1608Metric | D2 |
| 1 | PWR_Jumper | Jumper:SolderJumper-2_P1.3mm_Bridged2Bar_RoundedPad1.0x1.5mm | JP1 |
| 1 | RP2040 | Package_DFN_QFN:QFN-56-1EP_7x7mm_P0.4mm_EP3.2x3.2mm | U1 |
| 1 | SAM-M8Q-0 | imported_lcsc:LCC-20_L15.5-W15.5-P1.90_SAM-M10Q-00B | U6 |
| 1 | SPA06-003 | imported_lcsc:LGA-8_L2.5-W2.0-P0.65_SPA06-003 | U4 |
| 1 | TMI3341 | imported_lcsc:SOT-23-6_L2.9-W1.6-P0.95-LS2.8-BL | U3 |
| 1 | USB-TYPE-C-018 | imported_lcsc:USB-C_SMD-TYPE-C-31-M-12 | USB1 |
| 1 | W25Q16JVUXIQ | Package_SON:Winbond_USON-8-1EP_3x2mm_P0.5mm_EP0.2x1.6mm | U2 |
| 1 | X322512MOB4SI 12pF | Crystal:Crystal_SMD_3225-4Pin_3.2x2.5mm | Y1 |


Ethansuttor/drone_PCB
An 80×80 mm STM32F405 flight controller for a 4S freestyle quad, running Betaflight off a custom target I wrote.


Szymon423/Air-Quality-Sensor
Open-hardware indoor air quality monitor: ESP32-S3, SCD41 CO₂, SHT4x temp/humidity, SPA06 pressure, WS2812 LED ring. Round PCB in KiCad, 3D-printed enclosure.

adammakesthingsdev/Orpheus-Pico-Kicad
Kicad files and JLCPCB production gerbers for Orpheus Pico

Enderman8843/Rhenium
Rhenium is a Keyboard that is powered by RP2040 microprocessor that uses a USB-C,
It measures 50 × 50 mm and has 2 copper layers, 1.6 mm thick.
87 parts, built around the RP2040, SPA06-003, TMI3341 and W25Q16JVUXIQ. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the SharKingStudios/Guardrail-FC repository on GitHub, at the commit this page was made from: the board is PCB/Guardrail FC.kicad_pcb and its schematic PCB/Guardrail FC.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).