2 layers99.4 × 99.4 mm
RP2350 80QFN minimal
alvestav/alvestav-lee-thesis-project-2025
This is the GitHub repository for the thesis project in computer and electronics engineering by Alvestav and Lee
166 partsMIT
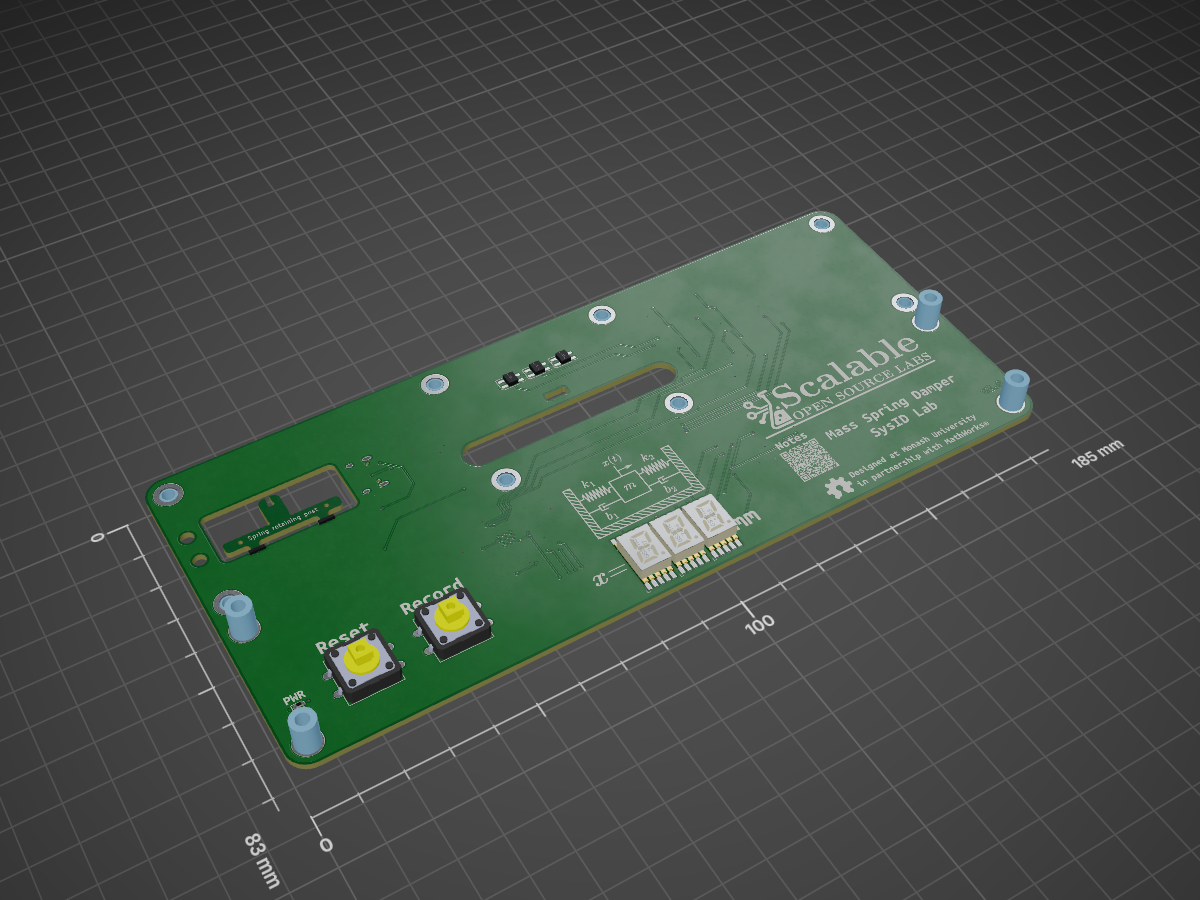
 Scalable-Open-Source-Labs/Mass-Spring-Damper-SysID-Lab1
An open source Mass-Spring-Damper to assist with teaching System Identification
Mass Spring Damper SysID Lab is an open-source printed circuit board by Scalable-Open-Source-Labs, from the Scalable-Open-Source-Labs/Mass-Spring-Damper-SysID-Lab repository on GitHub, published under the MIT licence. It is a 2-layer board of 185 × 83 mm with 135 parts on 99 nets, routed with 1,129 tracks and 129 vias.
It is built around the RP2040, 74AHCT125D and LM358, with the MAX7219M, W25Q16JVSSIQ and GS3011CR-G among its other parts. Its parts include 32 resistors, 27 capacitors, 16 ICs, 3 switches and 1 diode. It belongs with the RP2040 boards of this library.


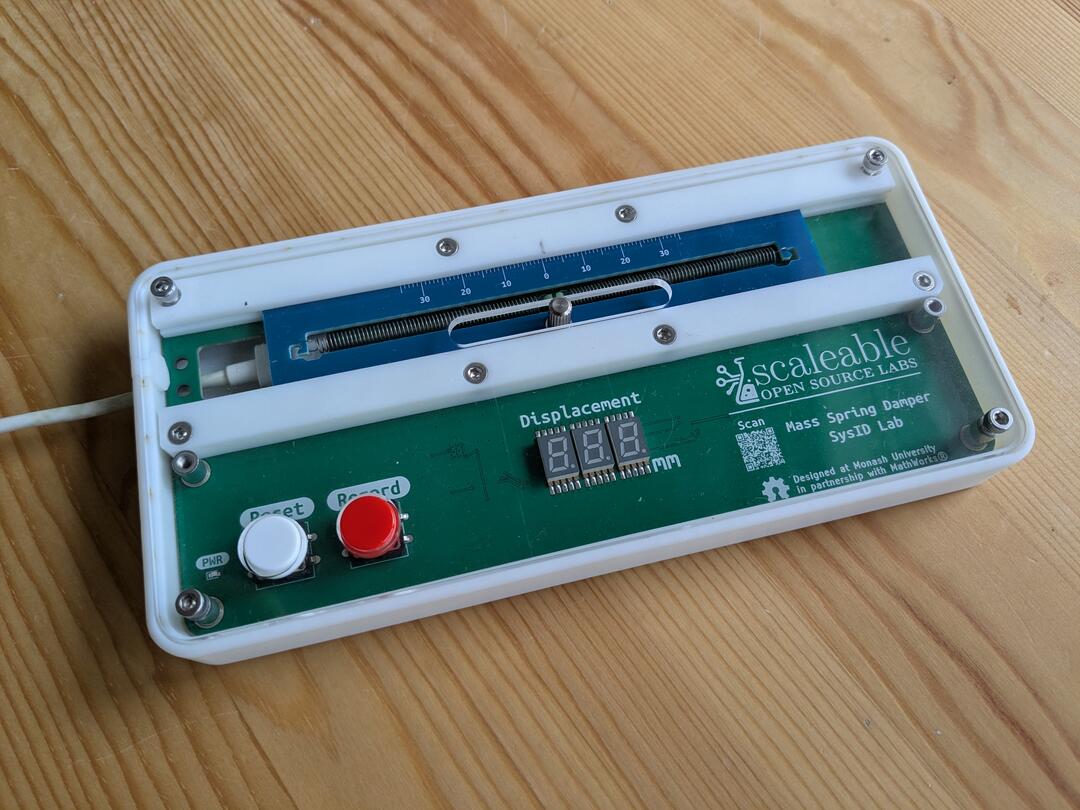
A low-cost dynamics lab that allows students to perform System Identification on a real Mass-Spring-Damper system.
This is the source repo where you can download files for manufacturing: hardware, firmware, and enclosure design files. If you're looking for usage instructions or lab notes, head to the user guide.
Designed by Michael Ruppe for Monash University in partnership with MathWorks®
| Path | What it is |
|---|---|
PCB/ | KiCad hardware source for the main board and carriage |
Enclosure/ | 3D-printable case, guide rail, and lasercut acrylic lid |
firmware-mass-spring-damper-sys-id-lab/ | Arduino sketch for the RP2040 main board |
Images/ | Photos used in the assembly guide |
Assembly-Instructions.md | Step-by-step mechanical build guide |
Programming-Instructions.md | Flashing and firmware dev setup |
Ordering-Instructions.md | Bill of materials and where to order/fabricate each part |
JLCPCB-Ordering-Instructions.md | Step-by-step JLCPCB order for the fabricated and assembled boards |
RELEASING.md | Maintainer checklist for cutting a tagged release |
This project is licensed under the MIT License.
Bundled third-party content — KiCad symbol/footprint libraries and vendor 3D step models under PCB/main-board/packages3D/ and PCB/carriage/CAD/, and the patched LedControl fork used by the firmware (see firmware README) — retains its original license terms.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 18 | 10k | Resistor_SMD:R_0603_1608Metric | R2, R3, R10, R11, R12, R15, R16, R17, R20, R21, R22, R26, R28, R29, R31, R32 +2 |
| 15 | 100nF | Capacitor_SMD:C_0603_1608Metric | C1, C2, C3, C4, C5, C6, C7, C8, C10, C11, C12, C13, C16, C22, C23 |
| 10 | TestPoint | TestPoint:TestPoint_Pad_D1.5mm | TP1, TP2, TP3, TP4, TP5, TP6, TP7, TP8, TP9, TP10 |
| 8 | SMTSO3060 | Footprints:MountingHole_SMTSO3060_3.2mm_M3 | H1, H2, H3, H4, H5, H6, H7, H8 |
| 7 | 1uF | Capacitor_SMD:C_0603_1608Metric | C14, C15, C21, C24, C25, C26, C27 |
| 7 | 220 | Resistor_SMD:R_0603_1608Metric | R8, R14, R19, R30, R34, R35, R36 |
| 4 | LOGO | LOGO | G***, G***, G***, G*** |
| 4 | SMTSO3080 | Footprints:MountingHole_SMTSO3080_3.2mm_M3 | H9, H10, H11, H12 |
| 3 | 10uF | Capacitor_SMD:C_0603_1608Metric | C19, C20, C28 |
| 3 | 330k | Resistor_SMD:R_0603_1608Metric | R6, R13, R18 |
| 3 | GS3011C | Footprints:GS3011 | U5, U6, U7 |
| 3 | ITR8307-S17-TR8 | OptoDevice:Everlight_ITR1201SR10AR | U9, U11, U12 |
| 2 | 1k | Resistor_SMD:R_0603_1608Metric | R25, R27 |
| 2 | 27R | Resistor_SMD:R_0603_1608Metric | R23, R24 |
| 2 | 27pF | Capacitor_SMD:C_0603_1608Metric | C17, C18 |
| 2 | LM358 | Package_SO:SOIC-8_3.9x4.9mm_P1.27mm | U2, U3 |
| 2 | LM393 | Package_SO:SOIC-8_3.9x4.9mm_P1.27mm | U1, U4 |
| 2 | VAL** | Footprints:mouse-bite-2mm-4mm-single-sided | mousebite1, mousebite2 |
| 1 | 12MHz 20pF 50Ohm_ESR | Crystal:Crystal_SMD_3225-4Pin_3.2x2.5mm | Y1 |
| 1 | 74AHCT125 | Package_SO:SOIC-14_3.9x8.7mm_P1.27mm | U10 |
| 1 | AMS1117-3.3 | Package_TO_SOT_SMD:SOT-223-3_TabPin2 | U15 |
| 1 | BOOT | Button_Switch_SMD:SW_Push_1P1T_NO_E-Switch_TL3301NxxxxxG | SW1 |
| 1 | G*** | kibuzzard-6A5DFDED | kibuzzard-6A5DFDED |
| 1 | G*** | kibuzzard-6A9CBA92 | kibuzzard-6A9CBA92 |
| 1 | G*** | kibuzzard-6A9CBA16 | kibuzzard-6A9CBA16 |
| 1 | G*** | kibuzzard-6A5DA214 | kibuzzard-6A5DA214 |
| 1 | G*** | kibuzzard-6A9CBA9F | kibuzzard-6A9CBA9F |
| 1 | G*** | kibuzzard-6A9CBA31 | kibuzzard-6A9CBA31 |
| 1 | G*** | kibuzzard-6978363D | kibuzzard-6978363D |
| 1 | G*** | kibuzzard-69310180 | kibuzzard-69310180 |
| 1 | G*** | kibuzzard-6A9CABE9 | kibuzzard-6A9CABE9 |
| 1 | G*** | kibuzzard-6A601CB9 | kibuzzard-6A601CB9 |
| 1 | G*** | kibuzzard-6A5D9E3D | kibuzzard-6A5D9E3D |
| 1 | G*** | kibuzzard-6A9CBA99 | kibuzzard-6A9CBA99 |
| 1 | G*** | kibuzzard-6A9CBB45 | kibuzzard-6A9CBB45 |
| 1 | G*** | kibuzzard-6A601CBF | kibuzzard-6A601CBF |
| 1 | G*** | kibuzzard-69783696 | kibuzzard-69783696 |
| 1 | G*** | kibuzzard-6A601CD4 | kibuzzard-6A601CD4 |
| 1 | G*** | kibuzzard-6A815F94 | kibuzzard-6A815F94 |
| 1 | G*** | kibuzzard-69645CED | kibuzzard-69645CED |
| 1 | G*** | kibuzzard-6A9CBA3E | kibuzzard-6A9CBA3E |
| 1 | G*** | kibuzzard-6A9CBA47 | kibuzzard-6A9CBA47 |
| 1 | G*** | kibuzzard-6A9CB9E8 | kibuzzard-6A9CB9E8 |
| 1 | G*** | kibuzzard-6A9CBA29 | kibuzzard-6A9CBA29 |
| 1 | G*** | kibuzzard-6930AF86 | kibuzzard-6930AF86 |
| 1 | G*** | kibuzzard-6A5DFE62 | kibuzzard-6A5DFE62 |
| 1 | MAX7219 | Package_SO:SOIC-24W_7.5x15.4mm_P1.27mm | U8 |
| 1 | PWR | LED_SMD:LED_0603_1608Metric | D2 |
| 1 | PolyFuse 1A Trip | Resistor_SMD:R_1206_3216Metric | F1 |
| 1 | REC/STOP | Button_Switch_THT:SW_SPST_Omron_B3F-40xx | SW2 |
| 1 | RESET | Button_Switch_THT:SW_SPST_Omron_B3F-40xx | SW3 |
| 1 | RP2040 | RP2040_minimal:RP2040-QFN-56 | U14 |
| 1 | USBLC6-2SC6 | Package_TO_SOT_SMD:SOT-23-6 | U13 |
| 1 | USB_C_Receptacle_USB2.0_16P | Connector_USB:USB_C_Receptacle_HCTL_HC-TYPE-C-16P-01A | J1 |
| 1 | W25Q16JVSS | Package_SO:SOIC-8_5.3x5.3mm_P1.27mm | U16 |
The 134 most common of 135 parts.
alvestav/alvestav-lee-thesis-project-2025
This is the GitHub repository for the thesis project in computer and electronics engineering by Alvestav and Lee

bejaouihamza/robotic_arm_controller
Traditional servo controllers simply send PWM signals. This board goes further:


RoboticsBrno/Robutek
Robůtek je robotická platforma založená na čipu ESP32-S3. Je velice rozšitiřelný, ale ze základu umí jezdit, kreslit fixou, jezdit po čáře, pohybovat se bludištěm. Programování je přes Jaculus.


It measures 185 × 83 mm and has 2 copper layers, 1.6 mm thick.
135 parts, built around the RP2040, 74AHCT125D, LM358 and MAX7219M. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the Scalable-Open-Source-Labs/Mass-Spring-Damper-SysID-Lab repository on GitHub, at the commit this page was made from: the board is PCB/main-board/main-board.kicad_pcb and its schematic PCB/carriage/carriage.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).