2 layers100 × 100 mm
Flipdot H Bridge
comakingspace/FlipDotDisplay
They were bought at the Makerfaire Hannover 2016.
76 parts3
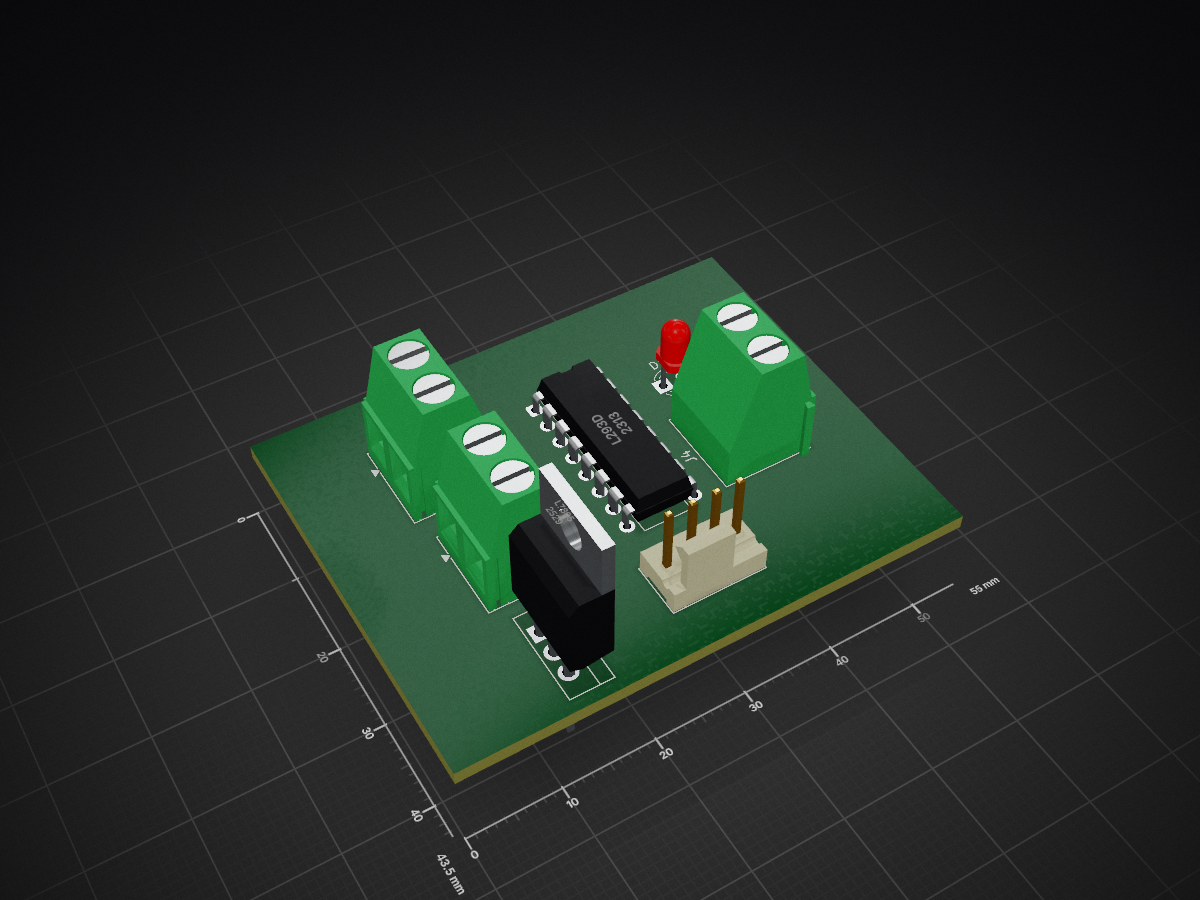
 Sandeeksha/L293-Motor-Driver
This project contains the schematic and PCB layout files for a basic L293D Motor Driver Module. The design uses the L293D H-Bridge IC to control two DC motors independently in both forward and reverse directions.
L298 Motor Driver is an open-source printed circuit board by Sandeeksha, from the Sandeeksha/L293-Motor-Driver repository on GitHub. It is a 2-layer board of 55 × 43.5 mm with 8 parts on 12 nets, routed with 135 tracks and 0 vias.
It is built around the L293D and L7805. Its parts include 4 connectors, 2 ICs, 1 resistor and 1 diode. It belongs with the robots and motor control and interfaces and adapters boards of this library.


This project contains the schematic and PCB for a motor driver circuit using an L293D H-Bridge IC, with a regulated 5V supply provided by a 7805 voltage regulator.
Schematic Diagram:
PCB Diagram:
3D View of Front Side PCB:
3D View of Back Side PCB:
J2.U2) regulates the voltage down to 5V for logic operation and powering low-power peripherals.L293D (U1) is a dual H-bridge motor driver IC used to drive two DC motors independently.J1 (4-pin header).J3 and J4, each controlling one motor.D1) with a current-limiting resistor (R1) is used to indicate that the 5V regulated power is available.PWR_FLAG symbols are added for validation to indicate power availability in schematic design tools.| Reference | Component | Description |
|---|---|---|
| U1 | L293D | Dual H-Bridge Motor Driver IC |
| U2 | 7805 | 5V Linear Voltage Regulator IC |
| J1 | Header | Motor Control Input Connector |
| J2 | Screw Terminal | External Voltage Input Connector |
| J3, J4 | Screw Terminals | Motor Output Connectors |
| R1 | Resistor | LED Current Limiting Resistor |
| D1 | LED | Power Status Indicator |
J2.U2 (7805) steps down the input voltage to 5V DC to power the logic circuitry.J1.U1 (L293D) uses these signals to drive two motors connected via J3 and J4.D1) lights up to indicate that 5V regulated power is available and the system is active.This project is open-source and free to use.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 3 | Screw_Terminal_01x02 | TerminalBlock_Phoenix:TerminalBlock_Phoenix_MKDS-1,5-2-5.08_1x02_P5.08mm_Horizontal | J2, J3, J4 |
| 1 | Conn_01x04_Pin | Connector:FanPinHeader_1x04_P2.54mm_Vertical | J1 |
| 1 | L293D | Package_DIP:DIP-16_W7.62mm | U1 |
| 1 | L7805 | Package_TO_SOT_THT:TO-220-3_Vertical | U2 |
| 1 | LED | LED_THT:LED_D3.0mm | D1 |
| 1 | R | Resistor_THT:R_Axial_DIN0204_L3.6mm_D1.6mm_P5.08mm_Horizontal | R1 |
comakingspace/FlipDotDisplay
They were bought at the Makerfaire Hannover 2016.


Yourself1011/sumo-bot
The code for Li Feng Yin and Daniel Zhang's sumo robot, for TEJ3MI


mrpossoms/openturret
Opensource designs and software for autonomously aiming gimble

It measures 55 × 43.5 mm and has 2 copper layers, 1.6 mm thick.
8 parts, built around the L293D and L7805. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the Sandeeksha/L293-Motor-Driver repository on GitHub, at the commit this page was made from: the board is L298 Motor Driver.kicad_pcb and its schematic L298 Motor Driver.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask Sandeeksha before reusing the design.