2 layers76.2 × 94 mm
Sumo
Yourself1011/sumo-bot
The code for Li Feng Yin and Daniel Zhang's sumo robot, for TEJ3MI
57 parts2

 personion222/sumo-robot1
TEJ3MI Final Sumo Wrestling Robot Project Files
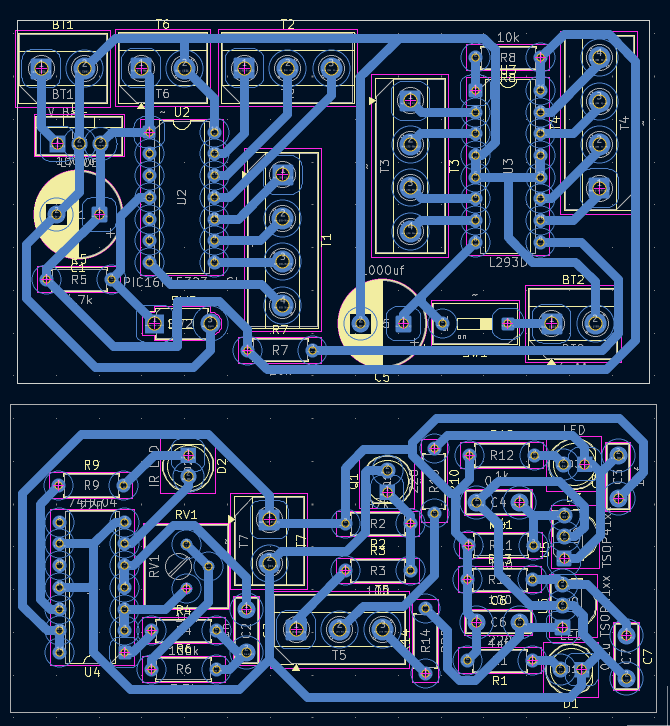
Sumobot is an open-source printed circuit board by personion222, from the personion222/sumo-robot repository on GitHub. It is a 2-layer board of 73.9 × 42.4 mm with 43 parts on 49 nets, routed with 265 tracks and 0 vias.
It is built around the L293D, 74HC04D and L7805. Its parts include 14 resistors, 7 capacitors, 6 ICs, 3 diodes and 2 switches. It belongs with the PIC boards of this library.


Speedbump - TEJ3MI sumo robot competition 2nd place winner.
designed in OnShape and 3D printed
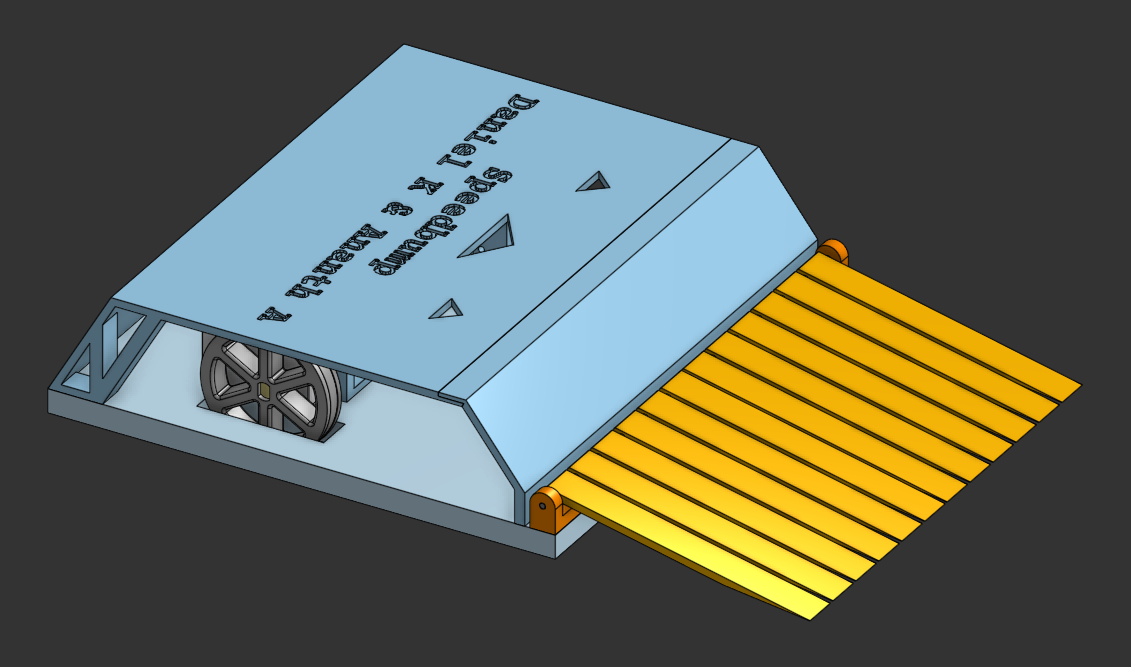
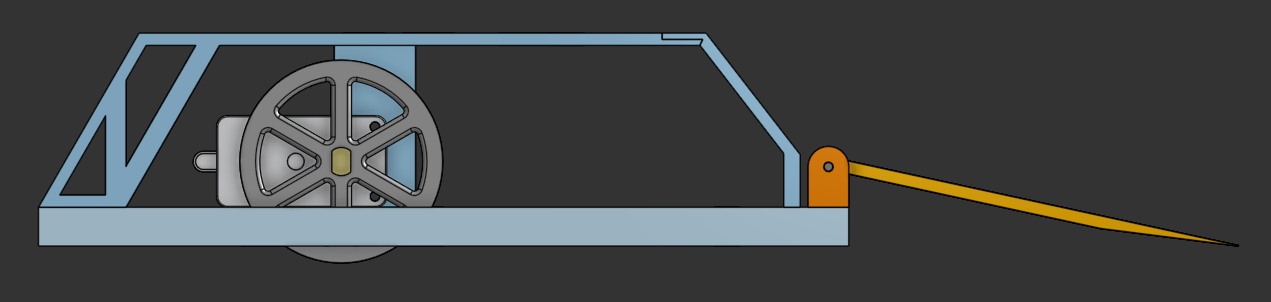
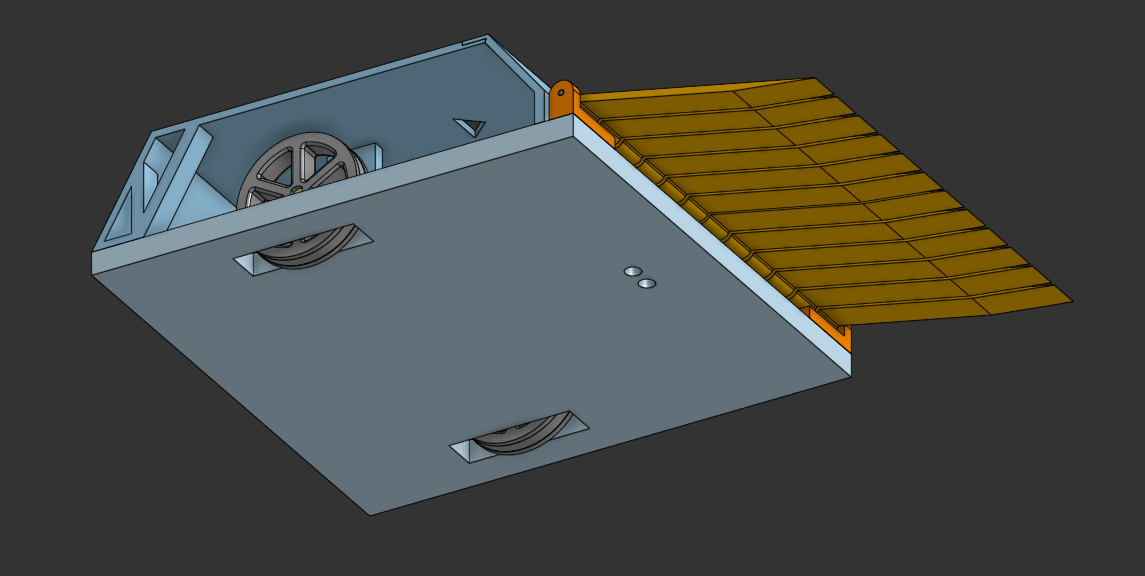
board designed in KiCad
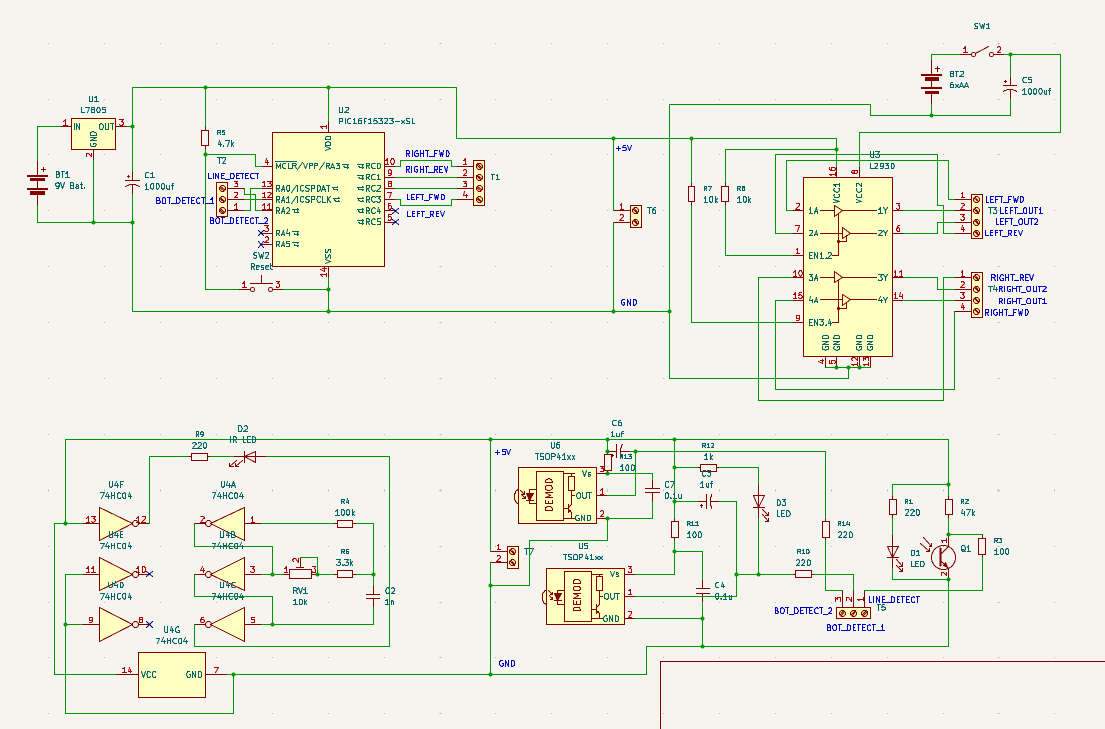
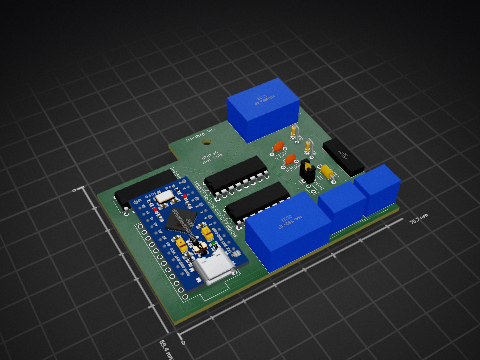
powered by PIC16F15323 programmed with GCBasic script
| Qty | Value | Footprint | References |
|---|---|---|---|
| 4 | 220 | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R1, R9, R10, R14 |
| 3 | 100 | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R3, R11, R13 |
| 3 | ~ | TerminalBlock_MetzConnect:TerminalBlock_MetzConnect_Type101_RT01604HBWC_1x04_P5.08mm_Horizontal | T1, T3, T4 |
| 2 | 0.1u | Capacitor_THT:C_Disc_D7.5mm_W2.5mm_P5.00mm | C4, C7 |
| 2 | 1000uf | Capacitor_THT:CP_Radial_D10.0mm_P5.00mm | C1, C5 |
| 2 | 10k | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R7, R8 |
| 2 | 1uf | Capacitor_THT:C_Disc_D7.5mm_W2.5mm_P5.00mm | C3, C6 |
| 2 | LED | LED_THT:LED_D5.0mm_Clear | D1, D3 |
| 2 | TSOP41xx | OptoDevice:Vishay_MOLD-3Pin | U5, U6 |
| 2 | ~ | TerminalBlock_MetzConnect:TerminalBlock_MetzConnect_Type101_RT01603HBWC_1x03_P5.08mm_Horizontal | T2, T5 |
| 2 | ~ | TerminalBlock_MetzConnect:TerminalBlock_MetzConnect_Type101_RT01602HBWC_1x02_P5.08mm_Horizontal | T6, T7 |
| 1 | 100k | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R4 |
| 1 | 10k | Potentiometer_THT:Potentiometer_Bourns_3386P_Vertical | RV1 |
| 1 | 1k | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R12 |
| 1 | 1n | Capacitor_THT:C_Disc_D7.5mm_W2.5mm_P5.00mm | C2 |
| 1 | 3.3k | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R6 |
| 1 | 4.7k | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R5 |
| 1 | 47k | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R2 |
| 1 | 6xAA | TerminalBlock_MetzConnect:TerminalBlock_MetzConnect_Type101_RT01602HBWC_1x02_P5.08mm_Horizontal | BT2 |
| 1 | 74HC04 | Package_DIP:DIP-14_W7.62mm | U4 |
| 1 | 9V Bat. | TerminalBlock_MetzConnect:TerminalBlock_MetzConnect_Type101_RT01602HBWC_1x02_P5.08mm_Horizontal | BT1 |
| 1 | IR LED | LED_THT:LED_D5.0mm_IRBlack | D2 |
| 1 | L293D | Package_DIP:DIP-16_W7.62mm | U3 |
| 1 | L7805 | Package_TO_SOT_THT:TO-220-3_Vertical | U1 |
| 1 | PIC16F15323-xSL | Package_DIP:DIP-14_W7.62mm | U2 |
| 1 | Reset | custom:SW_PUSH_1P1T_6x3.5mm_H5.0_APEM_MJTP1250 | SW2 |
| 1 | ~ | LED_THT:LED_D5.0mm_Clear | Q1 |
| 1 | ~ | Button_Switch_THT:SW_DIP_SPSTx01_Slide_9.78x4.72mm_W7.62mm_P2.54mm | SW1 |
Yourself1011/sumo-bot
The code for Li Feng Yin and Daniel Zhang's sumo robot, for TEJ3MI

comakingspace/FlipDotDisplay
They were bought at the Makerfaire Hannover 2016.


mrpossoms/openturret
Opensource designs and software for autonomously aiming gimble

abdelrauf-44/Self-Balancing-Robot
ESP32-based self-balancing robot using MPU6050 IMU and PID control, with wireless monitoring and tuning via Blynk.
It measures 73.9 × 42.4 mm and has 2 copper layers, 1.58 mm thick.
43 parts, built around the L293D, 74HC04D and L7805. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the personion222/sumo-robot repository on GitHub, at the commit this page was made from: the board is sumobot.kicad_pcb and its schematic sumobot.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask personion222 before reusing the design.