

2 layers61 × 36.8 mm
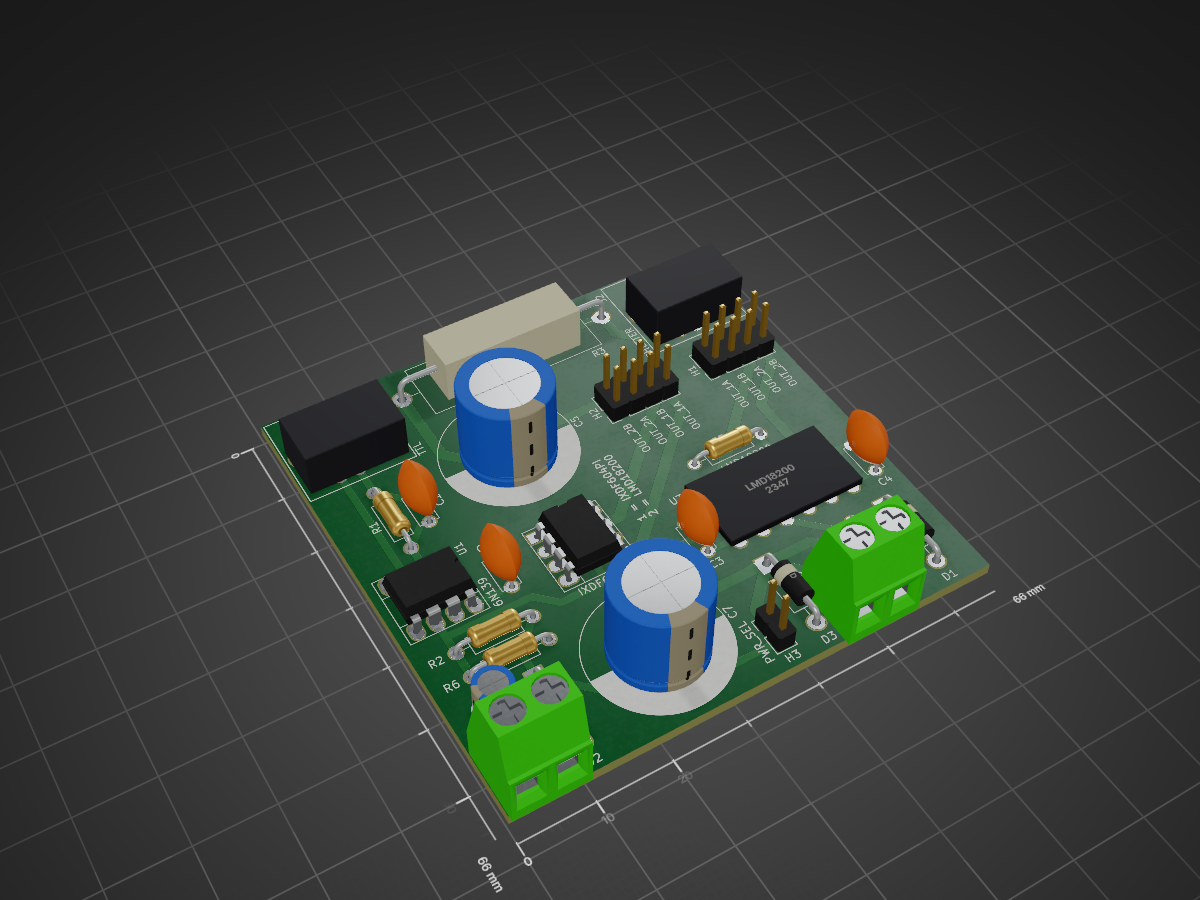
 RiceAMO/HDD_Shutter_Driver
HDD shutter driver circuit.
Shutter Driver is an open-source printed circuit board by RiceAMO, from the RiceAMO/HDD_Shutter_Driver repository on GitHub, published under the MIT licence. It is a 2-layer board of 66 × 66 mm with 26 parts on 24 nets, routed with 105 tracks and 0 vias.
It is built around the IXDF604PI and LMD18200T. Its parts include 7 capacitors, 6 resistors, 4 connectors, 3 ICs and 3 diodes.
HDD shutter driver circuit based on Rob Scholten's 2007 RSI paper (see below). Modifications include the option of using an IXYS IXDF604PI (about $2/IC) instead of the TI LMD18200 (about $17/IC) to drive the shutter.
The main circuit for driving HDD shutters.
Circuit used to breakout a power supply for multiple shutter driver boards.
Enhanced laser shutter using a hard disk drive rotary voice-coil actuator
R. E. Scholten
Review of Scientific Instruments 78, 026101 (2007)
https://doi.org/10.1063/1.2437199
| Qty | Value | Footprint | References |
|---|---|---|---|
| 2 | 10nF | Capacitors_ThroughHole:C_Disc_D5.0mm_W2.5mm_P5.00mm | C3, C4 |
| 2 | D | Diodes_ThroughHole:D_DO-41_SOD81_P10.16mm_Horizontal | D2, D3 |
| 1 | 0.1uF | Capacitors_ThroughHole:C_Disc_D5.0mm_W2.5mm_P5.00mm | C2 |
| 1 | 10k | Resistors_ThroughHole:R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R4 |
| 1 | 10uF | Capacitors_ThroughHole:CP_Radial_D5.0mm_P2.00mm | C6 |
| 1 | 2.7k | Resistors_ThroughHole:R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R5 |
| 1 | 2500uF | Capacitors_ThroughHole:CP_Radial_D18.0mm_P7.50mm | C7 |
| 1 | 5.6V | Diodes_ThroughHole:D_DO-41_SOD81_P10.16mm_Horizontal | D1 |
| 1 | 6N139 | Housings_DIP:DIP-8_W7.62mm_Socket_LongPads | U1 |
| 1 | C | Capacitors_ThroughHole:CP_Radial_D18.0mm_P7.50mm | C5 |
| 1 | CP | Capacitors_ThroughHole:C_Disc_D5.0mm_W2.5mm_P5.00mm | C1 |
| 1 | IC_PWR | Sockets_MOLEX_KK-System:Socket_MOLEX-KK-RM2-54mm_Lock_2pin_straight | P1 |
| 1 | IXDF604PI | Housings_DIP:DIP-8_W7.62mm_Socket_LongPads | U2 |
| 1 | LMD18200 | TO_SOT_Packages_THT:Multiwatt_15_Vertical | U3 |
| 1 | PWR_SEL | Pin_Headers:Pin_Header_Straight_1x02_Pitch2.54mm | H3 |
| 1 | R | Resistors_ThroughHole:R_Axial_Power_L25.0mm_W9.0mm_P30.48mm | R3 |
| 1 | R | Resistors_ThroughHole:R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R6 |
| 1 | RI | Resistors_ThroughHole:R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R1 |
| 1 | RL | Resistors_ThroughHole:R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R2 |
| 1 | SEL_1 | Pin_Headers:Pin_Header_Straight_2x04_Pitch2.54mm | H1 |
| 1 | SEL_2 | Pin_Headers:Pin_Header_Straight_2x04_Pitch2.54mm | H2 |
| 1 | SHUTTER | Sockets_BNC:BNC_Socket_TYCO-AMP_LargePads | J2 |
| 1 | SHUTTER_PWR | Sockets_MOLEX_KK-System:Socket_MOLEX-KK-RM2-54mm_Lock_2pin_straight | P2 |
| 1 | TTL | Sockets_BNC:BNC_Socket_TYCO-AMP_LargePads | J1 |

Cemetech/TI-DCC
Direct z80 ASM DCC implementation for the TI-84 Plus C Silver Edition and similar calculators.

Pr0fiNoob/MopBot
MopBot ist ein experimenteller Bodenreinigungsroboter. Die Python-Software MopSlothOS läuft auf einem Raspberry Pi und übernimmt Navigation sowie die übergeordnete Steuerung.


ClubRobotInsat/cartes
Toutes les cartes ici sont les cartes en développement au club. Vous pouvez retrouver dans les release les cartes correspondant à chaque robot.

ClubRobotInsat/h_bridge_2018
The H bridge PCB we use to power and control our DC motors


frangipp/TANK-PCB
Projet étudiant réalisé en binôme à l’ESEO Angers, ce TANK est un robot mobile à entraînement différentiel, piloté en Bluetooth via une application Android.

It measures 66 × 66 mm and has 2 copper layers, 1.6 mm thick.
26 parts, built around the IXDF604PI and LMD18200T. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the RiceAMO/HDD_Shutter_Driver repository on GitHub, at the commit this page was made from: the board is Shutter_Driver/Shutter_Driver.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).