2 layers102 × 90.8 mm
Kicad project
OPRobots/DragonBot2
Siguelíneas de tipo Robotracer para competir en la All Japan Robotracer 2027
252 parts5
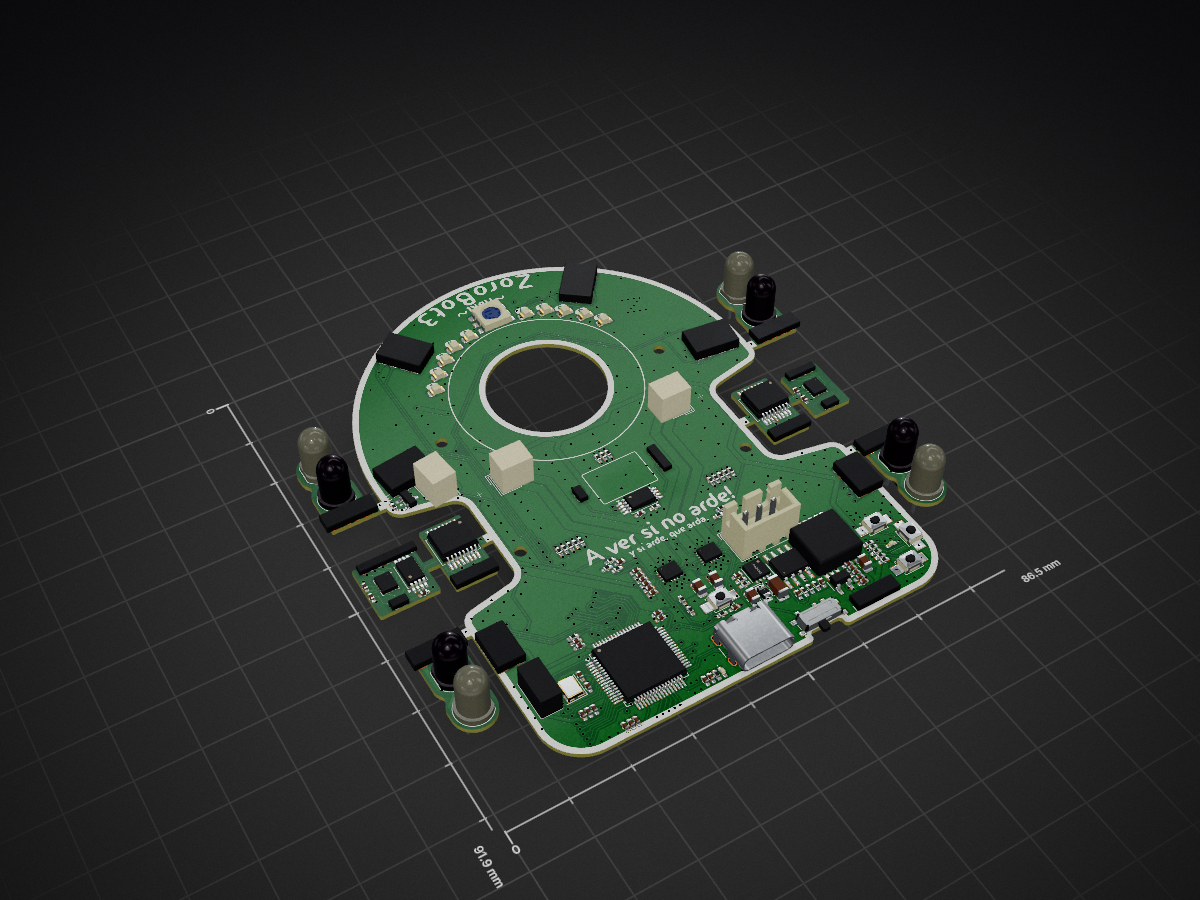
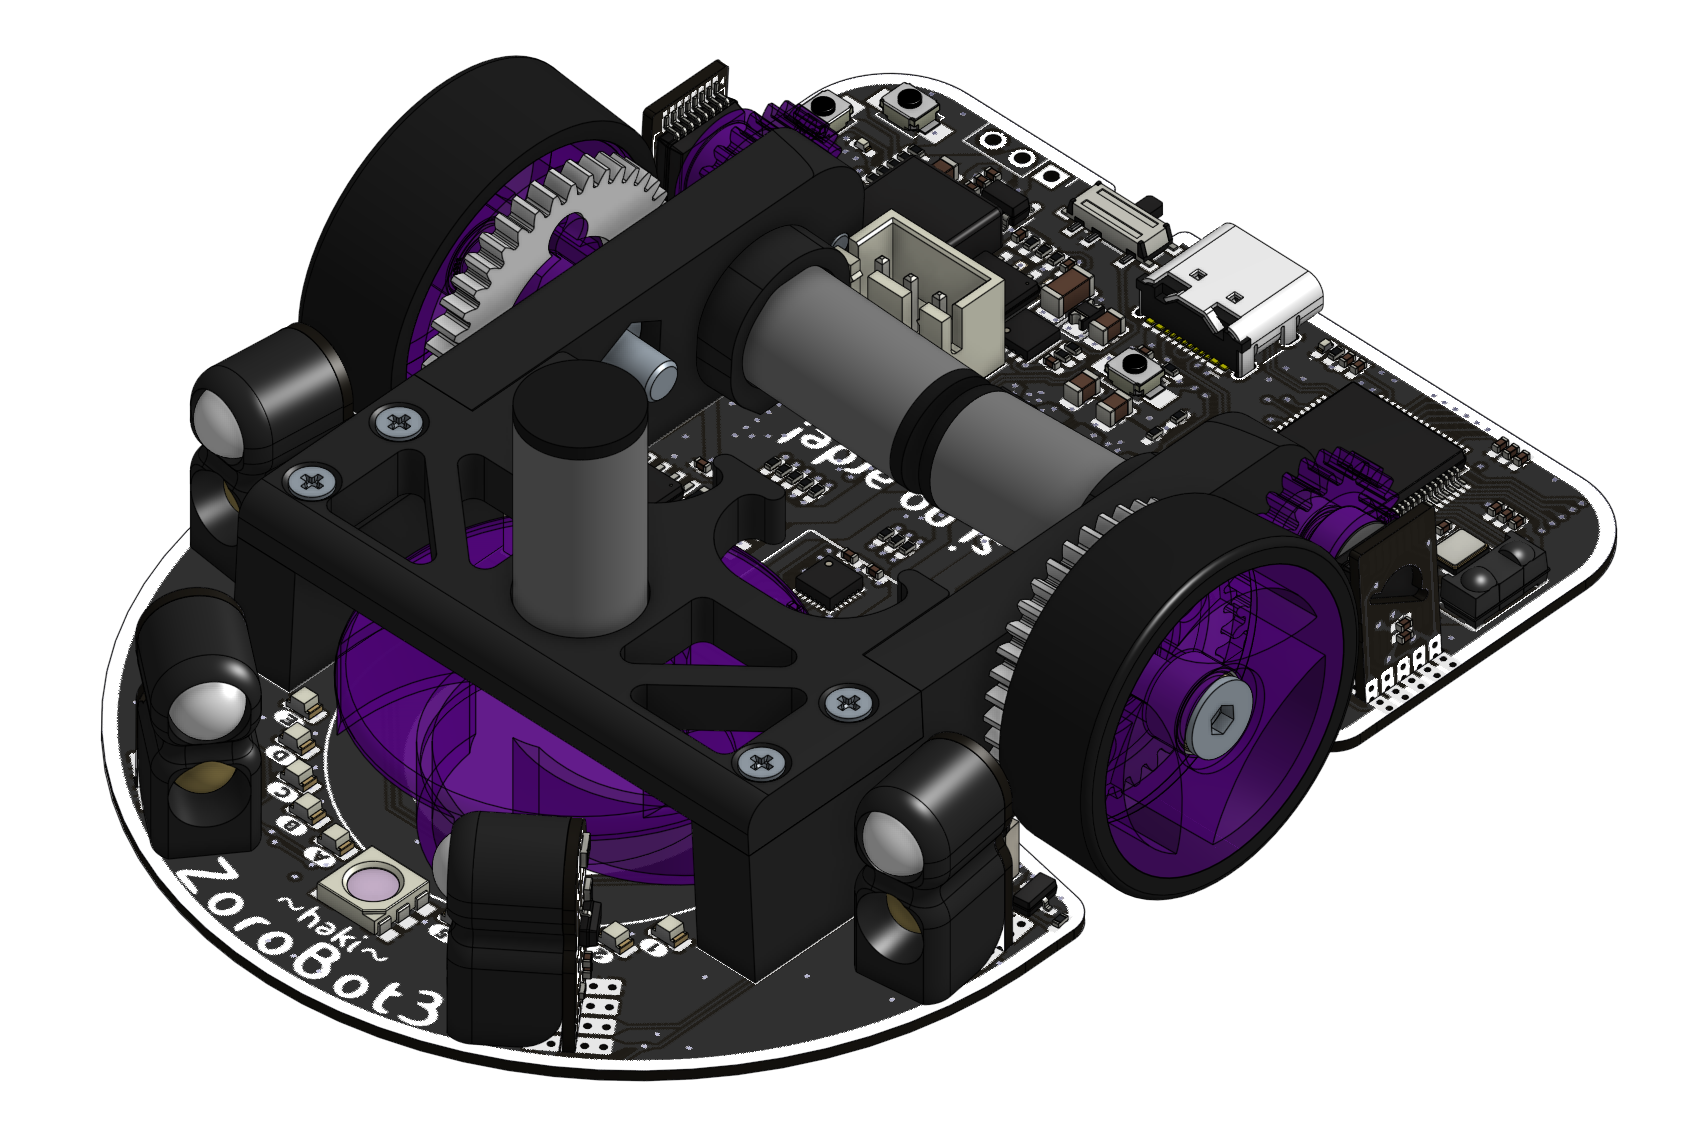
 OPRobots/ZoroBot343
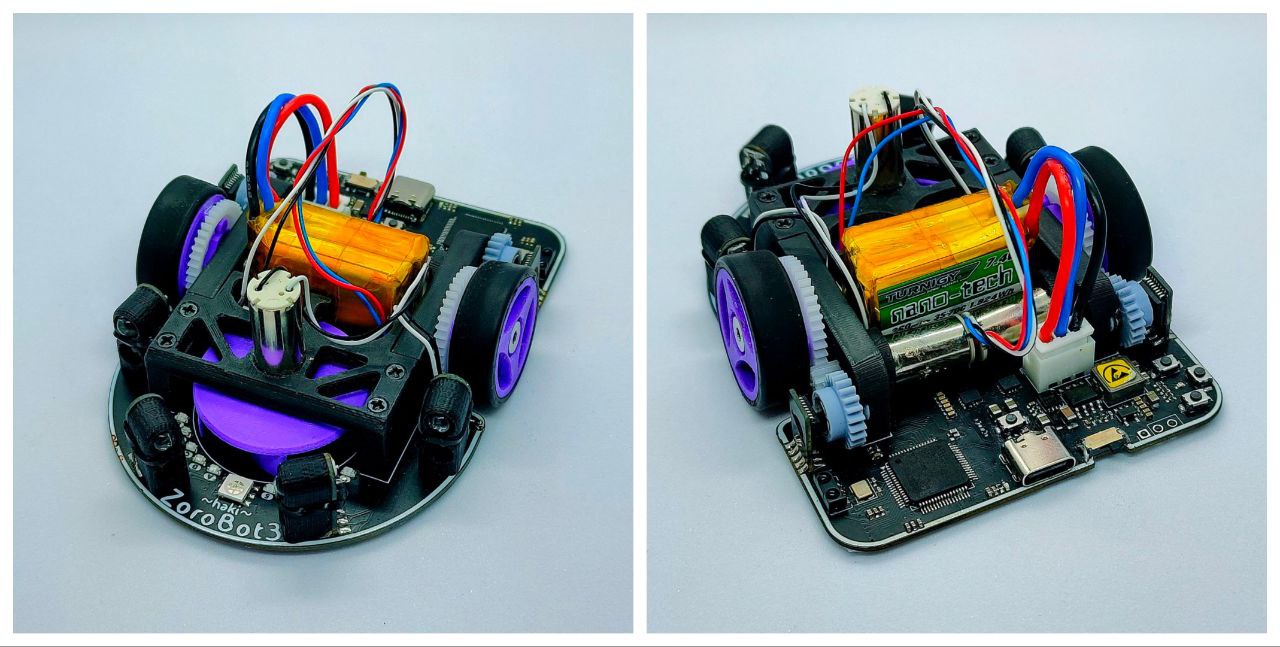
Tercera versión de nuestro primer robot. Un robot micromouse de alto rendimiento con STM32F4, encoders magneticos de alta resolución, succión y muchos leds molones.
ZoroBot3 is an open-source printed circuit board by OPRobots, from the OPRobots/ZoroBot3 repository on GitHub, published under the GPL-3.0 licence. It is a 2-layer board of 86.5 × 91.9 mm with 205 parts on 171 nets, routed with 2,621 tracks and 662 vias.
It is built around the STM32F405RGT6, AO3400A and AON7423. Its parts include 58 capacitors, 35 resistors, 14 diodes, 5 transistors and 1 inductor. It belongs with the robots and motor control boards and the STM32 boards of this library.


Tercera versión de nuestro primer robot. Un robot micromouse de alto rendimiento con STM32F4, encoders magneticos de alta resolución, succión y muchos leds molones.
| 🥇 | 🥈 | 🥉 |
|---|---|---|
| 8 | 0 | 0 |
| Evento | Categoría | Posición | Año |
|---|---|---|---|
 Micromouse Portuguese Contest | Micromouse Classic | 🥇 | 2026 |
 RoboChallenge | Maze | 🥇 | 2025 |
 OSHWDem | Micromouse Classic | 🥇 | 2025 |
| Micromouse Portugese Contest | Micromouse Classic | 🥇 | 2025 |
| Micromouse Portugese Contest | Time Trial | 🥇 | 2025 |
| RoboChallenge | Maze | 🥇 | 2024 |
| OSHWDem | Micromouse Classic | 🥇 | 2024 |
| OSHWDem | Micromouse Wall-Follower | 🥇 | 2023 |
| Qty | Value | Footprint | References |
|---|---|---|---|
| 24 | 0.1uF | Capacitor_SMD:C_0402_1005Metric_Pad0.74x0.62mm_HandSolder | C2, C4, C7, C10, C11, C17, C20, C21, C24, C33, C35, C37, C38, C39, C40, CR1 +8 |
| 20 | 10uF | Capacitor_SMD:C_0402_1005Metric_Pad0.74x0.62mm_HandSolder | C3, C6, C9, C23, C30, C41, C42, C44, C45, C46, C47, C48, C49, C50, C51, C52 +4 |
| 14 | 330 | Resistor_SMD:R_0402_1005Metric_Pad0.72x0.64mm_HandSolder | R1, R2, R3, R4, R5, R6, R7, R8, R9, R10, R14, R15, R16, R22 |
| 10 | LED | LED_SMD:LED_0805_2012Metric | D1, D2, D3, D4, D5, D6, D7, D8, D9, D10 |
| 8 | 47K | Resistor_SMD:R_0402_1005Metric_Pad0.72x0.64mm_HandSolder | R11, R17, R24, R25, RS5, RS6, RS11, RS12 |
| 5 | 1uF | Capacitor_SMD:C_0402_1005Metric_Pad0.74x0.62mm_HandSolder | C18, C22, C32, C34, CR3 |
| 5 | AO3400A | Package_TO_SOT_SMD:SOT-23 | MOSFET-N-SUC1, MOSFET-N1, MOSFET-N2, MOSFET-N3, MOSFET-N4 |
| 4 | 33 | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | RS1, RS2, RS7, RS8 |
| 4 | 47uF | Capacitor_SMD:C_0805_2012Metric | C5, C8, C31, C43 |
| 4 | 5k | Resistor_SMD:R_0402_1005Metric_Pad0.72x0.64mm_HandSolder | RCM1, RCM2, RCM3, RCM4 |
| 4 | Conn_01x04_Socket | custom_footprints:ZoroBot3_Sensors | CONN_SEN_FRONT_D1, CONN_SEN_FRONT_I1, CONN_SEN_PA_D1, CONN_SEN_PA_I1 |
| 4 | Conn_01x04_Socket | custom_footprints:ZoroBot3_Main_sensors | SEN_FRONT_D1, SEN_FRONT_I1, SEN_PARED_D1, SEN_PARED_I1 |
| 4 | SFH-4550 | LED_THT:LED_D5.0mm_Clear | LED_IR1, LED_IR2, LED_IR3, LED_IR4 |
| 4 | ST-1KL3A | LED_THT:LED_D5.0mm_IRBlack | Q3, Q4, Q5, Q6 |
| 4 | ~ | custom_footprints:Generic_SmallButton_6x3 | BTN_RST1, BTN1, BTN2, BTN3 |
| 3 | 10K | Resistor_SMD:R_0402_1005Metric_Pad0.72x0.64mm_HandSolder | R27, RRAM1, RRAM2 |
| 3 | 1K | Resistor_SMD:R_0402_1005Metric_Pad0.72x0.64mm_HandSolder | R20, R23, R28 |
| 3 | Conn_01x02_Socket | custom_footprints:ZoroBot3_Power_MPU | POWER_MPU1, POWER_MPU2, POWER_MPU3 |
| 3 | Conn_01x02_Socket | custom_footprints:Connector_motor_1.25_Hirose_DF13-02P-1.25DSA_1x02_P1.25mm_Vertical | Mot_D1, Mot_I1, Mot_S1 |
| 2 | 0.1uF | Capacitor_SMD:C_0603_1608Metric | CR4, CR7 |
| 2 | 1.5K | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | RS9, RS10 |
| 2 | 1k | Resistor_SMD:R_0402_1005Metric_Pad0.72x0.64mm_HandSolder | RF1, RF2 |
| 2 | 2.2uF | Capacitor_SMD:C_0402_1005Metric_Pad0.74x0.62mm_HandSolder | C12, C19 |
| 2 | 20pF | Capacitor_SMD:C_0402_1005Metric_Pad0.74x0.62mm_HandSolder | C13, C15 |
| 2 | 220nF | Capacitor_SMD:C_0402_1005Metric_Pad0.74x0.62mm_HandSolder | CF1, CF2 |
| 2 | 23AA04M-I/ST | Package_SO:TSSOP-8_4.4x3mm_P0.65mm | SRAM1, SRAM2 |
| 2 | 3.3K | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | RS3, RS4 |
| 2 | AS5145B-HSST | custom_footprints:Encoder_AS5145B | AS5145B_D1, AS5145B_I1 |
| 2 | Conn_01x04_Socket | custom_footprints:ZoroBot3_Data_MPU | DATA_MPU1, DATA_MPU2 |
| 2 | Conn_01x05_Pin | custom_footprints:ZoroBot3_PCBmodule_encoder | ENC_D_CONN1, ENC_I_CONN1 |
| 2 | Conn_01x05_Socket | custom_footprints:ZoroBot3_PCBmain_Encoder | ENC_D1, ENC_I1 |
| 2 | D | Diode_SMD:D_0805_2012Metric_Pad1.15x1.40mm_HandSolder | D13, DS1 |
| 2 | LED | LED_SMD:LED_0402_1005Metric_Pad0.77x0.64mm_HandSolder | D11, D12 |
| 2 | ~ | Package_LGA:Bosch_LGA-14_3x2.5mm_P0.5mm | LSM6DSR1, LSM6DSR2 |
| 2 | ~ | custom_footprints:PH-MP6551GQB-P | PH1, PH2 |
| 1 | 100K | Resistor_SMD:R_0402_1005Metric_Pad0.72x0.64mm_HandSolder | R18 |
| 1 | 100k | Resistor_SMD:R_0402_1005Metric_Pad0.72x0.64mm_HandSolder | R30 |
| 1 | 27K | Resistor_SMD:R_0402_1005Metric_Pad0.72x0.64mm_HandSolder | R26 |
| 1 | 27k | Resistor_SMD:R_0402_1005Metric_Pad0.72x0.64mm_HandSolder | R19 |
| 1 | 4.7uF | Capacitor_SMD:C_0402_1005Metric_Pad0.74x0.62mm_HandSolder | C1 |
| 1 | 45K | Resistor_SMD:R_0402_1005Metric_Pad0.72x0.64mm_HandSolder | R29 |
| 1 | 47k | Resistor_SMD:R_0402_1005Metric_Pad0.72x0.64mm_HandSolder | R21 |
| 1 | 47uF | Capacitor_SMD:C_1206_3216Metric | CR6 |
| 1 | 60k | Resistor_SMD:R_0402_1005Metric_Pad0.72x0.64mm_HandSolder | R31 |
| 1 | AON7423 | Package_DFN_QFN:DFN-8-1EP_3x3mm_P0.65mm_EP1.55x2.4mm | Q2 |
| 1 | Conn_01x03_Pin | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | AUX_CONN1 |
| 1 | Conn_01x03_Pin | Connector_JST:JST_XH_B3B-XH-A_1x03_P2.50mm_Vertical | BATT1 |
| 1 | Conn_01x05_Socket | custom_footprints:ZoroBot3_Data_MPU | DATA_MPU+SRAM1 |
| 1 | Crystal_GND24 | Crystal:Crystal_SMD_TXC_7M-4Pin_3.2x2.5mm | Y1 |
| 1 | G*** | kibuzzard-677A7D7B | kibuzzard-677A7D7B |
| 1 | G*** | kibuzzard-6A916D2B | kibuzzard-6A916D2B |
| 1 | G*** | kibuzzard-677A7C9A | kibuzzard-677A7C9A |
| 1 | G*** | kibuzzard-6A916D37 | kibuzzard-6A916D37 |
| 1 | G*** | kibuzzard-677A7C8F | kibuzzard-677A7C8F |
| 1 | G*** | kibuzzard-677A7CA3 | kibuzzard-677A7CA3 |
| 1 | G*** | kibuzzard-677A7CAF | kibuzzard-677A7CAF |
| 1 | G*** | kibuzzard-6A916D40 | kibuzzard-6A916D40 |
| 1 | G*** | kibuzzard-6779A9B1 | kibuzzard-6779A9B1 |
| 1 | G*** | kibuzzard-6A945D46 | kibuzzard-6A945D46 |
| 1 | G*** | kibuzzard-677A7E2E | kibuzzard-677A7E2E |
| 1 | G*** | kibuzzard-6A94423E | kibuzzard-6A94423E |
| 1 | G*** | kibuzzard-677A7E3B | kibuzzard-677A7E3B |
| 1 | G*** | kibuzzard-677A7D86 | kibuzzard-677A7D86 |
| 1 | G*** | kibuzzard-677A7D71 | kibuzzard-677A7D71 |
| 1 | G*** | kibuzzard-677A7CBB | kibuzzard-677A7CBB |
| 1 | L | Inductor_SMD:L_Wuerth_HCM-7050 | L1 |
| 1 | LED_RGB | LED_SMD:LED_RGB_5050-6 | RGB1 |
| 1 | LOGO | libs sueltas:ZoroBot3_curvado1 | G*** |
| 1 | LOGO | libs sueltas:A ver si no arde | G*** |
| 1 | LOGO | libs sueltas:OPR_24X10_silueta | G*** |
| 1 | LOGO | libs sueltas:QR_ZoroBot3 | G*** |
| 1 | STM32F405RGT6 | Package_QFP:LQFP-64_10x10mm_P0.5mm | DEIXAME_QUE_PENSE_1 |
| 1 | SW_DPDT_x2 | custom_footprints:Generic_Swich_ONOFF | POWER_SWITCH1 |
| 1 | SolderJumper_2_Open | Jumper:SolderJumper-2_P1.3mm_Open_RoundedPad1.0x1.5mm | JP2 |
| 1 | ~ | Package_SO:Texas_HTSOP-8-1EP_3.9x4.9mm_P1.27mm_EP2.95x4.9mm_Mask2.4x3.1mm_ThermalVias | DC-DC1 |
| 1 | ~ | custom_footprints:IR_SENSOR_SMD_TSSP77038ETR | IR_RECIVER1 |
| 1 | ~ | custom_footprints:USB-C ST-Link USART | USB1 |
| 1 | ~ | Package_TO_SOT_SMD:SOT-23-5_HandSoldering | MIC1 |
OPRobots/DragonBot2
Siguelíneas de tipo Robotracer para competir en la All Japan Robotracer 2027

tudsat-rocket/stigma
core board and mission board for a new flight computer


ajisrawi/5g-3d-printed-drone
3D-printed quadcopter with a custom F405 flight controller, 4G/5G companion connectivity, and phone control

Phil-CIA/Development-Station-Power-Supply
3 channel bench supply with current and voltage plotting

shamansystems/Cheap-FOCer-2
Low-Cost Motor Controller based on the VESC 6
It measures 86.5 × 91.9 mm and has 2 copper layers, 0.8 mm thick.
205 parts, built around the STM32F405RGT6, AO3400A and AON7423. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the OPRobots/ZoroBot3 repository on GitHub, at the commit this page was made from: the board is pcb_files/kicad_project/ZoroBot3.kicad_pcb and its schematic pcb_files/kicad_project/Encoders.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the GPL-3.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).