2 layers29.5 × 62.5 mm
MotorDriver
Kmshanley/MiniRobots
Firmware and PCB desgin for mini robots with UWB localization and lidar mapping
48 parts1
 Kmshanley/MiniRobots1
Firmware and PCB desgin for mini robots with UWB localization and lidar mapping
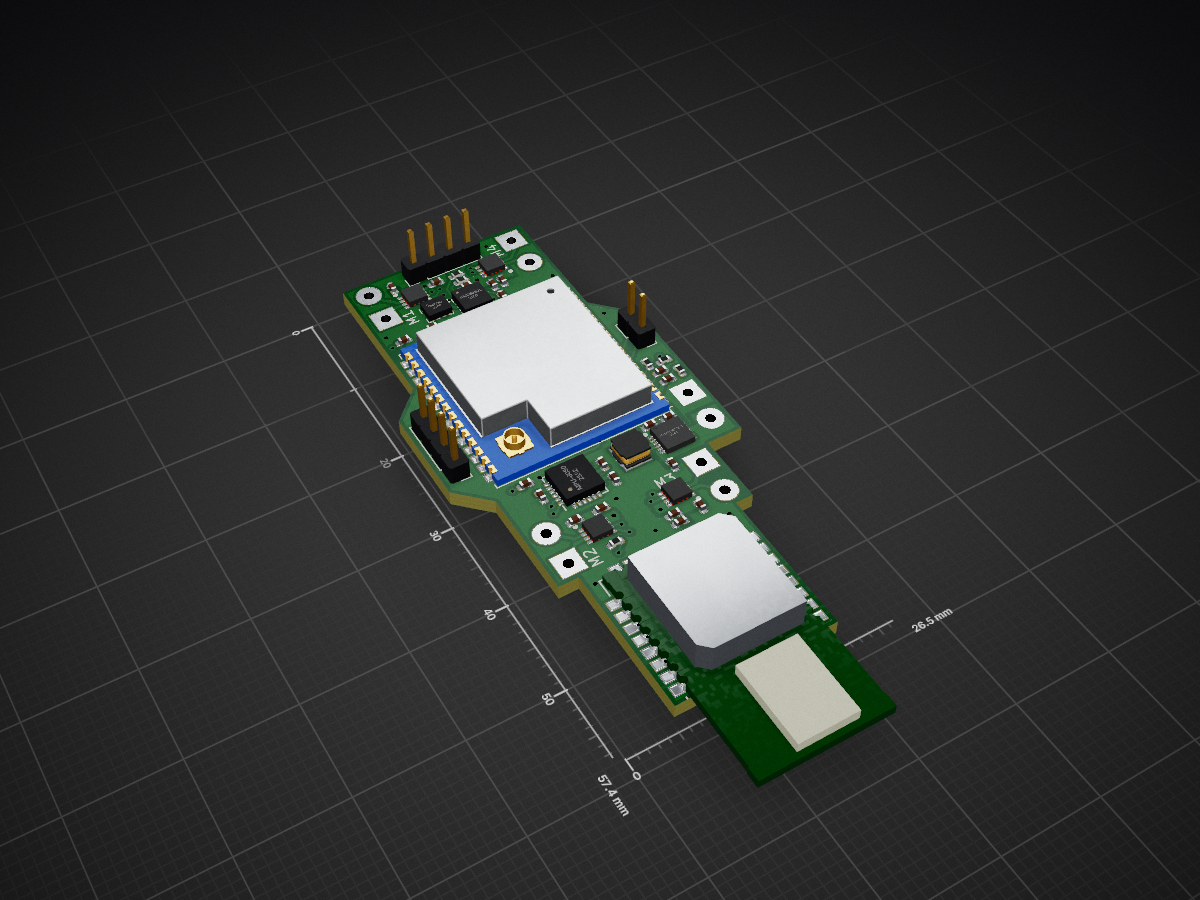
MotorDriver is an open-source printed circuit board by Kmshanley, from the Kmshanley/MiniRobots repository on GitHub. It is a 4-layer board of 26.5 × 57.4 mm with 50 parts on 40 nets, routed with 338 tracks and 82 vias.
It is built around the DWM1000, ESP32-WROVER-I and BMP280, with the ISL9110IRT7Z-T7A, HMC5883L and MPU-6050 among its other parts. Its parts include 22 capacitors, 8 ICs, 8 connectors, 6 resistors and 1 inductor. It belongs with the robots and motor control boards and the ESP32 boards of this library.


Firmware and PCB desgin for mini robots with UWB localization and lidar mapping
| Qty | Value | Footprint | References |
|---|---|---|---|
| 12 | 0.1uf | Capacitor_SMD:C_0402_1005Metric | C7, C8, C9, C10, C11, C12, C14, C15, C16, C17, C19, C22 |
| 4 | 10uf | Capacitor_SMD:C_0402_1005Metric | C2, C3, C5, C38 |
| 4 | DRV8837CDSGR | SamacSys_Parts:SON50P200X200X80-9N | IC1, IC2, IC3, IC4 |
| 2 | 10uF | Capacitor_SMD:C_0402_1005Metric | C6, C18 |
| 2 | 4.7k | Resistor_SMD:R_0402_1005Metric | R3, R4 |
| 1 | 0.22uf | Capacitor_SMD:C_0402_1005Metric | C1 |
| 1 | 100k | Resistor_SMD:R_0402_1005Metric | R22 |
| 1 | 10k | Resistor_SMD:R_0402_1005Metric | R10 |
| 1 | 10nf | Capacitor_SMD:C_0402_1005Metric | C13 |
| 1 | 128k | Resistor_SMD:R_0402_1005Metric | R1 |
| 1 | 2.2 uH | SamacSys_Parts:LQH3NPN100MMEL | L1 |
| 1 | 2.2nf | Capacitor_SMD:C_0402_1005Metric | C28 |
| 1 | 4.7uf | Capacitor_SMD:C_0402_1005Metric | C4 |
| 1 | 470k | Resistor_SMD:R_0402_1005Metric | R2 |
| 1 | BAT | Connector_Wire:SolderWirePad_1x02_P3.81mm_Drill1mm | J8 |
| 1 | BMP280 | Package_LGA:Bosch_LGA-8_2x2.5mm_P0.65mm_ClockwisePinNumbering | U2 |
| 1 | BOOT | Jumper:SolderJumper-2_P1.3mm_Open_Pad1.0x1.5mm | JP2 |
| 1 | DWM1000 | RF_Module:DWM1000 | DWM1 |
| 1 | ESP32-WROVER-I | RF_Module:ESP32-WROOM-32U | A1 |
| 1 | HMC5883L | HMC5883L:HMC5883L | U1 |
| 1 | I2C | Connector_PinHeader_2.00mm:PinHeader_1x04_P2.00mm_Vertical | J5 |
| 1 | IO | Connector_PinHeader_2.00mm:PinHeader_1x02_P2.00mm_Vertical | J10 |
| 1 | ISL9110IRT7Z-T7A | SamacSys_Parts:SON40P300X300X75-13N | IC5 |
| 1 | Jumper_NO_Small | Jumper:SolderJumper-2_P1.3mm_Open_Pad1.0x1.5mm | JP3 |
| 1 | M1 | Connector_Wire:SolderWirePad_1x02_P3.81mm_Drill1mm | J1 |
| 1 | M2 | Connector_Wire:SolderWirePad_1x02_P3.81mm_Drill1mm | J4 |
| 1 | M3 | Connector_Wire:SolderWirePad_1x02_P3.81mm_Drill1mm | J3 |
| 1 | M4 | Connector_Wire:SolderWirePad_1x02_P3.81mm_Drill1mm | J2 |
| 1 | MPU-6050 | Sensor_Motion:InvenSense_QFN-24_4x4mm_P0.5mm | U3 |
| 1 | RST | Jumper:SolderJumper-2_P1.3mm_Open_Pad1.0x1.5mm | JP1 |
| 1 | Uart | Connector_PinHeader_2.00mm:PinHeader_1x04_P2.00mm_Vertical | J9 |
Kmshanley/MiniRobots
Firmware and PCB desgin for mini robots with UWB localization and lidar mapping


rmingon/SkyIMU
Compact 3.3 V sensor board that combines an InvenSense MPU-6050 6-axis IMU, a Honeywell HMC5883L 3-axis magnetometer, and a Bosch BMP280 barometric pressure and temperature sensor.


phonght32/OpenDrone_HW_FC_F405
OpenDrone Project - Fly Controller hardware using STM32F405RG.
It measures 26.5 × 57.4 mm and has 4 copper layers, 1.6 mm thick.
50 parts, built around the DWM1000, ESP32-WROVER-I, BMP280 and ISL9110IRT7Z-T7A. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the Kmshanley/MiniRobots repository on GitHub, at the commit this page was made from: the board is Motor Driver PCB/MotorDriverRev2/MotorDriver.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask Kmshanley before reusing the design.