Skip to the content
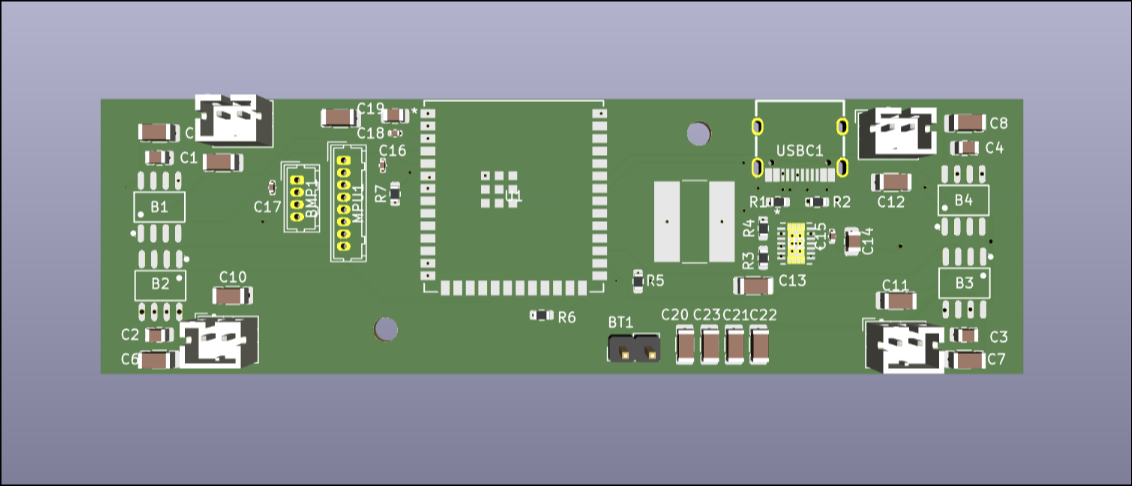
4 layers94 × 28 mmLux, the printed circuit board in 3D

Luxion is a custom made drone made with rust unlike standard c++ drones . It uses a custom pcb, ESP32-S3-WROOM-1U , MPU6500-IMU(breakout as it costs less than the bare), four motor drivers, and a 1S LiPo to power the…

Size
94 × 28 mm
Copper layers
4
Thickness
1.6 mm
Parts
50
Nets
73
Pads
210
Tracks, vias
327, 88
Pours
1
Routed
Yes
KiCad
KiCad 10.0 (file 20260206)
Created
26 Aug 2026
Updated
7 Nov 2026

Overview

Lux is an open-source printed circuit board by Erox-02, from the Erox-02/Luxion repository on GitHub, published under the GPL-3.0 licence. It is a 4-layer board of 94 × 28 mm with 50 parts on 73 nets, routed with 327 tracks and 88 vias.

It is built around the ESP32-S3-WROOM-1U-N16R8, TPS63020DSJR and BL5612, with the BMP180 and TYPE-C-31-M-12 among its other parts. Its parts include 23 capacitors, 7 resistors, 2 ICs and 1 inductor. It belongs with the robots and motor control boards and the ESP32 boards of this library.

Main components

5

README

README.md

Luxion

Luxion is a custom made drone made with rust unlike standard c++ drones . It uses a custom pcb, ESP32-S3-WROOM-1U , MPU6500-IMU(breakout as it costs less than the bare), four motor drivers, and a 1S LiPo to power the drone. Also a remote with same esp module, 2x joysticks connectin to the drone via esp-now .

Function

It is a remote controlled drone made from absolutely nothing , with 8520 motors and 65mm props it can easily take off with 2+ thrust-mass ratio . It is ideal for mini quadcoptor with mountable sensors ,as it has a lot of gpio's left any sensor can be easily mounted if not too heavy .

Why it exists

from when i saw the pluto x , a programable drone with esp 12f and stm32 , i always wanted to make one myself but better and cheaper thts why luxion exists today. I used esp32-s3 instead of 2 mcu's , used esp-now instead of wifi and a lot but the best part i didnt rely on the pluto x's architecture at all .

Design


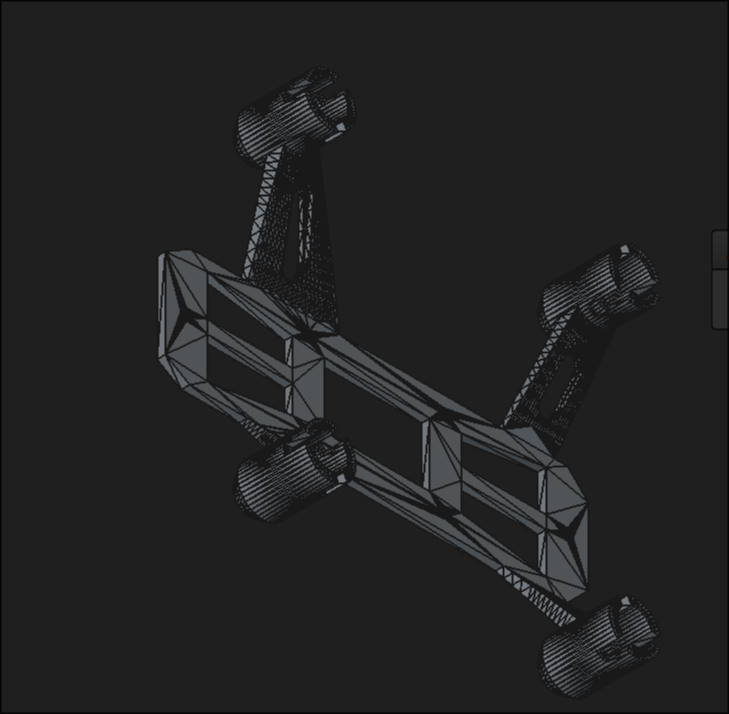
3D Model

Notice: All the screws there are 3mm .

The recommended range by me is M5x3 mm

heres a photo tagged:

but for the pcb M1.2x3 mm is totally usable

Drone

You can download the 3d model frm here : DOWNLOAD THE 3d MODEL

also the fcstd file is tagged here :

FCSTD

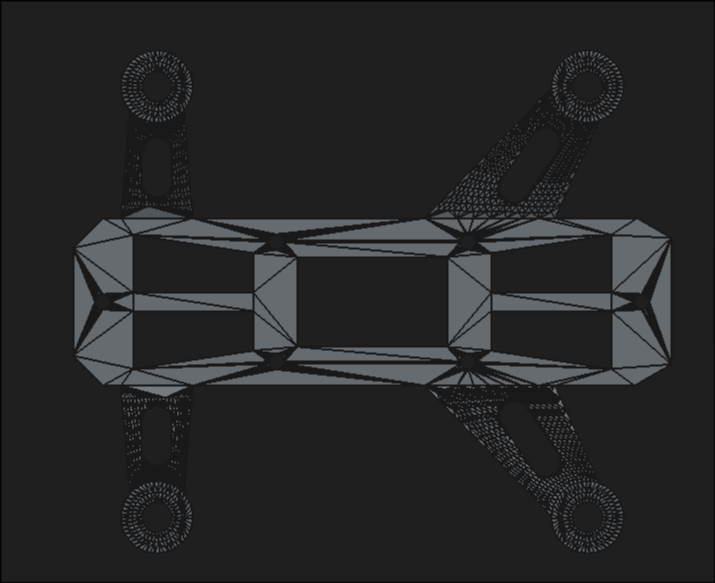
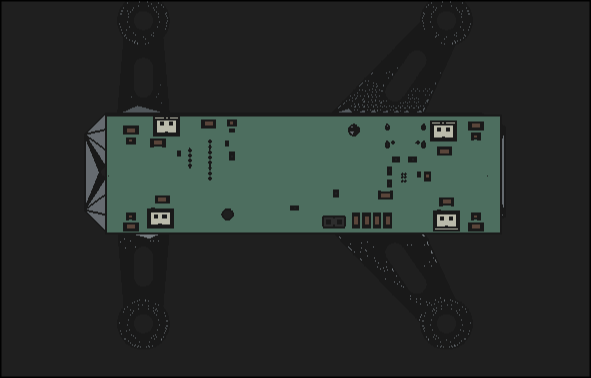
some photos for the frame :

side viewtop viewwith pcb

Remote

You can download the 3d model frm here :

DOWNLOAD THE 3d MODEL DOWNLOAD THE 3d MODEL

===

also the fcstd file is tagged here :

FCSTD

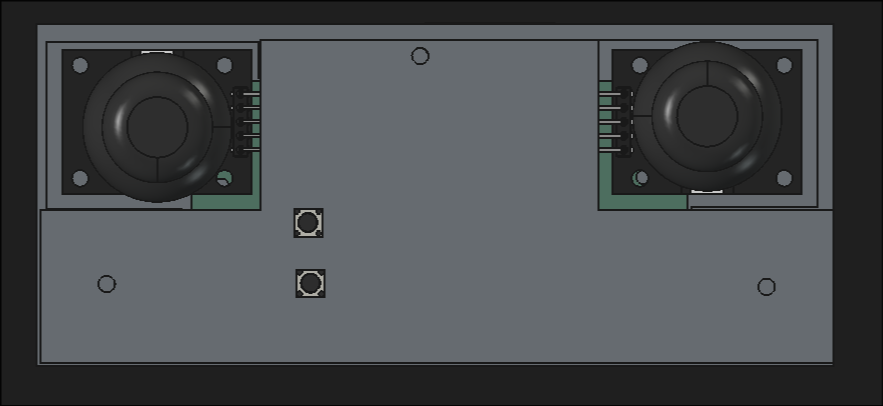
Some phots of the remote :

topcase open

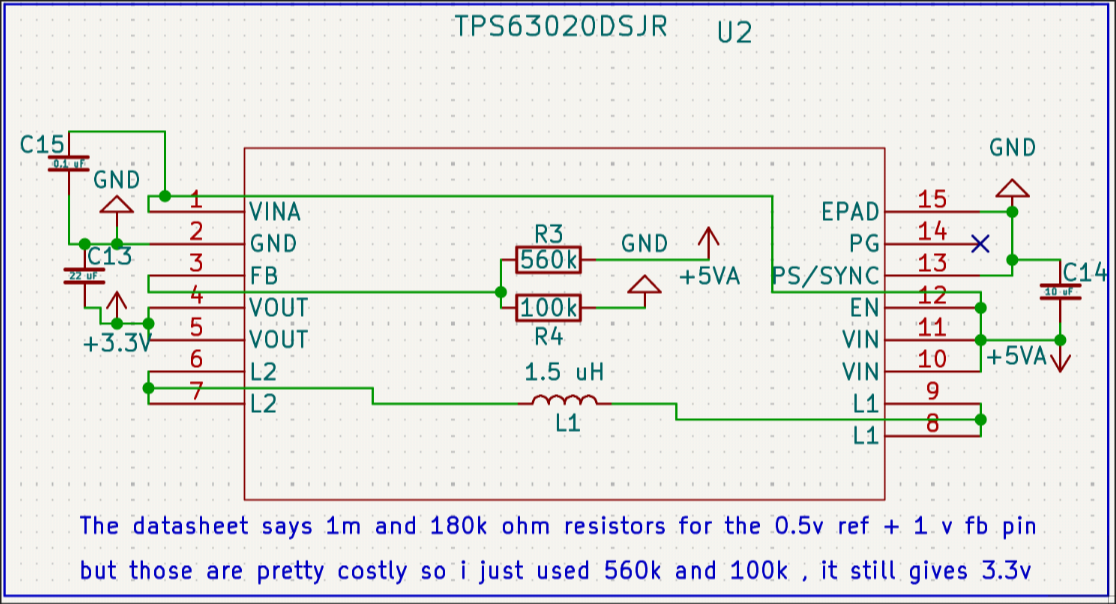
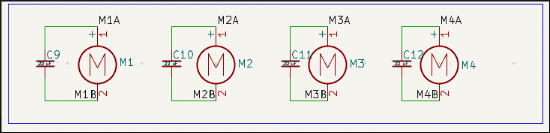
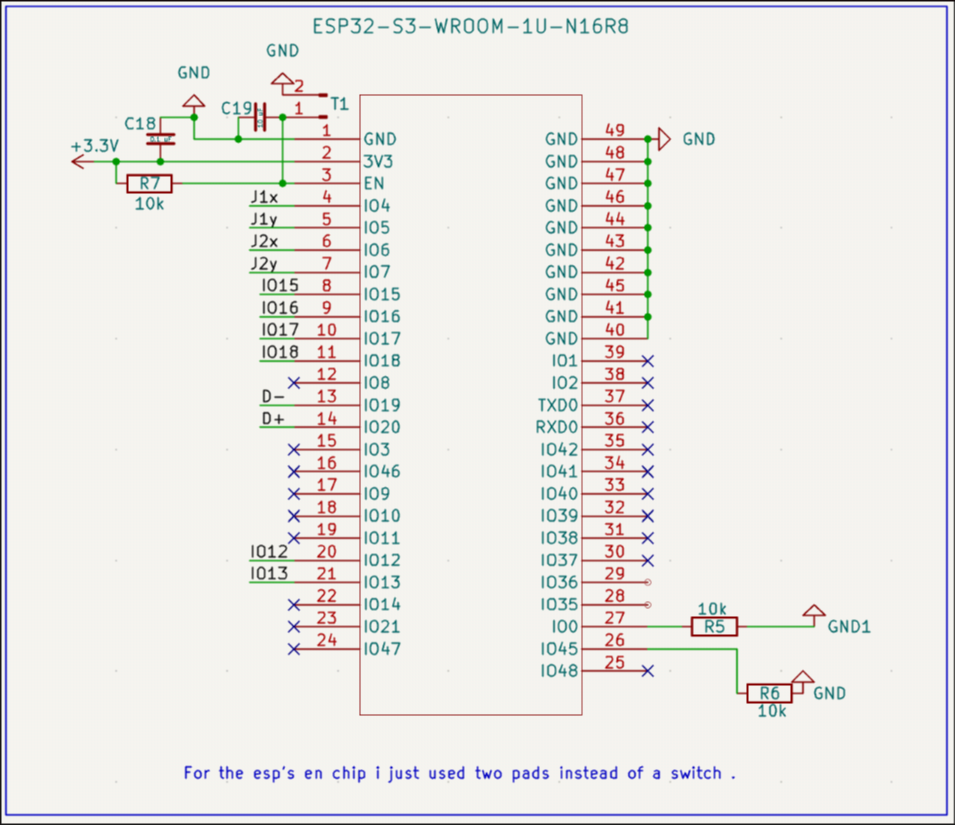
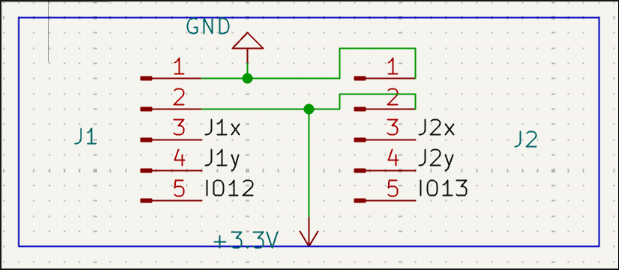
Schematic


drone
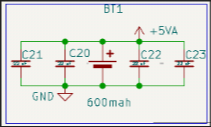
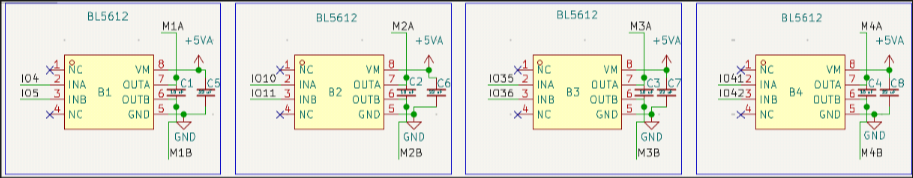
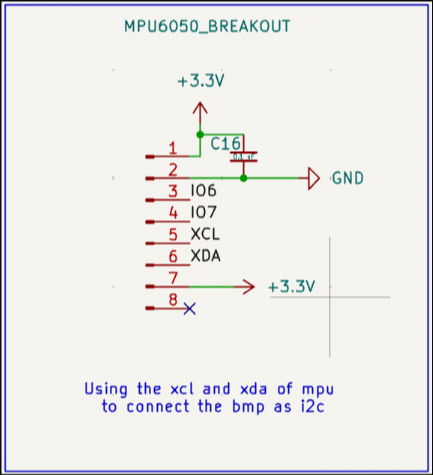
batterymotor driversmpu6050
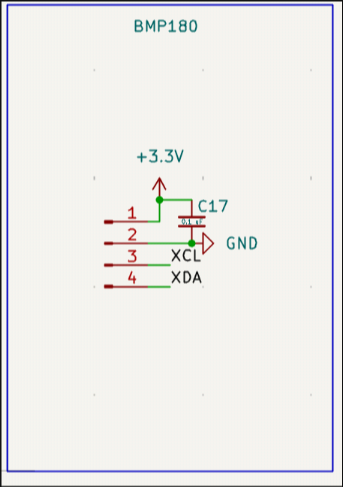
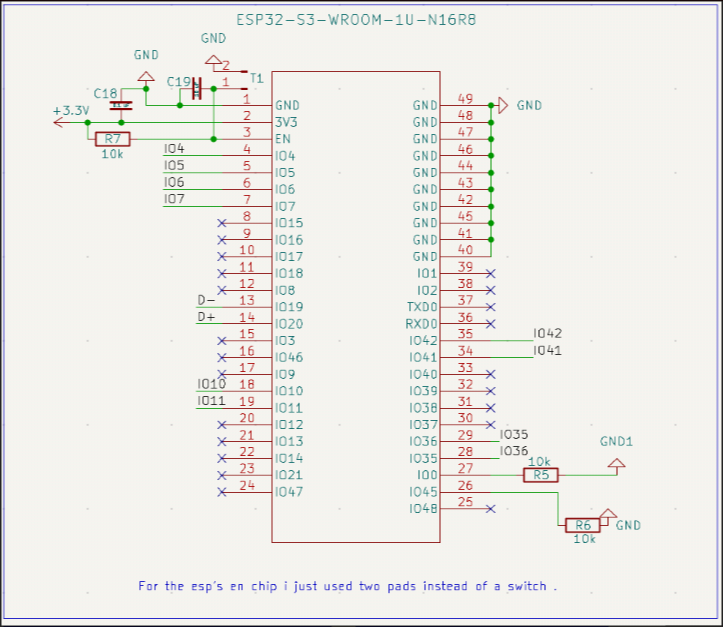
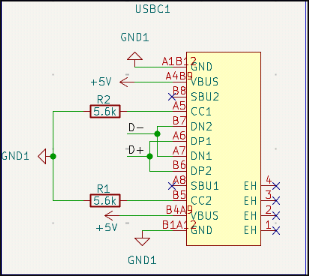
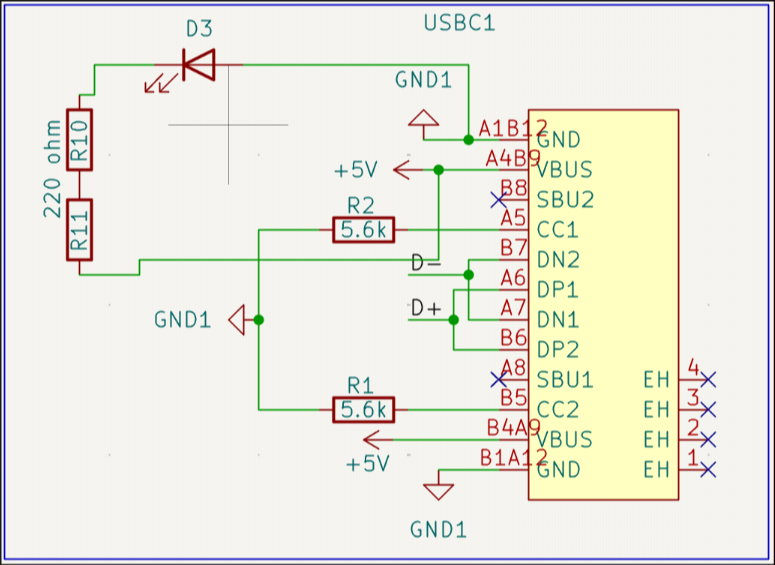
barometermcu(esp32-s3)usb-c
step up (tps63020)motors

remote

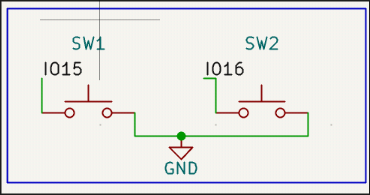
mcujoystick
switchsusb c

PCB

drone

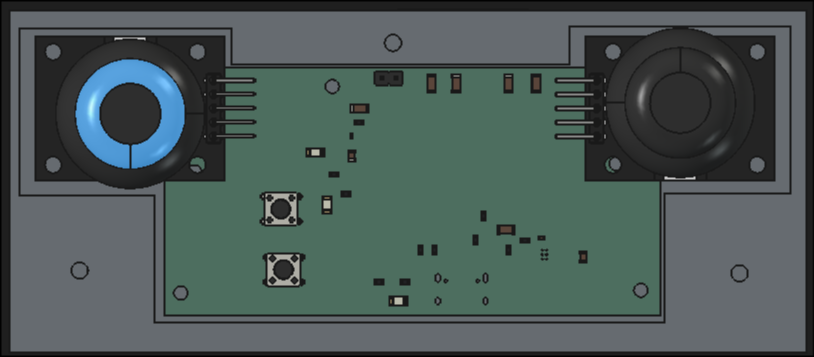
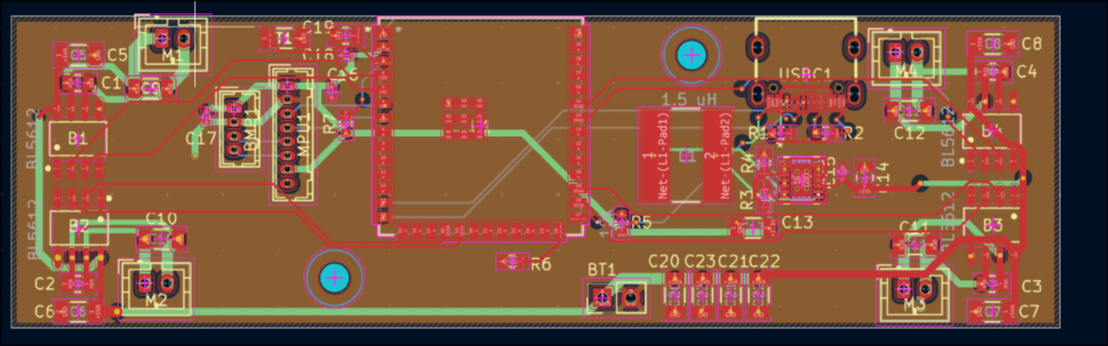
Heres the pcb :

drone pcbdrone pcb 3d
remote

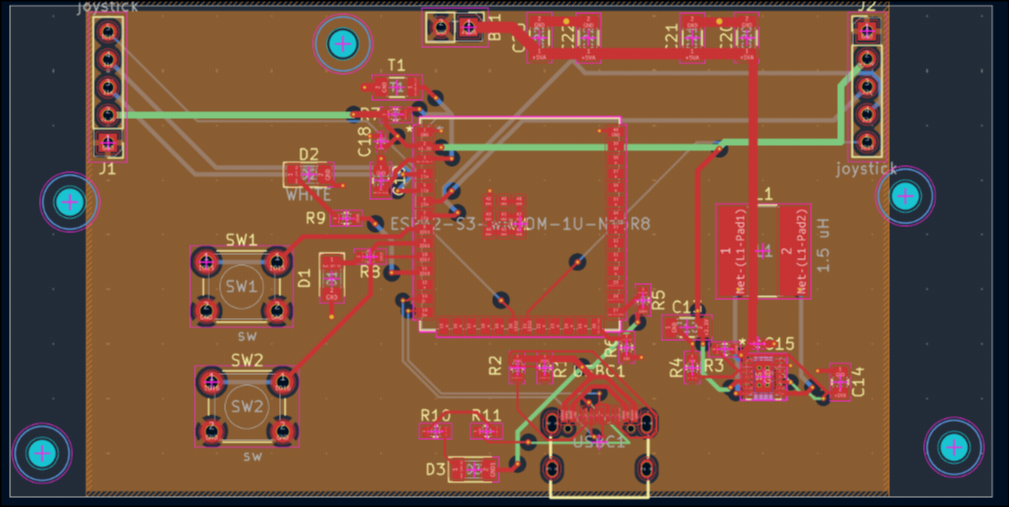
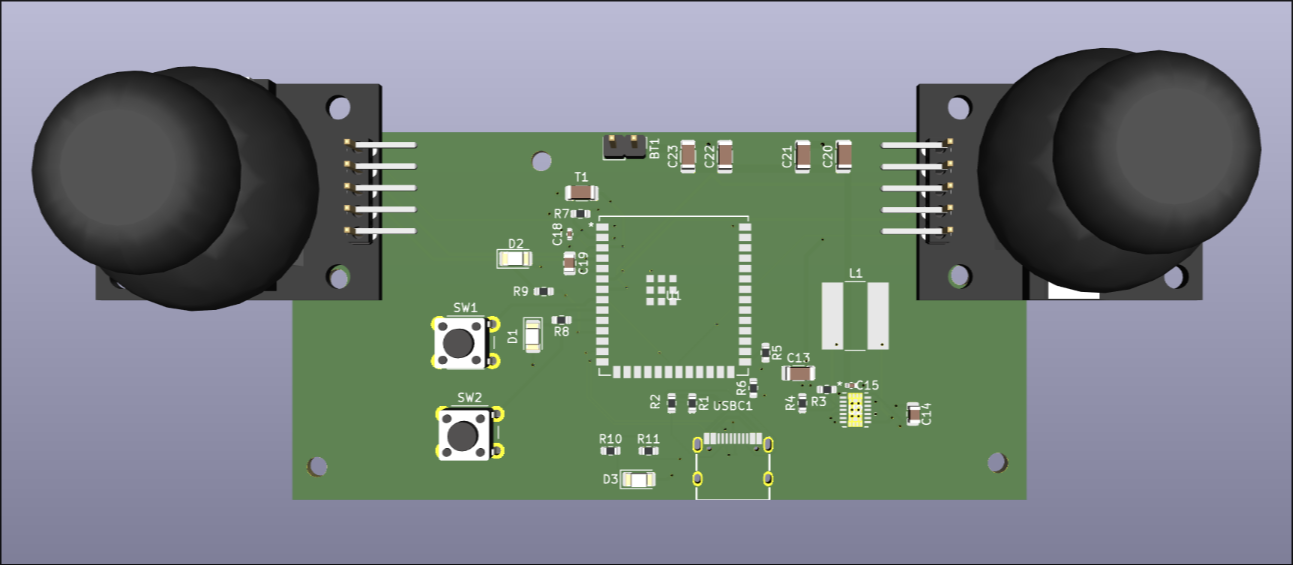
Heres the pcb :

remote pcbremote pcb 3d

Firmware

I have written likely most of the firmware already before getting approved or building the physical drone .

Current stack have :

text
[erox@archbtw luxion]$ tree src 
src
├── filter.rs
├── main.rs
├── motor.rs
├── mpu.rs          
└── pid.rs

1 directory, 5 files

the mpu.rs is a custom driver(really basic) for the mpu6050 , the filte* take mpu's data(gyro and acc) then converts tht into yaw roll and pitch , the moto* haved ldec and controlls the motors state , the pid is just pid controller nothing more , and the main.rs integrates them all and runs them when needed either in loop or once .

Whats remainin?

  • esp now impl
  • build.rs
  • proper pid vals and calibration

How to assemble

Solder all the components from bom(except the antenna) on the pcb , also You might need to solder a jst socket according to your battery (more detailed explanation after i do it myself first lol)

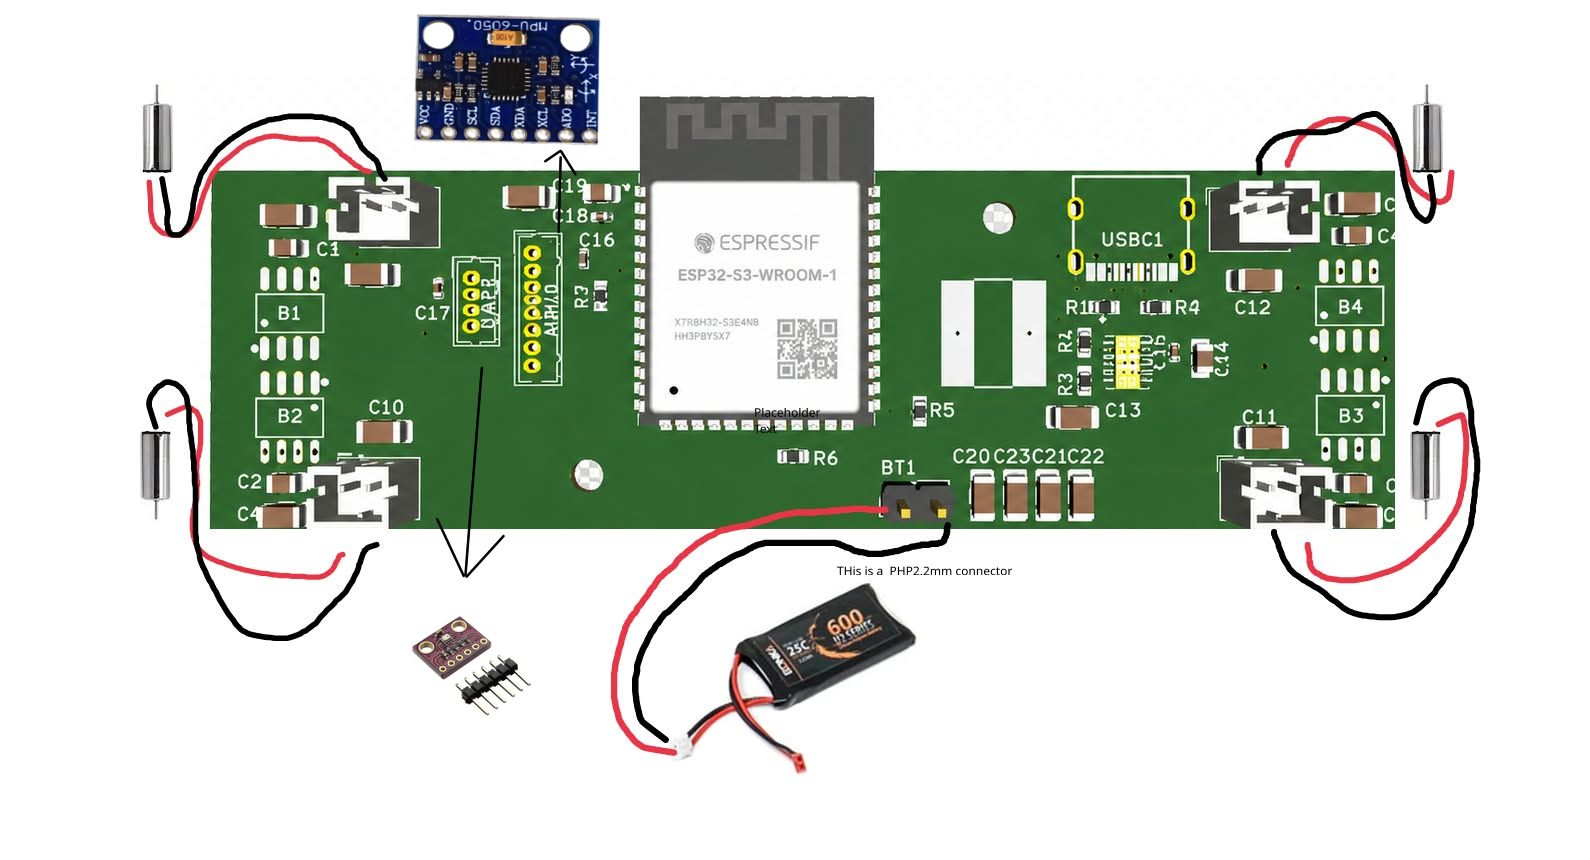
you can follow this hand drawn diagram(even orphy is better than me)

diagram

another thing to consider, this photo doesnt have all the components placed so this isnt the final pcb(checkt he comps on bom ) , and for the mpu6050 and the bmp , they are supposed to be placed horizontal to the pcb , mpu on the esp farday cage(tested by max imagination, he is a cool dude btw , i saw his Arduino drone on YouTube) and the bmp shld be stacked on top of mpu , it shld give them the least vibration err , still idea but i will be sure after i build it myself lol.

Credits

This project uses:

  • KiCad
  • Freecad for 3D renders
  • A opensource frame from the link below

link

It was the reference for my frame i had to rebuild it .

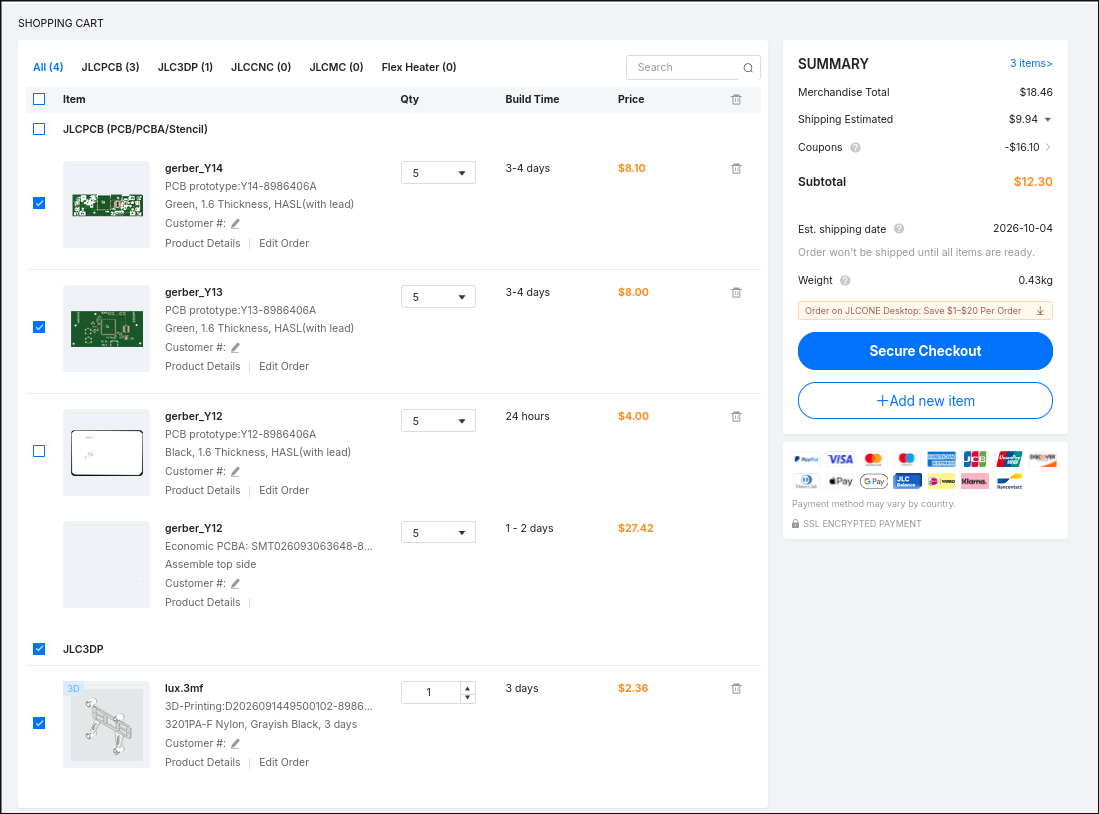
JLCPCB order


the price might fluctuate over time

BOM

PartQuantityUnit Price (INR)Unit Price (USD)Total (INR)Total (USD)Link
MPU-6050 3-Axis Accelerometer + Gyro1151.001.59151.001.59Link
PS2 Joystick Module Breakout Sensor239.000.4178.000.82Link
8520 Magnetic Micro Coreless Motors – 2xCW + 2xCCW pack1459.004.83459.004.83Link
100kΩ 0603 resistor (MOQ)300.340.00410.200.11Link
220Ω 0603 resistor (MOQ)300.340.00410.200.11Link
3V Active Electromagnetic Buzzer – pack of 5121.000.2221.000.22Link
1206 Surface Mount LED White (MOQ)101.070.01110.700.11Link
1206 Surface Mount LED Yellow (MOQ)250.400.00410.000.11Link
BMP180 Digital Barometric Pressure Sensor Module133.000.3533.000.35Link
LWC-2400-DIP-03 (V1.0) Dipole Antenna 2.4 GHz2132.001.39264.002.78Link
Bonka 3.7V 600mAh 25C 1S LiPo1499.005.25499.005.25Link
22µF 16V 1206 X5R capacitor (MOQ)280.360.00410.080.11Link
100nF 0402 X7R capacitor (MOQ)1000.100.00110.000.11Link
10kΩ 0603 resistor (MOQ)150.680.00710.200.11Link
ESP32-S3-WROOM-1U-N16R82469.004.94938.009.87Link
10µF 10V 0805 X5R capacitor (MOQ)220.470.00510.340.11Link
SRN8040-1R5Y 1.5µH 7A inductor123.000.2423.000.24Link
BL5612-BL H-Bridge Motor Driver IC441.000.43164.001.73Link
560kΩ 0603 resistor (MOQ)280.360.00410.080.11Link
5.6kΩ 0603 resistor (MOQ)280.370.00410.360.11Link
TYPE-C-31-M-12 Hroparts 5A 1 16P Female Type-C SMD USB Connector226.000.2752.000.55Link
JST 2P Male + Female Terminal Connection Socket130.000.3230.000.32Link
TPS63020DSJR2178.001.87356.003.75Link
Drone PCB1769.508.10769.508.10—
Remote PCB1760.008.00760.008.00—
Drone Frame1224.202.36224.202.36—
TOTAL4,923.8651.83

i used 95inr = 1$ , also the prices gonna change soon .

Parts

50
QtyValueFootprintReferences
1322 uFCapacitor_SMD:C_1206_3216MetricC5, C6, C7, C8, C9, C10, C11, C12, C13, C20, C21, C22, C23
610 uFCapacitor_SMD:C_0805_2012MetricC1, C2, C3, C4, C14, C19
40.1 uFCapacitor_SMD:C_0402_1005MetricC15, C16, C17, C18
4BL5612easyeda2kicad:SOP-8_L4.9-W3.9-P1.27-LS6.0-BLB1, B2, B3, B4
4Motor_DCConnector_JST:JST_PH_B2B-PH-K_1x02_P2.00mm_VerticalM1, M2, M3, M4
4MountingHoleMountingHole:MountingHole_2.5mmH1, H1, H2, H2
310kResistor_SMD:R_0603_1608MetricR5, R6, R7
25.6kResistor_SMD:R_0603_1608MetricR1, R2
11.5 uHInductor_SMD:L_Bourns-SRN8040_8x8.15mmL1
1100kResistor_SMD:R_0603_1608MetricR4
1560kResistor_SMD:R_0603_1608MetricR3
1600mahConnector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_VerticalBT1
1BMP180Connector_Hirose:Hirose_DF13-04P-1.25DSA_1x04_P1.25mm_VerticalBMP1
1ESP32-S3-WROOM-1U-N16R8footprints:ESP32-S3-WROOM-1U_EXPU1
1MPU6050_BREAKOUTConnector_Hirose:Hirose_DF13-08P-1.25DSA_1x08_P1.25mm_VerticalMPU1
1TPS63020DSJRfootprints:DSJ14_2P85X1P58U2
1TYPE-C-31-M-12easyeda2kicad:USB-C_SMD-TYPE-C-31-M-12_1USBC1
1traceCapacitor_SMD:C_1206_3216MetricT1

More from Erox-02/Luxion

1
  • 4 layers90 × 45 mmRemote, the printed circuit board in 3D

    Remote

    Erox-02/Luxion

    Luxion is a custom made drone made with rust unlike standard c++ drones . It uses a custom pcb, ESP32-S3-WROOM-1U , MPU6500-IMU(breakout as it costs less than the bare), four motor drivers, and a 1S LiPo to power the…

    38 parts1GPL-3.0

Similar boards

  • 4 layersHush main, the printed circuit board in 3D

    Hush main

    Terryzhao-dev/Hush

    Bluetooth dictation mic in an aluminium cup that keeps people nearby from hearing you (ESP32, KiCad, CadQuery)

    108 parts
  • 4 layers65 × 56 mmPi hat ups, the printed circuit board in 3D

    Pi hat ups

    Doenec/pi-hat

    collection of different shields to be stacked in raspberry pi

    80 parts1MIT
  • 4 layers94.1 × 152 mmDevelopment board panel, the printed circuit board in 3D

    Development board panel

    portapack-mayhem/mayhem-mdk

    PortaPack - Module Develoment Kit

    298 parts88GPL-3.0
  • 4 layers90.8 × 121.7 mmMeshDeck, the printed circuit board in 3D

    MeshDeck

    ThePangel/MeshDeck

    Standalone ESP32-S3 powered Meshtastic device!

    242 parts1
  • 2 layersPCB DESIGN, the printed circuit board in 3D

    PCB DESIGN

    RaykiDan/PCB-Design-Project

    Design PCB untuk monitoring kompor gas akan adanya kebocoran gas dan kemungkinan kondisi berbahaya

    57 parts
  • 4 layers30.5 × 68.6 mm32bit-5v, the printed circuit board in 3D

    32bit-5v

    bread-modular/bread-modular

    Modular Synths for Everyone

    61 parts67MIT
  • 2 layers65 × 31 mmDiy tracker, the printed circuit board in 3D

    Diy tracker

    glidernet/diy-tracker

    Do-it-Yourself OGN Tracker software

    27 parts30GPL-3.0
  • 2 layers98 × 83.8 mmProjeto placa, the printed circuit board in 3D

    Projeto placa

    phfbertoleti/placa_lorawan

    Repositório oficial da placa LoRaWAN, um kit de desenvolvimento para protótipos IoT.

    39 parts19MIT

Questions

How big is the Lux PCB?

It measures 94 × 28 mm and has 4 copper layers, 1.6 mm thick.

What parts does the Lux use?

50 parts, built around the ESP32-S3-WROOM-1U-N16R8, TPS63020DSJR, BL5612 and BMP180. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.

Where can I download the Lux KiCad files?

From the Erox-02/Luxion repository on GitHub, at the commit this page was made from: the board is kicad/drone/lux.kicad_pcb and its schematic kicad/drone/lux.kicad_sch. PCBKit opens the board in the browser, with nothing to install.

Can I use the Lux design in my own project?

Its repository publishes it under the GPL-3.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).