2 layers169.9 × 135.9 mm
Circuits
DVA490-474-Project-Course/SSL-Hardware-Development
Contains all hardware related material. (No software).
65 partsMIT
 DVA490-474-Project-Course/SSL-Hardware-Development
Contains all hardware related material. (No software).
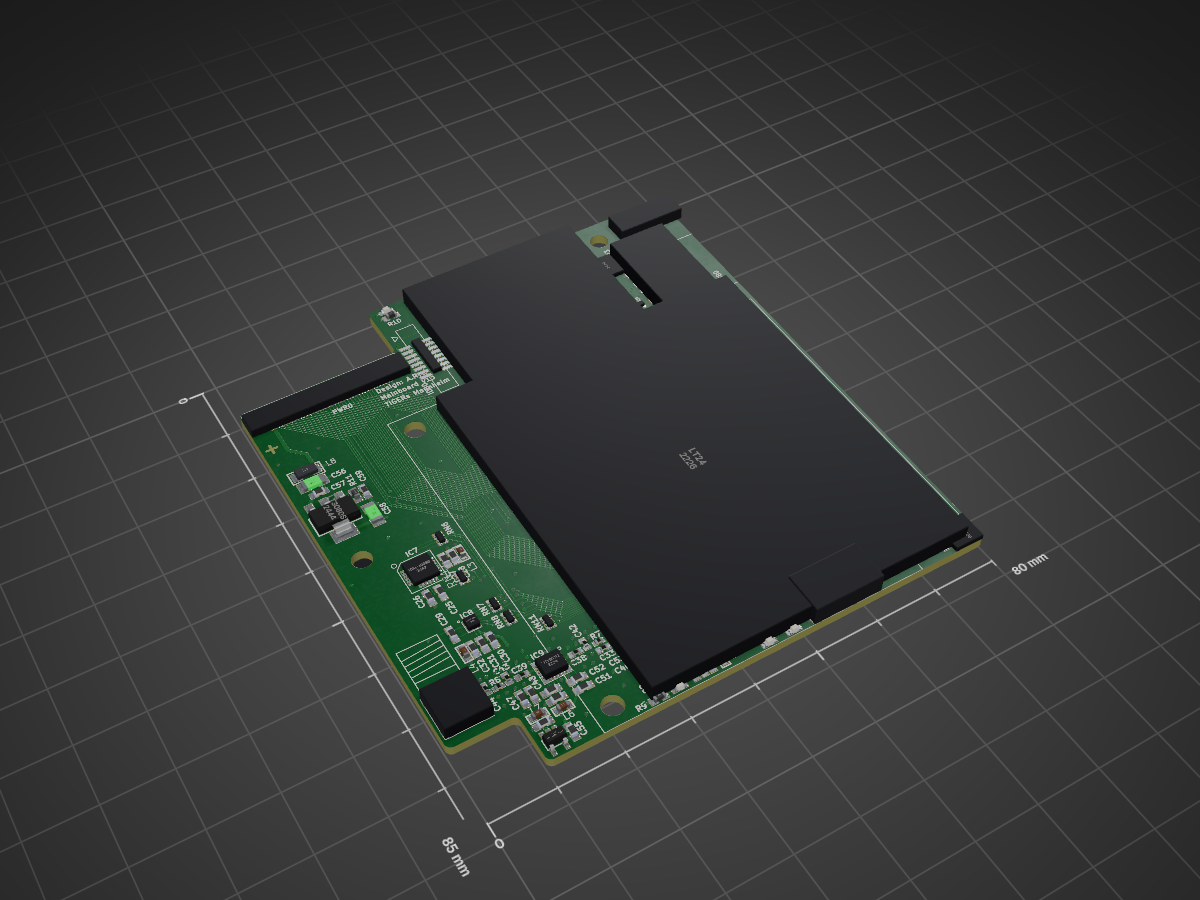
Mainboard v13 is an open-source printed circuit board by DVA490-474-Project-Course, from the DVA490-474-Project-Course/SSL-Hardware-Development repository on GitHub, published under the MIT licence. It is a 4-layer board of 80 × 85 mm with 118 parts on 184 nets, routed with 2,005 tracks and 386 vias.
It is built around the SKY66112-11, LIS3MDL and MP34DT05, with the ICM-20689, LP5907MFX-3.3 and ASE-4.000MHZ-LC-T among its other parts. Its parts include 59 capacitors, 12 ICs, 10 resistors, 8 inductors and 4 diodes. It belongs with the computers and single-board computers boards and the STM32 boards of this library.


Welcome to the SSL Robot Project repository! This project encompasses both hardware and software components essential for building and controlling an SSL robot. Our goal is to create a robust, scalable, and maintainable robot platform.
/SSL-Robot-Project
├── /3D_Models
│   ├── /CAD_Files            # All CAD files for different robot parts
│   ├── /STL_Files            # STL exports for 3D printing
│   └── /Renderings           # Renders of the 3D models
├── /Circuits
│   ├── /Motor_Control        # Motor circuit design files
│   ├── /Kicker               # Kicker circuit design files
│   ├── /Dribbler             # Dribbler circuit design files
│   └── /Sensor               # Sensor circuit design files
├── /BOM                      # Bill of Materials for different components
├── /Software
│   ├── /Motor_Control
│   │   ├── /Firmware          # Firmware code for motor controllers
│   │   │   ├── /src           # Source code files
│   │   │   ├── /include       # Header files
│   │   │   ├── /tests         # Unit and integration tests
│   │   │   └── README.md      # Firmware-specific documentation
│   │   ├── /Software_Doc      # Documentation related to motor control software
│   │   │   ├── /API_Docs      # API documentation if applicable
│   │   │   └── /User_Guides   # User manuals or setup guides
│   │   ├── /Libraries         # Any libraries or dependencies specific to motor control
│   │   └── /Examples          # Example projects or usage scenarios
│ ├── /Kicker_Control # Similar structure for kicker control softwareClone the Repository
git clone git@github.com:DVA490-474-Project-Course/SSL-Hardware-Development.git
cd SSL-Robot-Project
Setup Software Environment
cd Software/Motor_ControlREADME.md to build and deploy the firmware.Accessing Documentation
We welcome contributions! Please read our CONTRIBUTING.md for guidelines on how to get involved.
This project is licensed under the MIT License.
For any questions or support, please open an issue or contact the project maintainers.
Pontus Svensson - psn19003@student.mdu.se
| Qty | Value | Footprint | References |
|---|---|---|---|
| 31 | 100n | Mainboard v13:C0603_334 | C1, C2, C10, C11, C12, C13, C14, C15, C16, C17, C18, C19, C21, C24, C26, C27 +15 |
| 12 | 100 | Mainboard v13:EXB28V_342 | RN1, RN2, RN3, RN4, RN5, RN6, RN7, RN8, RN9, RN10, RN11, RN12 |
| 10 | 10u | Mainboard v13:C0603_334 | C4, C5, C20, C22, C23, C25, C28, C32, C54, C55 |
| 7 | 120R | Mainboard v13:L0603 | L1, L2, L3, L4, L5, L6, L7 |
| 5 | 1n | Mainboard v13:C0603_334 | C35, C37, C48, C50, C52 |
| 4 | 1k | Mainboard v13:R0603_334 | R1, R2, R9, R10 |
| 3 | Mainboard v13:5,4_3,0 | PAD1, PAD2, PAD3 | |
| 3 | gr | Mainboard v13:CHIP-LED0603_259 | LED1, LED3, LED4 |
| 2 | 10k | Mainboard v13:R0603_334 | R3, R4 |
| 2 | 10n | Mainboard v13:C0603_334 | C46, C53 |
| 2 | 33u | Mainboard v13:C1206_334 | C56, C58 |
| 2 | MP34DT05 | Mainboard v13:HCLGA4 | IC4, IC5 |
| 2 | NA | Mainboard v13:C0402_334 | C42, C44 |
| 2 | STMPS2151STR | Mainboard v13:SOT23-5 | IC2, IC6 |
| 1 | Mainboard v13:TE-1-84952-0 | LEDS0 | |
| 1 | Mainboard v13:TE-1734248-8 | IDD0 | |
| 1 | Mainboard v13:ANT-SMA-RA | ANT0 | |
| 1 | Mainboard v13:USBA-TE | USB0 | |
| 1 | 0p5 | Mainboard v13:C0402_334 | C33 |
| 1 | 0p6 | Mainboard v13:C0402_334 | C43 |
| 1 | 0p8 | Mainboard v13:C0402_334 | C40 |
| 1 | 100p | Mainboard v13:C0402_334 | C38 |
| 1 | 1p5 | Mainboard v13:C0402_334 | C41 |
| 1 | 1u | Mainboard v13:C0603_334 | C45 |
| 1 | 2n7 | Mainboard v13:R0402_334 | R7 |
| 1 | 330k | Mainboard v13:R0603_334 | R11 |
| 1 | 3n | Mainboard v13:R0402_334 | R6 |
| 1 | 3n9 | Mainboard v13:R0402_334 | R8 |
| 1 | 4-1734742-0 | Mainboard v13:TE-4-1734592-0 | PWR0 |
| 1 | 470R | Mainboard v13:L1206 | L8 |
| 1 | 47p | Mainboard v13:C0402_334 | C39 |
| 1 | ASE-4.000MHZ-LC-T | Mainboard v13:OSCI-ASE | Q1 |
| 1 | FL520WFMT1 | Mainboard v13:CRYSTAL-7M | Q2 |
| 1 | ICM-20689 | Mainboard v13:QFN24-4X4-P | IC7 |
| 1 | KT11P4SA3M | Mainboard v13:KT11 | SW2 |
| 1 | KT11P4SA3M | Mainboard v13:BUTTON4 | SW1 |
| 1 | LIS3MDL | Mainboard v13:VFLGA-12 | IC8 |
| 1 | LP5907MFX-3.3 | Mainboard v13:SOT23-5L | IC11 |
| 1 | LT24 | Mainboard v13:LT24 | IC3 |
| 1 | LT3080ST | Mainboard v13:SOT223 | IC12 |
| 1 | SDCARD | Mainboard v13:SDCARD | SD0 |
| 1 | SKY66112 | Mainboard v13:SMCM-22 | IC9 |
| 1 | STM32H743ZST | Mainboard v13:LQFP144-ST | IC1 |
| 1 | SX1280 | Mainboard v13:QFN24L | IC10 |
| 1 | rd | Mainboard v13:CHIP-LED0603_259 | LED2 |
DVA490-474-Project-Course/SSL-Hardware-Development
Contains all hardware related material. (No software).

DVA490-474-Project-Course/SSL-Hardware-Development
Contains all hardware related material. (No software).

DVA490-474-Project-Course/SSL-Hardware-Development
Contains all hardware related material. (No software).

DVA490-474-Project-Course/SSL-Hardware-Development
Contains all hardware related material. (No software).

DVA490-474-Project-Course/SSL-Hardware-Development
Contains all hardware related material. (No software).

DVA490-474-Project-Course/SSL-Hardware-Development
Contains all hardware related material. (No software).

DVA490-474-Project-Course/SSL-Hardware-Development
Contains all hardware related material. (No software).


SubstrateElectronics/SoundStick
An eraser sized music player/walkie-talkie supporting Bluetooth and SD card playback.

owl-and-goat/sensor-board
general-purpose thread-based iot home automation sensor board


luhbots/luhsoccer_electronics
The eletronics projects of our robots and basestation.

felixfelix-bot/balloon-fresh
Open-source pico-balloon hardware and firmware, multi-radio LoRa/FLRC mesh networking, ground stations, and RF range-test tooling.

megmem044/Portfolio
This repo consists the source code for the different projects listed on my resume

nekonaute/pogobot
Pogobot is an open-source open-hardware robotic platform for swarm robotics
It measures 80 × 85 mm and has 4 copper layers, 1.6 mm thick.
118 parts, built around the SKY66112-11, LIS3MDL, MP34DT05 and ICM-20689. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the DVA490-474-Project-Course/SSL-Hardware-Development repository on GitHub, at the commit this page was made from: the board is Circuits/Tiger_Mannheim_Mainboard/Mainboard v13.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).