
2 layers23 × 120 mm

 CoreElectronics/CE-PiicoDev-IMU-MPU6050
PiicoDev IMU MPU-6050 Board
PiicoDev IMU MPU6050 is an open-source printed circuit board by CoreElectronics, from the CoreElectronics/CE-PiicoDev-IMU-MPU6050 repository on GitHub. It is a 2-layer board of 25.4 × 25.4 mm with 29 parts on 15 nets, routed with 143 tracks and 20 vias.
It is built around the MPU-6050. Its parts include 5 resistors, 5 connectors, 3 capacitors, 1 IC and 1 diode. It belongs with the sensors and measurement boards of this library.
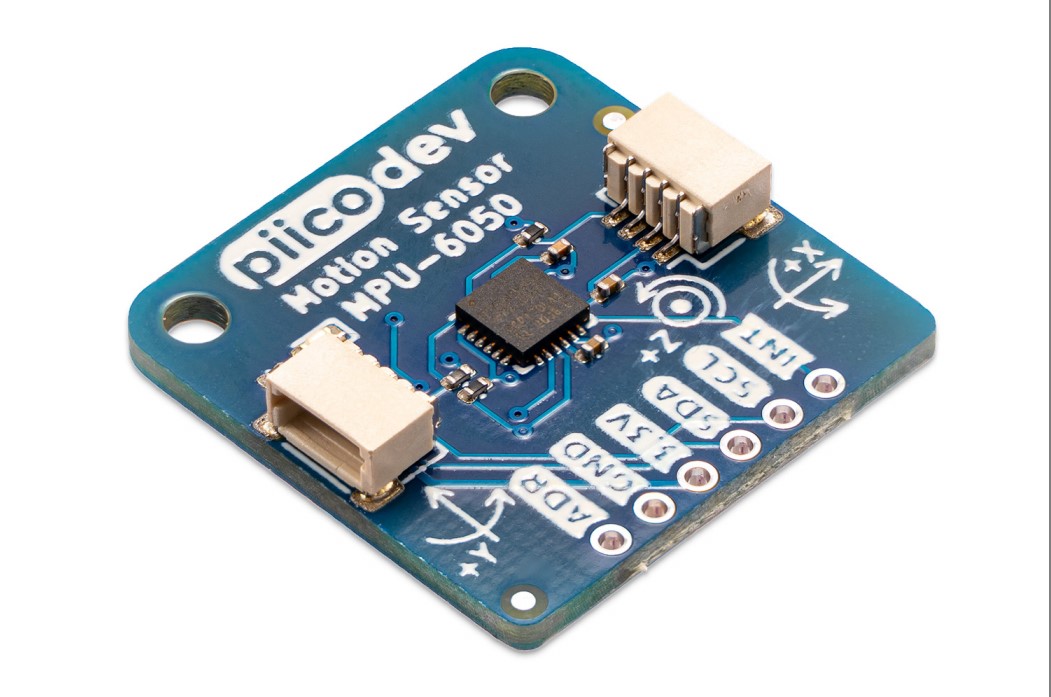
This is the repo for the Core Electronics PiicoDev Motion Sensor MPU-6050.
Our PiicoDev® Motion Sensor makes it super easy to detect linear or angular motion in your next project. The Motion Sensor features a the ubiquitous MPU-6050 6-axis Inertial Measurement Unit (IMU) featuring 16-bit resolution Accelerometer and Gyroscope.
This project is open source - please review the LICENSE.md file for further licensing information.
If you have any technical questions, or concerns about licensing, please contact technical support on the Core Electronics forums.
"PiicoDev" and the PiicoDev logo are trademarks of Core Electronics Pty Ltd.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 4 | 10k | Resistor_SMD:R_0402_1005Metric | R1, R3, R4, R5 |
| 2 | Connector_JST:JST_SH_SM04B-SRSS-TB_1x04-1MP_P1.00mm_Horizontal | J1, J2 | |
| 2 | 100n | Capacitor_SMD:C_0402_1005Metric | C1, C4 |
| 2 | Fiducial | Fiducial:Fiducial_1mm_Mask2mm | FID1, FID2 |
| 2 | MountingHole | MountingHole:MountingHole_2.7mm_M2.5 | H1, H4 |
| 1 | CoreElectronics_Components:PiicoDev_header_4pin | J3 | |
| 1 | 120R | Resistor_SMD:R_0402_1005Metric | R2 |
| 1 | 2n2 50V | Capacitor_SMD:C_0402_1005Metric | C3 |
| 1 | Address | CoreElectronics_Components:PiicoDev_header_1pin_ADR | J4 |
| 1 | Address | CoreElectronics_Components:PiicoDev_header_1pin_INT_uninverted | J5 |
| 1 | I2C | CoreElectronics_Components:SolderJumper-3_P1.3mm_Closed_RoundedPad1.0x1.5mm_NumberLabels | JP3 |
| 1 | IMU_axes_and_polarity_X | CoreElectronics_Artwork:IMU_axes_and_polarity_X | Ref** |
| 1 | IMU_axes_and_polarity_Y | CoreElectronics_Artwork:IMU_axes_and_polarity_Y | Ref** |
| 1 | IMU_axes_and_polarity_Z | CoreElectronics_Artwork:IMU_axes_and_polarity_Z | Ref** |
| 1 | LED | CoreElectronics_Components:SolderJumper-2_P1.3mm_Bridged_RoundedPad1.0x1.5mm | JP1 |
| 1 | LED | LED_SMD:LED_0603_1608Metric | D1 |
| 1 | LOGO | CoreElectronics_Artwork:CoreElectronics_logo_5mm_v2 | G*** |
| 1 | LOGO_CoreElectronics_made-with-love | CoreElectronics_Artwork:piicodev_logo_14.2x3.4mm | G1 |
| 1 | LOGO_piico | CoreElectronics_Artwork:piicodev_logo_14.2x3.4mm | G2 |
| 1 | Logo_Open_Hardware_Small | CoreElectronics_Artwork:oshw | LOGO1 |
| 1 | MPU-6050 | Sensor_Motion:InvenSense_QFN-24_4x4mm_P0.5mm | U1 |
| 1 | SW_DIP_x01 | CoreElectronics_Components:SW_DIP_x01_Slide_CHS-01A1 | SW1 |

ZhuYanzhen1/MM32_CLion
本项目是全国大学生智能车竞赛GDUT 2022年极速越野组的项目文件。采用了LQR控制器和多速率卡尔曼融合算法,并在单片机上实现。This project is the project document for the GDUT 2022 Extreme Off-Road Category of the National Student Intelligent Vehicle Competition.


victorhook/asac-fc
asac fc is an rp2040 based flight controller made for FPV drone flying


pms67/PModlet
PMOD PCB with USB-to-UART converter and IMU (MPU-6050, I2C) for FPGAs.
It measures 25.4 × 25.4 mm and has 2 copper layers, 1.6 mm thick.
29 parts, built around the MPU-6050. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the CoreElectronics/CE-PiicoDev-IMU-MPU6050 repository on GitHub, at the commit this page was made from: the board is PCB/PiicoDev-IMU-MPU6050.kicad_pcb and its schematic PCB/PiicoDev-IMU-MPU6050.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask CoreElectronics before reusing the design.