4 layers193.2 × 52.8 mm

 paradise-fi/RoFI42
Distributed Metamorphic Robots
ControlBoard is an open-source printed circuit board by paradise-fi, from the paradise-fi/RoFI repository on GitHub. It is a 4-layer board of 305 × 208.3 mm with 224 parts on 260 nets, routed with 4,223 tracks and 1,793 vias.
It is built around the ESP32-WROVER-E-N16R8, SD8942 and TPS61088RHL, with the HT7533-1(SOT89-3), MPU-6050 and AONR21357 among its other parts. Its parts include 60 capacitors, 40 resistors, 40 connectors, 10 ICs and 6 diodes. It belongs with the robots and motor control boards and the ESP32 boards of this library.


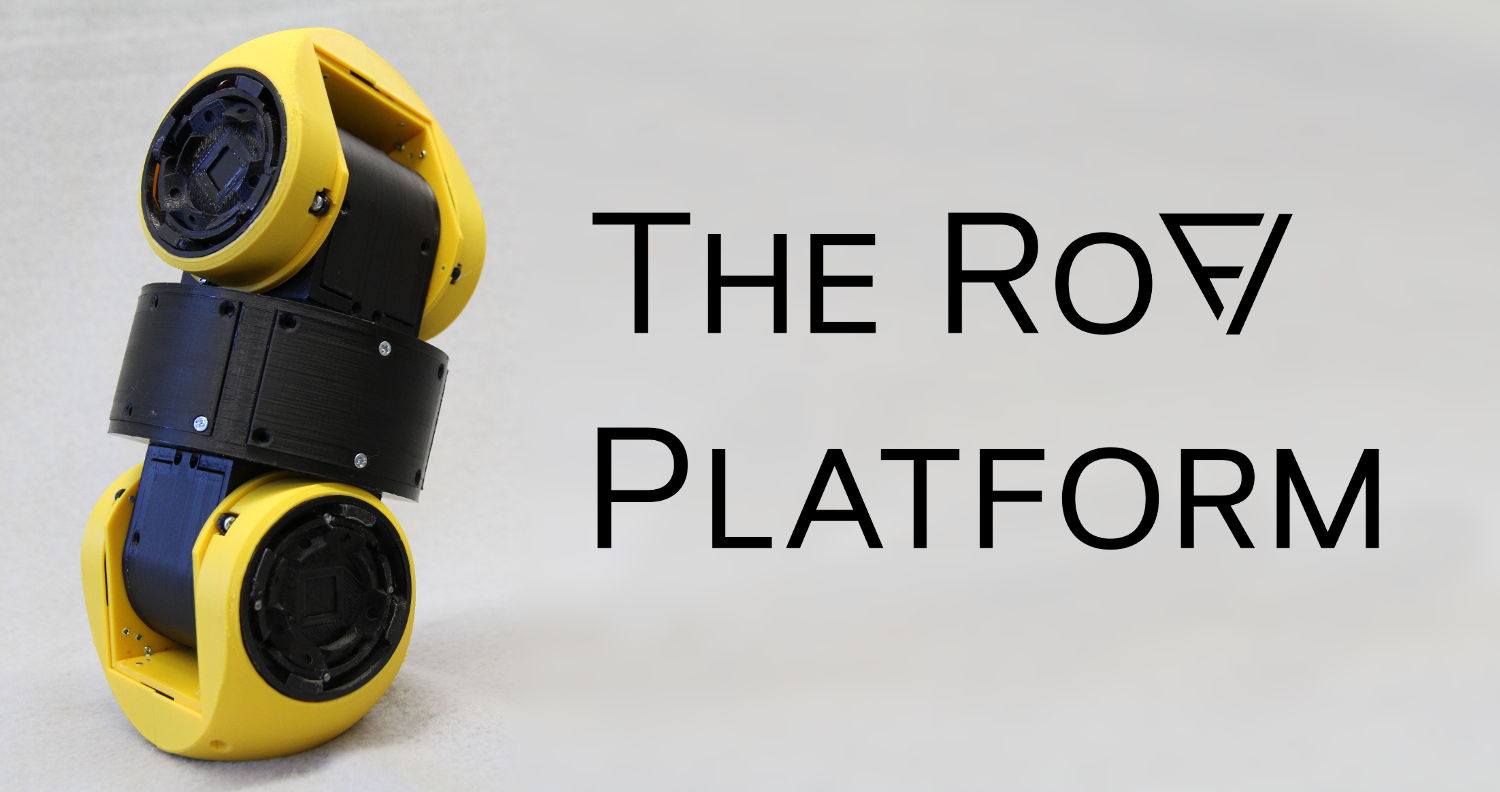
Project website: https://rofi.fi.muni.cz/
RoFI is a platform of modular robots developed at Faculty of Informatics at Masaryk University. The platform is designed for building larger robots (RoFIbots) from a small number of module types.
The modules of the platform can connect together using RoFI dock. Mechanically connected modules can communicate over TCP/IP and share power.
For an in-depth description of the RoFI platform see the project website.
If you are interested in building your modules or development of the platform, please refer to the project documentation: https://paradise-fi.github.io/RoFI/.
You will find all the necessary information about building and using the project there. For a brief reminder of the compilation process, see:
$ source setup.sh <Configuration> # Setup your shell for compiling the
                                  # project in a configuration
$ rcfg --list                     # Show available compilation suites
$ rcfg <suiteName>                # Configure given suite
$ rmake --all                     # Compile all configured suites or...
$ rmake <targetName>              # Compile given target or...
$ rmake tools/ # Compile all configured targets from source prefix| Qty | Value | Footprint | References |
|---|---|---|---|
| 27 | 22u | Capacitor_SMD:C_0805_2012Metric | C1, C10, C12, C13, C19, C20, C25, C26, C27, C28, C29, C30, C32, C34, C35, C37 +11 |
| 16 | MountingHole | rofi:ThreadedHole-M2 | H16, H17, H18, H19, H20, H21, H22, H23, H24, H25, H26, H27, H28, H29, H30, H31 |
| 11 | BOARD | kikit:Board | BODY1, BODY2, BODY3, BODY4, BODY5, CABLE1, CABLE2, DEBUG1, SHOE1, SHOE2, SHOE3 |
| 9 | 10k | Resistor_SMD:R_0402_1005Metric | R2, R17, R22, R27, R30, R32, R34, R36, R56 |
| 8 | 470n | Capacitor_SMD:C_0402_1005Metric | C41, C42, C43, C51, C59, C62, C63, C64 |
| 8 | MountingHole | MountingHole:MountingHole_2.1mm | H1, H2, H3, H4, H5, H6, H7, H8 |
| 6 | 100n | Capacitor_SMD:C_0402_1005Metric | C45, C46, C47, C53, C54, C57 |
| 4 | 100k | Resistor_SMD:R_0402_1005Metric | R7, R24, R25, R26 |
| 4 | 100n | Capacitor_SMD:C_0603_1608Metric | C14, C15, C16, C17 |
| 3 | 0R | Resistor_SMD:R_0402_1005Metric | R5, R6, R19 |
| 3 | 1u | Capacitor_SMD:C_0603_1608Metric | C18, C23, C24 |
| 3 | DBG1 | Connector_PinHeader_2.54mm:PinHeader_1x07_P2.54mm_Vertical | J24, J30, J36 |
| 3 | GREEN | LED_SMD:LED_0603_1608Metric | D16, D17, D18 |
| 3 | MountingHole | rofi:RoFICoM-MountingHolesThreaded | H13, H14, H15 |
| 3 | OUTPUT | rofi:UM_SHOE_PADS | J27, J33, J39 |
| 3 | ROFICOM1_A | rofi:SOLO-9258 | J23, J29, J35 |
| 3 | ROFICOM1_B | rofi:SOLO-9258 | J25, J31, J37 |
| 3 | ROFICOM1_C | rofi:SOLO-9258 | J26, J32, J38 |
| 3 | Servo | rofi:Dynamixel-XL-430-TOP | U1, U2, U3 |
| 2 | 10p | Capacitor_SMD:C_0402_1005Metric | C52, C65 |
| 2 | 150k | Capacitor_SMD:C_0402_1005Metric | R3, R4 |
| 2 | 1u5/2u2 | rofi:MGV1004 | L1, L2 |
| 2 | 22n | Capacitor_SMD:C_0402_1005Metric | C21, C22 |
| 2 | 27p | Capacitor_SMD:C_0402_1005Metric | C31, C33 |
| 2 | 2k2 | Resistor_SMD:R_0402_1005Metric | R33, R35 |
| 2 | 2u2 | Capacitor_SMD:C_0603_1608Metric | C9, C11 |
| 2 | 3k3 | Resistor_SMD:R_0402_1005Metric | R28, R29 |
| 2 | 470p | Capacitor_SMD:C_0402_1005Metric | C36, C44 |
| 2 | 47k | Resistor_SMD:R_0402_1005Metric | R11, R12 |
| 2 | 510k | Resistor_SMD:R_0402_1005Metric | R13, R15 |
| 2 | 56k | Resistor_SMD:R_0402_1005Metric | R14, R16 |
| 2 | 5k1 | Resistor_SMD:R_0402_1005Metric | R37, R38 |
| 2 | 68k | Resistor_SMD:R_0402_1005Metric | R21, R23 |
| 2 | 75k | Resistor_SMD:R_0402_1005Metric | R9, R10 |
| 2 | AONR21357 | rofi:DFN3.3X3.3-EP | Q1, Q2 |
| 2 | Battery_Cell | rofi:BATTERY_18350 | BT1, BT2 |
| 2 | INPUT | rofi:UM_SHOE_PADS | J28, J34 |
| 2 | MountingHole | MountingHole:MountingHole_2.7mm | H9, H10 |
| 2 | SB1045L | Package_TO_SOT_SMD:TO-277B | D2, D3 |
| 2 | SHOE | rofi:FPC_0.5_24_PADS | J42, J44 |
| 2 | SLIP_RING_OUT | Connector_FFC-FPC:Hirose_FH12-40S-0.5SH_1x40-1MP_P0.50mm_Horizontal | J13, J48 |
| 2 | TPS61088 | rofi:VFQFN-20-4.5mmx3.5mm | U5, U8 |
| 1 | 10u | Capacitor_SMD:C_0805_2012Metric | C55 |
| 1 | 10u | Capacitor_SMD:C_0402_1005Metric | C60 |
| 1 | 1k | Resistor_SMD:R_0402_1005Metric | R55 |
| 1 | 200k | Resistor_SMD:R_0402_1005Metric | R1 |
| 1 | 20k | Resistor_SMD:R_0402_1005Metric | R31 |
| 1 | 22k | Resistor_SMD:R_0402_1005Metric | R8 |
| 1 | 22u | rofi:SLO0630H | L4 |
| 1 | 2N7002 | Package_TO_SOT_SMD:SOT-23 | Q3 |
| 1 | 470R | Resistor_SMD:R_0402_1005Metric | R18 |
| 1 | 4u7 | rofi:SMNR5020 | L3 |
| 1 | 75m | Resistor_SMD:R_1206_3216Metric | R20 |
| 1 | 7D024000H01 | Crystal:Crystal_SMD_2016-4Pin_2.0x1.6mm | Y1 |
| 1 | A | rofi:UM_SHOE_PADS_BOTH | J40 |
| 1 | B | rofi:UM_SHOE_PADS_BOTH | J41 |
| 1 | BATTERY_BOARD_CONN | Connector_PinHeader_2.00mm:PinHeader_2x12_P2.00mm_Vertical | J7 |
| 1 | BOARD_IN | Connector_FFC-FPC:Hirose_FH12-40S-0.5SH_1x40-1MP_P0.50mm_Horizontal | J3 |
| 1 | BootSelector | Jumper:SolderJumper-3_P2.0mm_Open_TrianglePad1.0x1.5mm | JP1 |
| 1 | CONTROL_BOARD_CONN | Connector_PinHeader_2.00mm:PinHeader_2x12_P2.00mm_Vertical_SMD | J11 |
| 1 | Conn_02x10_Odd_Even | Connector_PinSocket_2.54mm:PinSocket_2x10_P2.54mm_Vertical | J18 |
| 1 | Conn_ST_STDC14 | Connector_PinSocket_1.27mm:PinSocket_2x07_P1.27mm_Vertical_SMD | J20 |
| 1 | DEBUG | rofi:Hirose_FH12-10S-0.5SH_1x10-1MP_P0.50mm_Horizontal | J1 |
| 1 | DEBUG | Connector_FFC-FPC:Hirose_FH12-10S-0.5SH_1x10-1MP_P0.50mm_Horizontal | J21 |
| 1 | ESP-DBG | Connector_IDC:IDC-Header_2x05_P2.54mm_Vertical | J19 |
| 1 | ESP32-WROVER-E-N16R8 | rofi:ESP32-WROVER | U6 |
| 1 | HT7533-1-SOT89 | Package_TO_SOT_SMD:SOT-89-3 | U12 |
| 1 | INPUT | rofi:FPC_0.5_24_PADS | J15 |
| 1 | INTERFACE_CONN_BOTTOM | Connector_PinHeader_2.00mm:PinHeader_2x12_P2.00mm_Vertical | J9 |
| 1 | INTERFACE_CONN_TOP | rofi:2xM22-6550642R | J10 |
| 1 | MPU-6050 | Sensor_Motion:InvenSense_QFN-24_4x4mm_P0.5mm | U7 |
| 1 | OLED_DISPLAY | rofi:OLED_128_32_I2C | J2 |
| 1 | PIEZO | rofi:CST-931AP | U9 |
| 1 | RED | LED_SMD:LED_0603_1608Metric | D14 |
| 1 | REFERENCE_PINS | rofi:SlipRing-120220-0161 | J14 |
| 1 | SD8942 | Package_TO_SOT_SMD:SOT-23-6 | U4 |
| 1 | SERVO | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J4 |
| 1 | SHOE | Connector_FFC-FPC:Hirose_FH12-24S-0.5SH_1x24-1MP_P0.50mm_Horizontal | J12 |
| 1 | SHOE_B1 | rofi:SlipRing-120220-0161 | J5 |
| 1 | SHOE_B2 | rofi:SlipRing-120220-0161-incomplete | J6 |
The 207 most common of 224 parts.


sandgum/Triangulate-SF_01-Speaker-Frame
A 24 inch Raspberry Pi-based Android digital picture frame attached to a 220W stereo Bluetooth speaker with DSP

hacker-fab/uw-p901-reader
Custom PCB and code to read off a MKS P901 vacuum pressure transducer.


It measures 305 × 208.3 mm and has 4 copper layers, 1.6 mm thick.
224 parts, built around the ESP32-WROVER-E-N16R8, SD8942, TPS61088RHL and HT7533-1(SOT89-3). The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the paradise-fi/RoFI repository on GitHub, at the commit this page was made from: the board is hardwareModules/universalModule/hardware/controlBoard/controlBoard.kicad_pcb and its schematic hardwareModules/RoFICoM/hardware/control_board/bi-switch.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask paradise-fi before reusing the design.