2 layers
Dyno LED PCB
zumdar/ContactlessBikeDynamo
Contactless Bicycle Dynamo (using eddy currents) and a light!
14 parts10

 zumdar/ContactlessBikeDynamo10
Contactless Bicycle Dynamo (using eddy currents) and a light!
REV2 Dyno Rectifier PCB 2 is an open-source printed circuit board by zumdar, from the zumdar/ContactlessBikeDynamo repository on GitHub. It is a 2-layer board of 25 × 22 mm with 38 parts on 17 nets, routed with 452 tracks and 48 vias.
It is built around the PAM2803AAF095 and TPS63070RNMR. Its parts include 10 capacitors, 5 resistors, 5 diodes, 2 ICs and 2 connectors.


 This is a certified Open Source small electrical generator that creates enough current to power a small bicycle light while your wheel is spinning.
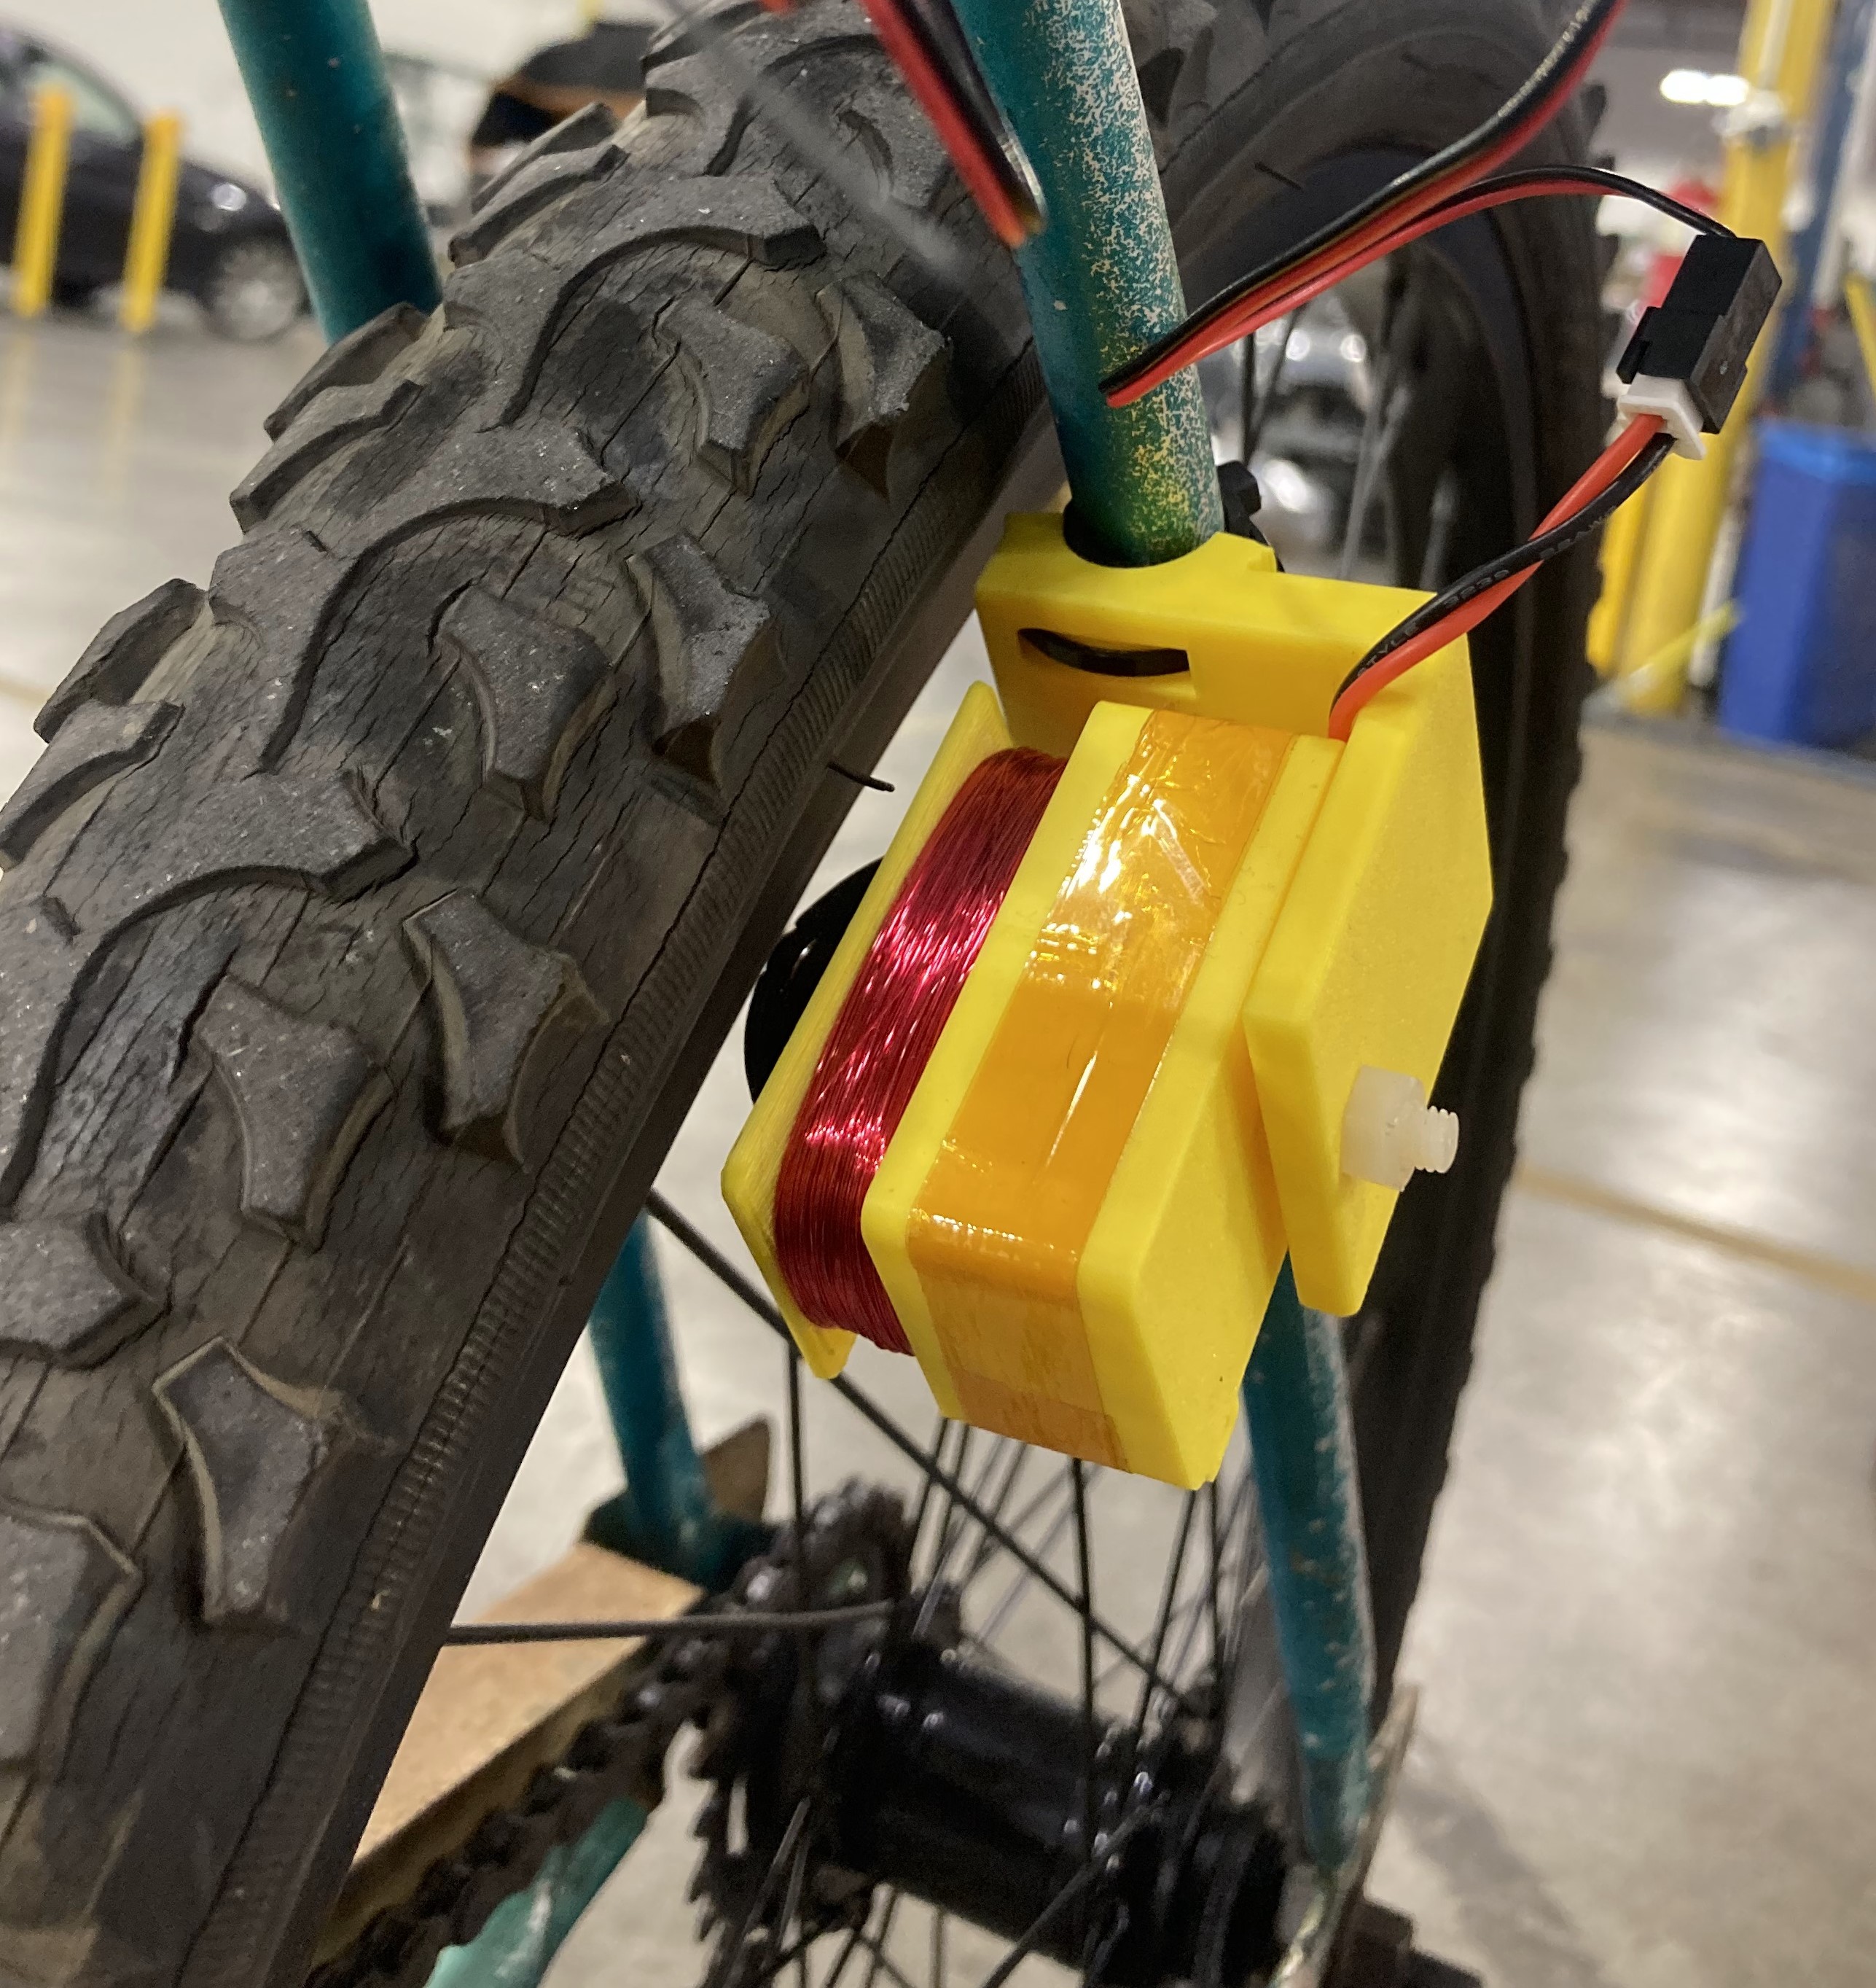
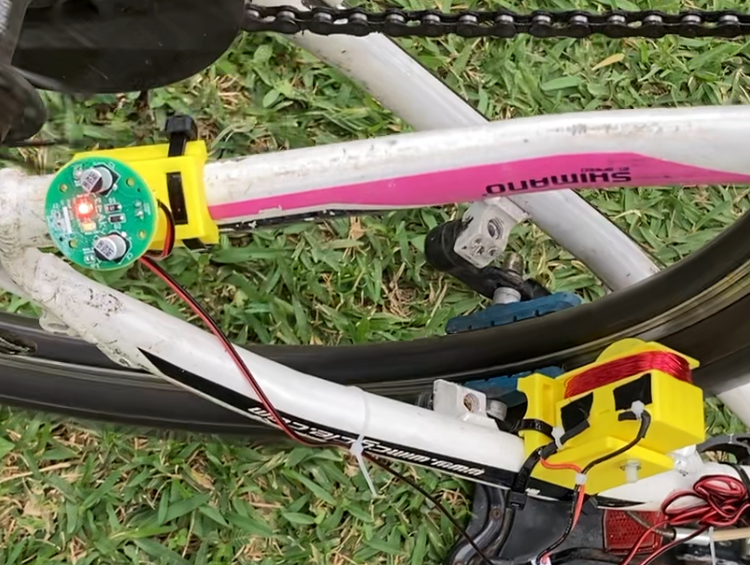
The design files here include the physical design files for the Dynamo and the LED light, as well as a custom PCB for the LED light which is a simple voltage rectifier doubler and choice of red or white led.
If you would like to make this project:
This project started off with a desire to be a workshop I could host to show an interesting way to generate electricity and power a bike light without needing a battery.
Here are the workshop slides: https://docs.google.com/presentation/d/1txSlyZcSNcTIk4scu_-NPuIz-HN-7od_rSDEqWW2YtM/edit?usp=sharing
The parts are labelled as follows:
There is also an assembly of the Dynamo labelled:
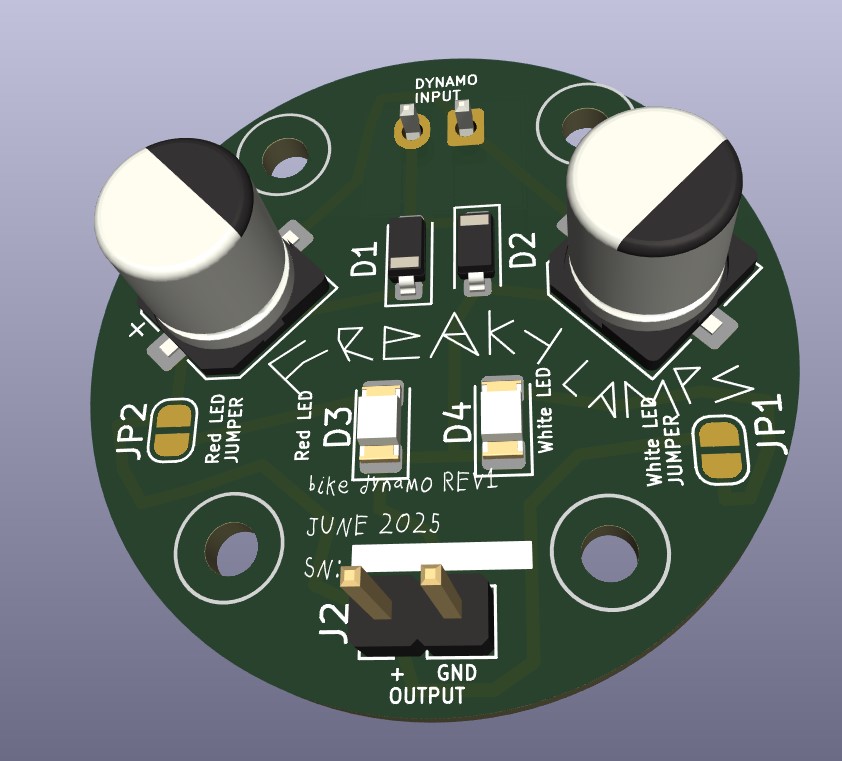
The PCB contains red and white LEDs which can be selected by doing a solder bridge while assembling.
You can't use both at the same time. If you solder both, only the Red LED will light (it has a lower forward voltage).
The LED PCB design can be found in:
Thank you to:
Lucas Ray, Clara Caspard, and YJ Rodrigues for helping develop this!
This is an certified open source project!
| Qty | Value | Footprint | References |
|---|---|---|---|
| 7 | TestPoint | TestPoint:TestPoint_Pad_1.0x1.0mm | TP1, TP2, TP3, TP4, TP5, TP6, TP7 |
| 5 | D_Schottky | Diode_SMD:D_SOD-923 | D1, D2, D3, D4, D5 |
| 4 | 10uF | Capacitor_SMD:C_0805_2012Metric | C2, C8, C9, C10 |
| 2 | 10uF | Capacitor_SMD:C_0603_1608Metric | C3, C5 |
| 2 | SolderJumper_3_Bridged12 | Jumper:SolderJumper-3_P1.3mm_Bridged2Bar12_RoundedPad1.0x1.5mm | JP1, JP2 |
| 1 | 1.5uH | Inductor_SMD:L_1008_2520Metric | L1 |
| 1 | 1.8 | Resistor_SMD:R_0402_1005Metric | R5 |
| 1 | 100k | Resistor_SMD:R_0402_1005Metric | R4 |
| 1 | 100nF | Capacitor_SMD:C_0603_1608Metric | C4 |
| 1 | 100u | Capacitor_THT:CP_Radial_D5.0mm_P2.00mm | C1 |
| 1 | 10k | Resistor_SMD:R_0402_1005Metric | R1 |
| 1 | 150k | Resistor_SMD:R_0402_1005Metric | R3 |
| 1 | 1F - 2.7V | william_custom:supercapacitor - 4mm diameter | C7 |
| 1 | 2.2uH | Inductor_SMD:L_1008_2520Metric | L2 |
| 1 | 360k | Resistor_SMD:R_0402_1005Metric | R2 |
| 1 | 47uF | Capacitor_SMD:C_0805_2012Metric | C6 |
| 1 | Barrel_Jack_MountingPin | Connector_BarrelJack:BarrelJack_Horizontal | J2 |
| 1 | Dynamo Input | william_custom2:TerminalBlock_Xinya_XY308-2.54-2P_1x02_P2.54mm_Horizontal | J1 |
| 1 | PAM2803AAF095 | william_custom:PAM2803_SOT-23-6_L2.9-W1.6-P0.95-LS2.8-BR | U2 |
| 1 | TPS63070RNMR | william_custom:TPS63070RNMR-2 | U1 |
The 35 most common of 38 parts.
zumdar/ContactlessBikeDynamo
Contactless Bicycle Dynamo (using eddy currents) and a light!

zumdar/ContactlessBikeDynamo
Contactless Bicycle Dynamo (using eddy currents) and a light!

zumdar/ContactlessBikeDynamo
Contactless Bicycle Dynamo (using eddy currents) and a light!

mx3353672833-debug/moto-gps-waveshare
MOTO GPS · Waveshare ESP32-S3 1.75C 圆屏导航 + iPhone App | Author: Maler X | Noncommercial, attribution required | Experimental

psas/lv3.1-recovery
design, analysis, CAD, and testing for the LV3.1 recovery system


Tinkerbug-Robotics/TinkerNav
RTK Rover and Base Station Firmware for TinkerNav Boards


nsreeni07/Polaris
A custom-built TVC rocket with a self-designed STM32F722 flight computer (Madgwick AHRS, dual-axis PID, active gimbal correction) for stable, actively-corrected flight.
It measures 25 × 22 mm and has 2 copper layers, 1.6 mm thick.
38 parts, built around the PAM2803AAF095 and TPS63070RNMR. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the zumdar/ContactlessBikeDynamo repository on GitHub, at the commit this page was made from: the board is Electrical/REV2_Dyno_Rectifier_PCB_2/REV2_Dyno_Rectifier_PCB_2.kicad_pcb and its schematic Electrical/Dyno_LED_PCB/Dyno_LED_PCB.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask zumdar before reusing the design.