6 layers48.8 × 40.2 mm

 winsonlin8/SpinnyKittyCommittee
A rhythm-synchronized speaker system featuring a 3D-printed cat that spins and flashes RGB LEDs in time with music — inspired by this video.
SpinnyKittyCommittee is an open-source printed circuit board by winsonlin8, from the winsonlin8/SpinnyKittyCommittee repository on GitHub, published under the MIT licence. It is a 2-layer board of 120 × 97 mm with 90 parts on 107 nets, routed with 831 tracks and 55 vias.
It is built around the MSPM0G3507SDGS28R, SN74AHCT125N and LT8609EMSE#PBF, with the AP33771CFBZ-13-FA01, TL3305AF260QG and PSMN2R6-30YLC,115-VB among its other parts. Its parts include 37 capacitors, 23 resistors, 9 ICs, 9 connectors and 8 switches.


A rhythm-synchronized speaker system featuring a 3D-printed cat that spins and flashes RGB LEDs in time with music — inspired by this video.
Group Members: Katherine Han, Evan Ho, Hajime Kioi, Winson Lin
The Spinning Cat Speaker is a custom-built embedded audio system that plays music while driving a DC motor to spin a 3D-printed cat figurine in sync with the beat. An RGB LED ring mounted on the assembly pulses with the music for a visual effect that complements the audio.
The system is powered via a 5V USB connection and streams audio and motor movement data concurrently from a microSD card. Physical buttons allow the user to cycle through tracks, control playback, and trigger LED effects.
The system is built around two microcontrollers:
| Component | Role |
|---|---|
| ESP32 | Main compute: audio, SD, buttons, I2C master |
| MSPM0G3507 | Peripheral control: motor, LEDs (I2C target) |
| ADA254 (microSD Breakout) | Music and movement file storage (SPI) |
| ICS-43434 | MEMS microphone (I2S) |
| MAX98357A | I2S Class D amplifier |
| EK1725 (2"–3", 4Ω, 3W) | Speaker |
| L298N | DC motor driver (PWM + GPIO direction) |
| DC Motor | Spins the cat |
| 35x WS2812 5050 LED Ring | RGB lighting effects (1-wire) |
| 8 Buttons | User input (GPIO with pull-ups) |
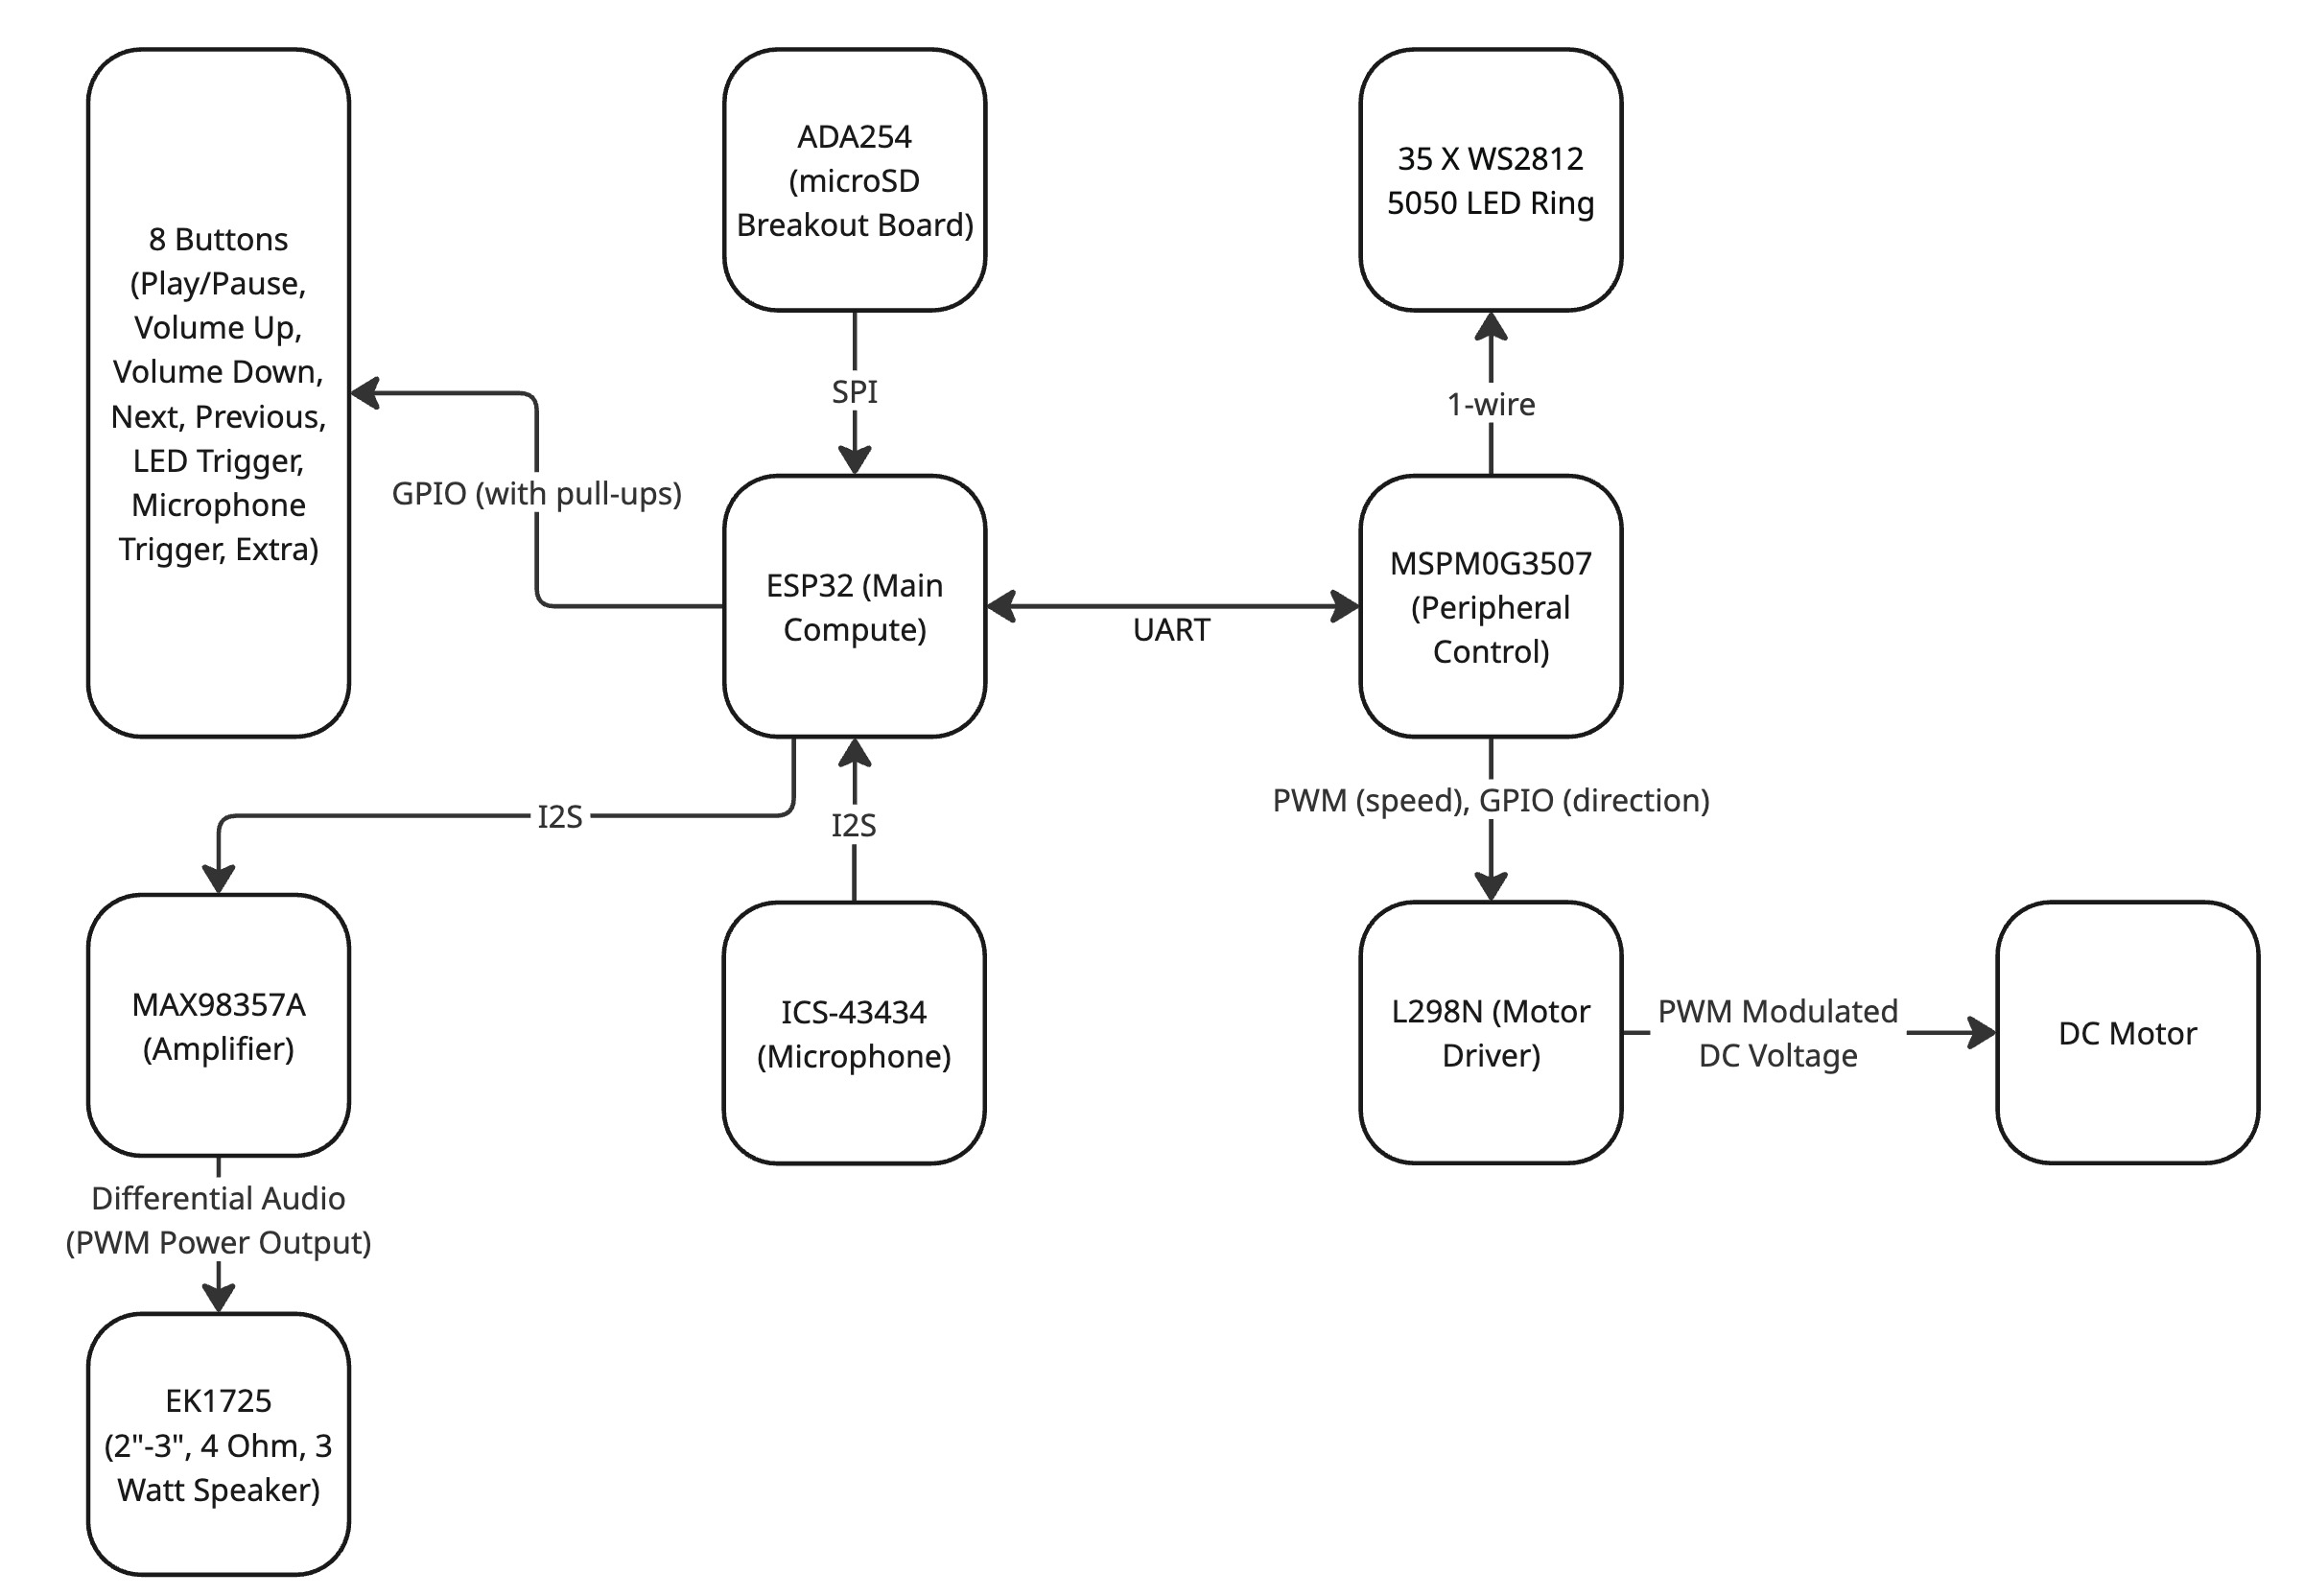
The entire system is powered from a single 5V USB connection.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 13 | 0.1uF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C5, C13, C14, C16, C18, C20, C23, C25, C26, C28, C30, C32, C34 |
| 8 | 10k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R14, R15, R16, R17, R18, R19, R20, R21 |
| 8 | TL3305AF260QG | SpinnyKitty:TL3305AF160QG | S1, S2, S3, S4, S5, S6, S7, S8 |
| 6 | 22uF | Capacitor_SMD:C_1206_3216Metric_Pad1.33x1.80mm_HandSolder | C8, C11, C12, C19, C27, C33 |
| 5 | 10uF | Capacitor_SMD:C_1206_3216Metric_Pad1.33x1.80mm_HandSolder | C2, C3, C10, C29, C35 |
| 4 | 4.7uF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C4, C21, C22, C31 |
| 3 | 47uF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C15, C17, C24 |
| 3 | 5.1k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R1, R2, R7 |
| 2 | 10nF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C7, C36 |
| 2 | 1uF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C1, C6 |
| 2 | 2.2k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R12, R13 |
| 2 | PSMN2R6-30YLC,115 | SpinnyKitty:PSMN2R630YLC115 | Q1, Q2 |
| 2 | ~ | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J7, J9 |
| 1 | 0.47uF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C37 |
| 1 | 100k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R8 |
| 1 | 100k | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R23 |
| 1 | 10pF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C9 |
| 1 | 18.2k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R9 |
| 1 | 187k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R10 |
| 1 | 1M | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R11 |
| 1 | 2.2uH | SpinnyKitty:PM5402222NLT | L1 |
| 1 | 200 | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R5 |
| 1 | 254 | SpinnyKitty:MODULE_254 | U2 |
| 1 | 3.9uH | SpinnyKitty:SRR3818A3R9Y | L2 |
| 1 | 47k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R22 |
| 1 | 5m | Resistor_SMD:R_2512_6332Metric_Pad1.40x3.35mm_HandSolder | R4 |
| 1 | 6.2k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R3 |
| 1 | 66k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R6 |
| 1 | AP33771CFBZ-13-FA01 | SpinnyKitty:AP33771CFBZ13FA01 | IC2 |
| 1 | AP63203WU-7 | SpinnyKitty:AP63203WU7 | IC4 |
| 1 | ICS43434 Breakout | SpinnyKitty:ICS43434 Breakout | J1 |
| 1 | LED_Header | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J4 |
| 1 | LT8609EMSE#PBF | SpinnyKitty:SOP50P490X110-11N | IC3 |
| 1 | MAX98357_Breakout | SpinnyKitty:MAX98357 | J2 |
| 1 | MSPM0 Programming Header | Connector_PinHeader_2.54mm:PinHeader_1x05_P2.54mm_Vertical | J5 |
| 1 | MSPM0G3507SDGS28R | SpinnyKitty:SOP50P490X110-28N | IC1 |
| 1 | Motor_Driver_Power | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J8 |
| 1 | SN74AHCT125N | SpinnyKitty:DIP794W45P254L1930H508Q14 | U5 |
| 1 | UJ20-C-V-SMT-TR-68 | SpinnyKitty:UJ20CVSMTTR68 | J3 |
| 1 | USBC_Power_Breakout | SpinnyKitty:USBC_POWER_BREAKOUT | J6 |
| 1 | ~ | SpinnyKitty:ESP32_30pin | U1 |
| 1 | ~ | SpinnyKitty:3V3 1.8A Buck | U4 |
| 1 | ~ | SpinnyKitty:5V 3A Buck | U3 |

bennystrange/beat-saber
Beat Saber using custom joysticks, LED arrays and a MSPM0G3507 microcontroller

maxtk4/elec327finalproject
Our Final Project for ELEC 327, a robotic Payload for the SAE Aero Design Advanced Competition


IIP-Group/polymap
Repository for the PolyMap Hardware and PolyMap Studio VST Plugin (prototype version).


o7-machinehum/flipper-blackhat
Linux based WiFi pentesting device for the Flipper Zero.

It measures 120 × 97 mm and has 2 copper layers, 1.6 mm thick.
90 parts, built around the MSPM0G3507SDGS28R, SN74AHCT125N, LT8609EMSE#PBF and AP33771CFBZ-13-FA01. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the winsonlin8/SpinnyKittyCommittee repository on GitHub, at the commit this page was made from: the board is PCB/PCB.kicad_pcb and its schematic PCB/PCB.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).