6 layers36 × 36 mm
Stm32h743-px4
DataFlux-Robot/fluxpcb
全自动AI电路设计流水线: 需求→选型→原理图→PCB→验收仿真→固件,六环节门禁闭环 | Six-stage automated circuit design pipeline with machine-checkable verification gates
22 parts1Apache-2.0
 will-da-pro/Drone-Flight-Controller
Custom drone flight controller using STM32H743
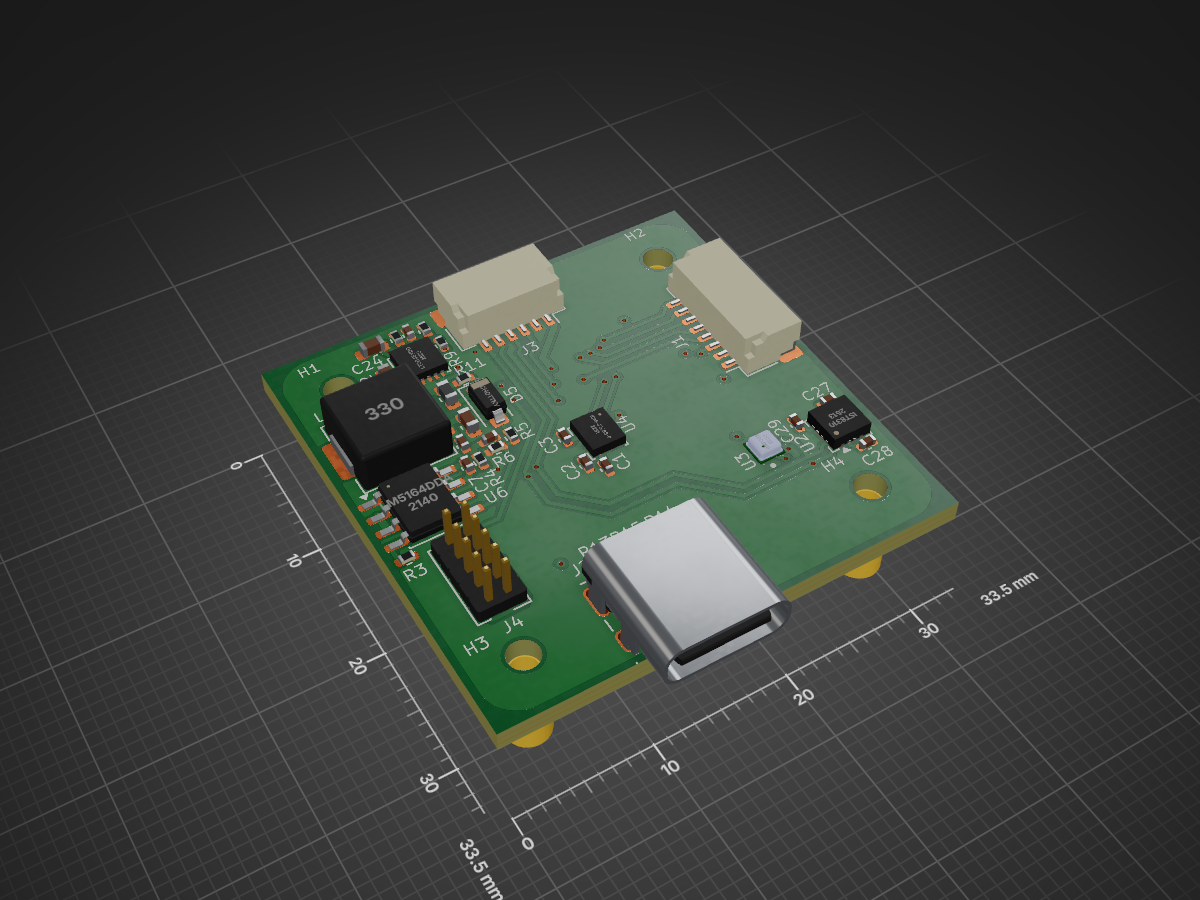
Drone Flight Controller is an open-source printed circuit board by will-da-pro, from the will-da-pro/Drone-Flight-Controller repository on GitHub. It is a 4-layer board of 33.5 × 33.5 mm with 73 parts on 128 nets, routed with 328 tracks and 49 vias.
It is built around the BMP388, IST8310 and LM5164DDA, with the ICM-42688-P among its other parts. Its parts include 31 capacitors, 17 resistors, 6 ICs, 6 diodes and 4 connectors. It belongs with the robots and motor control boards and the STM32 boards of this library.


| Qty | Value | Footprint | References |
|---|---|---|---|
| 9 | 100nF | Capacitor_SMD:C_0402_1005Metric | C4, C6, C8, C9, C10, C11, C21, C25, C26 |
| 4 | D_Schottky | Diode_SMD:D_0402_1005Metric | D1, D2, D3, D4 |
| 4 | MountingHole | MountingHole:MountingHole_2.2mm_M2 | H1, H2, H3, H4 |
| 3 | 0.1uF | Capacitor_SMD:C_0402_1005Metric | C1, C28, C29 |
| 3 | 4.7k | Resistor_SMD:R_0402_1005Metric | R14, R16, R17 |
| 2 | 10k | Resistor_SMD:R_0402_1005Metric | R1, R15 |
| 2 | 10nF | Capacitor_SMD:C_0402_1005Metric | C3, C13 |
| 2 | 12pF | Capacitor_SMD:C_0402_1005Metric | C61, C62 |
| 2 | 1k | Resistor_SMD:R_0402_1005Metric | R2, R8 |
| 2 | 1uF | Capacitor_SMD:C_0402_1005Metric | C14, C15 |
| 2 | 2.2nF | Capacitor_SMD:C_0402_1005Metric | C7, C16 |
| 2 | 2.2uF | Capacitor_SMD:C_0402_1005Metric | C2, C5 |
| 2 | 22pF | Capacitor_SMD:C_0402_1005Metric | C69, C70 |
| 2 | 4.7uF | Capacitor_SMD:C_0402_1005Metric | C23, C27 |
| 2 | 4.7uF | Capacitor_SMD:C_0603_1608Metric | C22, C24 |
| 2 | 5.1k | Resistor_SMD:R_0402_1005Metric | R12, R13 |
| 2 | D_Schottky | Diode_SMD:D_SOD-123 | D5, D6 |
| 1 | 101k | Resistor_SMD:R_0402_1005Metric | R6 |
| 1 | 10uF | Capacitor_SMD:C_0603_1608Metric | C12 |
| 1 | 120R | Inductor_SMD:L_0603_1608Metric | FB1 |
| 1 | 200k | Resistor_SMD:R_0402_1005Metric | R11 |
| 1 | 22uF | Capacitor_SMD:C_0603_1608Metric | C18 |
| 1 | 237k | Resistor_SMD:R_0402_1005Metric | R4 |
| 1 | 25MHz | Crystal:Crystal_SMD_3225-4Pin_3.2x2.5mm | Y1 |
| 1 | 316k | Resistor_SMD:R_0402_1005Metric | R5 |
| 1 | 32.768KHz | Crystal:Crystal_SMD_3215-2Pin_3.2x1.5mm | Y2 |
| 1 | 33.2k | Resistor_SMD:R_0402_1005Metric | R7 |
| 1 | 33uH | Inductor_SMD:L_Vishay_IHLP-2525 | L1 |
| 1 | 41.2k | Resistor_SMD:R_0402_1005Metric | R3 |
| 1 | 453k | Resistor_SMD:R_0402_1005Metric | R9 |
| 1 | 49.9k | Resistor_SMD:R_0402_1005Metric | R10 |
| 1 | 56pF | Capacitor_SMD:C_0402_1005Metric | C17 |
| 1 | BMP388 | drone:XDCR_BMP388 | U3 |
| 1 | Conn_01x06_MountingPin | Connector_JST:JST_SH_SM06B-SRSS-TB_1x06-1MP_P1.00mm_Horizontal | J3 |
| 1 | Conn_01x08_MountingPin | Connector_JST:JST_SH_SM08B-SRSS-TB_1x08-1MP_P1.00mm_Horizontal | J1 |
| 1 | Conn_ARM_JTAG_SWD_10 | Connector_PinHeader_1.27mm:PinHeader_2x05_P1.27mm_Vertical | J4 |
| 1 | FerriteBead | Inductor_SMD:L_0603_1608Metric | FB2 |
| 1 | ICM-42688-P | Package_LGA:LGA-14_3x2.5mm_P0.5mm_LayoutBorder3x4y | U4 |
| 1 | IST8310 | Package_LGA:LGA-16_3x3mm_P0.5mm | U2 |
| 1 | LM5164DDA | Package_SO:HSOP-8-1EP_3.9x4.9mm_P1.27mm_EP2.41x3.1mm_ThermalVias | U6 |
| 1 | LT3045xDD | Package_DFN_QFN:DFN-10-1EP_3x3mm_P0.5mm_EP1.65x2.38mm | U5 |
| 1 | STM32H743VITx | Package_QFP:LQFP-100_14x14mm_P0.5mm | U1 |
| 1 | USB_C_Receptacle_USB2.0_16P | Connector_USB:USB_C_Receptacle_GCT_USB4085 | J2 |
It measures 33.5 × 33.5 mm and has 4 copper layers, 1.6 mm thick.
73 parts, built around the BMP388, IST8310, LM5164DDA and ICM-42688-P. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the will-da-pro/Drone-Flight-Controller repository on GitHub, at the commit this page was made from: the board is drone_flight_controller.kicad_pcb and its schematic drone_flight_controller.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask will-da-pro before reusing the design.
DataFlux-Robot/fluxpcb
全自动AI电路设计流水线: 需求→选型→原理图→PCB→验收仿真→固件,六环节门禁闭环 | Six-stage automated circuit design pipeline with machine-checkable verification gates


xXsenseiXx/KHATAF-F411
Open-hardware 4-layer STM32F411 drone flight controller designed in KiCad for INAV and Betaflight.

rishikesh2715/STM32F7_FC
STM32F722RET6 Based Flight Controller with ICM-42688-P IMU, BMP388 Barometer, and much more!

fdiwth/tvc-drone
This repository contains the documentation, hardware designs, and source code for a Thrust Vector Control (TVC) drone.
