2 layers52.6 × 42.5 mm
Fsr left
UniMelbHumanRoboticsLab/ForceMoCap
System Development for measuring subject joint angle, task position tracking and human-environment interaction forces.
23 partsMIT
 UniMelbHumanRoboticsLab/ForceMoCap
System Development for measuring subject joint angle, task position tracking and human-environment interaction forces.
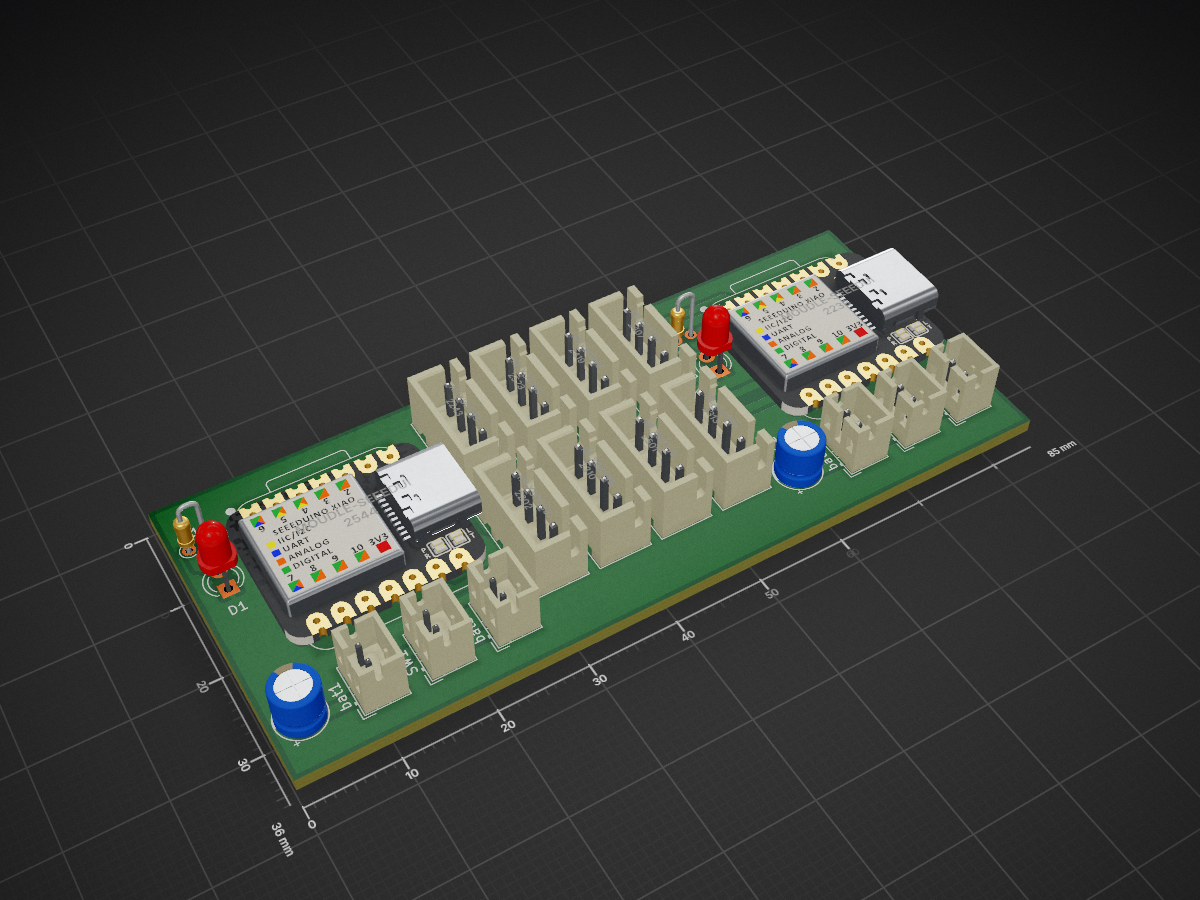
ForceCap pcb is an open-source printed circuit board by UniMelbHumanRoboticsLab, from the UniMelbHumanRoboticsLab/ForceMoCap repository on GitHub, published under the MIT licence. It is a 4-layer board of 85 × 36 mm with 22 parts on 33 nets, routed with 62 tracks and 0 vias.
Its parts include 10 ICs, 2 capacitors, 2 resistors, 2 diodes and 2 switches. It belongs with the ESP32 and RISC-V boards of this library.
System Development for measuring subject joint angle, task position tracking and human-environment interaction forces.
force_trackingmo_capisbul_pckg| Qty | Value | Footprint | References |
|---|---|---|---|
| 8 | MLX90393 | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | IC1, IC2, IC3, IC4, IC5, IC6, IC7, IC8 |
| 4 | ~ | Connector_JST:JST_PH_B2B-PH-K_1x02_P2.00mm_Vertical | bat1, bat2, bat3, bat4 |
| 2 | 100R | Resistor_THT:R_Axial_DIN0204_L3.6mm_D1.6mm_P1.90mm_Vertical | R1, R2 |
| 2 | 100nC | Capacitor_THT:CP_Radial_D5.0mm_P2.50mm | C1, C2 |
| 2 | LED | LED_THT:LED_D3.0mm | D1, D2 |
| 2 | MOUDLE-SEEEDUINO-XIAO-ESP32C3 | xiao-th:XIAO-ESP32C3-DIP | U1, U2 |
| 2 | SW_DPST_x2 | Connector_JST:JST_PH_B2B-PH-K_1x02_P2.00mm_Vertical | SW1, SW2 |
UniMelbHumanRoboticsLab/ForceMoCap
System Development for measuring subject joint angle, task position tracking and human-environment interaction forces.


hackclub/OnBoard
💡 Join 1,000 teenagers and make your first PCB with a $100 grant!


ahmadexp/Open-Source-PC110
Figuring out the missing technical documentation of the beloved PC110

neggles/cfxsx
CFexpress to M.2 NVMe drive adapter. Intended for Xbox Series X and S, but untested.

OpenSiPM/sipm-bias-control
Single channel silicon photomultipliers for high-speed fluorescence imaging
It measures 85 × 36 mm and has 4 copper layers, 1.6 mm thick.
22 parts. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the UniMelbHumanRoboticsLab/ForceMoCap repository on GitHub, at the commit this page was made from: the board is force_tracking/electronics/forceCap_pcb/forceCap_pcb.kicad_pcb and its schematic force_tracking/electronics/FMC_fsr/fsr_left/fsr_left.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).