
4 layers85 × 36 mm
ForceCap pcb
UniMelbHumanRoboticsLab/ForceMoCap
System Development for measuring subject joint angle, task position tracking and human-environment interaction forces.
22 partsMIT
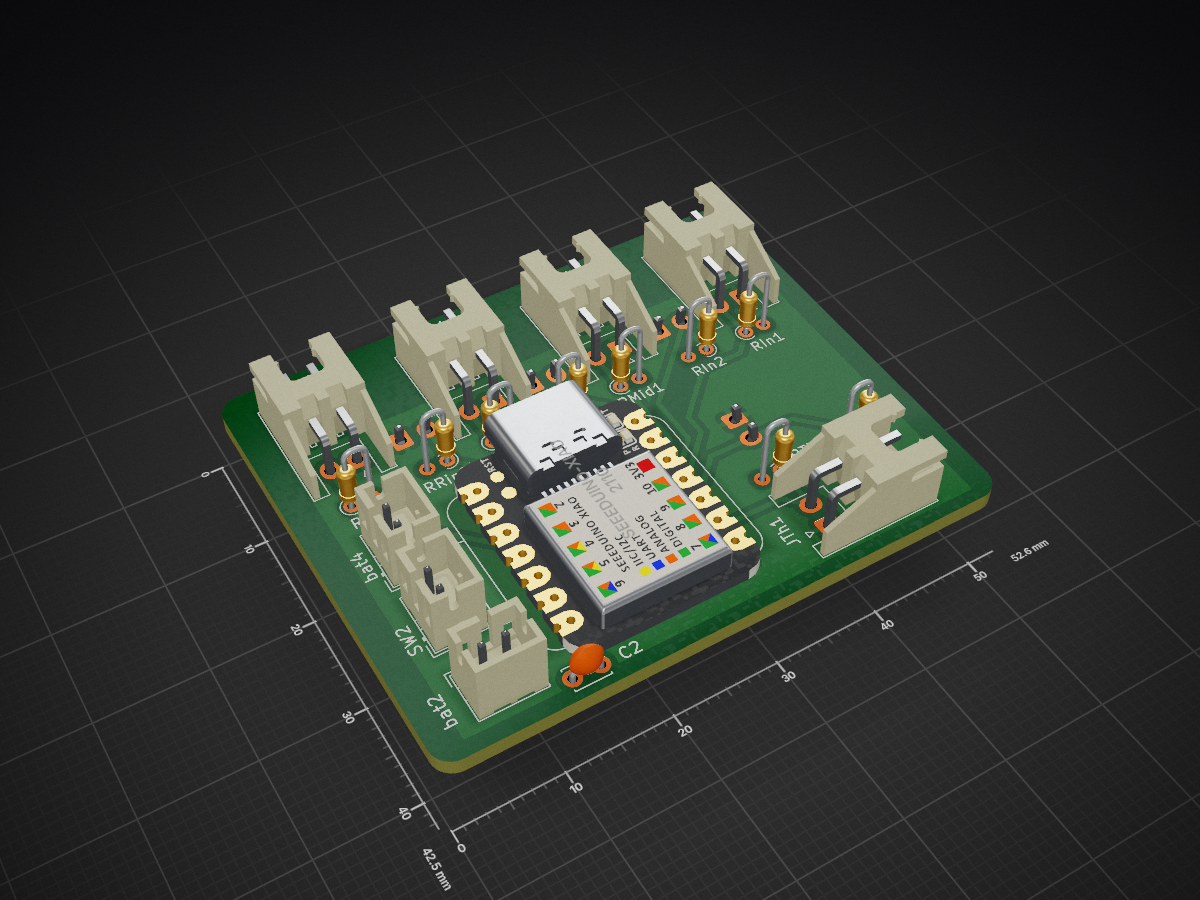
System Development for measuring subject joint angle, task position tracking and human-environment interaction forces.
Fsr left is an open-source printed circuit board by UniMelbHumanRoboticsLab, from the UniMelbHumanRoboticsLab/ForceMoCap repository on GitHub, published under the MIT licence. It is a 2-layer board of 52.6 × 42.5 mm with 23 parts on 19 nets, routed with 78 tracks and 0 vias.
Its parts include 1 capacitor, 1 IC and 1 switch. It belongs with the ESP32 boards of this library.
System Development for measuring subject joint angle, task position tracking and human-environment interaction forces.
force_trackingmo_capisbul_pckg| Qty | Value | Footprint | References |
|---|---|---|---|
| 9 | 100R | Resistor_THT:R_Axial_DIN0204_L3.6mm_D1.6mm_P1.90mm_Vertical | RIn1, RIn2, RMid1, RMid2, RPin1, RRin1, RRin2, RTh1, RTh2 |
| 9 | Conn_01x02_Pin | Connector_JST:JST_XH_S2B-XH-A_1x02_P2.50mm_Horizontal | JIn1, JIn2, JMid1, JMid2, JPin1, JRin1, JRin2, JTh1, JTh2 |
| 2 | ~ | Connector_JST:JST_PH_B2B-PH-K_1x02_P2.00mm_Vertical | bat2, bat4 |
| 1 | 100nC | Capacitor_THT:C_Disc_D3.0mm_W2.0mm_P2.50mm | C2 |
| 1 | SEEEDUINO-XIAO-ESP32S3 | xiao ESP32S3_PCB:MOUDLE14P-DIP-2.54-21X17.8MM | U1 |
| 1 | SW_DPST_x2 | Connector_JST:JST_PH_B2B-PH-K_1x02_P2.00mm_Vertical | SW2 |
UniMelbHumanRoboticsLab/ForceMoCap
System Development for measuring subject joint angle, task position tracking and human-environment interaction forces.


google/mozc-devices
Circuit diagrams and firmware source code for Gboard DIY keyboards


Duet3D/Duet-2-Hardware
The KiCAD source for the Duet 3d printer controller see www.duet3d.com
It measures 52.6 × 42.5 mm and has 2 copper layers, 1.6 mm thick.
23 parts. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the UniMelbHumanRoboticsLab/ForceMoCap repository on GitHub, at the commit this page was made from: the board is force_tracking/electronics/FMC_fsr/fsr_left/fsr_left.kicad_pcb and its schematic force_tracking/electronics/FMC_fsr/fsr_left/fsr_left.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).