ShiroFPV Flight Controller
ShiroFPV/ShiroFPV_Flight_Controller_Collection
Official repository for public ShiroFPV flight controller designs, encompassing fully verified productions as well as ongoing, untested hardware revisions.

ESC schematic and PCB layout to power one three-phase motor with a LiPo battery
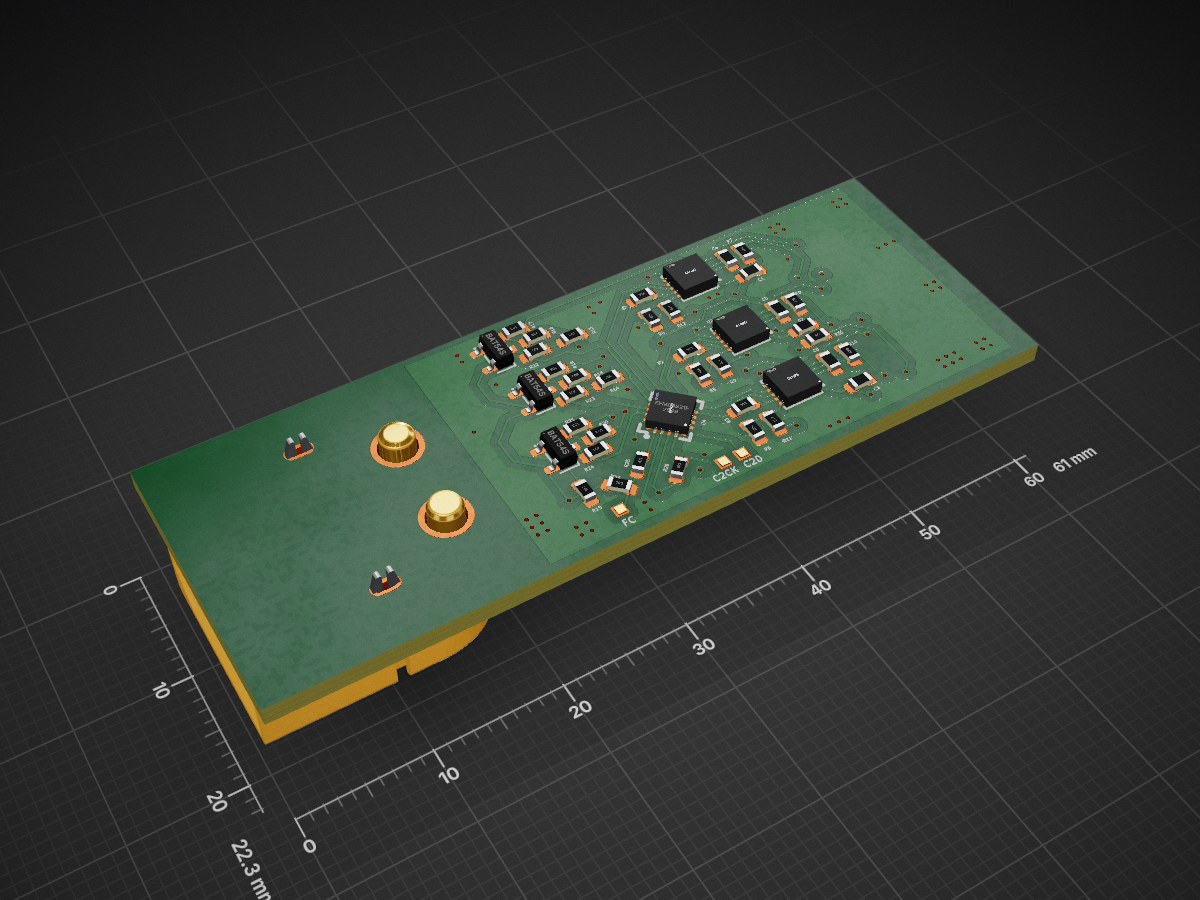
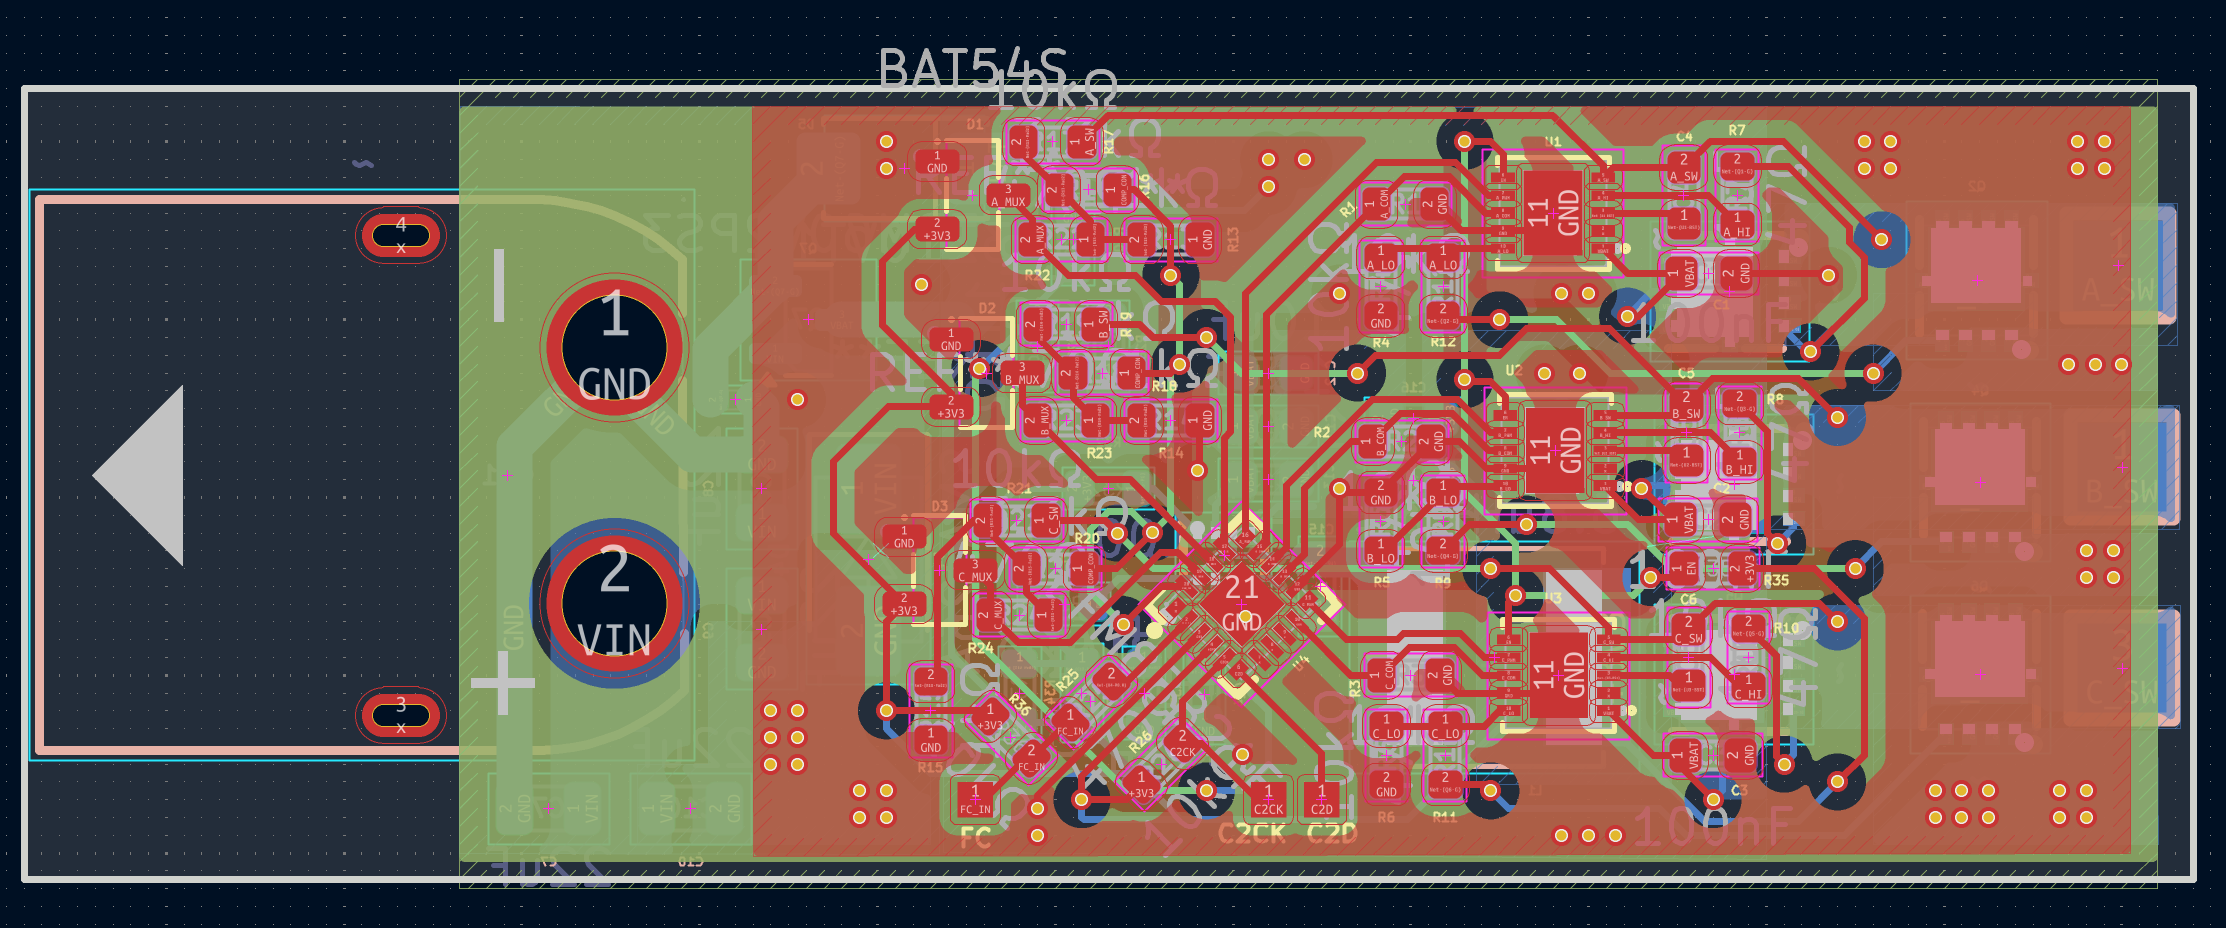
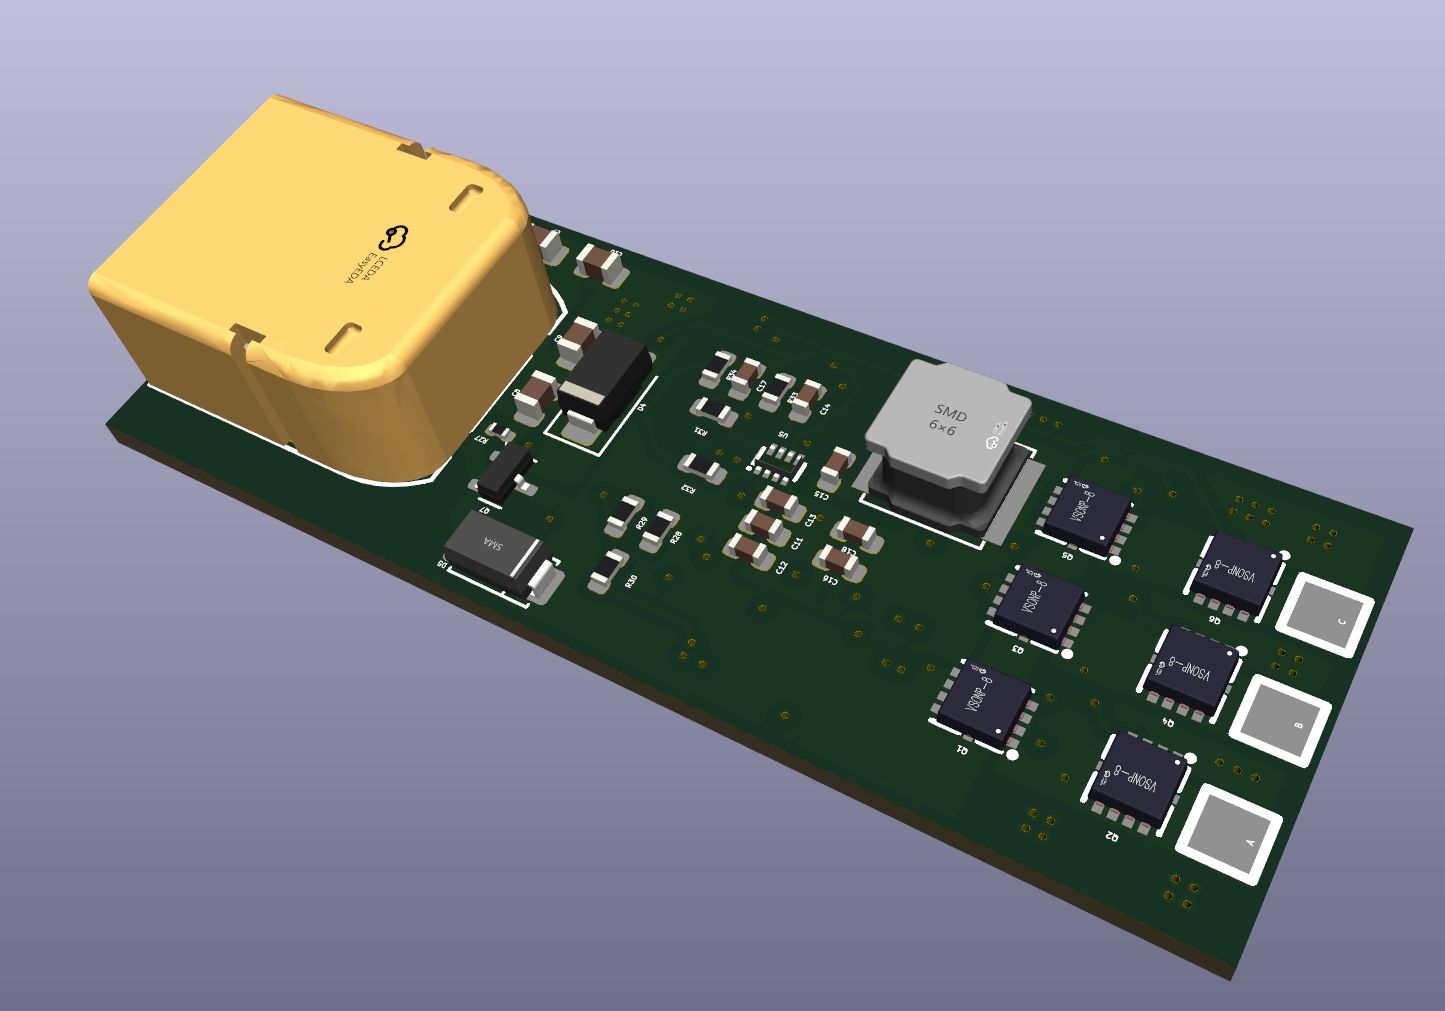
Electronic Speed Controller is an open-source printed circuit board by tsk04, from the tsk04/uav-electronic-speed-controller repository on GitHub. It is a 4-layer board of 61 × 22.3 mm with 79 parts on 58 nets, routed with 385 tracks and 88 vias.
It is built around the BAT54S, LM3Z10VT1G and SMAJ26A, with the TPM60V2PS3 among its other parts. Its parts include 36 resistors, 18 capacitors, 7 transistors, 5 ICs and 5 diodes. It belongs with the power and robots and motor control boards and the Silicon Labs (EFR32, EFM) boards of this library.
Electronic Speed Controller designed to power a three phase motor
| Qty | Value | Footprint | References |
|---|---|---|---|
| 13 | 10kΩ | PCM_JLCPCB:R_0603 | R1, R2, R3, R4, R5, R6, R17, R19, R21, R26, R31, R35, R36 |
| 6 | 47Ω | PCM_JLCPCB:R_0603 | R7, R8, R9, R10, R11, R12 |
| 6 | ~ | EasyEDA_Lib:TSON-8_L3.1-W3.1-P0.65-LS3.3-BL-EP | Q1, Q2, Q3, Q4, Q5, Q6 |
| 5 | 100nF | PCM_JLCPCB:C_0603 | C1, C2, C3, C13, C15 |
| 4 | 22uF | PCM_JLCPCB:C_0805 | C7, C8, C9, C10 |
| 4 | 470Ω | PCM_JLCPCB:R_0603 | R22, R23, R24, R25 |
| 3 | , , | ||
| 3 | 1kΩ | PCM_JLCPCB:R_0603 | R13, R14, R15 |
| 3 | 1uF | PCM_JLCPCB:C_0603 | C4, C5, C6 |
| 3 | 3.3kΩ | PCM_JLCPCB:R_0603 | R16, R18, R20 |
| 3 | BAT54S | PCM_JLCPCB:SOT-23-3_L2.9-W1.3-P1.90-LS2.4-BR | D1, D2, D3 |
| 3 | ~ | EasyEDA_Lib:QFN-10_L3.0-W3.0-P0.50-LS3.0-BL-EP | U1, U2, U3 |
| 2 | 10uF | PCM_JLCPCB:C_0603 | C11, C12 |
| 2 | 22uF | PCM_JLCPCB:C_0603 | C16, C18 |
| 1 | 100kΩ | PCM_JLCPCB:R_0603 | R32 |
| 1 | 100kΩ | PCM_JLCPCB:R_0402 | R27 |
| 1 | 11kΩ | PCM_JLCPCB:R_0603 | R29 |
| 1 | 180kΩ | PCM_JLCPCB:R_0603 | R28 |
| 1 | 22nF | PCM_JLCPCB:C_0603 | C14 |
| 1 | 470pF | PCM_JLCPCB:C_0603 | C17 |
| 1 | 49.9kΩ | PCM_JLCPCB:R_0603 | R30 |
| 1 | 51kΩ | PCM_JLCPCB:R_0603 | R34 |
| 1 | 6.8uH/3A | EasyEDA_Lib:IND-SMD_L6.0-W6.0_SWPA6045S | L1 |
| 1 | 9.1kΩ | PCM_JLCPCB:R_0603 | R33 |
| 1 | A_PAD | Footprints:SolderPad_1_2.5mm_SMD_Rectangle | A |
| 1 | B_PAD | Footprints:SolderPad_1_2.5mm_SMD_Rectangle | B |
| 1 | C_PAD | Footprints:SolderPad_1_2.5mm_SMD_Rectangle | C |
| 1 | EFM8BB21F | EasyEDA_Lib:QFN-20_L3.0-W3.0-P0.50-BL-EP1.7_EFM8BB21F16G | U4 |
| 1 | LM3Z10VT1G | PCM_JLCPCB:D_DO-214AC(SMA) | D5 |
| 1 | SMAJ26A | PCM_JLCPCB:D_SMA | D4 |
| 1 | TPM60V2PS3 | PCM_JLCPCB:D_SOT-23 | Q7 |
| 1 | ~ | EasyEDA_Lib:CONN-TH_XT60PW-M | CN1 |
| 1 | ~ | EasyEDA_Lib:SOT-583-8_L2.1-W1.2-P0.50-LS1.6-BR | U5 |
It measures 61 × 22.3 mm and has 4 copper layers, 1.6 mm thick.
79 parts, built around the BAT54S, LM3Z10VT1G, SMAJ26A and TPM60V2PS3. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the tsk04/uav-electronic-speed-controller repository on GitHub, at the commit this page was made from: the board is Electronic Speed Controller.kicad_pcb and its schematic Electronic Speed Controller.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask tsk04 before reusing the design.

ShiroFPV/ShiroFPV_Flight_Controller_Collection
Official repository for public ShiroFPV flight controller designs, encompassing fully verified productions as well as ongoing, untested hardware revisions.

iandchasse/silkscreen-pcb
Silkscreen: open-hardware ESP32-S3 e-paper reader mainboard (KiCad 9). Formerly the de-link hub.

loganrf/compactPi
compactPi is a project to develop a compact Raspberry Pi Compute Module carrier suitable for ArduPilot applications. It's primarily targeted at marine applications (ArduSub/ArduRover).

sandgum/Triangulate-SF_01-Speaker-Frame
A 24 inch Raspberry Pi-based Android digital picture frame attached to a 220W stereo Bluetooth speaker with DSP


shadedvox/arsenal
A fully custom 6 degree-of-freedom robotic arm, built from the ground up across hardware, firmware, and mechanical design.

shm-dmitry/auto_close_window
This IOT project allows you to open and close your window from any smart house. For example - you can setup rules like a "If night and noise greater then expected -> close window" and "Noise reduced -> open window"
