
2 layers40.6 × 110 mm
Europi surface mount
Allen-Synthesis/EuroPi
EuroPi: A reprogrammable Eurorack module based on the Raspberry Pi Pico
92 parts584CC0-1.0

 thekonon/WritingRobot1
My repo for CAN comunication between Raspberry (Python UI) and STM32 MCU
WritingRobotV2 is an open-source printed circuit board by thekonon, from the thekonon/WritingRobot repository on GitHub. It is a 2-layer board of 70 × 75 mm with 25 parts on 56 nets, routed with 202 tracks and 5 vias.
It is built around the L7805. Its parts include 10 connectors, 4 capacitors, 2 resistors and 2 ICs. It belongs with the robots and motor control boards of this library.
Draw anything using robot!
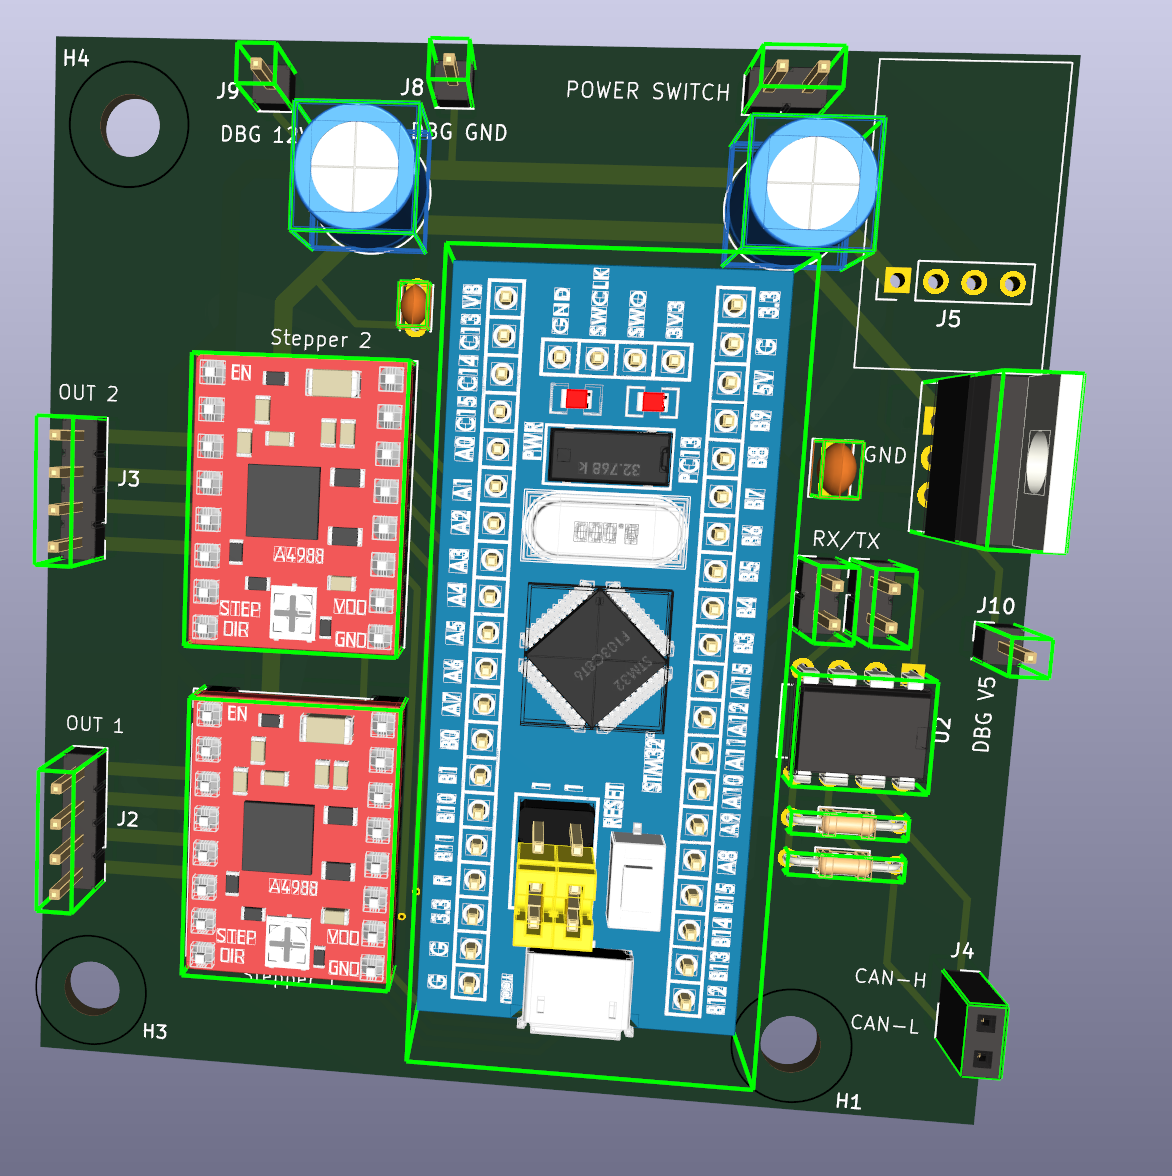
Robot is made of:
Arduino:
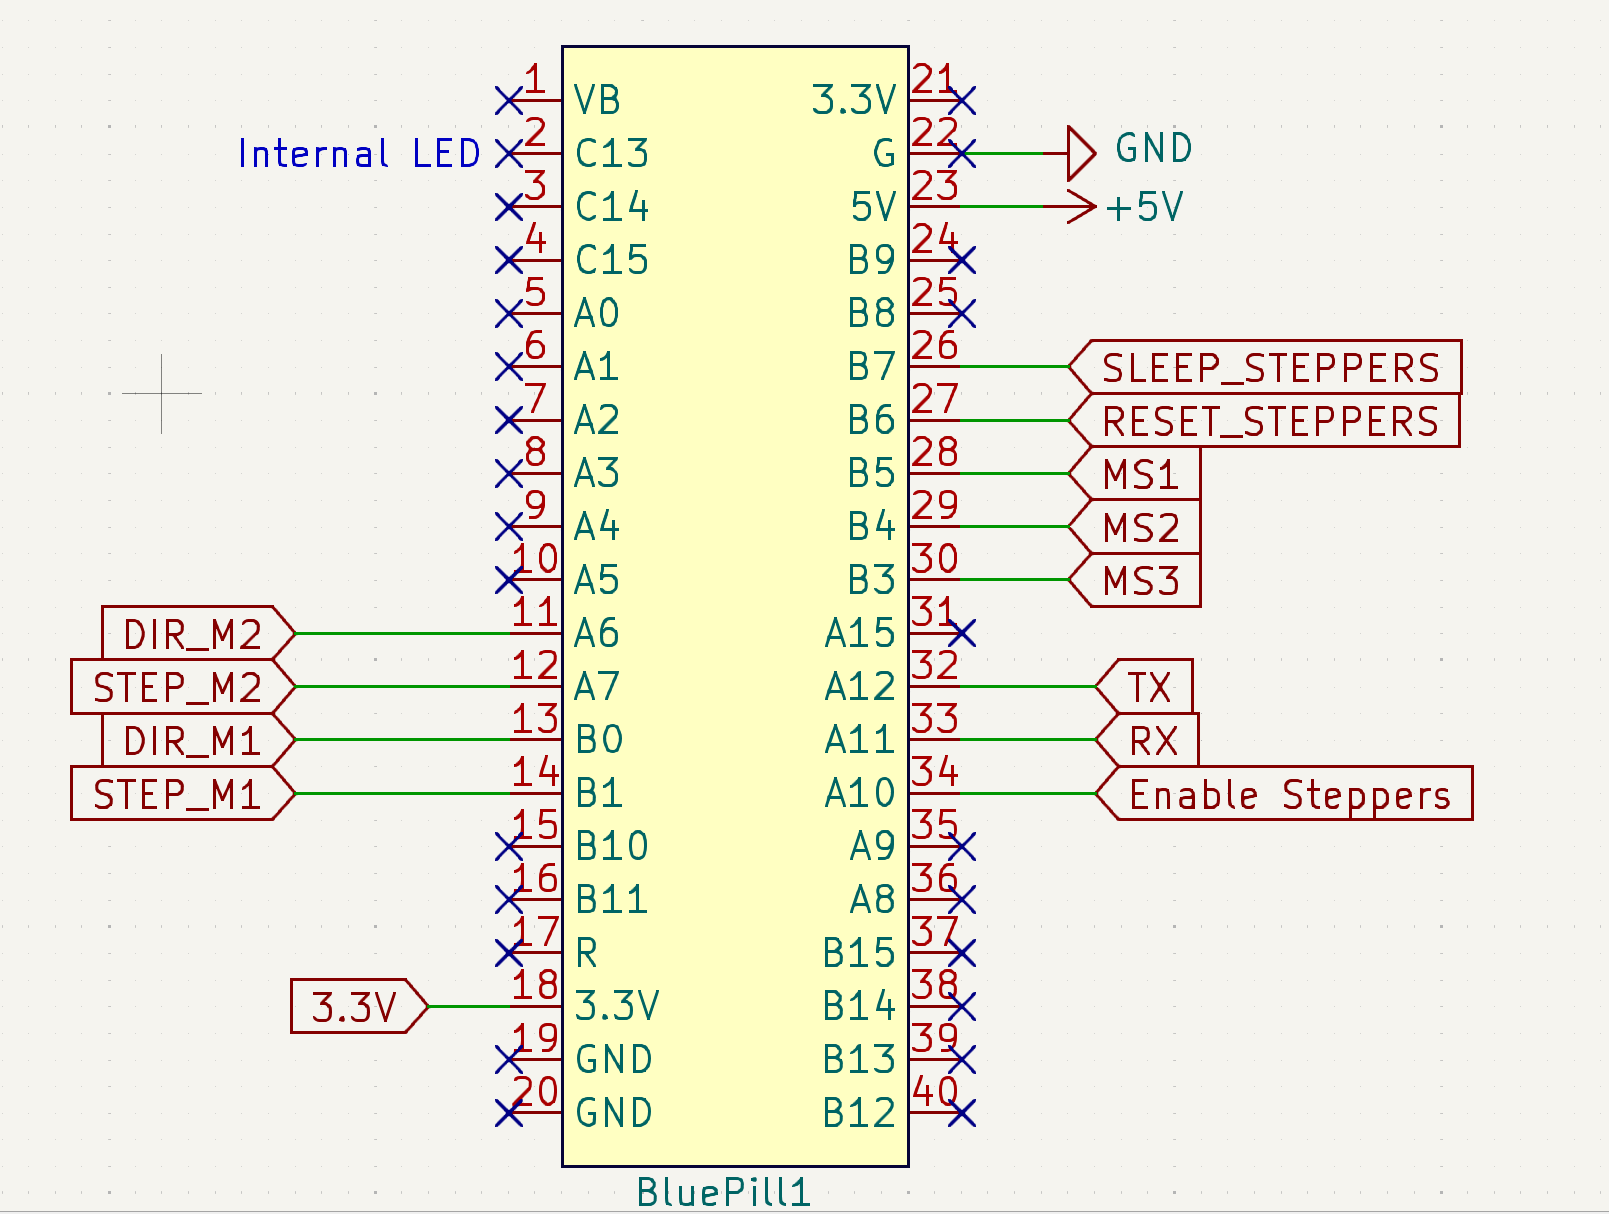
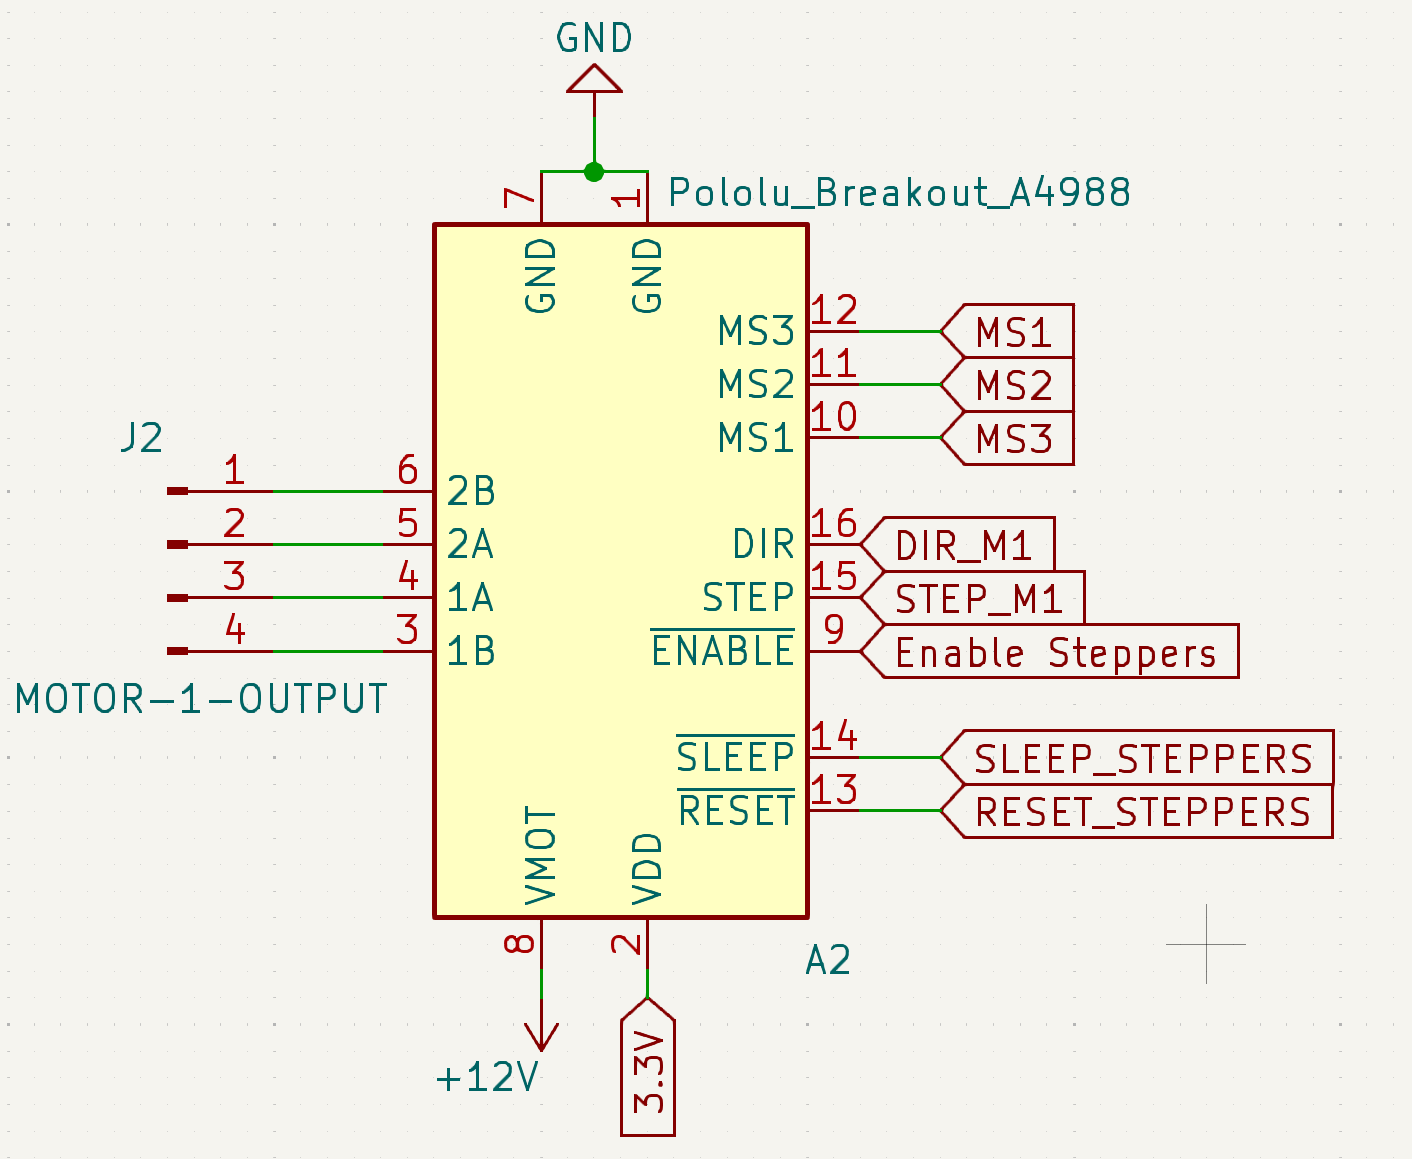
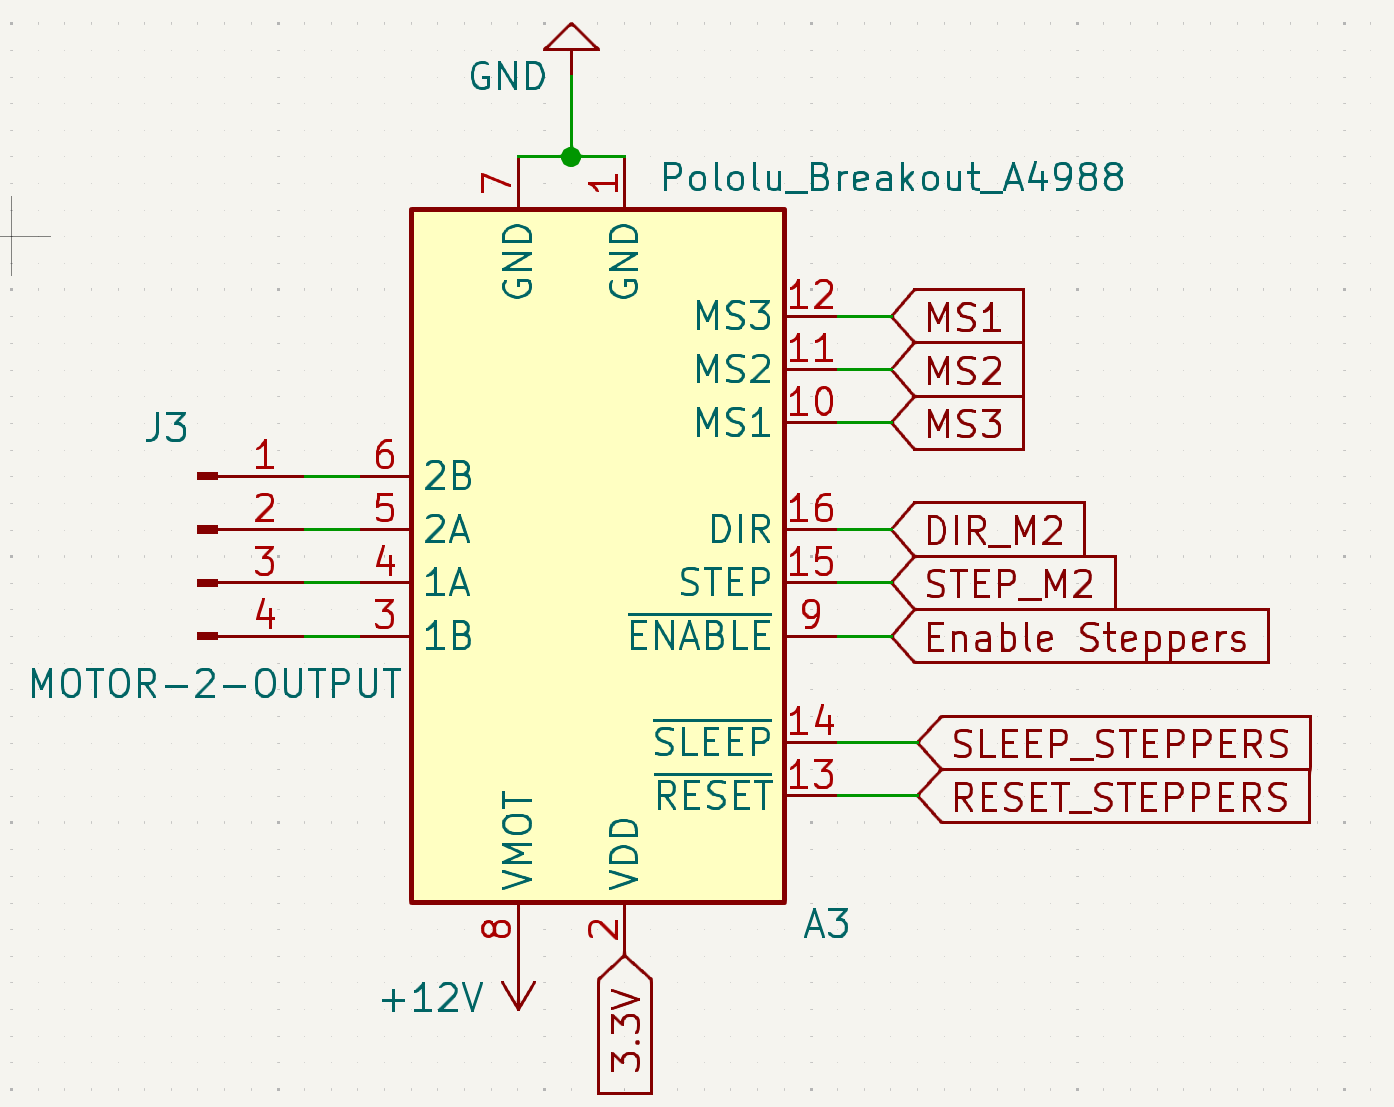
Stepper motors
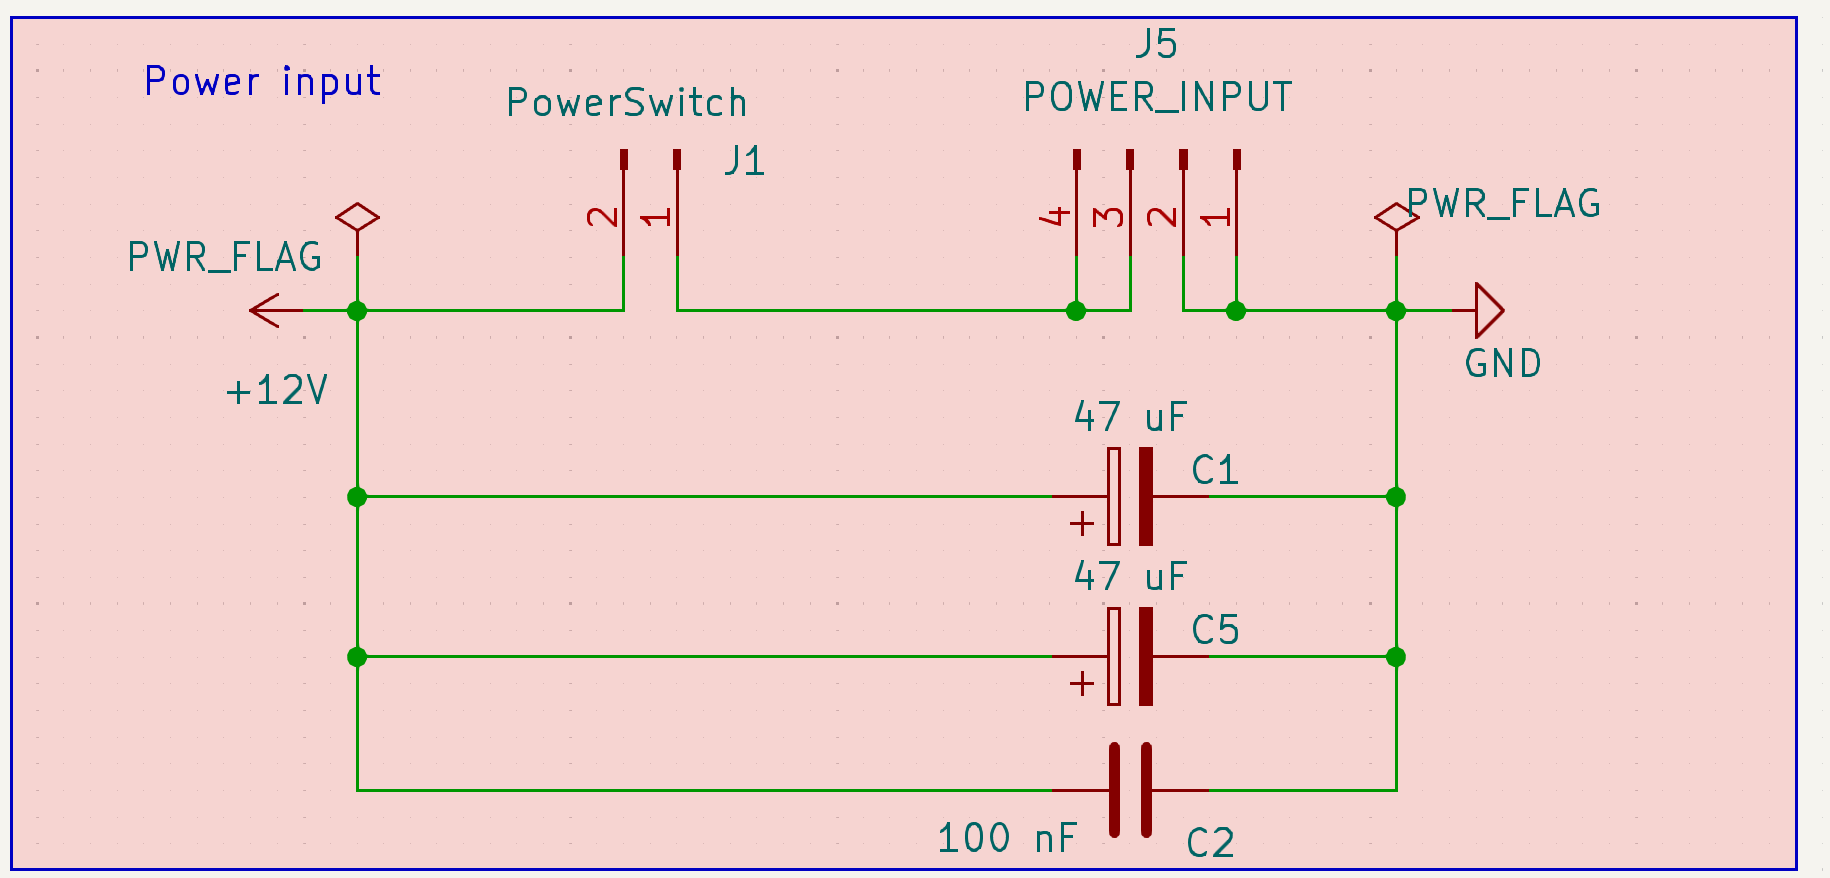
Powerline
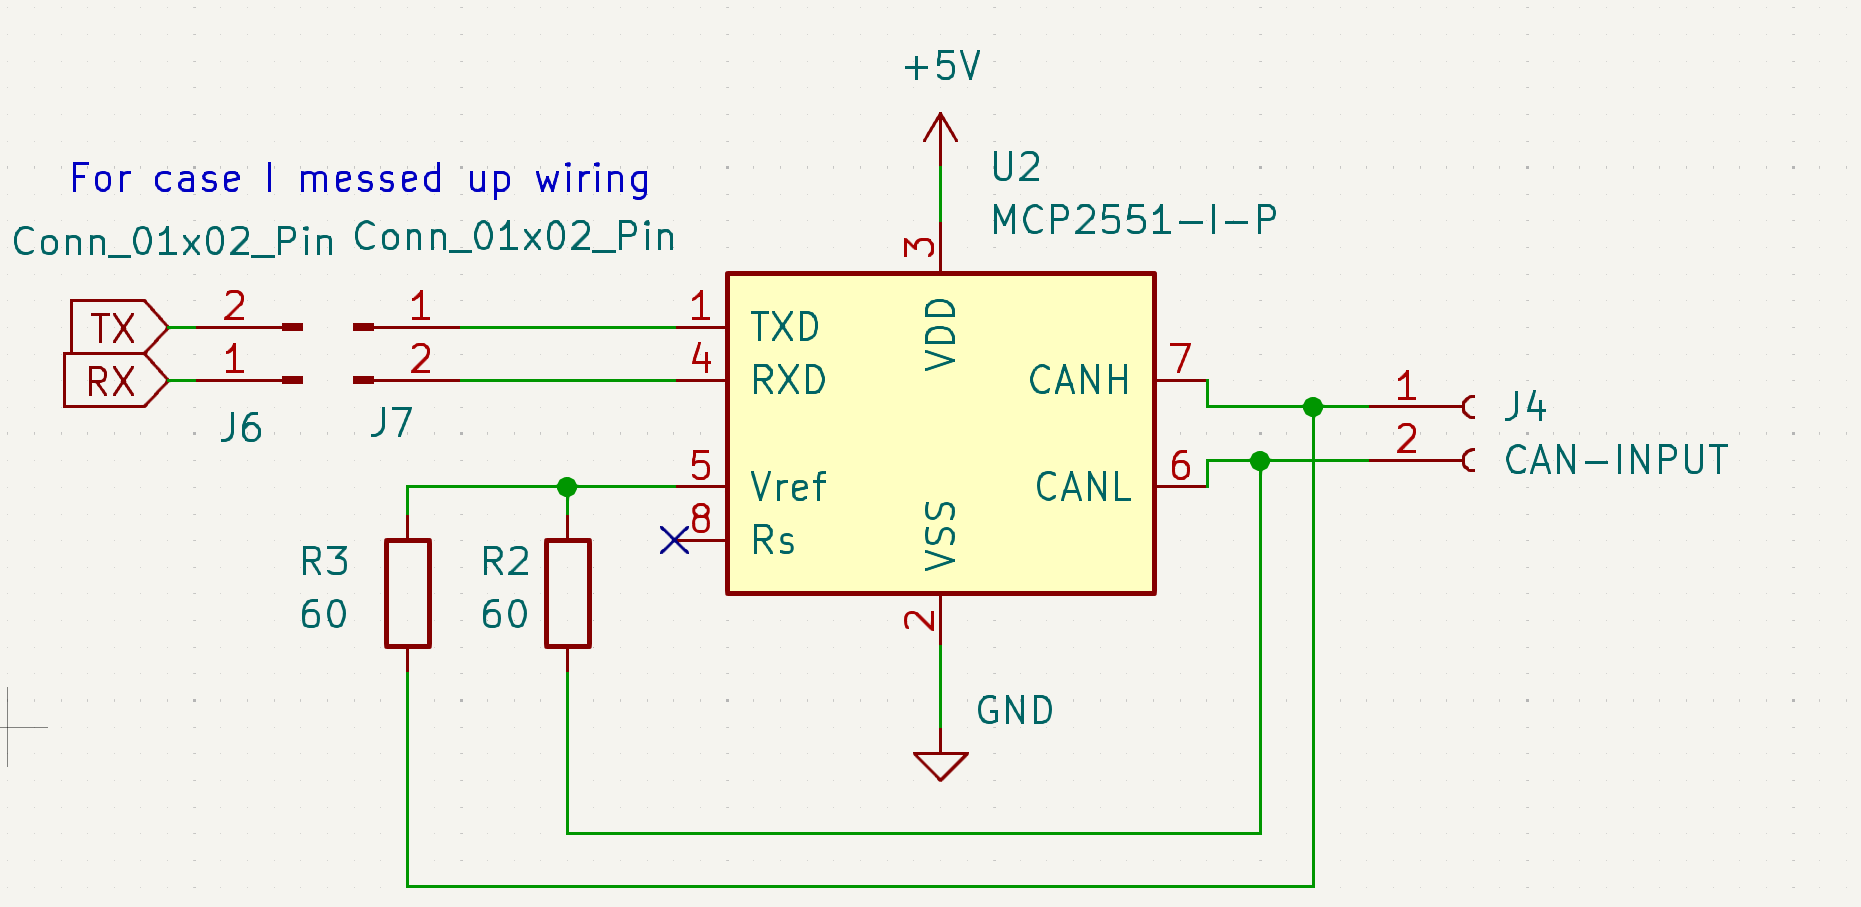
MCP2551 CANH/L -> Rx/Tx data module
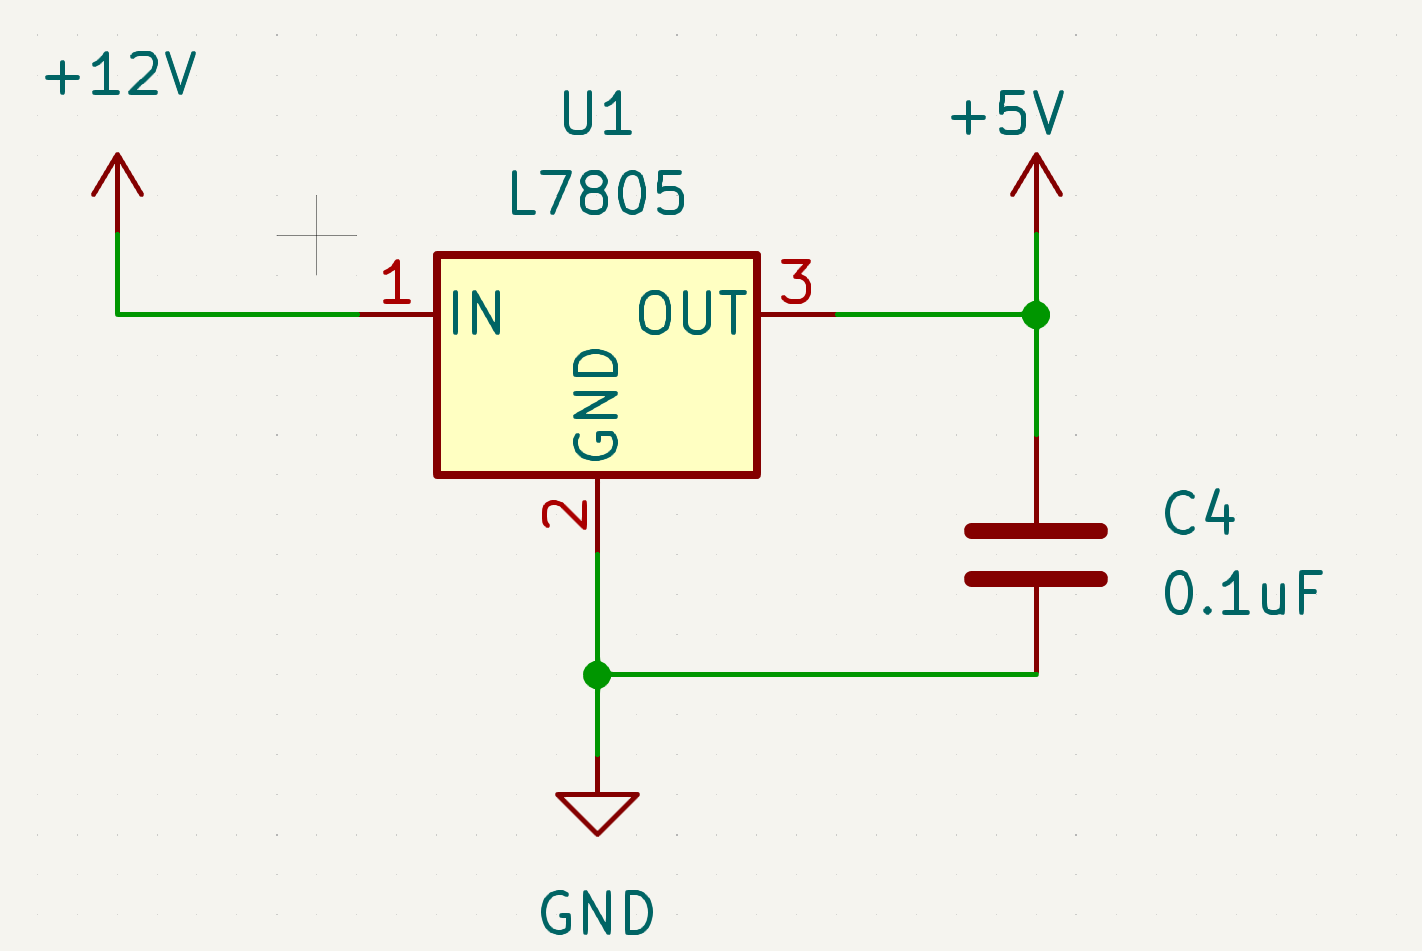
L7805 -> 12V -> 5V/1A
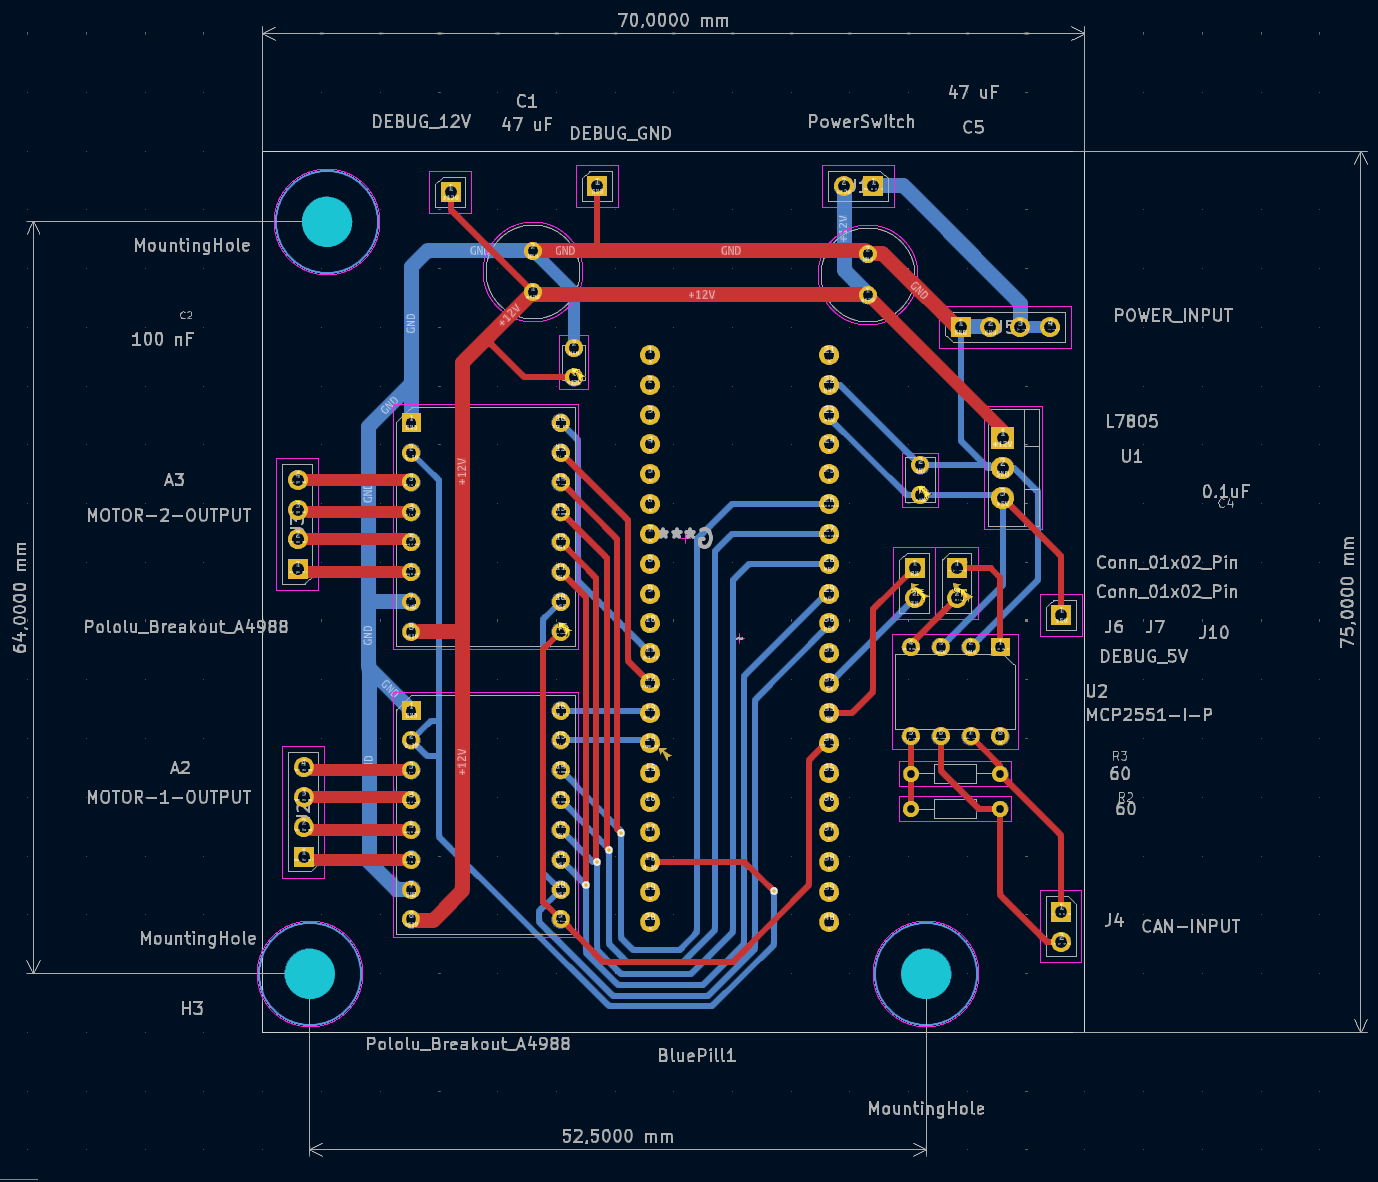
Wiring scheme of actual PCB
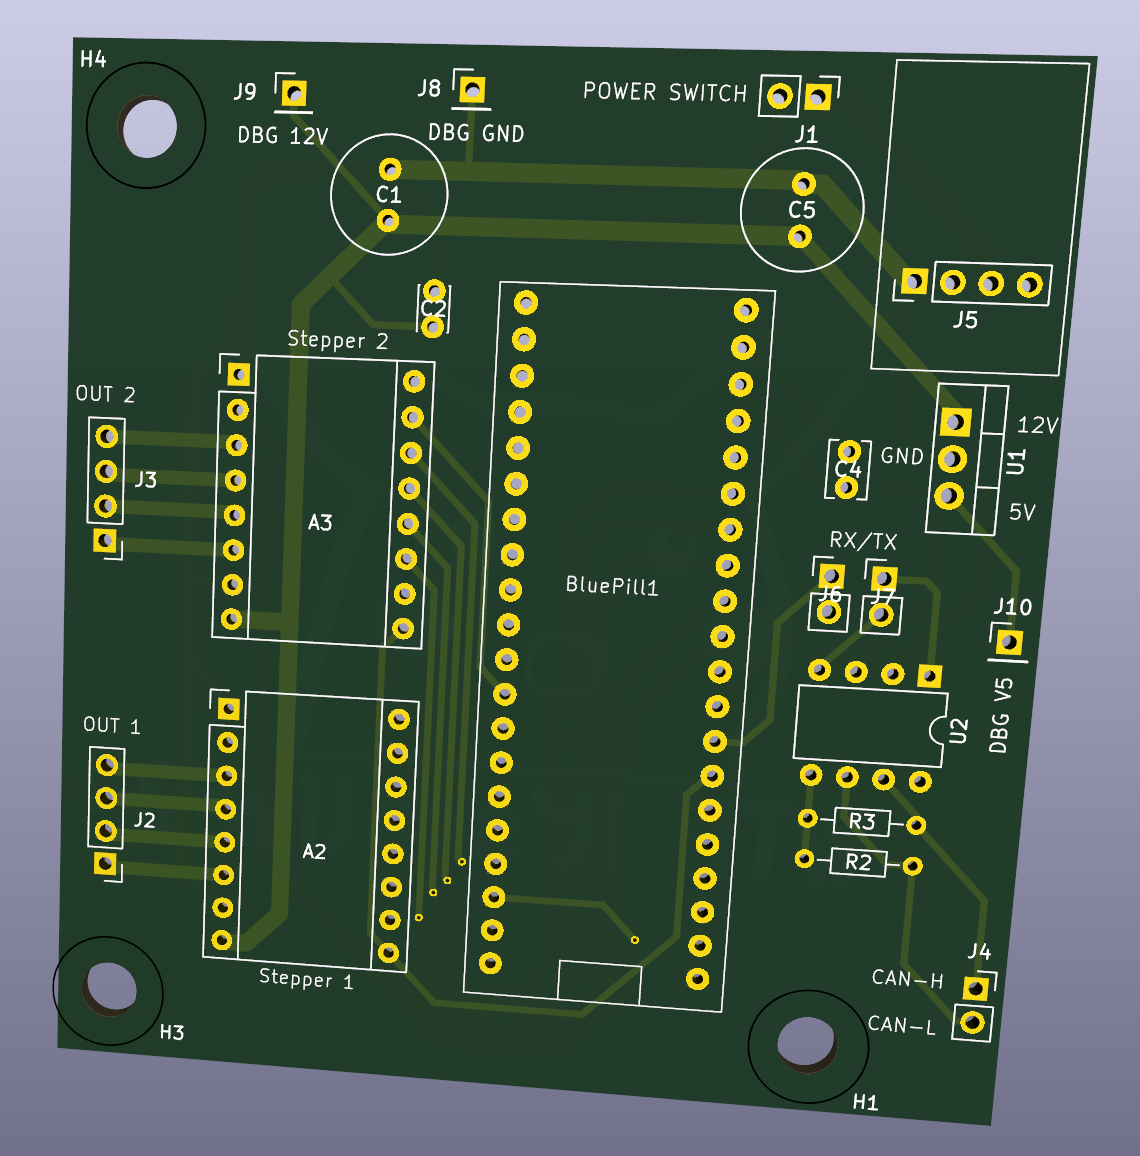
3D view to the board without and with modules
| Qty | Value | Footprint | References |
|---|---|---|---|
| 3 | MountingHole | MountingHole:MountingHole_4.3mm_M4 | H1, H3, H4 |
| 2 | 47 uF | Capacitor_THT:C_Radial_D8.0mm_H11.5mm_P3.50mm | C1, C5 |
| 2 | 60 | Resistor_THT:R_Axial_DIN0204_L3.6mm_D1.6mm_P7.62mm_Horizontal | R2, R3 |
| 2 | Conn_01x02_Pin | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J6, J7 |
| 2 | Pololu_Breakout_A4988 | Module:Pololu_Breakout-16_15.2x20.3mm | A2, A3 |
| 1 | 0.1uF | Capacitor_THT:C_Disc_D3.8mm_W2.6mm_P2.50mm | C4 |
| 1 | 100 nF | Capacitor_THT:C_Disc_D3.0mm_W2.0mm_P2.50mm | C2 |
| 1 | CAN-INPUT | Connector_PinSocket_2.54mm:PinSocket_1x02_P2.54mm_Vertical | J4 |
| 1 | DEBUG_12V | Connector_PinHeader_2.54mm:PinHeader_1x01_P2.54mm_Vertical | J9 |
| 1 | DEBUG_5V | Connector_PinHeader_2.54mm:PinHeader_1x01_P2.54mm_Vertical | J10 |
| 1 | DEBUG_GND | Connector_PinHeader_2.54mm:PinHeader_1x01_P2.54mm_Vertical | J8 |
| 1 | L7805 | Package_TO_SOT_THT:TO-220-3_Vertical | U1 |
| 1 | LOGO | Logo:pikachu_small_3 | G*** |
| 1 | MCP2551-I-P | Package_DIP:DIP-8_W7.62mm | U2 |
| 1 | MOTOR-1-OUTPUT | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J2 |
| 1 | MOTOR-2-OUTPUT | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J3 |
| 1 | POWER_INPUT | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J5 |
| 1 | PowerSwitch | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J1 |
| 1 | ~ | STM32_Bluepill:BluePill | BluePill1 |
Allen-Synthesis/EuroPi
EuroPi: A reprogrammable Eurorack module based on the Raspberry Pi Pico

peterheinrich/InternetOverSpaghetti
Transmitting IP packages over a pair of spaghetti thus demonstrating how media independent IP really is.


Tircown/ERCF-easy-brd
More informations on how to reset for flashing:\ https://wiki.seeedstudio.com/Seeeduino-XIAO/#enter-bootloader-mode

matthewcieplak/super-sixteen
Code and schematics for the Super Sixteen Eurorack sequencer

NikodemBartnik/Mini-Mars-Rover
Educational robotic platform made to look like a mini mars rover

starlightk7/OpenSFC
OSHW Reproduction Parts related to the Super Famicom / Super Nintendo game console

Redherring32/OpenTendo-TopLoader
An Open Source HardWare (OSHW) recreation of the 1993 toploading NES motherboard (Also known as NES-101)
It measures 70 × 75 mm and has 2 copper layers, 1.6 mm thick.
25 parts, built around the L7805. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the thekonon/WritingRobot repository on GitHub, at the commit this page was made from: the board is 02_HW/board/WritingRobotV2.kicad_pcb and its schematic 02_HW/board/WritingRobotV2.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask thekonon before reusing the design.