
2 layers80 × 80 mm
 teuler/hexpodling
"hexbotling" is a work-in-progress, 3-degrees of freedom (3DOF) hexapod robot based on the Vorpal from Vorpal Robotics.
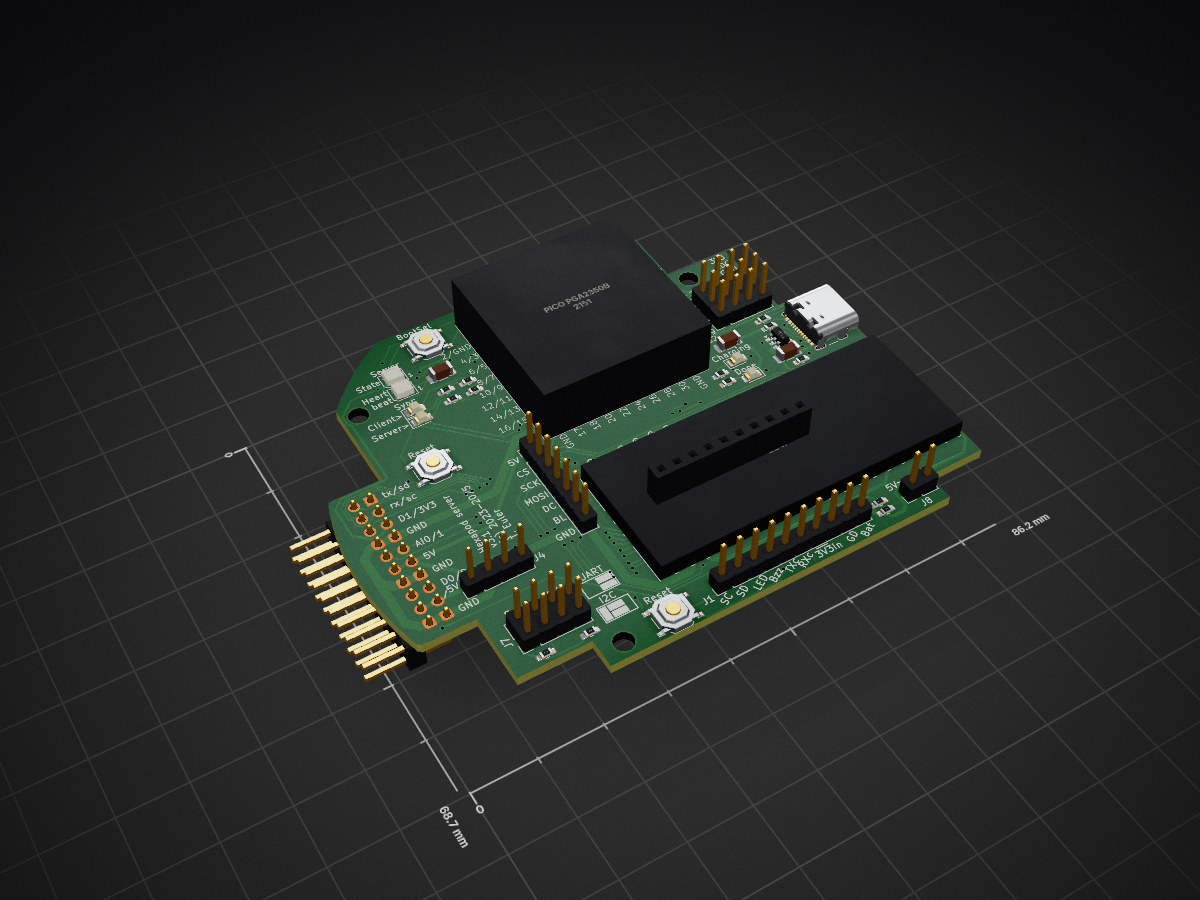
Hexapod2 cli is an open-source printed circuit board by teuler, from the teuler/hexpodling repository on GitHub. It is a 2-layer board of 86.2 × 68.7 mm with 43 parts on 125 nets, routed with 941 tracks and 99 vias.
It is built around the SK6805E-J. Its parts include 17 resistors, 10 connectors, 6 diodes, 3 capacitors and 3 ICs. It belongs with the robots and motor control boards and the RP2040 boards of this library.
 "hexpodling" is a work-in-progress, 3-degrees of freedom (3DOF) hexapod robot based on the Vorpal from Vorpal Robotics. The original Vorpal is remote-controlled and 2DOF; it is aimed at teaching in schools.
The main differences between the original and the version described here are:
Here is a video demonstrating its movements (remote-controlled).
For the details, see Wiki.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 7 | 1k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R3, R4, R7, R8, R9, R10, R17 |
| 3 | 10uF | Capacitor_SMD:C_1206_3216Metric_Pad1.33x1.80mm_HandSolder | C1, C2, C3 |
| 3 | LED green | LED_SMD:LED_0805_2012Metric_Pad1.15x1.40mm_HandSolder | D3, D4, D5 |
| 2 | 1.5k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R5, R6 |
| 2 | 4k7 | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R11, R12 |
| 2 | 5K1 | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R15, R16 |
| 2 | Conn_01x10_Pin | Connector_PinHeader_2.54mm:PinHeader_1x10_P2.54mm_Vertical | J1, J2 |
| 2 | Conn_02x04_Top_Bottom | Connector_PinHeader_2.54mm:PinHeader_2x04_P2.54mm_Vertical | J7, J9 |
| 2 | Reset | Button_Switch_SMD:SW_Push_1P1T_XKB_TS-1187A | SW2, SW3 |
| 2 | SK6805 | Library:LED_SK6805_PLCC4_2.4x2.7mm_P1.3mm_2427 | D1, D2 |
| 1 | 10k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R1 |
| 1 | 20k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R2 |
| 1 | 2K | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R18 |
| 1 | 470 | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R14 |
| 1 | BootSel | Button_Switch_SMD:SW_Push_1P1T_XKB_TS-1187A | SW1 |
| 1 | Conn_01x02 | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J8 |
| 1 | Conn_01x04 | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J10 |
| 1 | Conn_01x04_Pin | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J4 |
| 1 | Conn_01x07 | Connector_PinHeader_2.54mm:PinHeader_1x07_P2.54mm_Vertical | J5 |
| 1 | Conn_02x10_Odd_Even | Connector_PinHeader_2.54mm:PinHeader_2x10_P2.54mm_Horizontal | J3 |
| 1 | IRFTS2242PBF | Package_SO:TSOP-6_1.65x3.05mm_P0.95mm | Q1 |
| 1 | LED red | LED_SMD:LED_0805_2012Metric_Pad1.15x1.40mm_HandSolder | D6 |
| 1 | MCP73831-2-OT | Package_TO_SOT_SMD:SOT-23-5 | U2 |
| 1 | Pico | MCU_RaspberryPi_and_Boards:RPi_Pico_SMD_TH | U1 |
| 1 | Pico PGA2350B | Pimoroni:pga2350__pimoroni | U3 |
| 1 | USB_C_Receptacle_USB2.0_16P | Connector_USB:USB_C_Receptacle_GCT_USB4105-xx-A_16P_TopMnt_Horizontal | J6 |
It measures 86.2 × 68.7 mm and has 2 copper layers, 1.6 mm thick.
43 parts, built around the SK6805E-J. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the teuler/hexpodling repository on GitHub, at the commit this page was made from: the board is pcbs/hexpodling2_client_v3/hexapod2_cli/hexapod2_cli.kicad_pcb and its schematic pcbs/hexpodling2_client_v3/hexapod2_cli/hexapod2_cli.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask teuler before reusing the design.


DreaM117er/Paicorea
Paicorea is a 42 keys split keyboard, with optional way to drive Azoteq TPS43 trackpad.

fellettigiacomo/NeoHeart
Open Source ATtiny816-based heart shaped PCB with Addressable LEDs!


pierrebaillargeon/Microplate-Assistive-Pipetting-Light-Emitter
Microplate Assistive Pipetting Light Emitter (M.A.P.L.E.)