
2 layers178 × 145 mm
Ultra DB X51 v1
ExploreEmbedded/8051_DevelopmentBoard
Design files and sample code for 8051 development Ultra Boards
145 parts70
 SeAMKedu/sebot1
SeBot ROS2-ohjattu mobiilirobotti
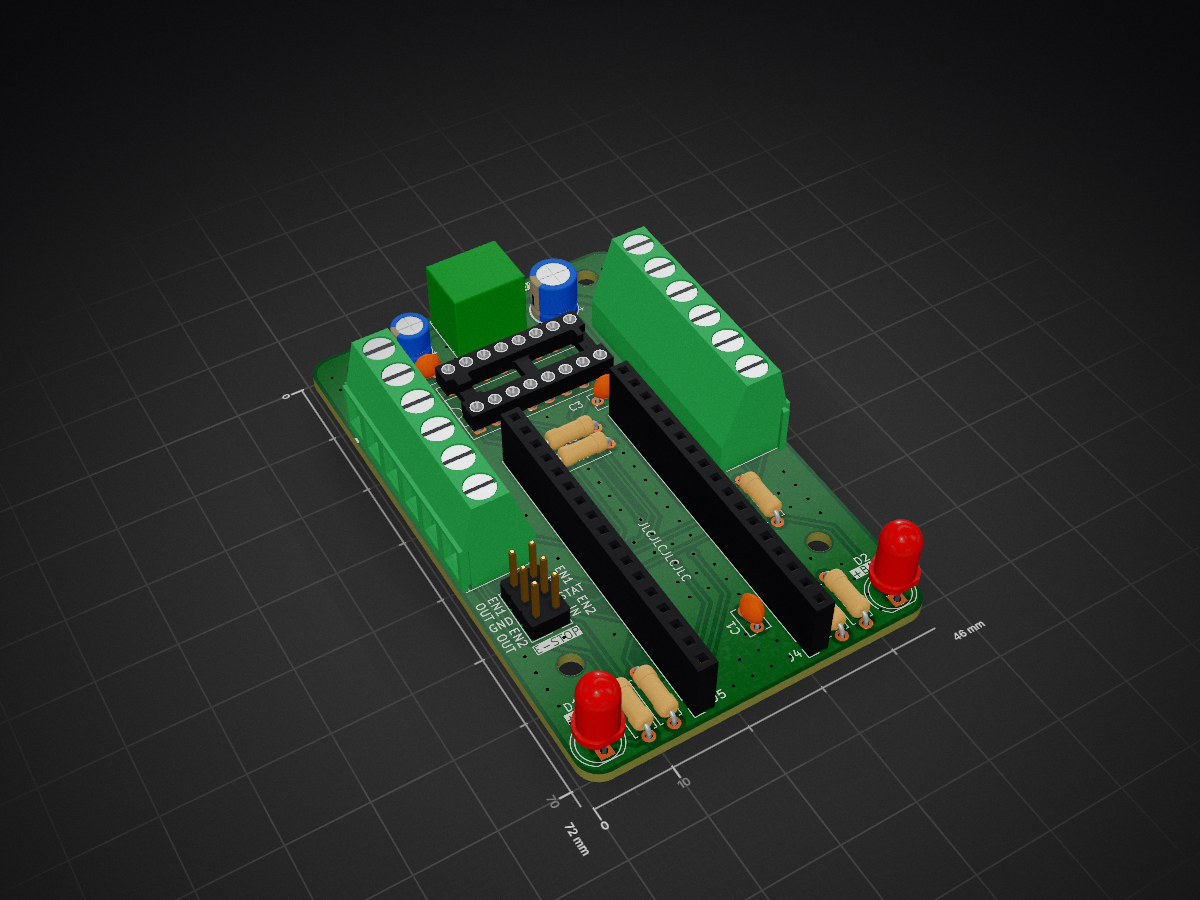
Sebot is an open-source printed circuit board by SeAMKedu, from the SeAMKedu/sebot repository on GitHub, published under the MIT licence. It is a 2-layer board of 46 × 72 mm with 26 parts on 43 nets, routed with 140 tracks and 132 vias.
It is built around the L293D. Its parts include 8 resistors, 6 connectors, 5 capacitors, 2 diodes and 1 IC.

SeBot-robotin ROS2 ohjelmointiohjeet 28.5.2025 OpenUGV-hankkeen ROS2 mobiilirobotti-työpajaan.
Varsinaiset ohjeet on kirjoitettu markdown-tiedostoihin. Niiden mukaiset valmiit koodit (ROS2, Arduino ja WWW) löydät repositorion code-kansiosta.
SeBotia varten on olemassa Rasberry Pi 5:lle sopiva image-tiedosto, jonka voi kirjoittaa MicroSD-muistikortille. Image sisältää valmiin ROS2 ympäristön ja muut tämän harjoituksen kannalta tarpeelliset muut tiedostot ja ohjelmat. Tiedosto on talletettu OpenUGV-hankkeen Teams-ryhmään (vaatii käyttöoikeuden SeAMK:lta). Mikäli sinulla ei ole käytössä tätä image-tiedostoa tai haluat tehdä harjoituksen jollain muulla koneella, voit hyvin asentaa ROS2-ympäristön itse apt install-komennolla Ubuntun pakettijakelun kautta. Ohje tähän löytyy Materiaali 0:sta.
Jos haluat tulostaa oman SeBot-pohjan, STP-malli ja PDF-mittakuva löytyy SeBot-kansiosta. Huomaa kuitenkin, että tämän harjoituksen kannalta pohjalevyn muoto on hyvin vapaa ja robotin voi rakentaa vaikkapa riittävän tukevaan muovirasiaan.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 4 | 10k | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R1, R6, R7, R8 |
| 4 | MountingHole | MountingHole:MountingHole_3mm | H1, H2, H3, H4 |
| 3 | 4k7 | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R2, R3, R5 |
| 2 | 100n | Capacitor_THT:C_Disc_D3.8mm_W2.6mm_P2.50mm | C2, C3 |
| 2 | Conn_01x17_Socket | Connector_PinSocket_2.54mm:PinSocket_1x17_P2.54mm_Vertical | J4, J5 |
| 2 | Screw_Terminal_01x06 | SeBot:TerminalBlock_Phoenix_MKDSN-1,5-6-5.08_1x06_P5.08mm_Horizontal | J1, J2 |
| 1 | 100u | Capacitor_THT:CP_Radial_D6.3mm_P2.50mm | C4 |
| 1 | 10u | Capacitor_THT:CP_Radial_D5.0mm_P2.00mm | C5 |
| 1 | 1k2 | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R4 |
| 1 | 33n | Capacitor_THT:C_Disc_D3.8mm_W2.6mm_P2.50mm | C1 |
| 1 | Conn_02x03_Counter_Clockwise | Connector_PinHeader_2.54mm:PinHeader_2x03_P2.54mm_Vertical | J6 |
| 1 | GREEN | LED_THT:LED_D5.0mm | D1 |
| 1 | L293D | Package_DIP:DIP-16_W7.62mm_Socket | U1 |
| 1 | Screw_Terminal_01x02 | SeBot:TerminalBlock_Phoenix_MKDSN-1,5-2-5.08_1x02_P5.08mm_Horizontal | J3 |
| 1 | YELLOW | LED_THT:LED_D5.0mm | D2 |
ExploreEmbedded/8051_DevelopmentBoard
Design files and sample code for 8051 development Ultra Boards

NikodemBartnik/Small-Projects
All of smaller projects (Arduino, PCBs, electronics, code)

geno543/Redropi_highway
the project aims to detect asteroids and meteor movement using high-quality cameras and radar detection methods using an AI model for accurate analysis, and it classifies bodies be in three categories: non-meteor…


harrislab-brown/DropGen
DropGen uses a fluid reservoir and a piezoelectric buzzer to precisely and repeatably dispense small droplets on demand.


It measures 46 × 72 mm and has 2 copper layers, 1.6 mm thick.
26 parts, built around the L293D. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the SeAMKedu/sebot repository on GitHub, at the commit this page was made from: the board is hardware/SeBot.kicad_pcb and its schematic hardware/SeBot.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).