2 layers247.5 × 71 mm
Chessboard pcb
EmilAAS/BlitzMate
This repository contains files regarding, BlitzMate, a self playing chessboard tailored towards blitz chess. The project is the basis for my masters thesis in mechanical engineering
29 parts
 RONITERVO/Automatic-Chessboard
The existing fabricated long PCB is functional and runs the photographed prototype after external wire and resistor modifications.
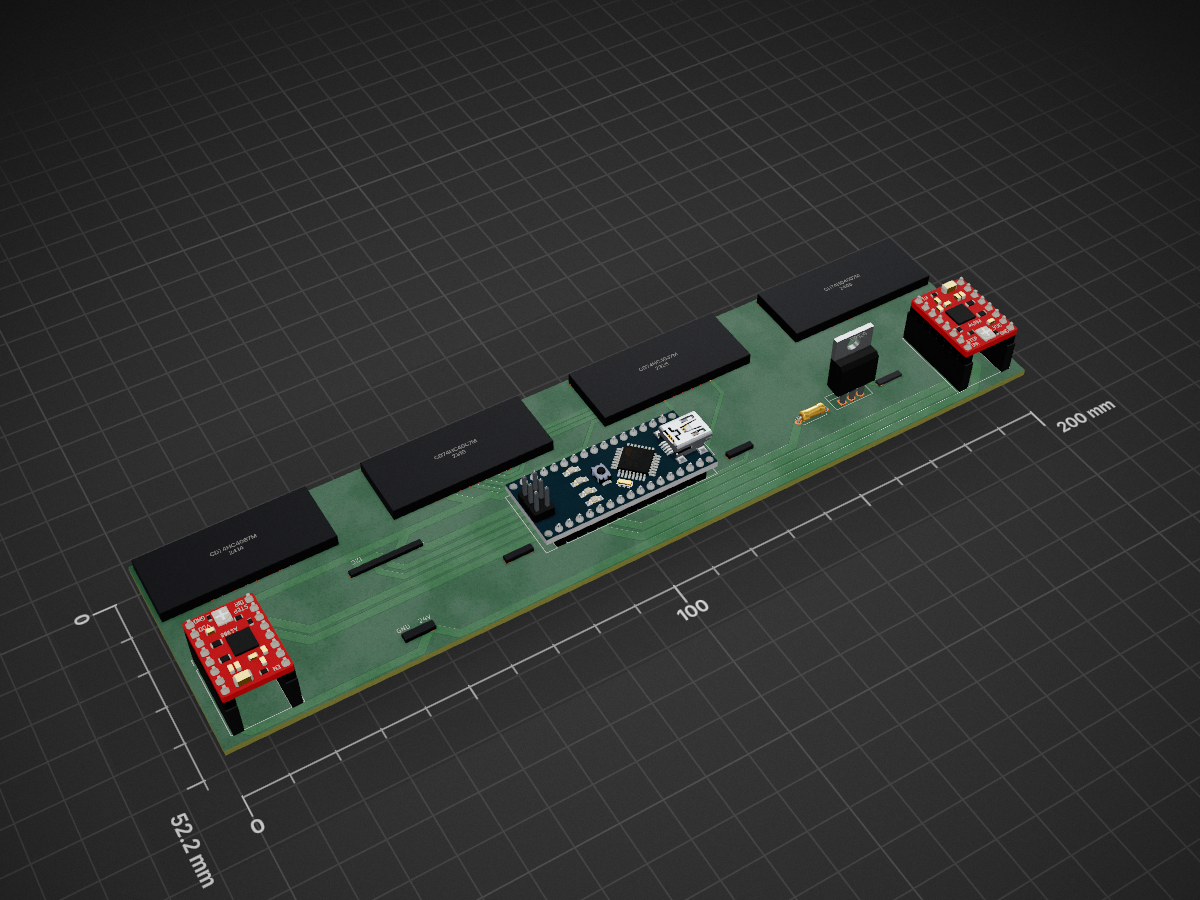
Automatic chessboard copy is an open-source printed circuit board by RONITERVO, from the RONITERVO/Automatic-Chessboard repository on GitHub. It is a 2-layer board of 200 × 52.2 mm with 14 parts on 115 nets, routed with 300 tracks and 0 vias.
It is built around the CD74HC4067M, A4988 and TIP120. Its parts include 5 ICs, 2 switches, 1 resistor, 1 transistor and 1 inductor.


The existing fabricated long PCB is functional and runs the photographed prototype after external wire and resistor modifications. Do not manufacture the archived PCB design unchanged and do not generate production Gerbers from it.
These KiCad files are preserved because their long component layout matches the physical working board and can help explain how the modules were arranged. They predate current firmware 4.6.0 wiring and are not the electrical source of truth or a verified fabrication release.
When reusing an already fabricated board, implement the complete
../../connections.csv contract. In particular:
TXD through 1 kohm to Nano D10;A6 and GND;A6 to 5 V;D1/TX through 1 kohm to HC-08 RXD, and add 2 kohm from that
divider node to GND; andDo not plug the second switch into the old D10 position: D10 is now the firmware's receive input for Bluetooth. Verify every modification by net name and meter continuity rather than copying wire colors from a photograph. The working-prototype page shows the physical board and its external rework.
Known limitations include:
RESET/SLEEP pair is not explicitly routed to 5 V;Use ../../WIRING.md, ../../connections.csv, and ../../sensor-map.csv for
the current build. The archive intentionally contains no Gerbers, drill files,
pick-and-place files, or fabrication ZIP. An existing board being operational
does not remove the need for the current public-build fuses, cutoff, polarity
protection, verified 5 V supply, and commissioning checks.
Files:
automatic_chessboard_copy.kicad_pcb: long board layout matching the
photographed controller form.automatic_chessboard_copy.kicad_pro: historical KiCad project settings.reference-schematic.kicad_sch: related historical circuit drawing; layout
and present-day wiring do not fully match it.| Qty | Value | Footprint | References |
|---|---|---|---|
| 4 | CD74HC4067M | multiplexer:multiplexer | U1, U2, U3, U4 |
| 2 | A4988 | Module:Pololu_Breakout-16_15.2x20.3mm | A2, A3 |
| 2 | SW_Push | buttons:button_pins | SW1, SW2 |
| 1 | 1k | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R1 |
| 1 | Arduino Nano | Module:Arduino_Nano | A1 |
| 1 | L | magnet_pins:electromagnet_pins | L1 |
| 1 | TIP120 | Package_TO_SOT_THT:TO-220-3_Vertical | Q1 |
| 1 | ~ | Powersupply:Power | U6 |
| 1 | ~ | I2C display:i2c display | I2C |
It measures 200 × 52.2 mm and has 2 copper layers, 1.6 mm thick.
14 parts, built around the CD74HC4067M, A4988 and TIP120. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the RONITERVO/Automatic-Chessboard repository on GitHub, at the commit this page was made from: the board is hardware/reference/legacy-controller/automatic_chessboard_copy.kicad_pcb and its schematic hardware/reference/legacy-controller/reference-schematic.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask RONITERVO before reusing the design.
EmilAAS/BlitzMate
This repository contains files regarding, BlitzMate, a self playing chessboard tailored towards blitz chess. The project is the basis for my masters thesis in mechanical engineering


grinje/AutoSatTracker
Tracking satellites with custom hardware based on stepper motors

phorton1/Arduino-cnc-cnc3018
A FluidNC based implementation of a controller for a cheap cnc3028 machine


kairobyte/bipedal_self_balance
A bipedal self balancing robot with 2DOF in each leg. Built from scratch.


m24h/espcnc
A 3D printer/CNC controller using ESP32 with its DMA/FIFO bufferd I2S port