2 layers56 × 65 mm
BPC PRP rpi hat
Robotics-BUT/fenrir-project
https://robotics-but.github.io/fenrir-project/
46 parts1MIT

 Robotics-BUT/fenrir-project1
https://robotics-but.github.io/fenrir-project/
BPC PRP microcontroller is an open-source printed circuit board by Robotics-BUT, from the Robotics-BUT/fenrir-project repository on GitHub, published under the MIT licence. It is a 2-layer board of 40 × 100 mm with 27 parts on 33 nets, routed with 213 tracks and 15 vias.
Its parts include 12 connectors, 6 resistors and 4 diodes. It belongs with the robots and motor control boards and the AVR (ATmega, ATtiny) boards of this library.
The Fenrir Project is an open source of a multi purpose education robot dedicated for wide range of applications and usage in high-schools and universities.
The robot is based on Raspberry Pi 4 and Arduino Nano. The Raspberry Pi provides computational power, ROS2 support, WiFi connection and USB support. The Arduino Nano extends the PRi IOs and handles peripherals.
The development is currently still under development
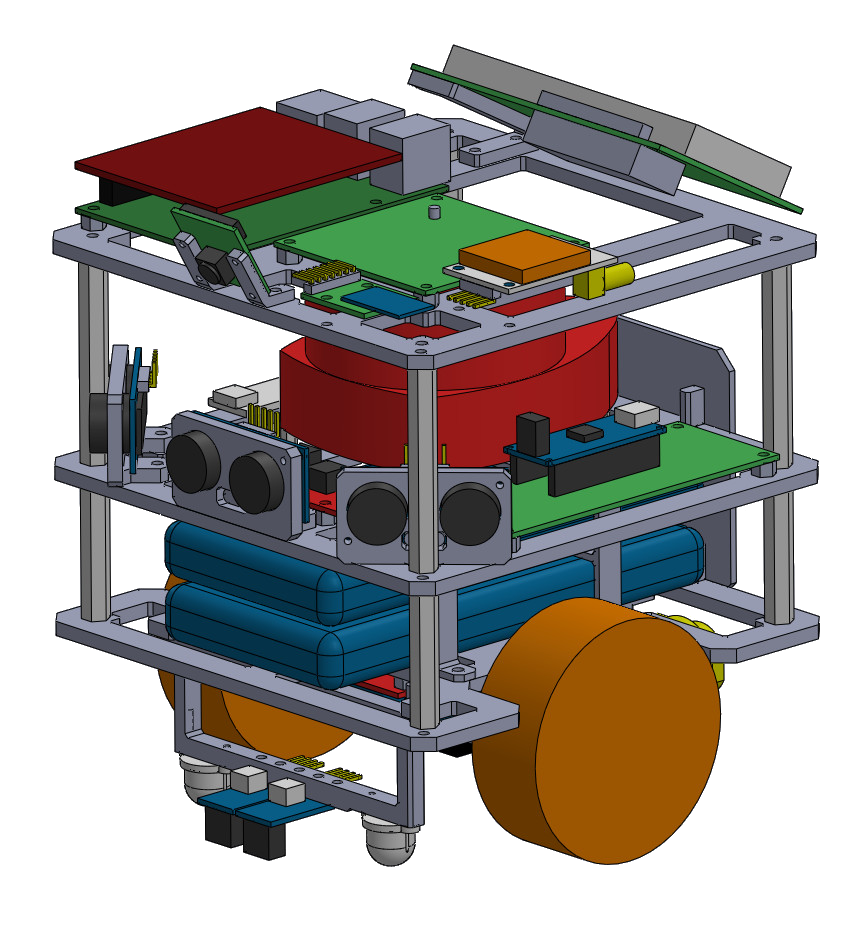
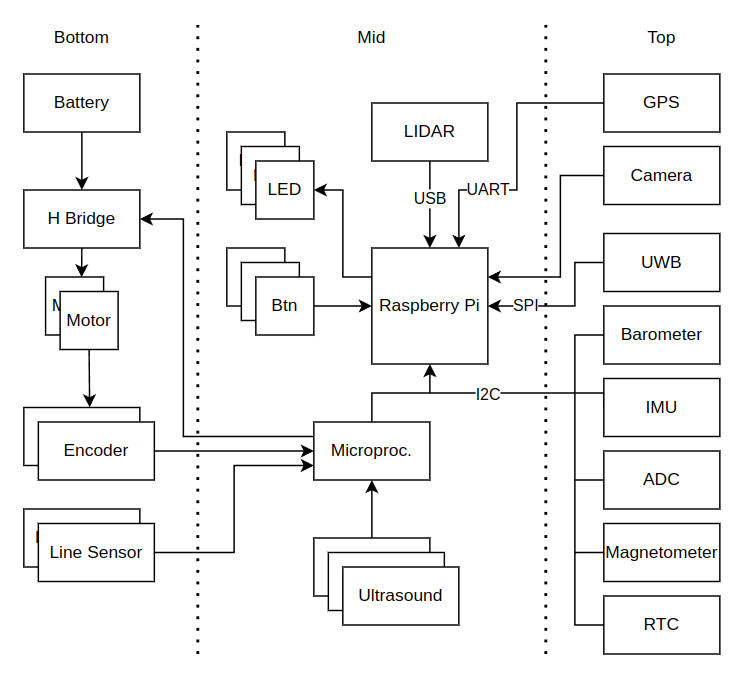
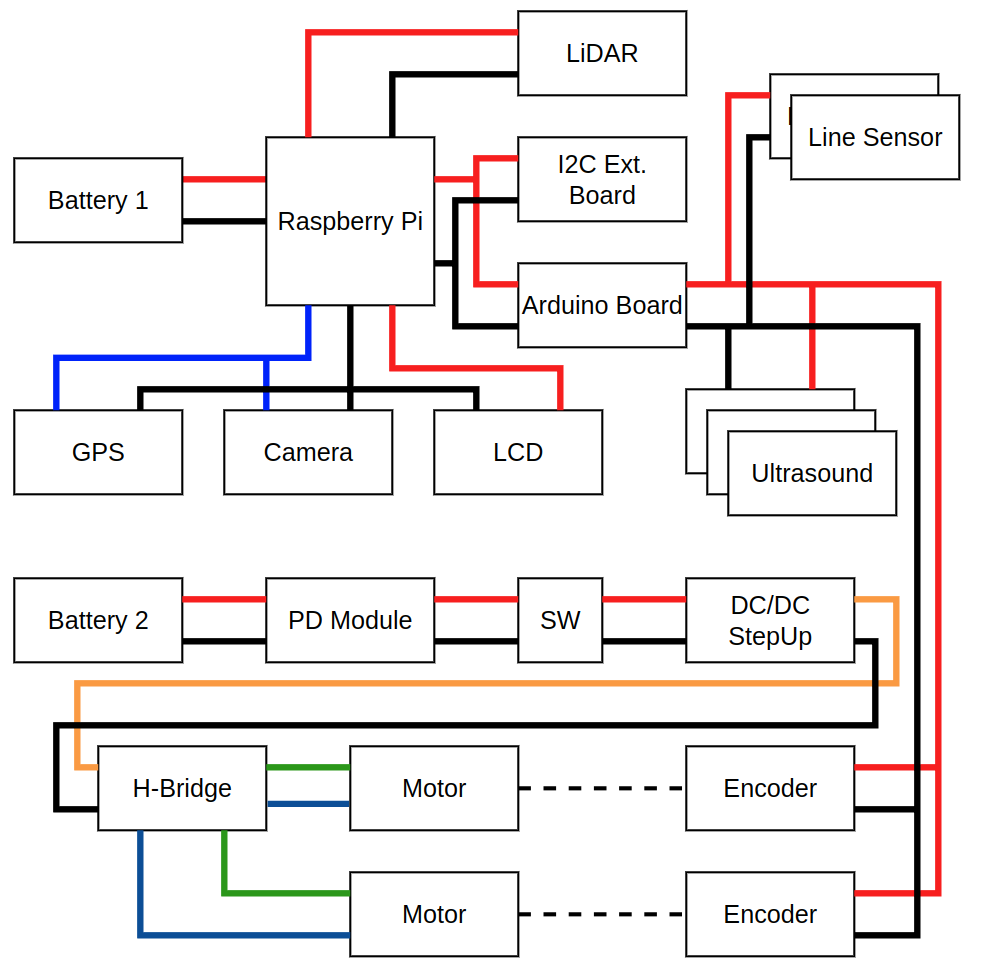
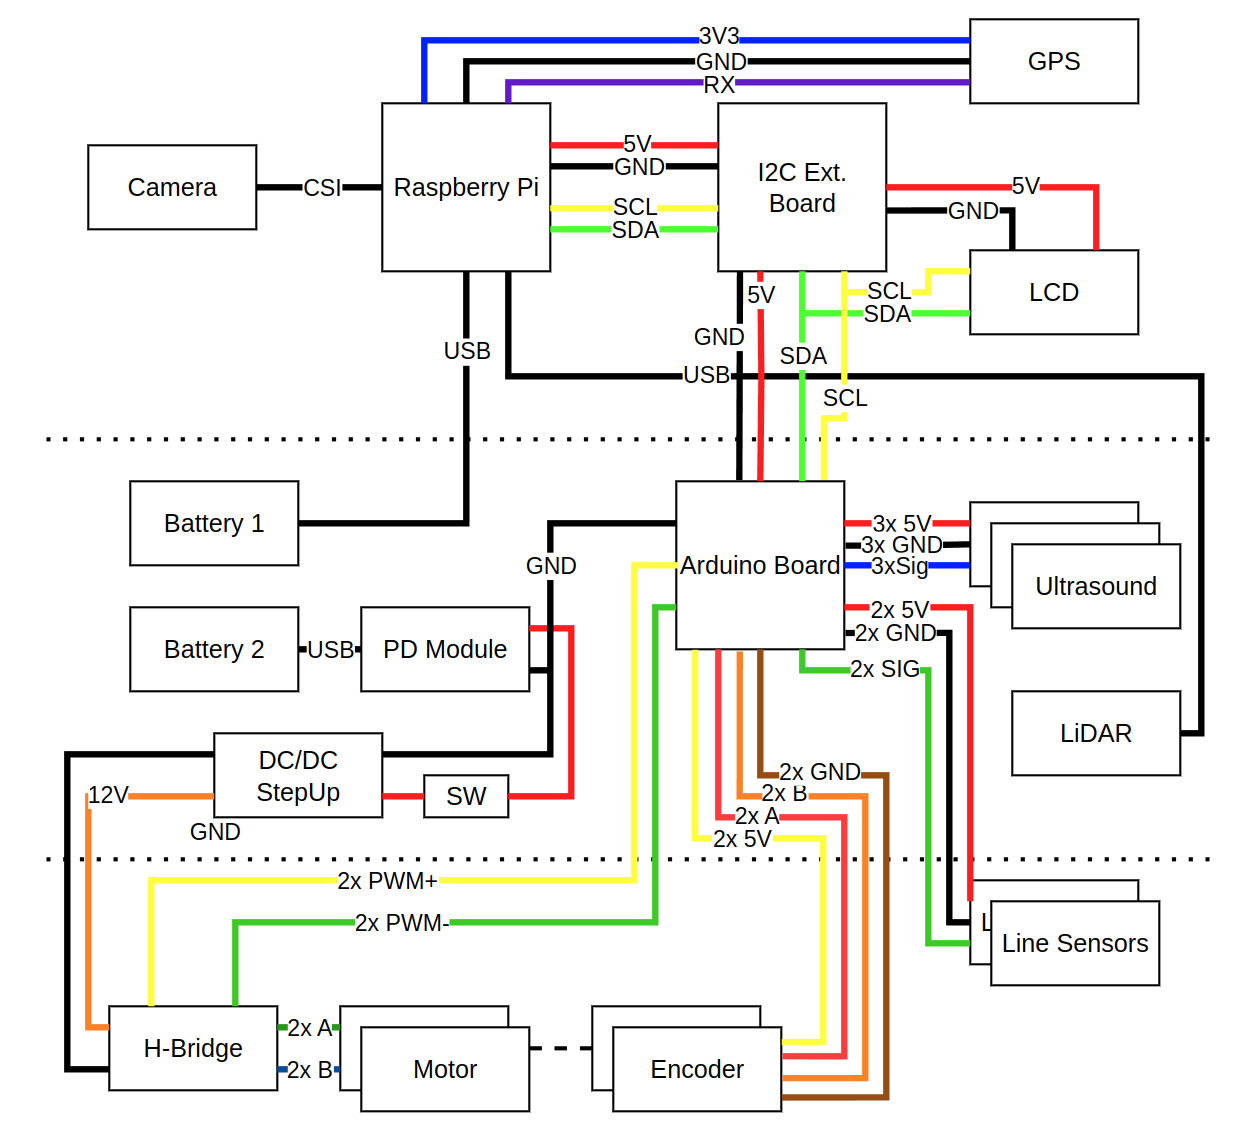
Note: The sensors numbering goes from left to right
| Module A | Pin | Module B | Pin | Type | Length | Note |
|---|---|---|---|---|---|---|
| Battery 1 | - | PD Module | - | USB-C - USB-C | 15cm | - |
| Battery 2 | - | Raspberry Pi | - | USB-C - USB-C | 15cm | - |
| Raspberry Pi | - | Camera | - | CSI Cable | 10cm | - |
| Raspberry Pi | 3v3 | GPS | VCC | wire (blue) | 10cm | 3V3 |
| Raspberry Pi | GND | GPS | GND | wire (black) | 10cm | GND |
| Raspberry Pi | Rx | GPS | TxD | wire (purple) | 10cm | UART |
| Raspberry Pi | 5V | I2C Board | 5V | wire (red) | 8cm | 5V |
| Raspberry Pi | GND | I2C Board | GND | wire (black) | 8cm | GND |
| Raspberry Pi | SCL | I2C Board | SCL | wire (yellow) | 8cm | SCL |
| Raspberry Pi | SDA | I2C Board | SDA | wire (green) | 8cm | SDA |
| Raspberry Pi | - | LIDAR | - | USB-A - microUSB | 10cm | - |
| I2C Board | 5V | LCD | VCC | wire (red) | 8cm | 5V |
| I2C Board | GND | LCD | GND | wire (black) | 8cm | GND |
| I2C Board | SCL | LCD | SCL | wire (yellow) | 8cm | SCL |
| I2C Board | SDA | LCD | SDA | wire (green) | 8cm | SDA |
| I2C Board | 5V | Arduino | VCC | wire (red) | 15cm | 5V |
| I2C Board | GND | Arduino | GND | wire (black) | 15cm | GND |
| I2C Board | SCL | Arduino | SCL | wire (yellow) | 15cm | SCL |
| I2C Board | SDA | Arduino | SDA | wire (green) | 15cm | SDA |
| Arduino | US1 | Ultrasound 1 | Vcc | wire (red) | 10cm | 5V |
| Arduino | US1 | Ultrasound 1 | GND | wire (black) | 10cm | GND |
| Arduino | US1 | Ultrasound 1 | Echo/Trig | wire (blue) | 10cm | signal |
| Arduino | US2 | Ultrasound 2 | Vcc | wire (red) | 10cm | 5V |
| Arduino | US2 | Ultrasound 2 | GND | wire (black) | 10cm | GND |
| Arduino | US2 | Ultrasound 2 | Echo/Trig | wire (blue) | 10cm | signal |
| Arduino | US3 | Ultrasound 3 | Vcc | wire (red) | 15cm | 5V |
| Arduino | US3 | Ultrasound 3 | GND | wire (black) | 15cm | GND |
| Arduino | US3 | Ultrasound 3 | Echo/Trig | wire (blue) | 15cm | signal |
| Arduino | Line1 | Line Sens. 1 | VCC | wire (red) | 15cm | 5V |
| Arduino | Line1 | Line Sens. 1 | GND | wire (black) | 15cm | GND |
| Arduino | Line1 | Line Sens. 1 | A0 | wire (blue) | 15cm | signal |
| Arduino | Line2 | Line Sens. 2 | VCC | wire (red) | 15cm | 5V |
| Arduino | Line2 | Line Sens. 2 | GND | wire (black) | 15cm | GND |
| Arduino | Line2 | Line Sens. 2 | A0 | wire (blue) | 15cm | signal |
| Arduino | 5V | Encoder 1 | - | wire (yellow) | 20cm | 5V |
| Arduino | GND | Encoder 1 | - | wire (brown) | 20cm | GND |
| Arduino | EN1A | Encoder 1 | - | wire (red) | 20cm | A |
| Arduino | EN1B | Encoder 1 | - | wire (orange) | 20cm | B |
| Arduino | 5V | Encoder 2 | - | wire (yellow) | 20cm | 5V |
| Arduino | GND | Encoder 2 | - | wire (brown) | 20cm | GND |
| Arduino | EN2A | Encoder 2 | - | wire (red) | 20cm | A |
| Arduino | EN2B | Encoder 2 | - | wire (orange) | 20cm | B |
| Arduino | GND | PD Module | OUT- | wire (black) | - | - |
| Arduino | M1A | H-Bridge | IN3 | wire (yellow) | 20cm | PWM A+ |
| Arduino | M1B | H-Bridge | IN4 | wire (green) | 20cm | PWM A- |
| Arduino | M2A | H-Bridge | IN1 | wire (yellow) | 20cm | PWM B+ |
| Arduino | M2B | H-Bridge | IN2 | wire (green) | 20cm | PWM B- |
| PD Module | + | H-Bridge | +12V | wire (orange) | 15cm | 12V |
| PD Module | - | H-Bridge | GND | wire (black) | 15cm | GND |
| H-Bridge | OUT1+ | Motor 1 | - | wire (green) | 20cm | + |
| H-Bridge | OUT1- | Motor 1 | - | wire (blue) | 20cm | - |
| H-Bridge | OUT2+ | Motor 2 | - | wire (green) | 20cm | + |
| H-Bridge | OUT2- | Motor 2 | - | wire (blue) | 20cm | - |
| Role | Component | URL |
|---|---|---|
| Main Computer | RPi | link |
| Helper Microcontroller | Arduino Nano | link |
| 2x Battery | Powerbank 10000 mAh | link |
| Camera | RPi Camera v2 | link |
| GPS | NEO-7M module | link |
| 2D LiDAR | RPLiDAR A1M8 | link |
| LCD | HD44780 20x4 I2C | link |
| 3x Ultrasound | SRF-05 | link |
| 2x Line Sensor | TCRT5000 module | link |
| H Bridge | L298N module | link |
| Motor with Encoder | DG01D‐E | link |
| IMU | MPU6050 | link |
| Barometer | BME280 | link |
| Real Time Clock | DS3231 | link |
| ADC | ADS1115 | link |
| UWB (not yet) | DWM1000 | link |
| DC/DC Step Up | XL6009 | link |
| Power Delivery | USB-C PD module | link |
| Switch | link |
This work was created with the support of project RP182401001 under the PPSŘ 2025 program.
Adam Ligocki - adam.ligocki@vut.cz
Petr Šopák - petr.sopak@vut.cz
Jakum Minařík
| Qty | Value | Footprint | References |
|---|---|---|---|
| 6 | 10k | Resistor_SMD:R_1206_3216Metric | R1, R2, R3, R4, R5, R6 |
| 4 | MountingHole | MountingHole:MountingHole_3.2mm_M3 | H1, H2, H3, H4 |
| 4 | ~ | LED_SMD:LED_1206_3216Metric | LED1, LED2, LED3, LED4 |
| 1 | 5V | TerminalBlock_TE-Connectivity:TerminalBlock_TE_282834-4_1x04_P2.54mm_Horizontal | J11 |
| 1 | Arduino_Nano_Every | arduino-library:Arduino_Nano_Every_Socket | A1 |
| 1 | Curr_probe | TerminalBlock_TE-Connectivity:TerminalBlock_TE_282834-3_1x03_P2.54mm_Horizontal | J10 |
| 1 | Encoder_1 | TerminalBlock_TE-Connectivity:TerminalBlock_TE_282834-4_1x04_P2.54mm_Horizontal | J8 |
| 1 | Encoder_2 | TerminalBlock_TE-Connectivity:TerminalBlock_TE_282834-4_1x04_P2.54mm_Horizontal | J9 |
| 1 | Gnd | TerminalBlock_TE-Connectivity:TerminalBlock_TE_282834-4_1x04_P2.54mm_Horizontal | J12 |
| 1 | I2C | TerminalBlock_TE-Connectivity:TerminalBlock_TE_282834-2_1x02_P2.54mm_Horizontal | J13 |
| 1 | Line_1 | TerminalBlock_TE-Connectivity:TerminalBlock_TE_282834-3_1x03_P2.54mm_Horizontal | J4 |
| 1 | Line_2 | TerminalBlock_TE-Connectivity:TerminalBlock_TE_282834-3_1x03_P2.54mm_Horizontal | J5 |
| 1 | Motor_driver_1 | TerminalBlock_TE-Connectivity:TerminalBlock_TE_282834-6_1x06_P2.54mm_Horizontal | J6 |
| 1 | Us_1 | TerminalBlock_TE-Connectivity:TerminalBlock_TE_282834-3_1x03_P2.54mm_Horizontal | J1 |
| 1 | Us_2 | TerminalBlock_TE-Connectivity:TerminalBlock_TE_282834-3_1x03_P2.54mm_Horizontal | J2 |
| 1 | Us_3 | TerminalBlock_TE-Connectivity:TerminalBlock_TE_282834-3_1x03_P2.54mm_Horizontal | J3 |
Robotics-BUT/fenrir-project
https://robotics-but.github.io/fenrir-project/

Robotics-BUT/fenrir-project
https://robotics-but.github.io/fenrir-project/


hackclub/OnBoard
💡 Join 1,000 teenagers and make your first PCB with a $100 grant!


CRImier/MyKiCad
My KiCad boards. Can't be bothered uploading individually anymore, so here you go.

pjgpetecodes/pico-streamdeck
This project is an OBS Controller using a Raspberry Pi Pico and CircuitPython.

freeDSP/freeDSP-aurora
freeDSP ADAU1452 with 8 analog input, 8 analog outputs, S/P-DIF I/O, ADAT I/O, USB Audio Class2, WiFi, Bluetooth

ugcs/ddc
Drone Show Software is software designed for drone shows, allowing flight path planning as well as control of dozens of drones simultaneously in a synchronized manner.
It measures 40 × 100 mm and has 2 copper layers, 1.6 mm thick.
27 parts. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the Robotics-BUT/fenrir-project repository on GitHub, at the commit this page was made from: the board is pcbs/microcontroller_board/BPC-PRP-microcontroller.kicad_pcb and its schematic pcbs/i2c_board/BPC-PRP-i2c-board.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).