2 layers115 × 115 mm

 rmingon/drone-vision
Drone uses machine vision to stabilize itself
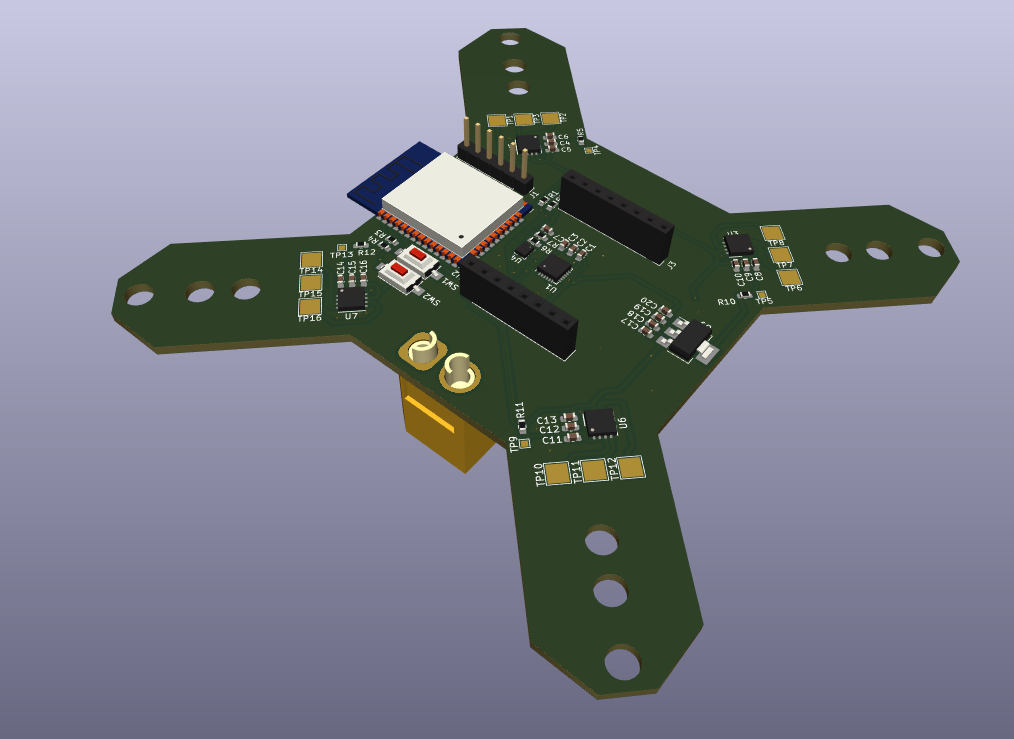
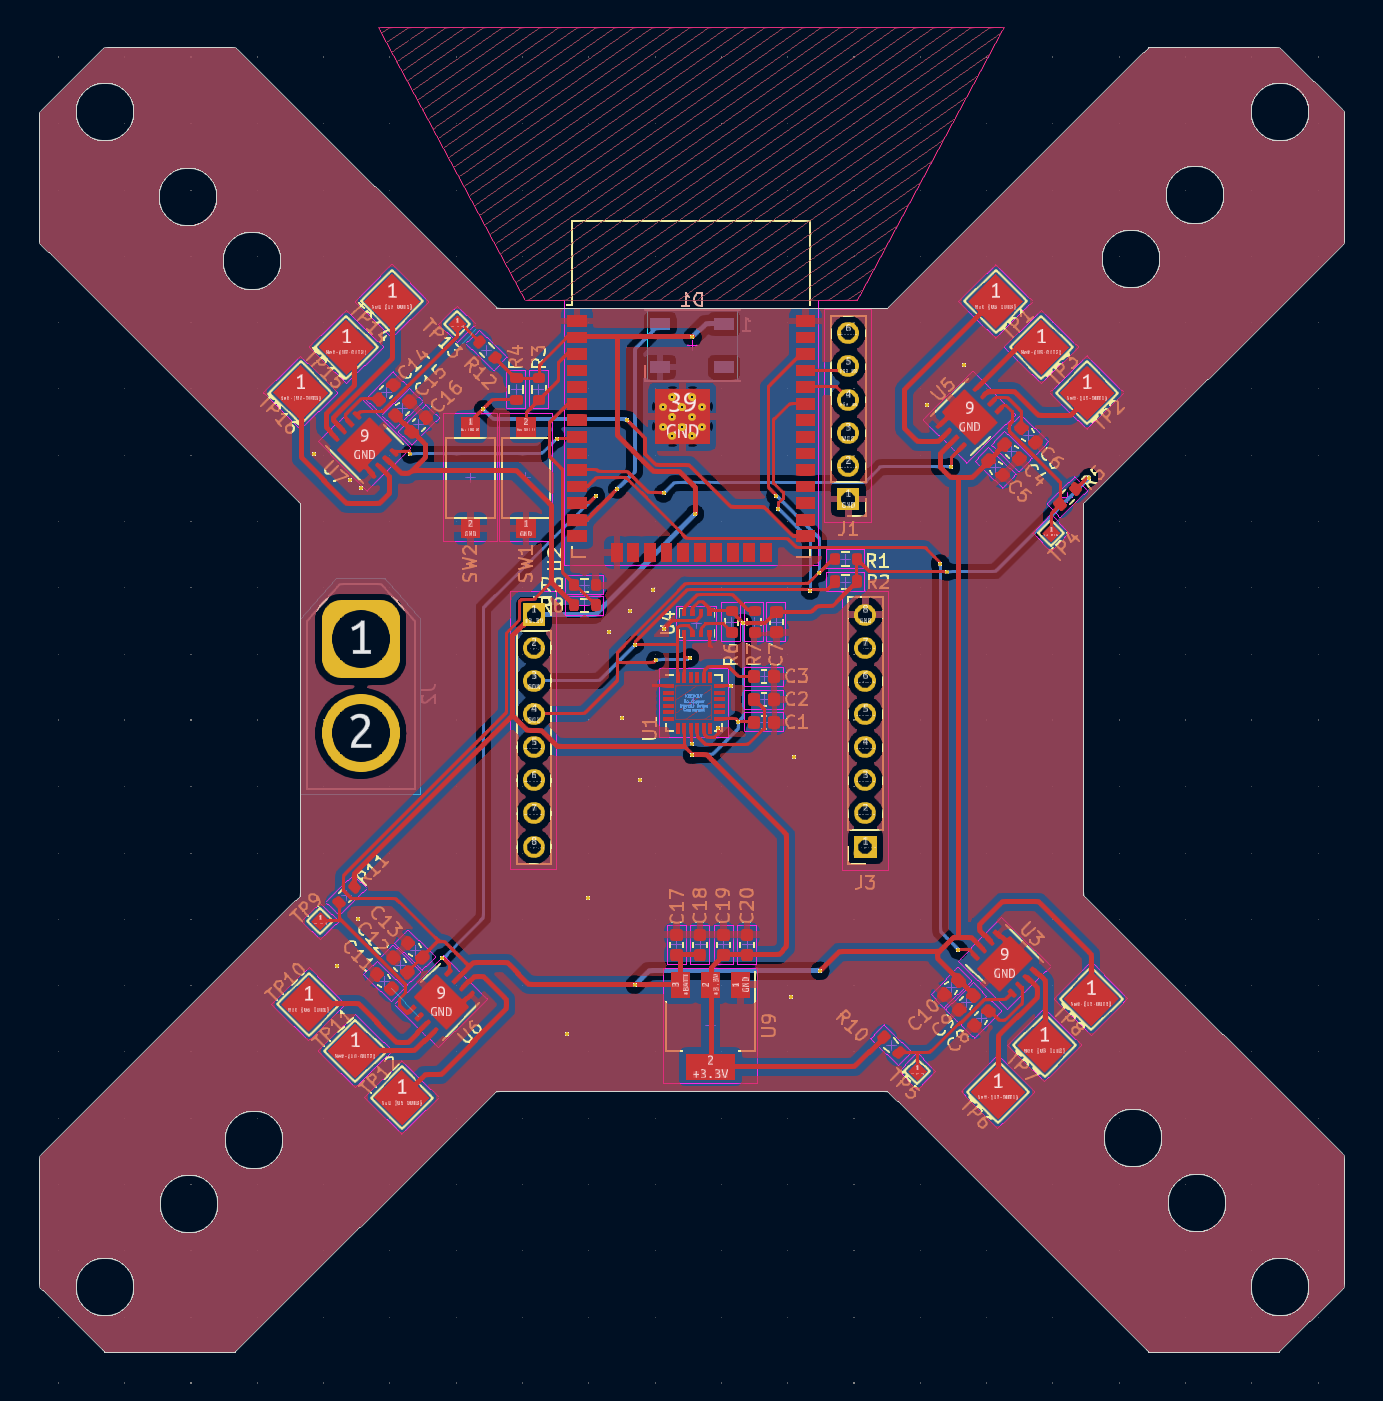
Drone is an open-source printed circuit board by rmingon, from the rmingon/drone-vision repository on GitHub. It is a 2-layer board of 100 × 100 mm with 61 parts on 80 nets, routed with 475 tracks and 106 vias.
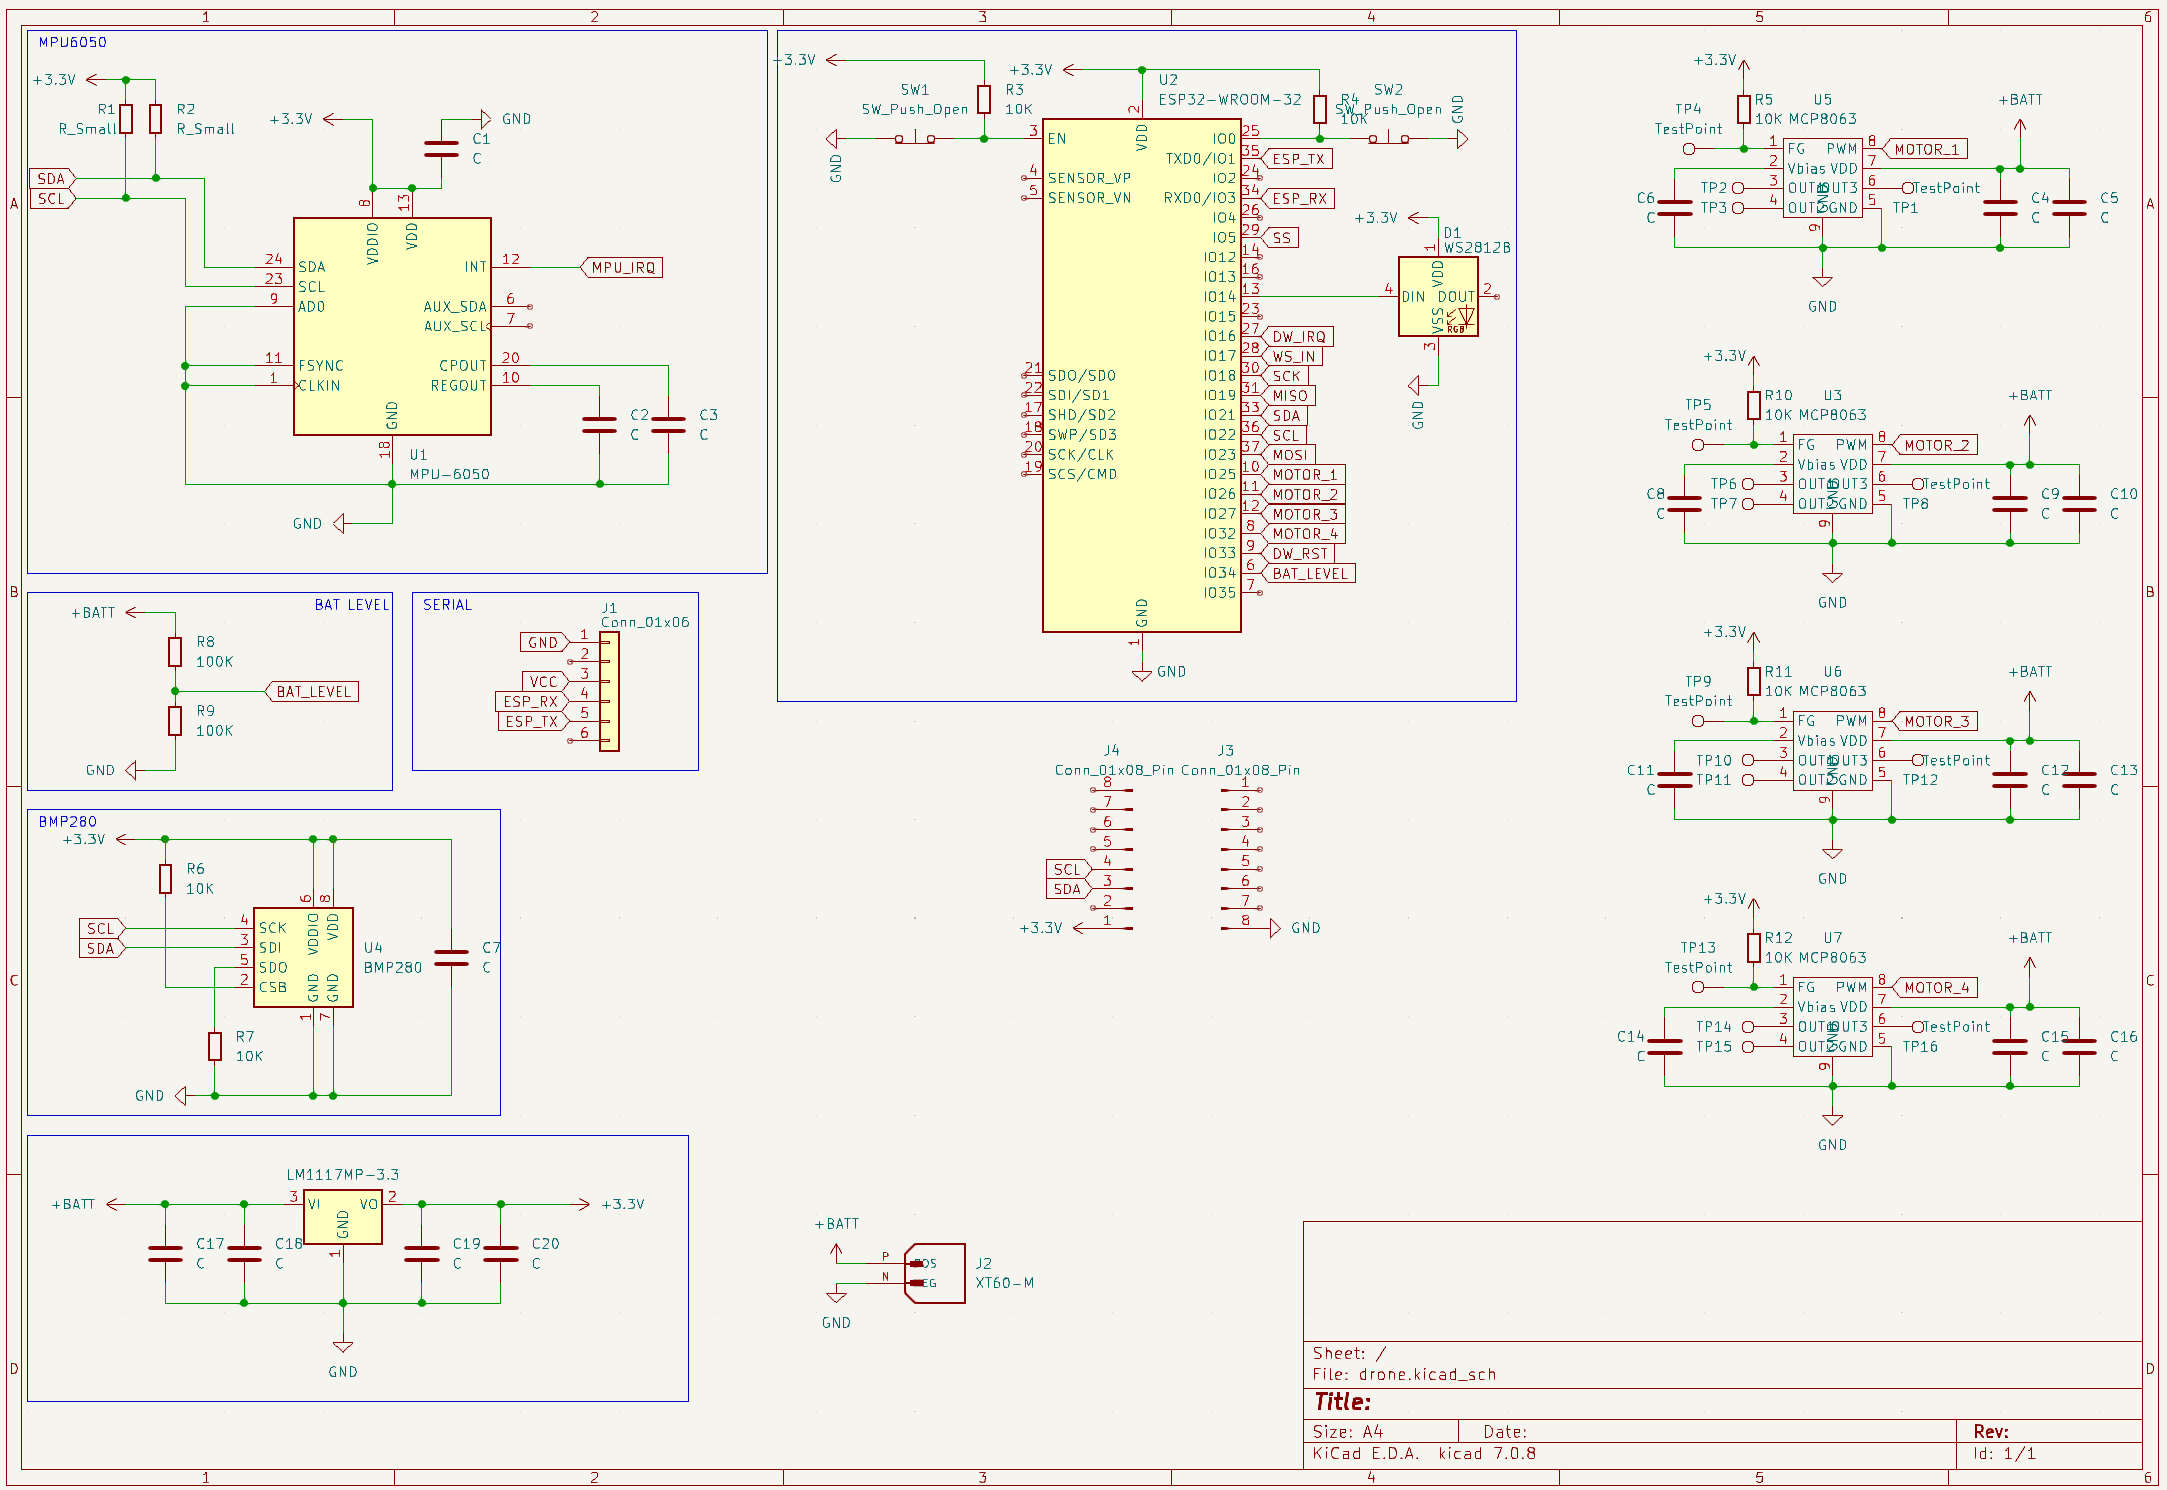
It is built around the ESP32-WROOM-32, MCP8063-E/MD and BMP280, with the LM1117MP-3.3, MPU-9250 and WS2812B among its other parts. Its parts include 20 capacitors, 10 resistors, 8 ICs, 4 connectors and 2 switches. It belongs with the robots and motor control boards and the ESP32 boards of this library.


| Qty | Value | Footprint | References |
|---|---|---|---|
| 20 | C | Capacitor_SMD:C_0603_1608Metric | C4, C5, C10, C11, C12, C13, C14, C15, C16, C17, C18, C19, C20, C21, C22, C23 +4 |
| 12 | TestPoint | TestPoint:TestPoint_Pad_3.0x3.0mm | TP1, TP2, TP3, TP6, TP7, TP8, TP10, TP11, TP12, TP14, TP15, TP16 |
| 8 | 10K | Resistor_SMD:R_0603_1608Metric | R3, R4, R5, R6, R7, R10, R11, R12 |
| 4 | MCP8063 | Package_DFN_QFN:DFN-8-1EP_4x4mm_P0.8mm_EP2.5x3.6mm | U3, U5, U6, U7 |
| 4 | TestPoint | TestPoint:TestPoint_Pad_1.0x1.0mm | TP4, TP5, TP9, TP13 |
| 2 | 100K | Resistor_SMD:R_0603_1608Metric | R8, R9 |
| 2 | Conn_01x08_Pin | Connector_PinSocket_2.54mm:PinSocket_1x08_P2.54mm_Vertical | J3, J4 |
| 2 | SW_Push_Open | Button_Switch_SMD:SW_SPST_CK_RS282G05A3 | SW1, SW2 |
| 1 | BMP280 | Package_LGA:Bosch_LGA-8_2x2.5mm_P0.65mm_ClockwisePinNumbering | U4 |
| 1 | Conn_01x06 | Connector_PinHeader_2.54mm:PinHeader_1x06_P2.54mm_Vertical | J1 |
| 1 | ESP32-WROOM-32 | RF_Module:ESP32-WROOM-32 | U2 |
| 1 | LM1117MP-3.3 | Package_TO_SOT_SMD:SOT-223-3_TabPin2 | U9 |
| 1 | MPU-9250 | Sensor_Motion:InvenSense_QFN-24_3x3mm_P0.4mm | U8 |
| 1 | WS2812B | LED_SMD:LED_WS2812B_PLCC4_5.0x5.0mm_P3.2mm | D1 |
| 1 | XT30PW-M | Connector_AMASS:AMASS_XT30U-F_1x02_P5.0mm_Vertical | J2 |


embeddedalpha/IMU_V100
Inertial Measurement Unit based around STM32F407VGT6. This is a product development repo.


arnaumora/TFG-Plataforma-Instrumentacion-Avionica
An ESP32-S3 sensor unit, built on a custom KiCad-designed PCB, estimates aircraft attitude, heading, altitude and vertical speed in real time and streams them over a 2.4 GHz RF link to a Primary Flight Display (PFD)…

ikajdan/rc-helicopter-mainboard
RC helicopter mainboard based on an STM32 MCU

It measures 100 × 100 mm and has 2 copper layers, 1.6 mm thick.
61 parts, built around the ESP32-WROOM-32, MCP8063-E/MD, BMP280 and LM1117MP-3.3. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the rmingon/drone-vision repository on GitHub, at the commit this page was made from: the board is drone/drone/drone.kicad_pcb and its schematic drone/drone/drone.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask rmingon before reusing the design.