4 layers100 × 40 mm

 reubenstr/zuko51
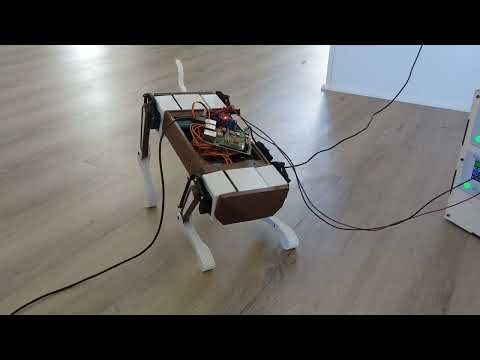
A quadruped robot dog!
Expansion board is an open-source printed circuit board by reubenstr, from the reubenstr/zuko repository on GitHub, published under the MIT licence. It is a 4-layer board of 100 × 49.8 mm with 75 parts on 85 nets, routed with 883 tracks and 130 vias.
It is built around the ADS1115IDGS, LM2596S-5.0 and PCA9635PW, with the 24LC256-I/P, ULN2003 and BSS138 among its other parts. Its parts include 19 resistors, 15 connectors, 12 ICs, 10 capacitors and 2 diodes. It belongs with the robots and motor control boards of this library.


 |
|---|
| Frame v2.2 CAD design. |
 |
|---|
| Zuko himself! |
 |
|---|
| Frame v2.1 parts printed. |
 |
|---|
| Expansion board v1 for direct RPi inteface. |
 |
|---|
| Frame v2.1 first time standing. |
 |
|---|
| Frame v2.1 upper leg's servo horn, linked leg bridge, and bridge bearing press fit together. |
 |
|---|
| Video: frame v2.1 first tests |
 |
|---|
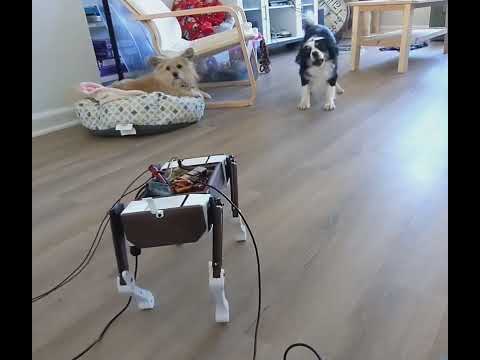
| Video: Sydney meets Zuko |
Development.
V2.2 Frame is being tested and is nearly ready for replication
Zuko uses the ROS2 framework for communication, launching, and 3rd party addons. Zuko uses a Rasberry Pi 4 with a custom expansion board for motor and peripheral control via a Playstation 4 controller.
ROS2 source code is contained the quad_ws directory.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 8 | 1.2k | Resistor_SMD:R_0805_2012Metric | R1, R2, R3, R5, R6, R7, R15, R16 |
| 6 | Conn_01x04 | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J8, J9, J10, J11, J13, J14 |
| 6 | MountingHole | General:RPi_Hat_Mounting_Hole | H1, H2, H3, H4, H5, H6 |
| 5 | 10k | Resistor_SMD:R_0805_2012Metric | R4, R8, R9, R11, R12 |
| 5 | Conn_03x03 | connectors:Conn_03x03 | U8, U9, U10, U11, U12 |
| 4 | 2200uF | Capacitor_THT:CP_Radial_D10.0mm_P5.00mm | C6, C8, C9, C10 |
| 4 | Jumper_2_Open | Jumper:SolderJumper-2_P1.3mm_Open_Pad1.0x1.5mm | JP1, JP2, JP3, JP4 |
| 3 | Jumper_3_Open | Jumper:SolderJumper-3_P1.3mm_Open_RoundedPad1.0x1.5mm | JP5, JP6, JP7 |
| 2 | 1uF | Capacitor_SMD:C_0805_2012Metric | C2, C5 |
| 2 | 20k | Resistor_SMD:R_0805_2012Metric | R10, R13 |
| 2 | 3.9k | Resistor_SMD:R_0805_2012Metric | R18, R19 |
| 2 | ADS1115IDGS | Package_SO:TSSOP-10_3x3mm_P0.5mm | U1, U5 |
| 2 | Conn_01x02 | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J1, J5 |
| 2 | Conn_02x03_Odd_Even | Connector_PinHeader_2.54mm:PinHeader_2x03_P2.54mm_Vertical | J3, J4 |
| 1 | 1.21k | Resistor_SMD:R_0805_2012Metric | R17 |
| 1 | 100nF | Capacitor_SMD:C_0805_2012Metric | C4 |
| 1 | 10uF | Capacitor_SMD:C_0805_2012Metric | C1 |
| 1 | 1nF | Capacitor_SMD:C_0805_2012Metric | C3 |
| 1 | 22uH | Inductor_SMD:L_12x12mm_H6mm | L1 |
| 1 | 24LC256 | Package_SO:SOIC-8_3.9x4.9mm_P1.27mm | U7 |
| 1 | 500Ω | Resistor_SMD:R_0805_2012Metric | R14 |
| 1 | 50k | General:Precision_pot | RV1 |
| 1 | 560uF | Capacitor_SMD:CP_Elec_10x10 | C7 |
| 1 | ACS712xLCTR-20A | Package_SO:SOIC-8_3.9x4.9mm_P1.27mm | U3 |
| 1 | BNO055_Module | General:BNO055 Module | MOD1 |
| 1 | BSS138 | Package_TO_SOT_SMD:SOT-23 | Q1 |
| 1 | Conn_01x02 | Connector_AMASS:AMASS_XT30U-M_1x02_P5.0mm_Vertical | J2 |
| 1 | Conn_01x03 | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J6 |
| 1 | Conn_01x06 | Connector_PinHeader_2.54mm:PinHeader_1x06_P2.54mm_Vertical | J15 |
| 1 | Conn_02x03_Counter_Clockwise | Connector_PinHeader_2.54mm:PinHeader_2x03_P2.54mm_Vertical | J7 |
| 1 | D_Schottky | Diode_SMD:D_SMC | D2 |
| 1 | LED | LED_SMD:LED_0805_2012Metric | D1 |
| 1 | LM2596S-5 | Package_TO_SOT_SMD:TO-263-5_TabPin3 | U6 |
| 1 | PCA9635 | Package_SO:TSSOP-28_4.4x9.7mm_P0.65mm | U2 |
| 1 | Raspberry_Pi_2_3 | General:Samtec_HLE-120-02-XXX-DV-BE-XX-XX | J12 |
| 1 | ULN2003 | Package_SO:SOIC-16_3.9x9.9mm_P1.27mm | U4 |


jacob-jarick/esp-solar-contoller
esp8266 and esp32 based solar controllers targetting fronius inverter users


JakobThiessen/NixieClock
Wichtig: Ohne Änderung tut die SD karte nicht. (Betrifft nur V2.0 in der V2.1 sind die Änderung im Layout schon umgesetzt)

matthieuvigne/MiAM_robotics
Generic repo for robotic projects with the former MiAM Eurobot team !

Anycircle11139s/Macropad-v2
I wanted to make a second version of my macropad because I was confident, that with my improved skills, I could cook up something better. I spent a long time creating this, and I'm really proud of what I made.
It measures 100 × 49.8 mm and has 4 copper layers, 1.6 mm thick.
75 parts, built around the ADS1115IDGS, LM2596S-5.0, PCA9635PW and 24LC256-I/P. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the reubenstr/zuko repository on GitHub, at the commit this page was made from: the board is pcbs/expansion-board/expansion-board.kicad_pcb and its schematic pcbs/battery-board/battery-board.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).