

4 layers100 × 49.8 mm

 reubenstr/zuko51
A quadruped robot dog!
Motor controller is an open-source printed circuit board by reubenstr, from the reubenstr/zuko repository on GitHub, published under the MIT licence. It is a 4-layer board of 100 × 40 mm with 67 parts on 62 nets, routed with 548 tracks and 74 vias.
It is built around the ULN2003 and BSS138. Its parts include 35 connectors, 14 resistors, 6 capacitors, 3 ICs and 2 transistors. It belongs with the robots and motor control boards and the NXP (LPC, Kinetis, i.MX RT) boards of this library.
 |
|---|
| Frame v2.2 CAD design. |
 |
|---|
| Zuko himself! |
 |
|---|
| Frame v2.1 parts printed. |
 |
|---|
| Expansion board v1 for direct RPi inteface. |
 |
|---|
| Frame v2.1 first time standing. |
 |
|---|
| Frame v2.1 upper leg's servo horn, linked leg bridge, and bridge bearing press fit together. |
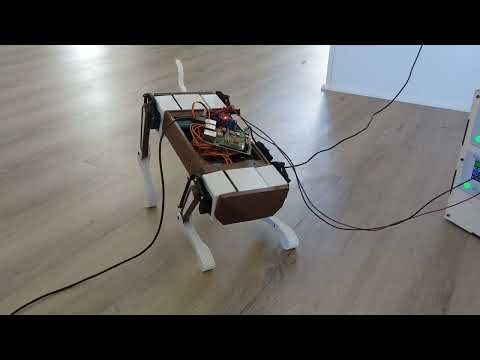 |
|---|
| Video: frame v2.1 first tests |
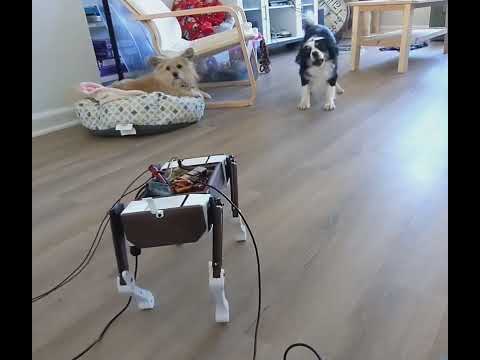 |
|---|
| Video: Sydney meets Zuko |
Development.
V2.2 Frame is being tested and is nearly ready for replication
Zuko uses the ROS2 framework for communication, launching, and 3rd party addons. Zuko uses a Rasberry Pi 4 with a custom expansion board for motor and peripheral control via a Playstation 4 controller.
ROS2 source code is contained the quad_ws directory.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 17 | Conn_01x03 | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J19, J20, J21, J22, J23, J24, J25, J26, J27, J28, J29, J30, J31, J32, J33, J34 +1 |
| 8 | Conn_01x02 | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J3, J4, J7, J8, J9, J11, J12, J13 |
| 8 | Conn_01x04 | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J1, J2, J5, J10, J15, J16, J17, J18 |
| 6 | 10k | Resistor_SMD:R_1206_3216Metric_Pad1.30x1.75mm_HandSolder | R2, R4, R5, R6, R7, R11 |
| 4 | 1.2k | Resistor_SMD:R_1206_3216Metric_Pad1.30x1.75mm_HandSolder | R1, R3, R8, R10 |
| 4 | 2200uF | Capacitor_THT:CP_Radial_D10.0mm_P5.00mm | C3, C4, C5, C6 |
| 3 | Jumper_3_Open | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | JP1, JP2, JP3 |
| 2 | 20k | Resistor_SMD:R_1206_3216Metric_Pad1.30x1.75mm_HandSolder | R9, R12 |
| 2 | 500Ω | Resistor_SMD:R_1206_3216Metric_Pad1.30x1.75mm_HandSolder | R13, R14 |
| 2 | BSS138 | Package_TO_SOT_SMD:SOT-23 | Q1, Q2 |
| 1 | 100nF | Capacitor_SMD:C_1206_3216Metric_Pad1.33x1.80mm_HandSolder | C2 |
| 1 | 1nF | Capacitor_SMD:C_1206_3216Metric_Pad1.33x1.80mm_HandSolder | C1 |
| 1 | ACS712xLCTR-20A | Package_SO:SOIC-8_3.9x4.9mm_P1.27mm | U1 |
| 1 | Conn_01x02 | Connector_AMASS:AMASS_XT30U-M_1x02_P5.0mm_Vertical | J6 |
| 1 | Conn_01x06 | Connector_PinHeader_2.54mm:PinHeader_1x06_P2.54mm_Vertical | J14 |
| 1 | Teensy4.0 | Teensy:Teensy40 | U2 |
| 1 | ULN2003 | Package_SO:SOIC-16_3.9x9.9mm_P1.27mm | U3 |
The 63 most common of 67 parts.
It measures 100 × 40 mm and has 4 copper layers, 1.6 mm thick.
67 parts, built around the ULN2003 and BSS138. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the reubenstr/zuko repository on GitHub, at the commit this page was made from: the board is pcbs/motor-controller/motor-controller.kicad_pcb and its schematic pcbs/battery-board/battery-board.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).


TheYoctoJester/dutler
A bench butler for your Device Under Test: turns a Raspberry Pi Pico into a USB-serial console bridge with power-relay and MOSFET strap/reset control for embedded-Linux bring-up and hardware-in-the-loop.


stormbots/MarketingBot
See the attached Wiki for documentation about the general system functionality


jmfriedt/SDR-GB-SAR
Opensource, openhardware implementation of a Software Defined Radio (SDR) Ground Based Synthetic-Aperture RADAR (GB-SAR)

tnn85/MPCNC-Nano-Estlcam-Shield
Ein CNC Shield für die MPCNC in Verwendung mit Estlcam

jlecomte/ascom-oag-focuser
Open Source ASCOM-Compatible OAG Focuser For Astrophotography
