6 layers100 × 100 mm
Imx8x eps leviathan v2
BroncoSpace-Lab/scales-hardware
Hardware design files for the Spacecraft Compartmentalized Autonomous Learning and Edge Computing System (SCALES)
449 parts6

 qwertpas/squirrelbrain1
Main control PCB for Pinto robot squirrel
Squirrelbrain is an open-source printed circuit board by qwertpas, from the qwertpas/squirrelbrain repository on GitHub, published under the MIT licence. It is a 2-layer board of 27 × 27 mm with 38 parts on 39 nets, routed with 353 tracks and 83 vias.
It is built around the RPM5.0-6.0, TPS1HB08BQPWPRQ1 and TPS22992SRXNR, with the SDM2U30CSP among its other parts. Its parts include 8 resistors, 7 ICs, 6 connectors, 5 capacitors and 1 diode. It belongs with the robots and motor control boards and the ESP32 boards of this library.


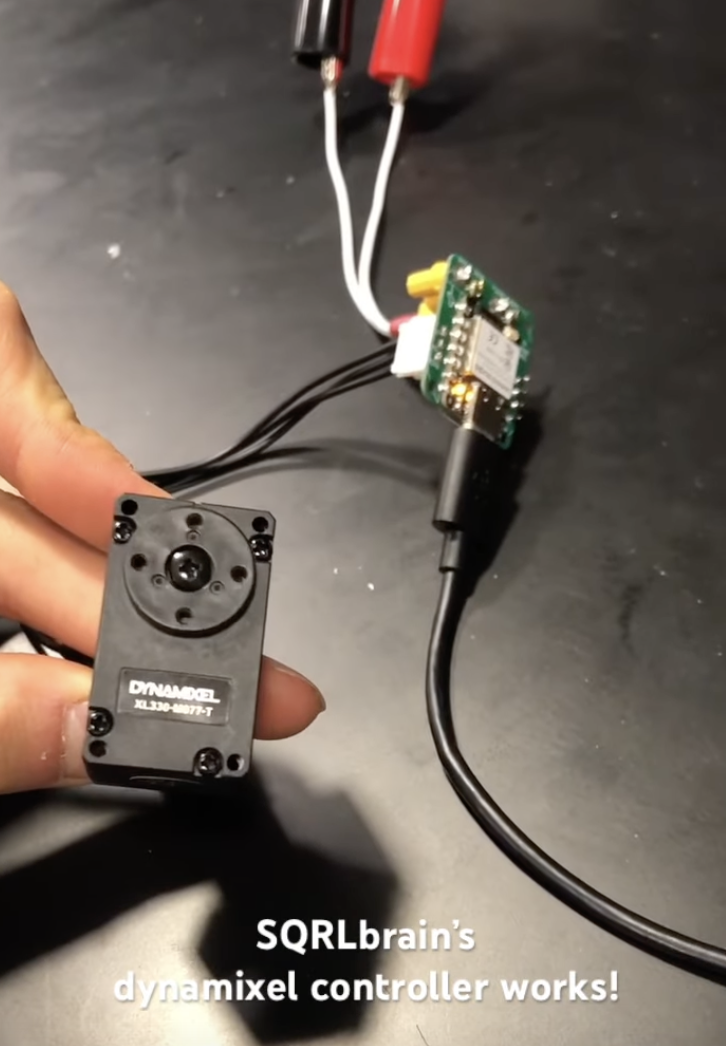
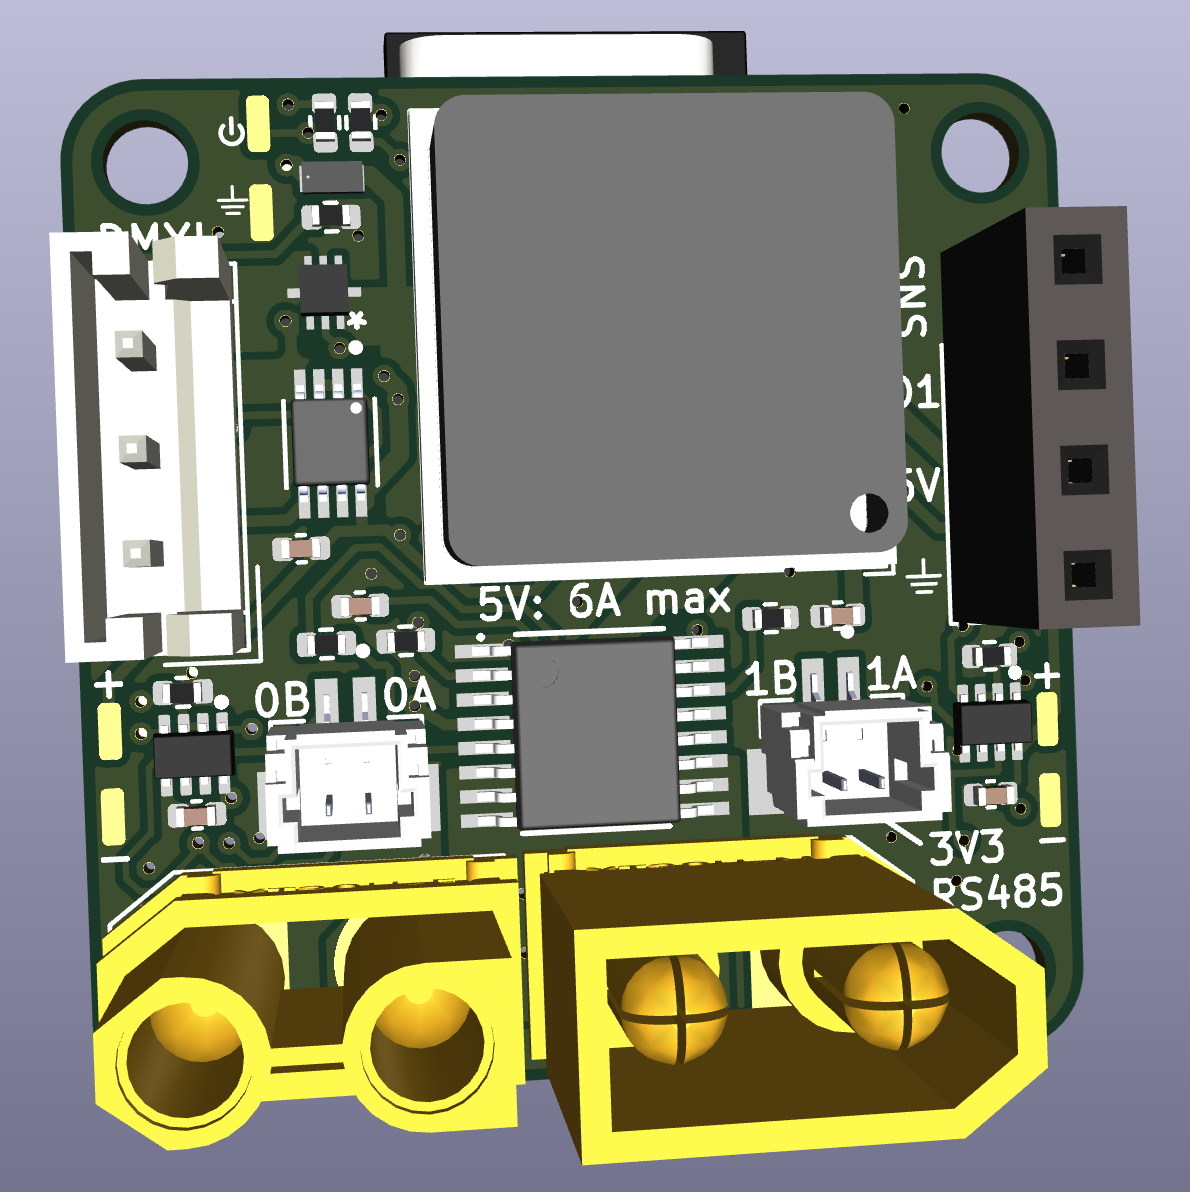
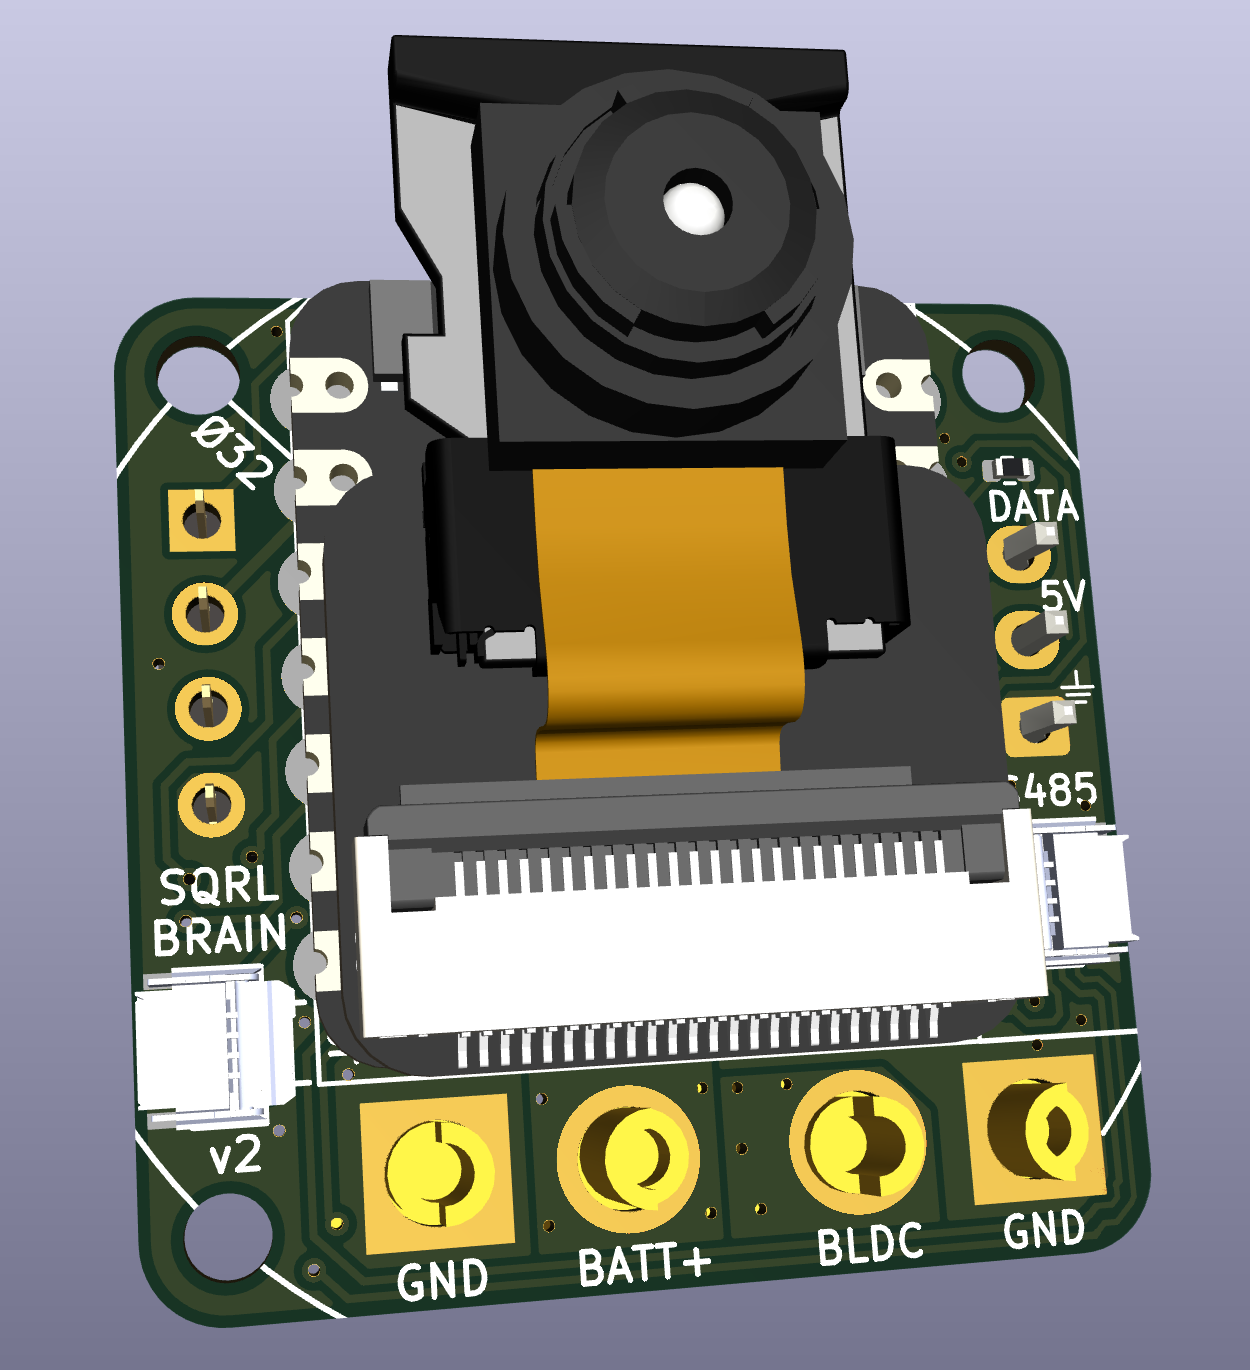
Main control board for the Pintobotics robotic squirrel. It uses a Seeeduino XIAO ESP32S3 for wireless communication with a base station, is able to drive dynamixel 5V TTL servos up to 6A, and has two separate RS485 buses.
The RS485 buses are intended for:
Squirrelbrain has two load switches to allow the ESP32 to cut off power to the motors when the battery is still connected. One load switch operates an XT30 output, featuring current sensing and a programmed current limit of 38A (limit can be adjusted by replacing a resistor). The other load switch operates on the 5V supply intended for dynamixel servos.
Size: 27mm x 27mm
Mounting: 4x M2 on 32mm diameter circle
Connections:
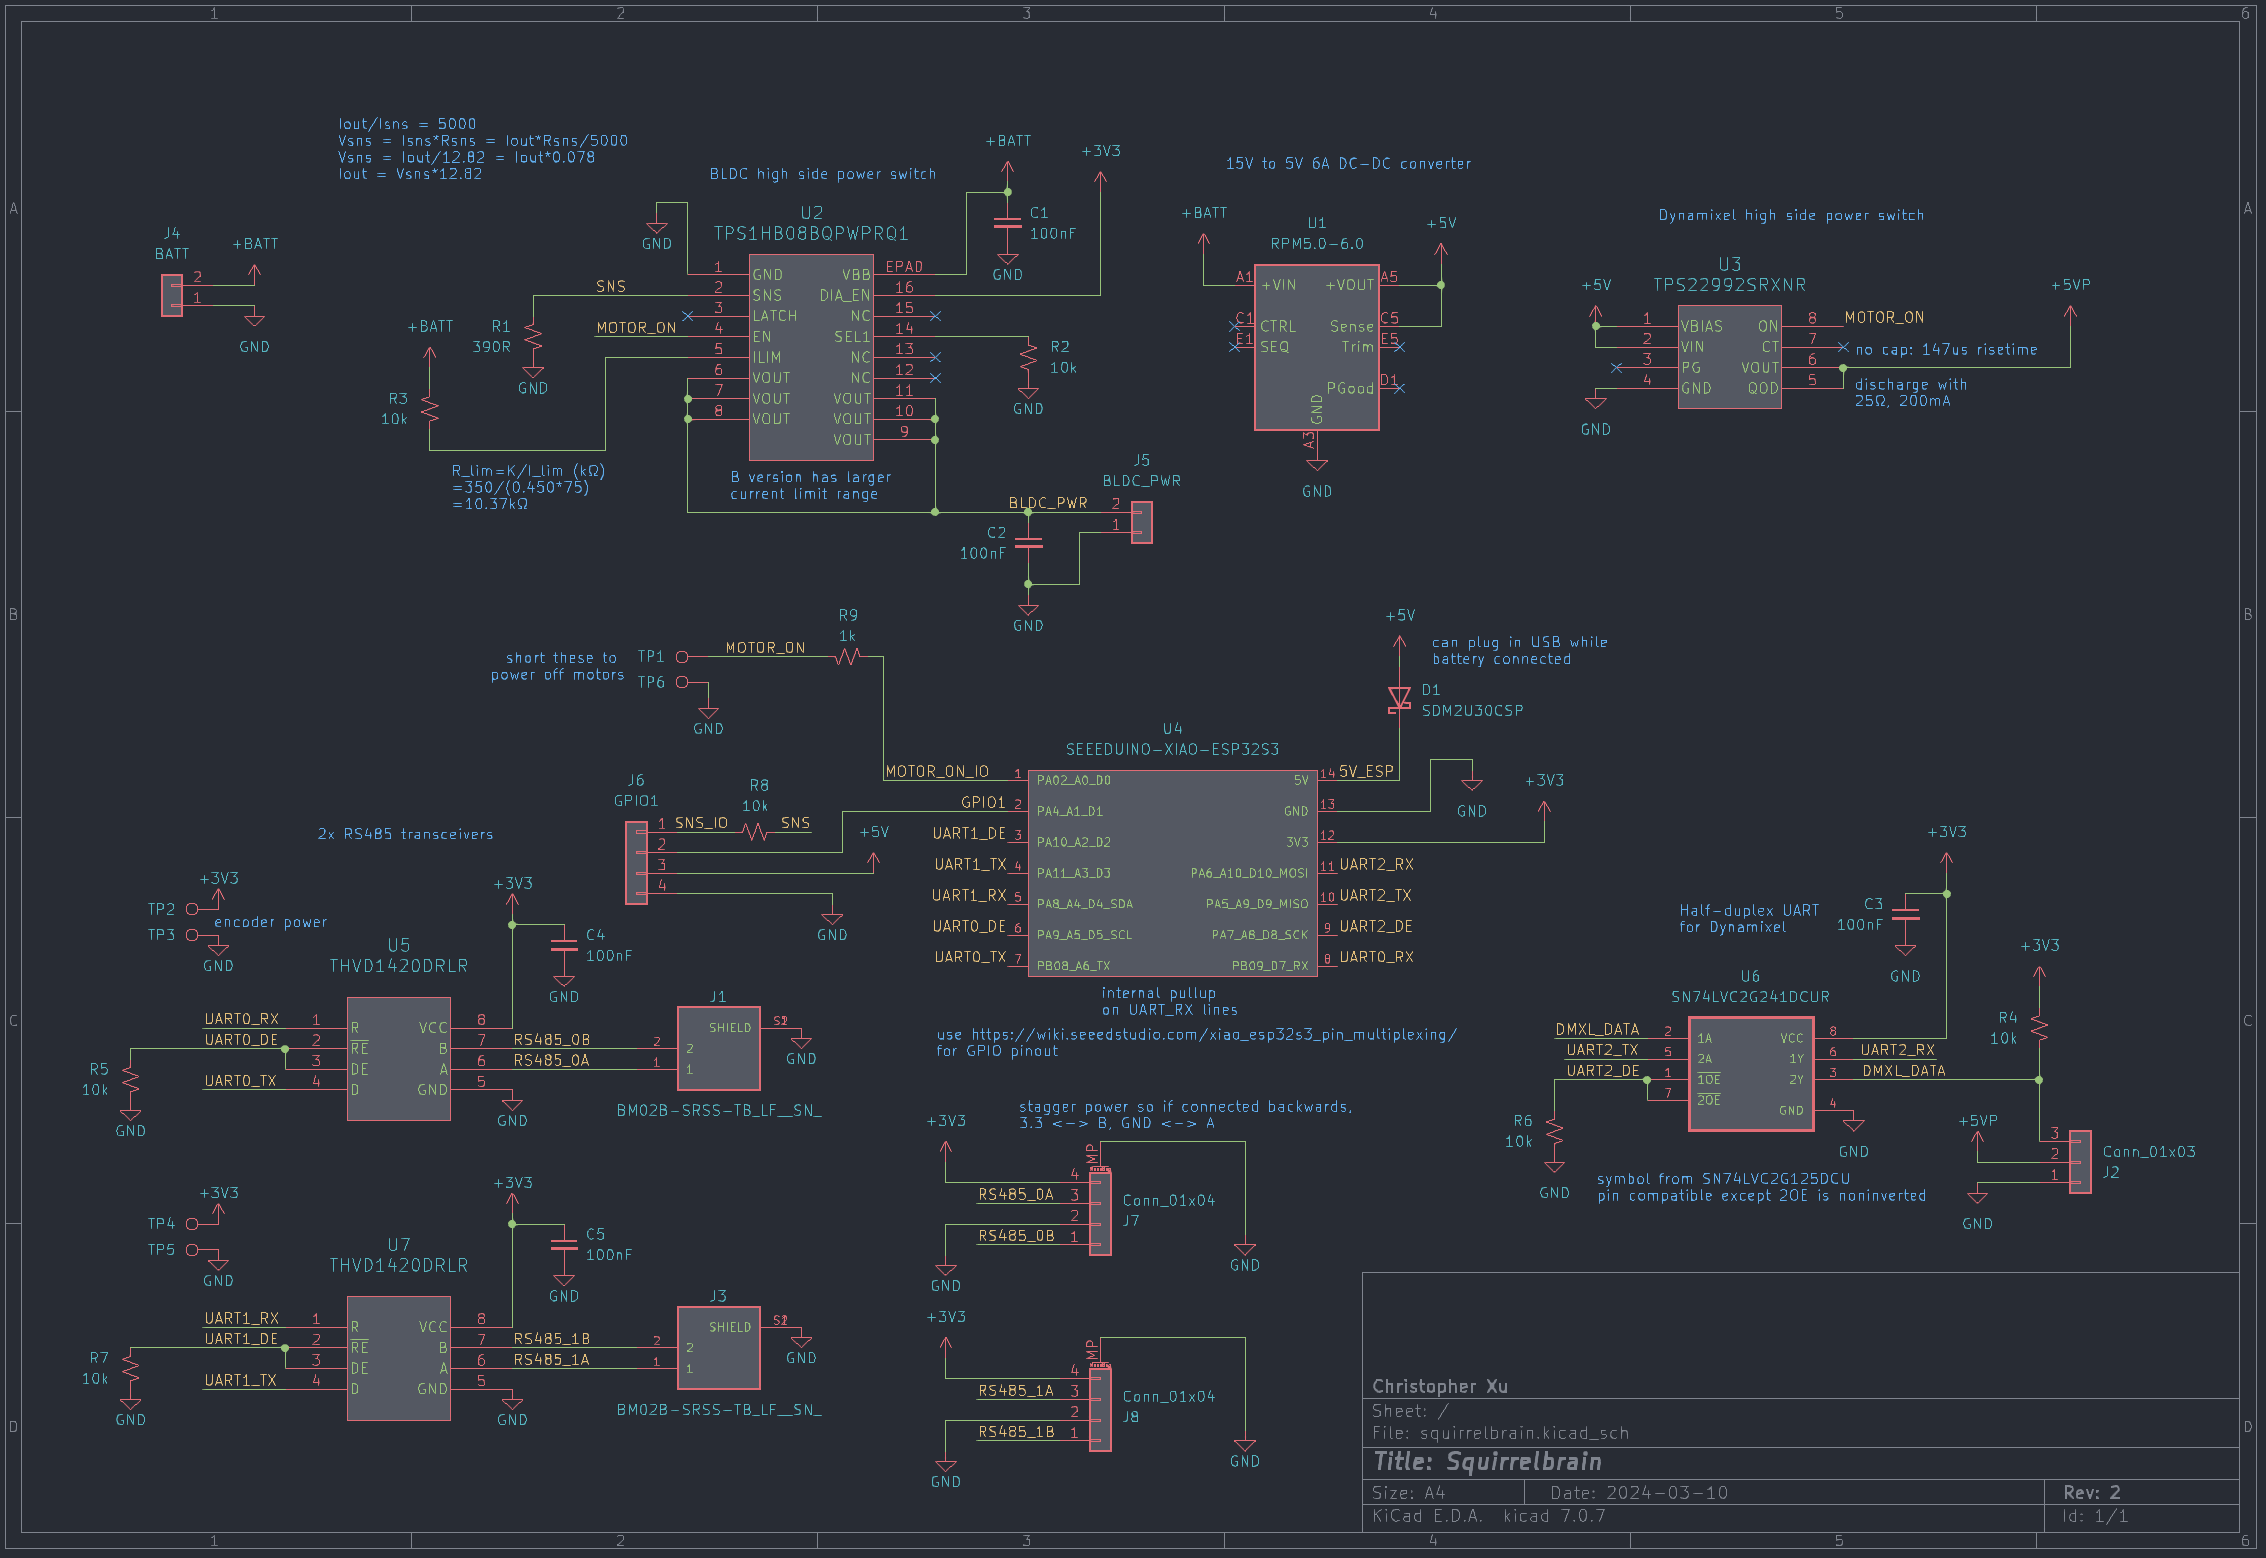
Squirrelbrain v1 does not have the FFC connectors and is missing a pullup on the dynamixel data line.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 6 | 10k | Resistor_SMD:R_0402_1005Metric | R2, R3, R5, R6, R7, R8 |
| 6 | TestPoint | squirrelbrain:TestPoint_Pad_Rect | TP1, TP2, TP3, TP4, TP5, TP6 |
| 5 | 100nF | Capacitor_SMD:C_0402_1005Metric | C1, C2, C3, C4, C5 |
| 5 | LOGO | LOGO | G***, G***, G***, G***, G*** |
| 2 | BM02B-SRSS-TB_LF__SN_ | squirrelbrain:JST_BM02B-SRSS-TB_LF__SN_ | J1, J3 |
| 2 | THVD1420DRLR | squirrelbrain:THVD1420DRLR_SOT-585 | U5, U7 |
| 1 | 1k | Resistor_SMD:R_0402_1005Metric | R9 |
| 1 | 390R | Resistor_SMD:R_0402_1005Metric | R1 |
| 1 | BATT | squirrelbrain:AMASS_XT30U-M_1x02_P5.0mm_Vertical | J4 |
| 1 | BLDC_PWR | squirrelbrain:AMASS_XT30U-F_1x02_P5.0mm_Vertical | J5 |
| 1 | Conn_01x03 | Connector_JST:JST_EH_B3B-EH-A_1x03_P2.50mm_Vertical | J2 |
| 1 | GPIO1 | Connector_PinSocket_2.54mm:PinSocket_1x04_P2.54mm_Vertical | J6 |
| 1 | RPM5.0-6.0 | Converter_DCDC:Converter_DCDC_RECOM_RPMx.x-x.0 | U1 |
| 1 | SDM2U30CSP | squirrelbrain:SDM2U30CSP-7 | D1 |
| 1 | SEEEDUINO-XIAO-ESP32S3 | squirrelbrain:XIAO-ESP32S3-2.54-21X17.8MM | U4 |
| 1 | SN74LVC2G241DCUR | squirrelbrain:SN74LVC2G125DCU | U6 |
| 1 | TPS1HB08BQPWPRQ1 | squirrelbrain:TPS1HB08 | U2 |
| 1 | TPS22992SRXNR | squirrelbrain:TPS22992S | U3 |
It measures 27 × 27 mm and has 2 copper layers, 0.8 mm thick.
38 parts, built around the RPM5.0-6.0, TPS1HB08BQPWPRQ1, TPS22992SRXNR and SDM2U30CSP. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the qwertpas/squirrelbrain repository on GitHub, at the commit this page was made from: the board is v1/squirrelbrain.kicad_pcb and its schematic v1/squirrelbrain.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).
BroncoSpace-Lab/scales-hardware
Hardware design files for the Spacecraft Compartmentalized Autonomous Learning and Edge Computing System (SCALES)

qwertpas/O32controller
Miniature closed-loop controller for brushless DC motors


roloran/ROLORAN-Hardware
Custom PCB designs and cases/mounting tools for ROLORAN devices

joeycastillo/The-Open-Book
For details on how to build, test and use Open Book, I've made documentation available here.
