2 layers97.3 × 148 mm
 project-neon/Neon_SSL_Robot
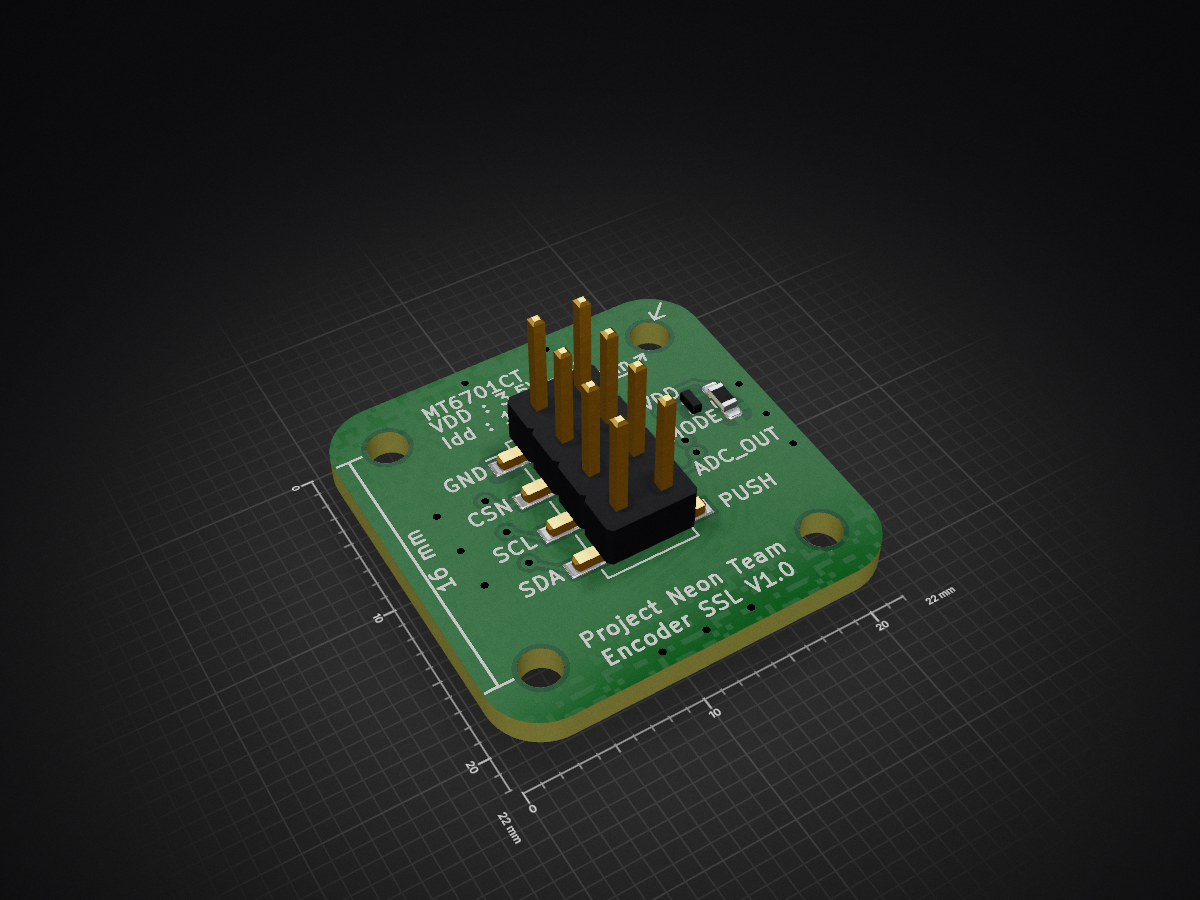
Encoder is an open-source printed circuit board by project-neon, from the project-neon/Neon_SSL_Robot repository on GitHub. It is a 2-layer board of 22 × 22 mm with 9 parts on 8 nets, routed with 36 tracks and 18 vias.
It is built around the MT6701CT-STD and VESD05A1B-HD1-GS08. Its parts include 1 capacitor, 1 IC, 1 diode and 1 connector.


| Qty | Value | Footprint | References |
|---|---|---|---|
| 4 | MountingHole | MountingHole:MountingHole_2.2mm_M2 | H201, H202, H203, H204 |
| 1 | VESD05A1B-HD1-GS08 | VESD05A1B-HD1:VESD05A1B-HD1 | D201 |
| 1 | 0.1UF | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | C201 |
| 1 | Conn_02x04_Counter_Clockwise | Connector_PinHeader_2.54mm:PinHeader_2x04_P2.54mm_Vertical_SMD | J201 |
| 1 | LOGO | LOGO | G*** |
| 1 | MT6701CT | Package_SO:SO-8_5.3x6.2mm_P1.27mm | U201 |


avenhaus/SO-ARM100-Encoders
It explores to use much cheaper magnetic encoders for the Leader Arm instead of the regular servos. These dummy servos are also much easier to move manually, as there is no gear train that needs to back drive the servo…

earlynerd/bl4818-servo-M23
This repository contains the electronics, embedded firmware, host software, and browser players for a network of brushless servo percussion actuators.

chpaxson/Echo-Telepresence
UC Berkeley ME 135/235 Spring 2025 Term Project


maxmunzner/NEMA17_FOC_Driver
A Stepper Driver project with a PCB that acts as the driver and encoder.
It measures 22 × 22 mm and has 2 copper layers, 1.6 mm thick.
9 parts, built around the MT6701CT-STD and VESD05A1B-HD1-GS08. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the project-neon/Neon_SSL_Robot repository on GitHub, at the commit this page was made from: the board is Eletronics/Encoder/Encoder.kicad_pcb and its schematic Eletronics/Board_V0/Board_V0/Board_V0.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask project-neon before reusing the design.