2 layers391 × 131.1 mm

 pagabel48/Drone_Controller
PCB and Code to control a quadcopter drone, uses PID controllers and Kalman filters with sensors to implement angle mode control.
Drone Motherboard is an open-source printed circuit board by pagabel48, from the pagabel48/Drone_Controller repository on GitHub. It is a 4-layer board of 47.5 × 47.5 mm with 63 parts on 77 nets, routed with 444 tracks and 124 vias.
It is built around the STM32F401RCT6, LM2574M-3.3 and IRF9540NS. Its parts include 19 capacitors, 12 resistors, 9 connectors, 6 diodes and 3 ICs. It belongs with the robots and motor control and power boards and the STM32 boards of this library.


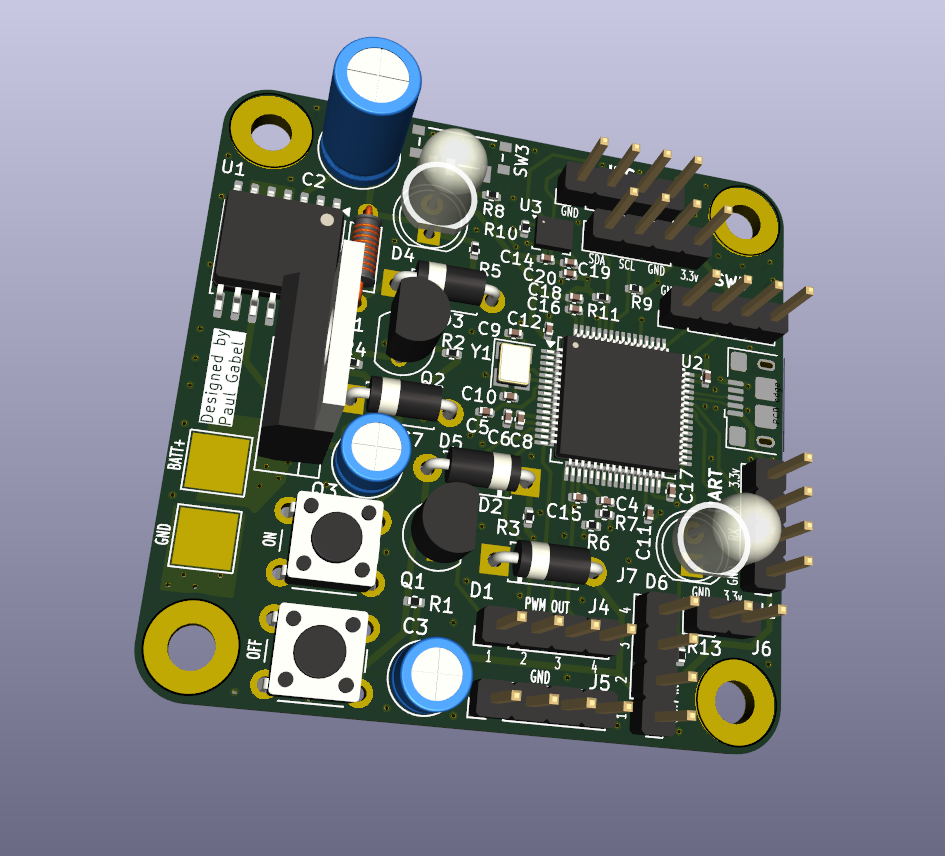
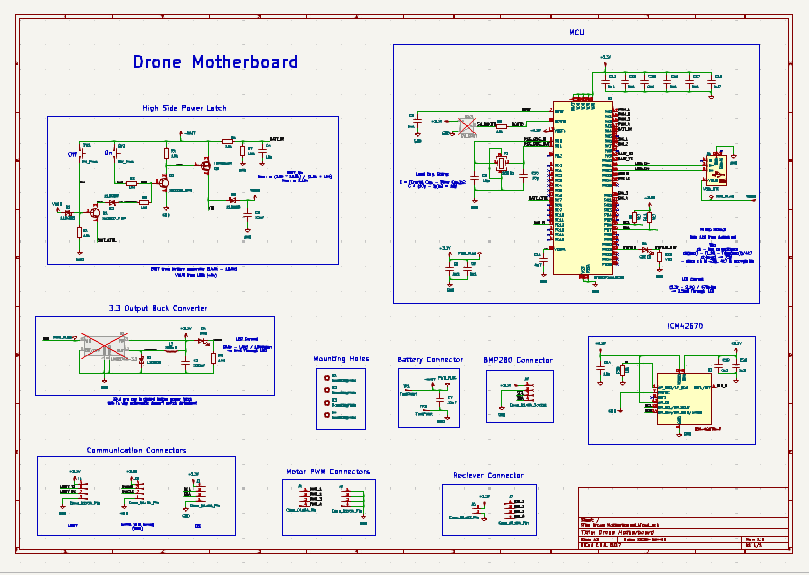
The control board is based around an STM32f401 MCU. For power regulation a buck converter is used to generate steady 3.3v from a 4s LiPO Battery or USB 5v line. When powered over battery, the highside power latch allows the board to be toggled on or off.
To allow for closed loop control a BMP280 barometer and an ICM42670P IMU are connected over I2C, and PWM is used to communicate with the motor ESCs and controller receiver. Programming is done over USB, and pins are exposed for UART, I2C, and SWD protocols for extensibility.
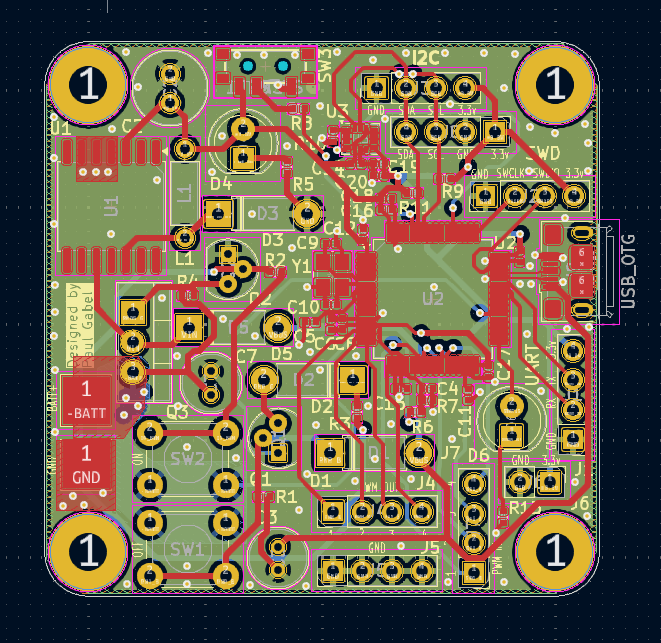
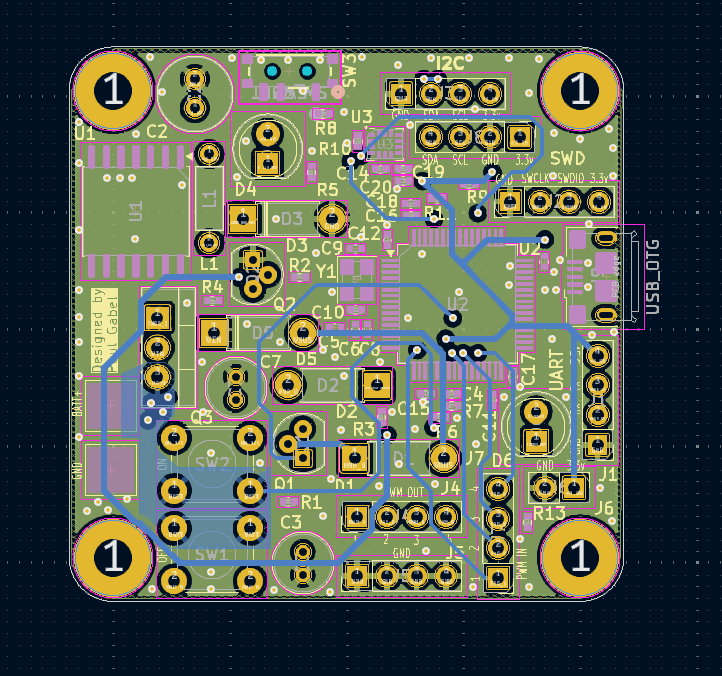
Four layers were used to make routing easier and improve signal integrity.
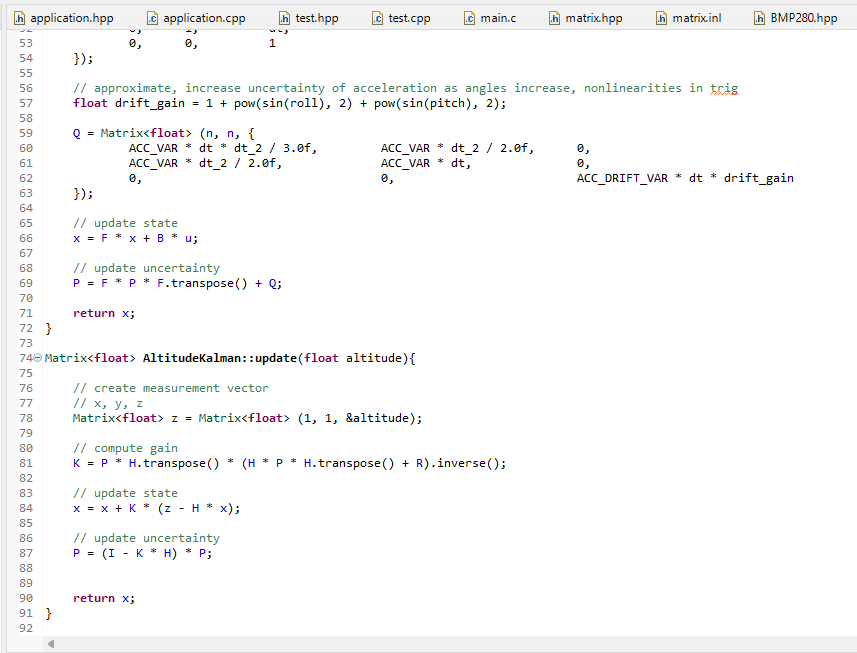
State estimation is achieved with two Kalman filters (attitude and altitude), and PID controllers are used in combination with a mixer to get final motor throttle values.
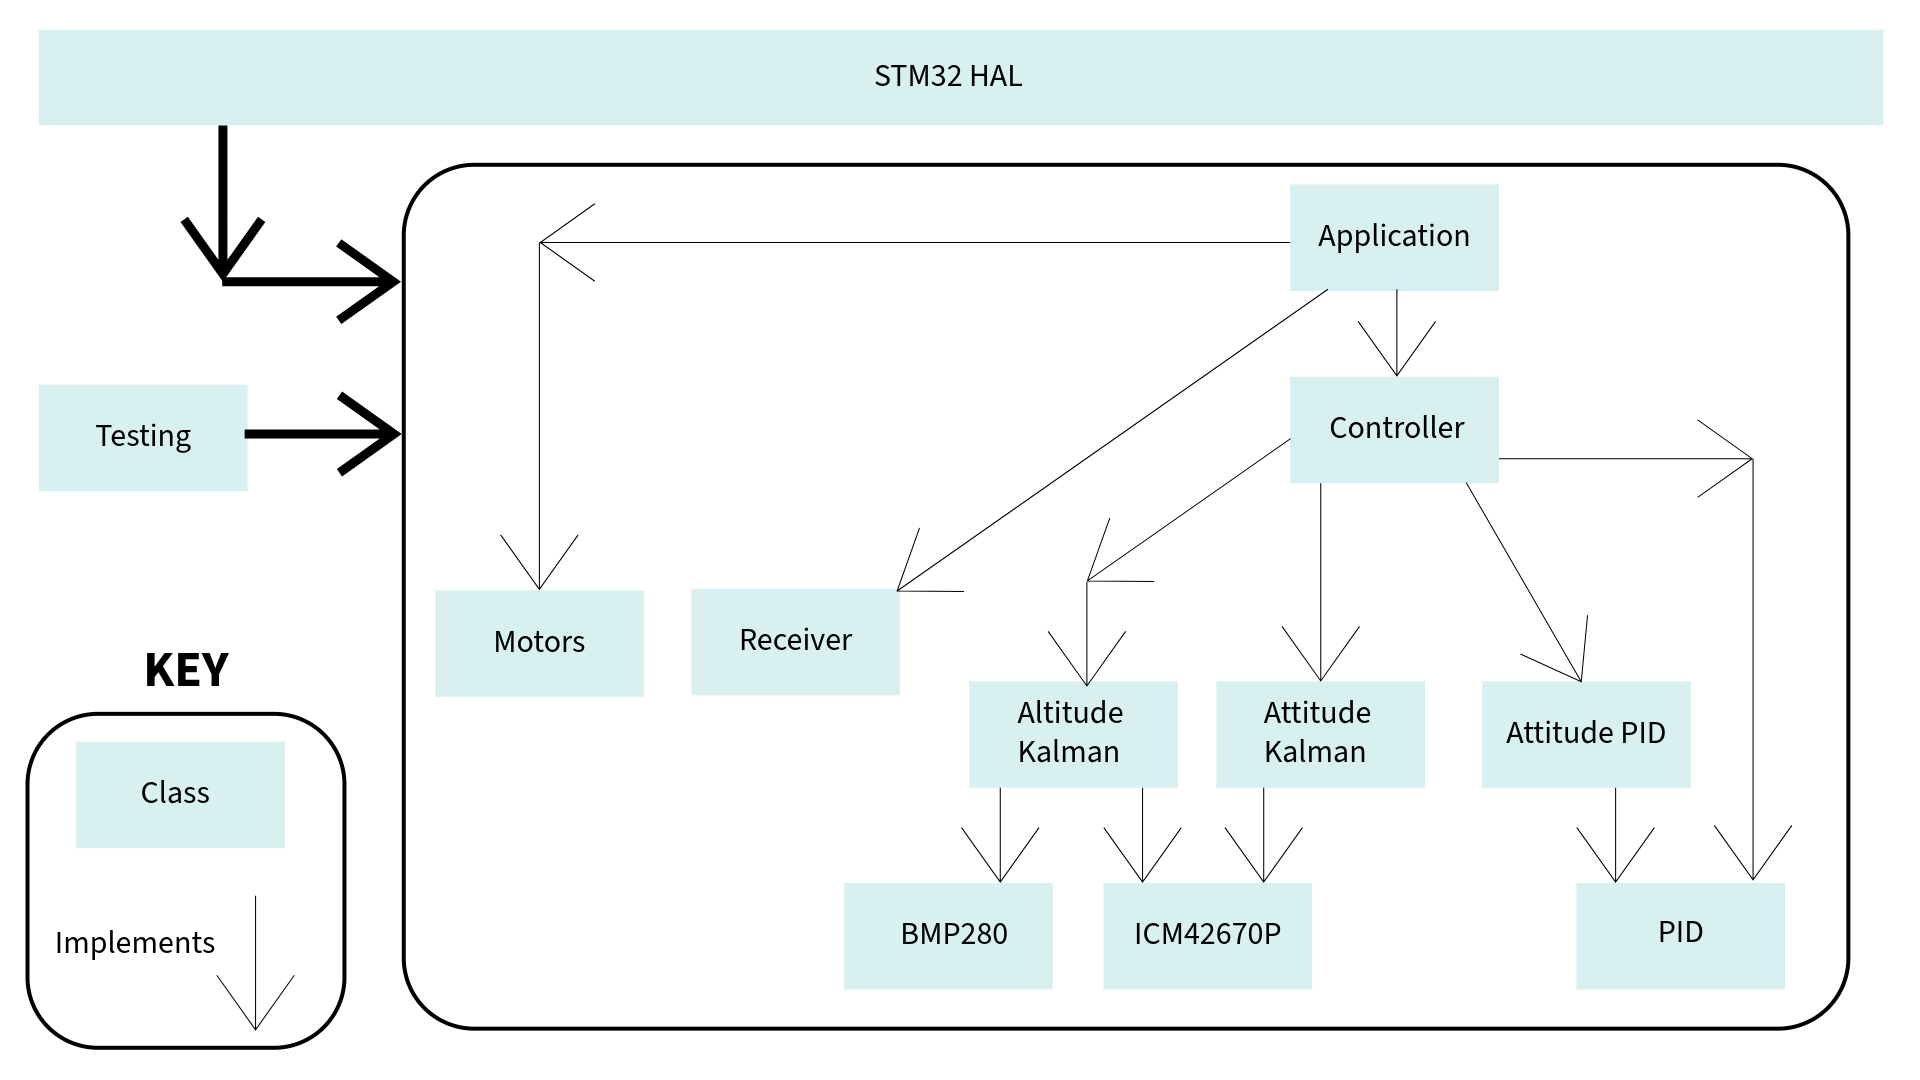
Custom drivers were written to interface with the sensors, and a matrix math library was written using c++ operator overloading - this allows for readable state space control code. The IMU driver reads when triggered by a pin interupt, and the barometer driver uses polling.
A testing routine was written which can be run instead of the main drone loop - it runs unit tests for the code, then tests operation of the sensors, motors, Kalman filters, and status light.
The firmware automatically turns the drone off when the battery voltage drops below a safe level.
Controller Code is Contained in Firmare/Core/
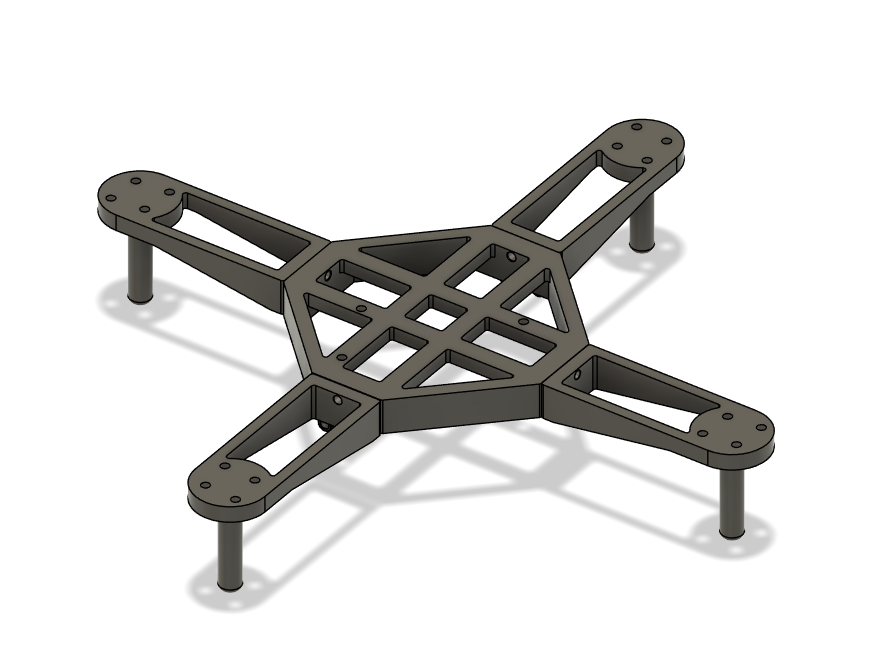
The frame was designed in fusion 360 and was 3d printed using PETG plastic. Care was taken to maximize rigidity whilst minimizing weight.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 8 | 0u1 | Capacitor_SMD:C_0402_1005Metric | C5, C8, C12, C13, C15, C16, C17, C19 |
| 6 | 10k | Resistor_SMD:R_0402_1005Metric | R1, R2, R4, R6, R8, R10 |
| 6 | Conn_01x04_Pin | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J1, J2, J3, J4, J5, J7 |
| 4 | 11DQ05 | Diode_THT:D_DO-41_SOD81_P7.62mm_Horizontal | D1, D2, D3, D5 |
| 4 | MountingHole | MountingHole:MountingHole_3.2mm_M3_Pad | H1, H2, H3, H4 |
| 3 | 1k5 | Resistor_SMD:R_0402_1005Metric | R3, R5, R7 |
| 2 | 10n | Capacitor_SMD:C_0402_1005Metric | C4, C14 |
| 2 | 10p | Capacitor_SMD:C_0402_1005Metric | C9, C10 |
| 2 | 22uF | Capacitor_THT:C_Radial_D5.0mm_H5.0mm_P2.00mm | C3, C7 |
| 2 | 2u2 | Capacitor_SMD:C_0402_1005Metric | C6, C20 |
| 2 | 4k7 | Resistor_SMD:R_0402_1005Metric | R9, R11 |
| 2 | 4u7 | Capacitor_SMD:C_0402_1005Metric | C11, C18 |
| 2 | SW_Push | Button_Switch_THT:SW_PUSH_6mm | SW1, SW2 |
| 2 | TestPoint | TestPoint:TestPoint_Pad_4.0x4.0mm | TP1, TP2 |
| 1 | 16MHz | Crystal:Crystal_SMD_3225-4Pin_3.2x2.5mm | Y1 |
| 1 | 220uF | Capacitor_THT:C_Radial_D6.3mm_H11.0mm_P2.50mm | C2 |
| 1 | 2N222A_NPN | Package_TO_SOT_THT:TO-92 | Q2 |
| 1 | 2N2907_PNP | Package_TO_SOT_THT:TO-92 | Q1 |
| 1 | 330uH | Inductor_THT:L_Axial_L5.3mm_D2.2mm_P7.62mm_Horizontal_Vishay_IM-1 | L1 |
| 1 | 470 | Resistor_SMD:R_0402_1005Metric | R13 |
| 1 | Conn_01x02_Pin | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J6 |
| 1 | Conn_01x04_Socket | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J8 |
| 1 | GREEN | LED_THT:LED_D5.0mm_Clear | D6 |
| 1 | IRF9540N | Package_TO_SOT_THT:TO-220-3_Vertical | Q3 |
| 1 | LM2574M-3.3 | Package_SO:SOIC-14W_7.5x9mm_P1.27mm | U1 |
| 1 | RED | LED_THT:LED_D5.0mm_Clear | D4 |
| 1 | STM32F401RCT6 | Package_QFP:LQFP-64_10x10mm_P0.5mm | U2 |
| 1 | SW_SPDT | footprints:CUS-12TB_NDC | SW3 |
| 1 | USB_OTG | Connector_USB:USB_Micro-B_Amphenol_10118193-0001LF_Horizontal | J9 |
| 1 | ~ | Package_LGA:LGA-14_3x2.5mm_P0.5mm_LayoutBorder3x4y | U3 |
It measures 47.5 × 47.5 mm and has 4 copper layers, 1.6 mm thick.
63 parts, built around the STM32F401RCT6, LM2574M-3.3 and IRF9540NS. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the pagabel48/Drone_Controller repository on GitHub, at the commit this page was made from: the board is PCB/Drone Motherboard.kicad_pcb and its schematic PCB/Drone Motherboard.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask pagabel48 before reusing the design.

gianlucarenzi/STM32F4XX
A generic development board for the STM32F401 microcontroller.


simonyiszk/STM32-RedPill
STM32-based development board with integrated ST-LINK/V2 compatible programmer, to be used on SEM advanced courses.
