2 layers57.3 × 19 mm

 OPRobots/PeronaBot
Robot de combate de 1lb estilo MeltyBrain
PeronaBot is an open-source printed circuit board by OPRobots, from the OPRobots/PeronaBot repository on GitHub, published under the GPL-3.0 licence. It is a 2-layer board of 75.2 × 44.3 mm with 26 parts on 24 nets, routed with 119 tracks and 69 vias.
It belongs with the robots and motor control boards of this library.
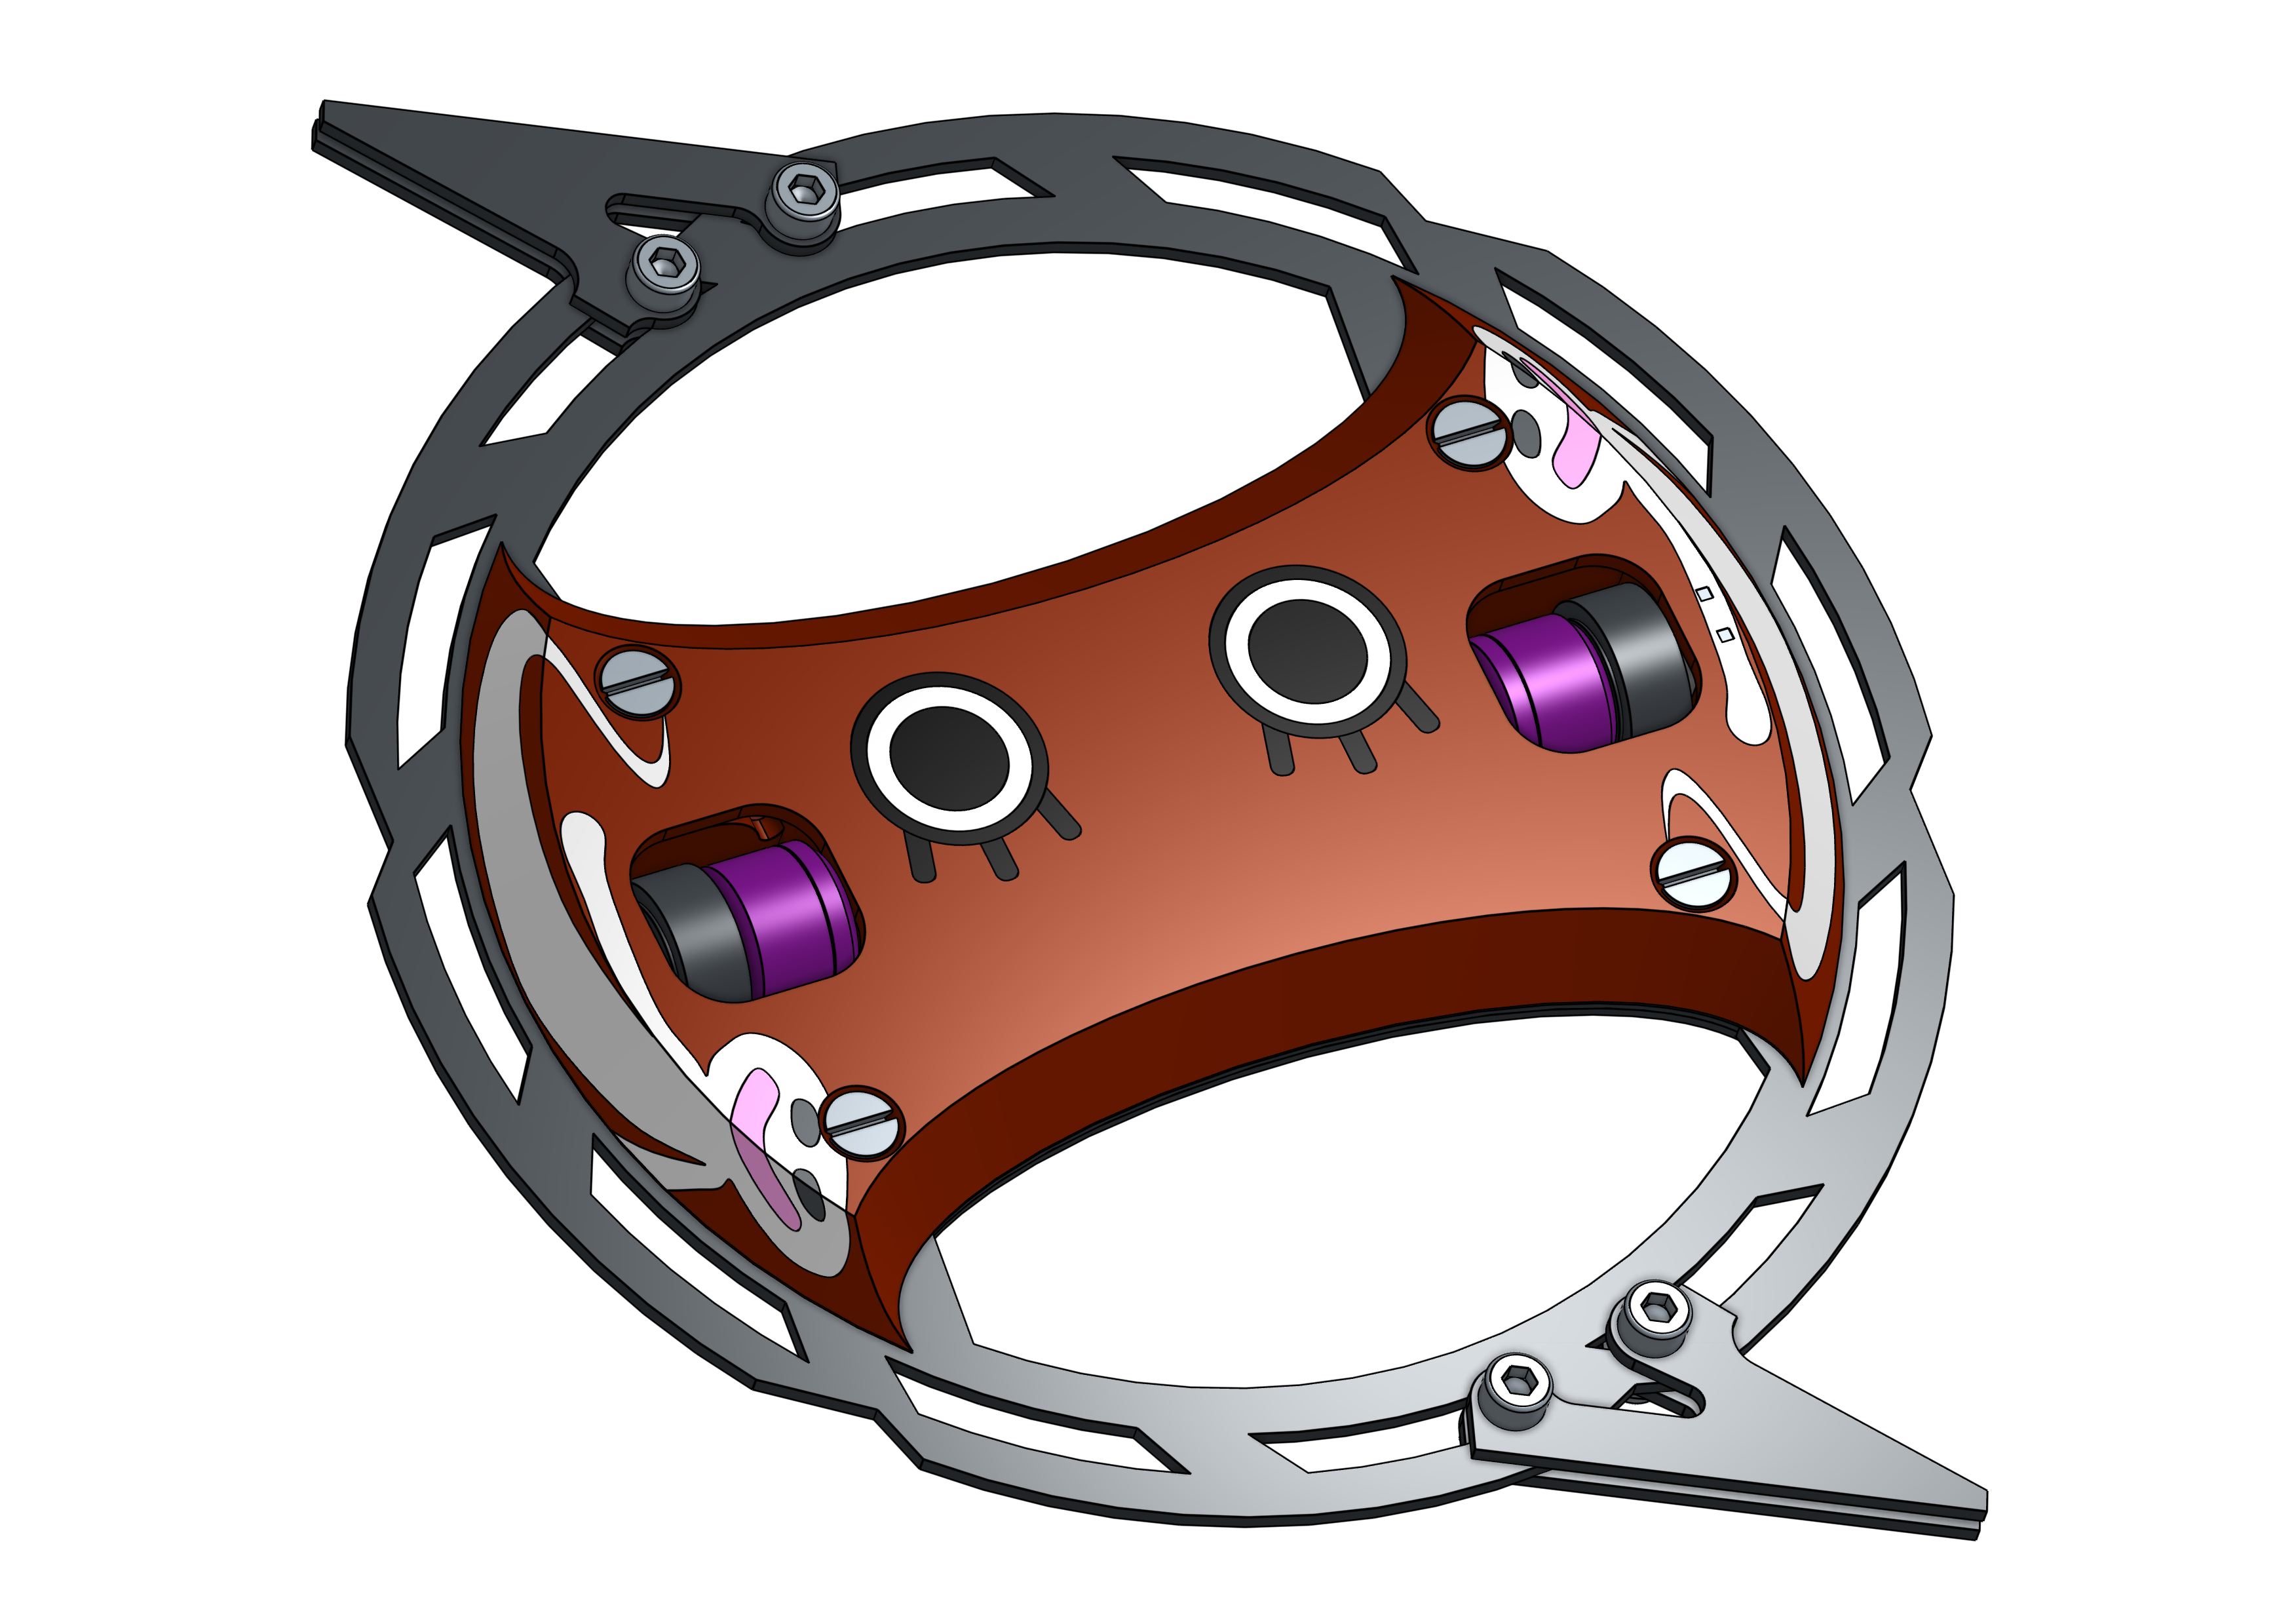
Este repositorio documenta el desarrollo de un robot de combate tipo MeltyBrain de 1lb (~454 g).
A rasgos generales, el robot está girando sobre si mismo constantemente a alta velocidad, y el acelerómetro mide las Gs de giro para determinar las RPM del robot. A partir de las RPM se obtiene un tiempo por giro promedio y se encienden los LEDs en el momento correcto para indicar la parte frontal del robot (gracias al efecto de Persisistencia de la visión). De la misma forma, aumentando la velocidad de los motores en el momento correcto, se consigue que el robot se desplace en la dirección deseada.
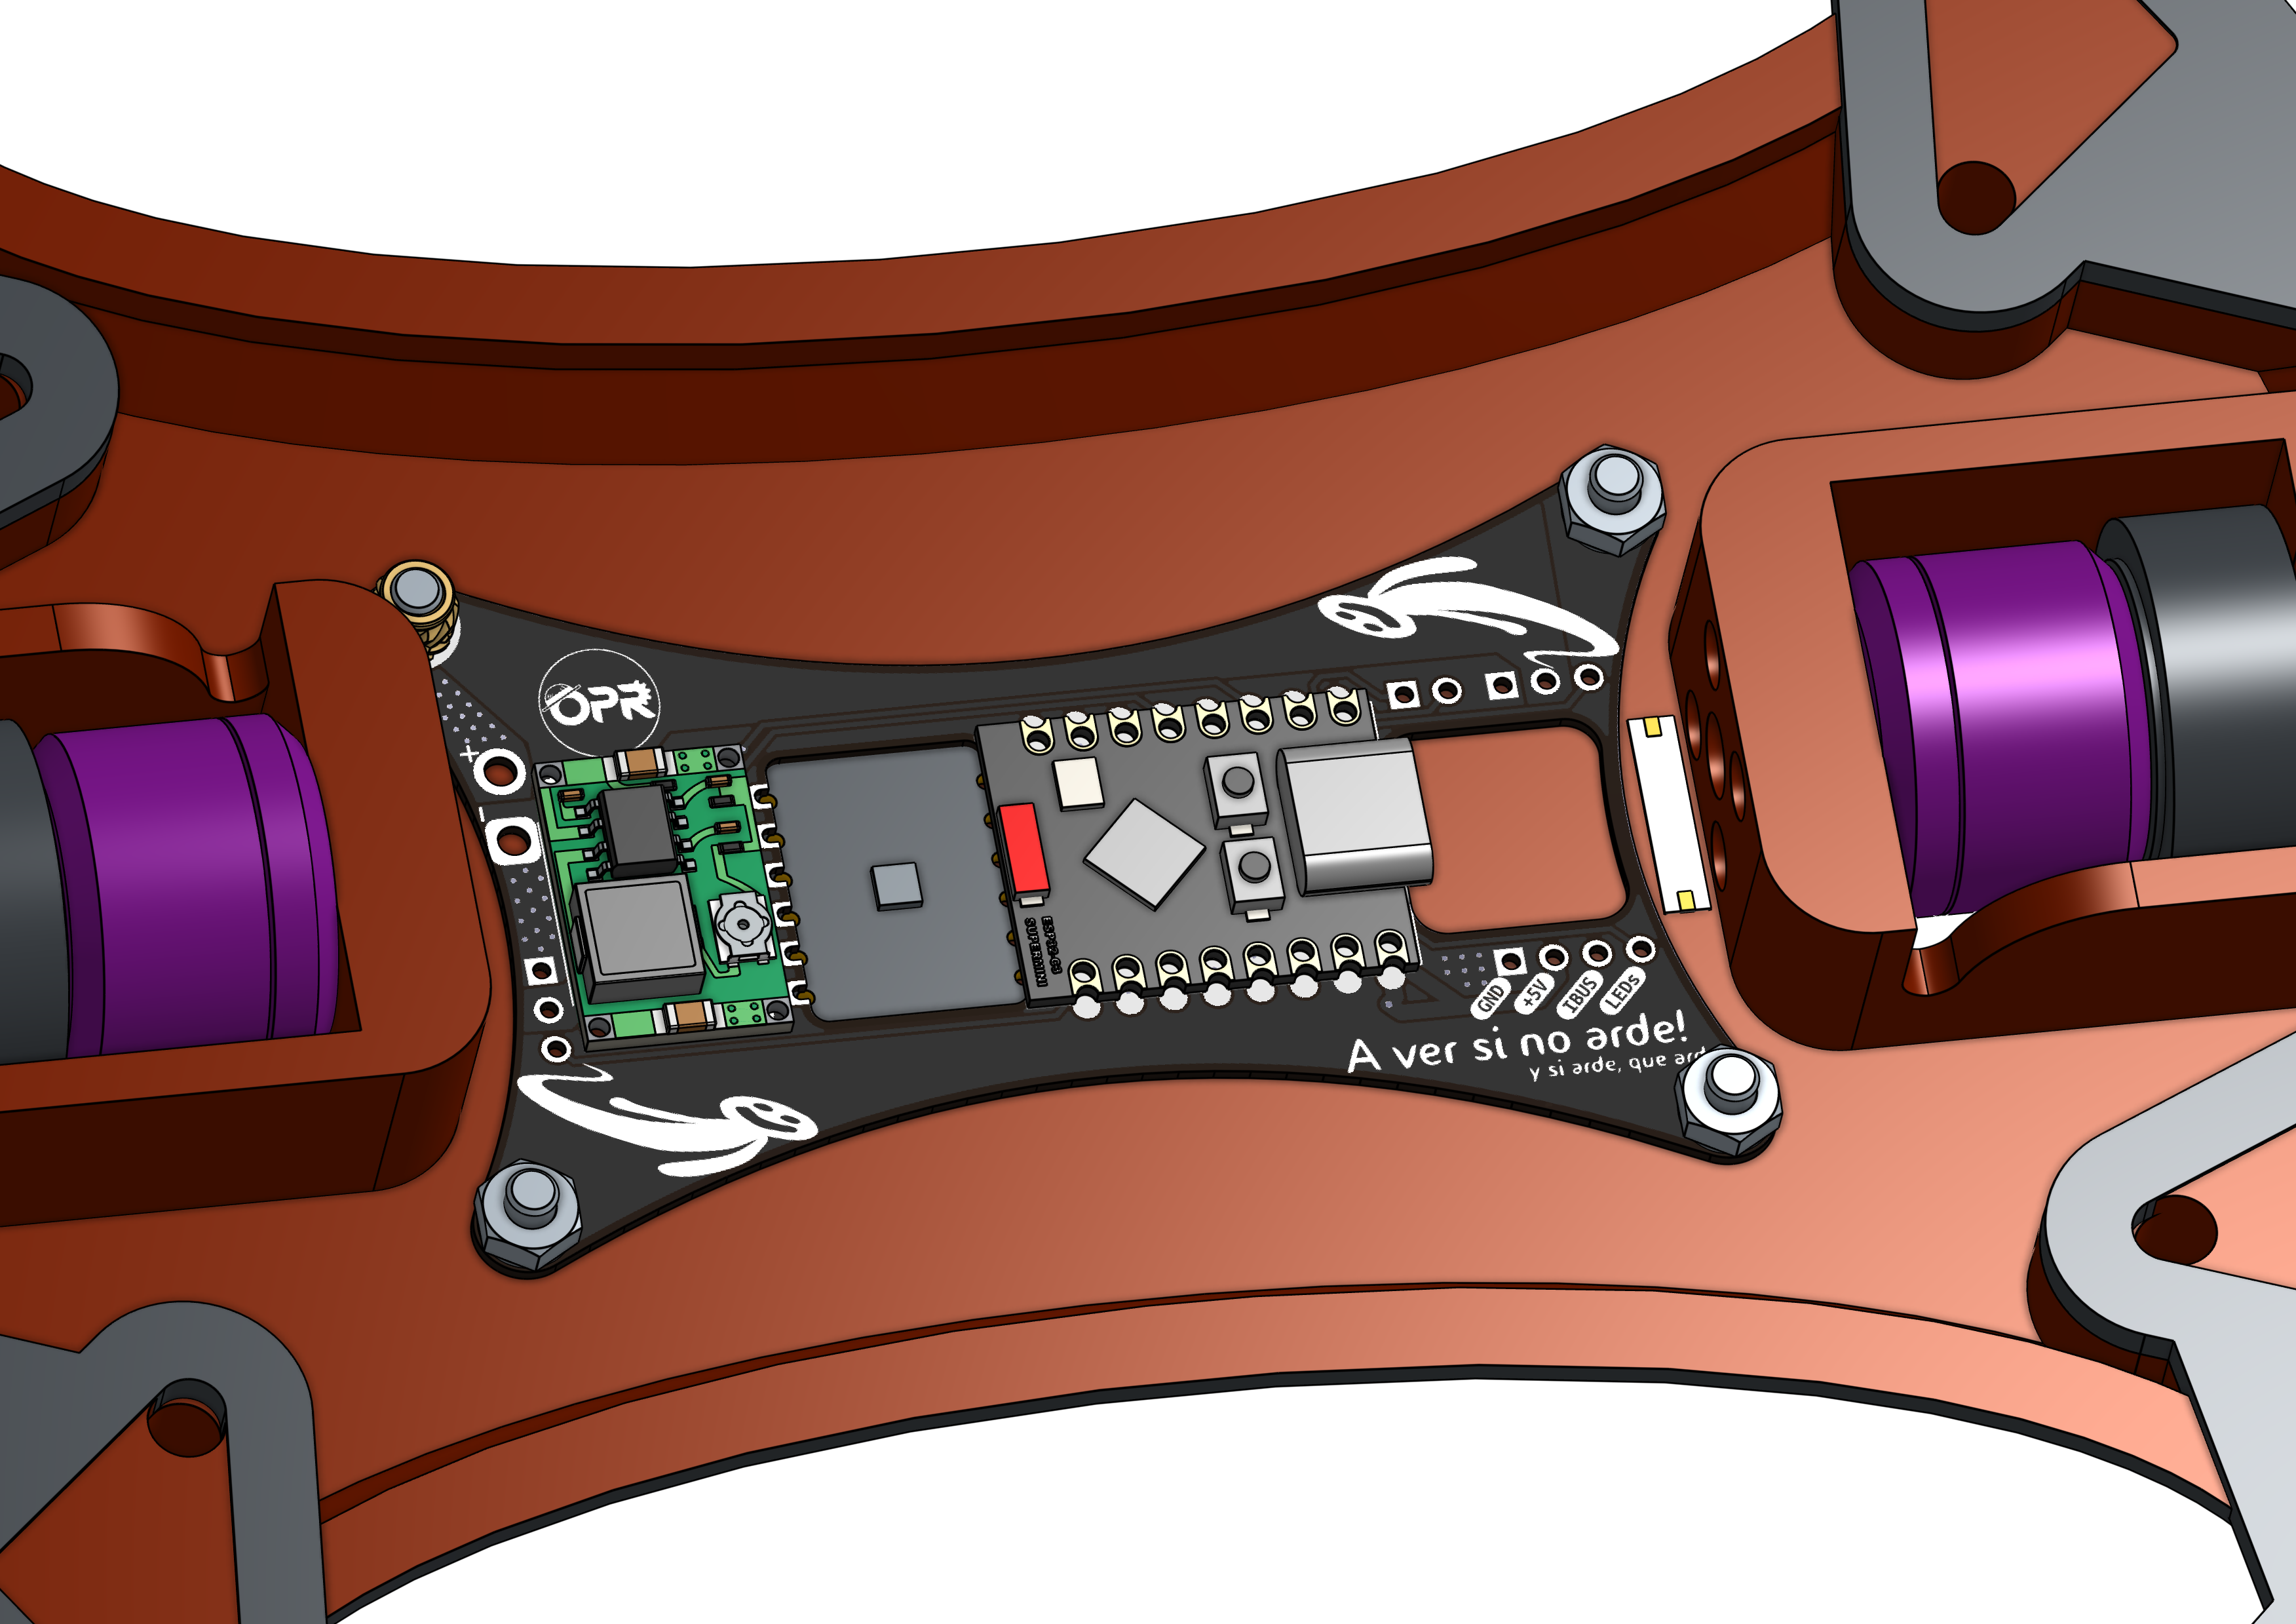
| Qty | Value | Footprint | References |
|---|---|---|---|
| 5 | LOGO | LOGO | G***, G***, G***, G***, G*** |
| 2 | Conn_01x03_Socket | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J4, J7 |
| 2 | G*** | kibuzzard-68B1DBB9 | kibuzzard-68B1DBB9, kibuzzard-68B1DBB9 |
| 2 | G*** | kibuzzard-68B1DBCB | kibuzzard-68B1DBCB, kibuzzard-68B1DBCB |
| 1 | Conn_01x02_Pin | custom_footprints:XT30 connector | J5 |
| 1 | Conn_01x02_Pin | custom_footprints:Switch_combat_robot_M3 | JINTERRUPTOR1 |
| 1 | Conn_01x02_Socket | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J3 |
| 1 | Conn_01x04_Socket | Connector_PinSocket_2.54mm:PinSocket_1x04_P2.54mm_Vertical | J6 |
| 1 | G*** | kibuzzard-68B1DEE5 | kibuzzard-68B1DEE5 |
| 1 | G*** | kibuzzard-68B1DF0B | kibuzzard-68B1DF0B |
| 1 | G*** | kibuzzard-68B1DBF2 | kibuzzard-68B1DBF2 |
| 1 | G*** | kibuzzard-68B1DED3 | kibuzzard-68B1DED3 |
| 1 | G*** | kibuzzard-68B1DEF2 | kibuzzard-68B1DEF2 |
| 1 | G*** | kibuzzard-68B1DE26 | kibuzzard-68B1DE26 |
| 1 | G*** | kibuzzard-68B1DE3F | kibuzzard-68B1DE3F |
| 1 | G*** | kibuzzard-68B1DC00 | kibuzzard-68B1DC00 |
| 1 | ~ | custom_footprints:H3LIS1_high-g | H3LIS1 |
| 1 | ~ | custom_footprints:Mini360 | DC-DC_5V1 |
| 1 | ~ | custom_footprints:ESP32_supermini | ESP1 |
It measures 75.2 × 44.3 mm and has 2 copper layers, 0.79 mm thick.
26 parts. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the OPRobots/PeronaBot repository on GitHub, at the commit this page was made from: the board is pcb_files/kicad_project/PeronaBot.kicad_pcb and its schematic pcb_files/kicad_project/PeronaBot.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the GPL-3.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).

hackclub/OnBoard
💡 Join 1,000 teenagers and make your first PCB with a $100 grant!


harbaum/galagino
A Galaga, Pac-Man and Donkey Kong arcade emulator for the ESP32

Luos-io/luos_engine
Open-source and real-time orchestrator for cyber-physical-systems, to easily design, test and deploy embedded applications and digital twins.

google/walt
A device for measuring latency of physical sensors and outputs on phones and computers
