

2 layers99.5 × 99.5 mm
SchematicKiCadProyect
dduarteCE/Robot-vacuum
Embedded Linux robotic vacuum system built with Yocto on Raspberry Pi 4, featuring autonomous navigation, audio playback, and remote control through a web interface.
42 parts1MIT

 omersoner-dev/SPECTRODRIVE
Light-following robot with PCB design, sensor integration, and Bluetooth control
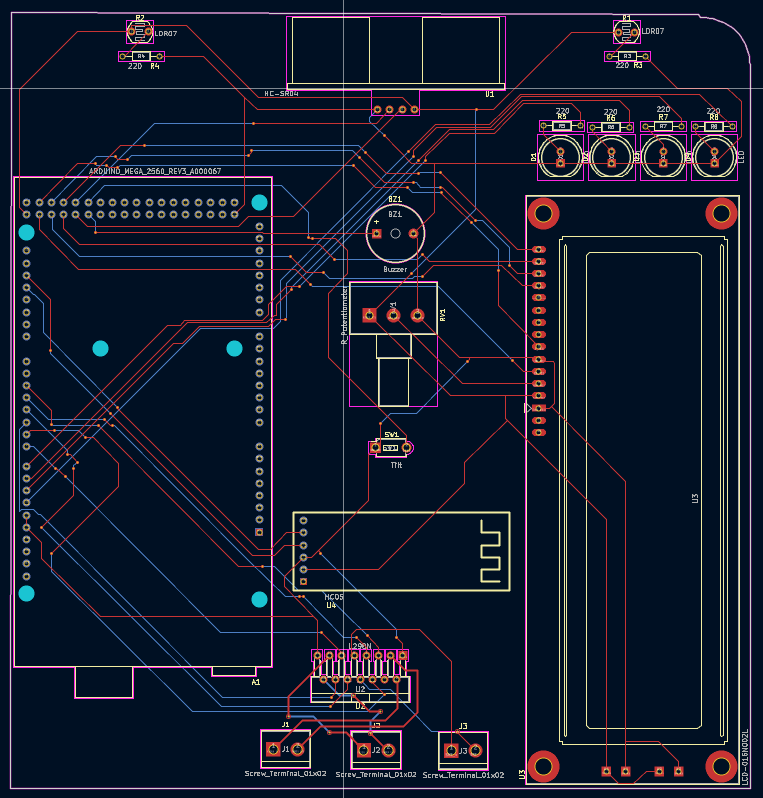
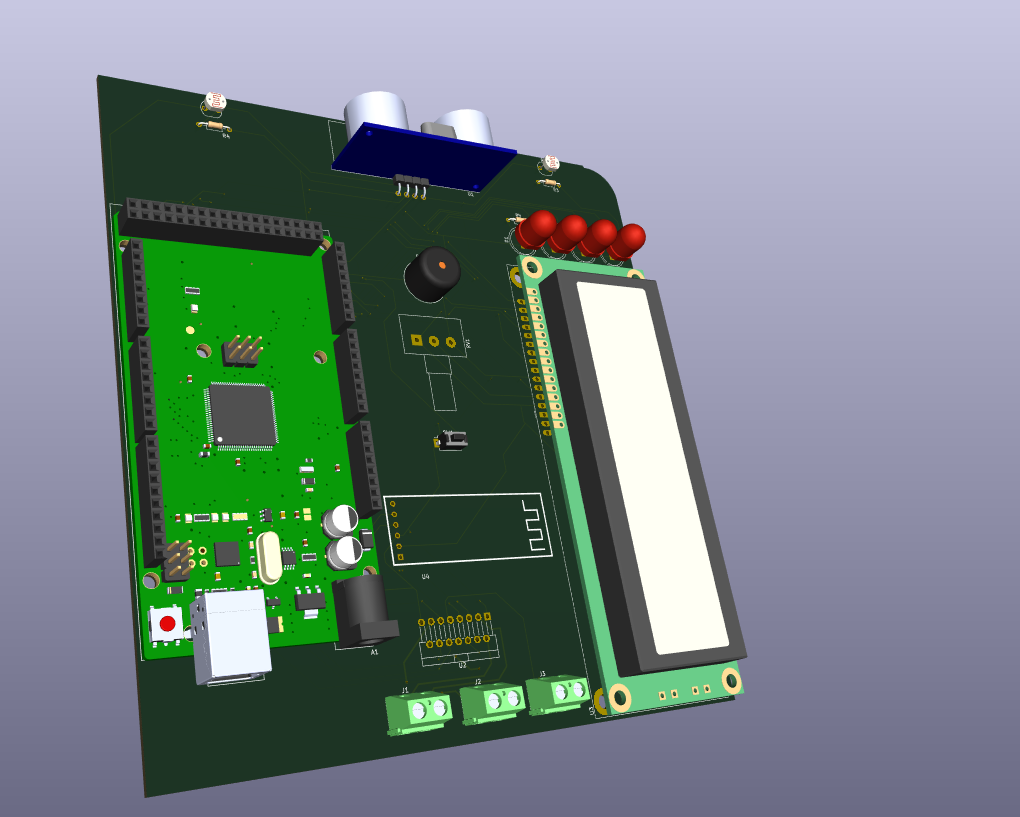
SPECTRODRIVE CİRCUİT is an open-source printed circuit board by omersoner-dev, from the omersoner-dev/SPECTRODRIVE repository on GitHub. It is a 2-layer board of 153.5 × 161.3 mm with 23 parts on 106 nets, routed with 418 tracks and 80 vias.
It is built around the L298N and HC-SR04. Its parts include 8 resistors, 4 ICs, 4 diodes, 3 connectors and 1 switch. It belongs with the robots and motor control and radio and wireless boards and the AVR (ATmega, ATtiny) boards of this library.
SpectroDrive is a multi-functional embedded robotics project integrating sensing, control, and wireless communication into a compact system.
This robot is capable of:
Firmware/
 └── Arduino/
      └── Spectrodrive.ino

Software/
 └── MobileApp/apk/
      └── Spectrodrive.apk

hardware/
 ├── BOM/
 ├── PCB/
 ├── schematic/
└── images/Full hardware design including schematic, PCB, and BOM:
Arduino-based embedded control system:
Bluetooth-based control interface:
Developed to gain hands-on experience in:
Electrical & Electronics Engineering student focused on embedded systems and robotics.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 6 | 220 | Resistor_THT:R_Axial_DIN0204_L3.6mm_D1.6mm_P7.62mm_Horizontal | R3, R4, R5, R6, R7, R8 |
| 4 | LED | LED_THT:LED_D8.0mm | D1, D2, D3, D4 |
| 3 | Screw_Terminal_01x02 | MyLibrary:TerminalBlock_bornier-2_P5.08mm | J1, J2, J3 |
| 2 | LDR07 | OptoDevice:R_LDR_5.1x4.3mm_P3.4mm_Vertical | R1, R2 |
| 1 | ARDUINO_MEGA_2560_REV3_A000067 | MyLibrary:ARDUINO_ARDUINO_MEGA_2560_REV3_A000067 | A1 |
| 1 | Buzzer | Buzzer_Beeper:Buzzer_12x9.5RM7.6 | BZ1 |
| 1 | HC-SR04 | MyLibrary:XCVR_HC-SR04 | U1 |
| 1 | HC05 | MyLibrary:HC05 | U4 |
| 1 | L298N | Package_TO_SOT_THT:TO-220-15_P2.54x5.08mm_StaggerOdd_Lead4.58mm_Vertical | U2 |
| 1 | LCD-016N002L | Display:LCD-016N002L | U3 |
| 1 | R_Potentiometer | Potentiometer_THT:Potentiometer_Alps_RK163_Single_Horizontal | RV1 |
| 1 | Tilt | Button_Switch_THT:SW_PUSH_1P1T_6x3.5mm_H5.0_APEM_MJTP1250 | SW1 |
It measures 153.5 × 161.3 mm and has 2 copper layers, 1.6 mm thick.
23 parts, built around the L298N and HC-SR04. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the omersoner-dev/SPECTRODRIVE repository on GitHub, at the commit this page was made from: the board is hardware/PCB/SPECTRODRIVE CİRCUİT.kicad_pcb and its schematic hardware/schematic/SPECTRODRIVE CİRCUİT.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask omersoner-dev before reusing the design.
dduarteCE/Robot-vacuum
Embedded Linux robotic vacuum system built with Yocto on Raspberry Pi 4, featuring autonomous navigation, audio playback, and remote control through a web interface.

Mohamed-Adel-ELshiemy/PCB
DC motor PCB Design with all files needed and make my foot print from scratch

ErickMorales1312/Proyecto-IMTC
IoT project for Autonomous Firefighting and Fire Detection System


pedro-ibs/trekking
Desenvolvimento de um robô rádio-controlado/autônomo da moralidade “tracker”

FabioNMI/C64PSU
A low-cost, lightweight and very reliable power supply for the Commodore 64

Khuzhin06/RoboForce
Тогда вы не зря зашли к нам, мы постараемся максимально подробно и быстро рассказать о нашем пути создания робота на ROS2 Jazzy и esp32,по этим материалам вы с легкостью сможете повторить этот проект.
