2 layers29.5 × 70.5 mm
Key fob pcb
BenMartens15/reviveride-key-fob-pcb
This repo contains the schematic and PCB for the key fob. The firmware for the key fob can be found here: https://github.com/BenMartens15/reviveride-key-fob-firmware
27 parts1

 NyanCat42/torque_sensor_controller
This repository contains hardware and firmware for an ESP32-S3 based torque sensor controller that talks to a VESC over CAN bus.
Lauryno torque controller is an open-source printed circuit board by NyanCat42, from the NyanCat42/torque_sensor_controller repository on GitHub. It is a 2-layer board of 52.7 × 40 mm with 35 parts on 54 nets, routed with 200 tracks and 48 vias.
It is built around the ESP32-S3-WROOM-1-N8, TJA1051T/3/1 and IRLML2502TRPBF, with the FM24CL16B-G among its other parts. Its parts include 13 resistors, 6 capacitors and 2 transistors. It belongs with the ESP32 boards of this library.


This repository contains hardware and firmware for an ESP32-S3 based torque sensor controller that talks to a VESC over CAN bus.
The controller reads bottom bracket torque and cadence, computes an assist current target, and sends motor current commands to the VESC. It also tracks odometer data with FRAM-backed persistence and exposes a local web UI for status, tuning, and OTA firmware updates.
lauryno_torque_controller_hardware/: KiCad schematic, PCB, and BOM.lauryno_torque_controller_software/: PlatformIO firmware project.documents/: reference documents, including torque sensor datasheet.images/: board render and finished board photo.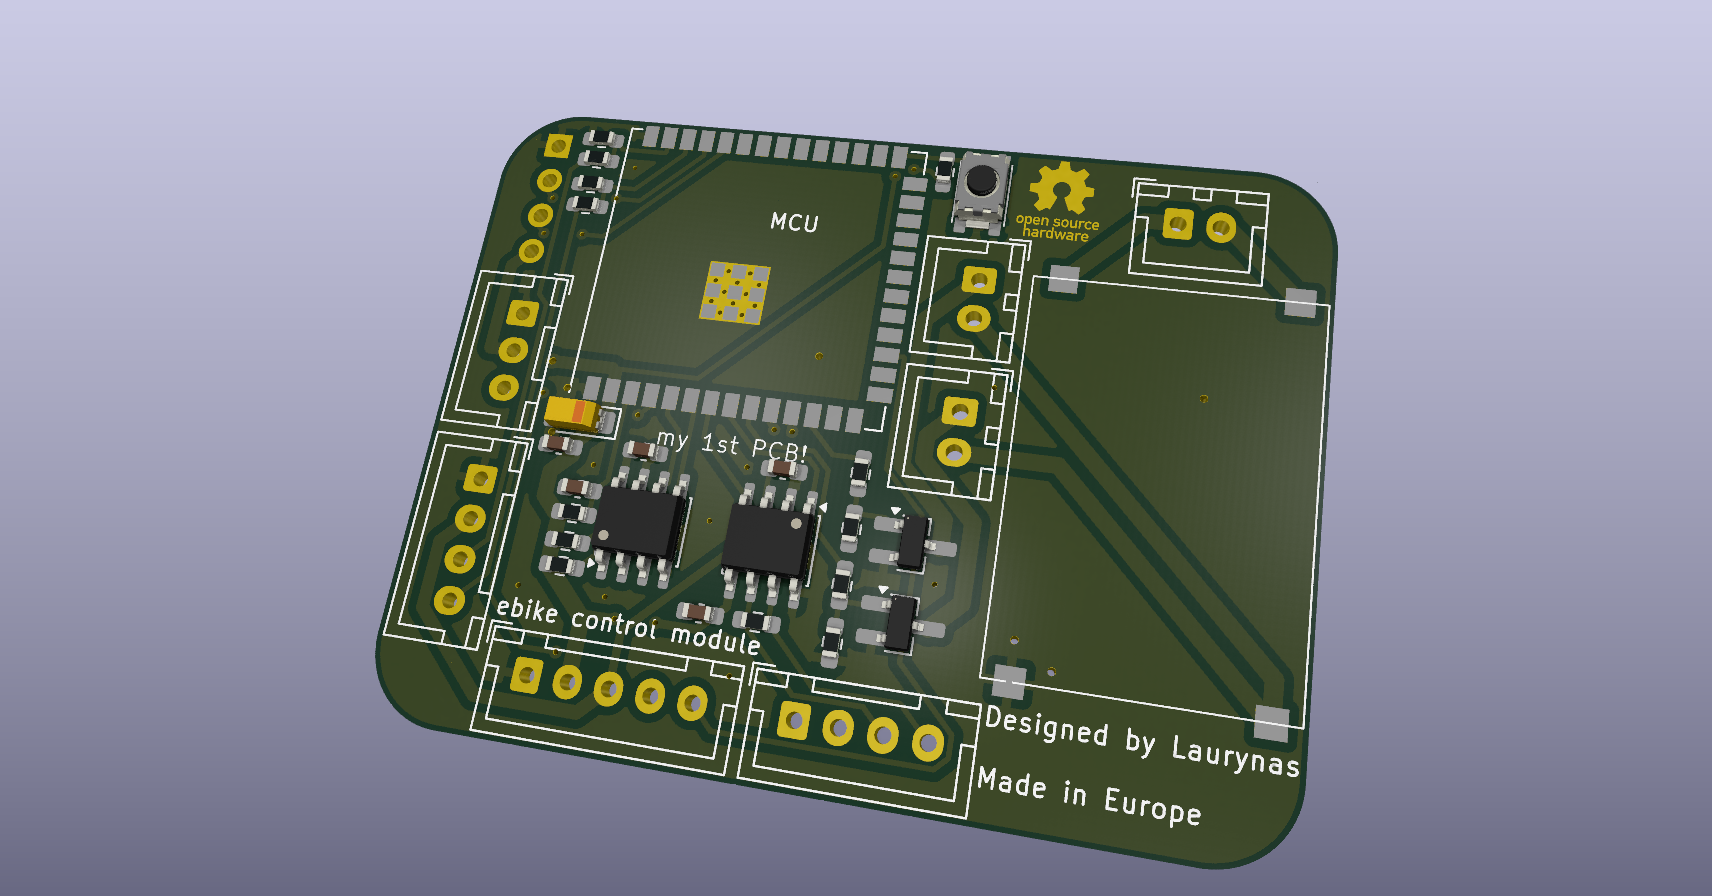
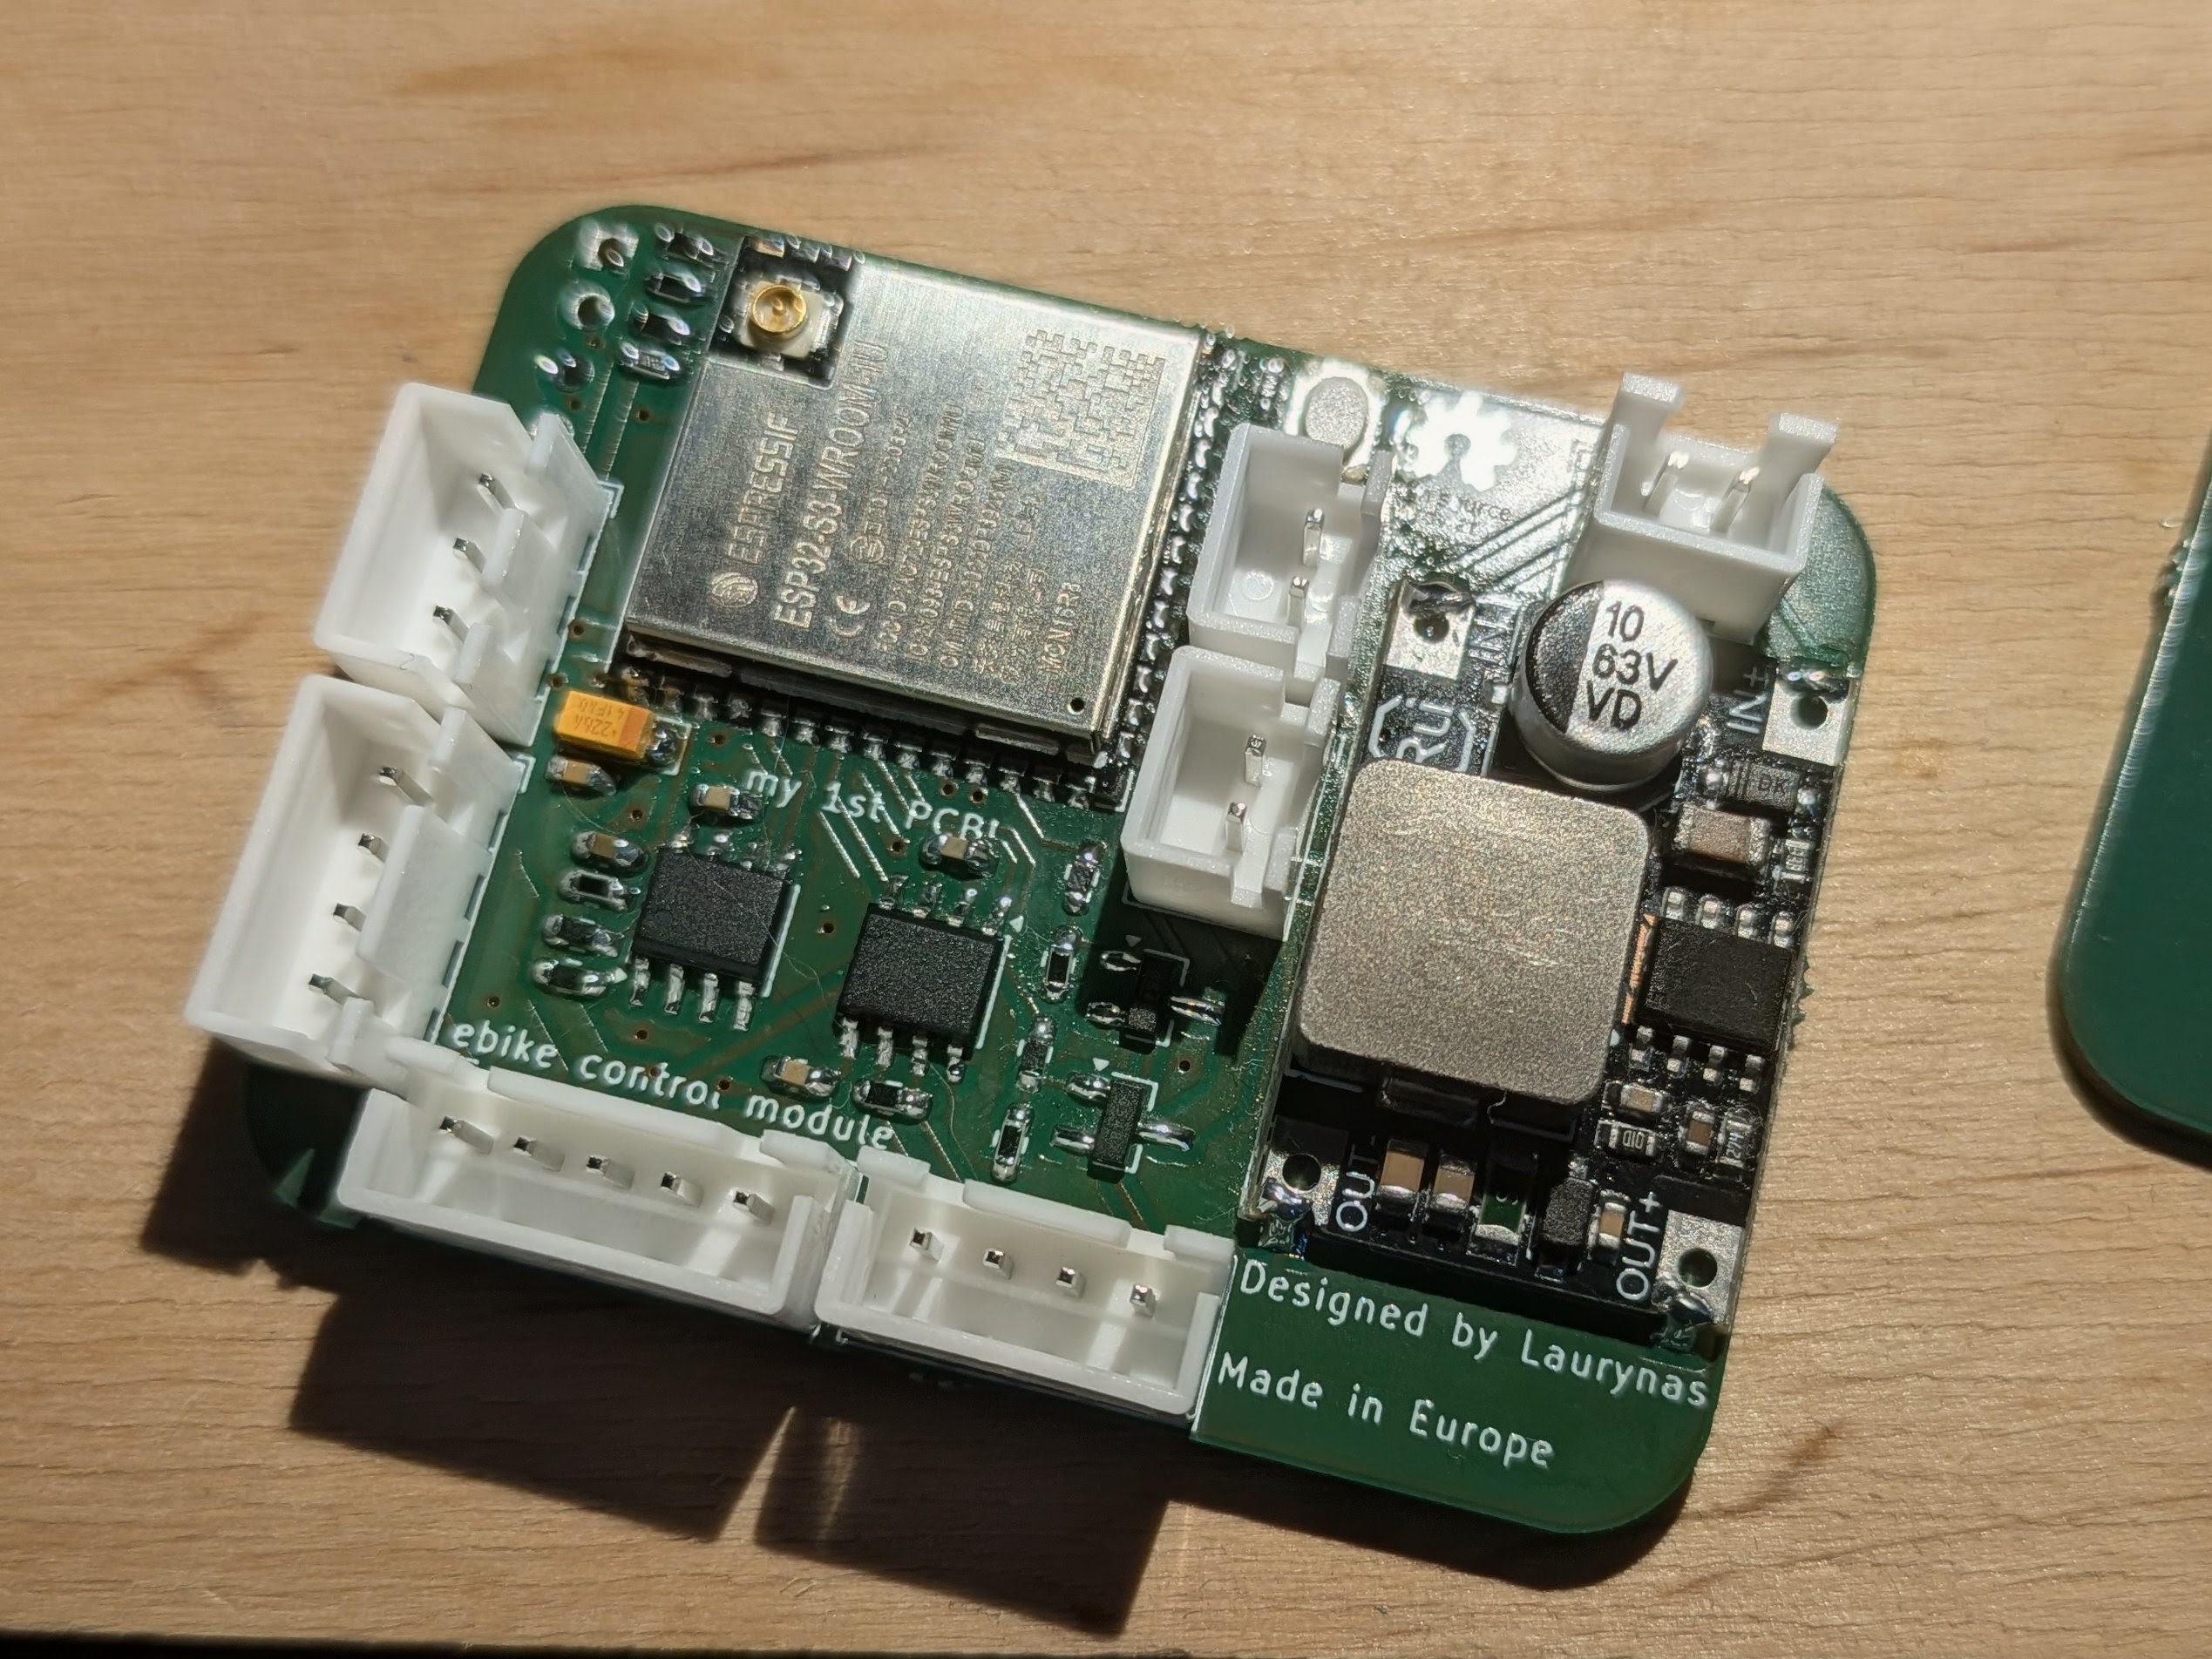
Hardware highlights:
The PCB was designed to fit AISLER simple 2-layer constraints for low-cost fabrication.
Available hardware design artifacts:
Main runtime modules:
PedalAssistManager: torque/cadence processing and motor current command generation.VescCan: CAN transport and VESC status/current command handling.OdometerManager: wheel pulse tracking, speed estimation, and persistence.FramStorage: I2C FRAM read/write backend.NetworkManager: station connect with timeout and fallback AP startup.OtaHttpServer: web UI, REST endpoints, and OTA upload flow.VescTcpBridge: optional TCP bridge (disabled by default).Task model:
First flash has to be done over UART, later ones can be done OTA.
lauryno_torque_controller_software/.platformio.secrets.ini (this file is git-ignored):[env:esp32-s3-devkitc-1]
build_flags =
-DWIFI_STA_SSID=\"YOUR_WIFI_SSID\"
-DWIFI_STA_PASSWORD=\"YOUR_WIFI_PASSWORD\"pio run -e esp32-s3-devkitc-1pio run -e esp32-s3-devkitc-1 -t uploadTorqueCtrl-Setup-<chipid>.lauryno-dviratis.local.80.65102 (can be toggled from API/UI).POST /api/pedal/calibrate_zero.Firmware can be uploaded from the web UI or directly by HTTP multipart upload:
curl -F "file=@.pio/build/esp32-s3-devkitc-1/firmware.bin" http://lauryno-dviratis.local/api/updateAfter a successful upload, the controller restarts automatically.
Hardware pins:
0x50.VESC IDs:
42, target controller 69 (make sure this matches the CAN ID of your VESC).See lauryno_torque_controller_software/include/app_config.h for the full set of constants and limits.
This project is licensed under CERN Open Hardware Licence Version 2 - Permissive (CERN-OHL-P-2.0).
See the repository LICENSE file for the project license notice and the official CERN-OHL-P v2 text reference.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 6 | 10k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R1, R4, R7, R8, R9, R12 |
| 4 | 0.1u | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C2, C4, C5, C6 |
| 3 | Conn_01x02_Socket | Connector_JST:JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | Battery1, LED1, LED2 |
| 2 | 15k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R10, R11 |
| 2 | 220 | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R5, R6 |
| 2 | 4.7k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R13, R14 |
| 2 | Conn_01x04_Socket | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | Torque_sensor1, VESC_coms1 |
| 2 | IRLML2502TRPBF | Package_TO_SOT_SMD:SOT-23_Handsoldering | Q1, Q2 |
| 1 | 120 | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R2 |
| 1 | 1u | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C3 |
| 1 | 22u | Capacitor_Tantalum_SMD:CP_EIA-3216-18_Kemet-A_HandSolder | C7 |
| 1 | Conn_01x03_Socket | Connector_JST:JST_XH_B3B-XH-A_1x03_P2.50mm_Vertical | Throttle1 |
| 1 | Conn_01x04_Pin | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | Chineesium_60V_to_12V1 |
| 1 | Conn_01x04_Socket | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | Flashing_UART1 |
| 1 | Conn_01x05_Socket | Connector_JST:JST_XH_B5B-XH-A_1x05_P2.50mm_Vertical | VESC1 |
| 1 | ESP32-S3-WROOM-1 | RF_Module:ESP32-S3-WROOM-1U | ESP32 |
| 1 | FM24CL16B | Package_SO:SOIC-8_3.9x4.9mm_P1.27mm | FRAM1 |
| 1 | LOGO | LOGO | G*** |
| 1 | SW_Push | Button_Switch_SMD:SW_Push_SPST_NO_Alps_SKRK | Boot1 |
| 1 | TJA1051T-3 | Package_SO:SOIC-8_3.9x4.9mm_P1.27mm | CAN_chip1 |
It measures 52.7 × 40 mm and has 2 copper layers, 1.58 mm thick.
35 parts, built around the ESP32-S3-WROOM-1-N8, TJA1051T/3/1, IRLML2502TRPBF and FM24CL16B-G. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the NyanCat42/torque_sensor_controller repository on GitHub, at the commit this page was made from: the board is lauryno_torque_controller_hardware/lauryno_torque_controller.kicad_pcb and its schematic lauryno_torque_controller_hardware/lauryno_torque_controller.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask NyanCat42 before reusing the design.
BenMartens15/reviveride-key-fob-pcb
This repo contains the schematic and PCB for the key fob. The firmware for the key fob can be found here: https://github.com/BenMartens15/reviveride-key-fob-firmware


romioRN/Dash6.8-hardware
wifi name "service", password 12345678, connect to 192.167.4.1

maximus64/opendiag-hardware
OpenDIAG - Open Source OBD2 Interface (Hardware)

Alex-C-EE/Reliable-Temp-Monitor
A CAN Node designed to take temperature measurement from 3 analog-output sensors and control 2x 24V fans

byui-formula-hybrid/legacy-Cooling-Pump-Board
BYUI Cooling pump CAN control board


milar111/HEAT
An open-source STM32 SMD assembly station for precision soldering. Uses a custom Smart Pulse & Coast algorithm to drive 400W mains heaters via SSR. Features OLED UI, NTC feedback, and safety cooling.