
2 layers70 × 73.1 mm
Neopico hd
fliperama86/neopico-hd
Digital video and audio capture with HDMI output for Neo Geo MVS arcade hardware using Raspberry Pi Pico 2
37 parts90Unlicense

 NeaveEng/nefive-motor-controller
A motor controller for NE-Five
Motor controller is an open-source printed circuit board by NeaveEng, from the NeaveEng/nefive-motor-controller repository on GitHub. It is a 2-layer board of 91.1 × 53 mm with 48 parts on 73 nets, routed with 369 tracks and 96 vias.
It is built around the SN74LVC2G14DBV. Its parts include 13 capacitors, 9 connectors, 8 ICs and 1 switch. It belongs with the robots and motor control boards and the RP2040 boards of this library.
This is the PCB that controls the wheels and linear actuator on NE-Five, it's a work in progress and used entirely at your own risk.
It uses a Pi Pico at its core with four IFX9201SG motor controllers, it has one servo header that includes an analogue feedback pin to control a linear actuator.
Many thanks to Mark Mellors, Phillip Skippy McGaw, and Robert Karpinski for incredibly useful feedback!
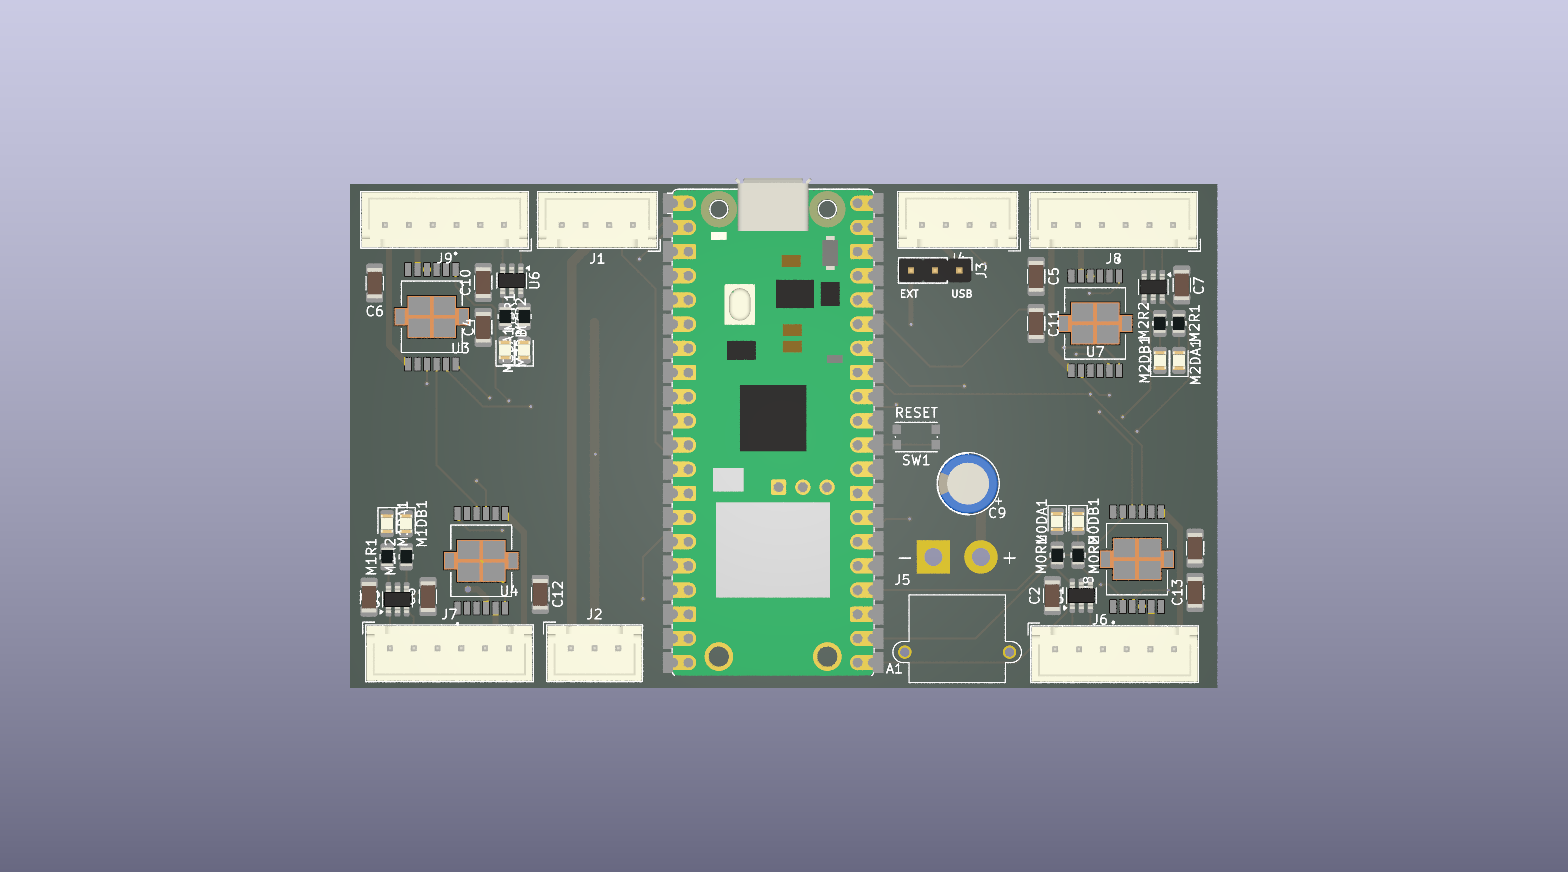
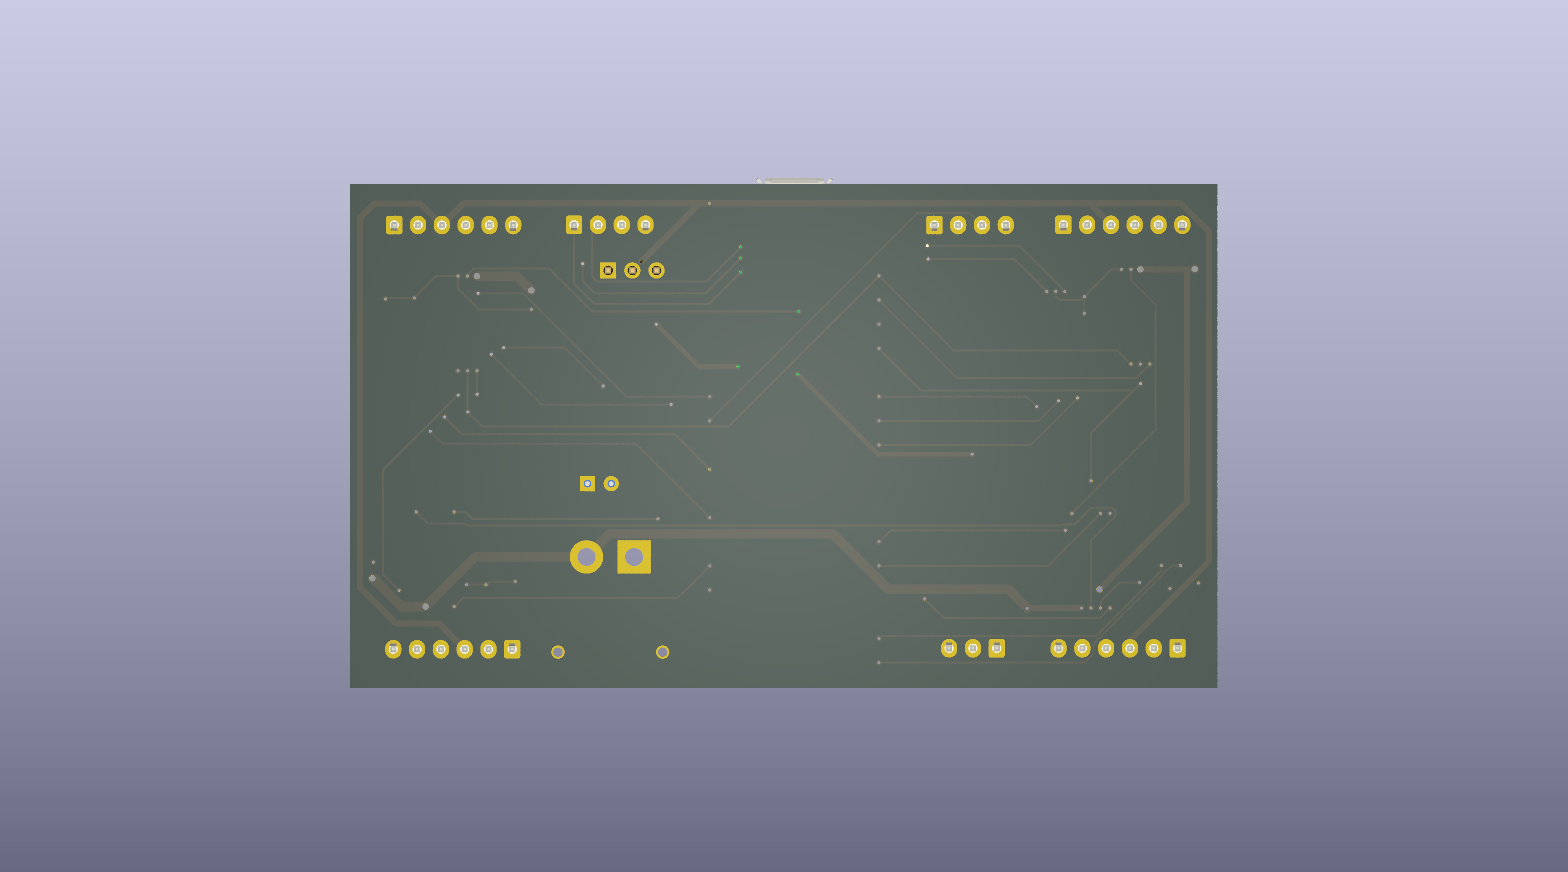
Using this github action
| Qty | Value | Footprint | References |
|---|---|---|---|
| 12 | 22n | Capacitor_SMD:C_1206_3216Metric | C1, C2, C3, C4, C5, C6, C7, C8, C10, C11, C12, C13 |
| 8 | LED | LED_SMD:LED_0805_2012Metric | M0DA1, M0DB1, M1DA1, M1DB1, M2DA1, M2DB1, M3DA1, M3DB1 |
| 8 | R_Small | Resistor_SMD:R_0805_2012Metric | M0R1, M0R2, M1R1, M1R2, M2R1, M2R2, M3R1, M3R2 |
| 4 | SN74LVC2G14 | Package_TO_SOT_SMD:SOT-23-6 | U1, U2, U5, U6 |
| 1 | 100uF | Capacitor_THT:CP_Radial_D6.3mm_P2.50mm | C9 |
| 1 | Ext Power | Connector_JST:JST_XH_B3B-XH-A_1x03_P2.50mm_Vertical | J2 |
| 1 | M0 | Connector_JST:JST_XH_B6B-XH-A_1x06_P2.50mm_Vertical | J6 |
| 1 | M0-IFX9201SG | 9201SG:PG_DSO_12_17 | U8 |
| 1 | M1 | Connector_JST:JST_XH_B6B-XH-A_1x06_P2.50mm_Vertical | J7 |
| 1 | M1-IFX9201SG | 9201SG:PG_DSO_12_17 | U4 |
| 1 | M2 | Connector_JST:JST_XH_B6B-XH-A_1x06_P2.50mm_Vertical | J8 |
| 1 | M2-IFX9201SG | 9201SG:PG_DSO_12_17 | U7 |
| 1 | M3 | Connector_JST:JST_XH_B6B-XH-A_1x06_P2.50mm_Vertical | J9 |
| 1 | M3-IFX9201SG | 9201SG:PG_DSO_12_17 | U3 |
| 1 | RESET | Button_Switch_SMD:SW_Push_1P1T_NO_CK_KMR2 | SW1 |
| 1 | RaspberryPi_Pico_W | Module_RaspberryPi_Pico:RaspberryPi_Pico_W_SMD | A1 |
| 1 | Servo Header | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J1 |
| 1 | USB Header | Connector_JST:JST_XH_B4B-XH-A_1x04_P2.50mm_Vertical | J4 |
| 1 | USB_PWR | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J3 |
| 1 | XT30 | Connector_AMASS:AMASS_XT30PW-M_1x02_P2.50mm_Horizontal | J5 |
It measures 91.1 × 53 mm and has 2 copper layers, 1.6 mm thick.
48 parts, built around the SN74LVC2G14DBV. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the NeaveEng/nefive-motor-controller repository on GitHub, at the commit this page was made from: the board is motor controller.kicad_pcb and its schematic motor controller.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask NeaveEng before reusing the design.
fliperama86/neopico-hd
Digital video and audio capture with HDMI output for Neo Geo MVS arcade hardware using Raspberry Pi Pico 2


maximus64/opendiag-hardware
OpenDIAG - Open Source OBD2 Interface (Hardware)

mpiraux/OpenTRV-ESP
An open-source and open-hardware thermostatic radiator valve based on the ESP32C6 and the 28BYJ-48 stepper motor.

offmor/RoboTheater
Code, hardware designs, and documentation for RoboTheater: A tabletop multi-robot platform that translates LLM-generated scripts into robot motion and multimedia output.

axpaul/KinetiCoreDC
Compact STM32G0-based DC motor controller board featuring TI DRV8874 H-bridge drivers, RS485 communication, optoisolated I/O, and hardware power protection.

