6 layers100 × 62 mm

 naizhao/Pilot-Kit-Box-ESP32-P411
Pilot Kit Box (ESP32-P4 Edition)
Expansion board v4 is an open-source printed circuit board by naizhao, from the naizhao/Pilot-Kit-Box-ESP32-P4 repository on GitHub, published under the MIT licence. It is a 6-layer board of 100 × 62 mm with 235 parts on 266 nets, routed with 1,952 tracks and 506 vias.
It is built around the XA17-G4K, AD8313ARMZ and ATGM336H-6N-74, with the BGA2817, BMP388 and TPS7A2033PDBVR-TP among its other parts. Its parts include 97 capacitors, 58 resistors, 14 inductors, 11 ICs and 9 diodes.


开源低成本飞行数据盒子与态势感知设备 | Open-source low-cost flight data box and situational-awareness device
官方网站 / Official website: air.club
网页刷机 / Web flasher: updater.pilotkit.app

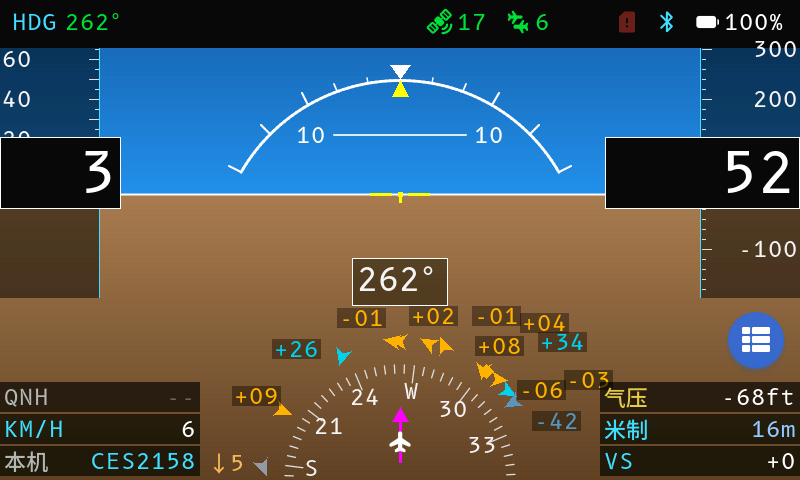
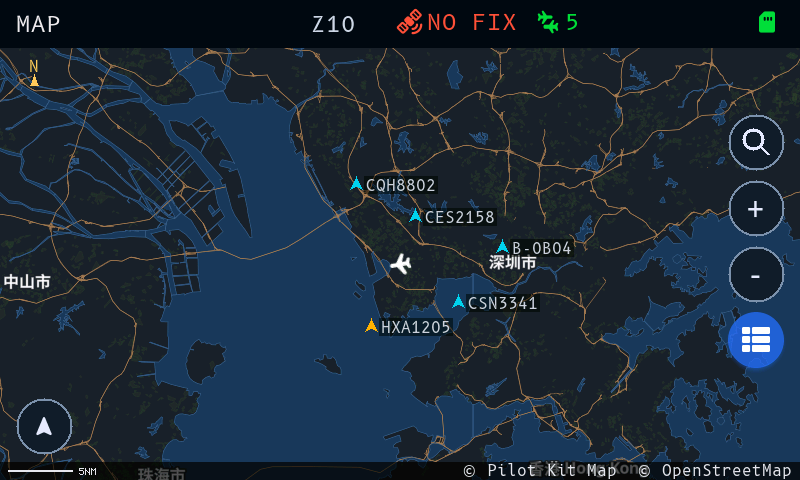
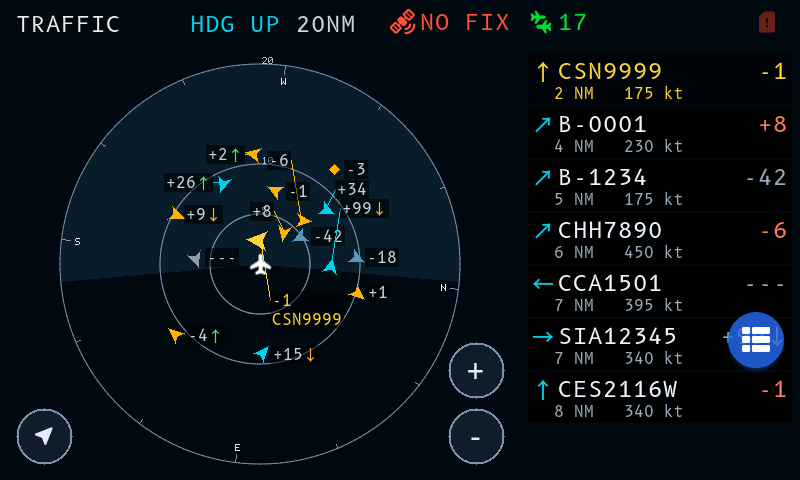
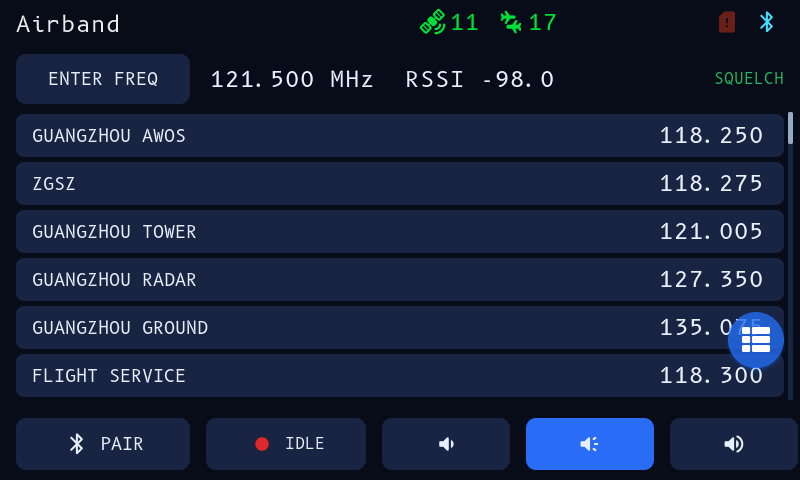
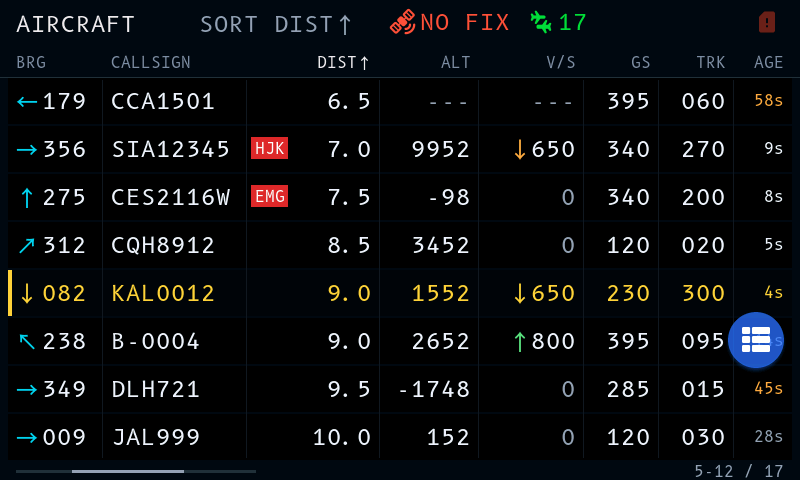
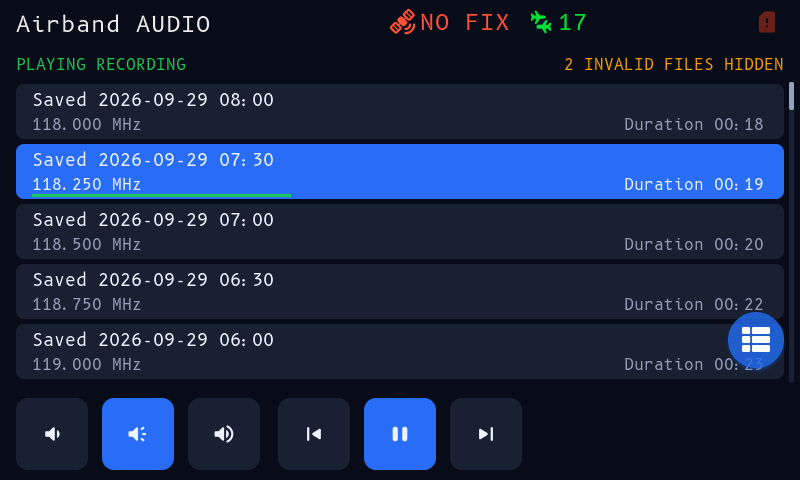
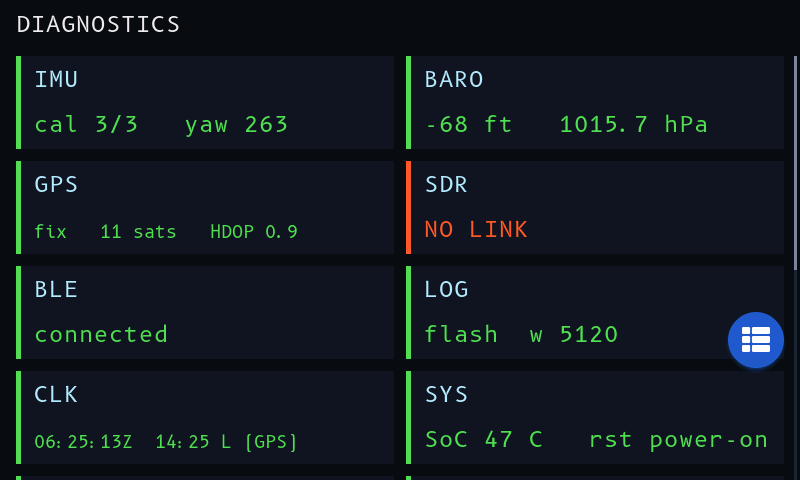
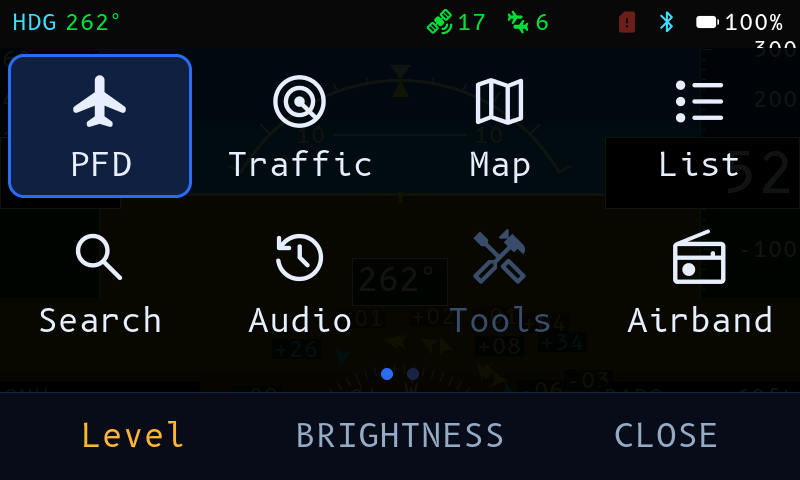
一块扩展板,一整套航空电子:G1000 风格 PFD、360° 交通雷达、离线 航空地图(机场/导航台/FIX 叠加层)、航空电台收听与录音回放——中英 双语,无需联网;GDL90 数据经蓝牙与 Wi-Fi 对外输出,手机/EFB 无线直连。 One expansion board, a full avionics suite: a G1000-style PFD, a 360° traffic radar, an offline aviation map (airports / navaids / fixes), and an airband radio with recording playback — bilingual, offline, with GDL90 out over both Bluetooth and Wi-Fi for phones and EFBs.
⚠️ 免责声明 / Disclaimer
本设备及其固件为辅助信息工具,未取得任何适航认证,不得用作主用或备用 导航设备,也不得用于正式的飞行活动。所显示的位置、高度、航向、交通、 导航台和气象等信息可能延迟、错误或缺失,且随时可能中断。一切飞行决策必须 以认证机载设备、官方航图与空管指令为准。使用者自行承担全部风险。
This device and its firmware are an auxiliary information tool only. They are not airworthiness certified and must not be used as a primary or backup navigation source, nor in any operational flight activity. Position, altitude, heading, traffic, navaid and weather information may be delayed, incorrect, or missing, and may stop without warning. All flight decisions must be based on certified avionics, official charts, and ATC instructions. Use entirely at your own risk.
分支
v4。 主机是 Waveshare ESP32-P4-WIFI6-Touch-LCD-4.3 一体板: ST7701 480×800 MIPI-DSI 面板以 PPA 旋转成 800×480 横屏,GT911 触摸, P4NRW32 + ESP32-C6。硬件目标是hardware/expansion-board-v4/的 6 层集成 扩展板——以 HAT 方式直插载板 2×20 排母,把 1090/978 接收链、GNSS、IMU、 气压计和电源整合到一块板上,自带 1090 接收链,不再需要 RTL-SDR dongle。 每个硬件版本一个分支;docs/jlc/lcd-2.4in-8pin/与下文 2.4 寸载板内容 保留为 v0.8.0 历史 PCB 参考,不代表本分支的当前接线。Branch
v4. Host board: Waveshare ESP32-P4-WIFI6-Touch-LCD-4.3. The hardware target is the 6-layer integrated expansion board inhardware/expansion-board-v4/, which stacks onto the carrier's 2×20 header and folds the 1090/978 receive chains, GNSS, IMU, barometer, and power onto one board — no RTL-SDR dongle required. One branch per hardware revision.
项目包含**硬件(扩展板)与软件(固件)**两条相互独立的版本线:
v1 → v2 → v3 → v4,每代一个分支;v0.5.0 / v0.6.0 / v0.8.0(见 Releases),
在任何硬件分支上发布,与板代无关。The project has two independent version lines: the hardware (expansion
boards) evolves through branches v1 → v2 → v3 → v4 (one branch per
board generation), while the firmware releases via tags v0.5.0 /
v0.6.0 / v0.8.0 (see Releases), cut from whichever hardware branch.
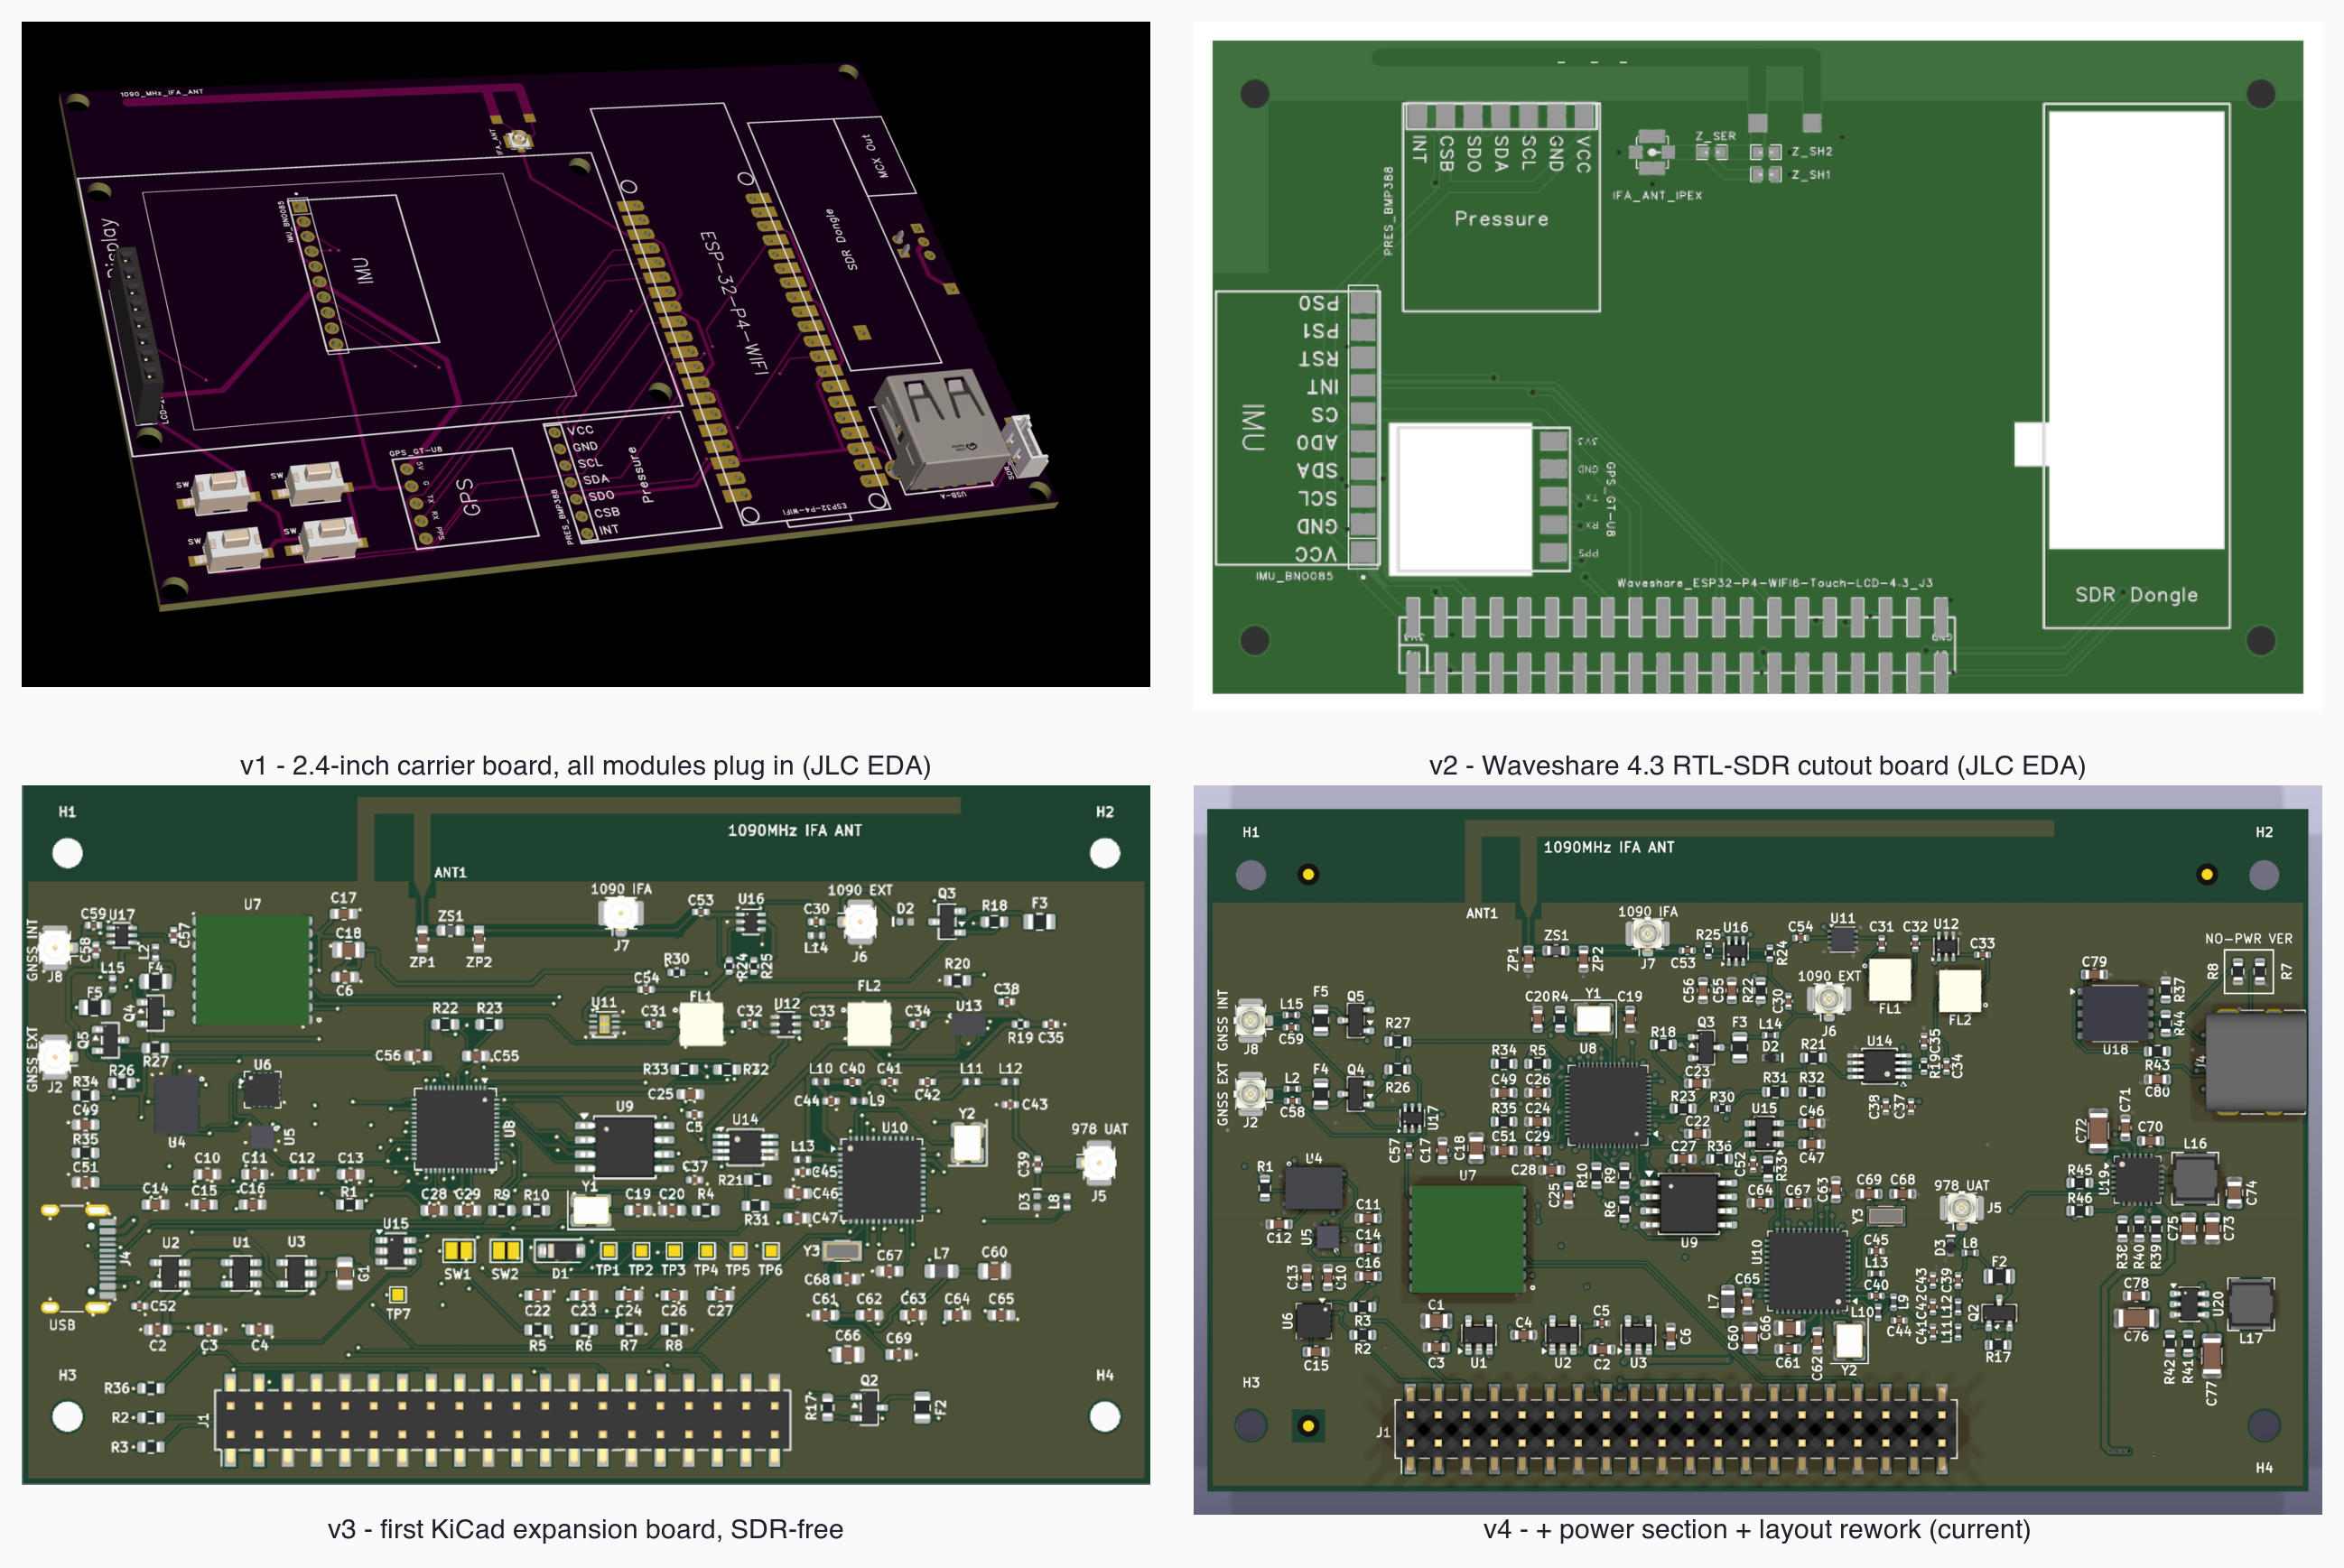
每个硬件版本一个分支,从旧到新 / One branch per hardware revision, oldest first:
| 分支 Branch | 板子 / Board | EDA | 说明 / Notes |
|---|---|---|---|
v1 | 2.4 寸大板:所有模块插在板上,含板载 1090 天线版 / 2.4-inch carrier, all modules plug in, on-board 1090 antenna revision | 嘉立创 EDA | 与 main 同源(v0.8.0 时代)/ same lineage as main (v0.8.0 era) |
v2 | 微雪 4.3 屏配套的 SDR RTL 镂空板 / RTL-SDR cutout board for the Waveshare 4.3 | 嘉立创 EDA | 归档:仅打样 Gerber + 说明,EDA 源不在 git / archive: fabrication Gerbers only, EDA sources not in git |
v3 | 脱离 SDR 的完整扩展板(KiCad、expansion-board 命名起点)/ SDR-free integrated expansion board (KiCad, where the expansion-board naming starts) | KiCad | 归档:只维护 v3 硬件,不携带 v4 / archived: v3 hardware only |
v4 | v3 + 电源部分 + 布局优化(当前硬件目标)/ v3 plus power section and layout rework (current target) | KiCad | 本分支 / this branch;公开区只留最终结果 / public tree keeps final results only |
Pilot Kit Box 是一个开源、低成本、便携式的飞行数据盒子和航空态势感知设备,可与 Pilot Kit 深度结合使用,也可以作为独立设备运行。
如果你熟悉 Stratux、Sentry、Garmin GDL 系列或 uAvionix ping 这类便携式 ADS-B / 飞行数据盒子,可以把 Pilot Kit Box 理解成一个更开放、更低成本、可自己搭建和二次开发的替代方案。它面向飞行员、飞行学员、飞行爱好者以及通航开发者,用常见硬件完成飞行记录、姿态显示、周边交通接收和后续数据分析。
它的核心价值不是单纯“看天上有哪些飞机”,而是帮助用户低成本记录、理解和管理自己的飞行数据。它可以随飞机一起使用,记录每一次飞行中的关键数据,用于飞行日志、回放、分享和分析;也可以接收附近飞机公开广播的 ADS-B / Mode-S 信号,在本机屏幕上显示周边交通信息。
你可以把它理解成一个“飞行员自己的小型数据记录与接收盒子”:它既能独立工作,也能和 Pilot Kit 紧密结合;并已支持通过标准航空数据格式(GDL90 over BLE)与 Garmin Pilot、ForeFlight 等第三方 EFB 软件配合使用。
Pilot Kit Box can work as a standalone device or integrate closely with Pilot Kit. If you know products such as Stratux, Sentry, Garmin GDL, or uAvionix ping, Pilot Kit Box is best understood as a more open, lower-cost, builder-friendly flight data and ADS-B box. It is intended for pilots, student pilots, aviation enthusiasts, and general-aviation developers who want local flight recording, attitude display, nearby traffic reception, and data they can later review or share.
The main point is not just watching aircraft overhead. Pilot Kit Box is meant to help users record, understand, and manage their own flying at a much lower cost. It can record each flight for logs, replay, sharing, and analysis; it can also receive public ADS-B / Mode-S broadcasts from nearby aircraft and show surrounding traffic on the built-in display.
Think of it as a pilot's own small flight data recorder and receiver: it can run independently, integrate tightly with Pilot Kit, and already speaks standard aviation data (GDL90 over BLE) for third-party EFB apps such as Garmin Pilot and ForeFlight.
Pilot Kit Box 的核心用途是:让普通飞行员、飞行学员和飞行爱好者,也能用较低成本拥有一个自己的飞行记录和态势感知盒子。
Pilot Kit Box is designed to give pilots, student pilots, and aviation enthusiasts an affordable personal flight recording and situational-awareness box.
市面上已经有 Stratux、Sentry、Garmin GDL、uAvionix ping 等便携式 ADS-B 接收器、飞行记录盒子和通航辅助设备,但很多产品要么价格较高,要么生态相对封闭,要么不方便用户理解、修改和扩展内部的数据链路。
Pilot Kit Box 想解决的是这个问题:
Portable ADS-B receivers and flight data boxes already exist, including Stratux, Sentry, Garmin GDL, and uAvionix ping. Many of them are effective products, but they can be expensive, relatively closed, or hard for users to inspect, modify, and extend.
Pilot Kit Box focuses on:
当前 ESP32-P4 版本把传统依赖 Linux 板卡的 ADS-B 接收链路压缩到单片机 + RTOS 架构。1090 MHz 接收由 v3/v4 扩展板完成:板载接收链(QPL9547 LNA + TA0970A SAW + AD8313 对数检波 + TLV3501 比较器)把脉冲馈给 RP2040,RP2040 以 PIO+DMA 捕获双沿、重建 56/112-bit Mode-S 帧,再经 921600 UART 送 ESP32-P4 做 CRC 过滤、CPR 定位融合、飞机状态聚合,并通过 BLE GATT、串口以及 LittleFS / MicroSD 文件输出给移动端或调试工具。(早期 v1/v2 载板走 P4 原生 USB 2.0 HS 驱动 RTL-SDR dongle 的路径已退役,固件与组件树均不再包含该代码。)
The ESP32-P4 edition removes the Linux SBC from the ADS-B path. The 1090 MHz receive chain lives on the v3/v4 expansion boards: the onboard chain (QPL9547 LNA + TA0970A SAW + AD8313 log detector + TLV3501 comparator) feeds pulses to an RP2040, which captures dual edges via PIO+DMA, rebuilds 56/112-bit Mode S frames, and ships them to the ESP32-P4 over a 921600-baud UART for CRC filtering, CPR position fusion, and per-aircraft state aggregation, published over BLE GATT, serial output, and LittleFS or MicroSD logs. (The early v1/v2-carrier path — the P4 driving an RTL-SDR dongle over native USB 2.0 HS — is retired; neither the firmware nor the component tree still carries it.)
Pilot Kit Box 是开源原型和态势感知设备,当前仓库没有 FAA、EASA、CAAC 或其他适航/TSO 认证。它不能作为主飞行仪表、备用飞行仪表、导航源或防撞系统使用;任何飞行决策必须以认证航电、机载仪表、目视观察和适用法规为准。
Pilot Kit Box is an open-source prototype and situational-awareness device. This repository does not represent FAA, EASA, CAAC, TSO, or other airworthiness certification. Do not use it as a primary flight instrument, backup flight instrument, navigation source, or collision-avoidance system; flight decisions must remain based on certified avionics, installed instruments, visual scan, and applicable regulations.
截至 2026-10-15,当前 4.3 寸固件已经覆盖 ADS-B 接收与解码、BLE
GDL90 分发、GPS 定位与两段式授时(pk_clock:BLE 粗校 + GPS fix 精校)、
BMP388 气压高度、LittleFS/MicroSD 记录、ST7701 MIPI-DSI 横屏显示、
GT911 触摸导航、交通雷达、ADS-B 列表、离线地图(microSD pmtiles 底图 +
机场/导航台/FIX 航空叠加层)、航空电台(Airband)收听与录音回放(ES8311
音频输出)、实时诊断、本地航空识别数据库和 BNO085 姿态融合。
As of 2026-10-15, the current 4.3-inch firmware includes ADS-B reception
and decode, BLE GDL90 distribution, GPS positioning and two-stage time
discipline (pk_clock: BLE coarse sync + GPS fine sync after fix), BMP388
barometric altitude, LittleFS/MicroSD recording, an ST7701 MIPI-DSI
landscape display, GT911 touch navigation, traffic radar, an ADS-B list,
the offline map (microSD pmtiles basemap plus airport/navaid/FIX overlay),
an airband radio with recording playback (ES8311 audio output), live
diagnostics, local aviation identity databases, and BNO085 attitude fusion.
v0.8.0 发布重点 / Release Highlights| 功能 | Feature | 状态 / Status |
|---|---|---|
| ESP32-P4 + FreeRTOS 固件,无 Linux 启动链路 | ESP32-P4 + FreeRTOS firmware, no Linux boot chain | 已实现 / Implemented |
| RP2040 拓展板双沿捕获 1090 MHz ADS-B,921600 UART 送 P4 解码(USB RTL-SDR 路径已退役) | RP2040 add-on dual-edge capture of 1090 MHz ADS-B, raw frames to the P4 over 921600-baud UART (USB RTL-SDR path retired) | 已实现 / Implemented |
adsb_lnk 任务:921600 UART 收 RP2040 帧、CRC 过滤后进 CPR/融合与记录链 | adsb_lnk task: RP2040 frames over 921600-baud UART, CRC-filtered into the CPR/fusion and recording chain | 已实现 / Implemented |
| dump1090 派生 Mode-S 解码、CRC 过滤、CPR 全球定位 | dump1090-derived Mode-S decode, CRC filtering, CPR global position decode | 已实现 / Implemented |
| 最多同时跟踪 64 个 ADS-B / Mode-S 目标,并聚合呼号、高度、位置、速度、垂直速度、应答机码和机型信息 | Tracks up to 64 ADS-B / Mode-S targets at once, aggregating callsign, altitude, position, velocity, vertical rate, squawk, and aircraft type | 已实现 / Implemented |
| UART、LittleFS / MicroSD 轮转文件、BLE raw ts-line 三路记录输出 | UART, rotating LittleFS/MicroSD files, and BLE raw ts-line output | 已实现 / Implemented |
| BLE GATT:GDL90 Ownship、Traffic、Heartbeat、Raw、Time Sync | BLE GATT: GDL90 Ownship, Traffic, Heartbeat, Raw, and Time Sync | 已实现 / Implemented |
| iOS Current Time Service 自动校时,Android/跨平台可写 Time Sync | iOS Current Time Service auto-sync, Android/cross-platform Time Sync writes | 已实现 / Implemented |
| GT-U8 GPS / 北斗定位、RMC 授时、GPS own-ship 兜底 | GT-U8 GPS/BeiDou positioning, RMC time sync, GPS own-ship fallback | 已实现;pk_clock 两段式校时(BLE 粗校 + GPS 精校)已接线 / Implemented; pk_clock two-stage discipline (BLE coarse + GPS fine) is wired |
| BMP388 气压高度和升降率,QNH 可调 | BMP388 barometric altitude and vertical speed with adjustable QNH | 已实现 / Implemented |
| ST7701 480×800 MIPI-DSI 面板,PPA 转为 800×480 横屏,双 DPI buffer | ST7701 480×800 MIPI-DSI panel, PPA-transformed to 800×480 landscape with dual DPI buffers | 已实现 / Implemented |
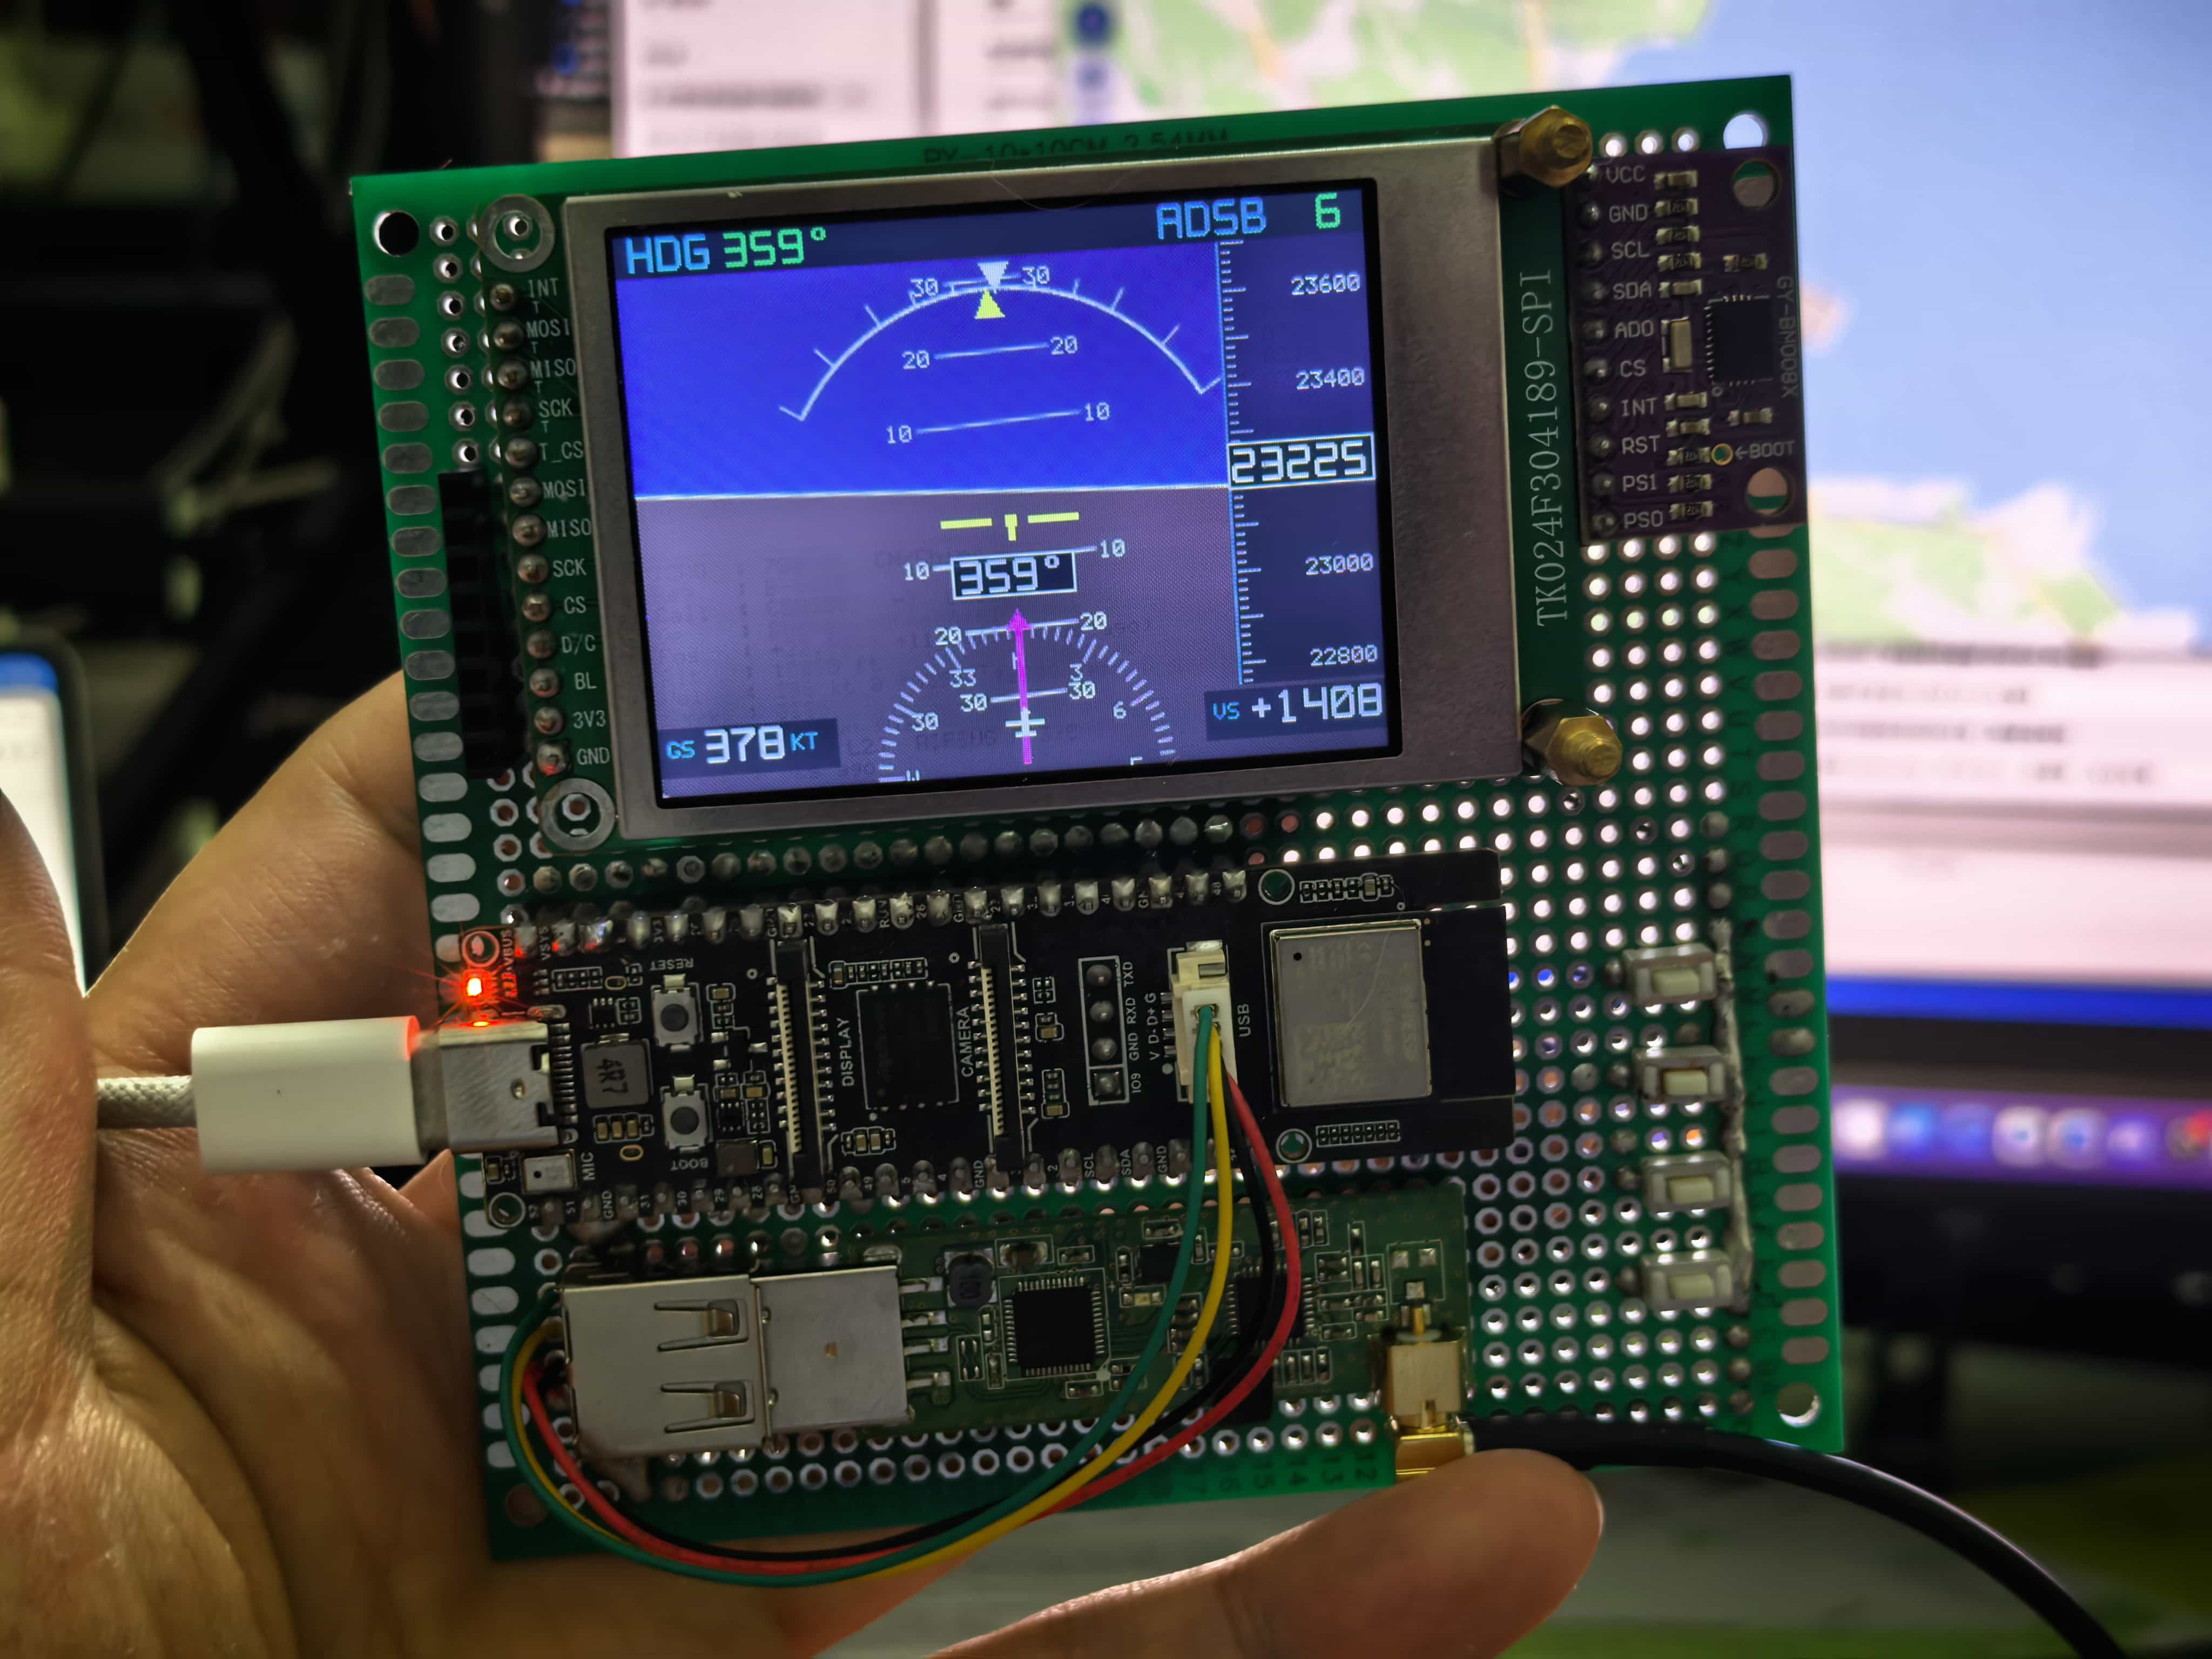
| G1000 风格 PFD:姿态、航向/HSI、高度带、GS/VS、ADS-B 数量 | G1000-style PFD: attitude, heading/HSI, altitude tape, GS/VS, ADS-B count | 已实现 / Implemented |
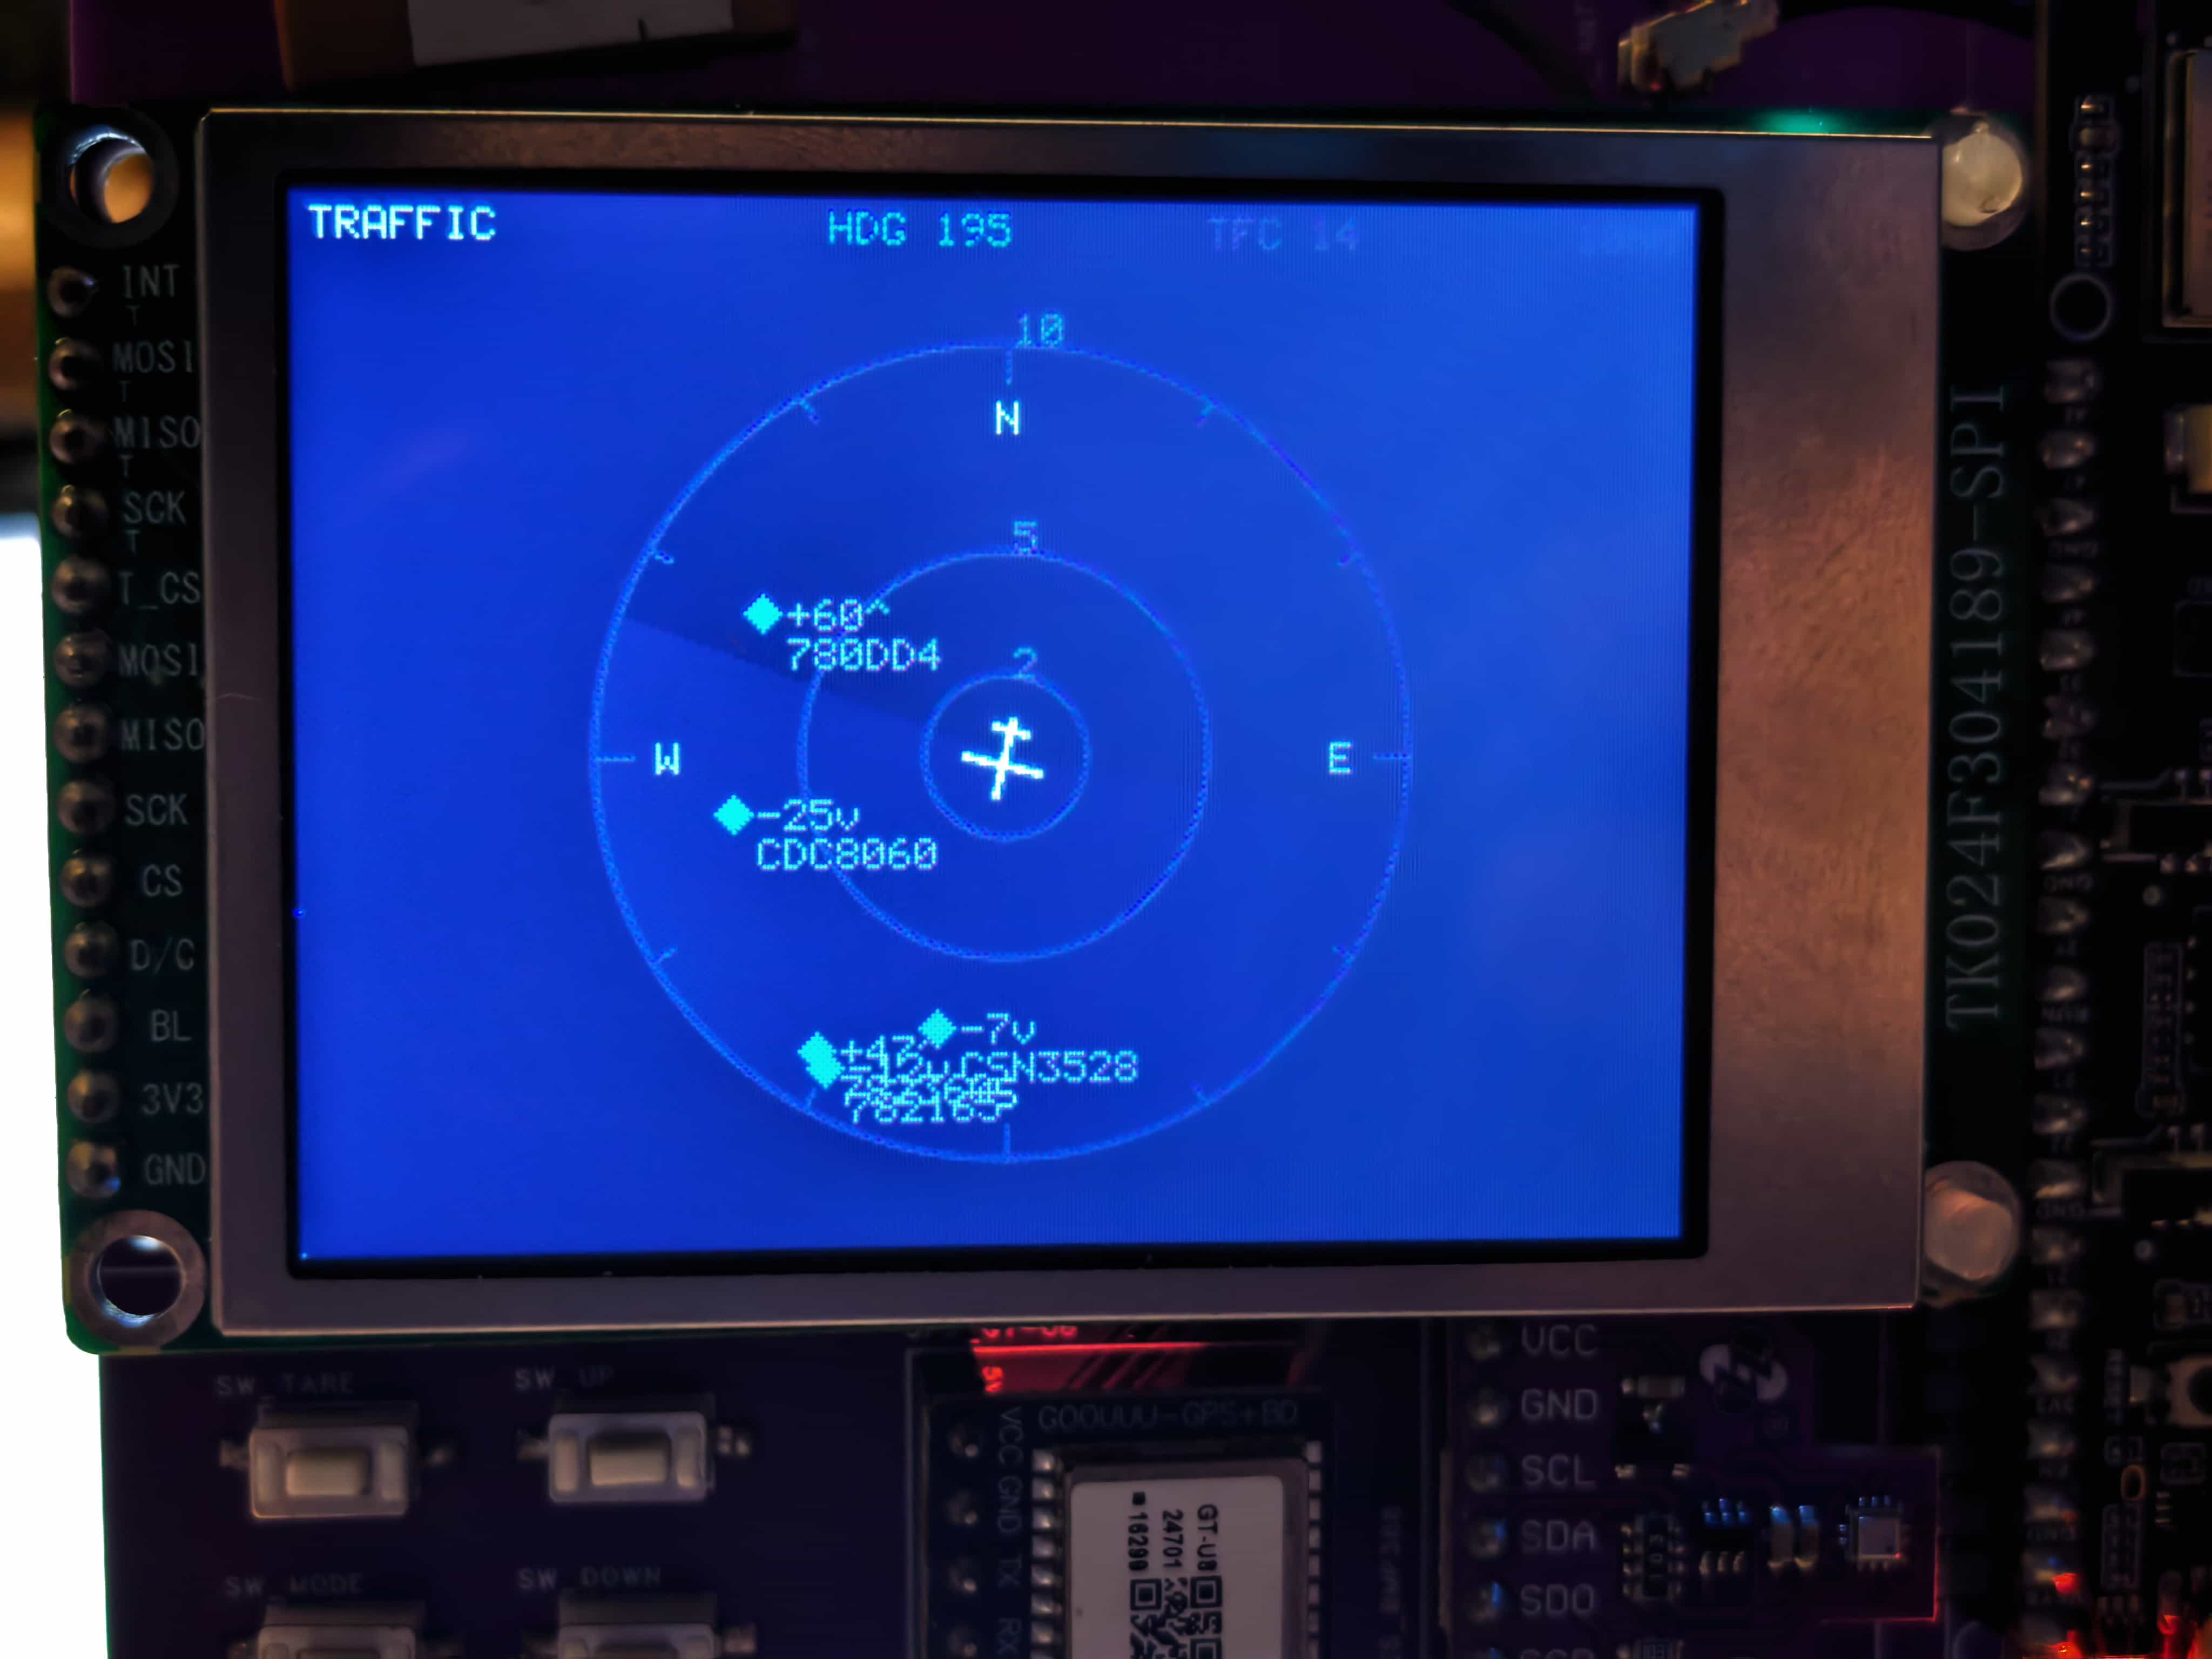
| 360° 交通雷达:航向朝上/北向上、2/5/10/20 NM、目标选择和相对高度 | 360° traffic radar: heading-up/north-up, 2/5/10/20 NM, target selection, relative altitude | 已实现 / Implemented |
| PFD HSI 前方交通叠加和后方目标计数 | Forward-traffic overlay and aft-target count on the PFD HSI | 已实现 / Implemented |
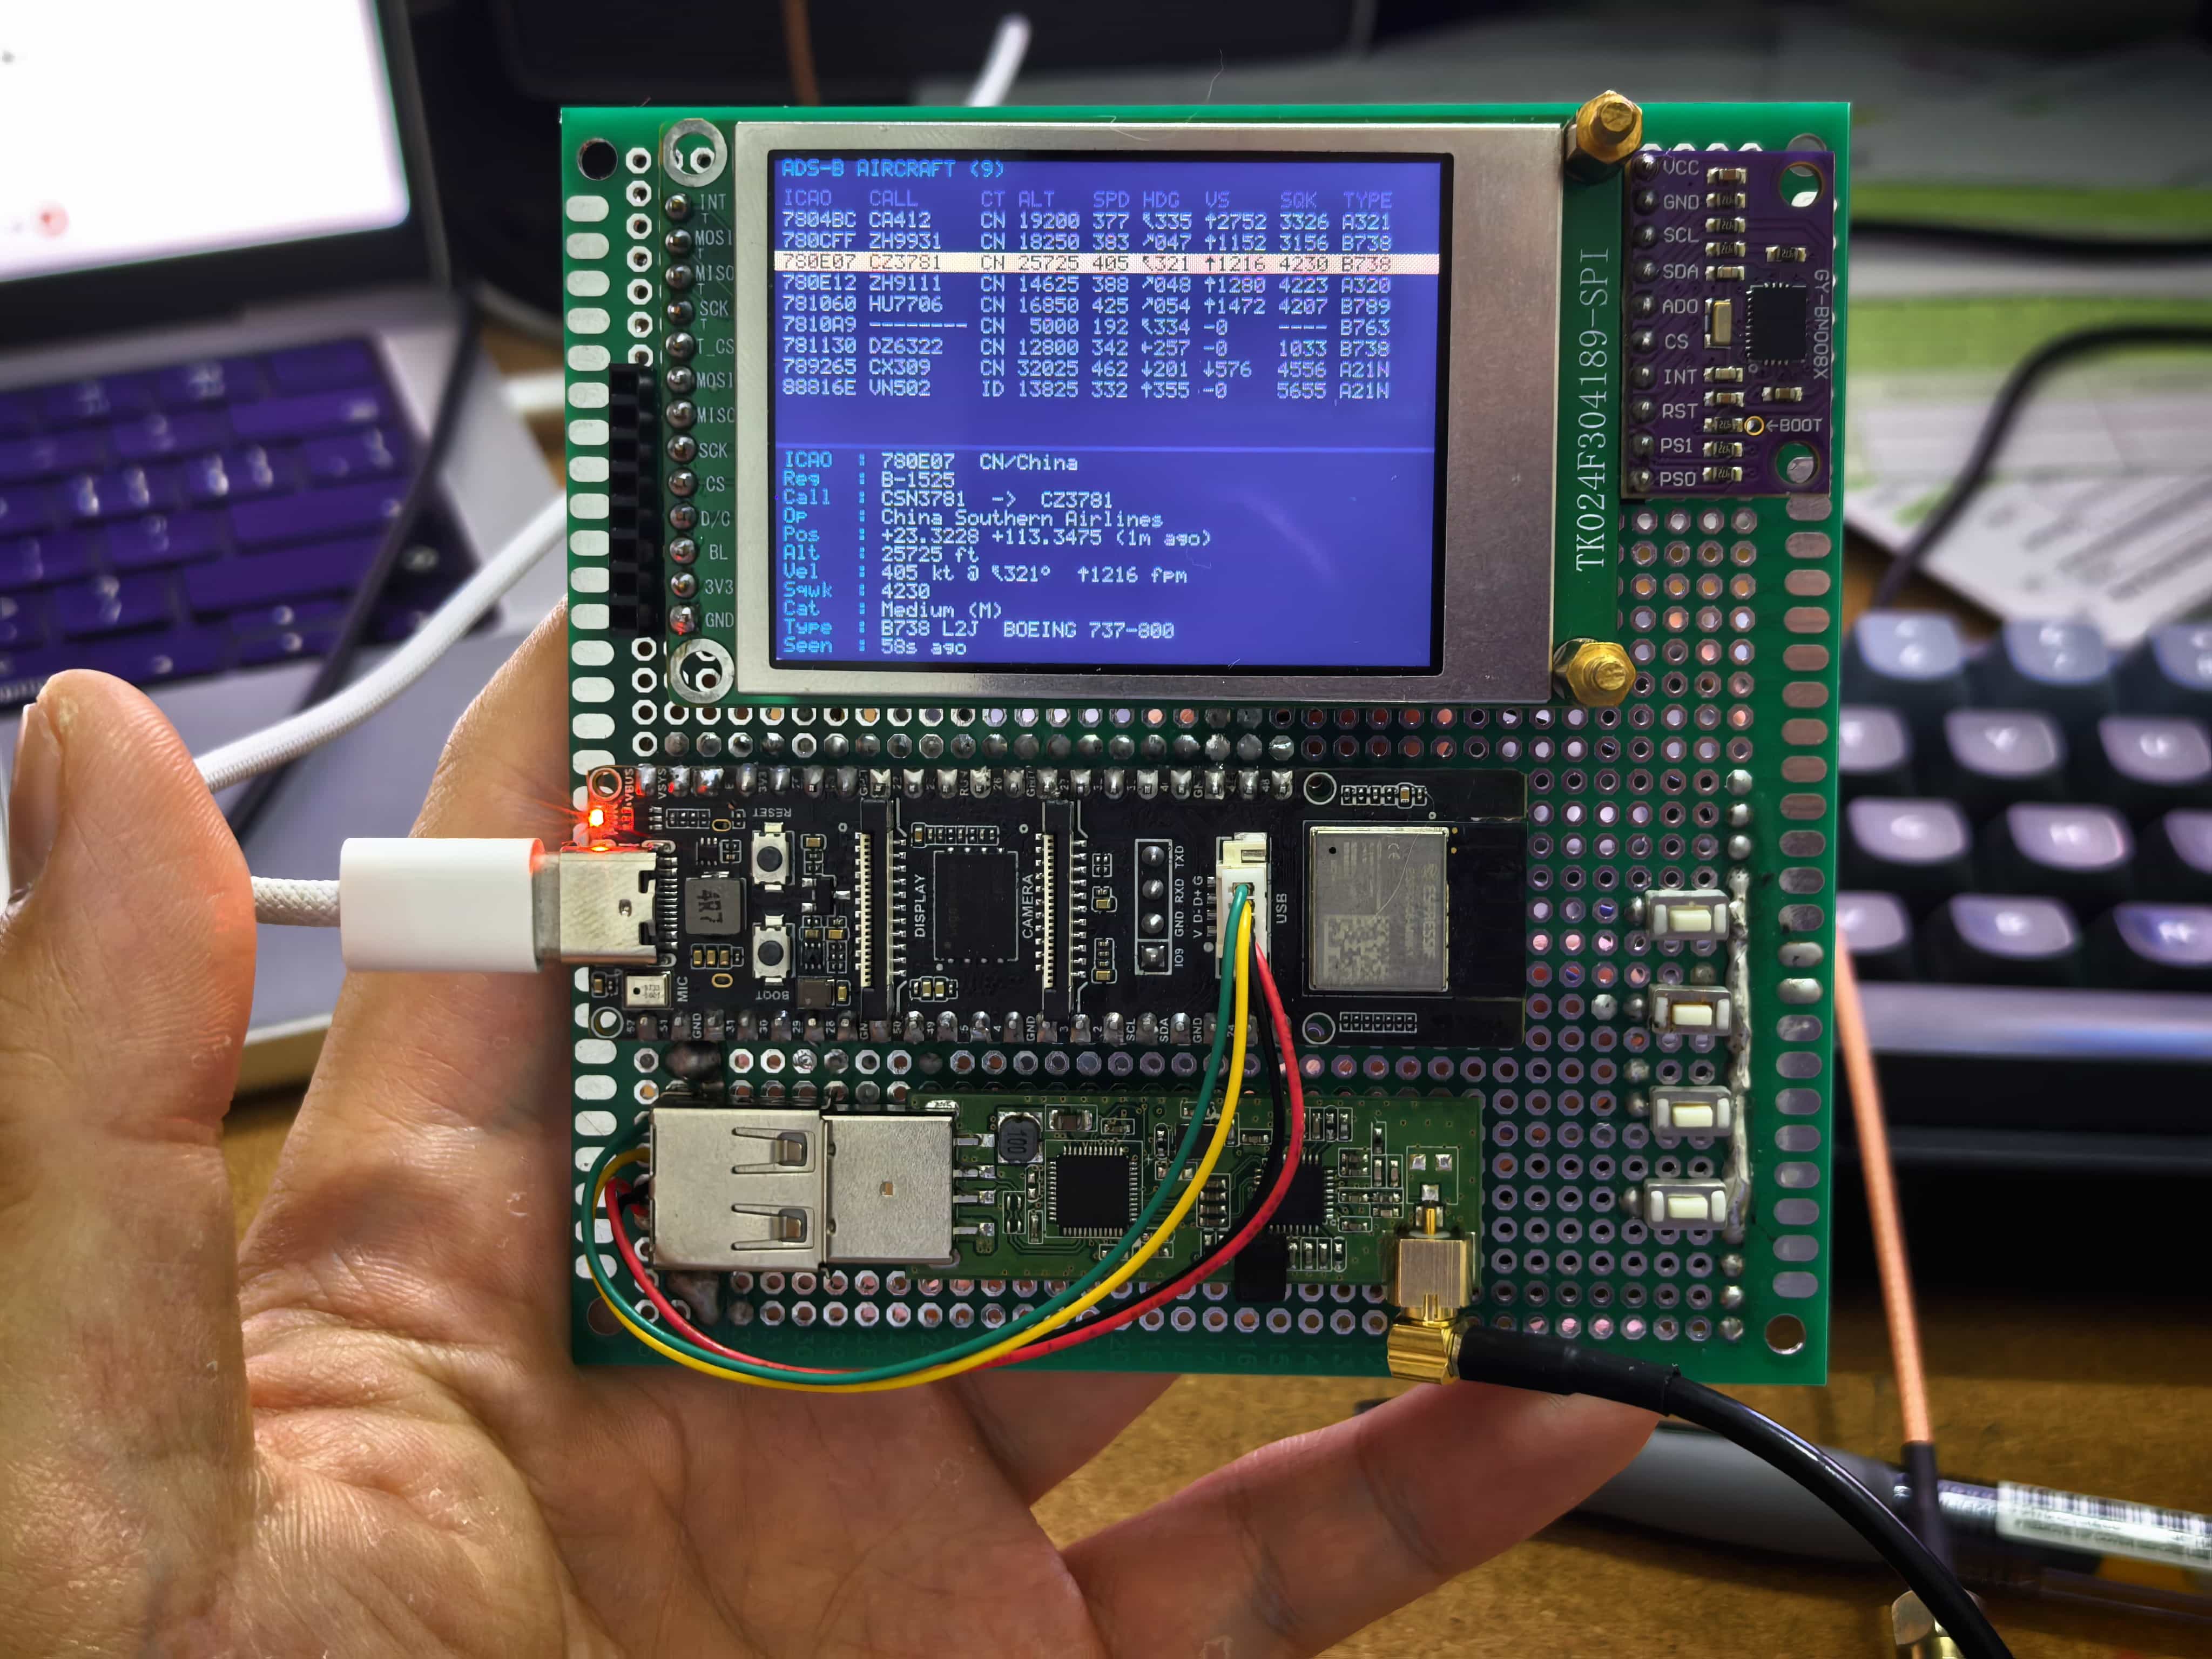
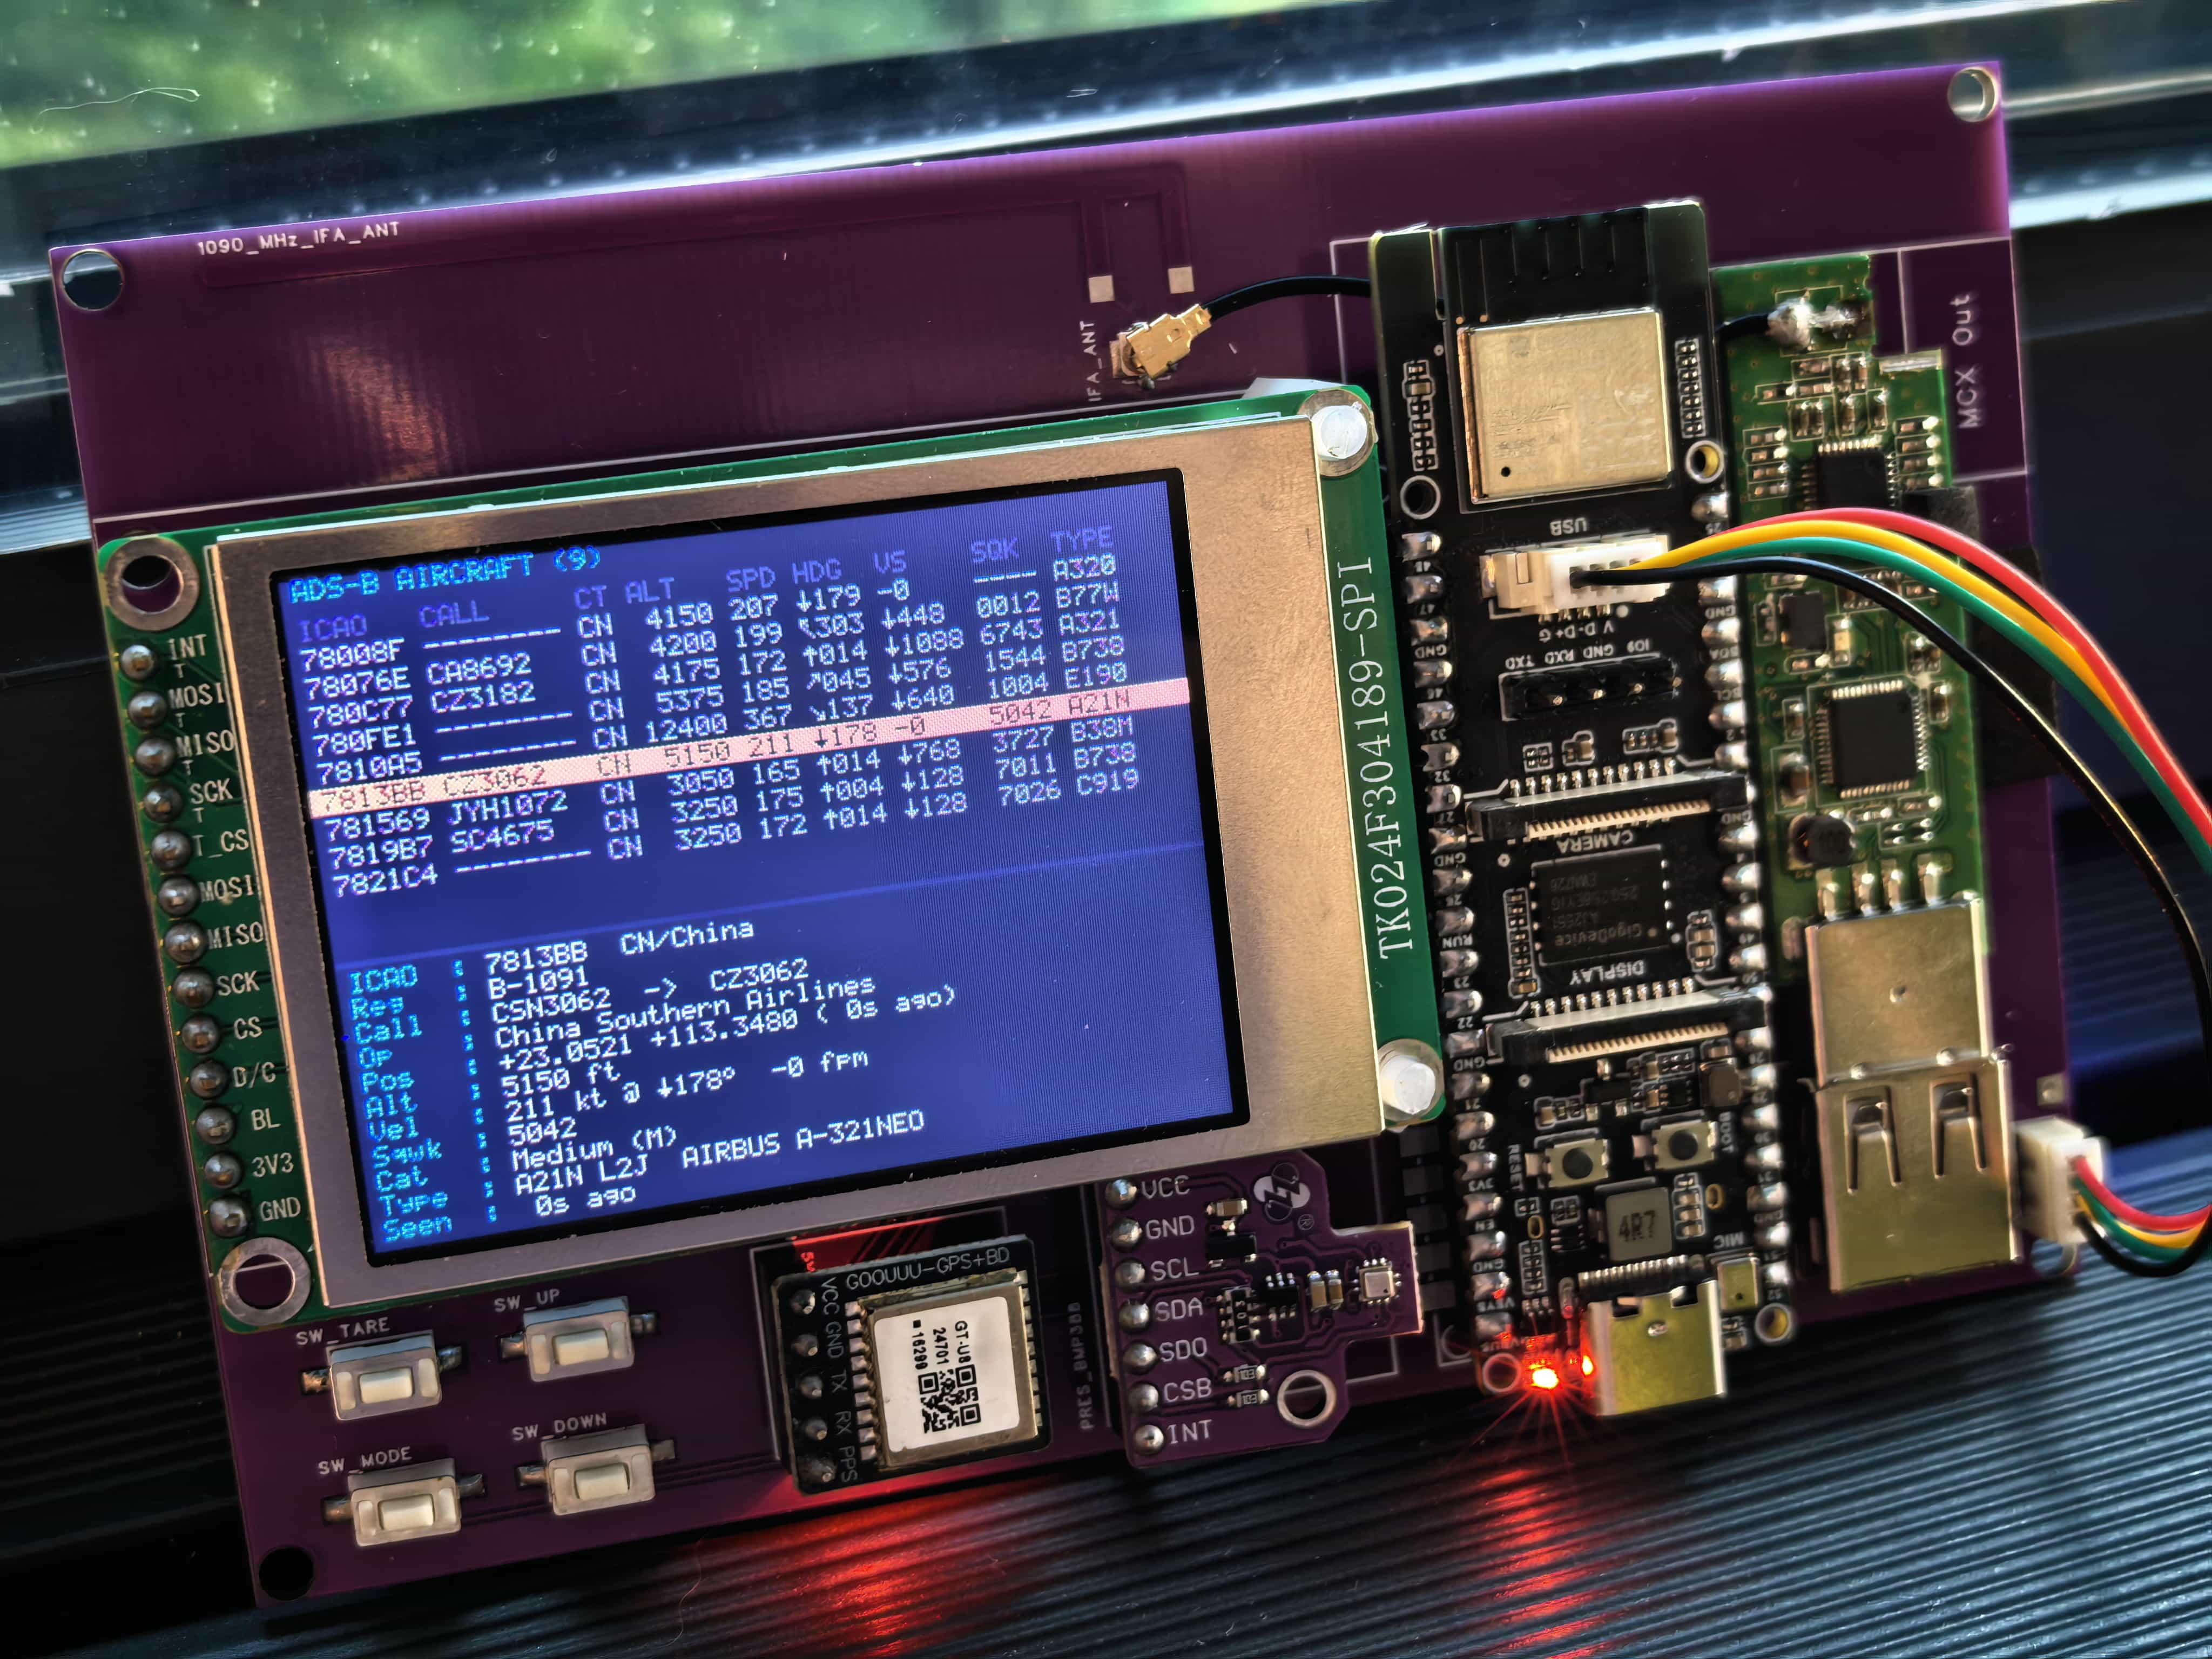
| ADS-B 列表页:ICAO、呼号、国家、ALT、SPD、HDG、VS、SQK、TYPE 和详情面板 | ADS-B list page: ICAO, callsign, country, ALT, SPD, HDG, VS, SQK, TYPE, and detail pane | 已实现 / Implemented |
| 本地航空识别数据库:航司 ICAO/IATA、运营人名称、ICAO24 国家、注册号、机型和型号 | Local aviation identity databases: airline ICAO/IATA, operator name, ICAO24 country, registration, type, and model | 已实现 / Implemented |
| BNO085 100 Hz 姿态融合、校准向导和导航网格长按“调平”持久化 | BNO085 100 Hz attitude fusion, calibration wizard, and persistent nav-grid Level action | 已实现 / Implemented |
| Settings / About / Diagnostics / Compass Calibration 中英文 UI,配置写入 NVS | English/Chinese Settings, About, Diagnostics, and Compass Calibration UI with NVS persistence | 已实现 / Implemented |
| Noto Sans SC 字形生成、中文 LCD 锐化曲线、英文硬像素路径 | Noto Sans SC glyph generation, sharpened CJK LCD alpha curve, crisp English bitmap path | 已实现 / Implemented |
| GT911 触摸 FAB 打开全屏导航网格直接切页(两页 10 项可翻页),FAB 可拖动记忆,详情页三路返回 | GT911 touch FAB opens a full-screen nav grid (10 items on two swipeable pages), remembers FAB position, and provides three detail-page back paths | 已实现 / Implemented |
| RP2040 链路健康监测:HELLO 心跳、链路停滞检测,诊断页显示收帧/坏 CRC | RP2040 link health: HELLO heartbeat and stalled-link detection; the diag page shows link rx/bad-CRC | 已实现 / Implemented |
PFD / ADS-B LIST / Traffic Radar / 完整原型为早期实机照片,UI 为当时版本; 设备与扩展板的最新装机照片待补充。
The PFD / ADS-B LIST / Traffic Radar / prototype photos below were taken on an early firmware build; the latest device and expansion-board assembly photos are pending.
| PFD / Primary Flight Display | ADS-B LIST / Aircraft List |
|---|---|
 |  |
| 交通雷达 / Traffic Radar | 完整原型 / Finished Prototype |
|---|---|
 | 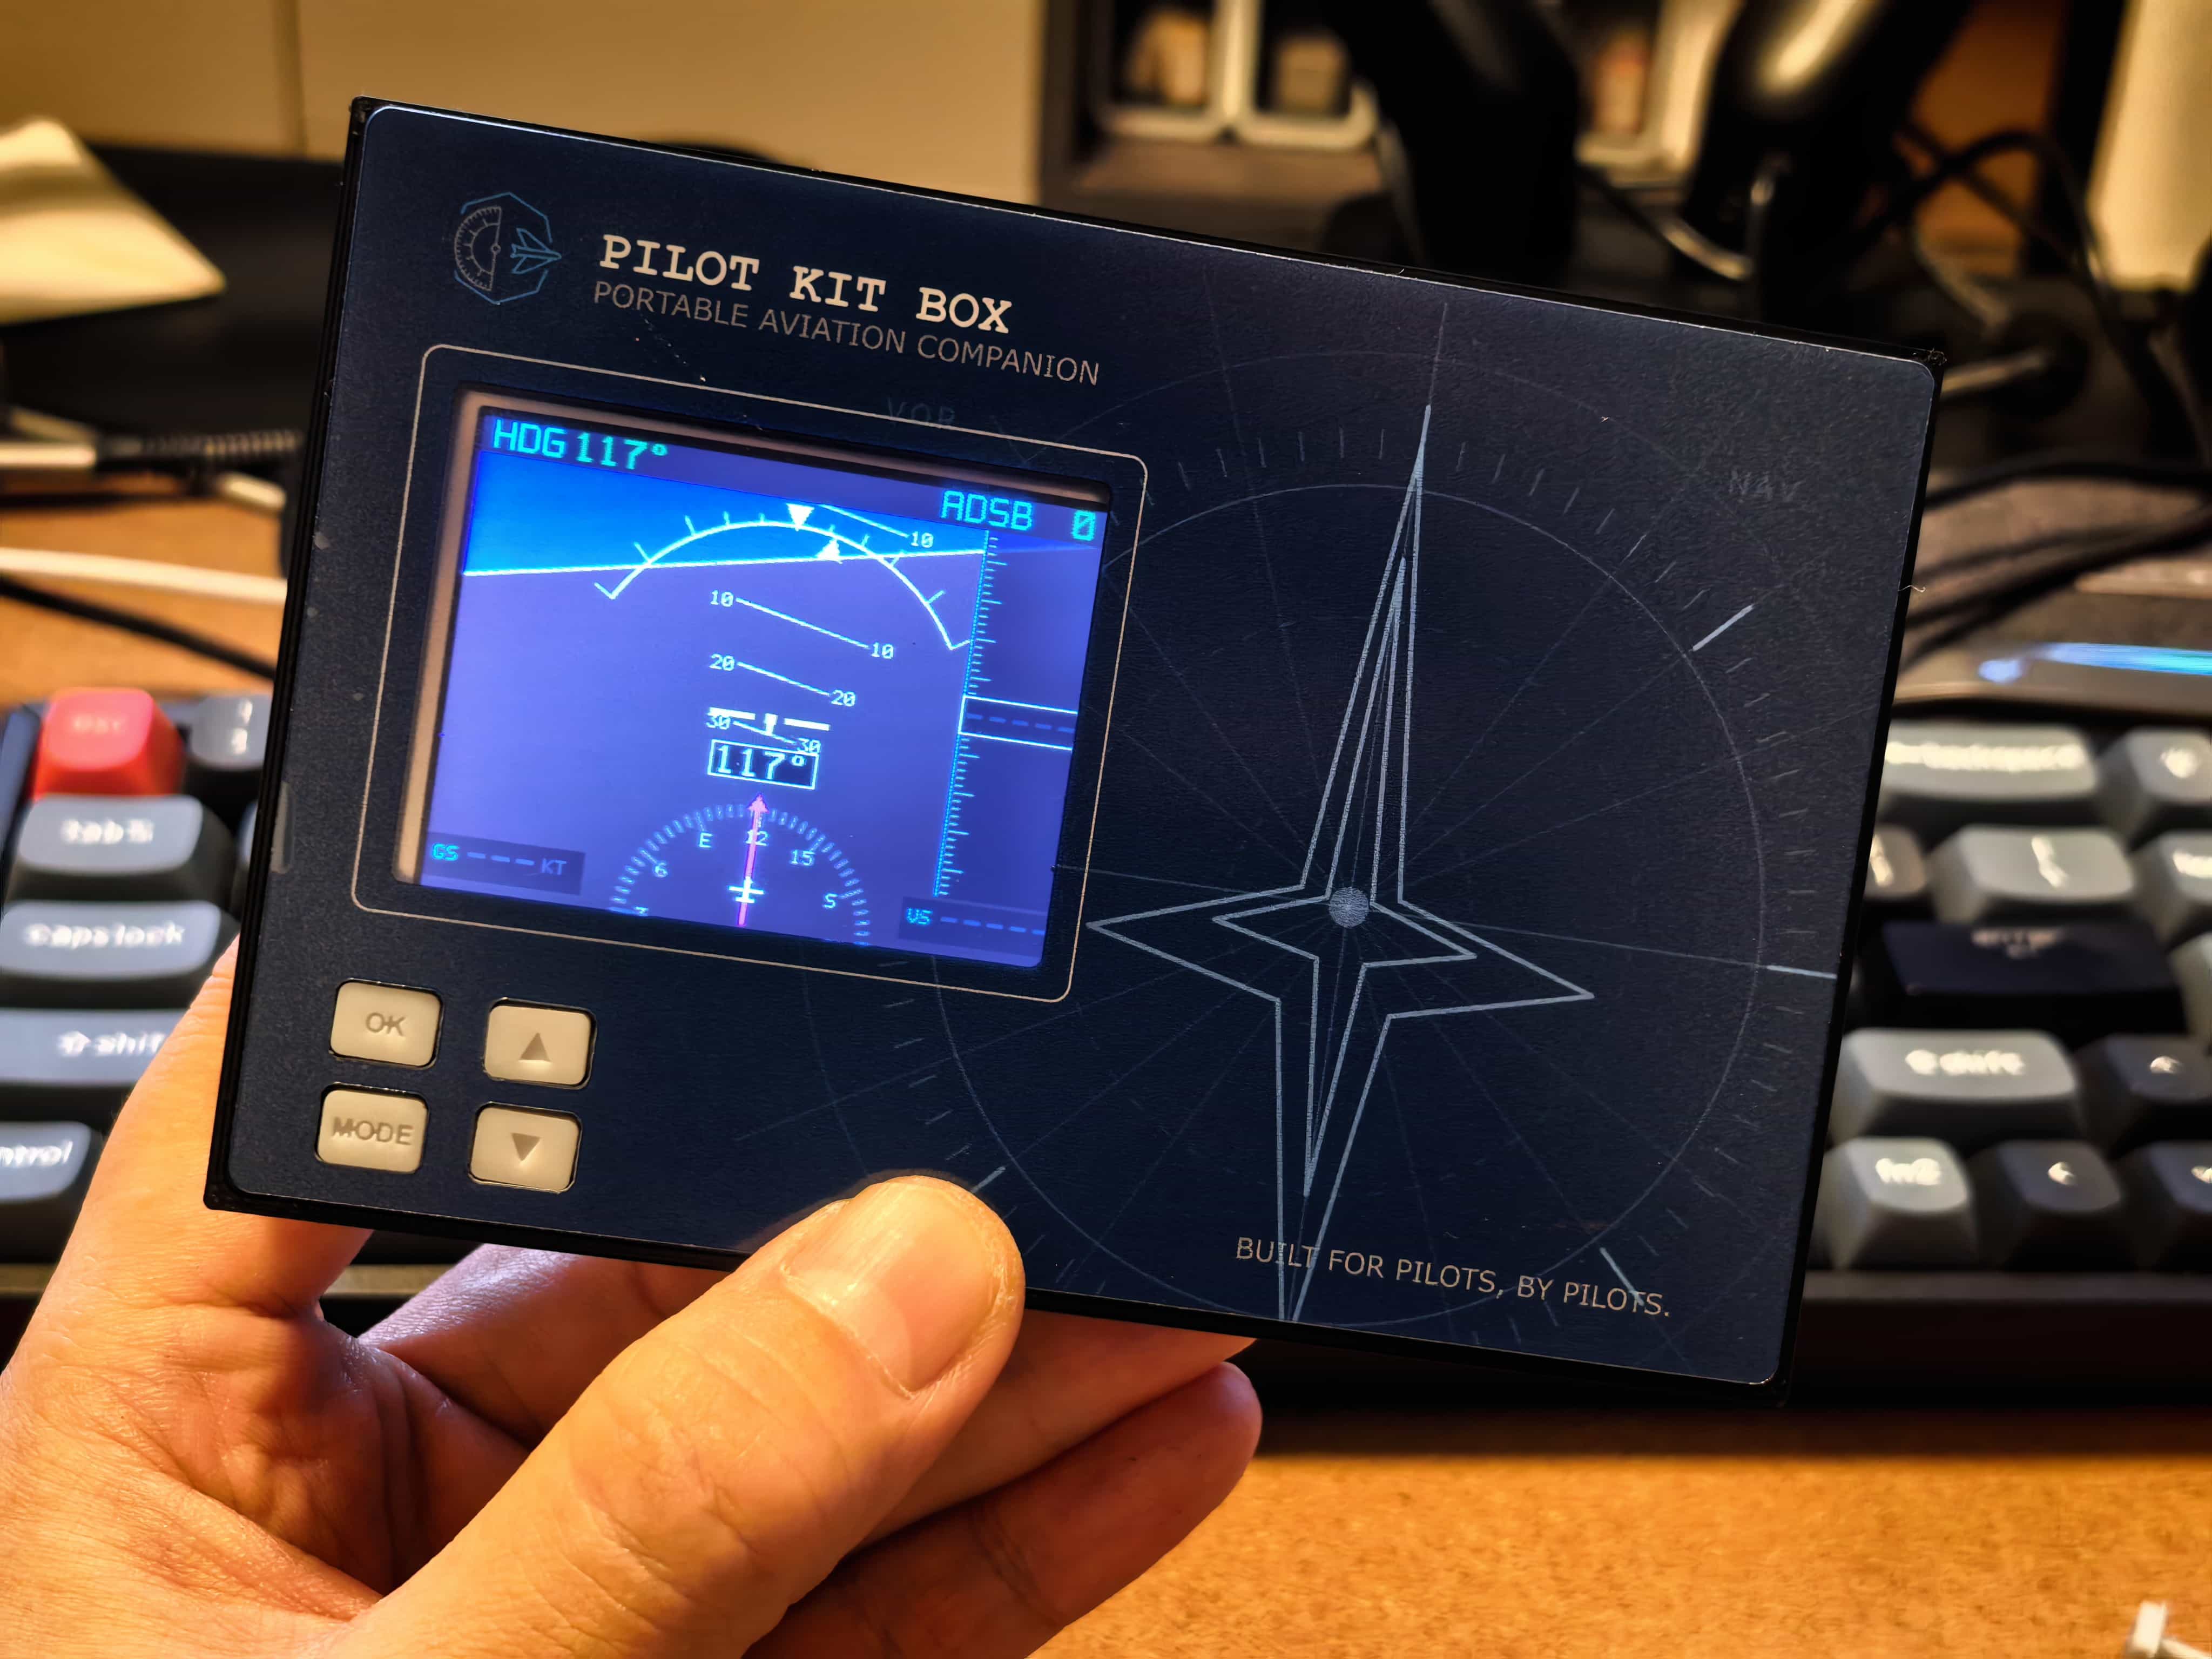 |
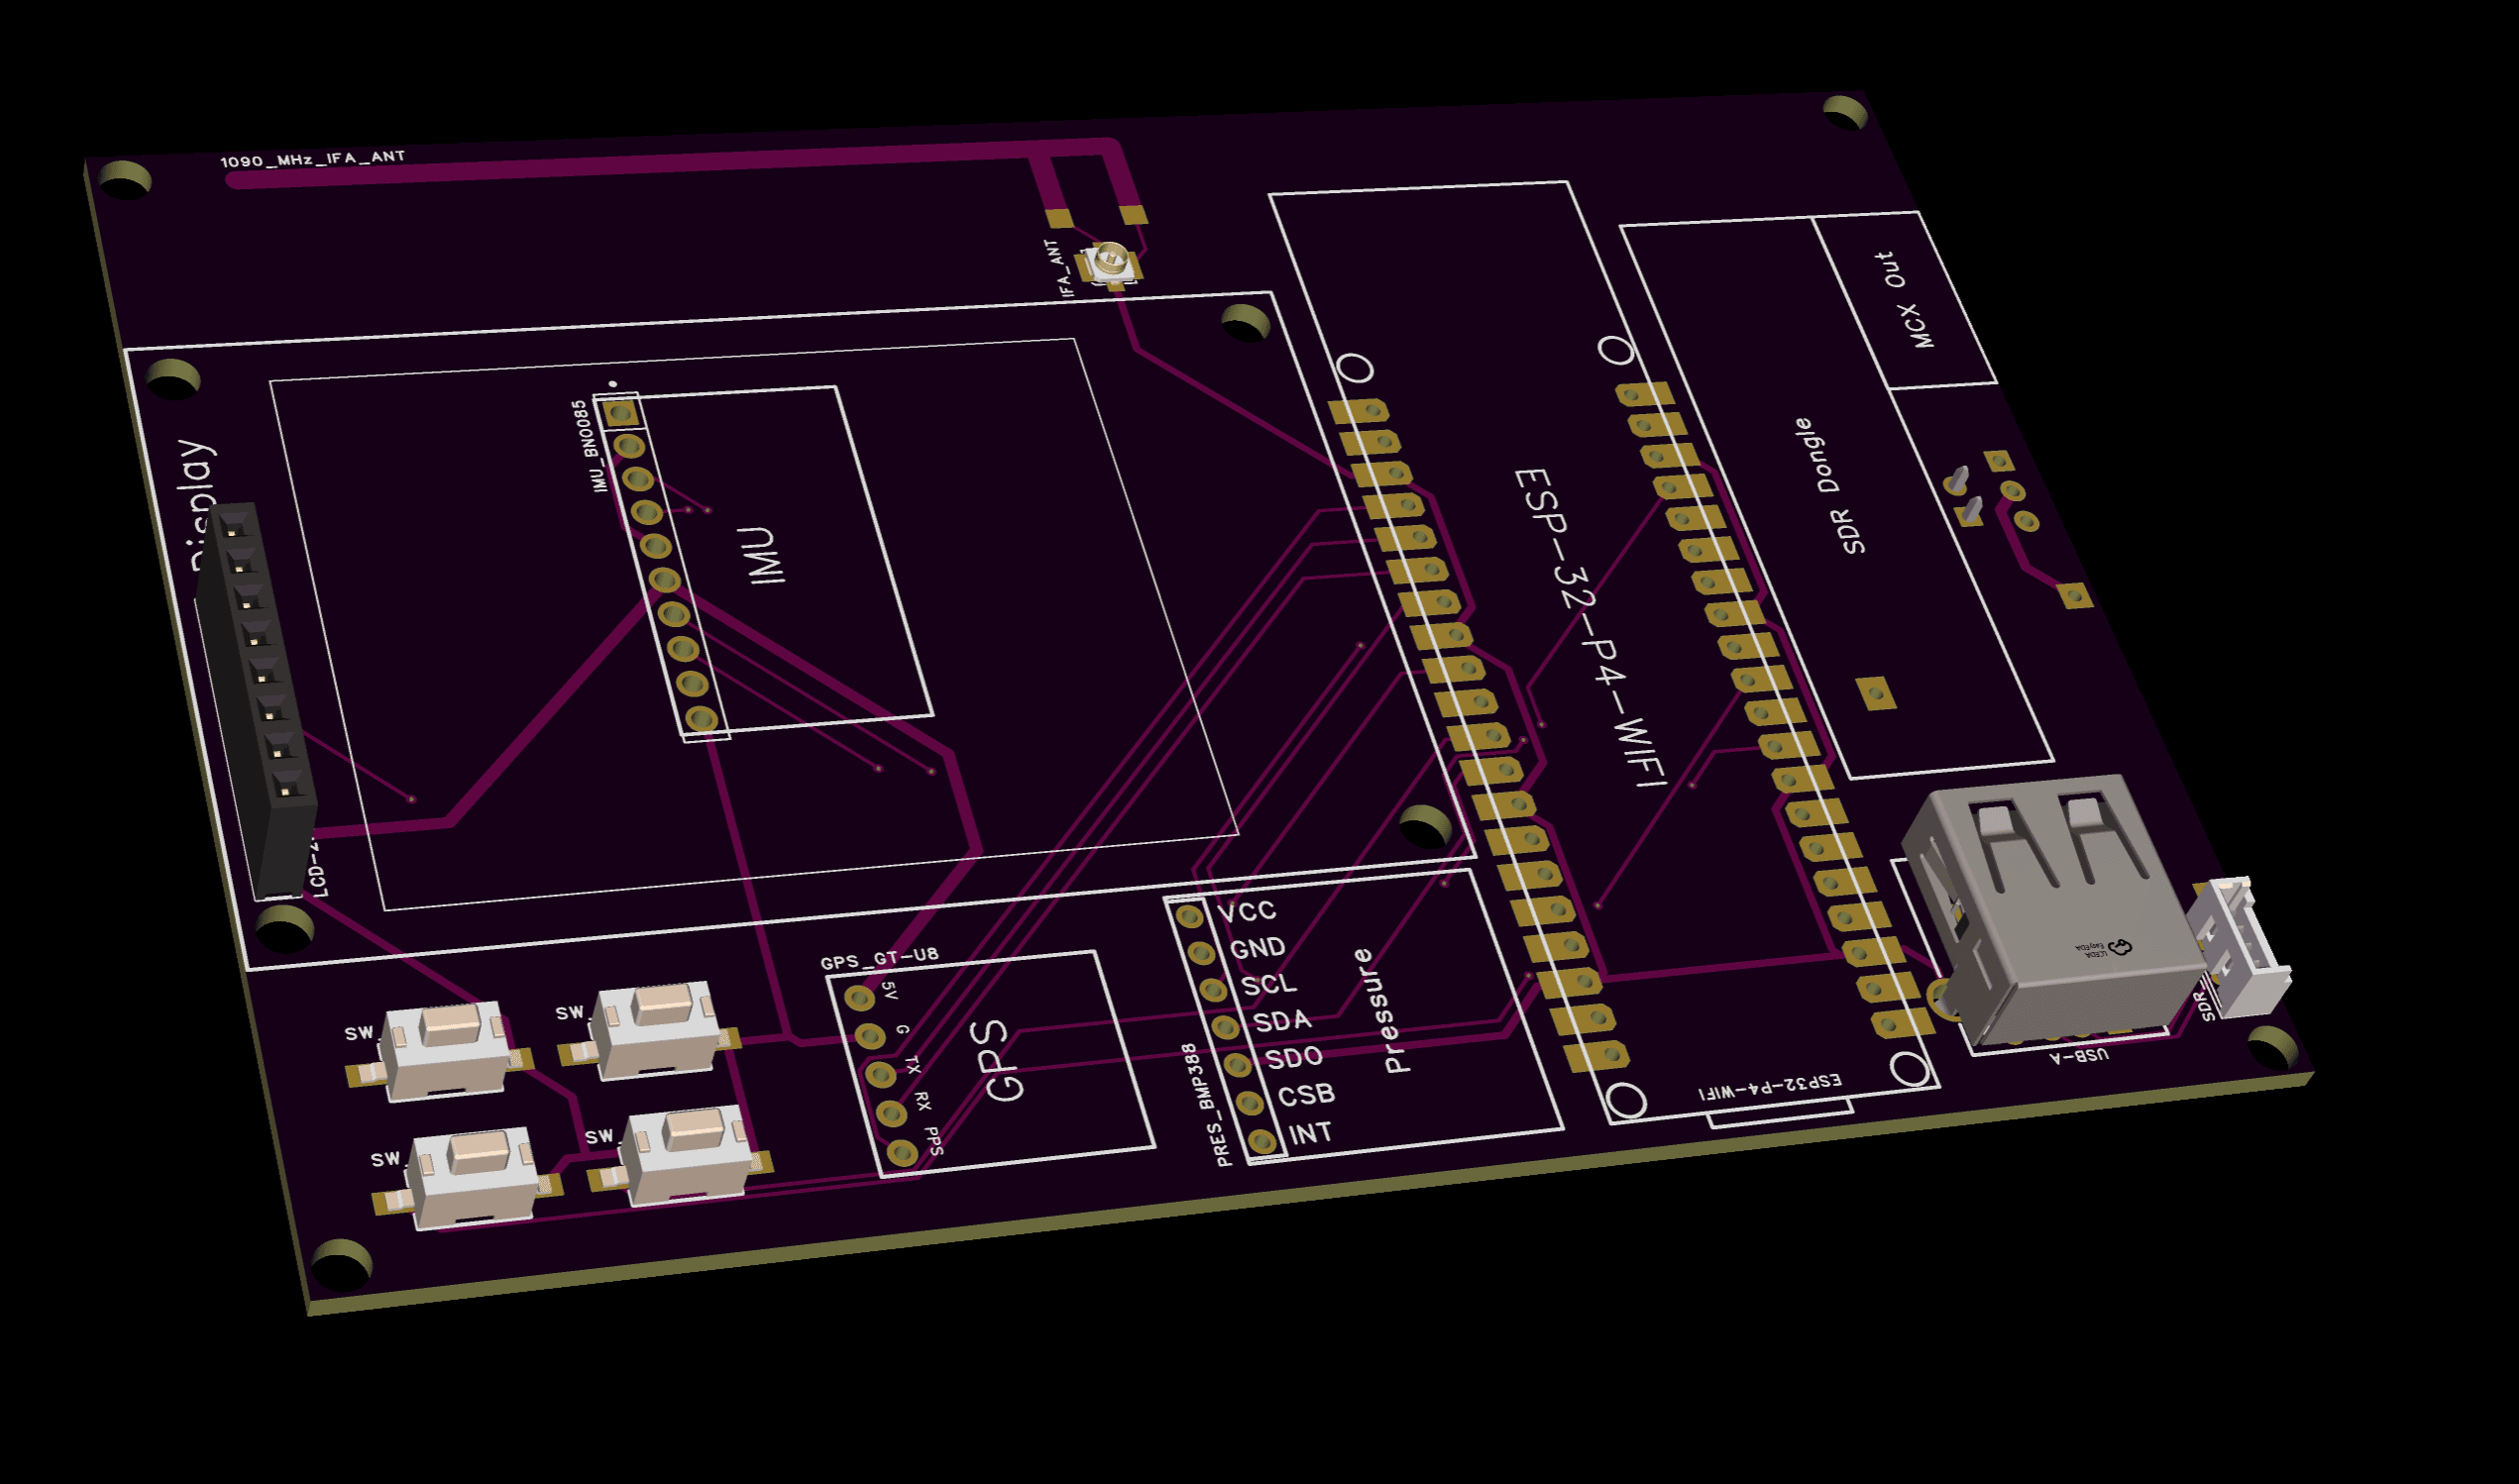
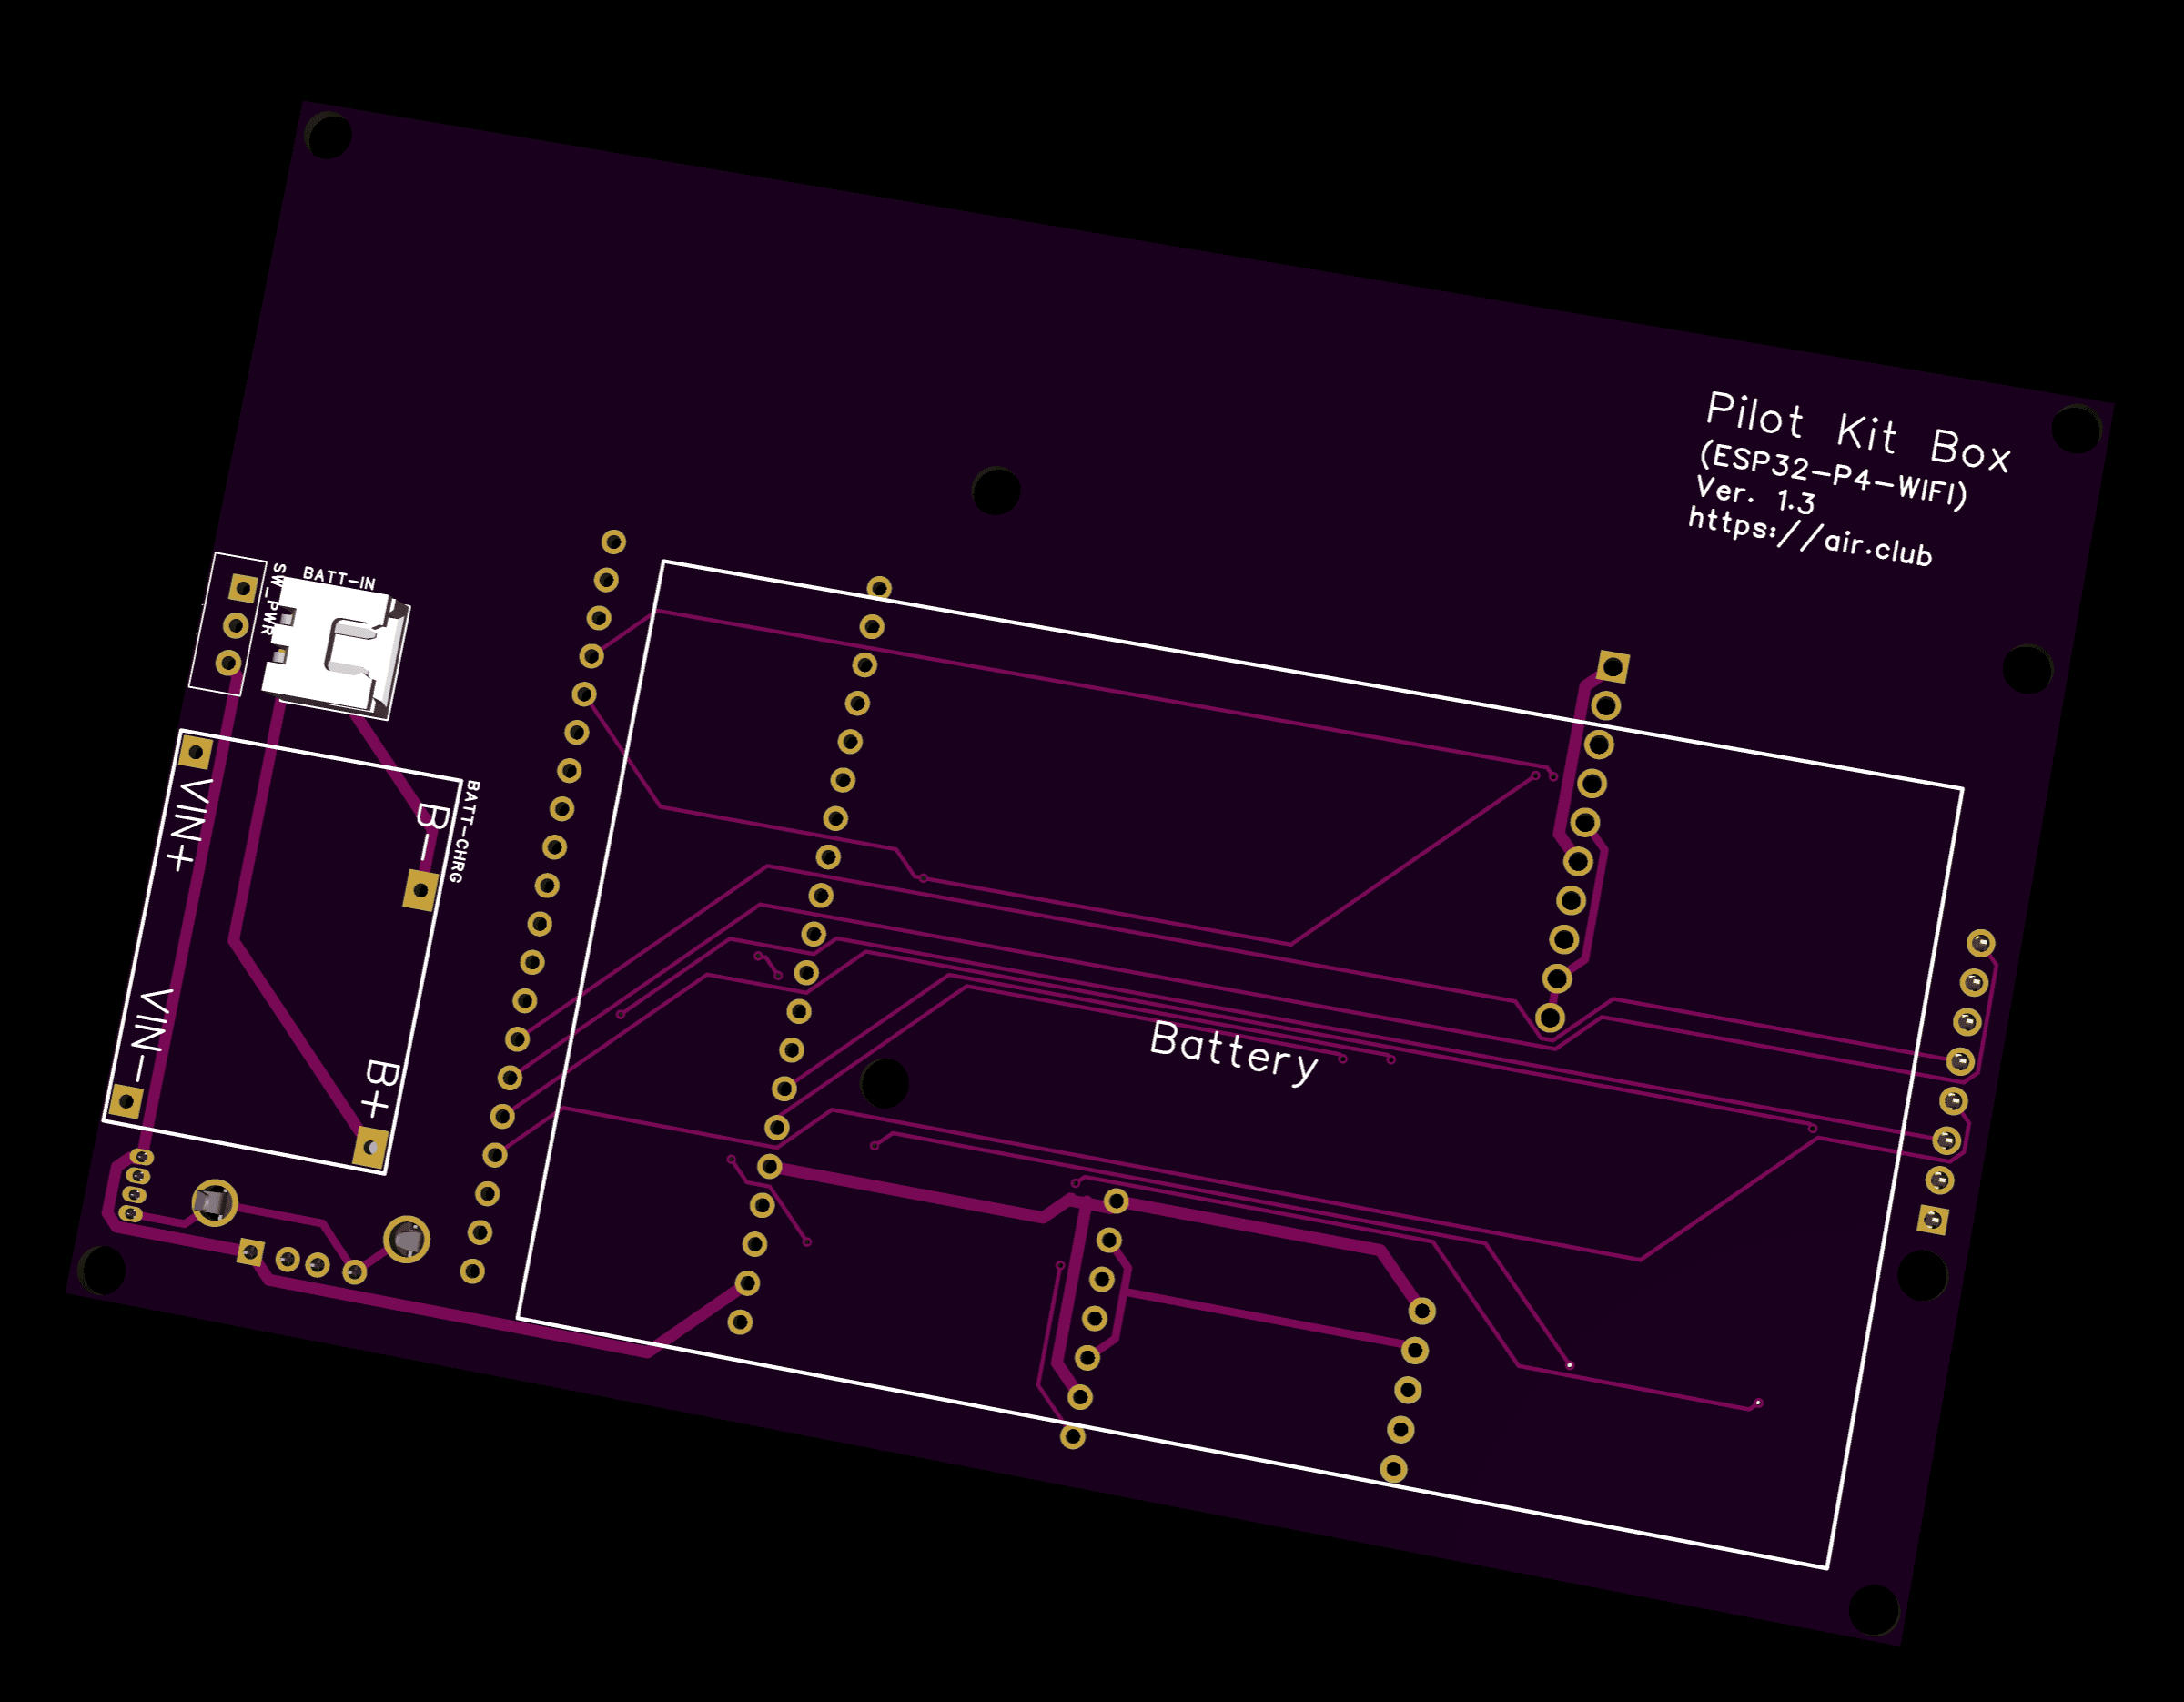
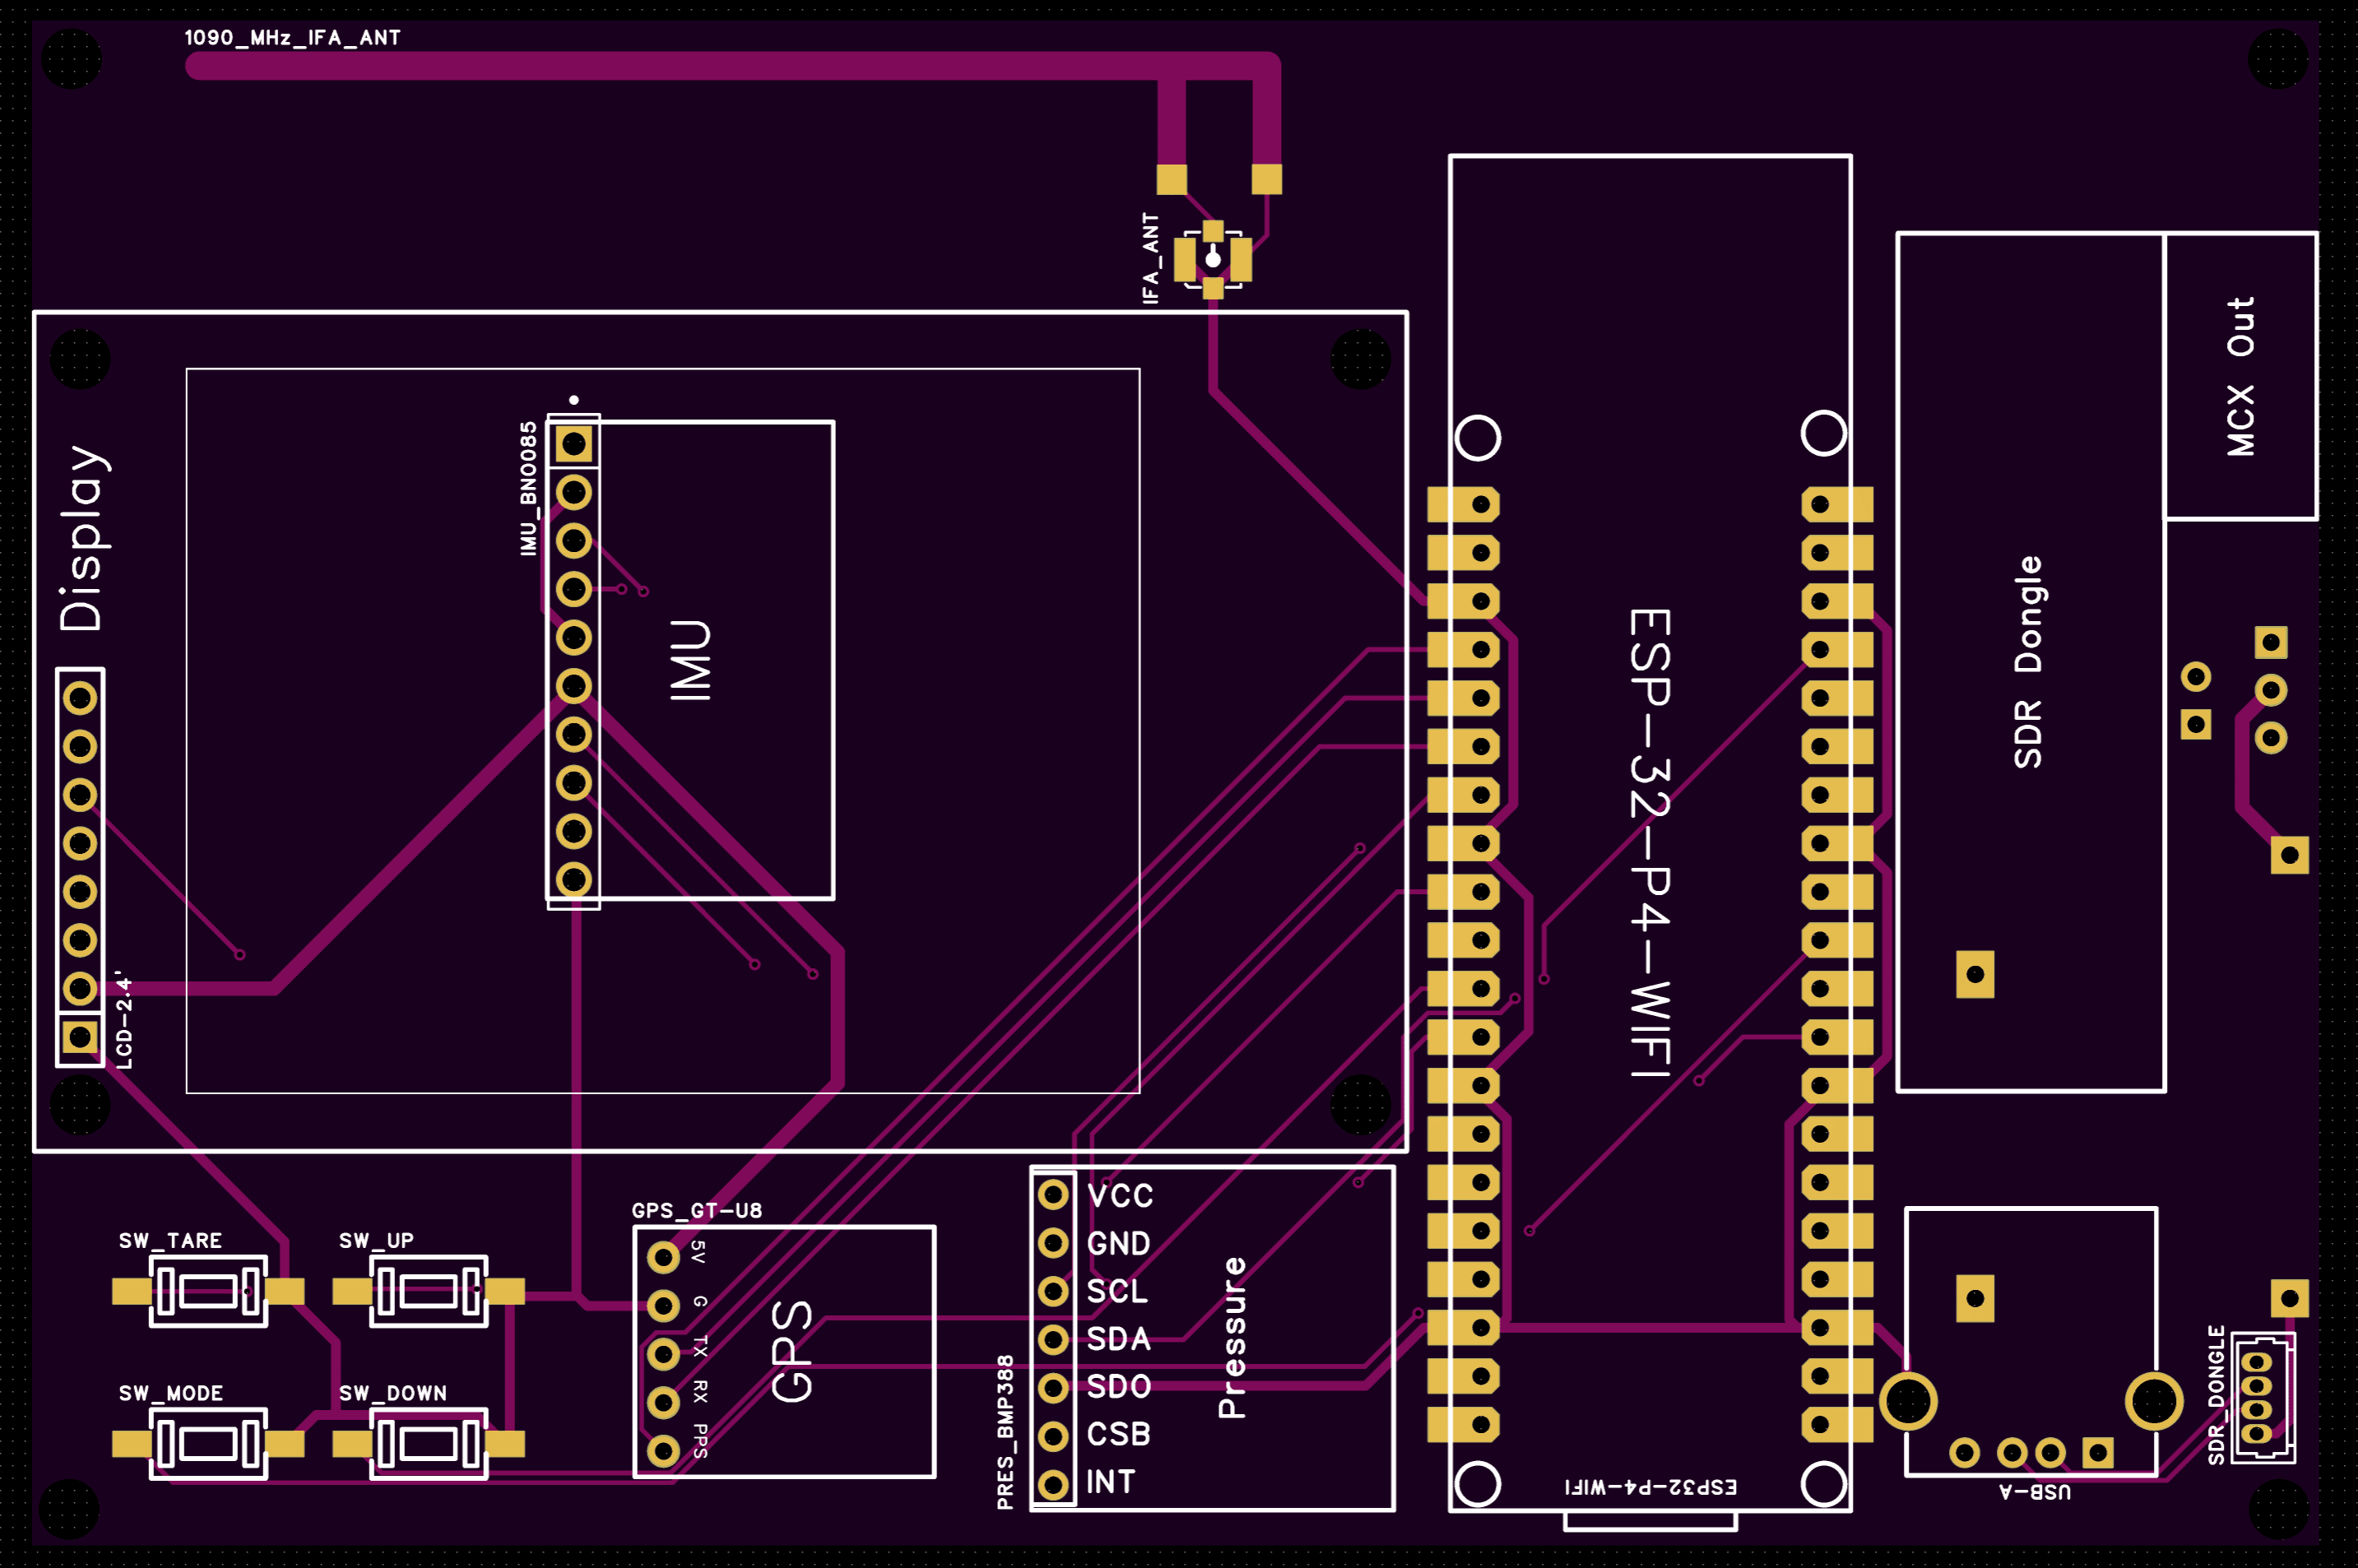
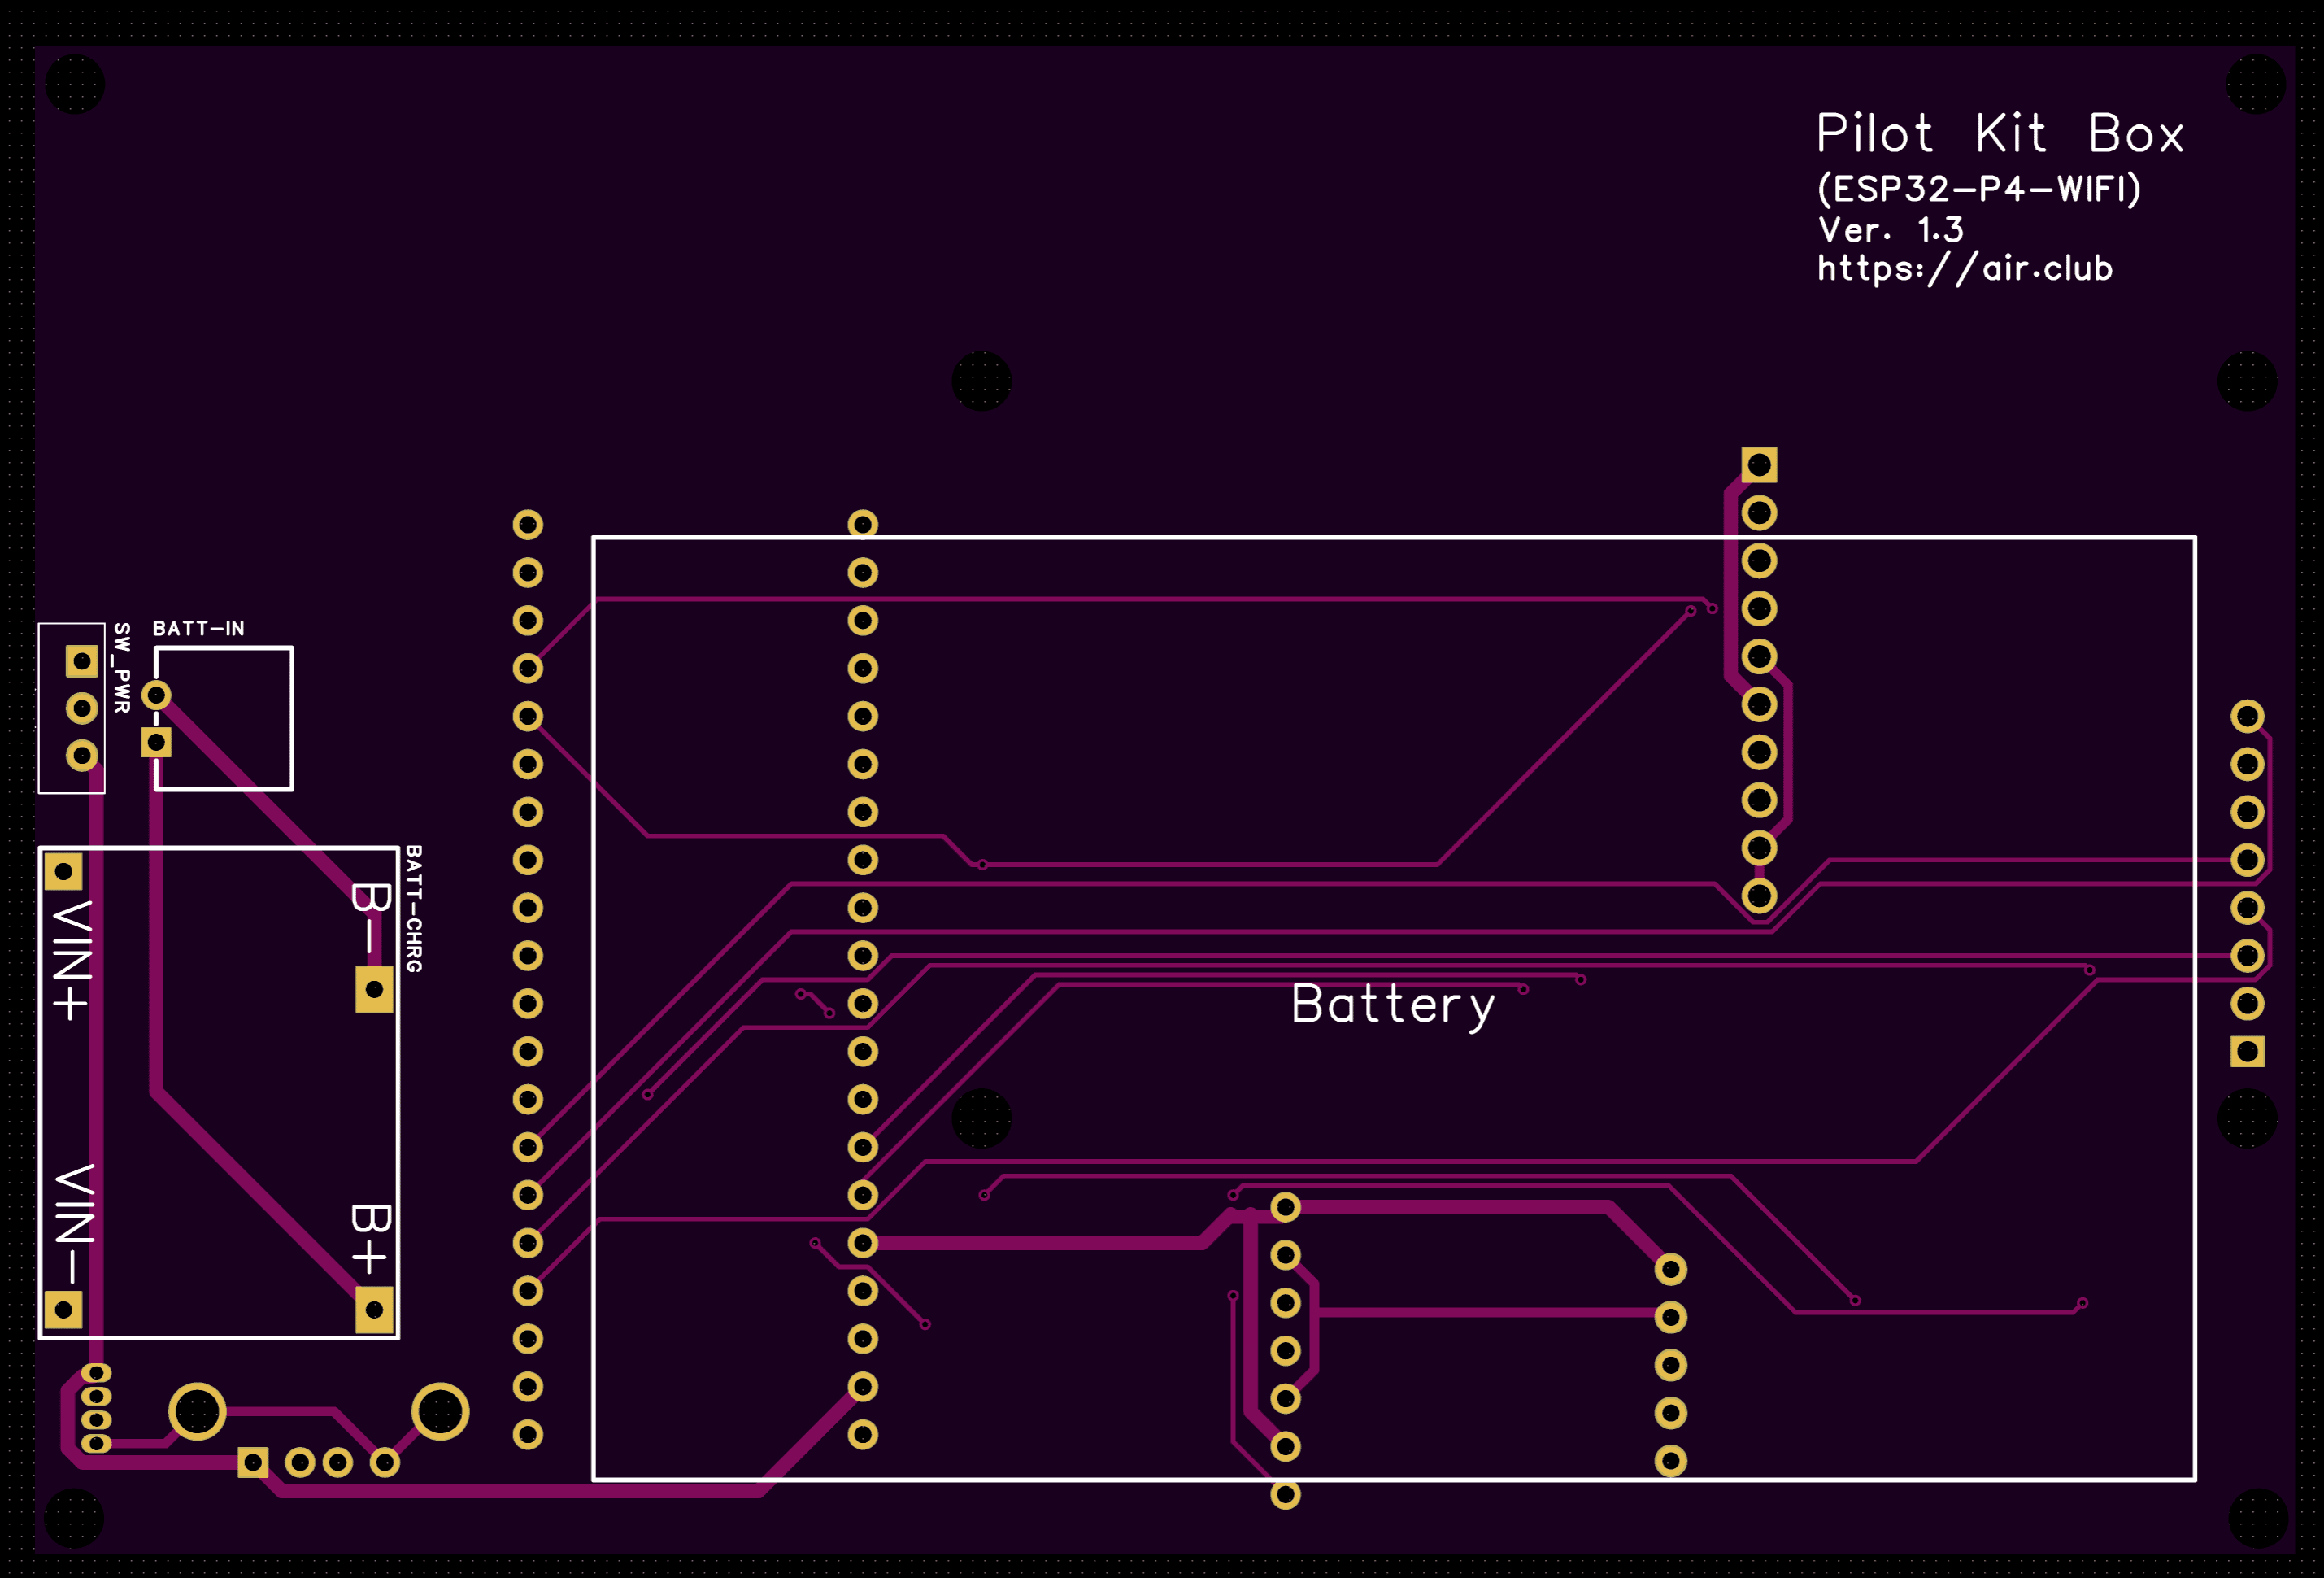
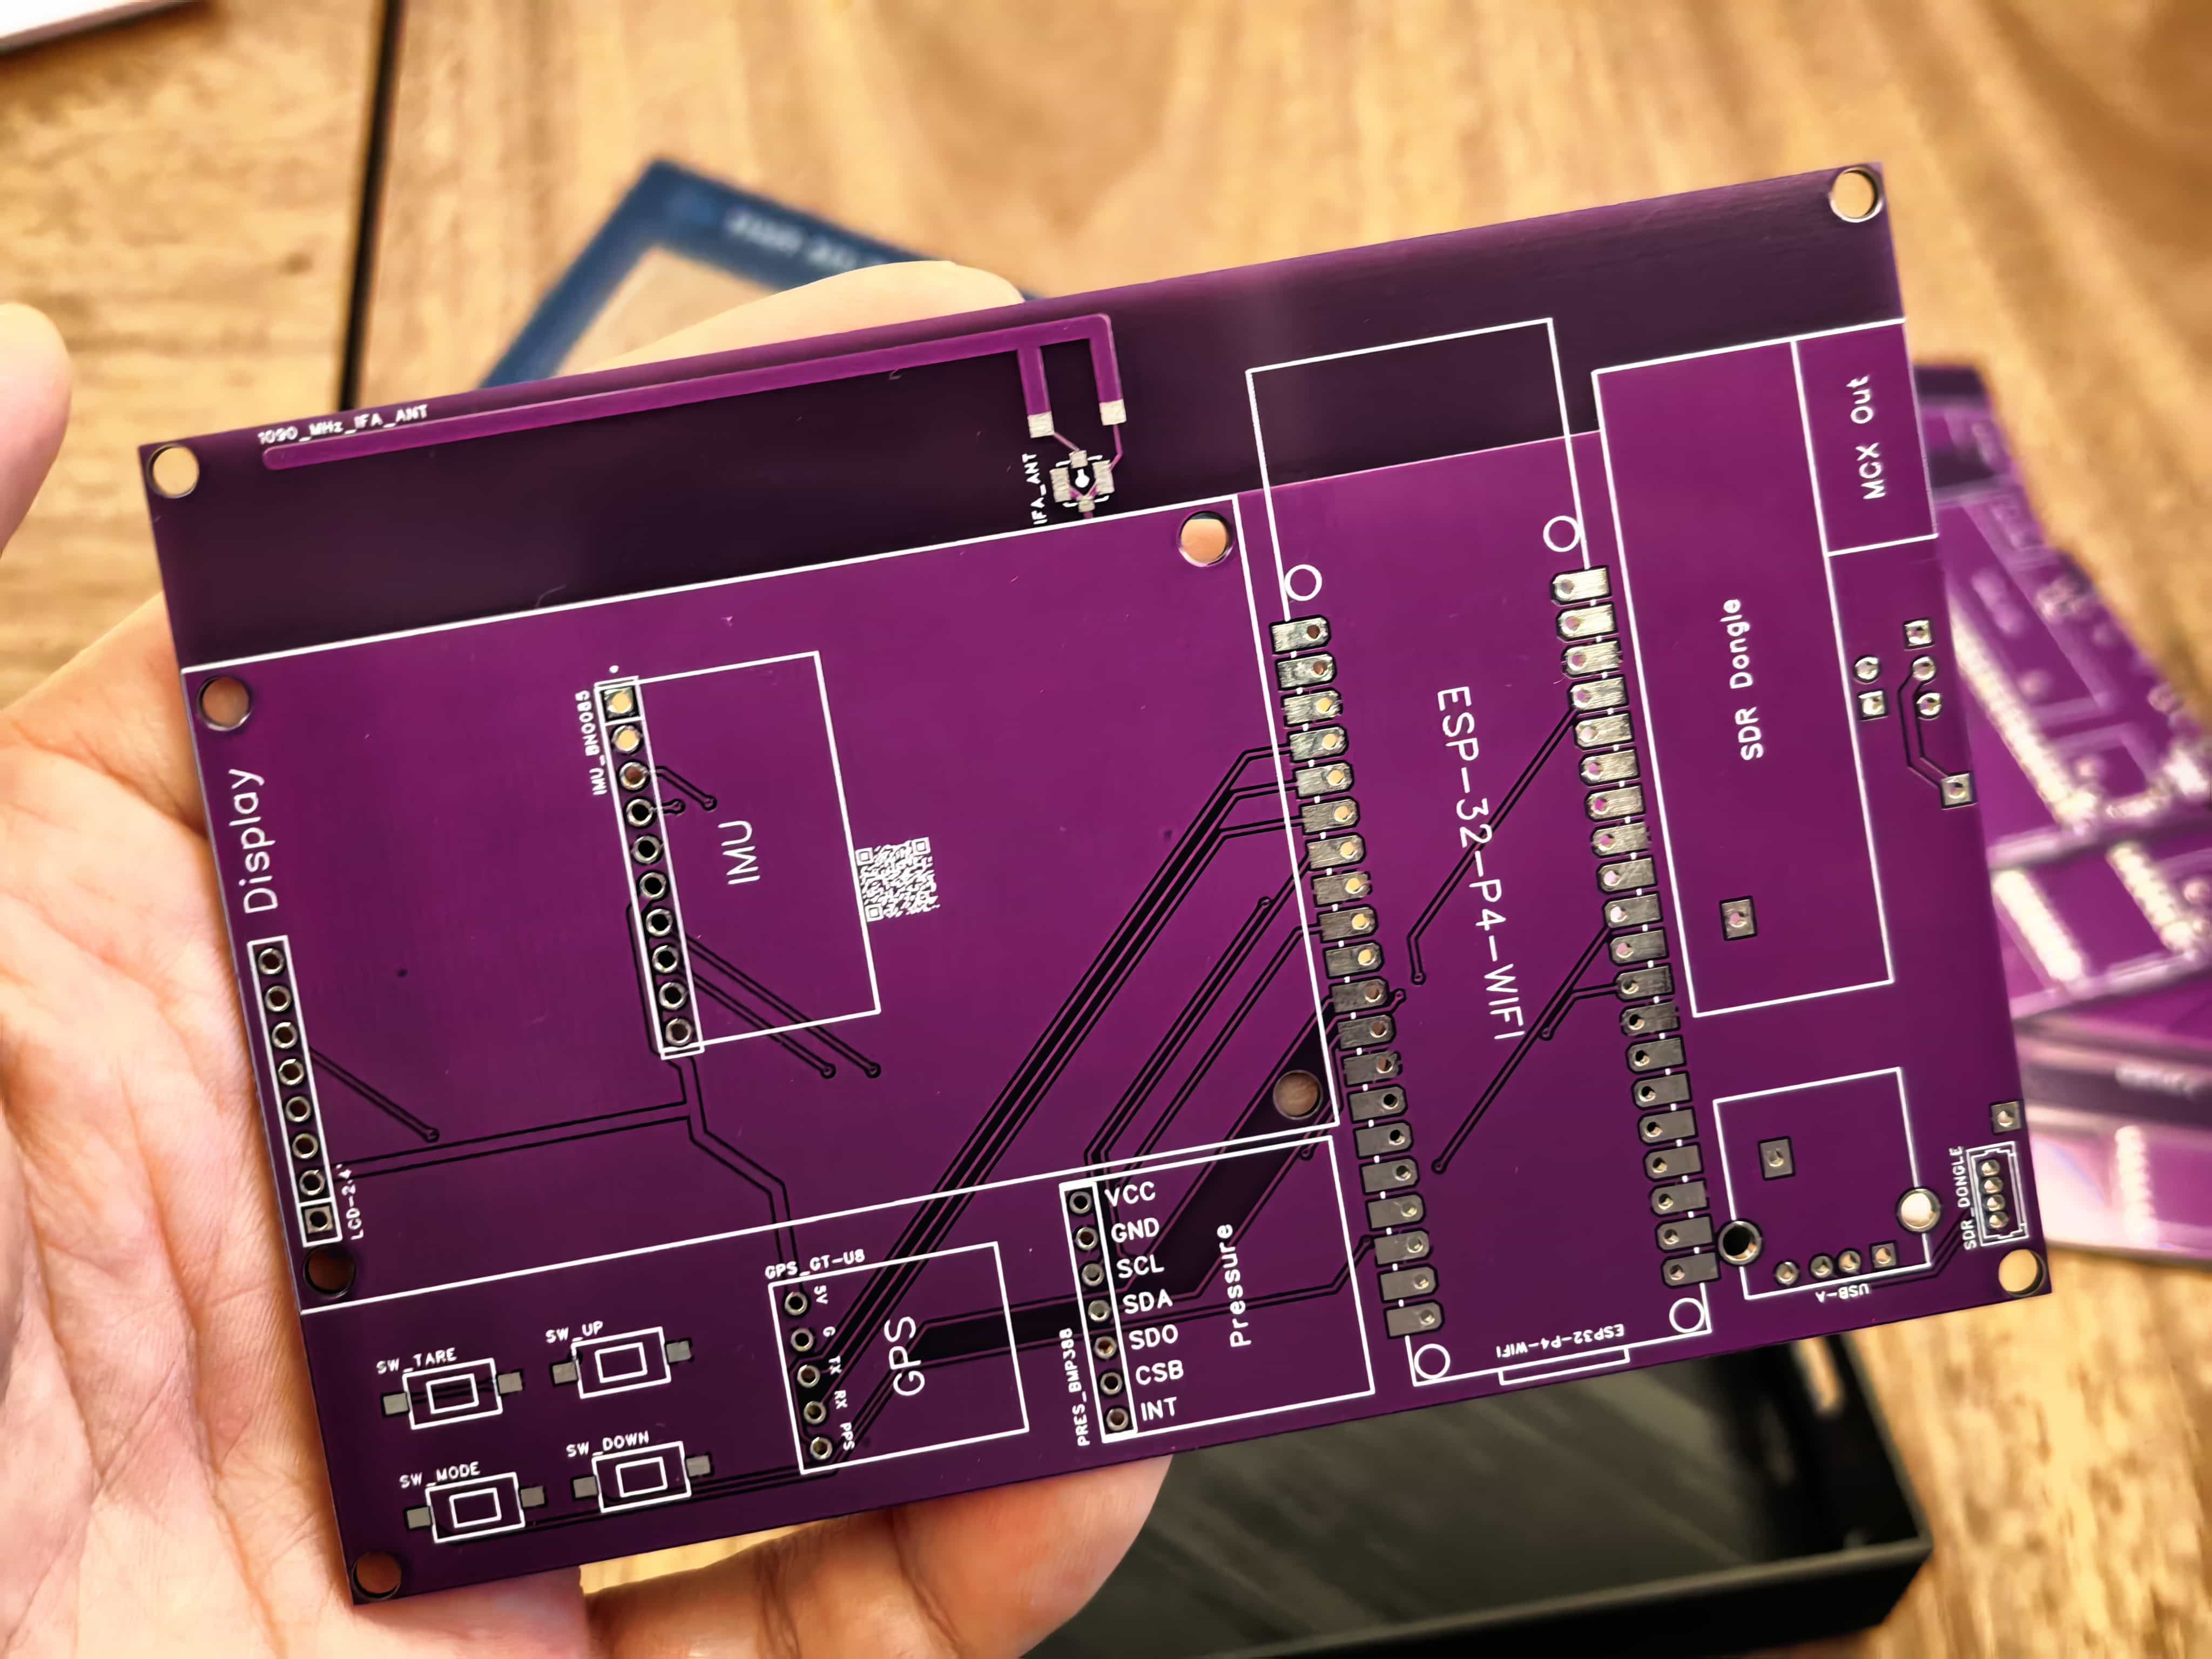
以下 2.4 寸载板(v1 大板,嘉立创 EDA 绘制,见
v1 分支)照片
与设计文件记录的是 v0.8.0 历史原型。它们不是当前 Rev1.2 4.3 寸板的装配或
接线指南。历史立创EDA 工程见
docs/jlc/lcd-2.4in-8pin/。
The following 2.4-inch carrier photos and design files document the
v1 board (the legacy v0.8.0 prototype, drawn in JLC EDA — see the
v1 branch).
They are not assembly or wiring instructions for the current Rev1.2 4.3-inch
board. Legacy EasyEDA sources:
docs/jlc/lcd-2.4in-8pin/.
| 载板 3D · 正面 / PCB 3D Front | 载板 3D · 背面(电池面)/ PCB 3D Back (battery side) |
|---|---|
 |  |
| 布线 · 顶层 / Routing Top | 布线 · 底层 / Routing Bottom |
|---|---|
 |  |
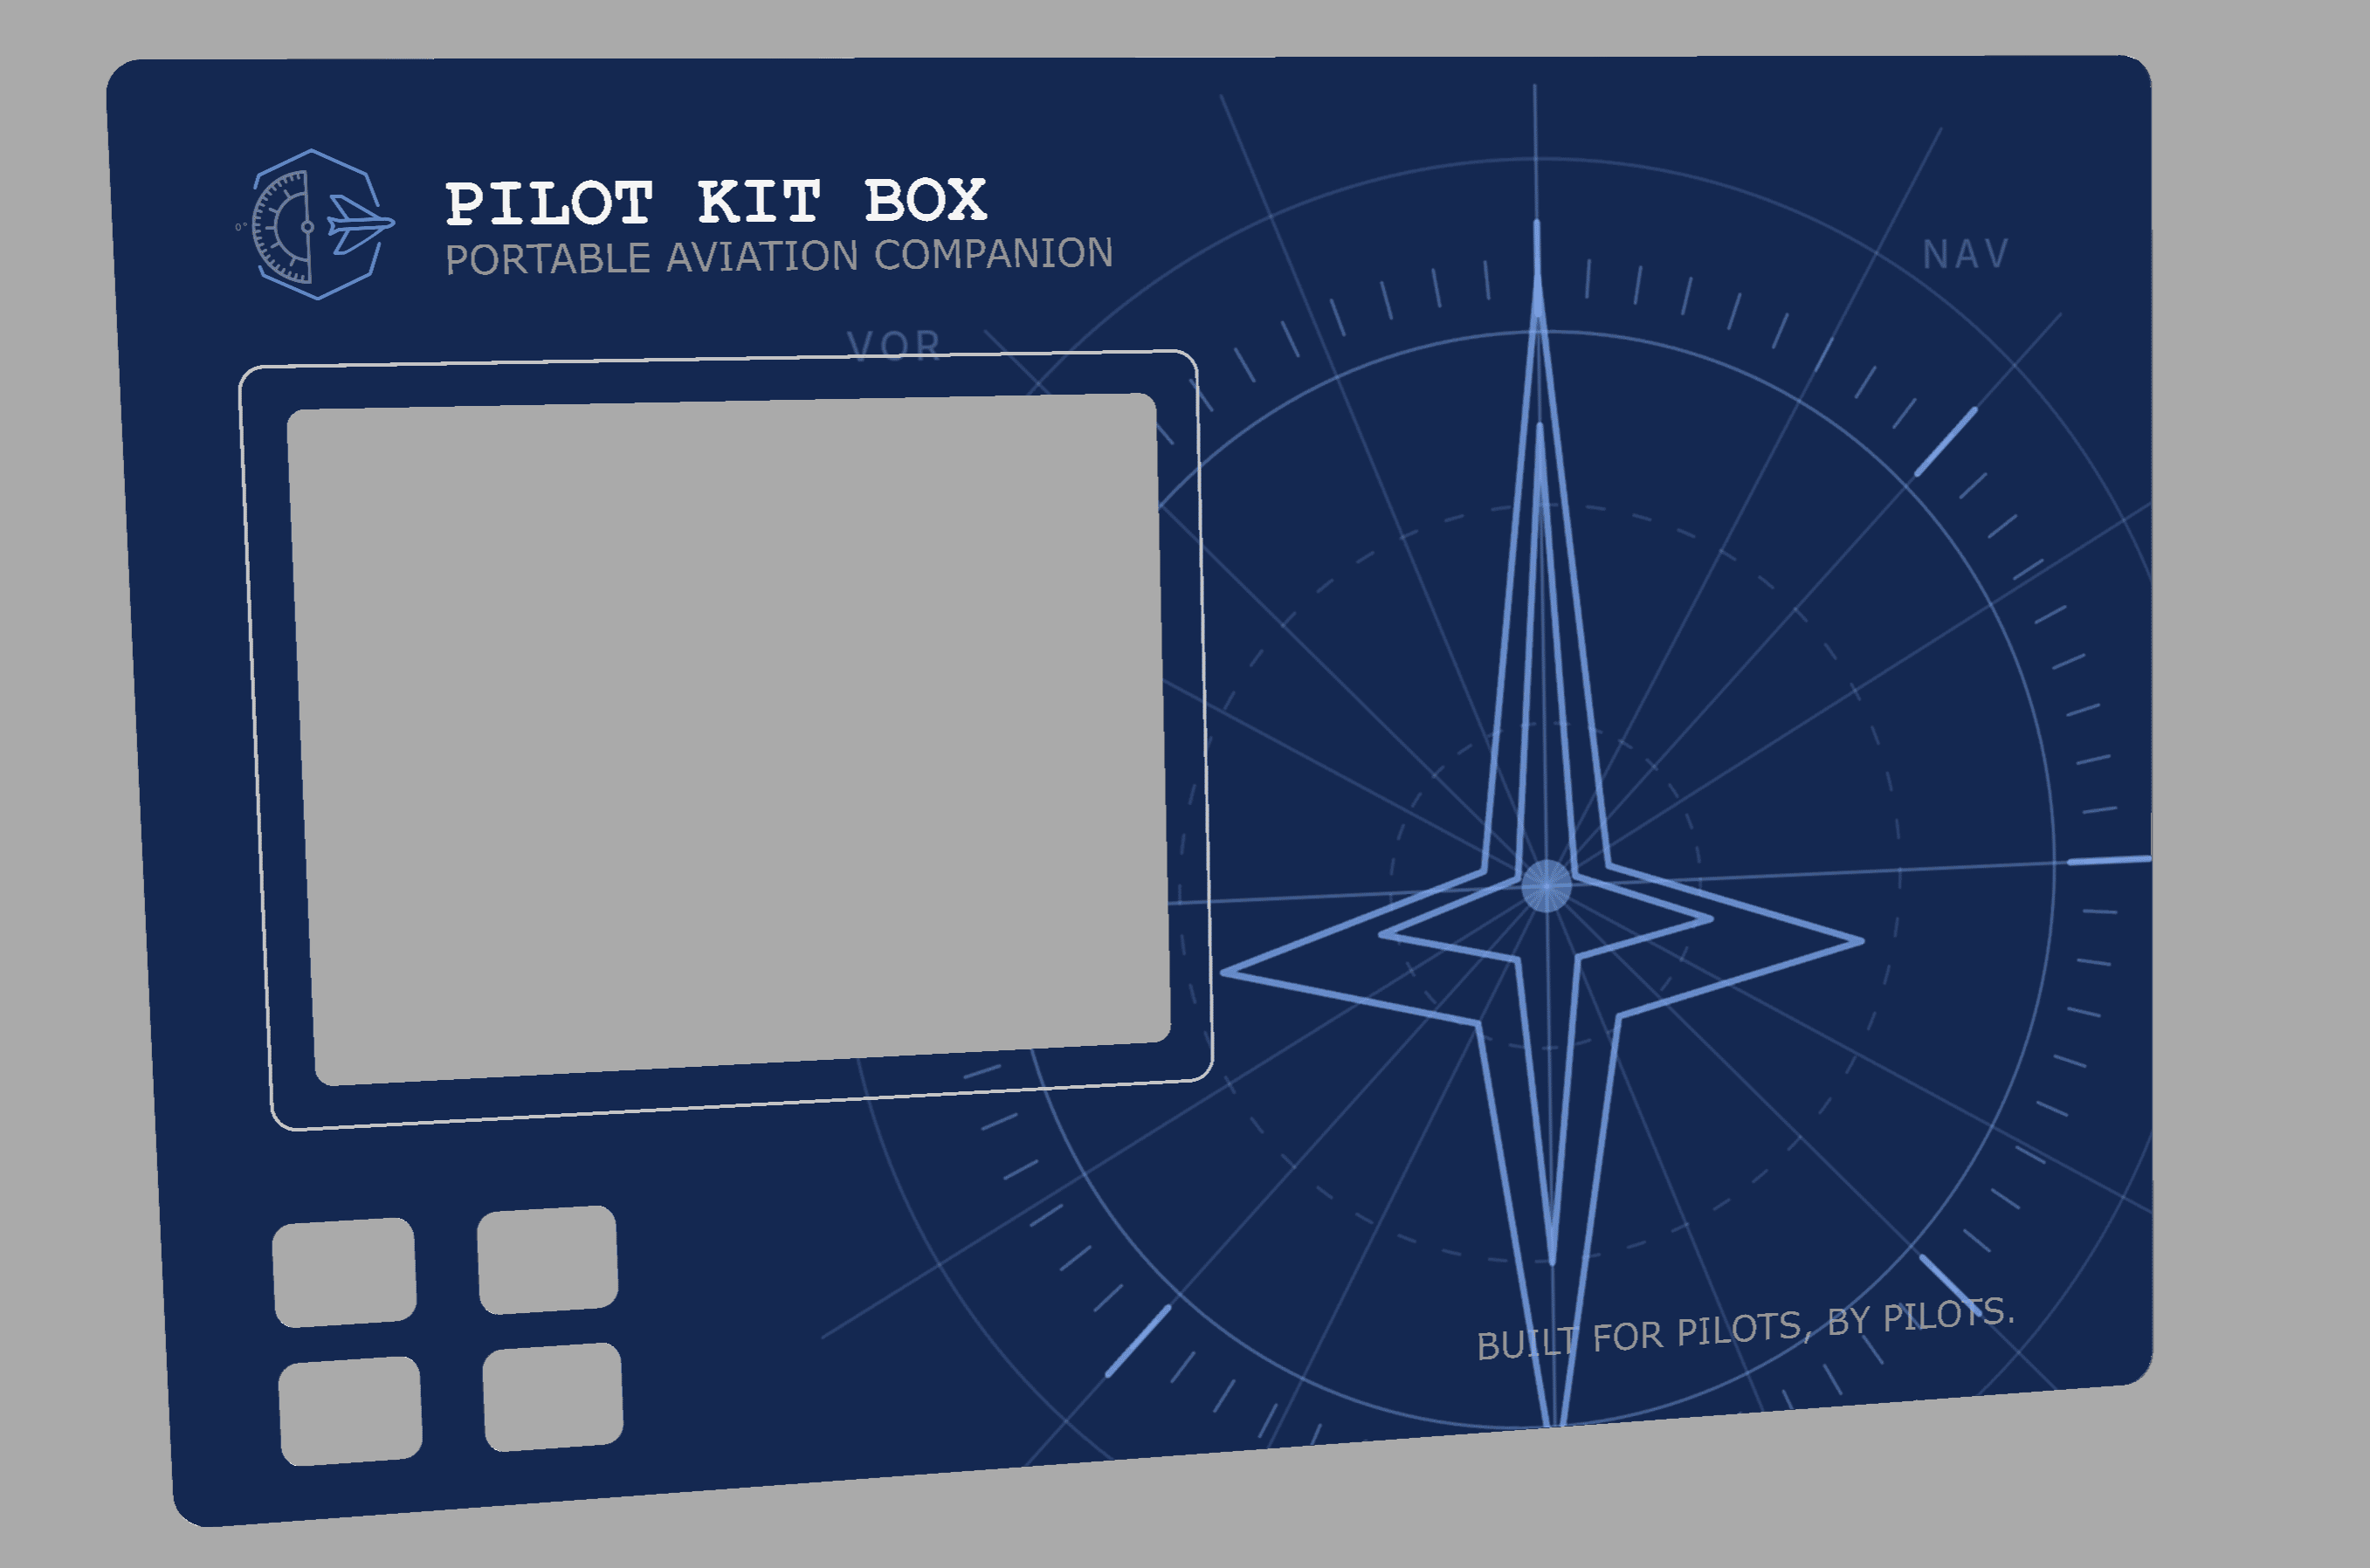
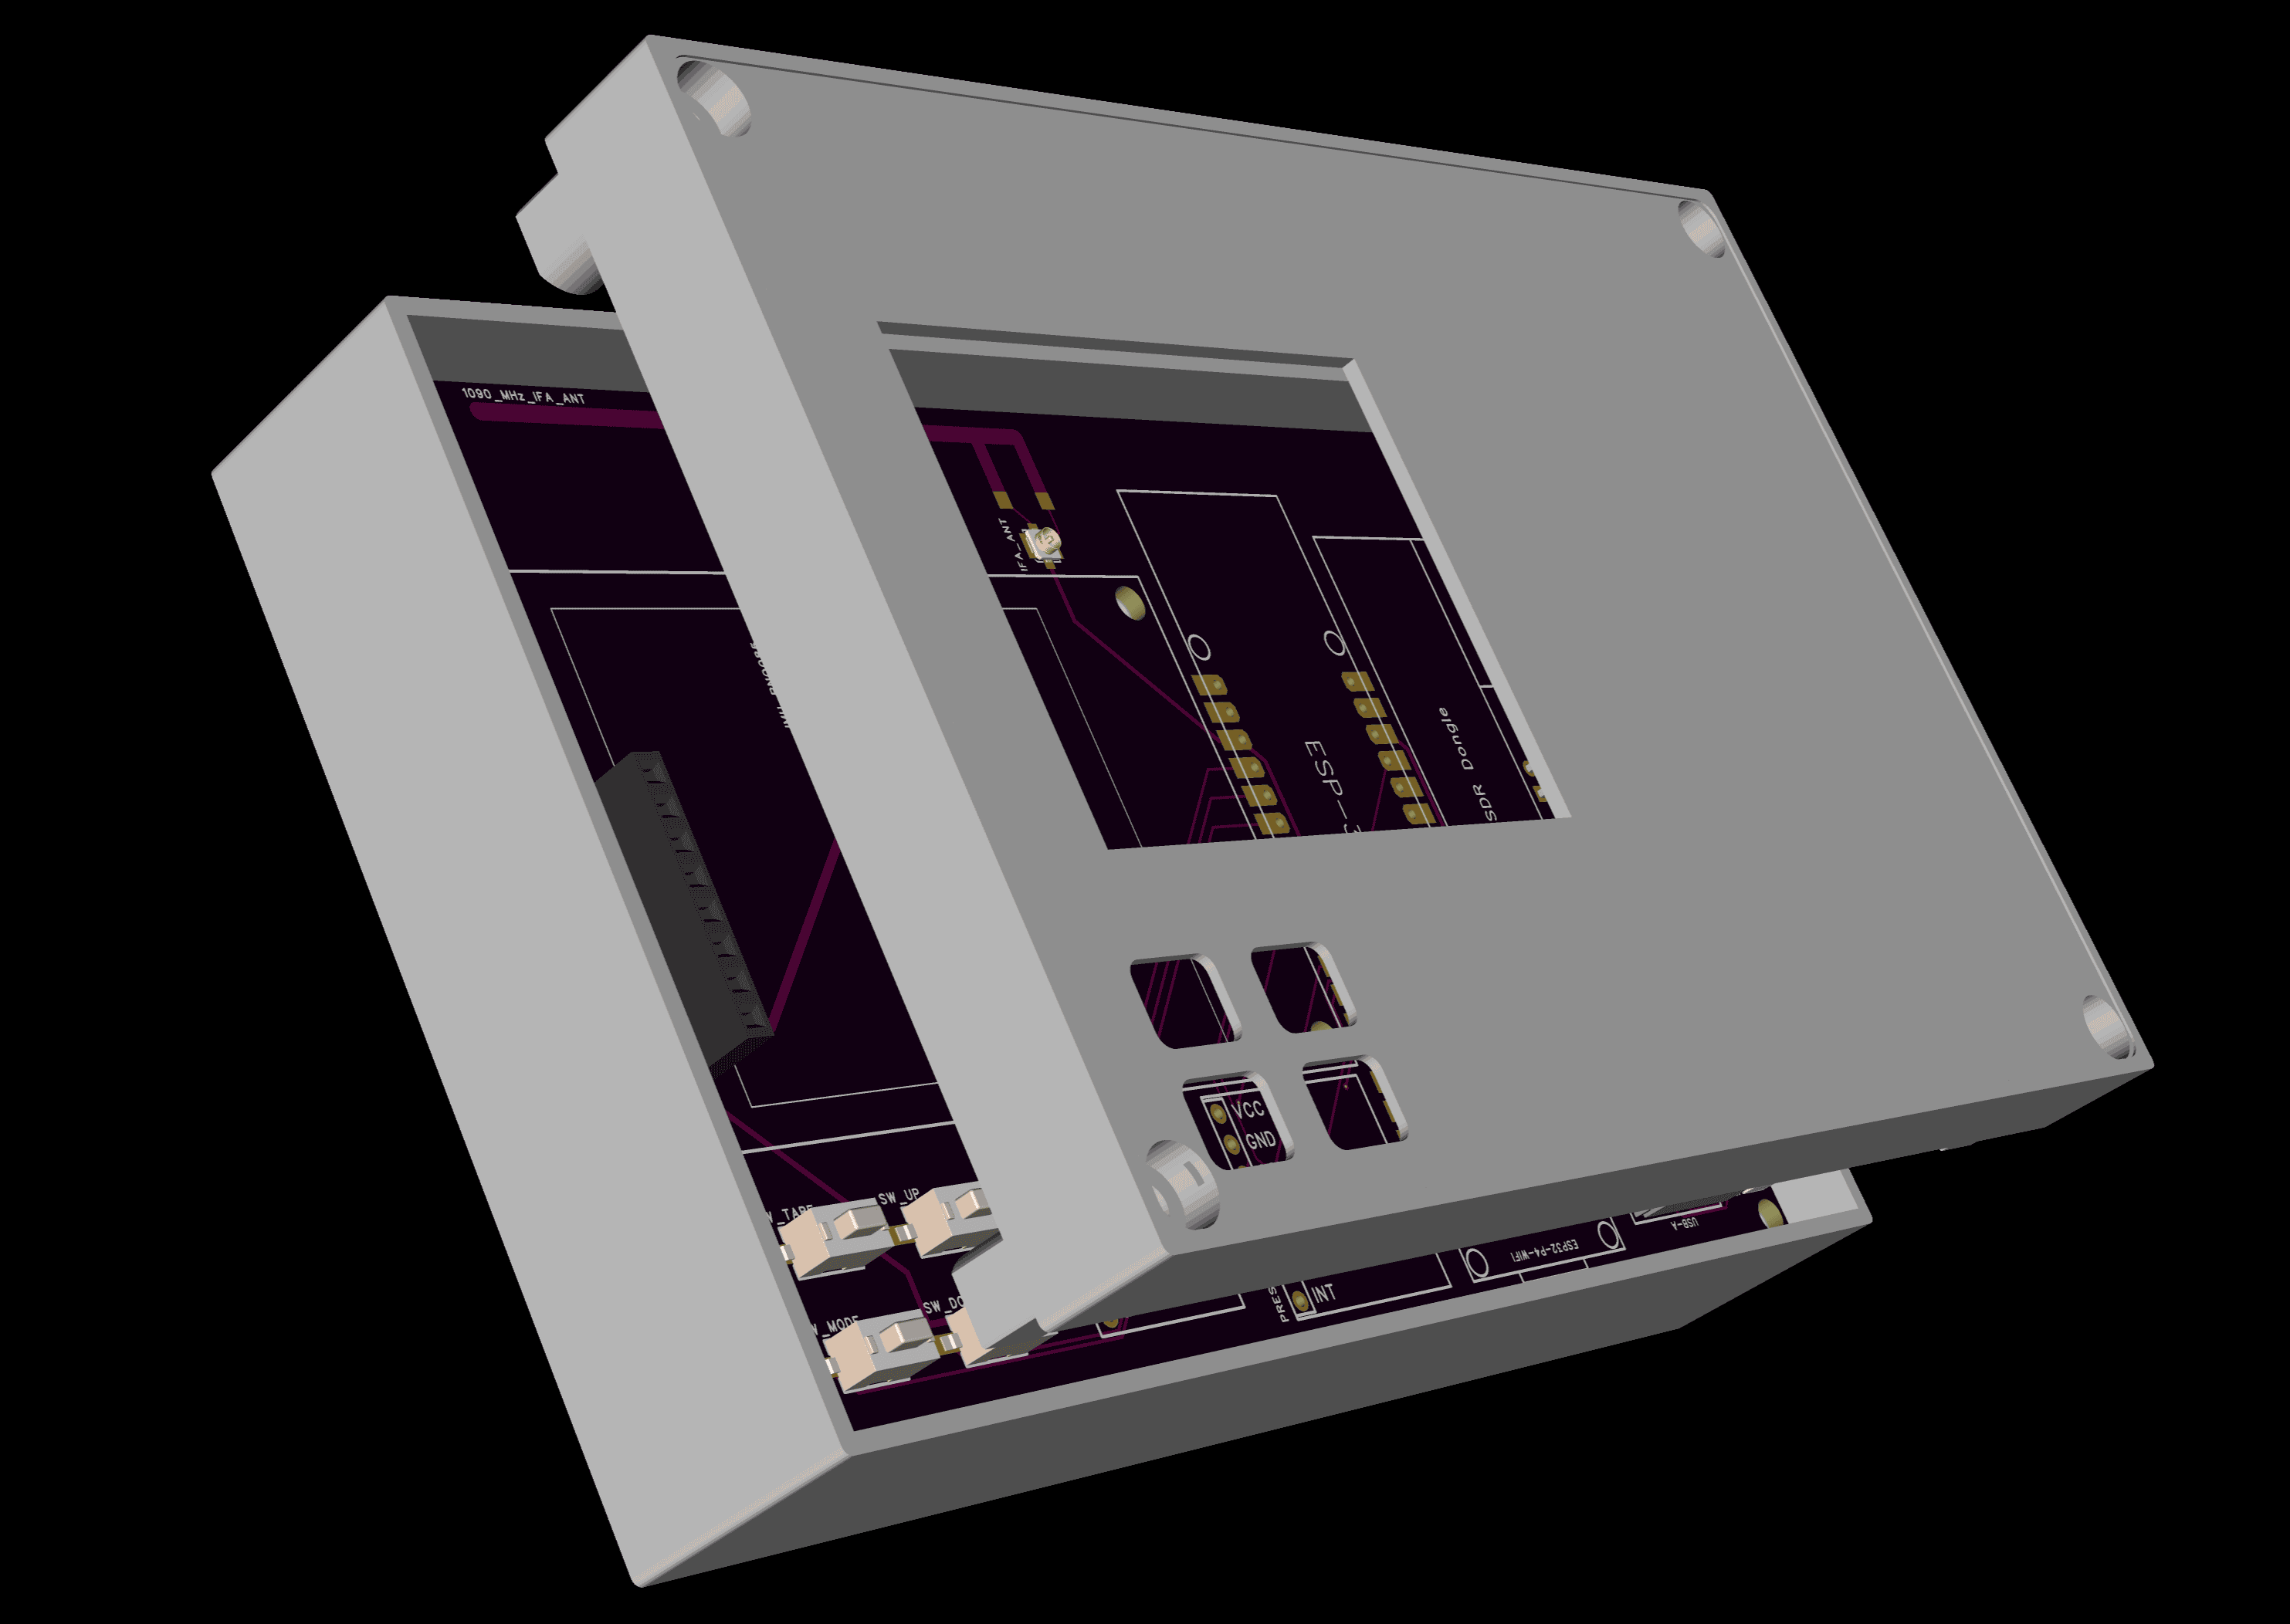
| 外壳面板 / Enclosure Faceplate | 外壳成品 / Enclosure |
|---|---|
 |  |
| 载板实物 / Fabricated Carrier PCB | 载板装配 / Assembled Carrier |
|---|---|
 |  |
| 3D 打印外壳 / Printed Enclosure | 面板装配完成 / Finished Faceplate Assembly |
|---|---|
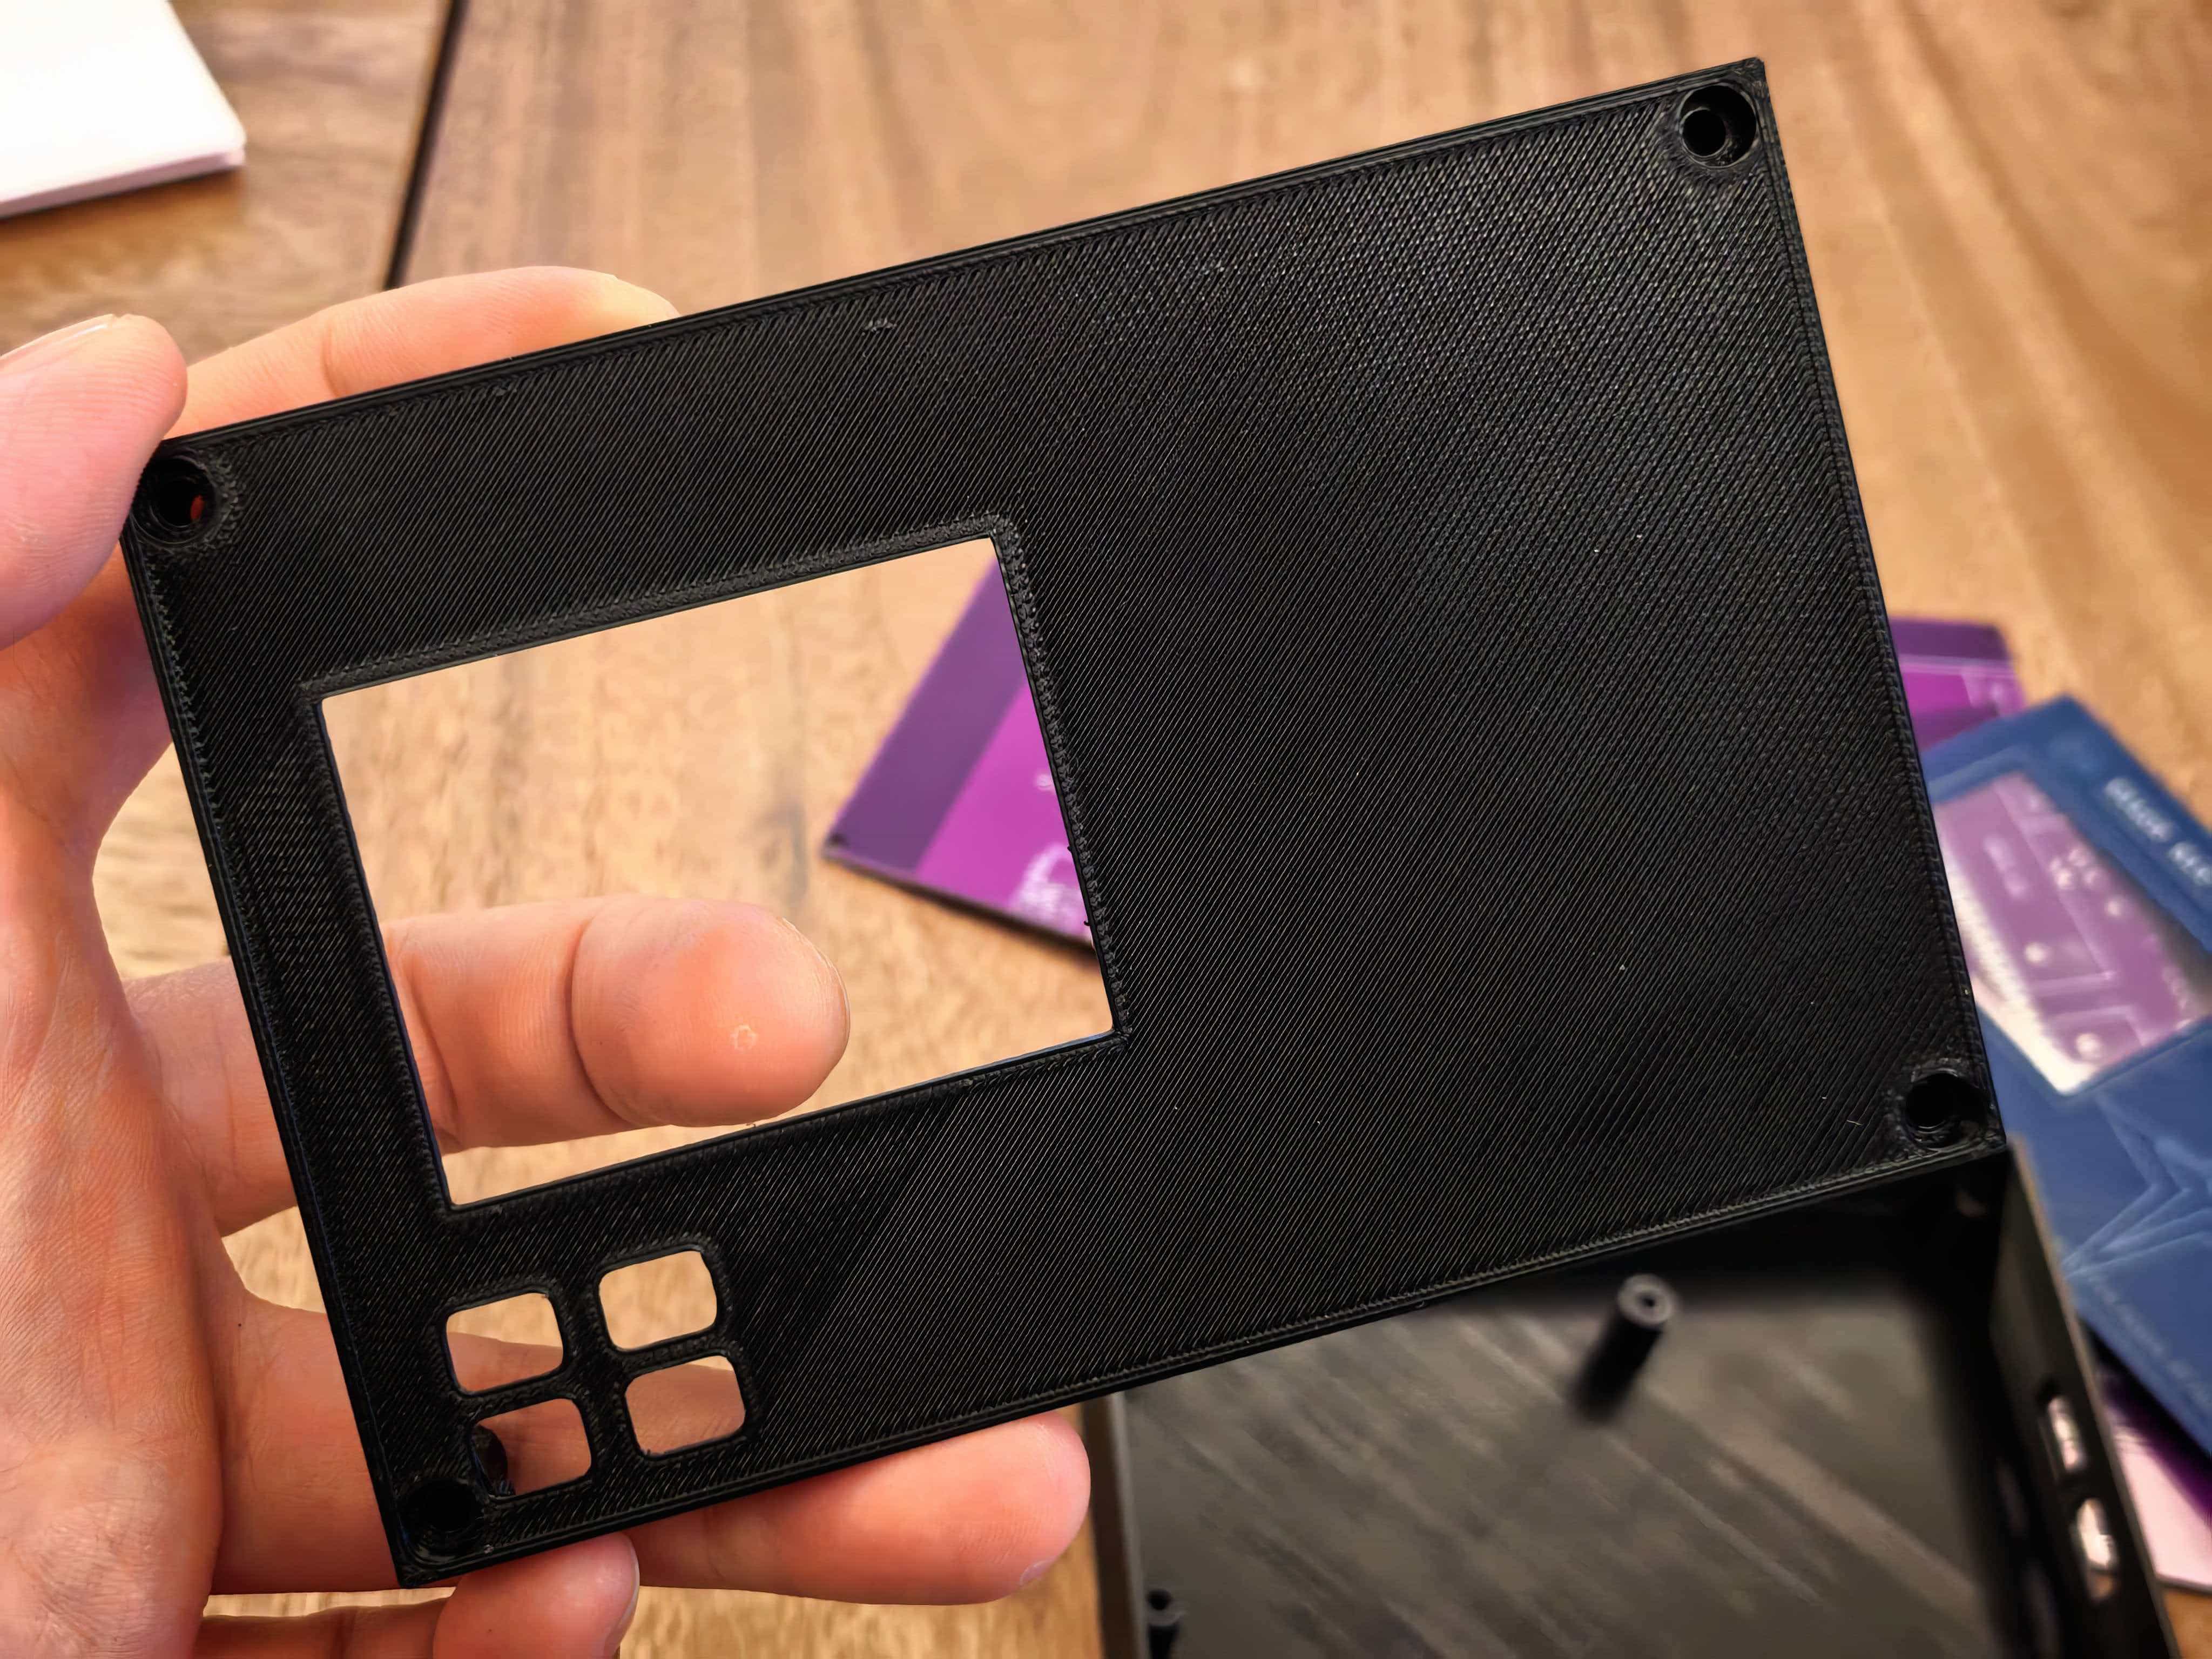 | |
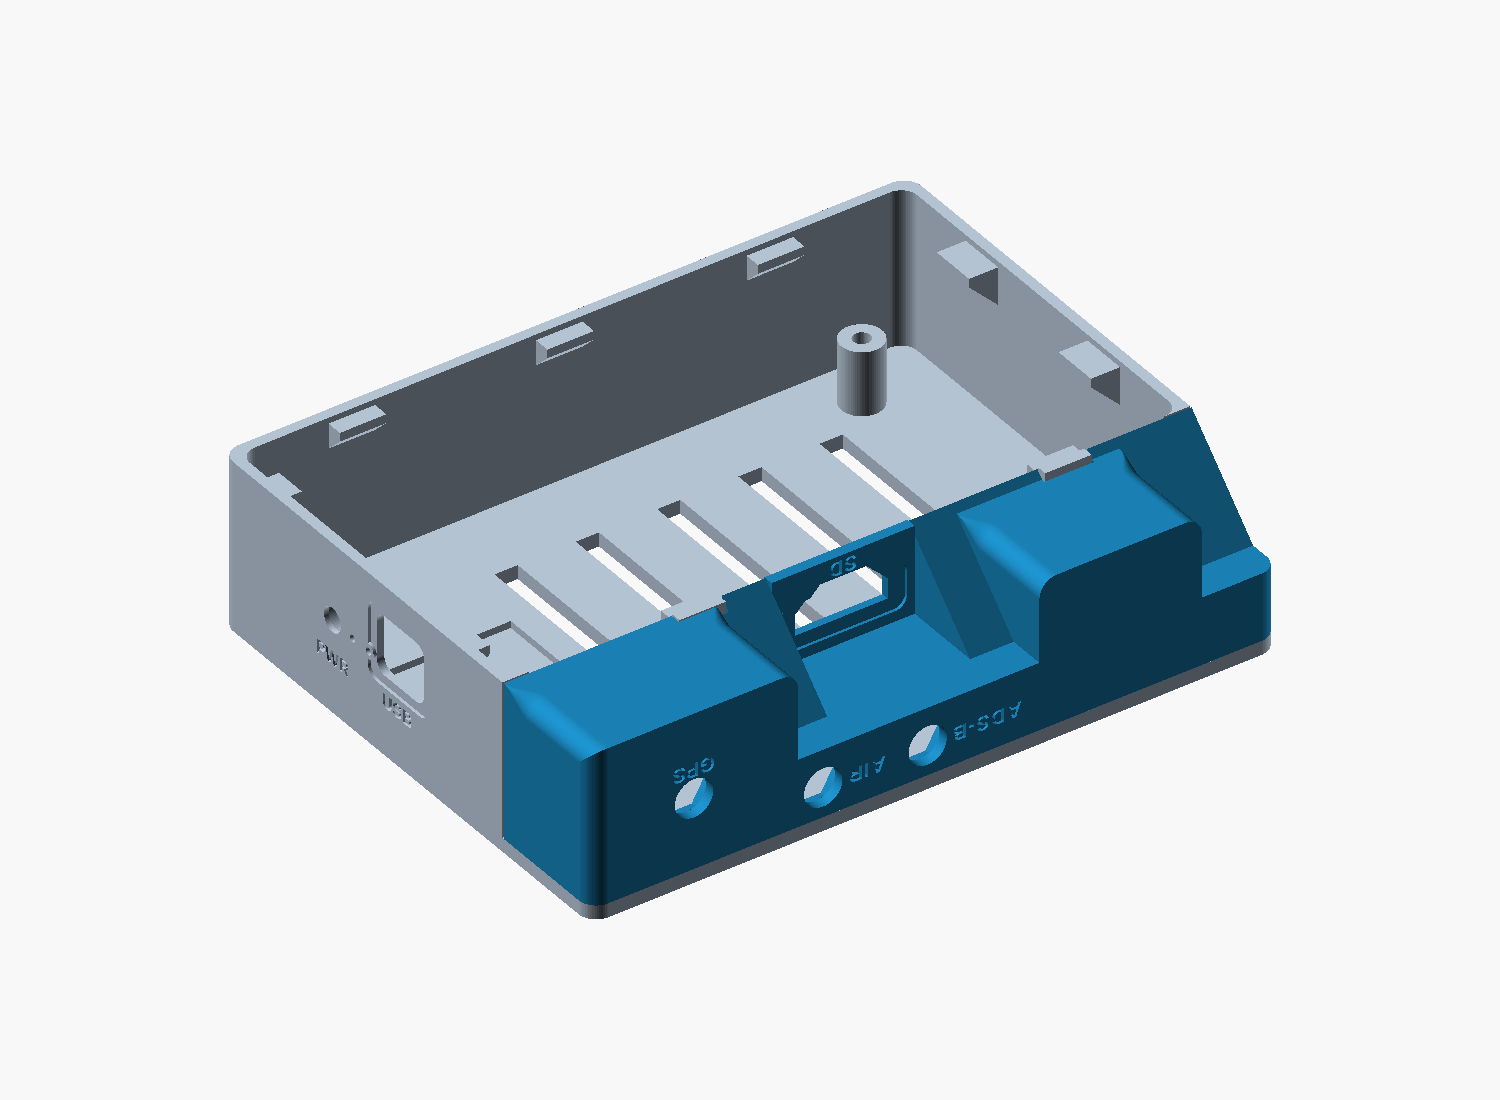
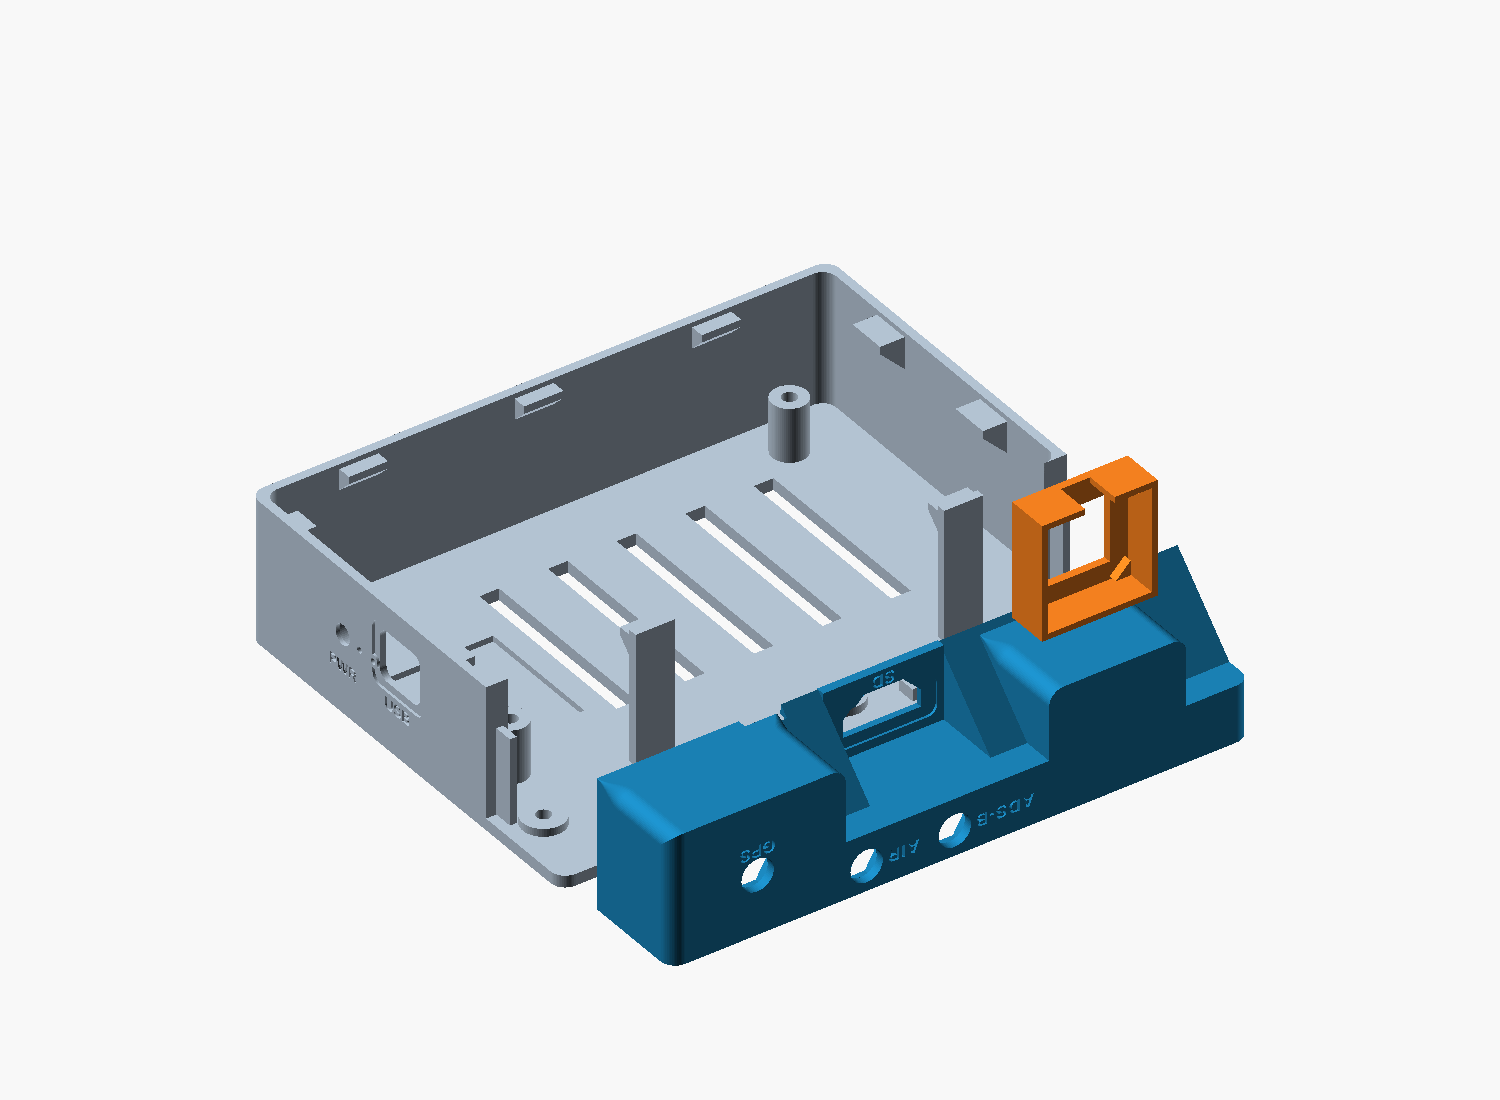
当前外壳为 3D 打印分体结构:主盒 + 顶盖 + GPS 托盘 + 电源按键销,源文件与
打印/装配说明见
docs/jlc/lcd-4.3in/3d-case/v4/。
The current enclosure is a printed split design: main body + top cap + GPS
tray + power plungers. Sources and print/assembly instructions live in
docs/jlc/lcd-4.3in/3d-case/v4/.
| 装配 / Assembly | 爆炸图 / Exploded |
|---|---|
 |  |
| GPS 仓剖面 / GPS bay section | |
|---|---|
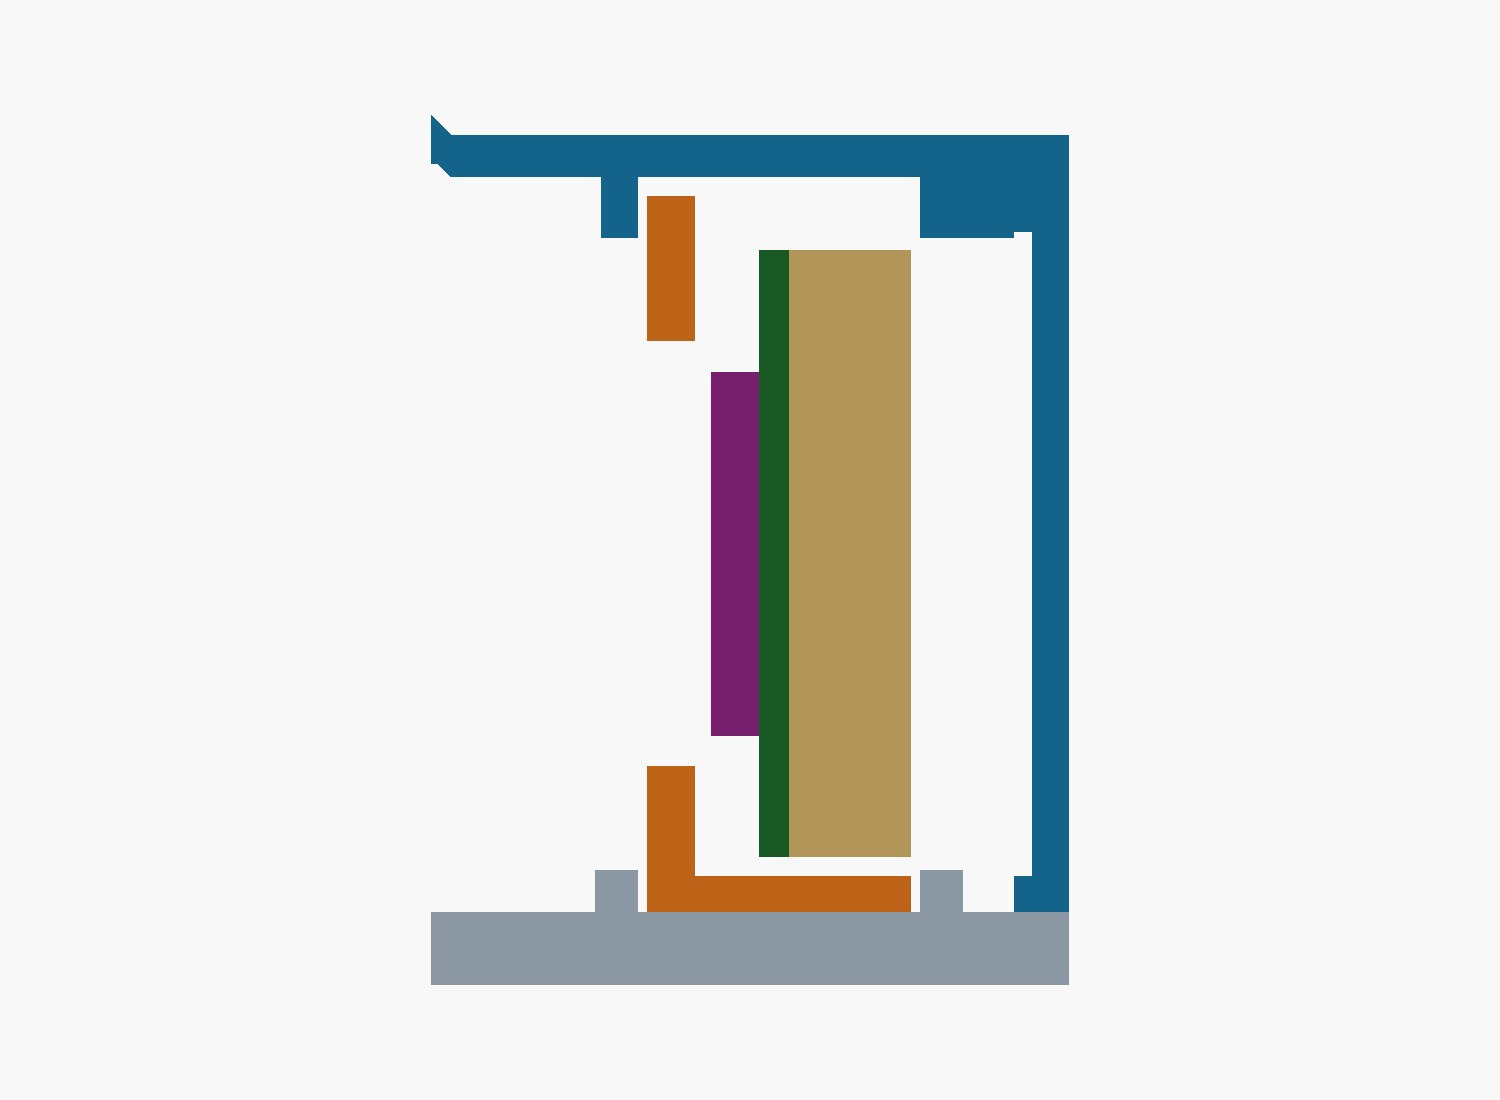 |
| 硬件 | Hardware | 说明 / Notes |
|---|---|---|
| Waveshare ESP32-P4-WIFI6-Touch-LCD-4.3 | Waveshare ESP32-P4-WIFI6-Touch-LCD-4.3 | Rev1.2 一体板:ESP32-P4NRW32、32 MB NOR、32 MB PSRAM、ESP32-C6、ST7701 和 GT911。 Rev1.2 integrated board with ESP32-P4NRW32, 32 MB NOR, 32 MB PSRAM, ESP32-C6, ST7701, and GT911. |
| 集成扩展板 V4.11 | Integrated expansion board V4.11 | 见下节与 hardware/expansion-board-v4/;带电源版 / 不带电源版两种选贴。See the next section and hardware/expansion-board-v4/; powered and unpowered variants. |
| USB-C 数据线 | USB-C data cable | 用于 P4 烧录、串口监视和供电;必须是数据线。 Used for P4 flashing, serial monitoring, and power; it must support data, not charge-only. |
| microSD 卡 | microSD card | 飞行轨迹记录、Airband 录音与离线地图都在卡上;建议 Class 10 及以上。 Flight tracks, Airband recordings and offline maps live on the card; Class 10 or better recommended. |
| 1090 MHz ADS-B 天线 | 1090 MHz ADS-B antenna | 默认用板载 IFA,无需外接;强信号需求场景可经 U.FL 外接(J6)。 The on-board IFA is the default; an external antenna can be attached via U.FL (J6) when range demands it. |
分立模块(IMU / GPS / 气压计)已全部集成到扩展板上,不再需要单独购买和接线; 旧 v1/v2 时代的 RTL-SDR dongle + OTG 方案已退役,固件不再包含该代码。
The discrete sensor modules (IMU / GNSS / barometer) are all integrated on the expansion board — nothing to buy or wire separately. The legacy v1/v2-era RTL-SDR dongle + OTG path is retired and no longer in the firmware.
| 正面 / Top | 背面 / Bottom |
|---|---|
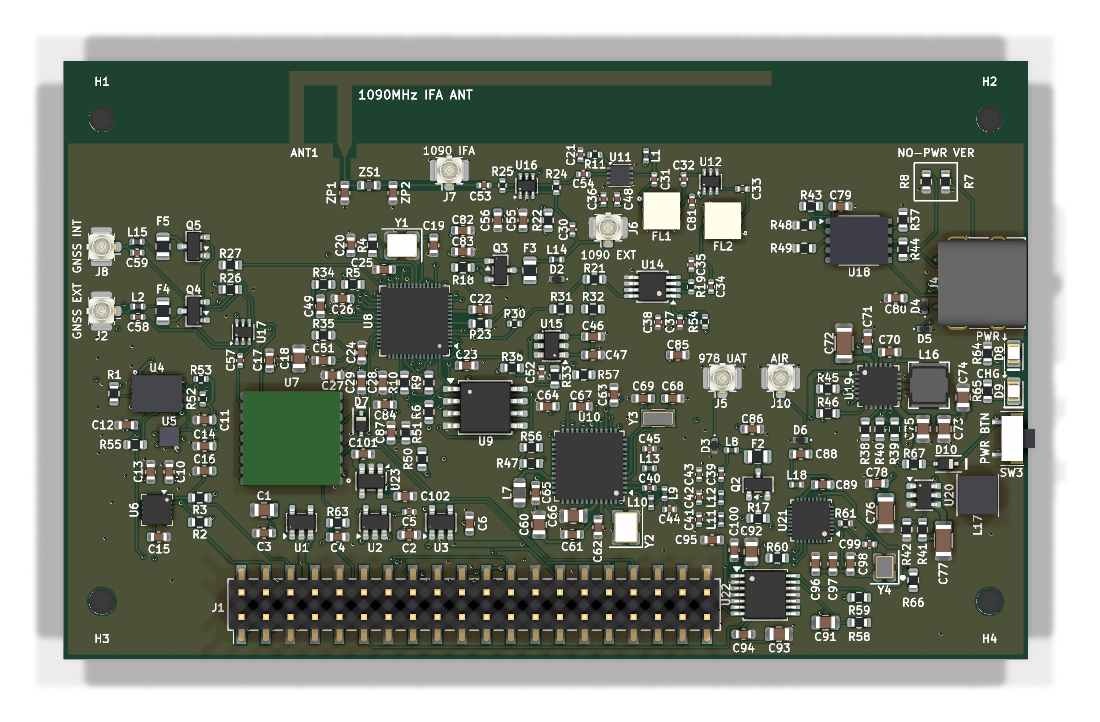 | 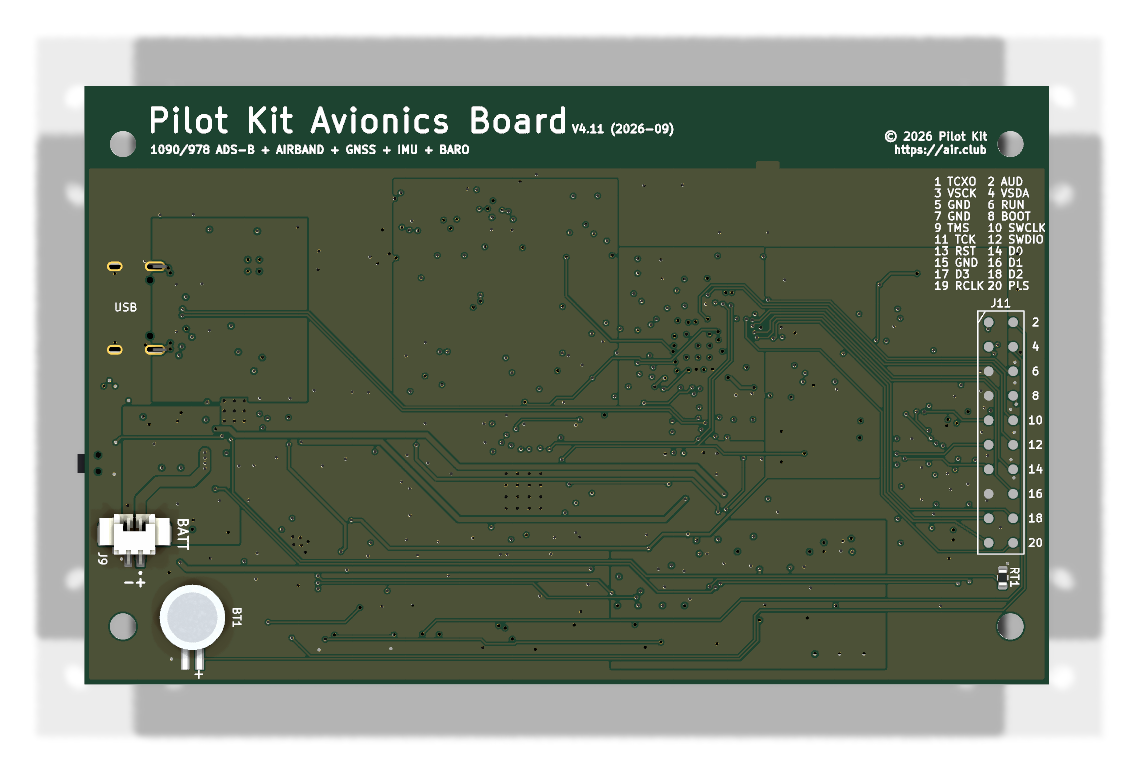 |
上面「必备硬件」里的分立传感器模块,已被 V4.11 集成扩展板取代。
它以 HAT 方式直插 Waveshare 载板的 2×20 排母,把接收链、传感器和电源
整合到一块 6 层板上,并自带 1090 MHz 接收链,不再需要 RTL-SDR
dongle(该 USB 路径已随 v1/v2 载板退役,固件与组件树均不再包含)。
工程、文档与制造包在
hardware/expansion-board-v4/(该目录的
README 是双语的)。
The discrete sensor modules listed under Required Hardware above have been
replaced by the V4.11 integrated expansion board. It stacks onto the
Waveshare carrier's 2×20 header as a HAT and folds the receive chains,
sensors, and power into one 6-layer PCB — including its own 1090 MHz
receive chain, so no RTL-SDR dongle is needed (that USB path is retired
along with the v1/v2 carriers; neither the firmware nor the component tree
still carries it). Project, docs, and fabrication packages live in
hardware/expansion-board-v4/ (bilingual
README).
| 项目 | Item | 规格 / Specification |
|---|---|---|
| 板框 / 层数 | Outline / layers | 100.1 × 62.1 mm,6 层(JLC06161H-3313) 100.1 × 62.1 mm, 6 layers (JLC06161H-3313) |
| 1090 MHz 接收 | 1090 MHz receive | LNA + SAW + 对数检波 + 比较器 → RP2040 PIO 解码 LNA, SAW, log detector, comparator into an RP2040 PIO decoder |
| 978 MHz UAT | 978 MHz UAT | Sub-GHz 收发器 + 差分 LC 匹配 Sub-GHz transceiver with differential LC matching |
| 航空电台接收 | Airband RX | 118–137 MHz AM 接收 + 24-bit I²S 采集(仅收音,无发射) 118–137 MHz AM receiver with 24-bit I²S capture (receive only, no TX) |
| 天线 | Antennas | 板载 1090 IFA(π 网络可调)+ 四个 U.FL 外接口(1090 / 978 / GNSS / 航空电台) On-board 1090 IFA (tunable π network) plus four U.FL ports (1090 / 978 / GNSS / airband) |
| 传感器 | Sensors | 四星座 GNSS(内置 patch / 外接可切)、BNO085 IMU、气压计、磁力计 4-constellation GNSS (internal patch / external switchable), IMU, barometer, magnetometer |
| 电源(选贴) | Power (optional) | USB-PD 诱骗 9V + 充电/电量计 + 升压 5V + 单节锂电 USB-PD sink at 9 V, charger/fuel gauge, 5 V boost, single-cell Li-po |
| 规模 | Scale | 231 个位号 + 4 安装孔、506 个过孔、1952 段走线(无 MARK 点) 231 placements + 4 mounting holes, 506 vias, 1952 track segments (no MARK/fiducials) |
状态:V4.11 已打板并通过整机测试(当前版本;带电源版 176 件
SMT + 43 件手贴已核对)。历史版本 V4.10 亦完成整板 bring-up;SW3 检测
ECO 已在 V4.11 固化。制造包与版本表见
release/;板载 IFA 装盒后的
VNA 实测与调谐流程见
BOM_IFA_TUNING.md。
Status: V4.11 fabricated and verified on the full stack (current
version; the powered variant's 176 SMT + 43 hand placements are checked
off). The earlier V4.10 also completed a full-board bring-up, and the
validated SW3 sensing ECO is frozen into V4.11. Fabrication packages and
the version table live in
release/; the in-enclosure VNA
measurement and tuning procedure for the on-board IFA is documented in
BOM_IFA_TUNING.md.
| 文档 | Document | 内容 / Contents |
|---|---|---|
PINMAP.md | 权威引脚/网络映射 / Authoritative pin and net map | |
ASSEMBLY.md | 手工贴片点位清单(脚本从板子生成)/ Hand-assembly placement list, generated from the board | |
CHECKLIST.md | 按位号贴片核对表(另附 .xlsx/.pdf 打印版)/ Per-reference placement checklist (with printable .xlsx/.pdf) | |
web/assembly/ | 贴片助手(浏览器交互式):焊盘图高亮当前位号、备料/换料卡、整组推进与计时,覆盖 V3.2 与 V4.5–V4.11 各变体 / Interactive placement assistant (browser): pad-map highlight, kitting/changeover cards, per-group progress and timing, covering V3.2 and V4.5–V4.11 variants | |
VARIANTS.md | 带电源 / 不带电源两个选贴版本 / Powered and unpowered assembly variants | |
SELECTIVE_PLACEMENT.md | 贴装分组与互斥规则(贴错会烧板)/ Placement groups and mutex rules | |
BOM_PURCHASE-zh_CN.md | 权威采购清单(脚本从网表生成)/ Authoritative purchasing list, generated from the netlist | |
BOM_IFA_TUNING.md | IFA 调谐备料与装盒 VNA 调试流程 / Antenna tuning kit and the in-enclosure VNA procedure | |
BASEBOARD_REF.md | 载板机械参数基准 / Mechanical reference for the Waveshare carrier |
以上文档均提供英文正名版与 -zh_CN.md 简体中文版;完整索引见
hardware/expansion-board-v4/README.md。
Each ships as an English canonical file plus a -zh_CN.md Simplified-Chinese
counterpart; see the v4 README for the full index.
以 v4 扩展板为准(两片用量、含备损;完整料号与选型依据见
BOM_PURCHASE-zh_CN.md):
| 项目 / Item | 金额 / Cost | 说明 / Notes |
|---|---|---|
嘉立创 SMT 贴装(full 方案,2 片)JLC SMT assembly ( full profile, 2 boards) | 实付 ¥51.06 ¥51.06 paid | 46 种 / 126 件 / 252 焊点;工程费、焊盘费、换料费优惠券后为 0 46 parts / 126 placements; setup & fees waived by coupons |
| 手贴件:贵价射频 IC、电源 IC、B 面件等 Hand-placed: pricier RF/Power ICs, B-side parts | 另计 extra | 数量与料号见 BOM_PURCHASE.md 中未列入嘉立创 SMT 贴装(手贴)的行;按 VARIANTS.md 的选贴规则取用see the hand-placed (non-SMT) rows in BOM_PURCHASE.md; quantities per VARIANTS.md |
| 6 层 PCB 打样(JLC06161H-3313,含盘中孔工艺) 6-layer PCB fab (JLC06161H-3313, via-in-pad) | 另计 extra | 叠层与阻抗依据 PCB_STACKUP_IMPEDANCE.md / see stackup doc |
| 外壳 / Enclosure | 另计 extra | 3D 打印(嘉立创) / 3D printed (JLC) |
2026-07-31 之前的 2.4 寸载板(v1)时代旧成本表已随
v1分支归档,可在 该分支的本文件历史中查阅。The legacy v1-era cost table is archived with thev1branch (see that branch's history of this file).
| 硬件 | Hardware | 说明 / Notes |
|---|---|---|
| USB-UART 转接器 | USB-UART adapter | 每块新 Waveshare 板首次烧 ESP32-C6 hosted slave 固件时需要;详见 docs/hardware/c6_slave_firmware.md。Required once per fresh Waveshare board to flash the ESP32-C6 hosted slave firmware; see docs/hardware/c6_slave_firmware.md. |
| 杜邦线 / 短接线 | Jumper wires / shorting wire | C6 首次烧录时把 P1-3 IO9 短接到 GND。 For shorting P1-3 IO9 to GND during first-time C6 flashing. |
| 3.7V 4000mAh 锂电池 | 3.7V 4000mAh lithium battery | 便携版本的标准电池;整机实测平均功耗约 606 mA,续航 5 小时以上。 The standard battery for portable builds; measured average draw is about 606 mA, giving 5+ hours of runtime. |
| 5V 2A / 2.4A Type-C 口充电模块 | 5V 2A / 2.4A Type-C charging module | 电池供电版本使用;给系统提供稳定 5V 输入。 Used in battery-powered builds to provide a stable 5V system input. |
| 外壳、支架、屏蔽和固定件 | Enclosure, mounts, shielding, fixtures | 当前外壳的源文件与打印/装配说明见 docs/jlc/lcd-4.3in/3d-case/v4/。Sources and print/assembly instructions for the current enclosure live in docs/jlc/lcd-4.3in/3d-case/v4/. |
ESP32-C6-MINI-1 通过 SDIO 作为 Wi-Fi 6 / BLE 5 协处理器;当前固件使用 BLE。
MicroSD 卡座已启用;设置页可在 10 MiB LittleFS 与 MicroSD 记录之间切换,并支持卡状态诊断和二次确认格式化。
CH343P USB-UART 桥用于 P4 烧录和串口监视。
ES8311 音频 codec、麦克风、扬声器功放为板载资源;扬声器输出已用于航空电台 (Airband)收听与录音回放。
The ESP32-C6-MINI-1 is connected over SDIO as the Wi-Fi 6 / BLE 5 co-processor; the current firmware uses BLE.
The MicroSD slot is active; Settings can select 10 MiB LittleFS or MicroSD recording, with card diagnostics and guarded formatting.
The CH343P USB-UART bridge handles P4 flashing and serial monitoring.
The ES8311 codec, microphone, and speaker amplifier are on-board; the speaker output now serves Airband listening and recording playback.
| 路径 | Path | 内容 / Contents |
|---|---|---|
firmware/ | firmware/ | ESP-IDF v6.0.1 固件工程 / ESP-IDF v6.0.1 firmware project |
firmware/main/ | firmware/main/ | 应用层 C 源码和编进固件的识别数据表(航司代码、ICAO24 国家段) / Application C sources and the identity tables compiled into the firmware (airline codes, ICAO24 countries) |
firmware/components/ | firmware/components/ | 工程内组件(adsb_link 编解码、LCD 驱动等) / In-tree components (adsb_link codec, LCD drivers, …) |
firmware/scripts/ | firmware/scripts/ | 字体、数据库和测试脚本 / Font, database, and test scripts |
hardware/expansion-board-v4/ | hardware/expansion-board-v4/ | 当前硬件目标:6 层集成扩展板 KiCad 工程、生成/校验脚本与装配文档 / Current hardware target: 6-layer integrated expansion board — KiCad project, generator/verification scripts, and assembly docs |
hardware/expansion-board-v3/ | hardware/expansion-board-v3/ | 上一版 4 层扩展板(v3.2 已打样,已归档;仍用于固件调试)——见其 README / Previous 4-layer expansion board (v3.2 fabricated, archived; still used for firmware debugging) — see its README |
datafiles/ | datafiles/ | SD 卡离线数据工作区:data/ 机型库与航空数据 bin、maps/ 底图包(内容不进 git,见 datafiles/README.md) / microSD offline data workspace: data/ aircraft and aeronautical binaries, maps/ basemap packs (contents gitignored, see datafiles/README.md) |
docs/ | docs/ | 构建、协议、架构、用户和硬件文档 / Build, protocol, architecture, user, and hardware docs |
web/flasher/ | web/flasher/ | ESP Web Tools 网页刷机页面 / ESP Web Tools web flasher |
web/assembly/ | web/assembly/ | 贴片助手(浏览器交互式手工贴片向导,见上文文档表)/ Interactive browser placement assistant (see doc table above) |
tools/firmware_release/ | tools/firmware_release/ | 固件发布打包工具 / Firmware release packaging tools |
盒子用三类本地识别数据库,把 ADS-B / Mode-S 中收到的 ICAO24 地址和呼号显示为更容易核对的航空信息。它们不是航班计划、航线、时刻表或实时联网数据。机型库放在 microSD 卡上(/sdcard/aero/pk_actdb.bin),更新只需把新文件拷进卡里,不用刷固件;航司代码表和 ICAO24 国家地址段仍编进固件镜像,随固件更新。
The box uses three local identity databases so ICAO24 addresses and ADS-B callsigns can be rendered as operationally useful aviation information. These are not flight-plan, route, timetable, or live network databases. The aircraft database lives on the microSD card (/sdcard/aero/pk_actdb.bin) and is refreshed by copying a new file onto the card — no reflash. The airline code table and ICAO24 country ranges are still compiled into the firmware image and ship with firmware updates.
| 数据库 | Database | 用途 / Purpose | 仓库位置 / Repository Location | 更新脚本 / Update Script |
|---|---|---|---|---|
| 飞机 ICAO24 数据库 | Aircraft ICAO24 database | ICAO24 -> 注册号、ICAO 机型代码、型号名称、Doc 8643 技术描述;当前快照约 574k 条记录、8.21 MB,随 SD 卡分发(/sdcard/aero/pk_actdb.bin),不再嵌入固件,开机后懒加载进 PSRAM,无卡时相关字段显示 ---。ICAO24 -> registration, ICAO type code, model name, and Doc 8643 descriptor; the current snapshot is about 574k records / 8.21 MB, shipped on the SD card ( /sdcard/aero/pk_actdb.bin) rather than embedded in the firmware, and lazily loaded into PSRAM after boot; without a card those fields render as ---. | datafiles/data/pk_actdb.bin(见 datafiles/README.md), firmware/main/aircraft_db.c, firmware/main/aircraft_db_reader.c, firmware/main/aircraft_db.h | firmware/scripts/gen_aircraft_db.py |
| 航司代码表 | Airline code table | ADS-B 呼号前三位 ICAO 航司代码 -> IATA 代码和运营人名称,用于把 CSN1234 等显示为更常见的航班号形式。ADS-B callsign ICAO prefix -> IATA code and operator name, used to render callsigns such as CSN1234 in a more familiar form. | firmware/main/airline_codes.c, firmware/main/airline_codes.h | firmware/scripts/gen_airline_codes.py --update-source |
| ICAO24 国家地址段 | ICAO24 country ranges | ICAO24 地址段 -> ISO 3166-1 alpha-2 国家/地区代码和名称,用于 ADS-B LIST 的 CT 列和详情面板。 ICAO24 address range -> ISO 3166-1 alpha-2 country/region code and name for the ADS-B LIST CT column and detail pane. | firmware/main/icao_country.c, firmware/main/icao_country.h | firmware/scripts/gen_icao_country.py |
维护流程详见 / Maintenance workflow: docs/database_maintenance.md / docs/database_maintenance-zh_CN.md。
| 我想做什么 | What I want | English | 中文 |
|---|---|---|---|
| 从零安装、编译、烧录 | Set up, build, and flash from scratch | docs/BUILD.md | docs/BUILD-zh_CN.md |
| 用网页更新 ESP32-P4 固件 | Update ESP32-P4 firmware from browser | updater.pilotkit.app | updater.pilotkit.app |
| 发布维护者固件包 | Publish a maintainer firmware release | docs/firmware_update.md | docs/firmware_update-zh_CN.md |
| 更新扩展板 RP2040 固件(Release 附 UF2) | Update the RP2040 expansion-board firmware (UF2 shipped with releases) | docs/firmware_update.md | docs/firmware_update-zh_CN.md |
| 看运行时任务和数据流 | Understand runtime tasks and data flow | docs/architecture.md | docs/architecture-zh_CN.md |
| 调整 sdkconfig | Tune sdkconfig options | docs/configuration.md | docs/configuration-zh_CN.md |
| 集成移动端 BLE | Integrate a mobile BLE client | docs/ble_protocol.md | docs/ble_protocol-zh_CN.md |
| 维护航空识别数据库 | Maintain the aviation identity databases | docs/database_maintenance.md | docs/database_maintenance-zh_CN.md |
| 使用 4.3 寸触摸 UI 和 PFD | Use the 4.3-inch touch UI and PFD | docs/user_guide.md | docs/user_guide-zh_CN.md |
| 接 IMU、GPS、BMP388 或 J3 扩展(v1/v2 的 RTL-SDR 路径已退役) | Wire IMU, GPS, BMP388, or J3 expansion (v1/v2 RTL-SDR path retired) | docs/hardware/board_pinout.md | docs/hardware/board_pinout-zh_CN.md |
| 装配 / 复刻 V4 扩展板 | Assemble or replicate the V4 expansion board | hardware/expansion-board-v4/README.md | 同左(各文档附 -zh_CN.md 中文版)/ same (each doc has a -zh_CN.md counterpart) |
| 手工贴片时对着屏幕走 | Walk through hand placement on screen | web/assembly/ | 中文界面;本地 python3 -m http.server 打开,见该目录 README |
| 首次烧 ESP32-C6 slave 固件 | Flash ESP32-C6 slave firmware once | docs/hardware/c6_slave_firmware.md | docs/hardware/c6_slave_firmware-zh_CN.md |
| 浏览全部文档语言覆盖 | Browse all docs and language coverage | docs/README.md | docs/README-zh_CN.md |
最短上手路径 / Minimal path:
# 1. 安装 ESP-IDF v6.0.1 / Install ESP-IDF v6.0.1
curl -L https://dl.espressif.com/dl/eim/eim-installer.sh | bash

# 2. 拉代码 / Clone the repository
git clone --recursive https://github.com/naizhao/Pilot-Kit-Box-ESP32-P4.git
cd Pilot-Kit-Box-ESP32-P4/firmware

# 3. 激活 IDF 并构建 / Activate IDF and build
source ~/.espressif/tools/activate_idf_v6.0.1.sh
./build.sh set-target esp32p4

# 3b. 选扩展板板系(默认 v4;v3 板必须改。小版本只是修订,看板号第一位)
#     Select the expansion board family (default v4; switch it for a v3 board)
#     ./build.sh menuconfig  ->  Pilot Kit Box  ->  Expansion board profile
./build.sh build

# 4. 烧录并监视 / Flash and monitor
./build.sh -p /dev/cu.usbmodem* flash monitor
⚠️ 板系默认是 v4。 手上是 v3 板(V3.x)就必须在
menuconfig里改过来——两个板系的传感器贴片角度不同,选错了 PFD 照样有姿态,只是横滚整体偏 90°,桌上看不出来。板号小版本只是修订,看第一位即可。切换与确认步骤见docs/configuration.md第 1 节。 The board profile defaults to the v4 family. Switch it for a v3 board: the sensor mounting angles differ, and the wrong profile still renders a live attitude that is simply rolled by 90 degrees.
新板如果要启用 BLE,必须先给板载 ESP32-C6 烧一次 hosted slave 固件。If BLE is needed on a fresh board, flash the on-board ESP32-C6 hosted slave firmware once first. See
docs/BUILD.mdsection 3.
当前 GT911 固件只使用第一个触点,未启用五点手势。
BLE Device Information Service 尚未暴露固件版本;版本目前显示在 boot splash 和 ABOUT 页。
GDL90 Heartbeat 的 utc_ok 位尚未随 GPS/BLE 校时状态更新;客户端应以时间戳值为准。
Wi-Fi 分发、BLE 配置写特征和 OTA A/B 分区仍是后续工作。
GDL90 Ownship Report 需要有效 GPS fix 或编译期配置的本机 ICAO;无有效位置时不会发送可信本机位置。
GPIO50 PPS 已由固件消费:PPS GPIO 中断(1 Hz 快照)与时间锁定状态已实现,
系统校时也统一走 pk_clock(BLE 粗校 + GPS 精校);尚未接入的是「PPS/NMEA
新鲜度实时参与时钟可信度判定」——pk_clock_is_synced() 仍是校过一次即锁定。
当前触摸 UI 没有旧 TARE 十秒工厂重置/DCD 擦除入口。
The current GT911 firmware consumes only the first contact; five-point gestures are not enabled.
BLE Device Information Service does not yet expose firmware version; the version is shown on the boot splash and ABOUT page.
The GDL90 Heartbeat utc_ok bit does not yet follow GPS/BLE clock discipline; clients should use the timestamp value.
Wi-Fi distribution, BLE configuration-write characteristics, and OTA A/B partitions remain future work.
GDL90 Ownship Report requires a valid GPS fix or a compile-time own-ship ICAO; the firmware does not advertise a trustworthy own position without one.
The GPIO50 PPS input is now consumed by firmware: a PPS GPIO interrupt (1 Hz snapshot) and the time-lock status are in place, and system clock discipline goes through pk_clock (BLE coarse + GPS fine sync). What remains a follow-up is feeding live PPS/NMEA freshness into the clock-trust decision — pk_clock_is_synced() still latches after the first successful sync.
The touch UI has no equivalent of the former ten-second TARE factory-reset/DCD-wipe gesture.
kvhnuke/esp32-rtl-sdr — librtlsdr API 封装参考(历史:该路径已于 2026-09 移除)/ librtlsdr API wrapper reference (historical: that path was removed in 2026-09)XTR1984/xtrsdr — ESP32 USB DMA 分包与吞吐调优参考(历史:该路径已于 2026-09 移除)/ ESP32 USB DMA transfer tuning reference (historical: that path was removed in 2026-09)MIT License — 完整条款见 LICENSE。
Full terms in LICENSE.
硬件设计(hardware/)同样以 MIT 发布。其中的 KiCad 工程内嵌了 KiCad 官方库的
封装,那些库是 CC-BY-SA 4.0,但其例外条款明确允许由此制造的板子不受限制使用,
不会传染到你的硬件。
The hardware designs under hardware/ are released under the same MIT terms.
The KiCad projects embed footprints from the KiCad standard libraries, which are
CC-BY-SA 4.0 with an exception explicitly permitting unrestricted use of boards
produced from them.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 28 | 100nF | C_0603_1608Metric | C10, C11, C12, C13, C14, C16, C17, C22, C23, C24, C25, C26, C27, C49, C61, C100 +12 |
| 19 | 10k | R_0603_1608Metric | R1, R5, R17, R18, R26, R27, R32, R34, R35, R44, R45, R46, R47, R51, R55, R56 +3 |
| 13 | 1uF | C_0603_1608Metric | C2, C3, C4, C6, C28, C29, C67, C78, C79, C84, C97, C101, C102 |
| 11 | 100pF | C_0402_1005Metric | C21, C30, C36, C38, C39, C45, C53, C54, C57, C58, C59 |
| 8 | 10uF | C_0805_2012Metric | C1, C18, C73, C74, C75, C91, C92, C93 |
| 7 | 0R | R_0603_1608Metric | R21, R22, R23, R37, R48, R49, R60 |
| 6 | 1k | R_0603_1608Metric | R4, R31, R43, R64, R65, R67 |
| 5 | 100pF C0G | C_0402_1005Metric | C31, C32, C33, C34, C35 |
| 5 | TPESD8L3.3 0.3pFtyp 0.5pFmax | D_0402_1005Metric | D2, D3, D4, D5, D6 |
| 4 | 6V/200mA | Fuse_0805_2012Metric | F2, F3, F4, F5 |
| 4 | AO3401A | SOT-23 | Q2, Q3, Q4, Q5 |
| 4 | MountingHole_2.7mm_M2.5 | MountingHole_2.7mm_M2.5 | H1, H2, H3, H4 |
| 3 | 100nF | C_0402_1005Metric | C37, C52, C99 |
| 3 | 100nH | L_0402_1005Metric | L8, L14, L18 |
| 3 | 100pF | C_0603_1608Metric | C55, C56, C88 |
| 3 | 10k | R_0402_1005Metric | R52, R53, R61 |
| 3 | 18pF | C_0603_1608Metric | C68, C69, C89 |
| 3 | TPS7A2033PDBVR | SOT-23-5 | U2, U3, U23 |
| 2 | 15pF C0G | C_0603_1608Metric | C19, C20 |
| 2 | 1N4148WS | D_SOD-323 | D7, D10 |
| 2 | 1uF | C_0402_1005Metric | C5, C48 |
| 2 | 22uF | C_0805_2012Metric | C60, C66 |
| 2 | 27R | R_0603_1608Metric | R9, R10 |
| 2 | 3.6pF | C_0402_1005Metric | C40, C44 |
| 2 | 33nH | L_0402_1005Metric | L2, L15 |
| 2 | 4.7k | R_0603_1608Metric | R2, R3 |
| 2 | 5.1k DNP(带电源版) | R_0603_1608Metric | R7, R8 |
| 2 | 6.8nH | L_0402_1005Metric | L11, L12 |
| 2 | 7.5nH | L_0402_1005Metric | L9, L13 |
| 2 | LED 红/黄(Vf2.0-2.2) | LED_0805_2012Metric | D8, D9 |
| 2 | TA0970A | TA0970A_SMD3838-6 | FL1, FL2 |
| 2 | XA17-G4K | SOT-363_SC-70-6 | U16, U17 |
| 1 | 0R DNP(TCXO探测隔离) | R_0603_1608Metric | R66 |
| 1 | 0R DNP(旁路外接) | R_0402_1005Metric | R24 |
| 1 | 0R DNP(旁路板载) | R_0402_1005Metric | R25 |
| 1 | 0R 串 | L_0603_1608Metric | ZS1 |
| 1 | 100k | R_0603_1608Metric | R33 |
| 1 | 10R | R_0402_1005Metric | R54 |
| 1 | 10nF C0G | C_0603_1608Metric | C87 |
| 1 | 10uF | C_1206_3216Metric | C72 |
| 1 | 12MHz CL=10pF ABM8-272-T3 | Crystal_SMD_3225-4Pin_3.2x2.5mm | Y1 |
| 1 | 150k | R_0603_1608Metric | R42 |
| 1 | 180R | R_0603_1608Metric | R38 |
| 1 | 18nH 0402CS-18NXGRW | L_0402_1005Metric | L1 |
| 1 | 1k DNP | R_0402_1005Metric | R30 |
| 1 | 1k DNP | R_0603_1608Metric | R36 |
| 1 | 1nF | C_0603_1608Metric | C51 |
| 1 | 1uF 25V | C_0603_1608Metric | C80 |
| 1 | 1uH | L_Bourns-SRN4018 | L16 |
| 1 | 2.2k | R_0603_1608Metric | R63 |
| 1 | 2.7pF | C_0402_1005Metric | C41 |
| 1 | 200pF | C_0603_1608Metric | C47 |
| 1 | 22uF | C_1206_3216Metric | C76 |
| 1 | 22uF 16V X5R | C_1206_3216Metric | C77 |
| 1 | 26MHz TCXO <=2.5ppm | Crystal_SMD_2520-4Pin_2.5x2.0mm | Y4 |
| 1 | 27nH | L_0402_1005Metric | L10 |
| 1 | 3.32k | R_0402_1005Metric | R11 |
| 1 | 30k | R_0603_1608Metric | R50 |
| 1 | 31.6k | R_0603_1608Metric | R40 |
| 1 | 32.768kHz FC-135 | Crystal_SMD_3215-2Pin_3.2x1.5mm | Y3 |
| 1 | 33R | R_0603_1608Metric | R57 |
| 1 | 3pF | C_0603_1608Metric | C46 |
| 1 | 3pF | C_0402_1005Metric | C43 |
| 1 | 4.7uF | C_0603_1608Metric | C15 |
| 1 | 4.7uF(带电源版) | C_0603_1608Metric | C71 |
| 1 | 4.7uH XEL4030-472MEC | L_Coilcraft_XxL4030 | L17 |
| 1 | 470k | R_0603_1608Metric | R41 |
| 1 | 470pF C0G | C_0402_1005Metric | C81 |
| 1 | 47nF | C_0603_1608Metric | C70 |
| 1 | 48MHz ABM8W-7pF | Crystal_SMD_3225-4Pin_3.2x2.5mm | Y2 |
| 1 | 5.62k | R_0603_1608Metric | R39 |
| 1 | 52.3R | R_0402_1005Metric | R19 |
| 1 | 6.2pF | C_0402_1005Metric | C42 |
| 1 | 6.8uH | L_0805_2012Metric | L7 |
| 1 | AD8313ARMZ | MSOP-8_3x3mm_P0.65mm | U14 |
| 1 | ATGM336H-6N-74 | ATGM336H_LCC-18 | U7 |
| 1 | BGA2817 | SOT-363_SC-70-6 | U12 |
| 1 | BK4819QN32SC | QFN-32-1EP_4x4mm_P0.4mm_EP2.65x2.65mm | U21 |
| 1 | BMP388 | BMP388_LGA-10 | U5 |
| 1 | BNO085 | BNO085_LGA-28 | U4 |
The 208 most common of 235 parts.


YeetTheAnson/RFly-One
Offline general aviation proximity awareness system with support for ADS-B, FLARM AIR V7, OGNTP and FANET+


It measures 100 × 62 mm and has 6 copper layers, 1.6 mm thick.
235 parts, built around the XA17-G4K, AD8313ARMZ, ATGM336H-6N-74 and BGA2817. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the naizhao/Pilot-Kit-Box-ESP32-P4 repository on GitHub, at the commit this page was made from: the board is hardware/expansion-board-v4/kicad/expansion-board-v4.kicad_pcb and its schematic hardware/expansion-board-v3/kicad/expansion-board-v3.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).